Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
Autonomous Agent Path Finding
Search
Sponsored
·
Your Podcast. Everywhere. Effortlessly.
Share. Educate. Inspire. Entertain. You do you. We'll handle the rest.
→
hankeceli
January 19, 2021
26
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
Autonomous Agent Path Finding
hankeceli
January 19, 2021
More Decks by hankeceli
See All by hankeceli
Introduction to Data Structures
hankeceli
0
120
Featured
See All Featured
Lightning Talk: Beautiful Slides for Beginners
inesmontani
PRO
2
730
Everyday Curiosity
cassininazir
0
350
How to make the Groovebox
asonas
2
2.5k
Breaking role norms: Why Content Design is so much more than writing copy - Taylor Woolridge
uxyall
1
450
Paper Plane (Part 1)
katiecoart
PRO
2
12k
Agile Actions for Facilitating Distributed Teams - ADO2019
mkilby
0
310
Prompt Engineering for Job Search
mfonobong
0
520
Statistics for Hackers
jakevdp
799
230k
Amusing Abliteration
ianozsvald
1
350
Optimizing for Happiness
mojombo
378
71k
Building an army of robots
kneath
307
47k
The Psychology of Web Performance [Beyond Tellerrand 2023]
tammyeverts
49
3.6k
Transcript
Autonomous Agent Path Finding
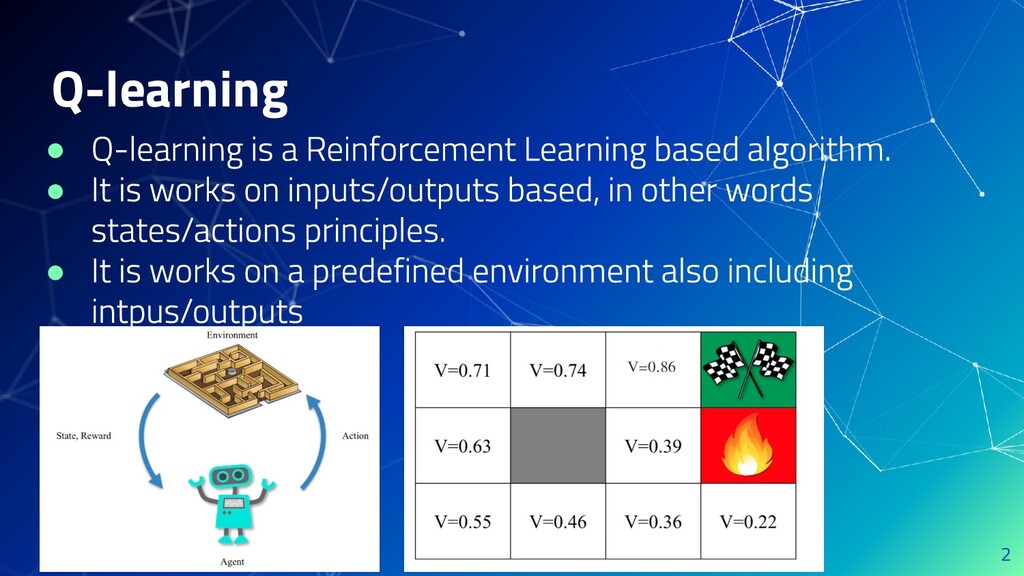
Q-learning • • •
Deep Q-learning
Building Steps ▰ ▰ ▰ ▰ ▰ ▰
Modeling the environment. • • • •
Goal • • • •
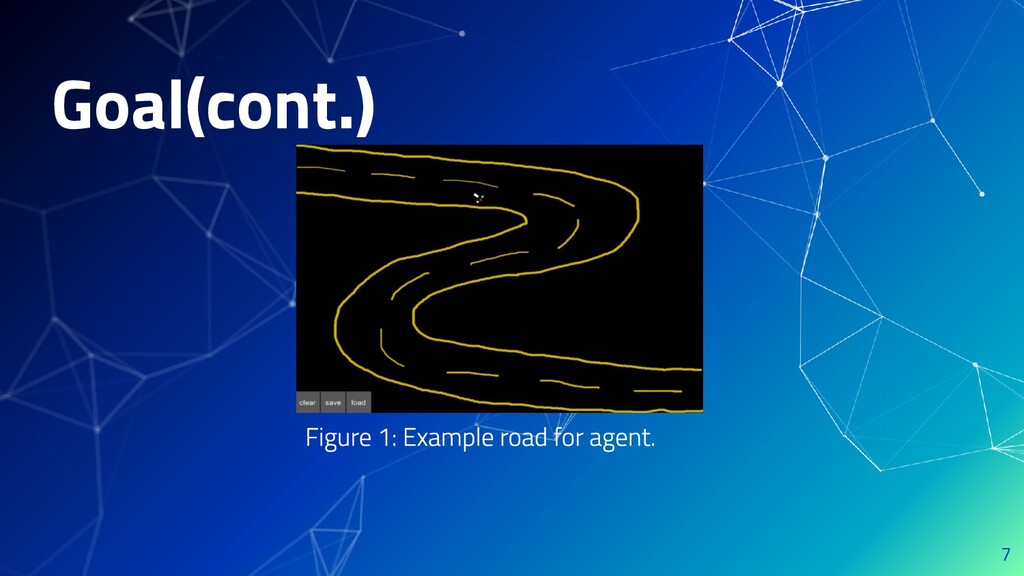
Goal(cont.)
Setting parameters angle: rotation: pos=(self.car.x, self.car.y): velocity=(velocity_x, velocity_y): sensor1:(sensor1_x, sensor1_y):
sensor2:(sensor2_x, sensor2_y): sensor3:(sensor3_x, sensor3_y): signal1: signal2: signal3:
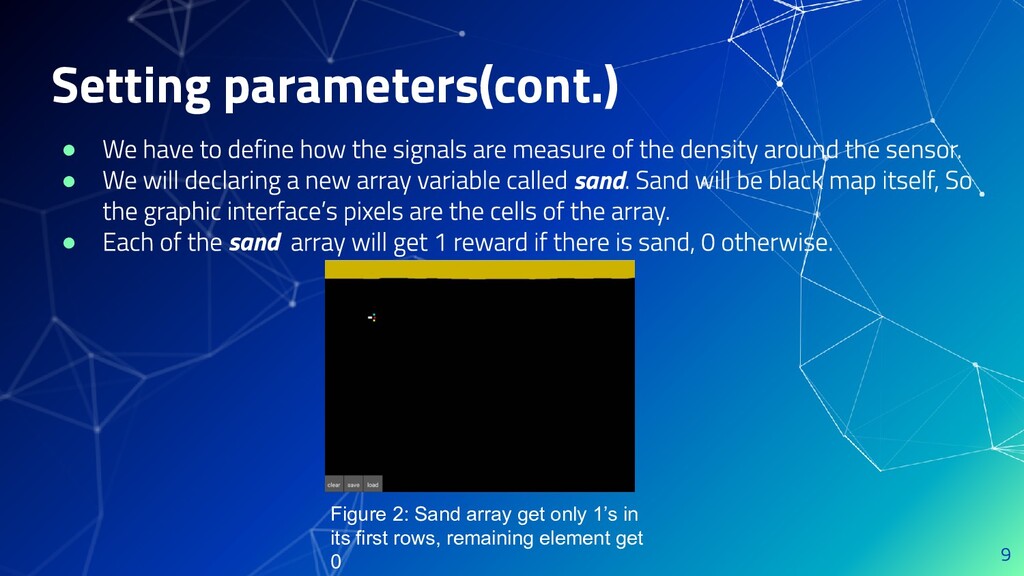
• • sand • sand Setting parameters(cont.) Figure 2: Sand
array get only 1’s in its first rows, remaining element get 0
Setting parameters(cont.) goal_x: goal_y: xx=(goal_x-self.car.x): yy=(goal_y-self.car.y): orientation:
• • orientation The input states
• • sensors • • The input states(cont.)
• • • • The output actions
• • The output actions(cont.)
• • • • The rewards
• • • The rewards(cont.)
REFERENCES ▰ ▰
THANKS! Any questions? ▰ ▰

 Your Podcast. Everywhere. Effortlessly.


 hankeceli
 inesmontani
 cassininazir
 asonas
 uxyall
 katiecoart
 mkilby
 mfonobong
 jakevdp
 ianozsvald
 mojombo
 kneath
 tammyeverts