Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
Data Augmentation Based on Cross-Modal Back Tra...
Search
Sponsored
·
SiteGround - Reliable hosting with speed, security, and support you can count on.
→
Semantic Machine Intelligence Lab., Keio Univ.
PRO
September 04, 2021
Technology
1k
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
Data Augmentation Based on Cross-Modal Back Translation for Multimodal Language Understanding for Fetching Instruction
Semantic Machine Intelligence Lab., Keio Univ.
PRO
September 04, 2021
Transcript
18 slides
慶應義塾大学 飯田紡,九曜克之,石川慎太朗,杉浦孔明 物体指示理解タスクにおける クロスモーダル言語生成に基づくデータ拡張
背景︓⽣活⽀援ロボットに⾃然⾔語で命令できれば便利 2 ⽣活⽀援ロボット • 障がいを持つ⼈々を物理的に⽀援可能 • 在宅介護者不⾜を克服 スムーズな対話に基づいて ⽣活⽀援タスクを実⾏できれば便利 例)「机の上の飲み物を取ってきて」
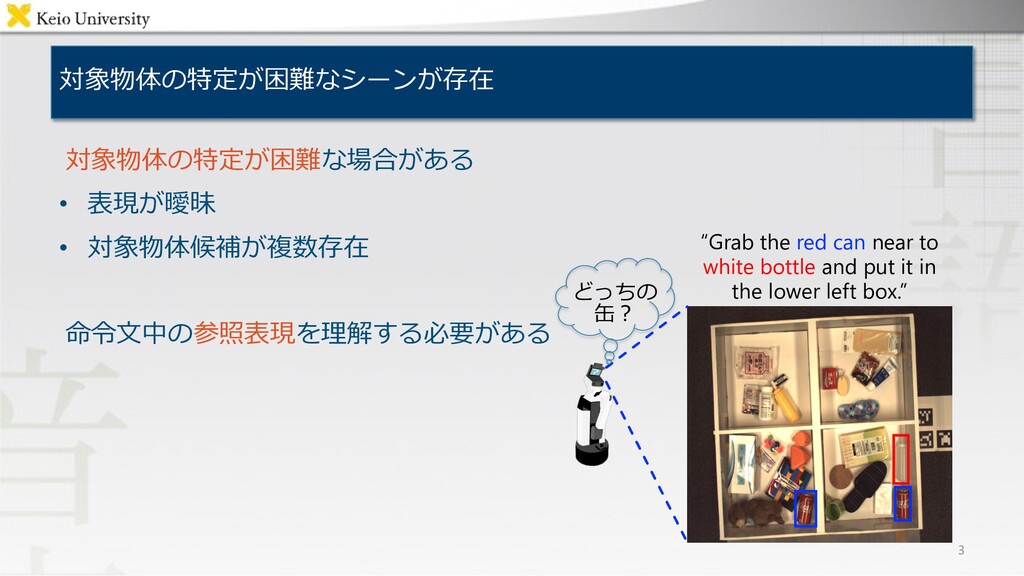
対象物体の特定が困難なシーンが存在 3 対象物体の特定が困難な場合がある • 表現が曖昧 • 対象物体候補が複数存在 命令⽂中の参照表現を理解する必要がある “Grab the
red can near to white bottle and put it in the lower left box.” どっちの ⽸︖
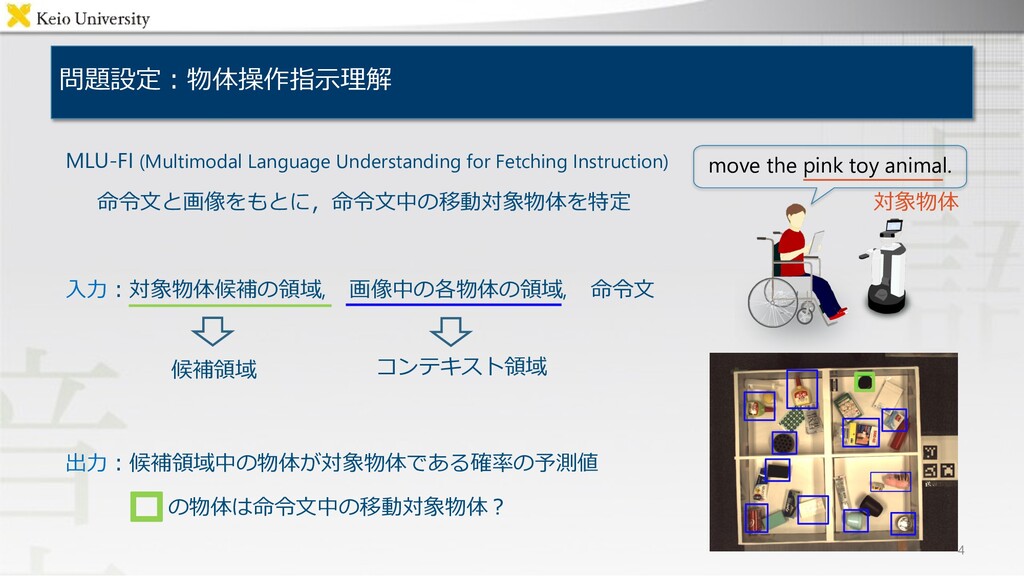
問題設定︓物体操作指⽰理解 4 MLU-FI (Multimodal Language Understanding for Fetching Instruction) 命令⽂と画像をもとに,命令⽂中の移動対象物体を特定
⼊⼒︓対象物体候補の領域, 画像中の各物体の領域, 命令⽂ 出⼒︓候補領域中の物体が対象物体である確率の予測値 の物体は命令⽂中の移動対象物体︖ コンテキスト領域 候補領域 move the pink toy animal. 対象物体
関連研究︓物体指⽰理解における既存⼿法はサンプル効率が悪い 6 • [Hatori+ ICRA18] – 物体のピッキングタスクにおける指⽰理解⼿法 • MTCM, MTCM-AB
[Magassouba+ ICRA19, 20] – 命令⽂と全体画像から対象物体を特定 • Target-dependent UNITER[Ishikawa+ RAL & IROS21] – 全体画像の代わりに物体領域を⼊⼒し物体間の関係を学習 1⽂につき 正例: 1物体, 負例: 正例以外の物体全て ⼤量の負例サンプルを使⽤していなかった “Grab the red can near to white bottle and put it in the lower left box.”
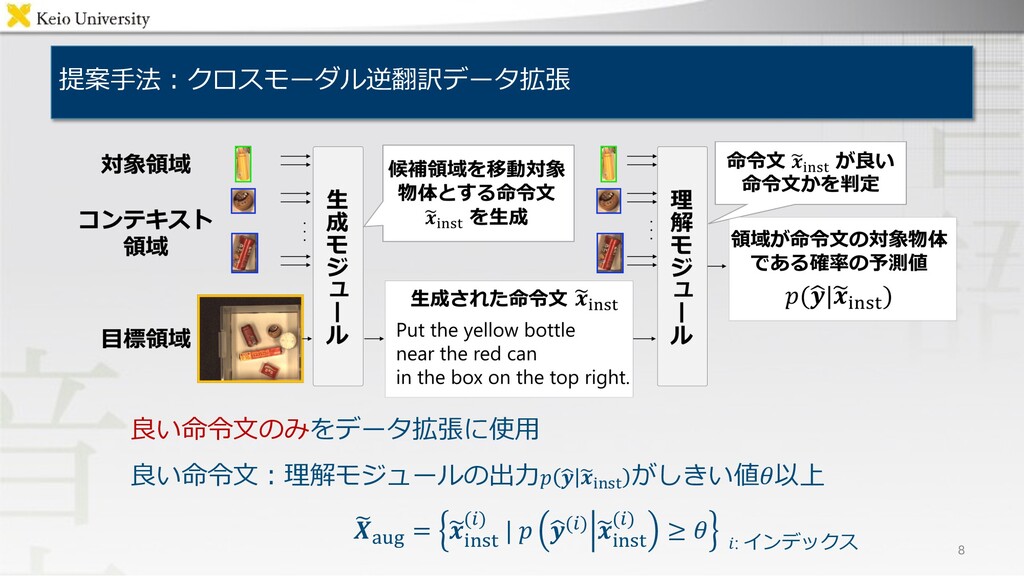
提案⼿法︓クロスモーダル逆翻訳データ拡張 8 良い命令⽂のみをデータ拡張に使⽤ 良い命令⽂︓理解モジュールの出⼒! " # $ %!"#$ がしきい値!以上 "
#!"# = % & $%&' ()) | ( ) *()) % & $%&' ()) ≥ ! !: インデックス
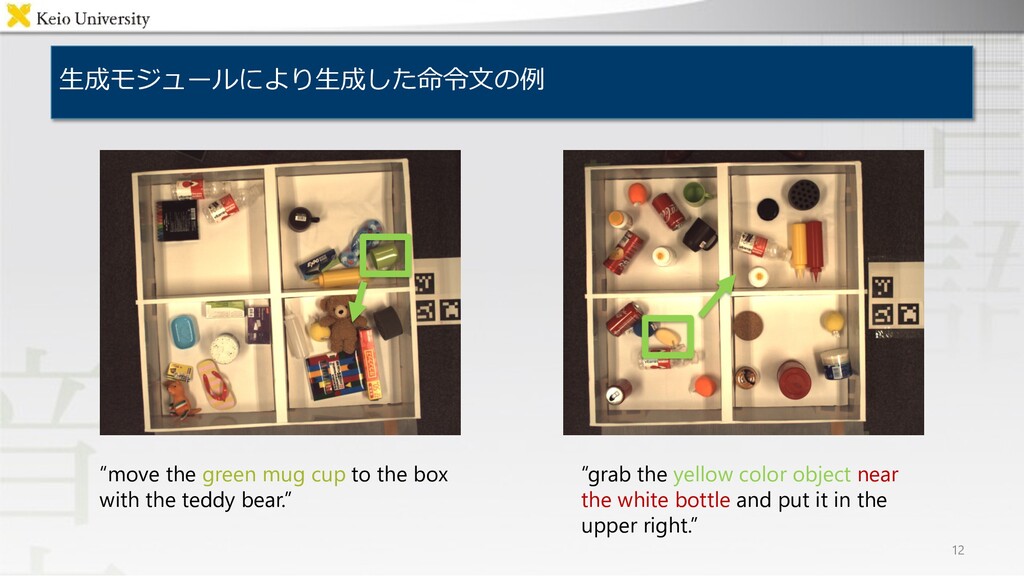
⽣成モジュールにより⽣成した命令⽂の例 12 “grab the yellow color object near the white
bottle and put it in the upper right.” “move the green mug cup to the box with the teddy bear.”
提案⼿法における⽣成モジュール 13 Case Relation Transformer[Kambara+ RAL & IROS21] ⼊⼒︓対象領域 コンテキスト領域(対象以外の物体領域)
⽬標領域 出⼒︓対象物体を⽬標領域に移動させる命令⽂ CRB (Case Relation Block)と Transformerにより • 物体間の位置関係をモデル化 • 参照表現を含む⽂を⽣成可能
Target-dependent UNITER[Ishikawa+ RAL & IROS21] ⼊⼒︓候補領域 コンテキスト領域 命令⽂ 出⼒︓候補領域が命令⽂の対象物体である確率の予測値(() *)
提案⼿法における理解モジュール 14 物体間の関係をモデル化 命令⽂中の参照表現理解
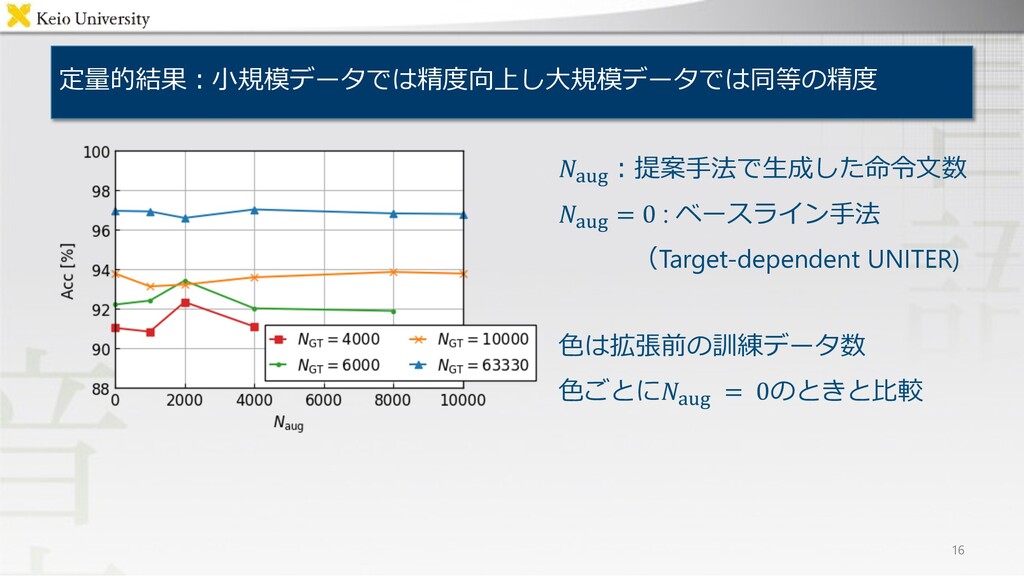
実験設定︓データ数ごとのMLU-FIタスクにおける提案⼿法の性能評価 15 PFN-PIC データセット[Hatori+ 18] 画像と画像中の物体に関する命令⽂から構成 4つの箱に物体を無作為に配置 訓練データ数.+,を変化させて データ拡張の効果を確認 .+,
= 4000, 6000, 10000, 63330 (全⽂) が命令⽂中の対象物体かどうかの分類精度により性能評価 “Move the yellow container to the top left box.”
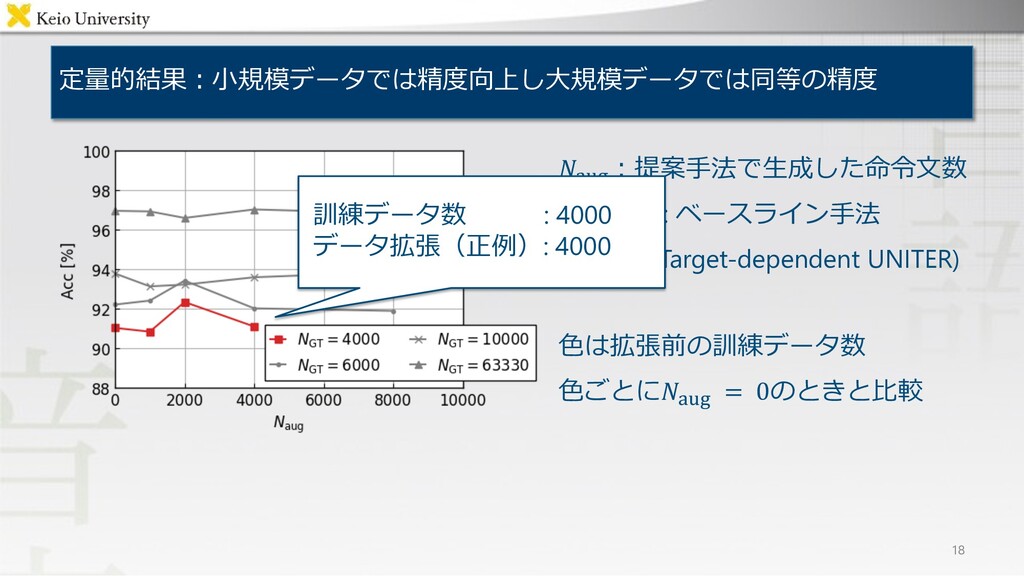
.!"#︓提案⼿法で⽣成した命令⽂数 .!"# = 0 : ベースライン⼿法 (Target-dependent UNITER) ⾊は拡張前の訓練データ数 ⾊ごとに.!"#
= 0のときと⽐較 定量的結果︓⼩規模データでは精度向上し⼤規模データでは同等の精度 16
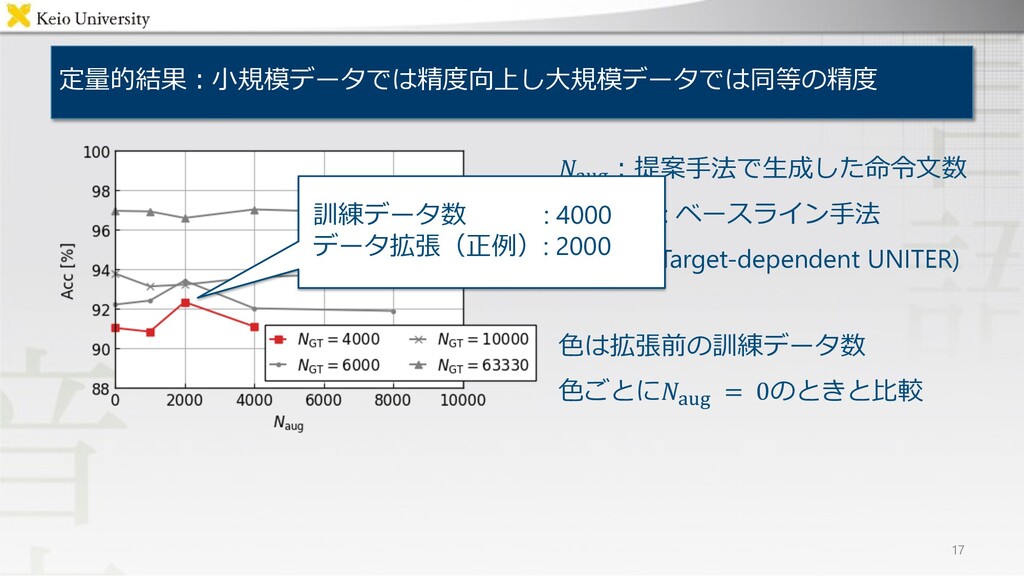
定量的結果︓⼩規模データでは精度向上し⼤規模データでは同等の精度 17 .!"#︓提案⼿法で⽣成した命令⽂数 .!"# = 0 : ベースライン⼿法 (Target-dependent UNITER)
⾊は拡張前の訓練データ数 ⾊ごとに.!"# = 0のときと⽐較 訓練データ数 : 4000 データ拡張(正例): 2000
定量的結果︓⼩規模データでは精度向上し⼤規模データでは同等の精度 18 .!"#︓提案⼿法で⽣成した命令⽂数 .!"# = 0 : ベースライン⼿法 (Target-dependent UNITER)
⾊は拡張前の訓練データ数 ⾊ごとに.!"# = 0のときと⽐較 訓練データ数 : 4000 データ拡張(正例): 4000
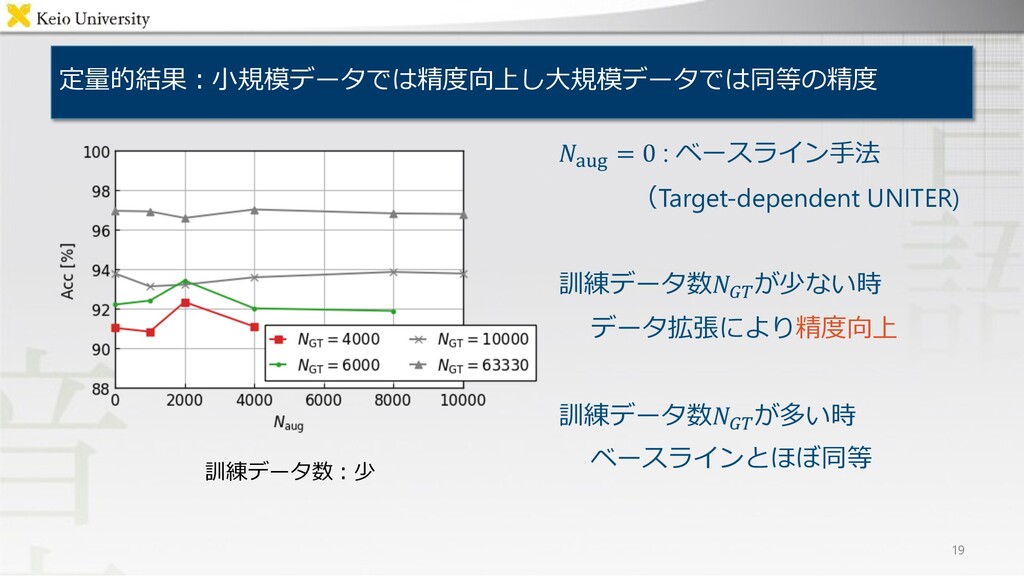
.!"# = 0 : ベースライン⼿法 (Target-dependent UNITER) 訓練データ数.-.が少ない時 データ拡張により精度向上 訓練データ数.-.が多い時
ベースラインとほぼ同等 定量的結果︓⼩規模データでは精度向上し⼤規模データでは同等の精度 19 訓練データ数︓少
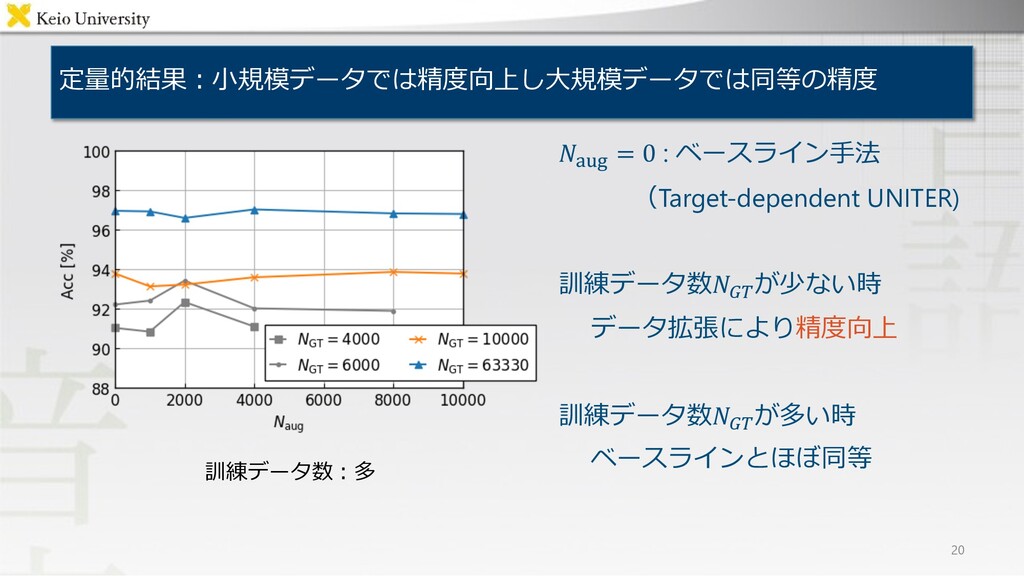
.!"# = 0 : ベースライン⼿法 (Target-dependent UNITER) 訓練データ数.-.が少ない時 データ拡張により精度向上 訓練データ数.-.が多い時
ベースラインとほぼ同等 定量的結果︓⼩規模データでは精度向上し⼤規模データでは同等の精度 20 訓練データ数︓多
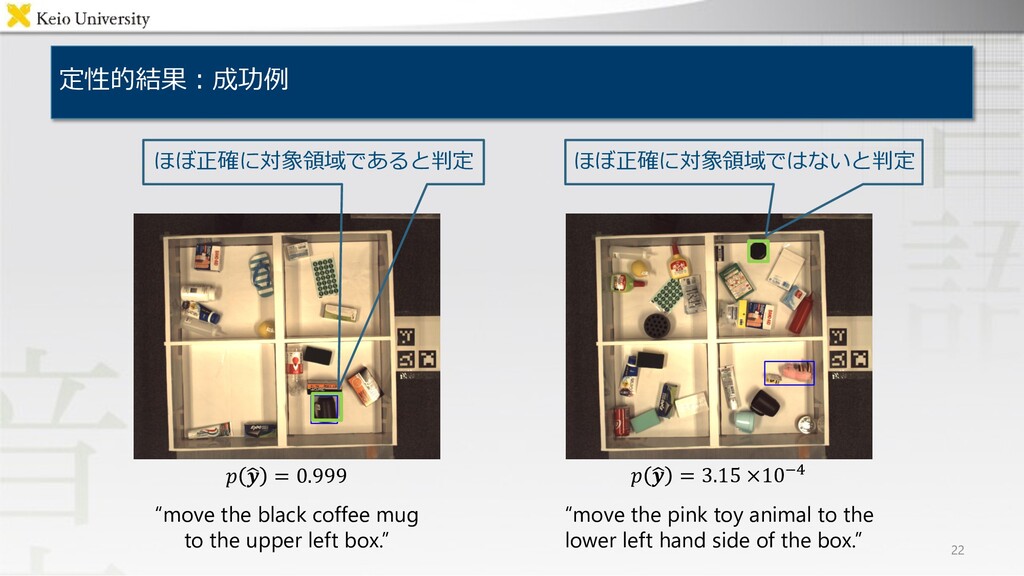
定性的結果︓成功例 22 “move the black coffee mug to the upper
left box.” ! " # = 0.999 ! " # = 3.15 ×10%& “move the pink toy animal to the lower left hand side of the box.” ほぼ正確に対象領域であると判定 ほぼ正確に対象領域ではないと判定
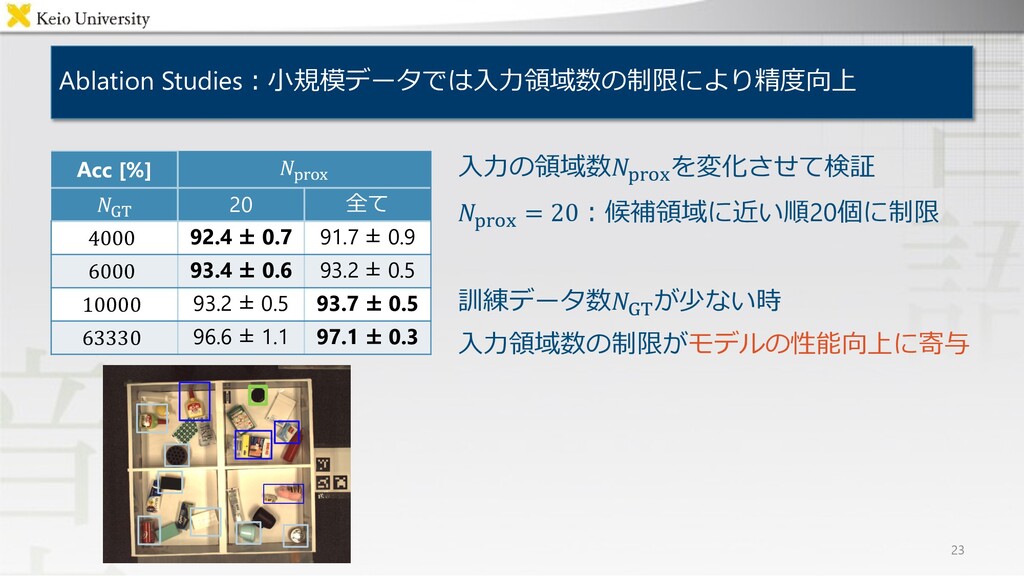
⼊⼒の領域数./012を変化させて検証 ./012 = 20︓候補領域に近い順20個に制限 訓練データ数.+,が少ない時 ⼊⼒領域数の制限がモデルの性能向上に寄与 Ablation Studies︓⼩規模データでは⼊⼒領域数の制限により精度向上 23 Acc
[%] .'()* .+, 20 全て 4000 92.4 ± 0.7 91.7 ± 0.9 6000 93.4 ± 0.6 93.2 ± 0.5 10000 93.2 ± 0.5 93.7 ± 0.5 63330 96.6 ± 1.1 97.1 ± 0.3
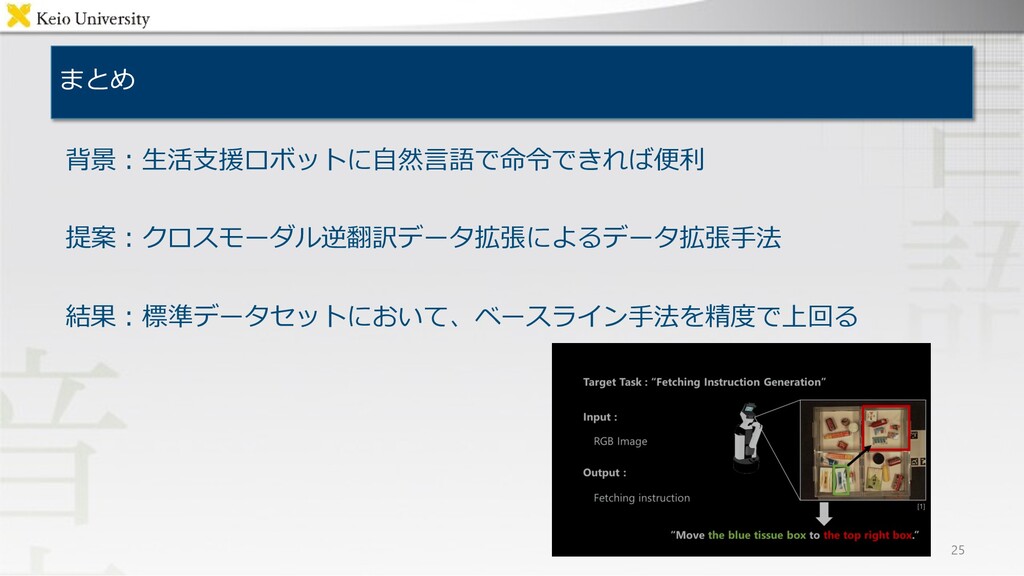
背景︓⽣活⽀援ロボットに⾃然⾔語で命令できれば便利 提案︓クロスモーダル逆翻訳データ拡張によるデータ拡張⼿法 結果︓標準データセットにおいて、ベースライン⼿法を精度で上回る まとめ 25
More Decks by Semantic Machine Intelligence Lab., Keio Univ.
See All by Semantic Machine Intelligence Lab., Keio Univ.
慶應義塾大学 AI実践05 論文執筆の仕組み化
keio_smilab
PRO
7
3.9k
[EMNLP26] RIGEL: Self-Distilled Score Adaptation for Image and Video Captioning Evaluation
keio_smilab
PRO
0
170
[RSJ26] Building a VLA Model Based on Self-Distilled Classification
keio_smilab
PRO
0
230
[RSJ26] AnoleVLA: Lightweight Vision-Language-Action Model with Deep State Space Models for Mobile Manipulation
keio_smilab
PRO
0
200
[RSJ26] NarrativeFlow: Flow-Based Vision-Language-Action Model Using Robot Velocity Fields
keio_smilab
PRO
0
270
[RSJ26] Flow as Flow: Modeling Robot Velocity Fields as Probability Velocity Fields
keio_smilab
PRO
1
300
[RSJ26] Hierarchy-Aware Multimodal Retrieval-Augmented Generation for Embodied Question Answering
keio_smilab
PRO
1
210
[MIRU26] Open-Vocabulary Intention-Guided Object Detection in Diverse Scenes
keio_smilab
PRO
0
260
[Journal club] Evo-1: Lightweight Vision-Language-Action Model with Preserved Semantic Alignment
keio_smilab
PRO
0
79
Other Decks in Technology
See All in Technology
並列度を下げたら速くなった — go build の重複コンパイルを実測で見る
tomoaki25
2
1.2k
bpf_arenaとstruct_opsを使うのが難しかった話
masu_mi
0
230
業務でAWSをあまり使っていない私が、AWSへのモチベを保つ方法
smt7174
0
190
アラートを見直していたら営業組織への理解にちょっとだけ繋がった話
z63d
1
190
Gifu WordPress Meetup #200 に向けて、私たちには何ができるだろうか?/ 2026-11-07 Gifu WordPress Meetup
torounit
0
290
Intro to Kiro (One agent, every surface) | Kiro: Zero to Hero 01
inariku
PRO
2
120
小さなエージェントから始めてみよう!実践コンテキストエンジニアリング
iwamot
PRO
0
120
速くなった開発の効果をどう推し量るのか
bulbulpaul
0
110
Kiro を使うコツ (頼み方、覚えさせ方、任せ方) | 目指せ Kiro マスター 09
inariku
PRO
3
150
Kiro アップデート 2026 年 11 月号 (11 月 8 日時点) | 目指せ Kiro マスター アップデート編
inariku
PRO
2
120
サボる子はいねぇがー!AgentCoreハーネスの脆弱性に学ぶ、エージェントの入力バリデーション
iwamot
PRO
5
330
【Oracle AI SPOTLIGHT ウェビナー】【特別開催:日本語で解説!】Oracle AI World 2026 最新情報フィードバック
oracle4engineer
PRO
1
210
Featured
See All Featured
Rebuilding a faster, lazier Slack
samanthasiow
85
9.8k
ReactJS: Keep Simple. Everything can be a component!
pedronauck
666
130k
Design of three-dimensional binary manipulators for pick-and-place task avoiding obstacles (IECON2024)
konakalab
0
660
Organizational Design Perspectives: An Ontology of Organizational Design Elements
kimpetersen
PRO
1
880
The Psychology of Web Performance [Beyond Tellerrand 2023]
tammyeverts
49
3.6k
How to Align SEO within the Product Triangle To Get Buy-In & Support - #RIMC
aleyda
2
1.9k
State of Search Keynote: SEO is Dead Long Live SEO
ryanjones
0
350
The SEO identity crisis: Don't let AI make you average
varn
0
630
DevOps and Value Stream Thinking: Enabling flow, efficiency and business value
helenjbeal
2
440
A Modern Web Designer's Workflow
chriscoyier
699
190k
XXLCSS - How to scale CSS and keep your sanity
sugarenia
250
1.3M
Building a A Zero-Code AI SEO Workflow
portentint
PRO
0
830