Share
Embed
IATBR2022_FatalitiesResponseModel
Presentation slides for the 16th International Conference on Travel Behavior Research (IATBR) at Santiago, Chile, entitled "A dynamic activity scheduling model for correcting fatalities’ non-response bias in tsunami evacuation."
SatokiMasuda
November 05, 2024
Transcript
36 slides
-
A dynamic activity scheduling model for correcting fatalities’ non-response bias
in tsunami evacuation Satoki Masuda, The University of Tokyo Takuya Iizuka, Hitachi Ltd Eiji Hato*, The University of Tokyo *Corresponding author 16th International Conference on Travel Behavior Research @ Santiago, Chile Thu. 15 Dec. 9:00-10:40, Room 207, Travel Behavior Applications II -
Table of contents 1. Introduction - Challenges for evacuation behavioral
models • Missing data • Transferability 2. Modeling - A dynamic activity scheduling model for evacuation 3. Estimation - Weighted RP/SP combined estimation 4. Numerical experiment 5. Empirical analysis 2 -
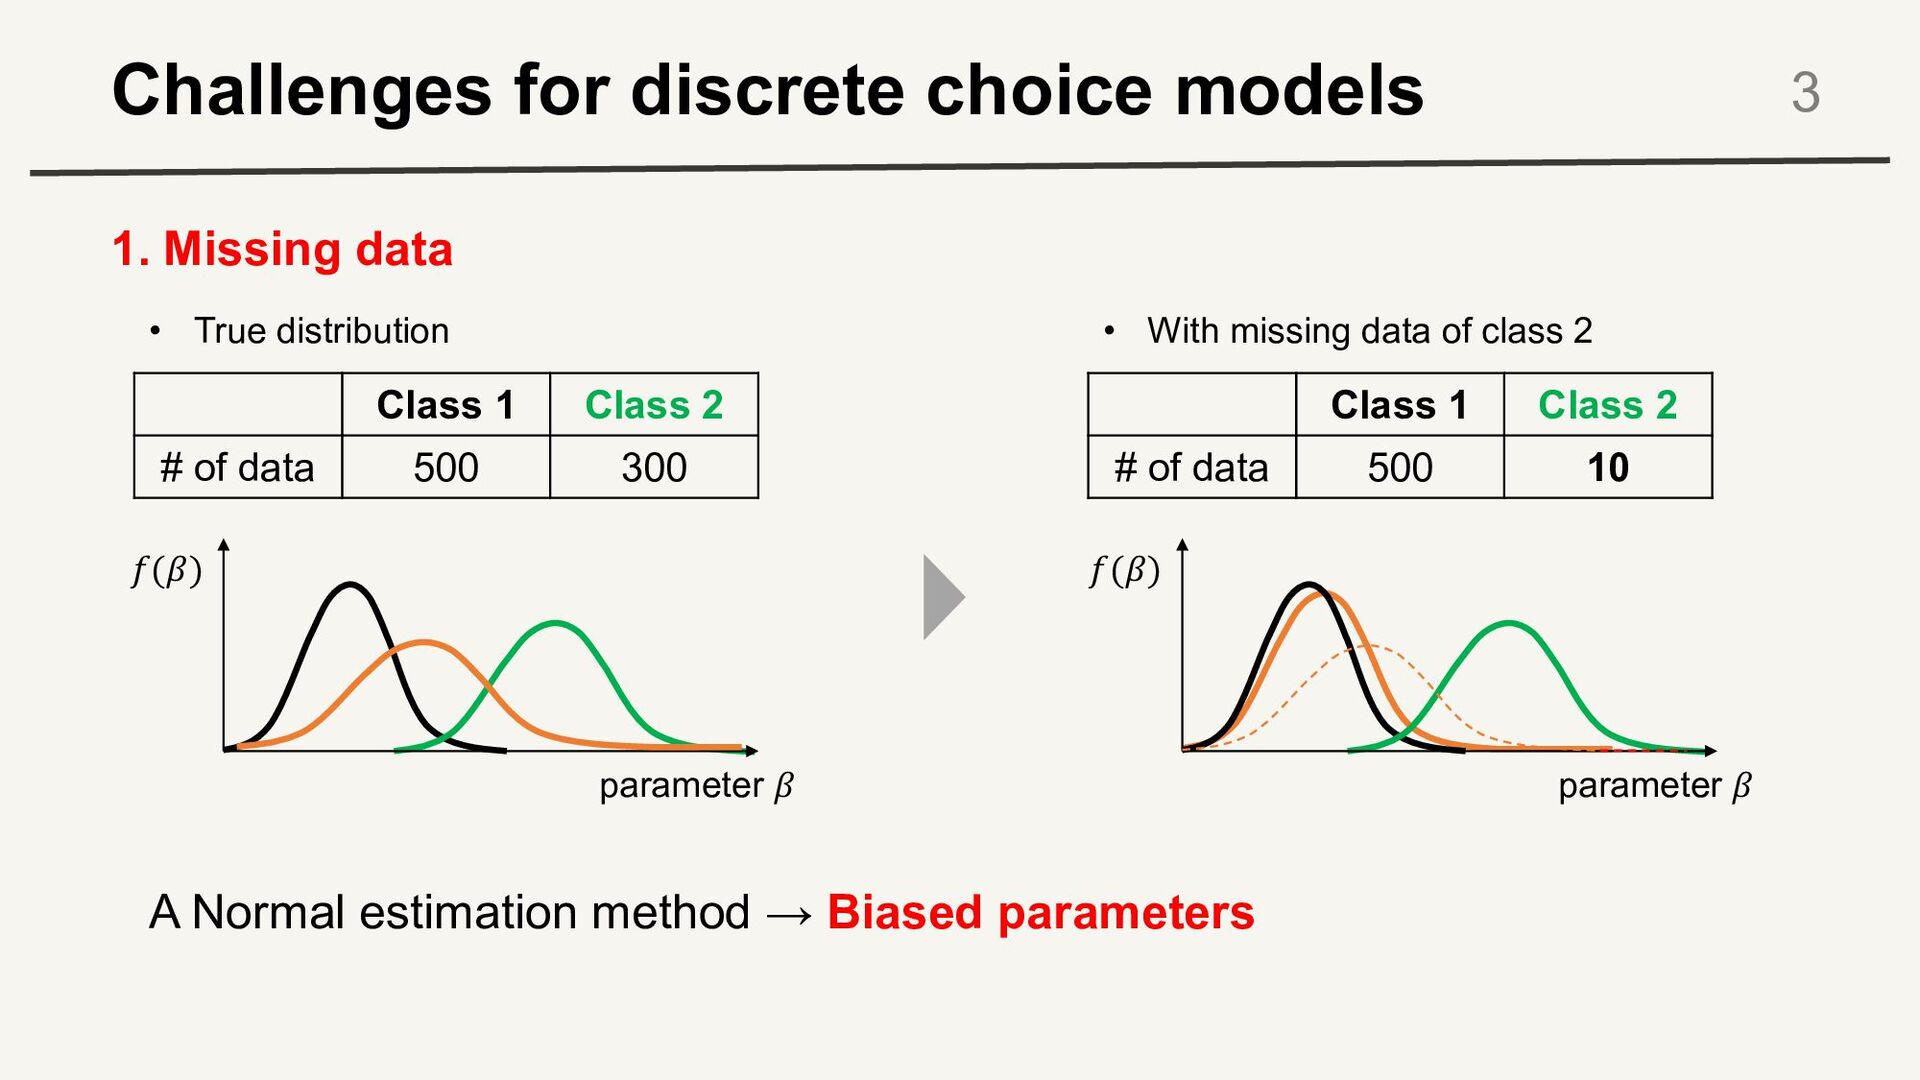
Challenges for discrete choice models 1. Missing data 3 Class
1 Class 2 # of data 500 300 Class 1 Class 2 # of data 500 10 A Normal estimation method → Biased parameters parameter ! "(!) parameter ! "(!) • True distribution • With missing data of class 2 -
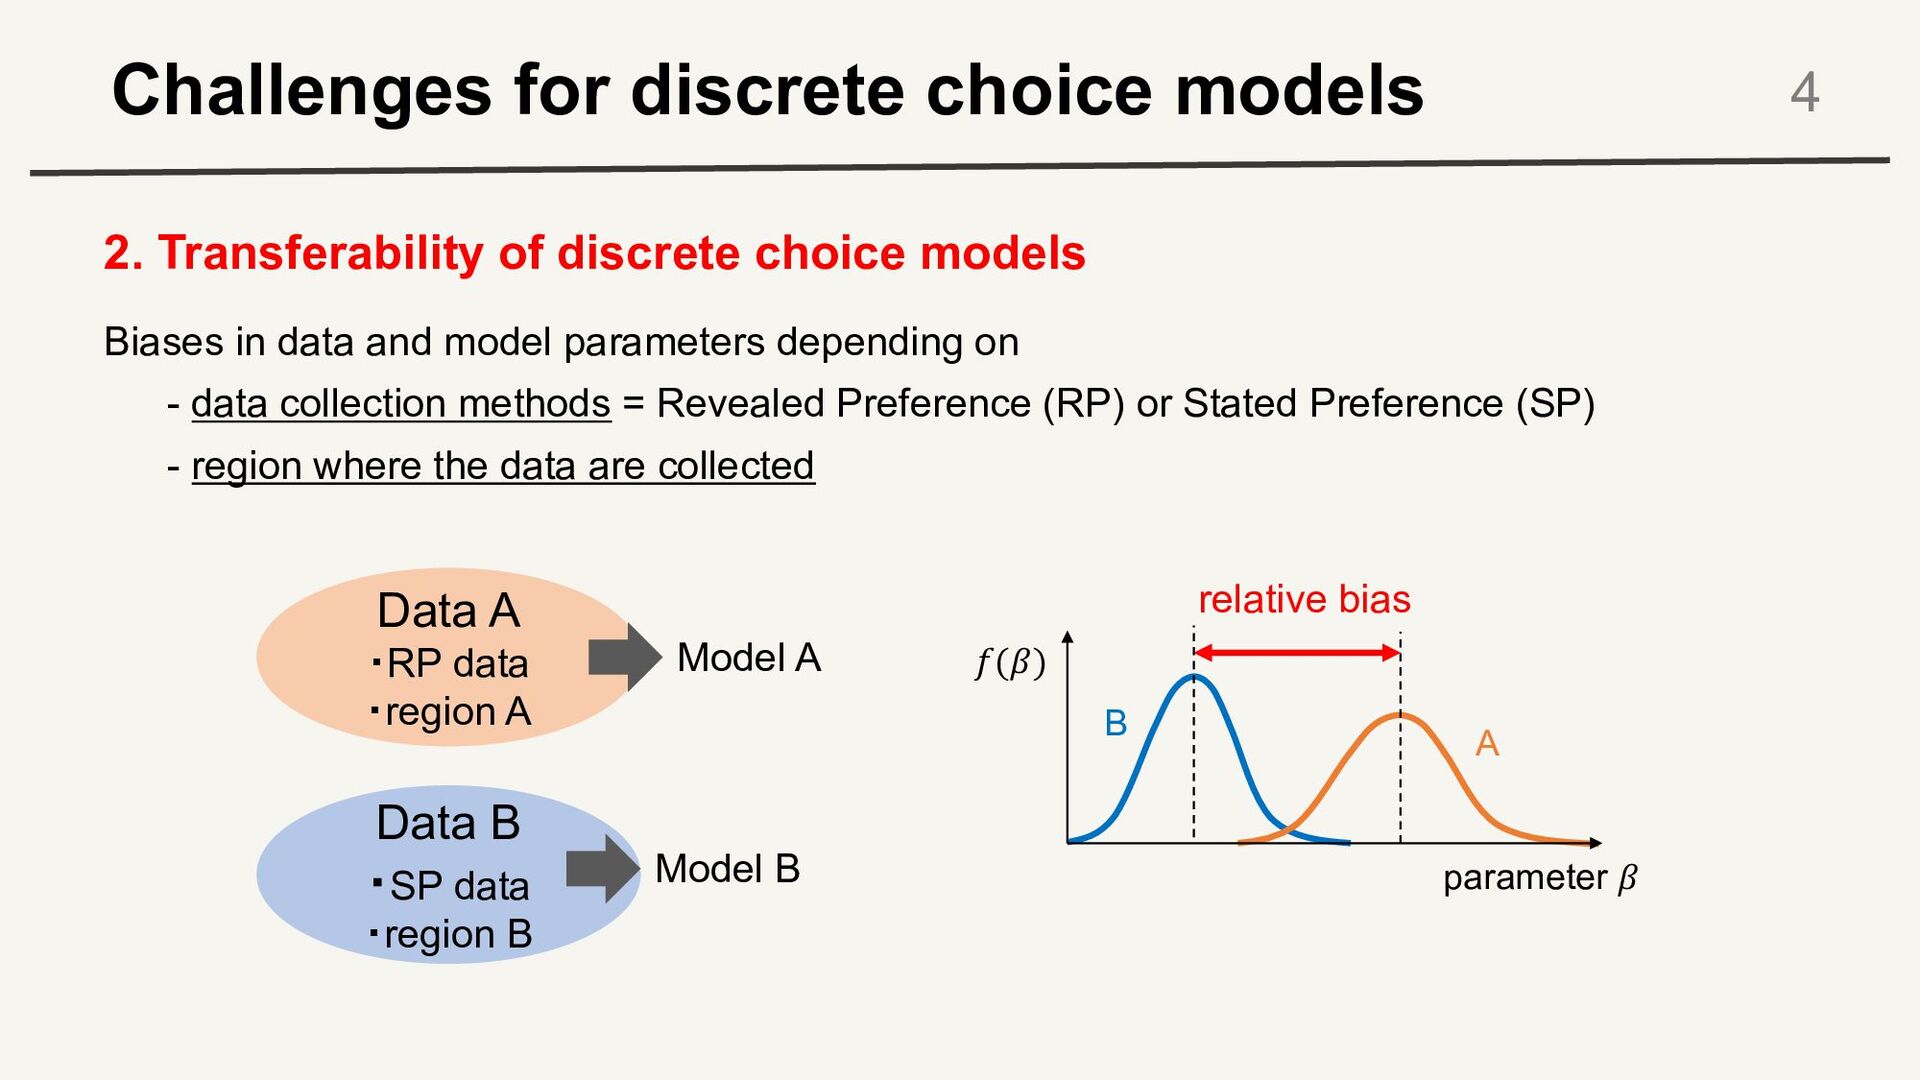
Challenges for discrete choice models 2. Transferability of discrete choice
models Biases in data and model parameters depending on - data collection methods = Revealed Preference (RP) or Stated Preference (SP) - region where the data are collected 4 Data A ・RP data ・region A Model A Data B ・SP data ・region B Model B parameter ! "(!) relative bias B A -
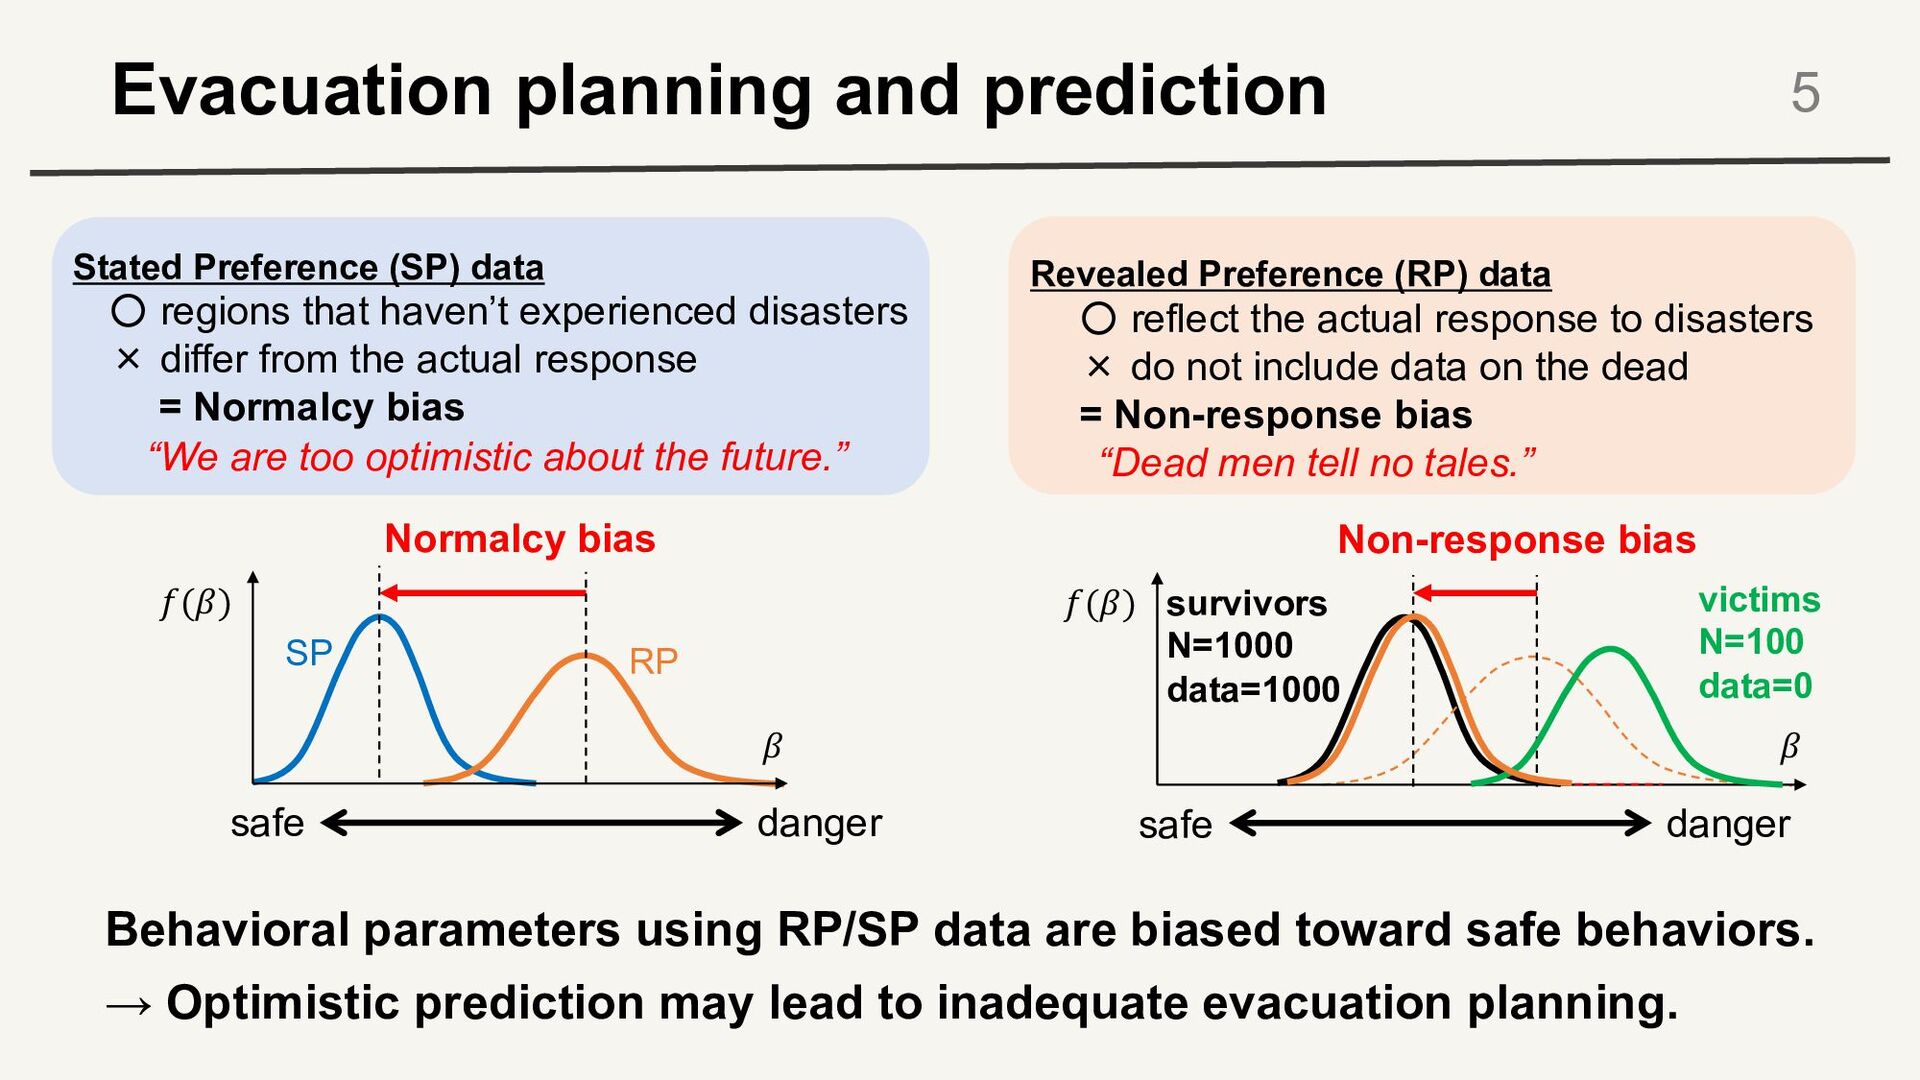
Evacuation planning and prediction 5 “Dead men tell no tales.”
“We are too optimistic about the future.” → Optimistic prediction may lead to inadequate evacuation planning. Behavioral parameters using RP/SP data are biased toward safe behaviors. Revealed Preference (RP) data ◦ reflect the actual response to disasters × do not include data on the dead = Non-response bias Stated Preference (SP) data ◦ regions that haven’t experienced disasters × differ from the actual response = Normalcy bias ! "(!) Normalcy bias safe danger SP RP "(!) safe danger ! Non-response bias survivors N=1000 data=1000 victims N=100 data=0 -
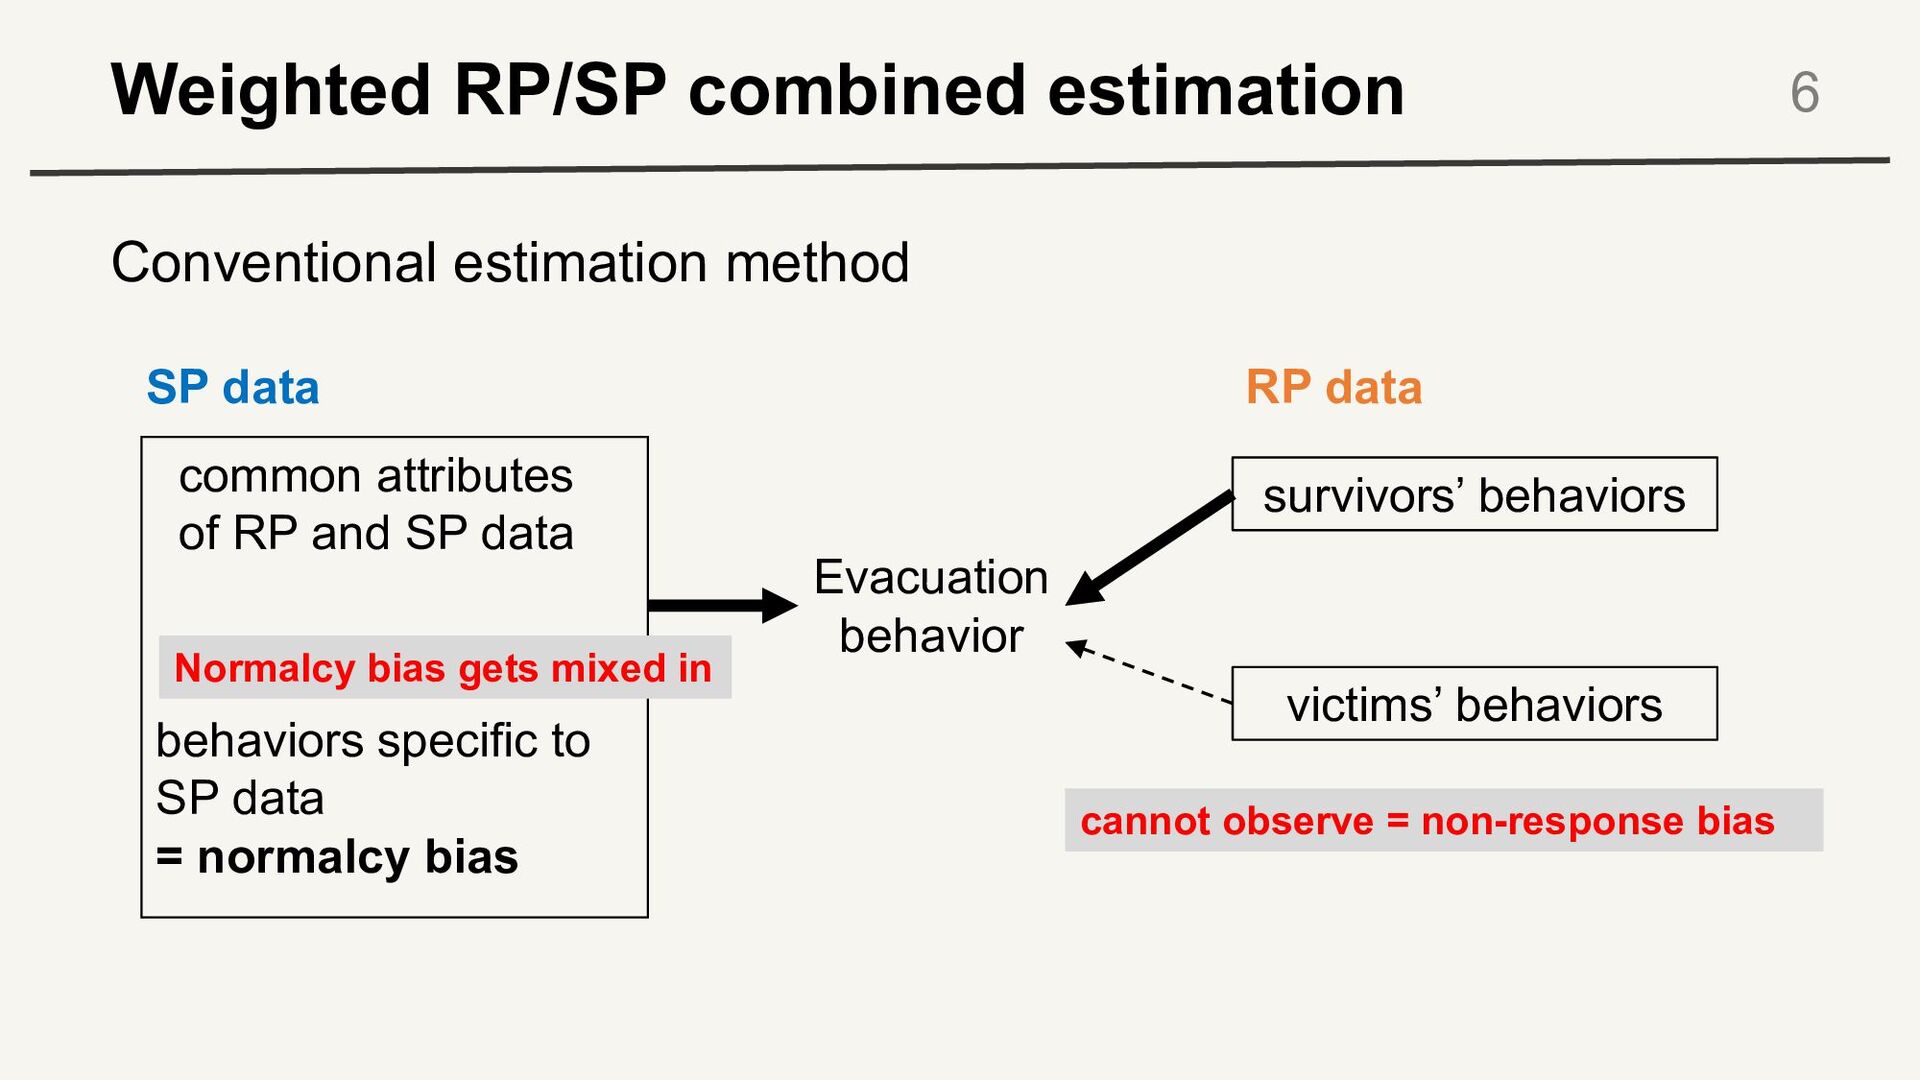
Weighted RP/SP combined estimation 6 Evacuation behavior behaviors specific to
SP data = normalcy bias common attributes of RP and SP data victims’ behaviors cannot observe = non-response bias survivors’ behaviors Conventional estimation method Normalcy bias gets mixed in RP data SP data -
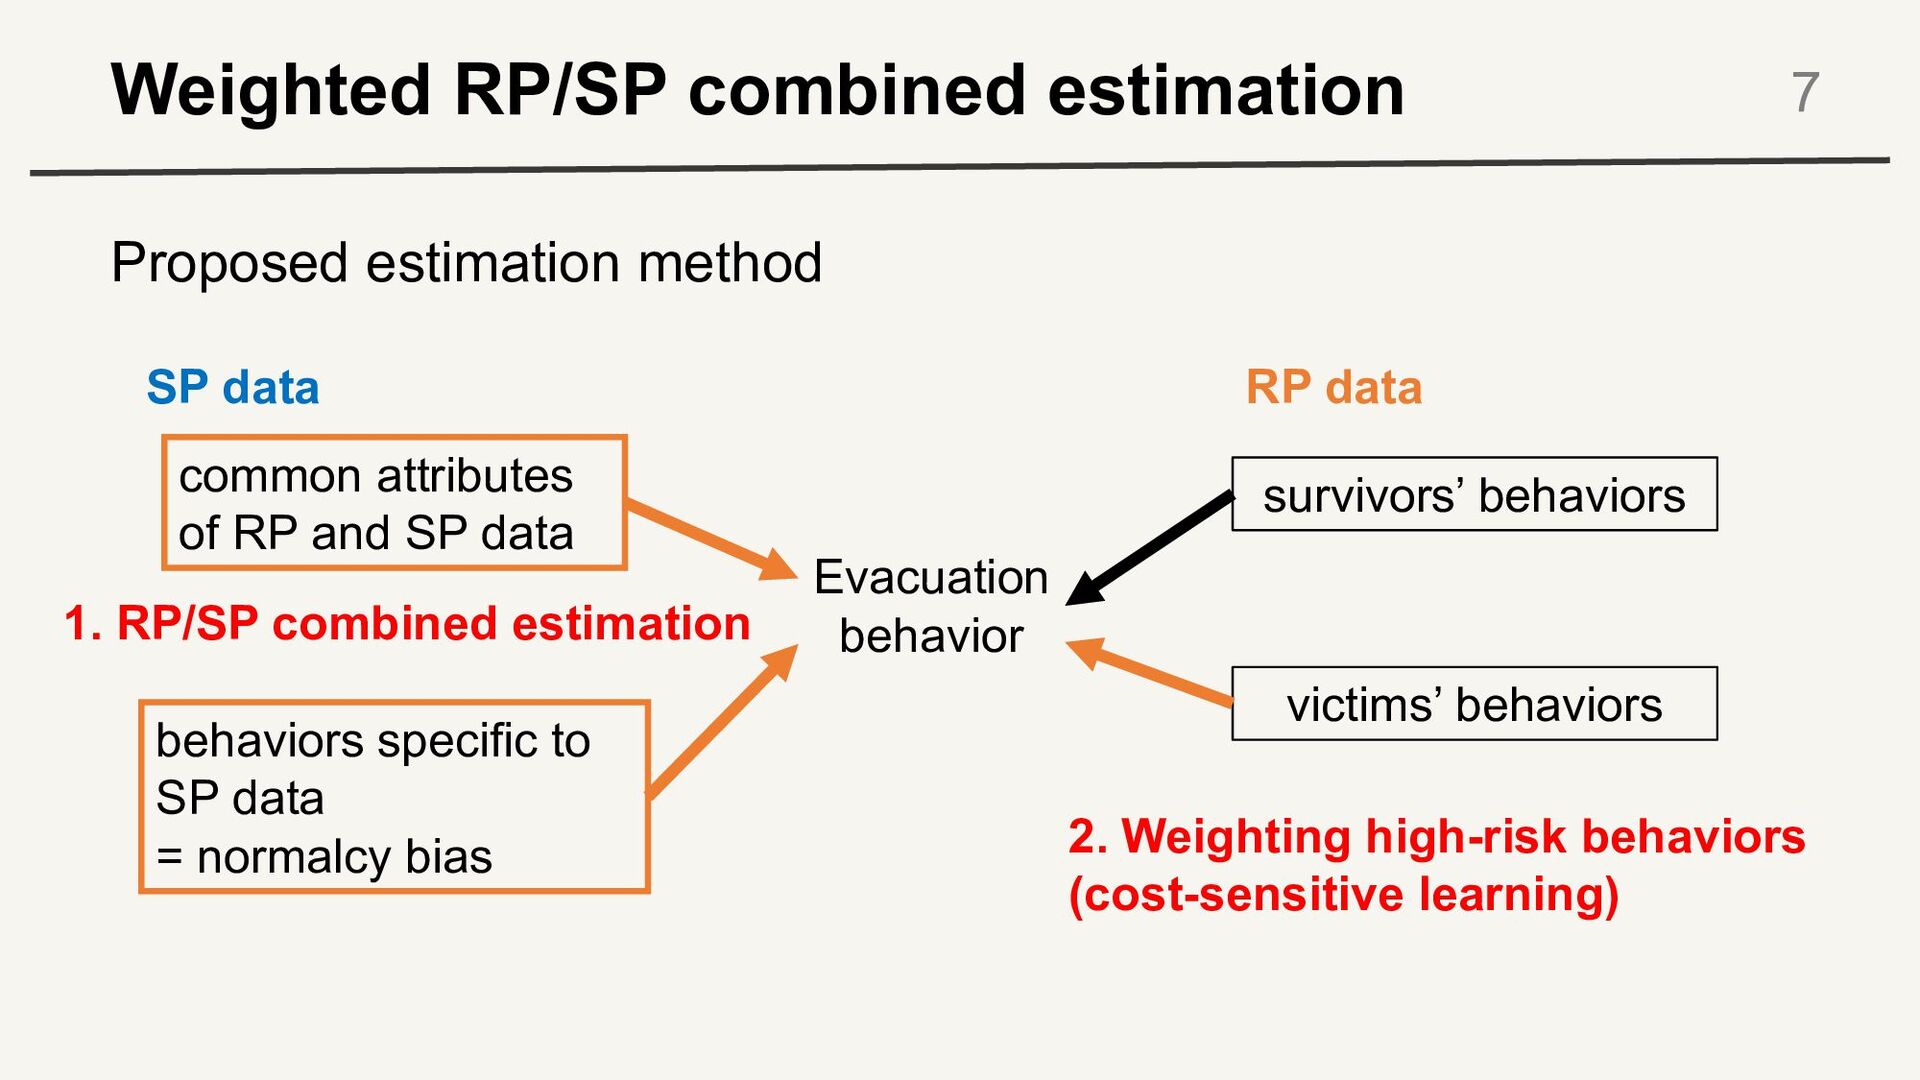
Weighted RP/SP combined estimation 7 Evacuation behavior behaviors specific to
SP data = normalcy bias common attributes of RP and SP data victims’ behaviors survivors’ behaviors RP data SP data 1. RP/SP combined estimation 2. Weighting high-risk behaviors (cost-sensitive learning) Proposed estimation method -
Table of contents 1. Introduction - Challenges for evacuation behavioral
models • Missing data • Transferability 2. Modeling - A dynamic activity scheduling model for evacuation 3. Estimation - Weighted RP/SP combined estimation 4. Numerical experiment 5. Empirical analysis 8 -
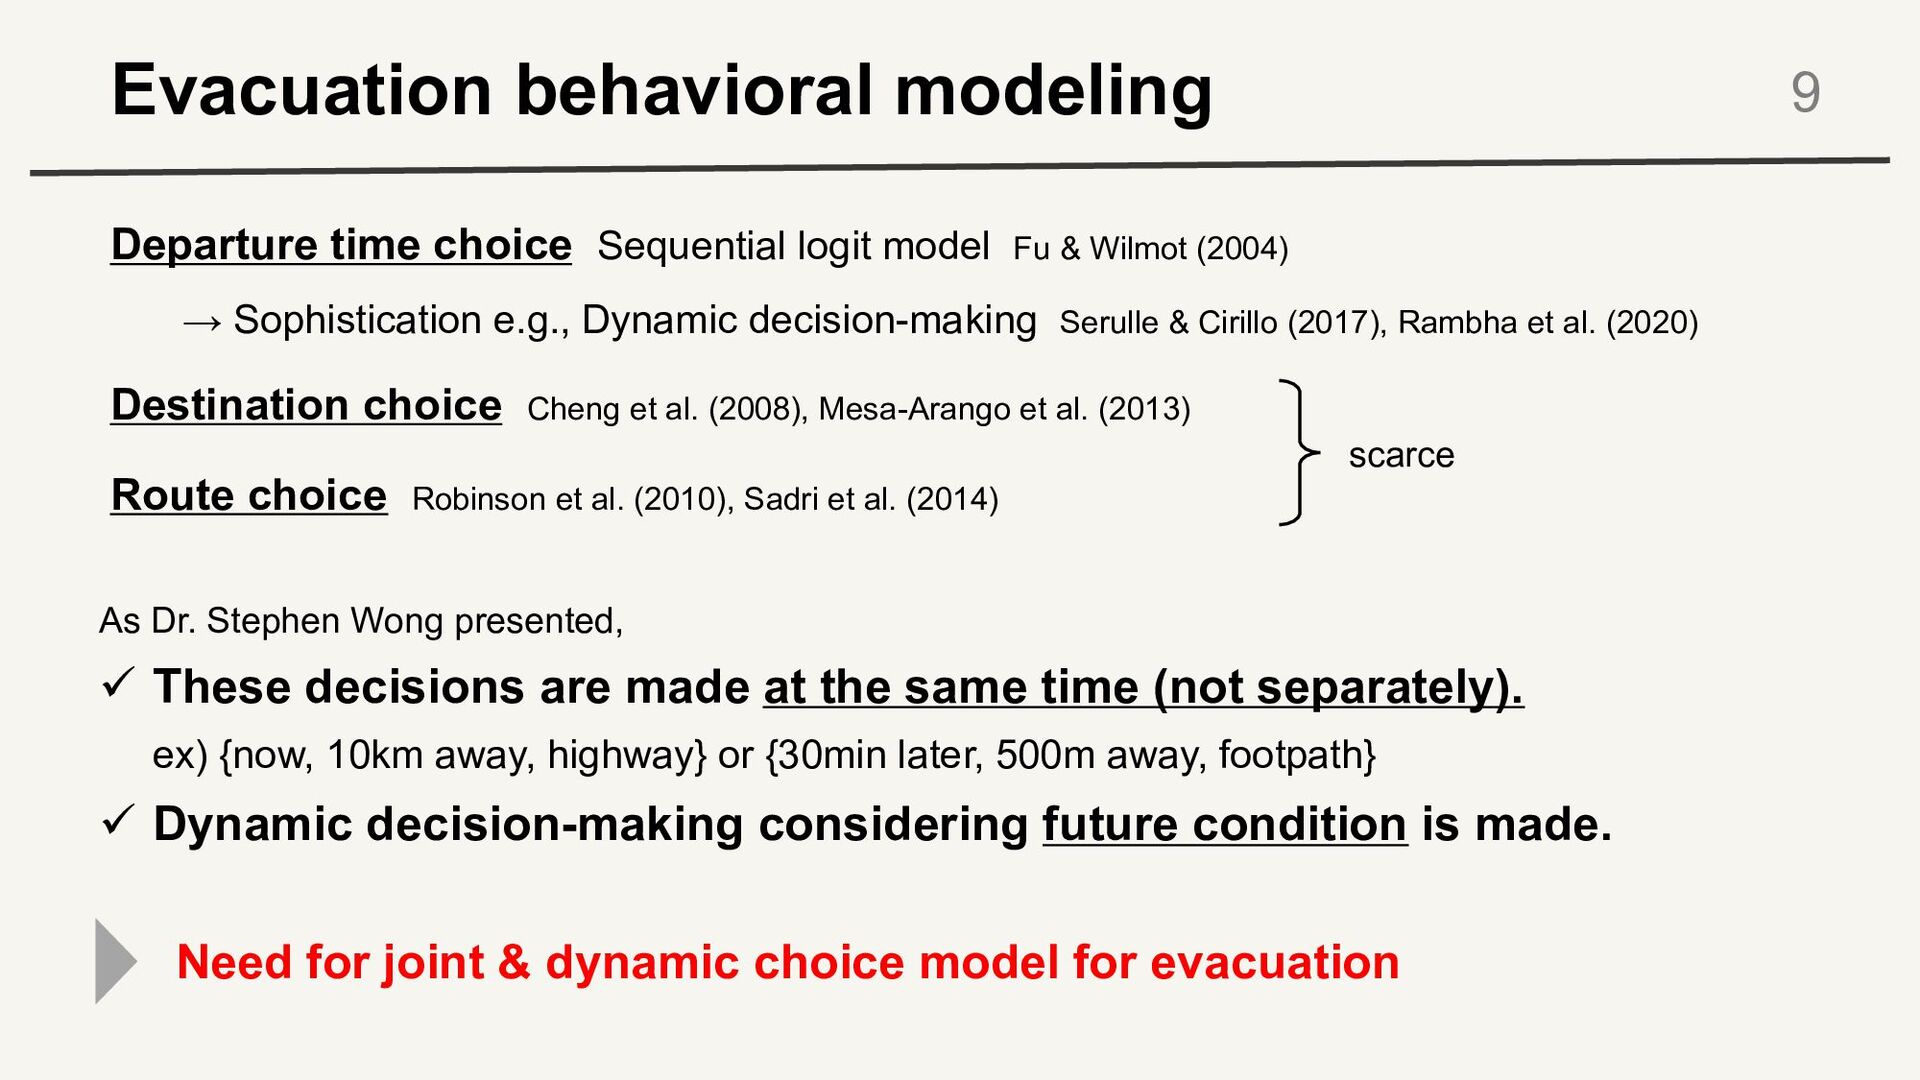
Evacuation behavioral modeling Departure time choice Sequential logit model Fu
& Wilmot (2004) → Sophistication e.g., Dynamic decision-making Serulle & Cirillo (2017), Rambha et al. (2020) Destination choice Cheng et al. (2008), Mesa-Arango et al. (2013) Route choice Robinson et al. (2010), Sadri et al. (2014) 9 scarce As Dr. Stephen Wong presented, ü These decisions are made at the same time (not separately). ex) {now, 10km away, highway} or {30min later, 500m away, footpath} ü Dynamic decision-making considering future condition is made. Need for joint & dynamic choice model for evacuation -
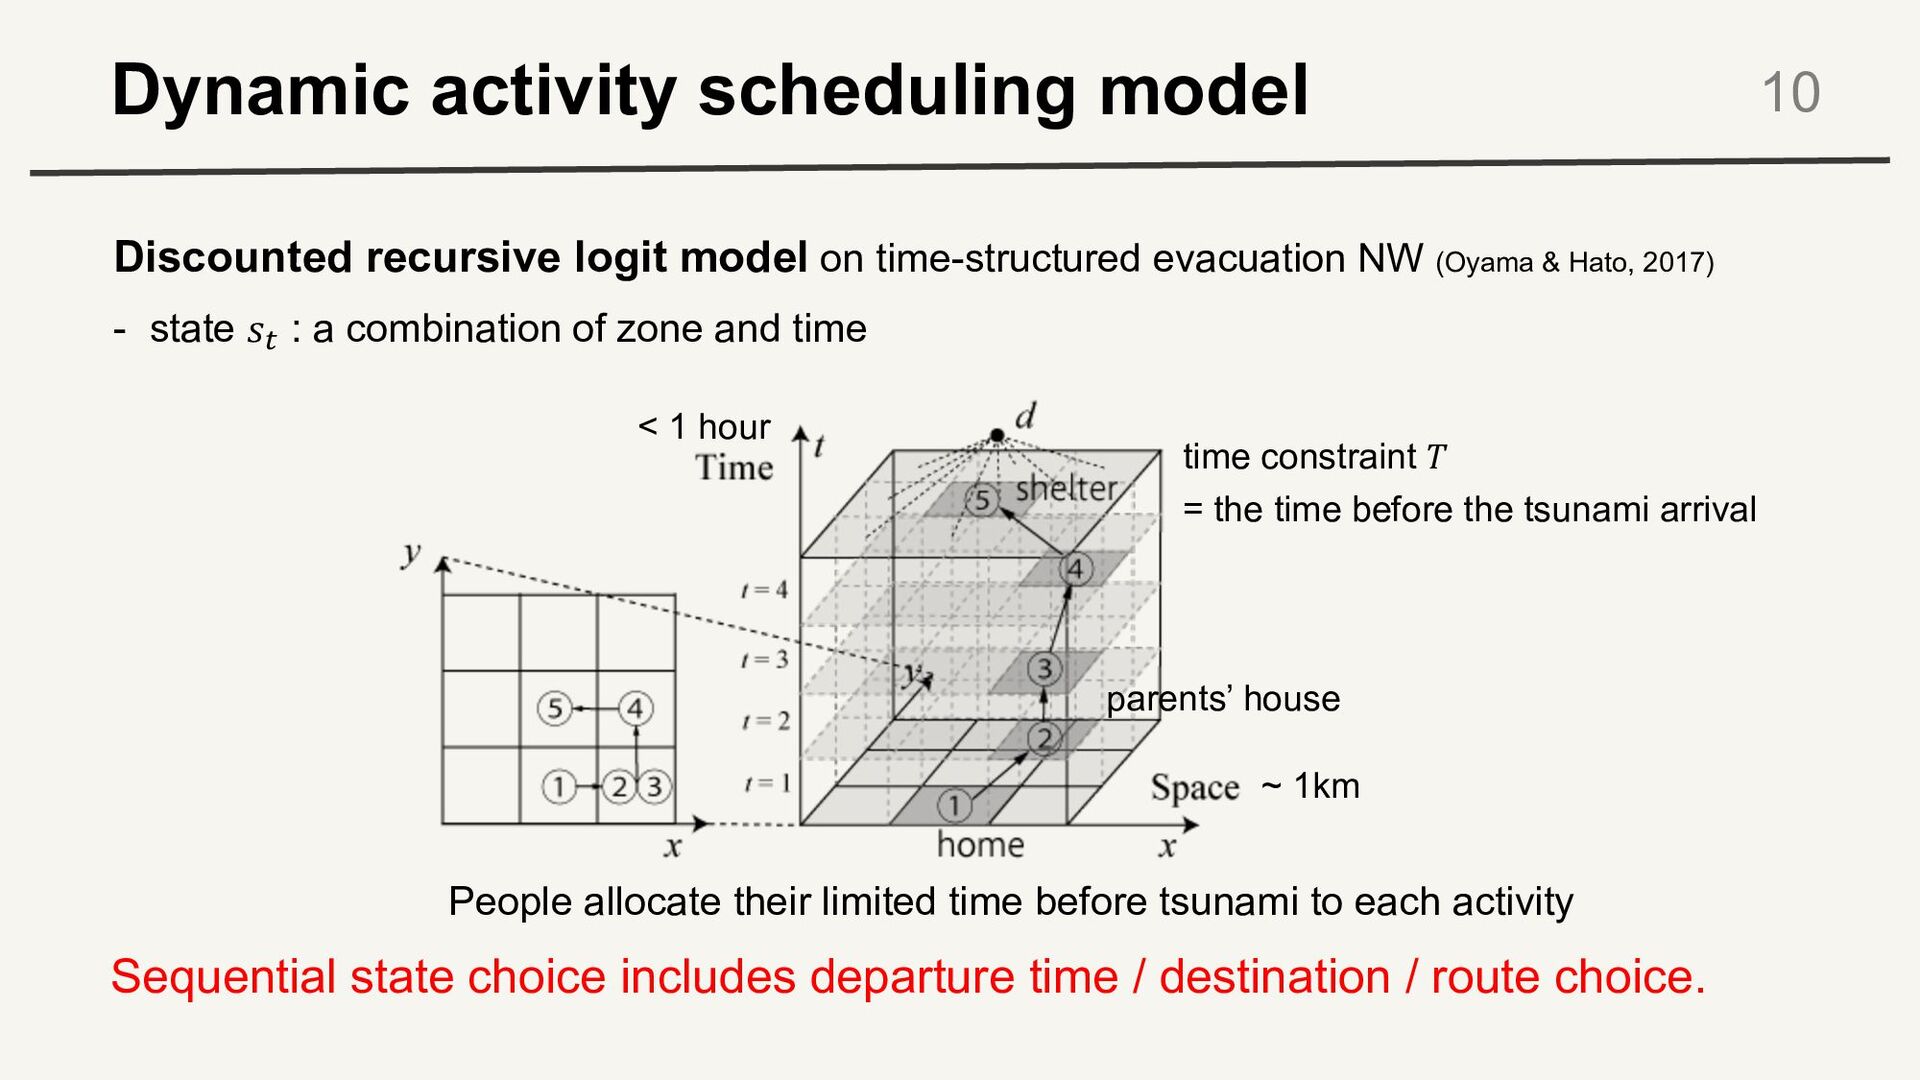
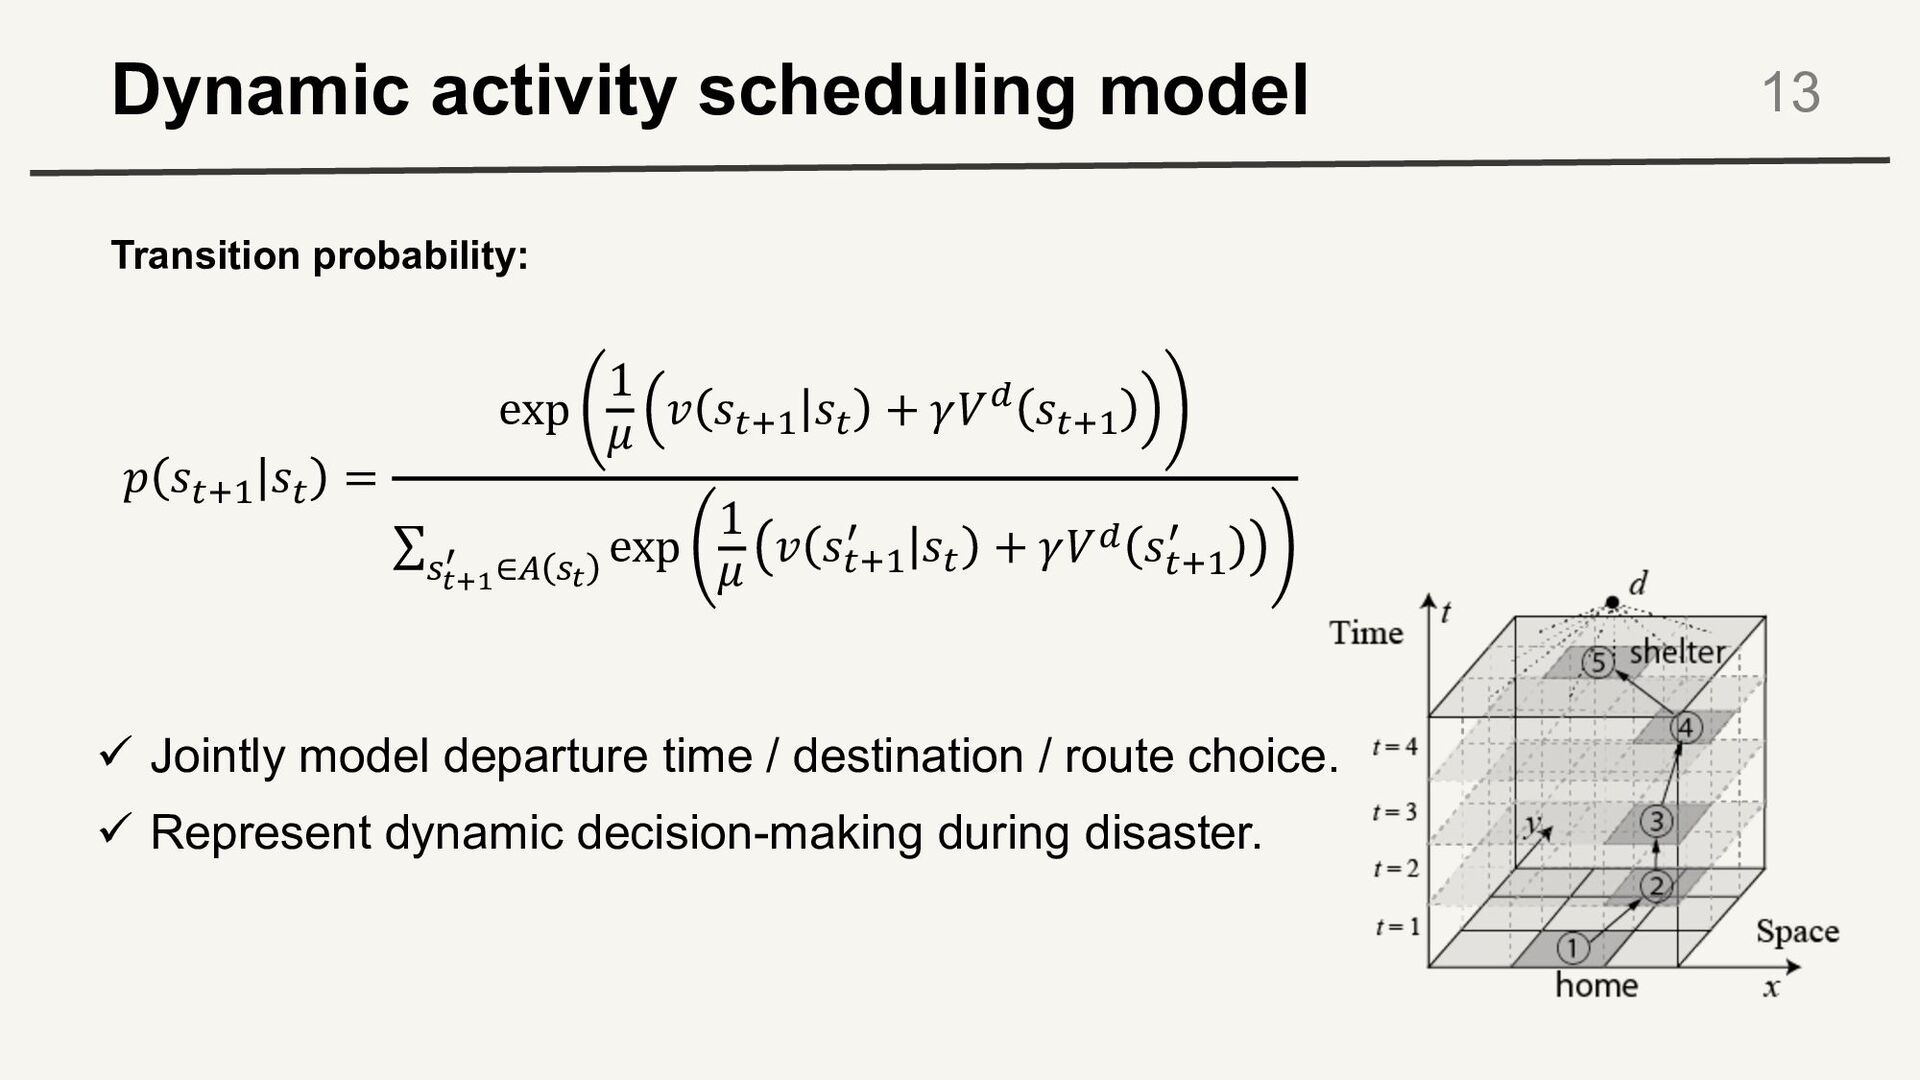
Dynamic activity scheduling model 10 Discounted recursive logit model on
time-structured evacuation NW (Oyama & Hato, 2017) - state !! : a combination of zone and time time constraint % ~ 1km < 1 hour Sequential state choice includes departure time / destination / route choice. parents’ house = the time before the tsunami arrival People allocate their limited time before tsunami to each activity -
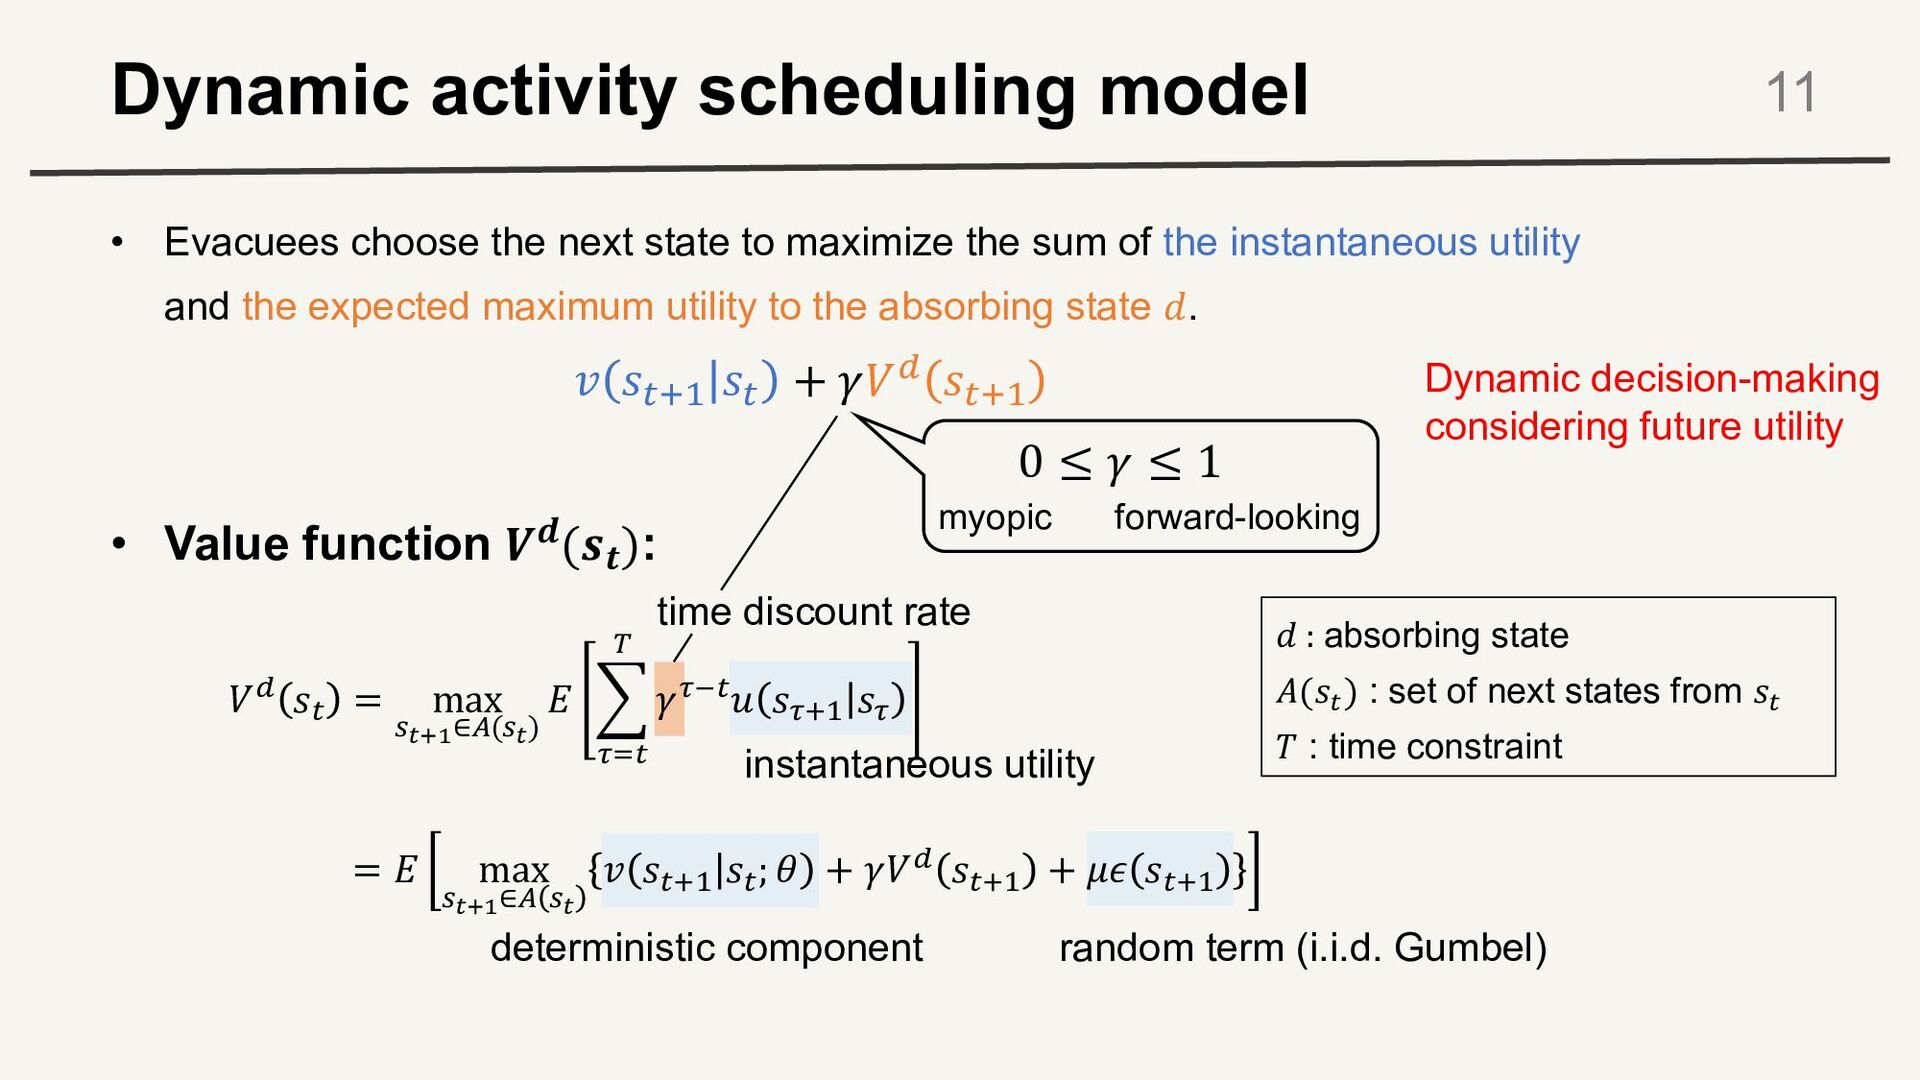
Dynamic activity scheduling model 11 • Value function !&(# '
): ( : absorbing state +(,!) : set of next states from ,! % : time constraint = # max "!"#∈$ "! ' !!%& !! ; ) + +,' !!%& + -. !!%& random term (i.i.d. Gumbel) deterministic component ,' !! = max "!"#∈$("!) # / *+! , +*-!0 !*%& !* instantaneous utility time discount rate • Evacuees choose the next state to maximize the sum of the instantaneous utility and the expected maximum utility to the absorbing state 1. % & -./ & - + ()0 & -./ Dynamic decision-making considering future utility 0 ≤ ( ≤ 1 myopic forward-looking -
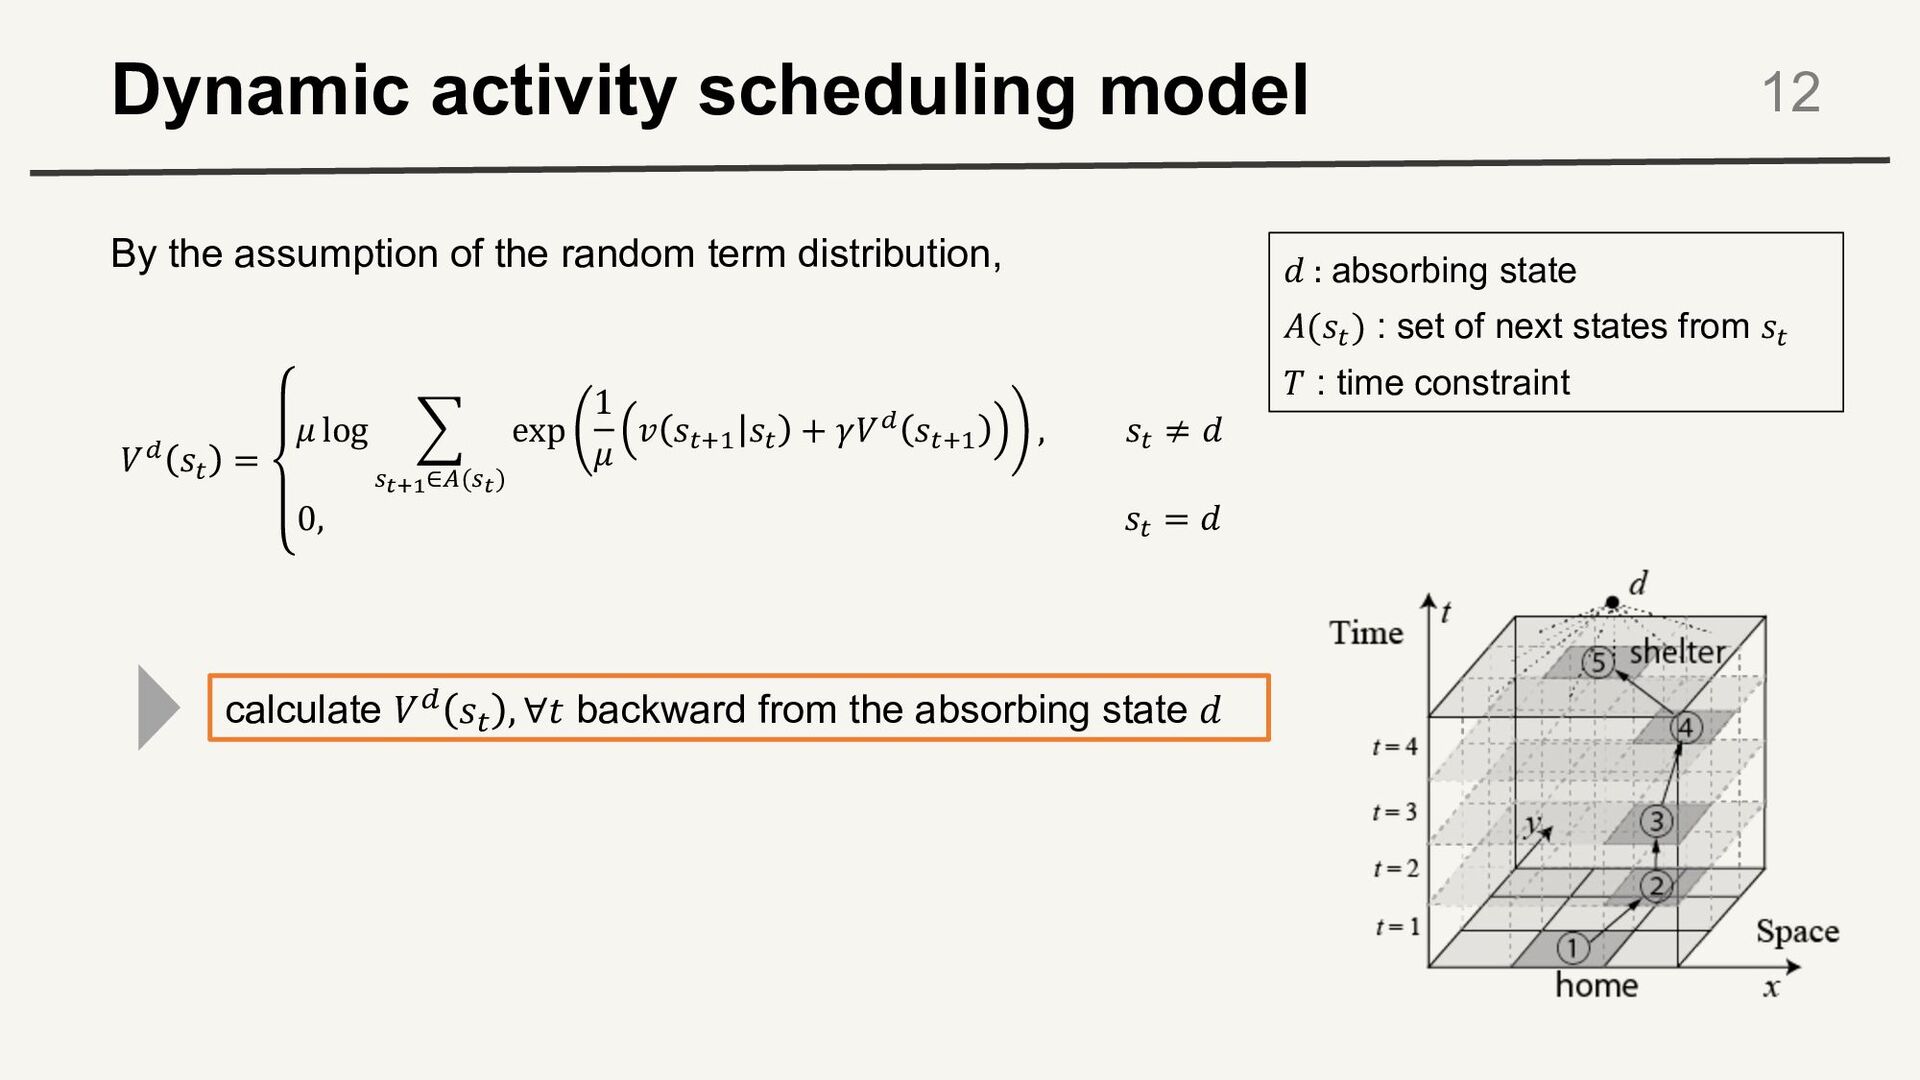
Dynamic activity scheduling model 12 1" ,! = 3 log
7 #!"#∈%(#!) exp 1 3 < ,!() ,! + >1" ,!() , ,! ≠ ( 0, ,! = ( By the assumption of the random term distribution, calculate ,' !! , ∀4 backward from the absorbing state 1 ( : absorbing state +(,!) : set of next states from ,! % : time constraint -
Dynamic activity scheduling model 13 Transition probability: - & -./
& - = exp 1 2 % & -./ & - + ()0 & -./ ∑ B!"# $ ∈D B! exp 1 2 % & -./ E & - + ()0 & -./ E ü Jointly model departure time / destination / route choice. ü Represent dynamic decision-making during disaster. -
Table of contents 1. Introduction - Challenges for evacuation behavioral
models • Missing data • Transferability 2. Modeling - A dynamic activity scheduling model for evacuation 3. Estimation - Weighted RP/SP combined estimation 4. Numerical experiment 5. Empirical analysis 14 -
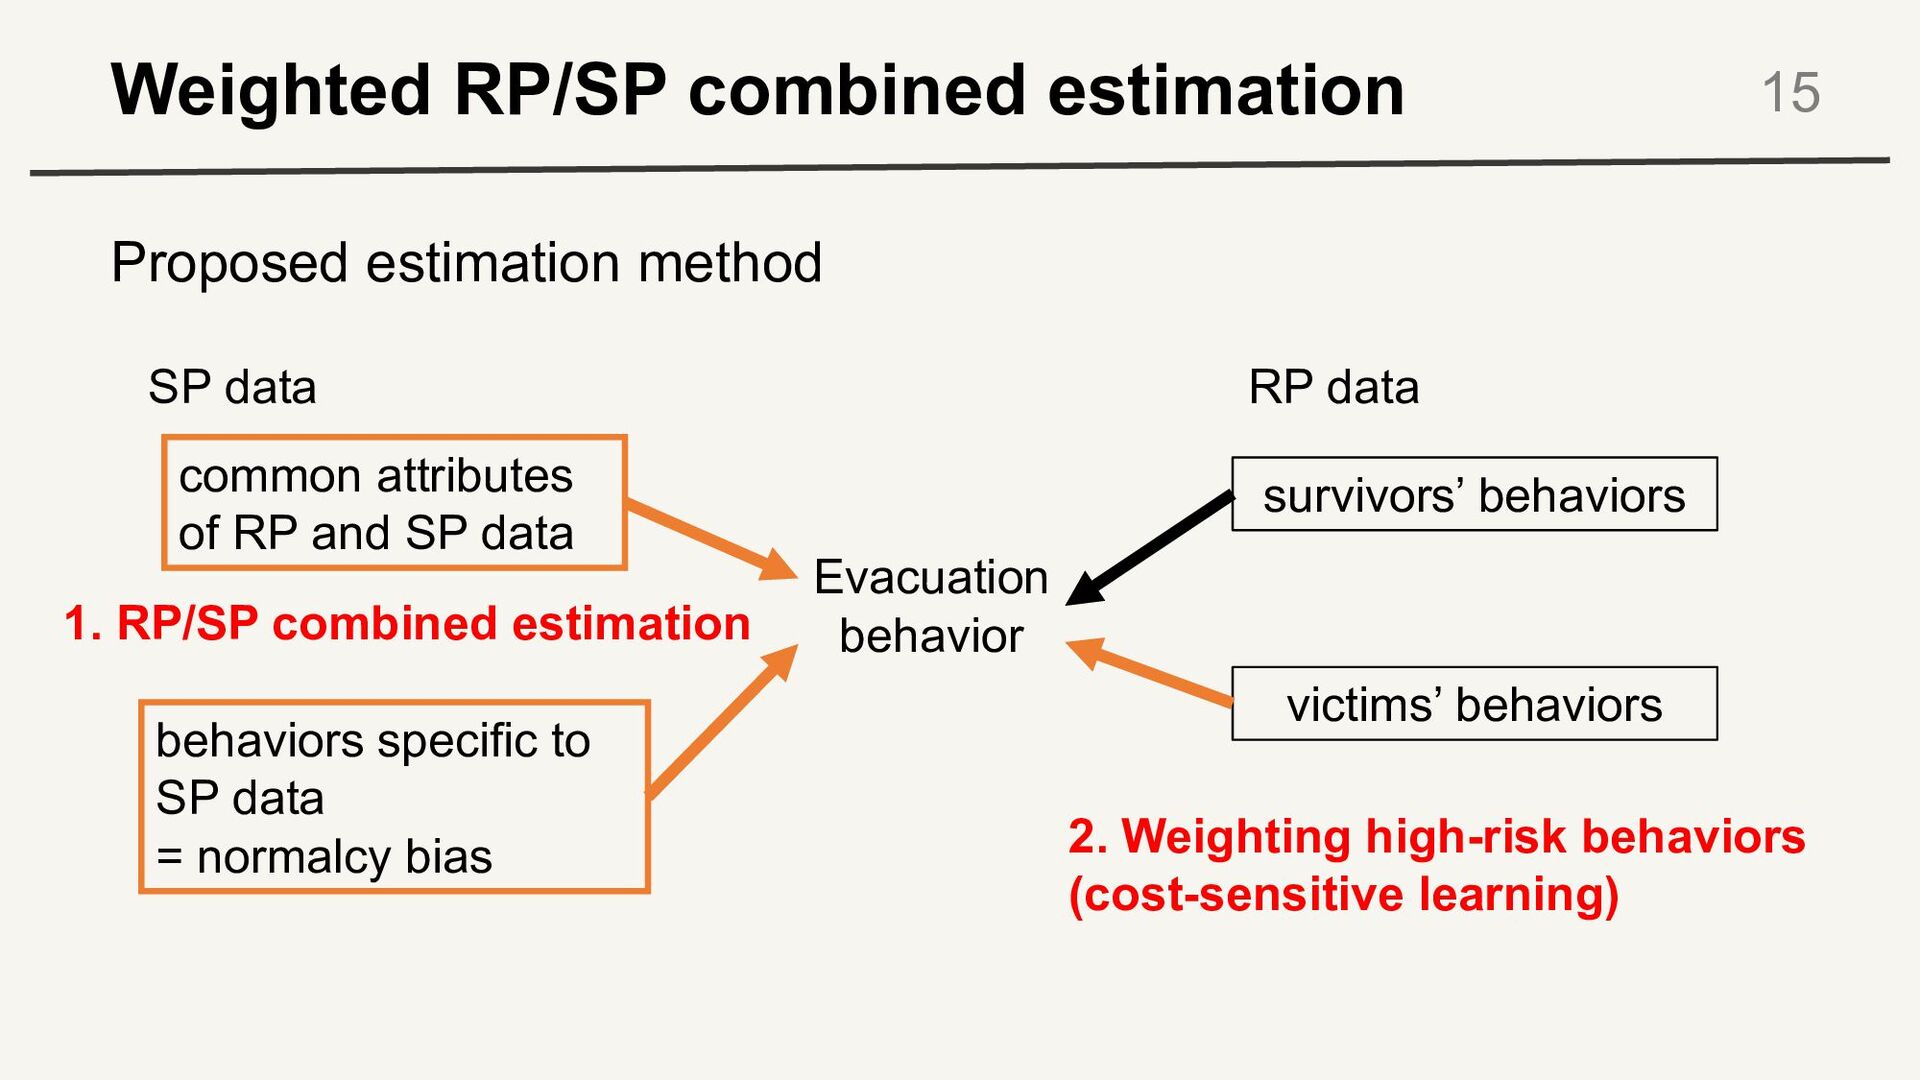
Weighted RP/SP combined estimation 15 Evacuation behavior behaviors specific to
SP data = normalcy bias common attributes of RP and SP data victims’ behaviors survivors’ behaviors RP data SP data 1. RP/SP combined estimation 2. Weighting high-risk behaviors (cost-sensitive learning) Proposed estimation method -
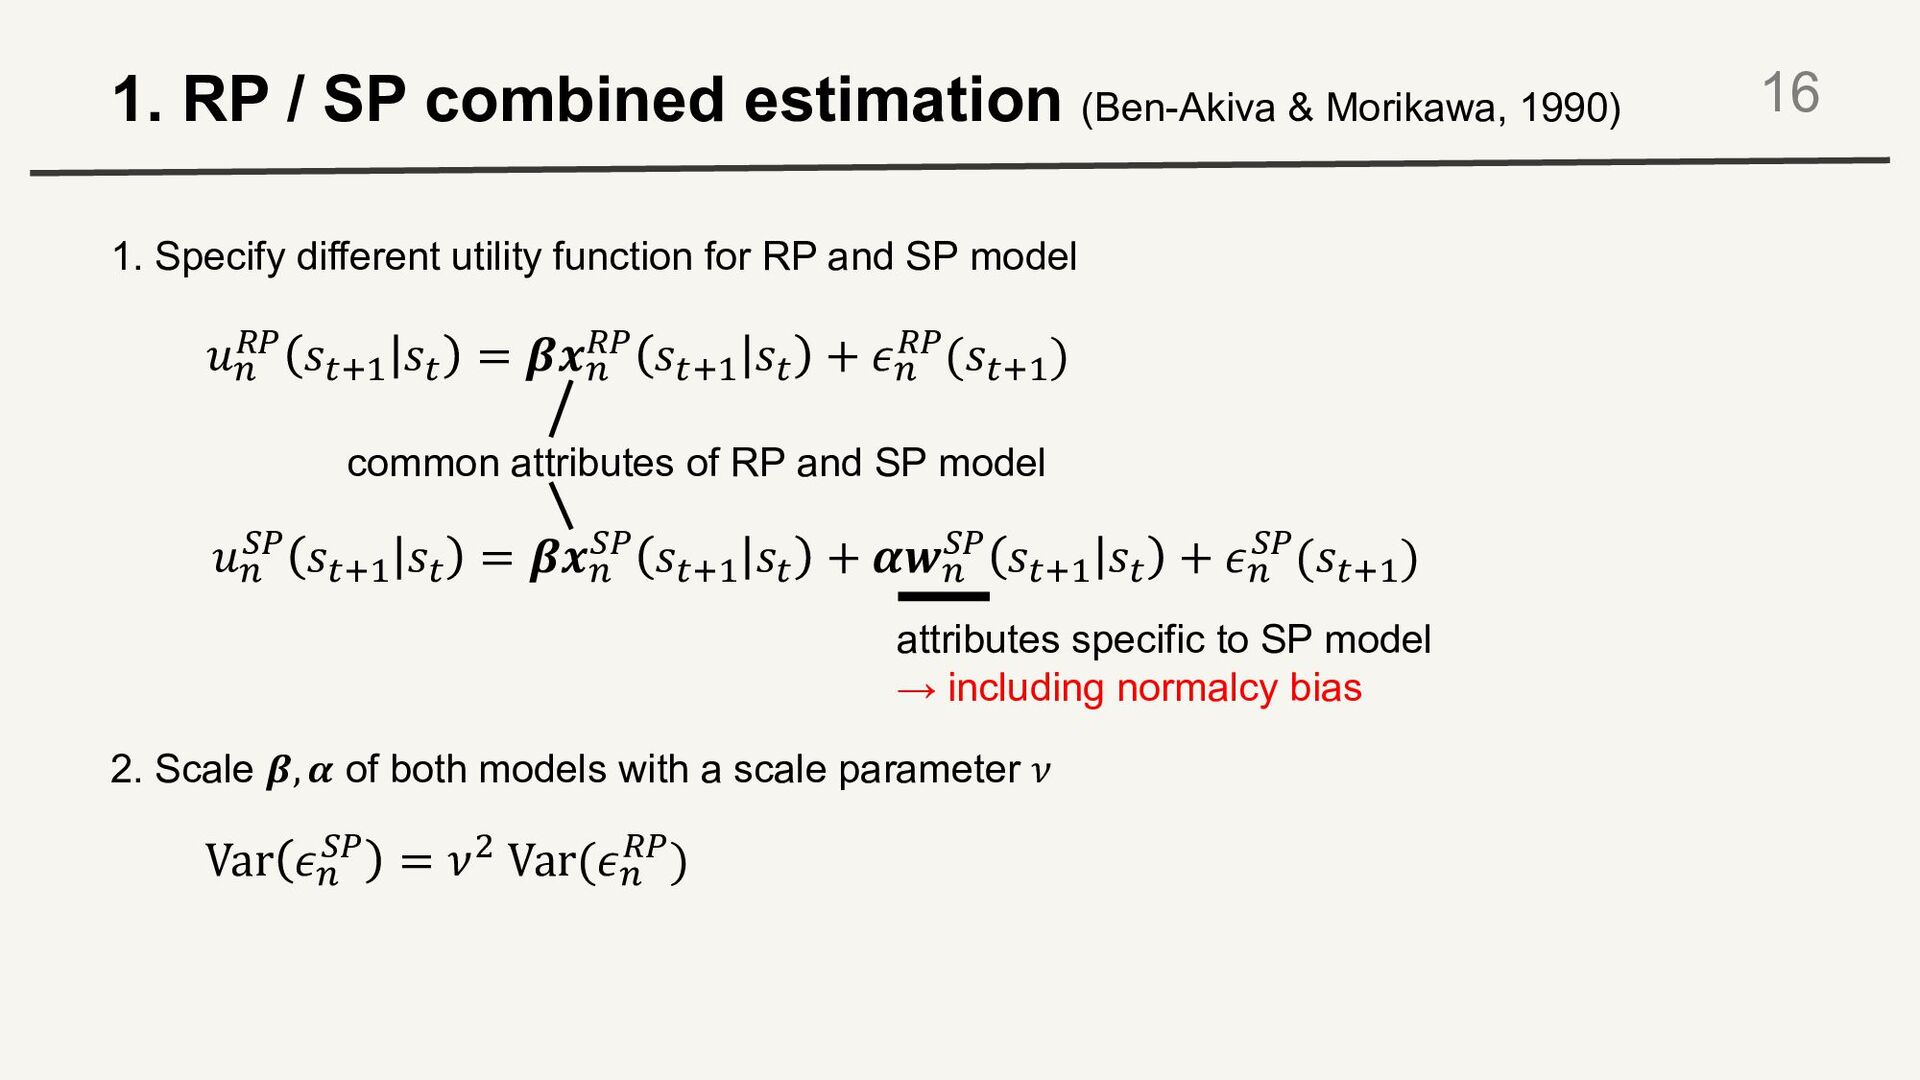
1. RP / SP combined estimation (Ben-Akiva & Morikawa, 1990)
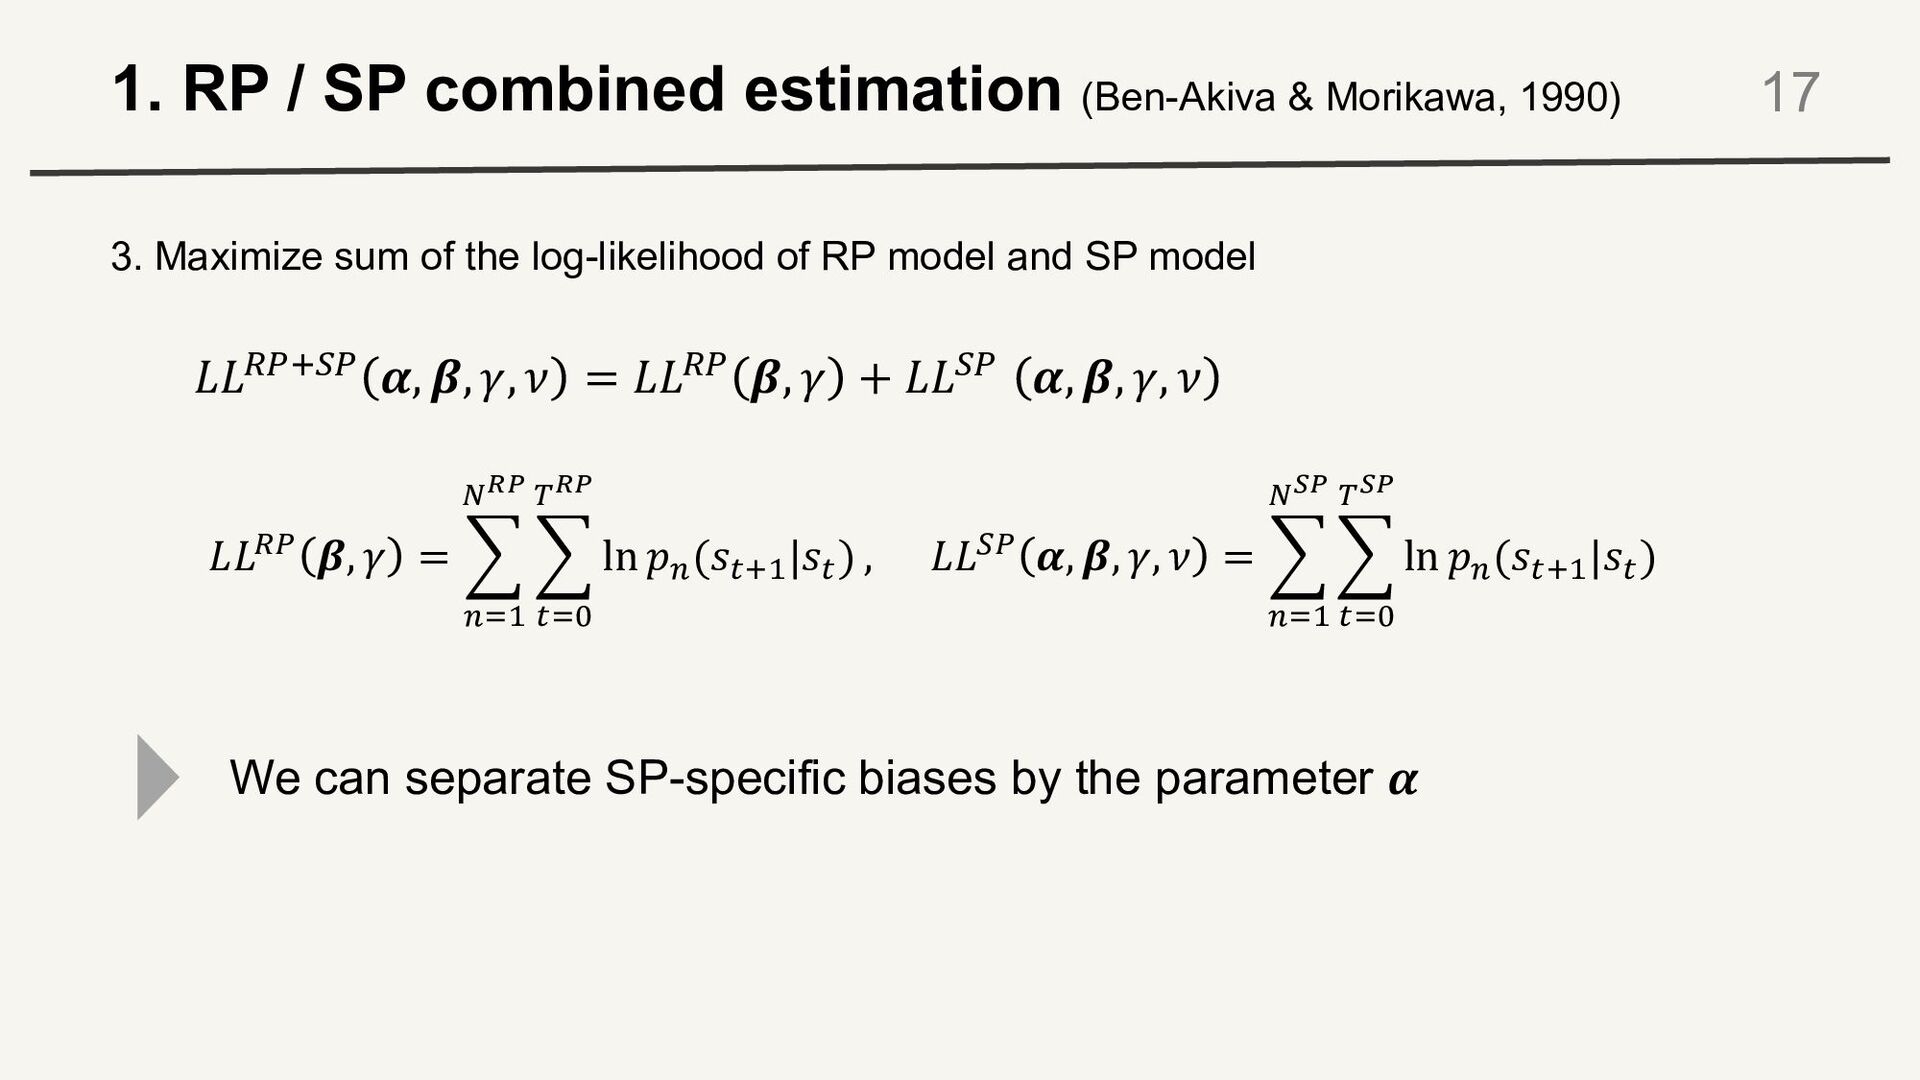
1. Specify different utility function for RP and SP model 16 4 F GH & -./ & - = 56 F GH & -./ & - + 7 F GH(& -./ ) 4 F IH & -./ & - = 56 F IH & -./ & - + 89 F IH & -./ & - + 7 F IH(& -./ ) common attributes of RP and SP model attributes specific to SP model → including normalcy bias 2. Scale 5, 6 of both models with a scale parameter 7 Var 7 F IH = =J Var(7 F GH) -
1. RP / SP combined estimation (Ben-Akiva & Morikawa, 1990)
3. Maximize sum of the log-likelihood of RP model and SP model 17 >>GH.IH 8, 5, (, = = >>GH 5, ( + >>IH 8, 5, (, = !!!" ", $ = & #$% &*+ & '$( )*+ ln )# (+'*% |+' ) , !!+" ., ", $, / = & #$% &,+ & '$( ),+ ln )# (+'*% |+' ) We can separate SP-specific biases by the parameter 8 -
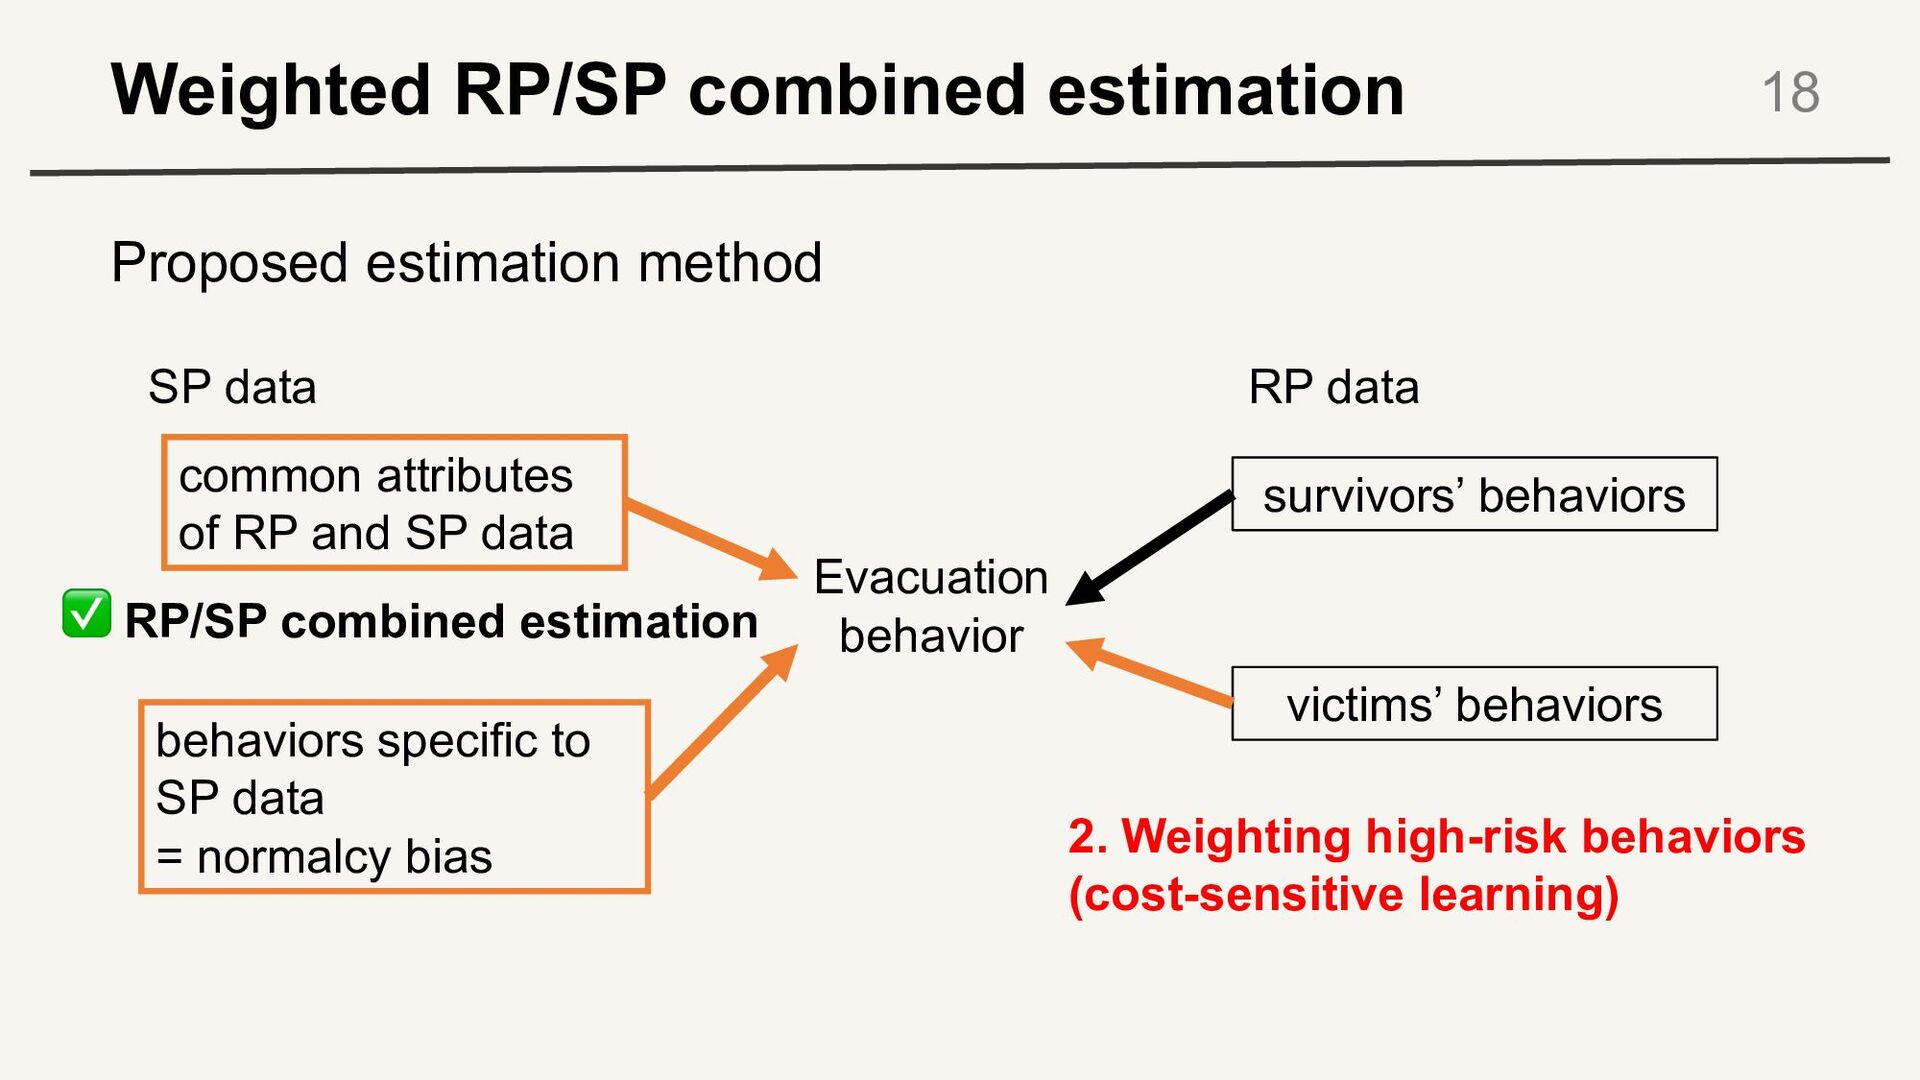
Weighted RP/SP combined estimation 18 Evacuation behavior behaviors specific to
SP data = normalcy bias common attributes of RP and SP data victims’ behaviors survivors’ behaviors RP data SP data 2. Weighting high-risk behaviors (cost-sensitive learning) Proposed estimation method ✅ RP/SP combined estimation -
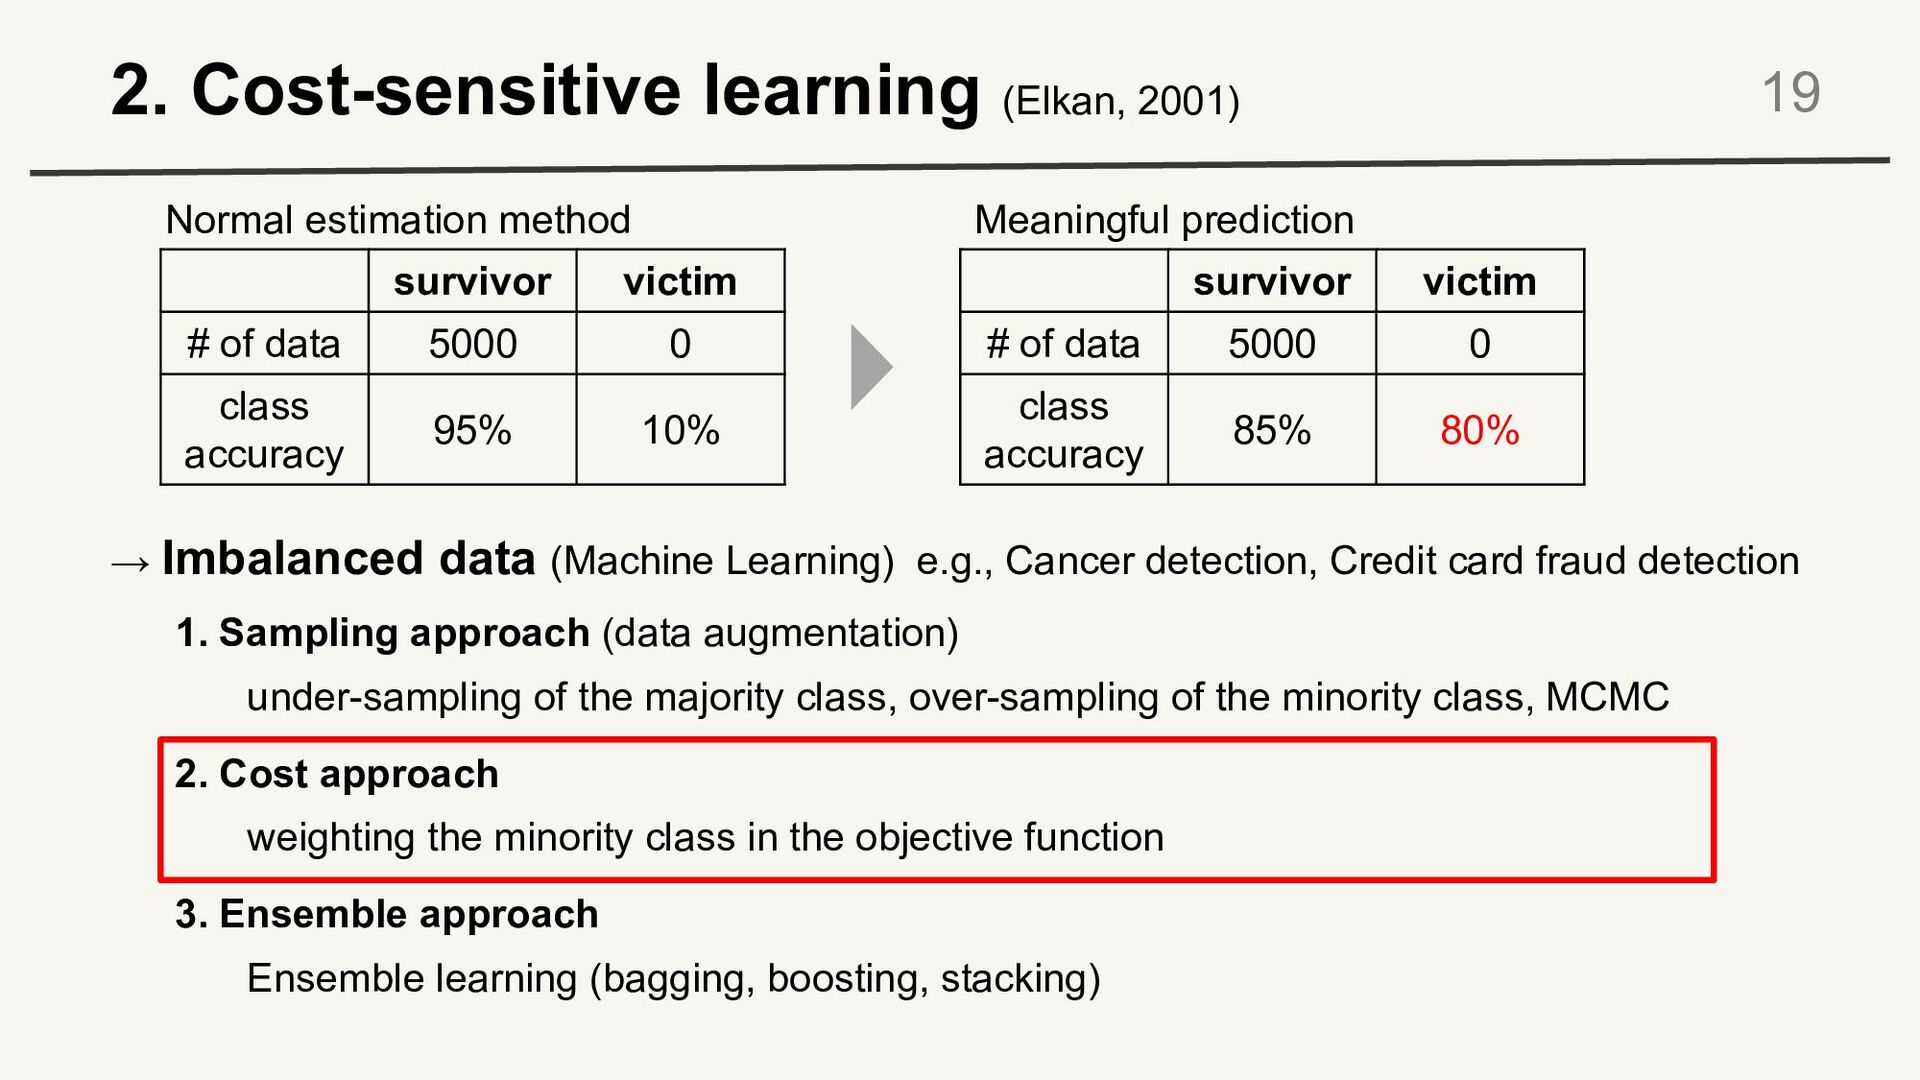
2. Cost-sensitive learning (Elkan, 2001) → Imbalanced data (Machine Learning)
e.g., Cancer detection, Credit card fraud detection 19 1. Sampling approach (data augmentation) under-sampling of the majority class, over-sampling of the minority class, MCMC 2. Cost approach weighting the minority class in the objective function 3. Ensemble approach Ensemble learning (bagging, boosting, stacking) survivor victim # of data 5000 0 class accuracy 95% 10% survivor victim # of data 5000 0 class accuracy 85% 80% Normal estimation method Meaningful prediction -
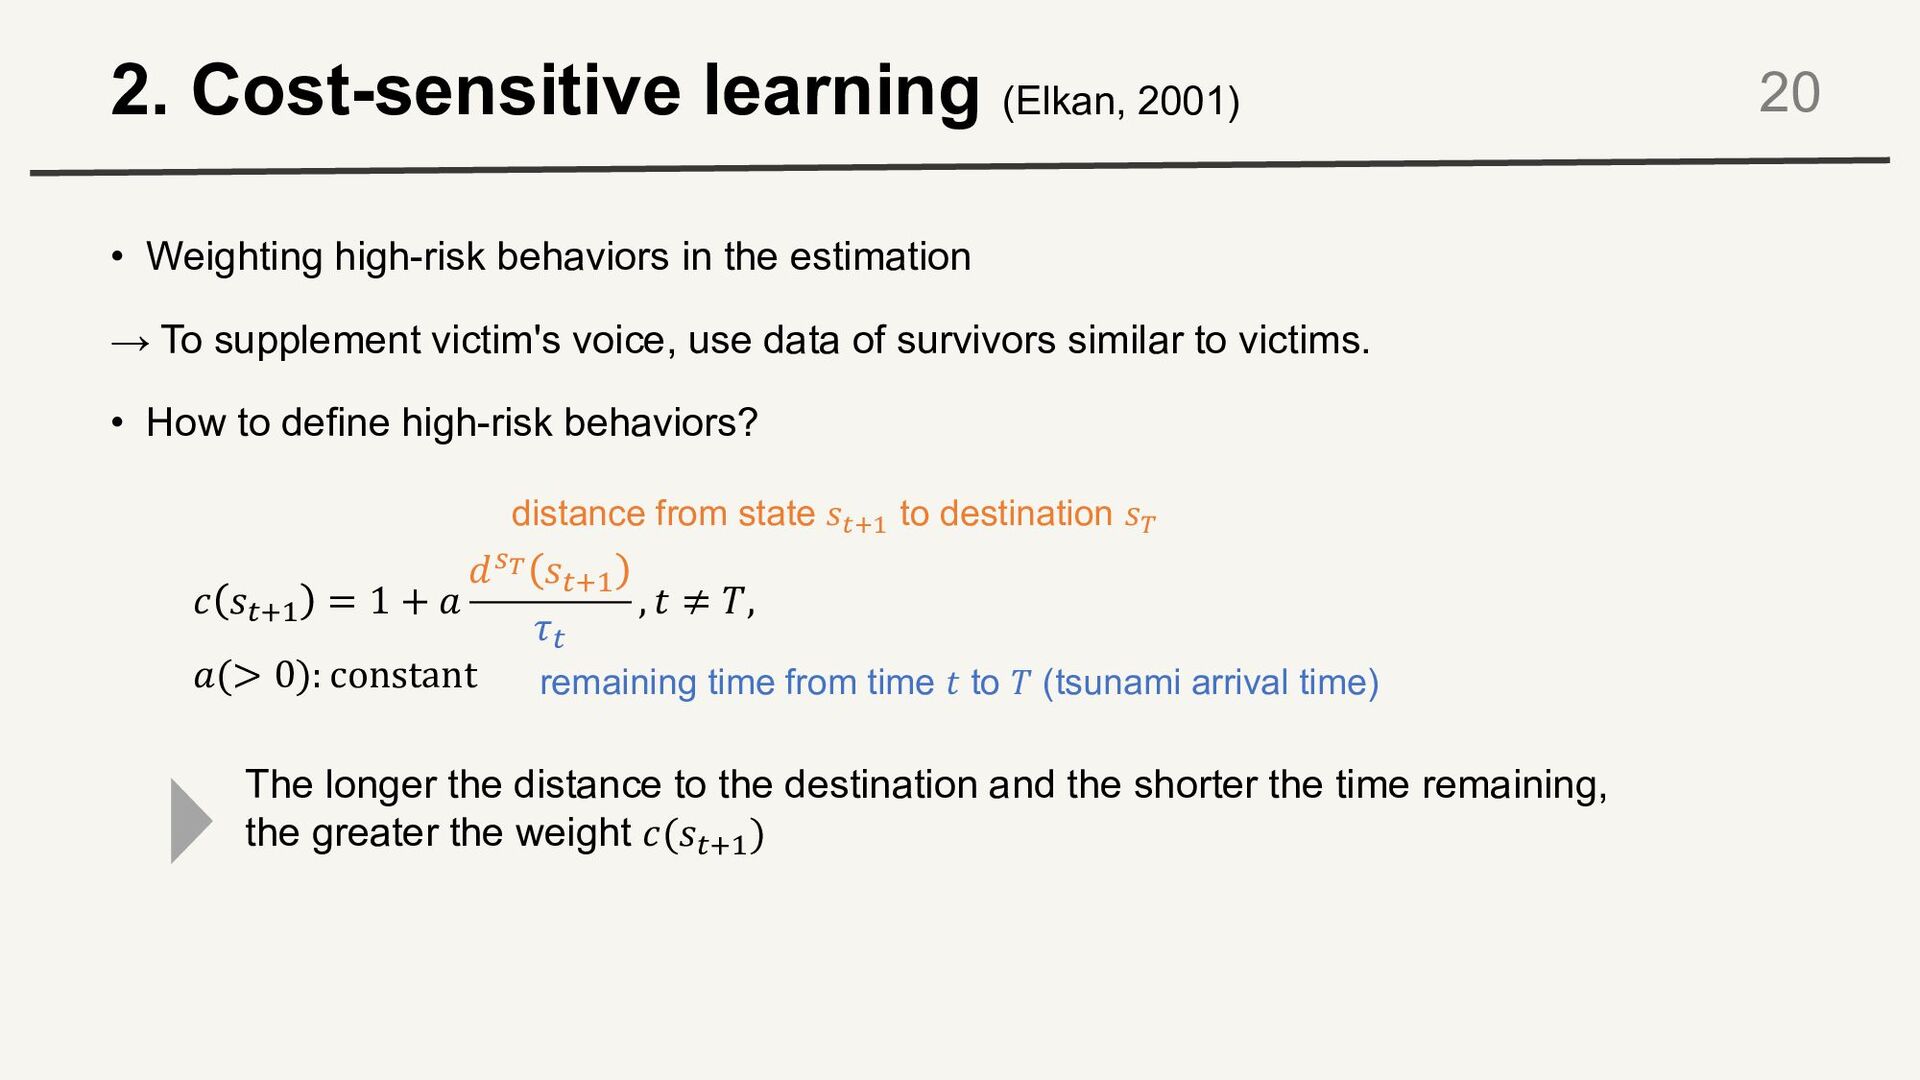
2. Cost-sensitive learning (Elkan, 2001) • Weighting high-risk behaviors in
the estimation → To supplement victim's voice, use data of survivors similar to victims. • How to define high-risk behaviors? 20 8 !!%& = 1 + : 1"$ !!%& ;! , 4 ≠ =, :(> 0): constant distance from state ,!() to destination ,- remaining time from time K to % (tsunami arrival time) The longer the distance to the destination and the shorter the time remaining, the greater the weight 8(!!%& ) -
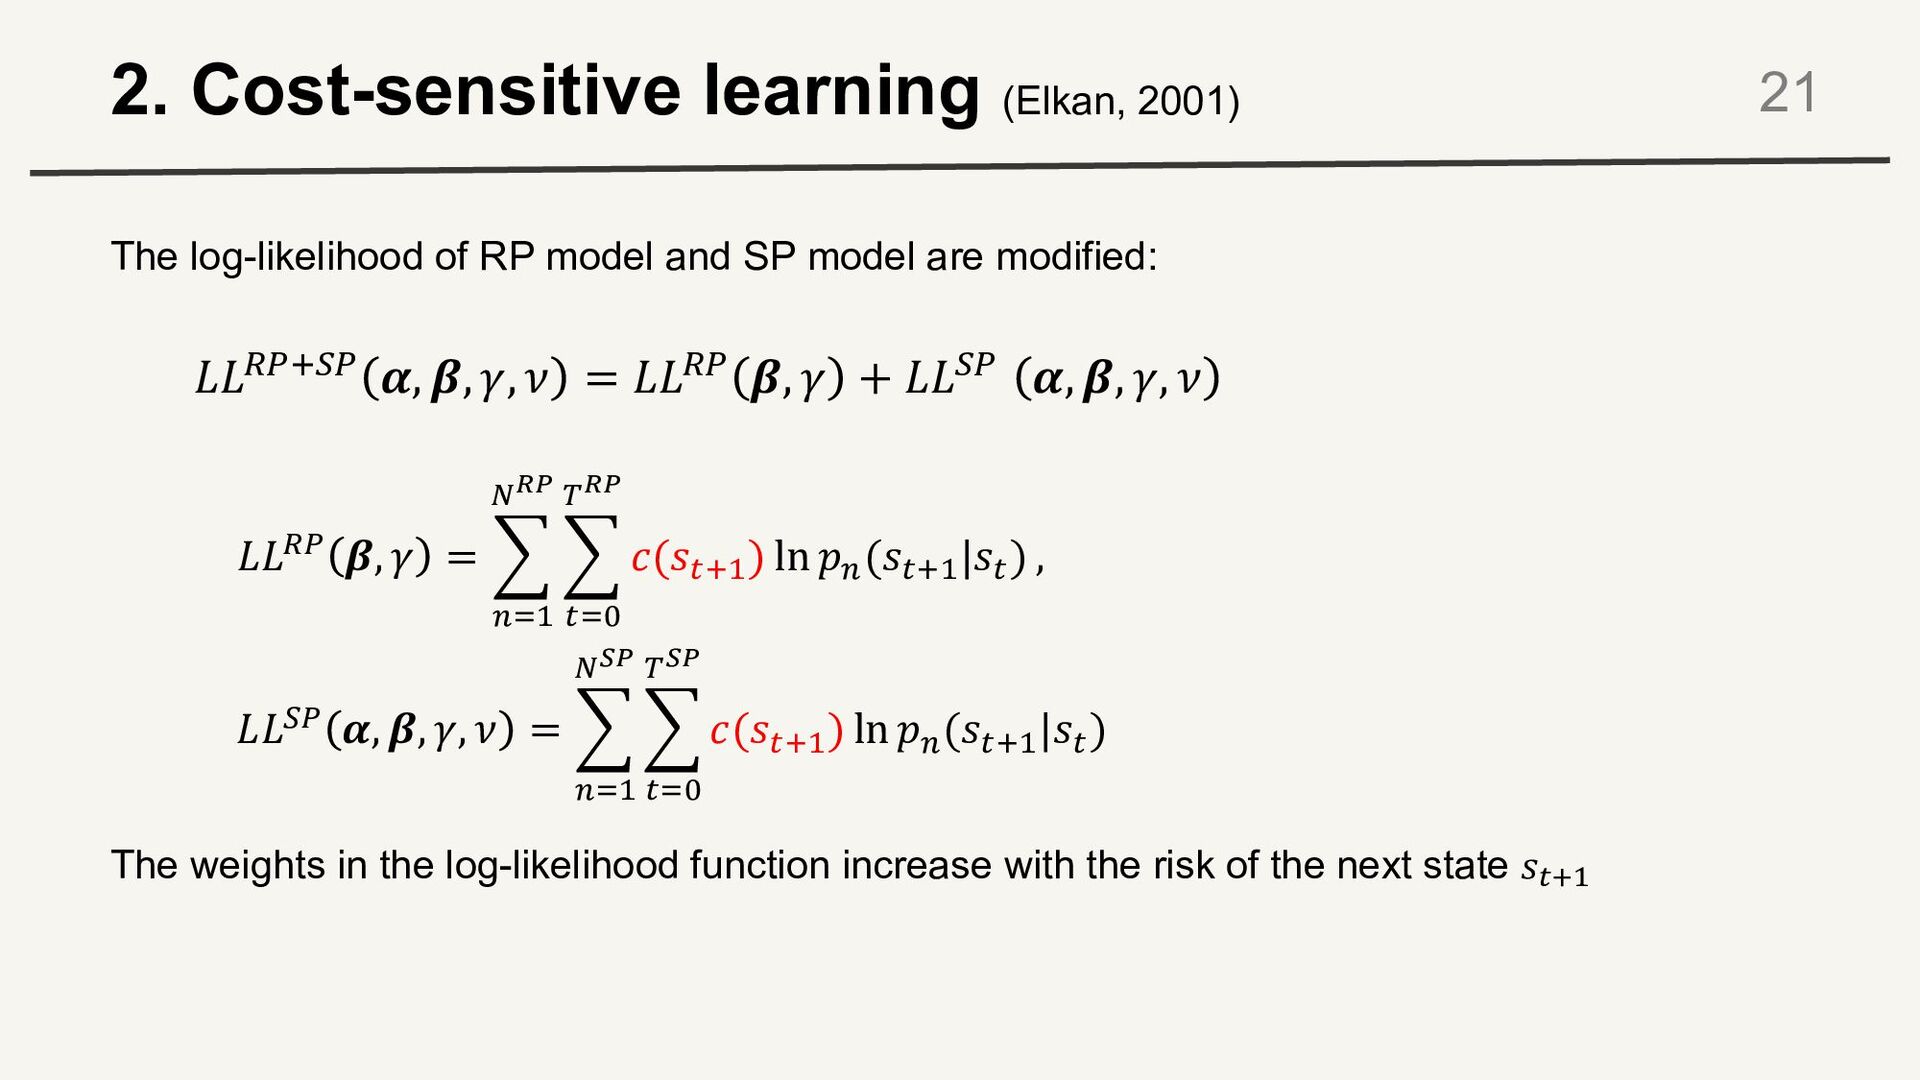
2. Cost-sensitive learning (Elkan, 2001) 21 The log-likelihood of RP
model and SP model are modified: >>GH.IH 8, 5, (, = = >>GH 5, ( + >>IH 8, 5, (, = !!!" ", $ = & #$% &*+ & '$( )*+ 0(+'*% ) ln )# (+'*% |+' ) , !!+" ., ", $, / = & #$% &,+ & '$( ),+ 0(+'*% ) ln )# (+'*% |+' ) The weights in the log-likelihood function increase with the risk of the next state !!%& -
Weighted RP/SP combined estimation 22 Evacuation behavior behaviors specific to
SP data = normalcy bias common attributes of RP and SP data victims’ behaviors survivors’ behaviors RP data SP data Proposed estimation method ✅ RP/SP combined estimation ✅ Weighting high-risk behaviors (cost-sensitive learning) -
Table of contents 1. Introduction - Challenges for evacuation behavioral
models • Missing data • Transferability 2. Modeling - A dynamic activity scheduling model for evacuation 3. Estimation - Weighted RP/SP combined estimation 4. Numerical experiment 5. Empirical analysis 23 -
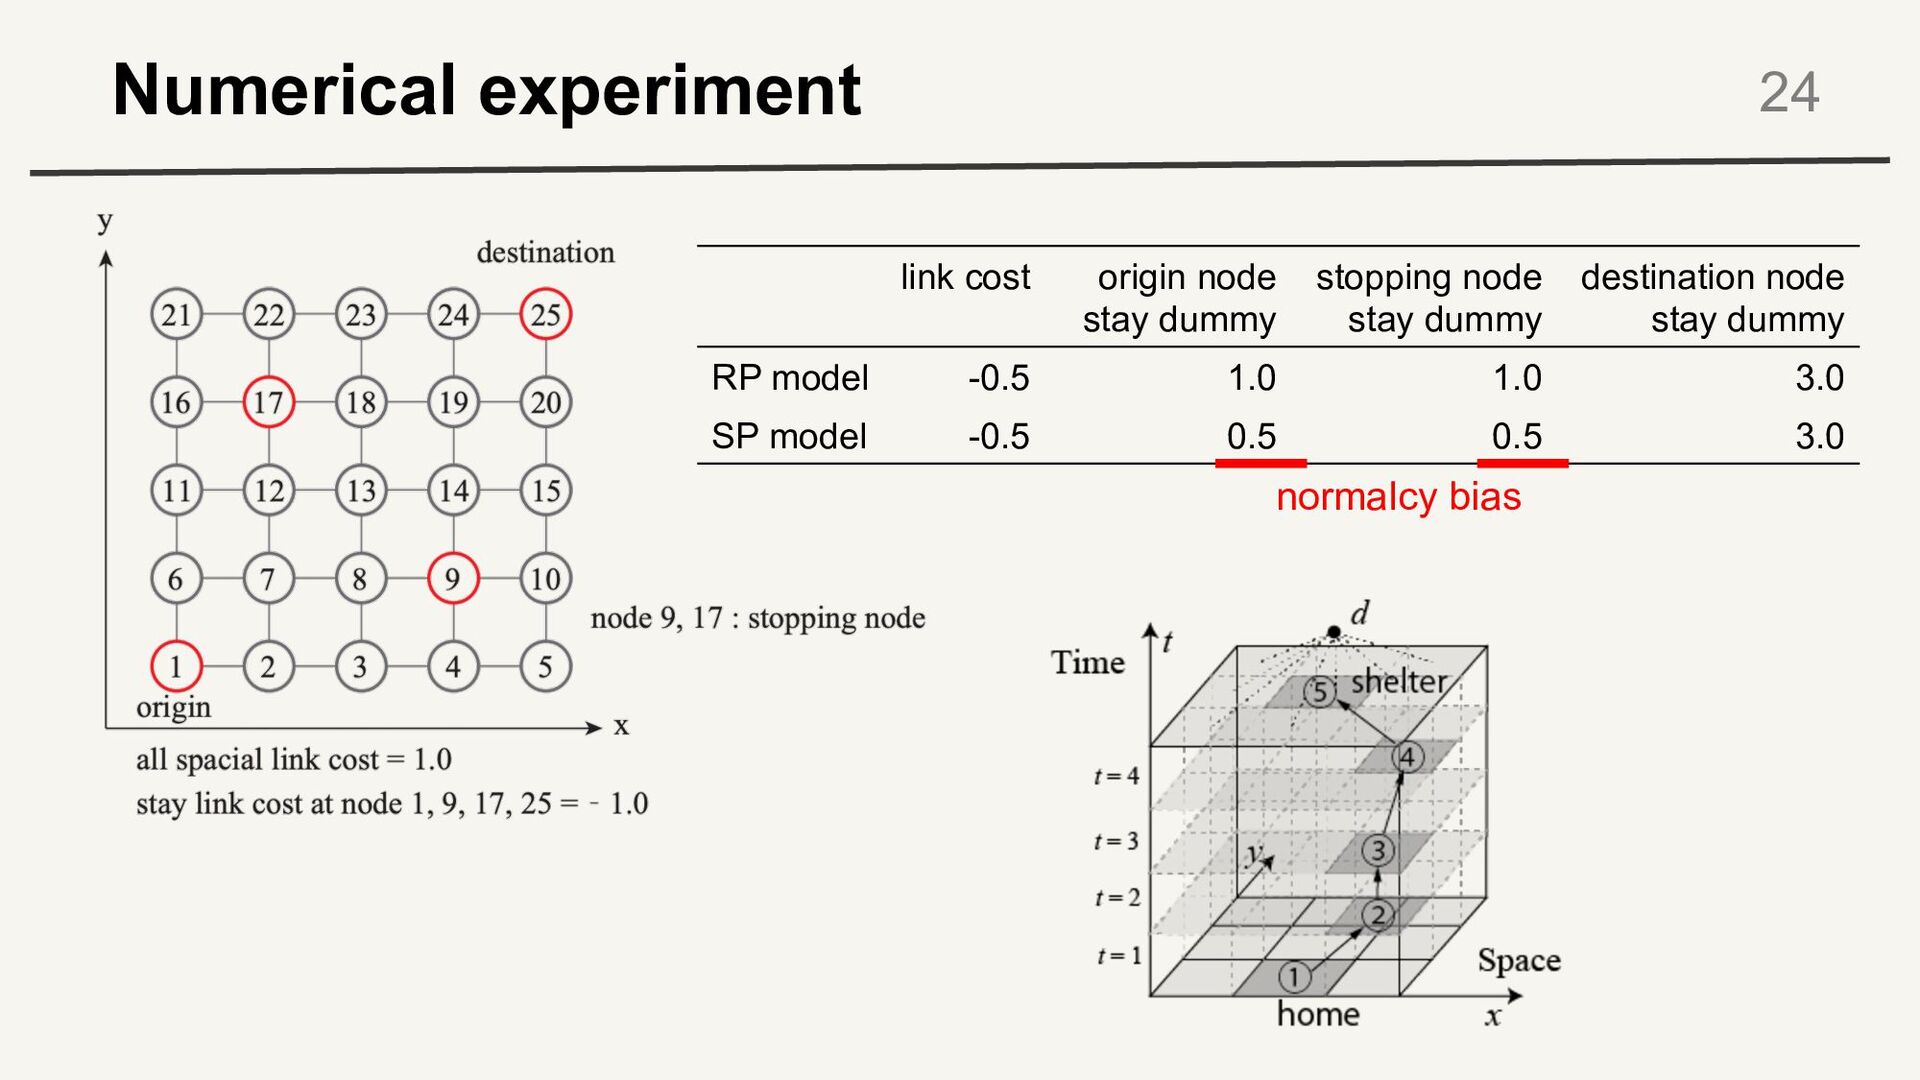
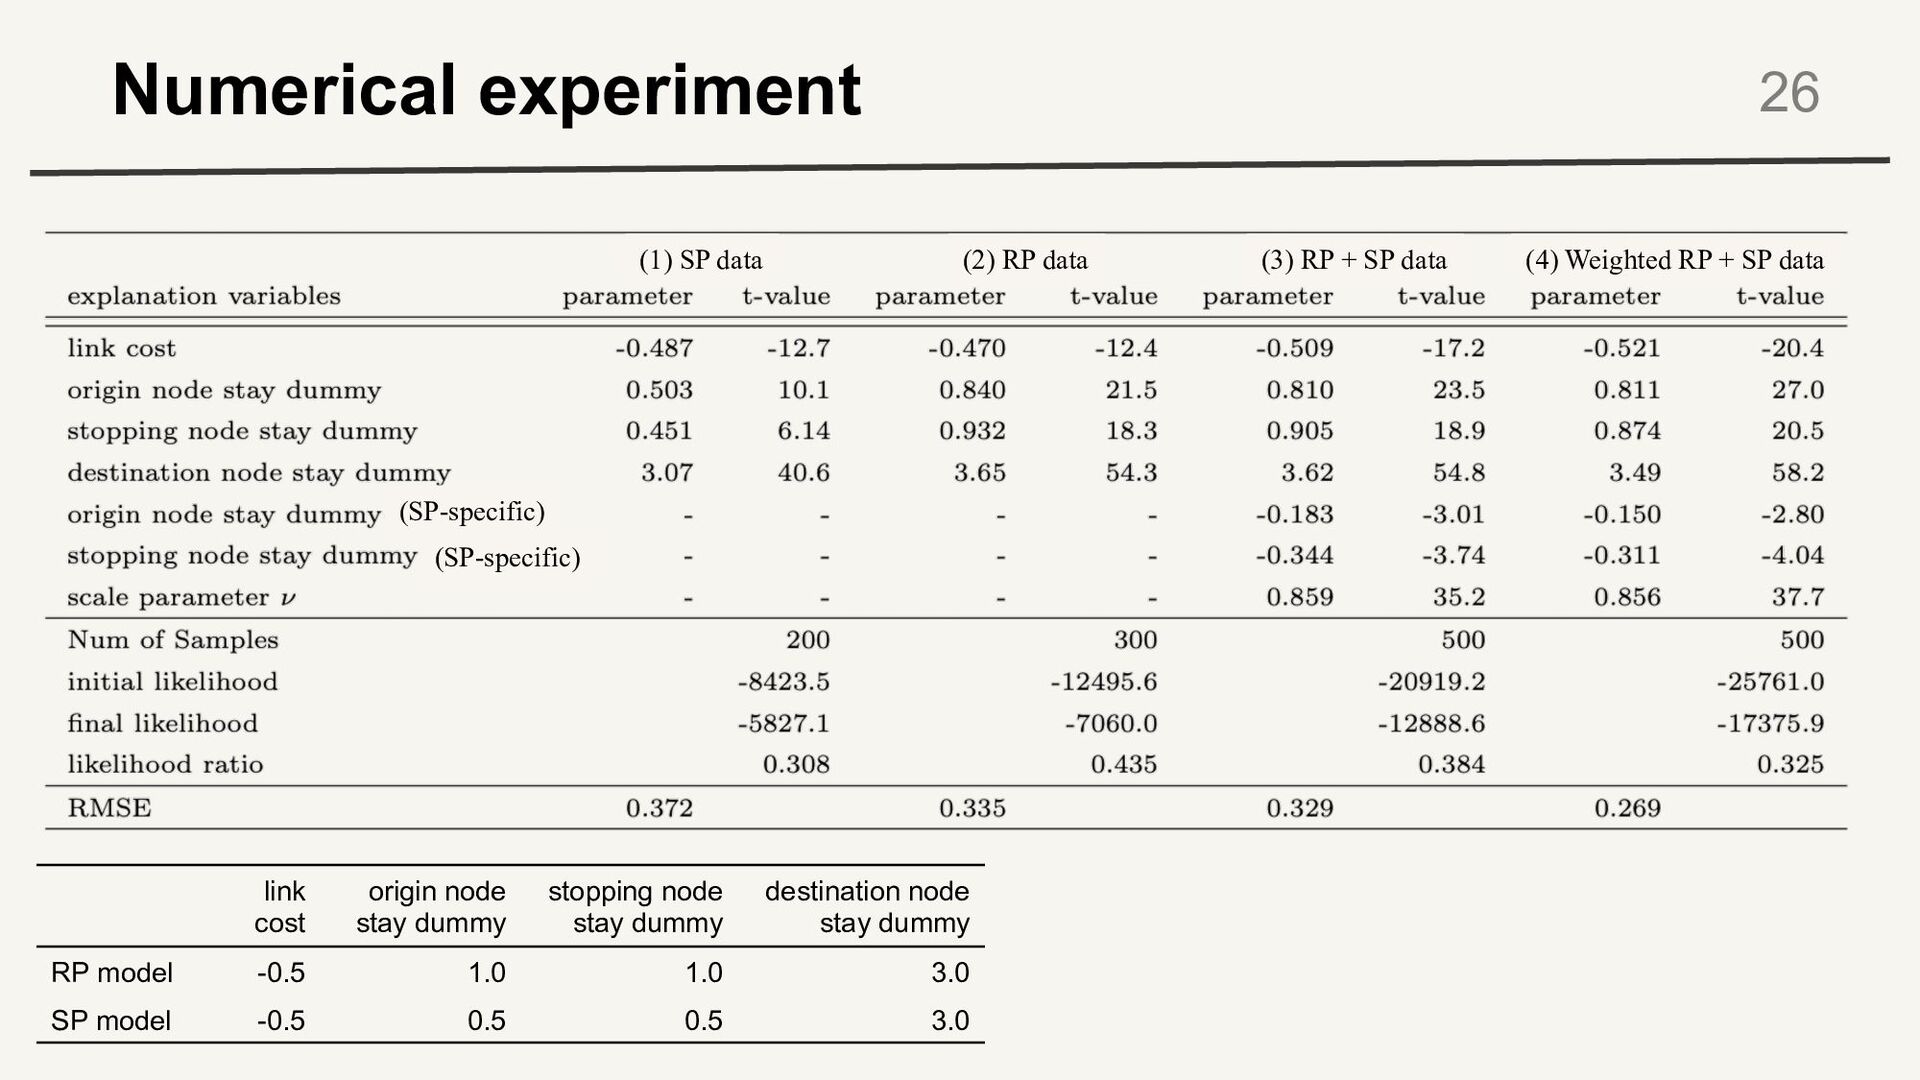
Numerical experiment 24 link cost origin node stay dummy stopping
node stay dummy destination node stay dummy RP model -0.5 1.0 1.0 3.0 SP model -0.5 0.5 0.5 3.0 normalcy bias -
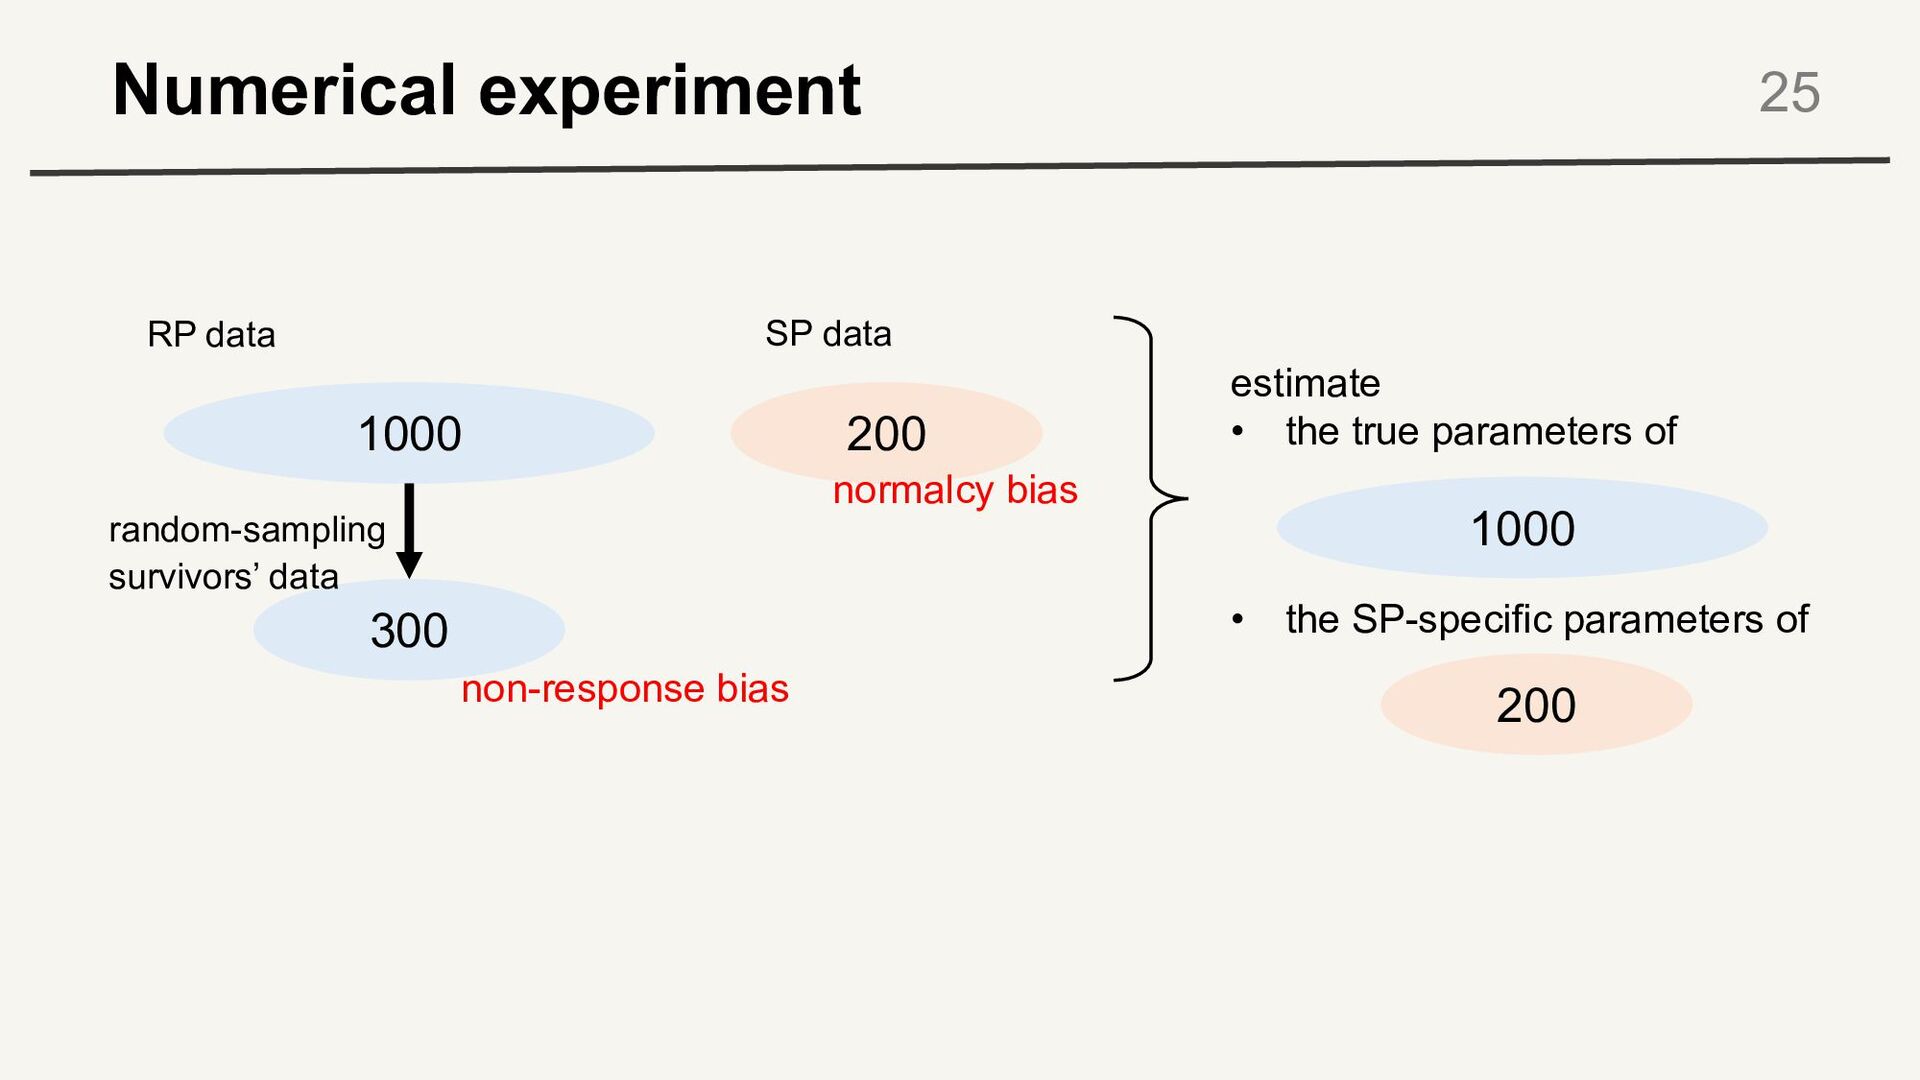
Numerical experiment 25 RP data SP data 1000 300 survivors’
data 200 estimate • the true parameters of normalcy bias non-response bias 1000 • the SP-specific parameters of 200 random-sampling -
Numerical experiment 26 (1) SP data (2) RP data (3)
RP + SP data (4) Weighted RP + SP data (SP-specific) (SP-specific) link cost origin node stay dummy stopping node stay dummy destination node stay dummy RP model -0.5 1.0 1.0 3.0 SP model -0.5 0.5 0.5 3.0 -
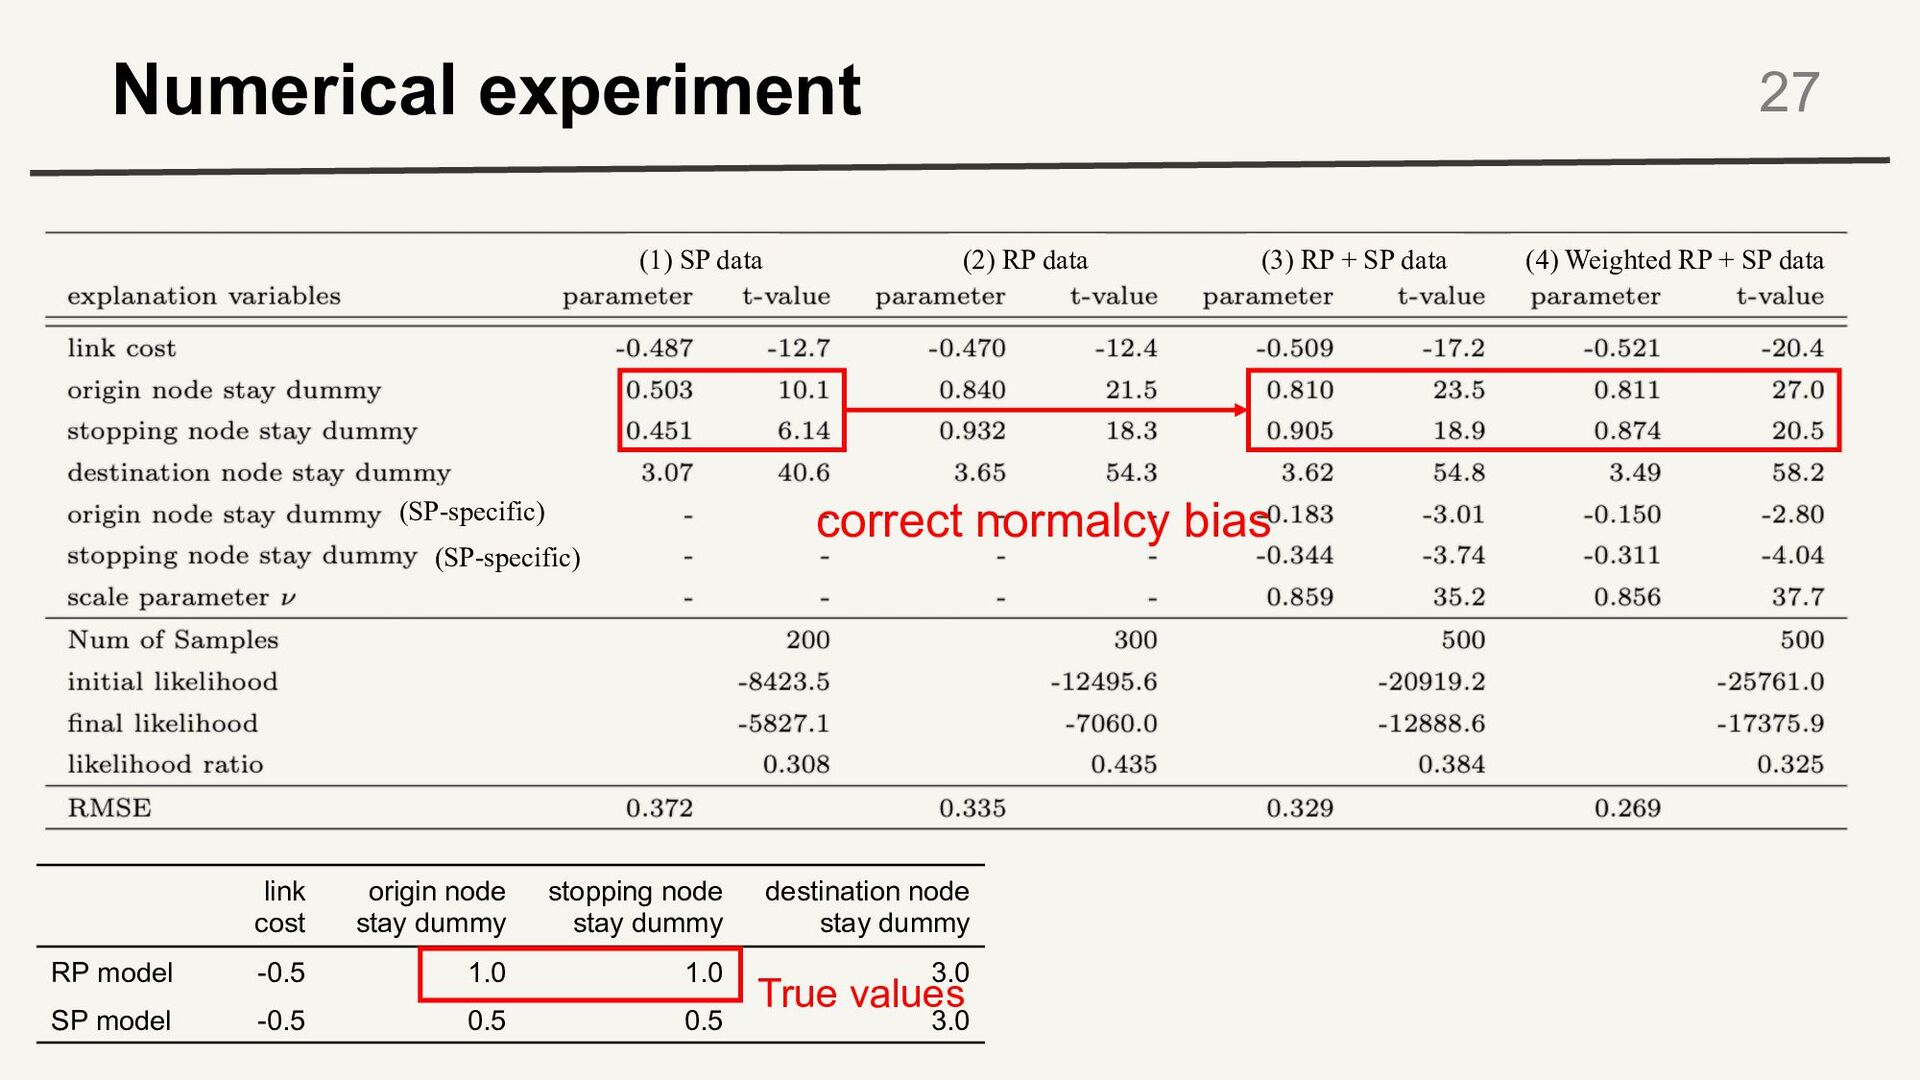
Numerical experiment 27 (1) SP data (2) RP data (3)
RP + SP data (4) Weighted RP + SP data (SP-specific) (SP-specific) link cost origin node stay dummy stopping node stay dummy destination node stay dummy RP model -0.5 1.0 1.0 3.0 SP model -0.5 0.5 0.5 3.0 correct normalcy bias True values -
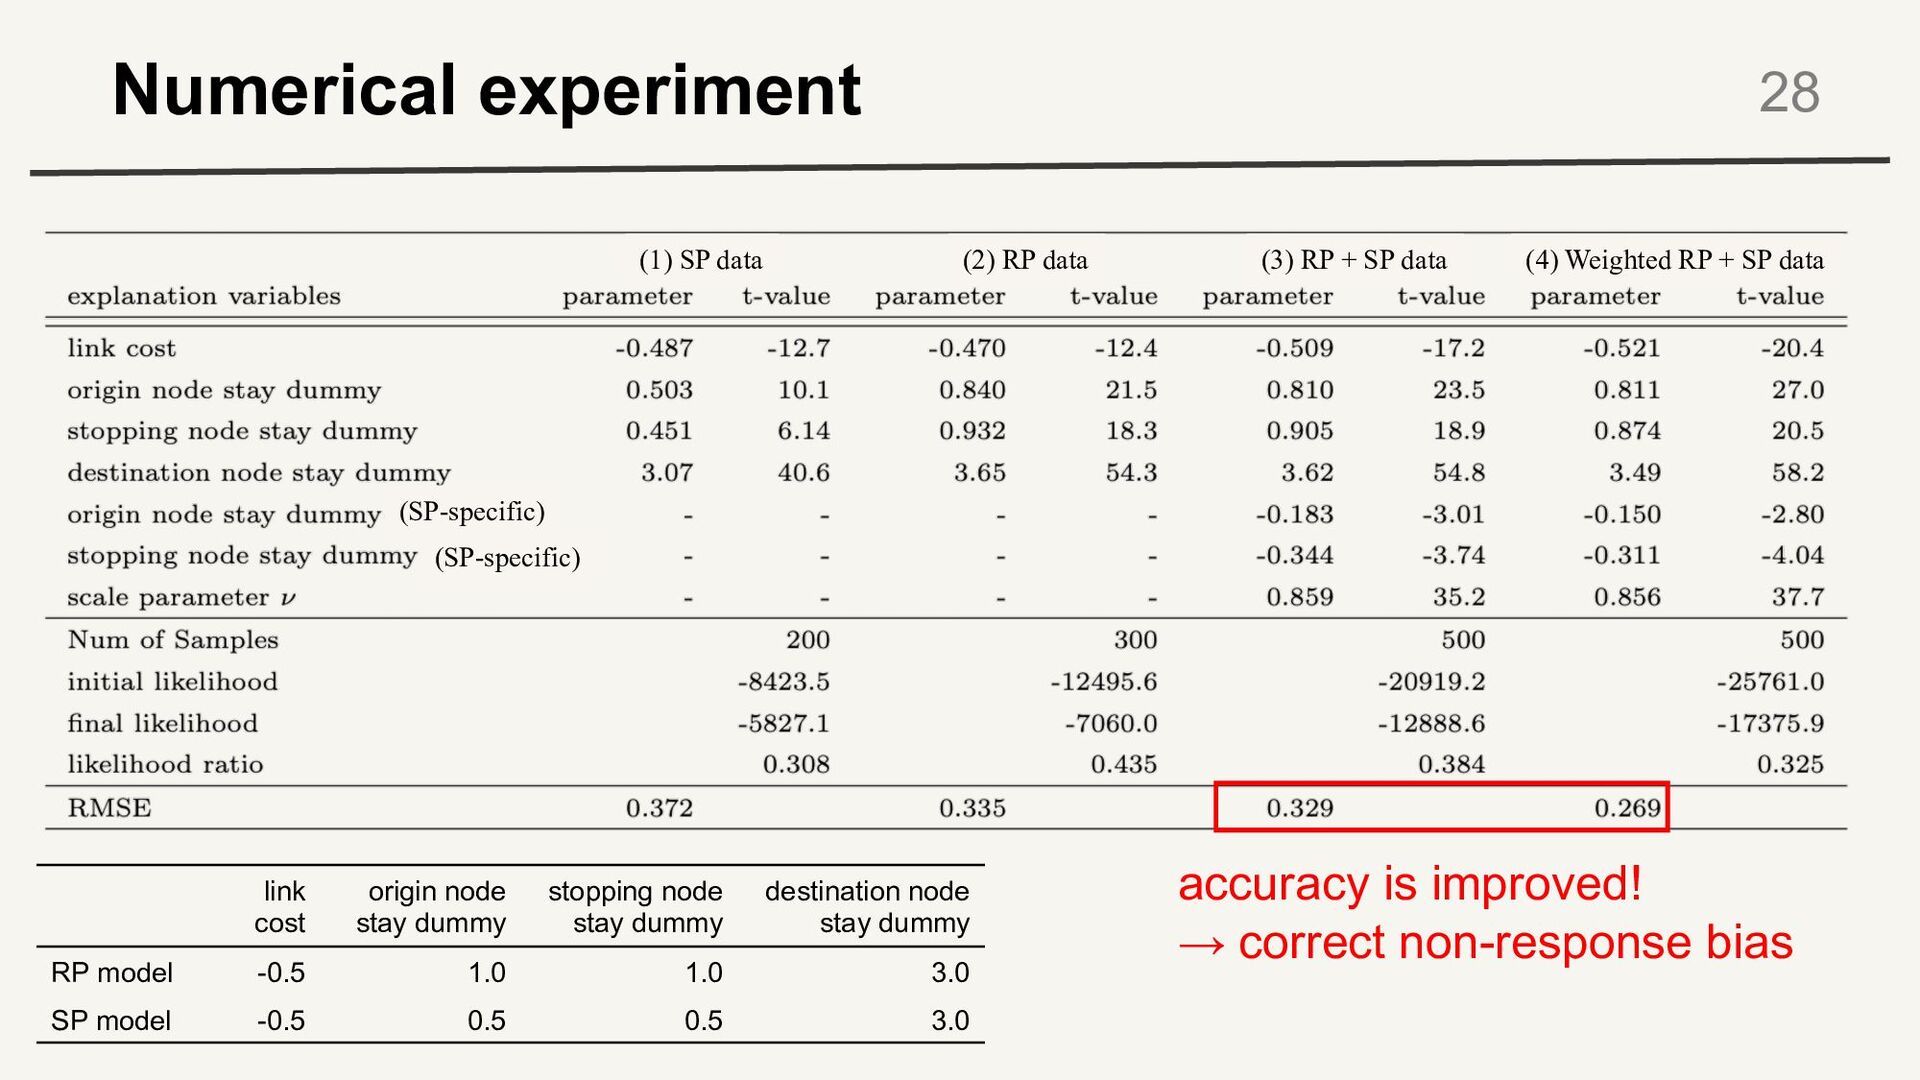
Numerical experiment 28 (1) SP data (2) RP data (3)
RP + SP data (4) Weighted RP + SP data (SP-specific) (SP-specific) link cost origin node stay dummy stopping node stay dummy destination node stay dummy RP model -0.5 1.0 1.0 3.0 SP model -0.5 0.5 0.5 3.0 accuracy is improved! → correct non-response bias -
Table of contents 1. Introduction - Challenges for evacuation behavioral
models • Missing data • Transferability 2. Modeling - A dynamic activity scheduling model for evacuation 3. Estimation - Weighted RP/SP combined estimation 4. Numerical experiment 5. Empirical analysis 29 -
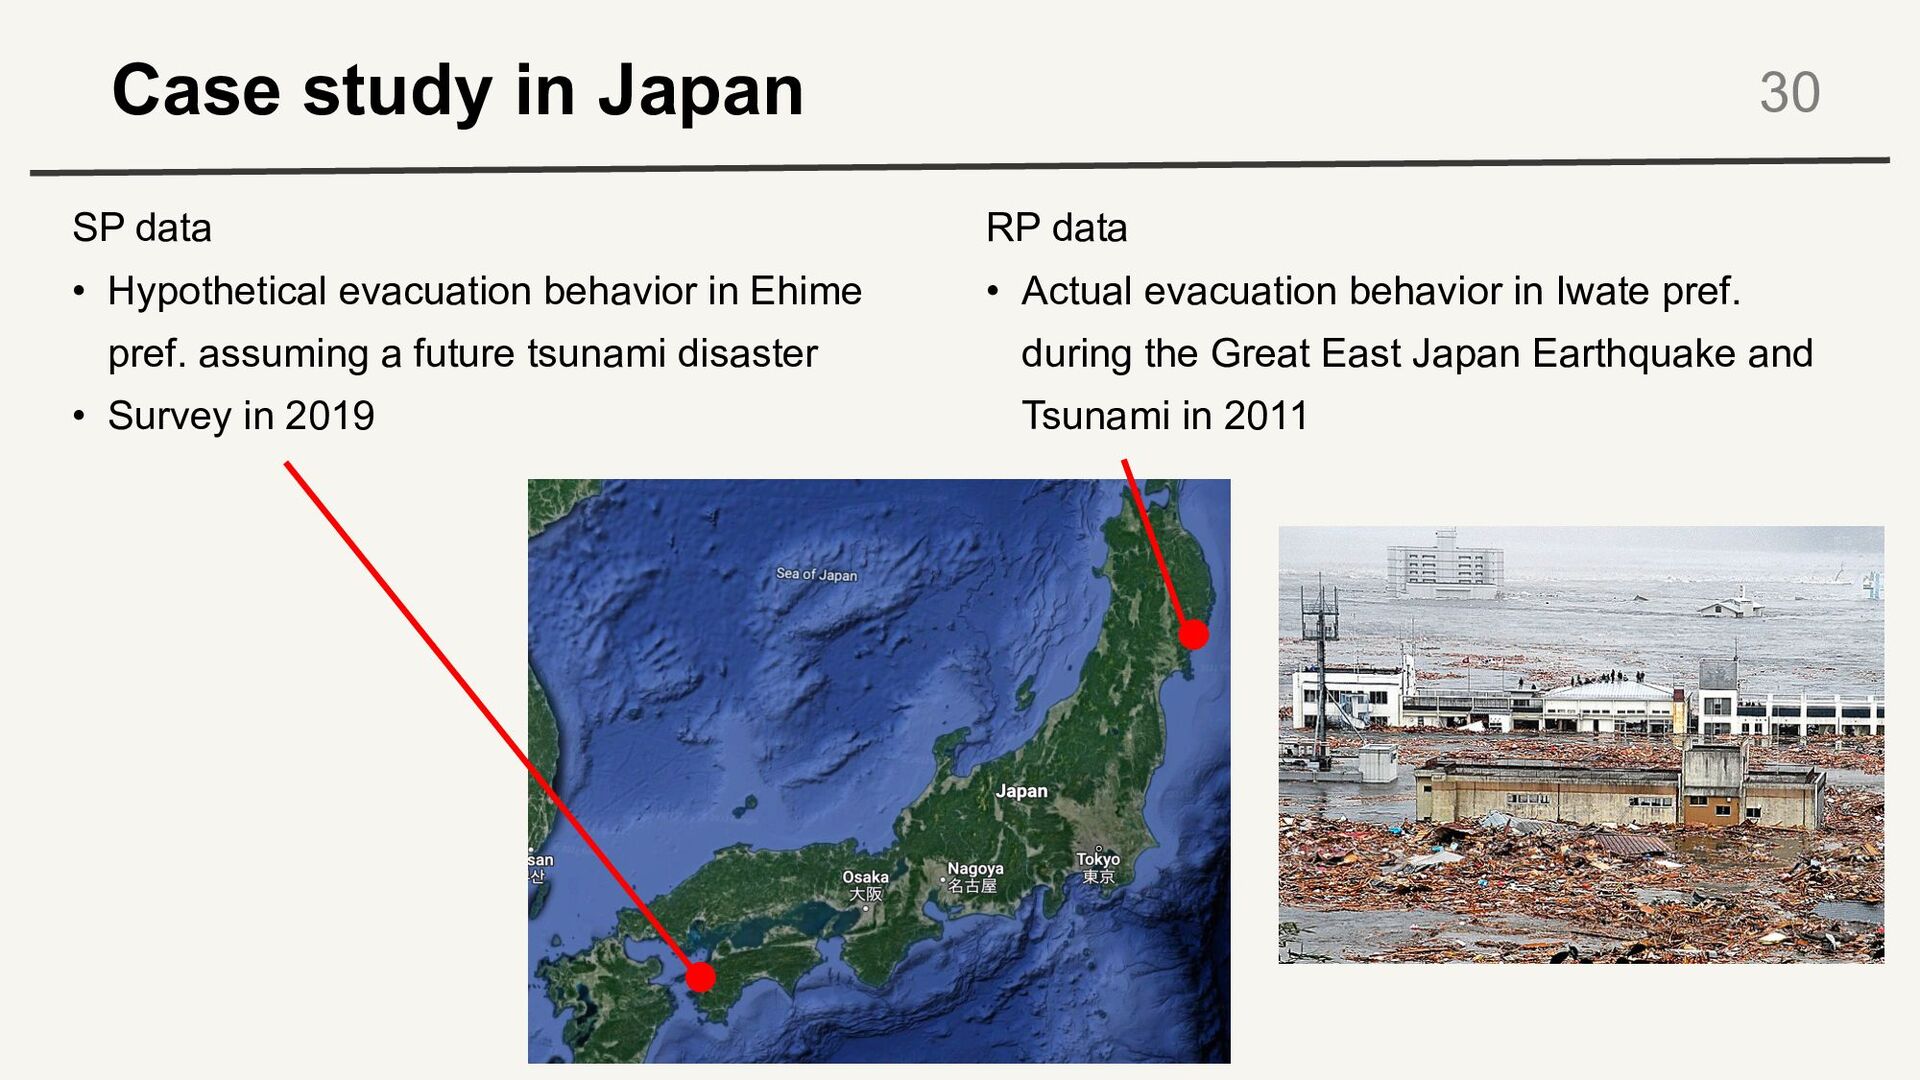
Case study in Japan 30 RP data • Actual evacuation
behavior in Iwate pref. during the Great East Japan Earthquake and Tsunami in 2011 SP data • Hypothetical evacuation behavior in Ehime pref. assuming a future tsunami disaster • Survey in 2019 -
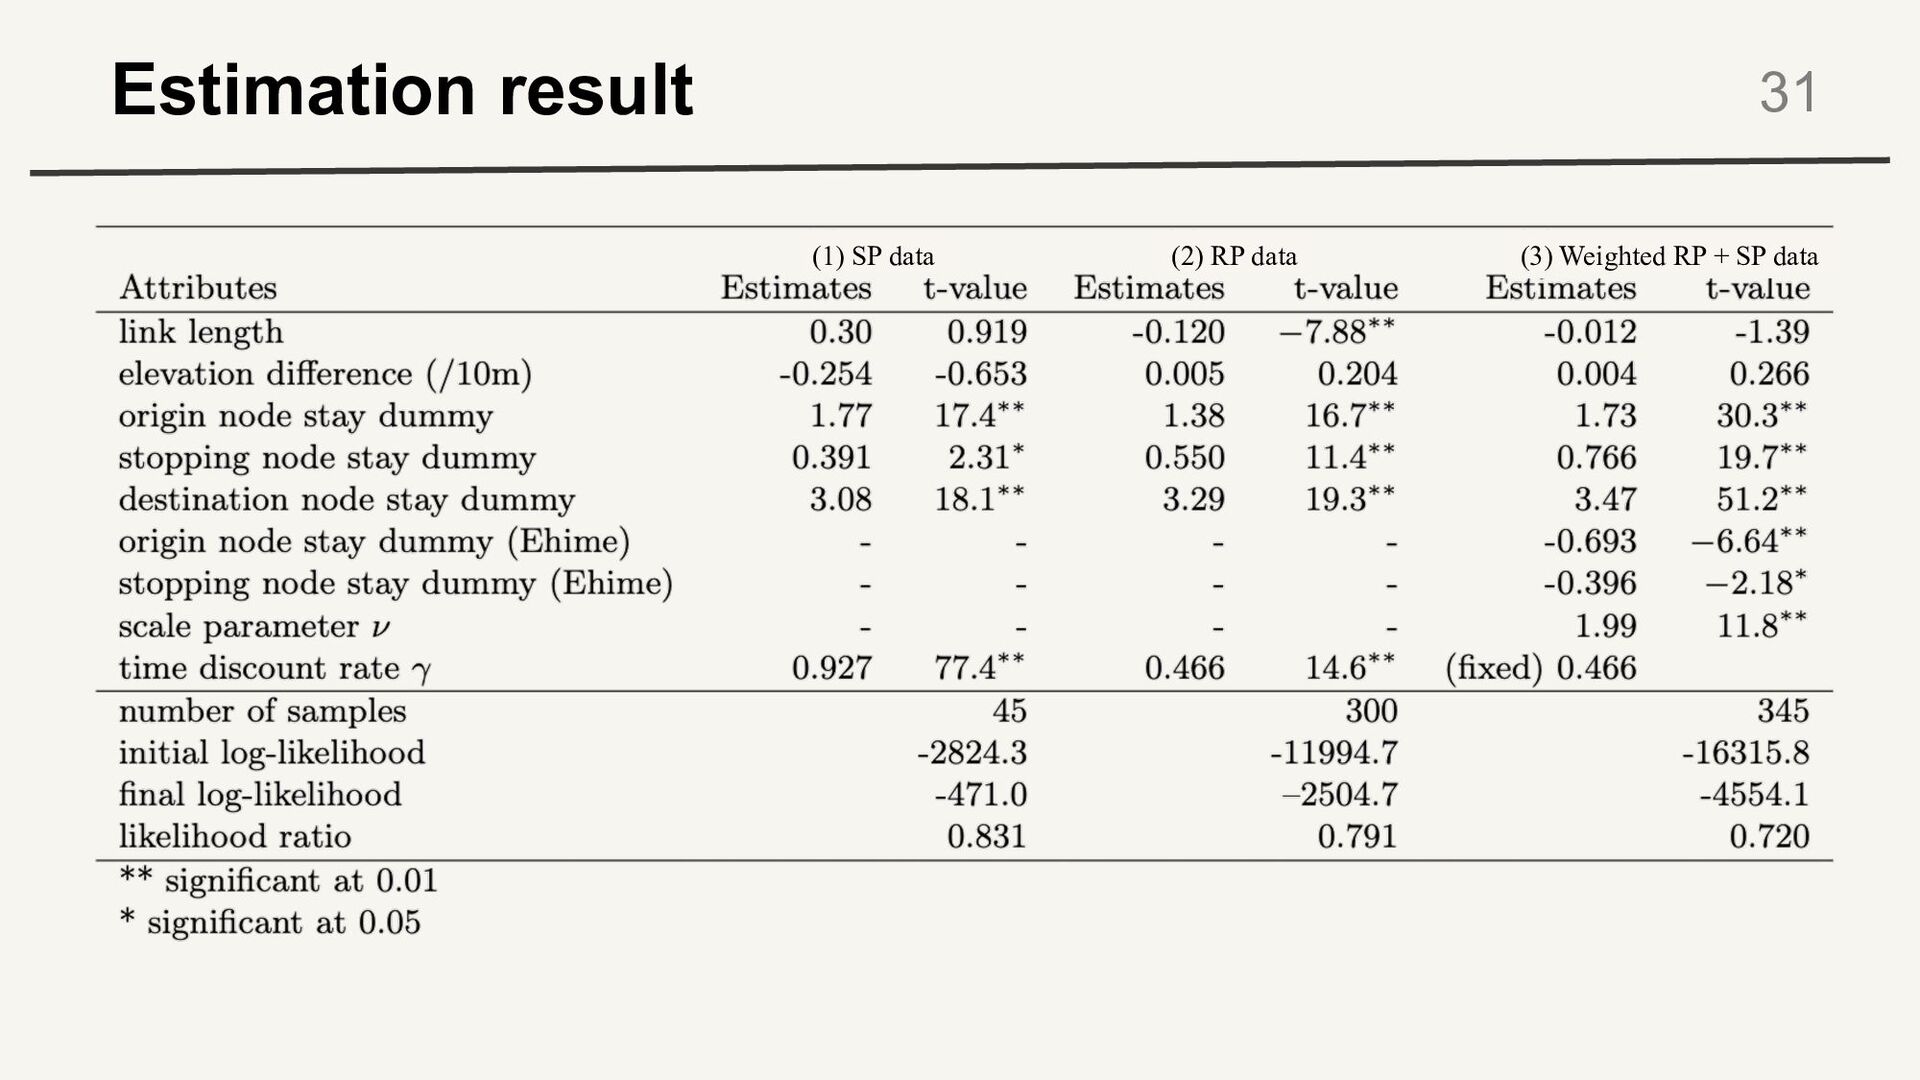
Estimation result 31 (1) SP data (2) RP data (3)
Weighted RP + SP data -
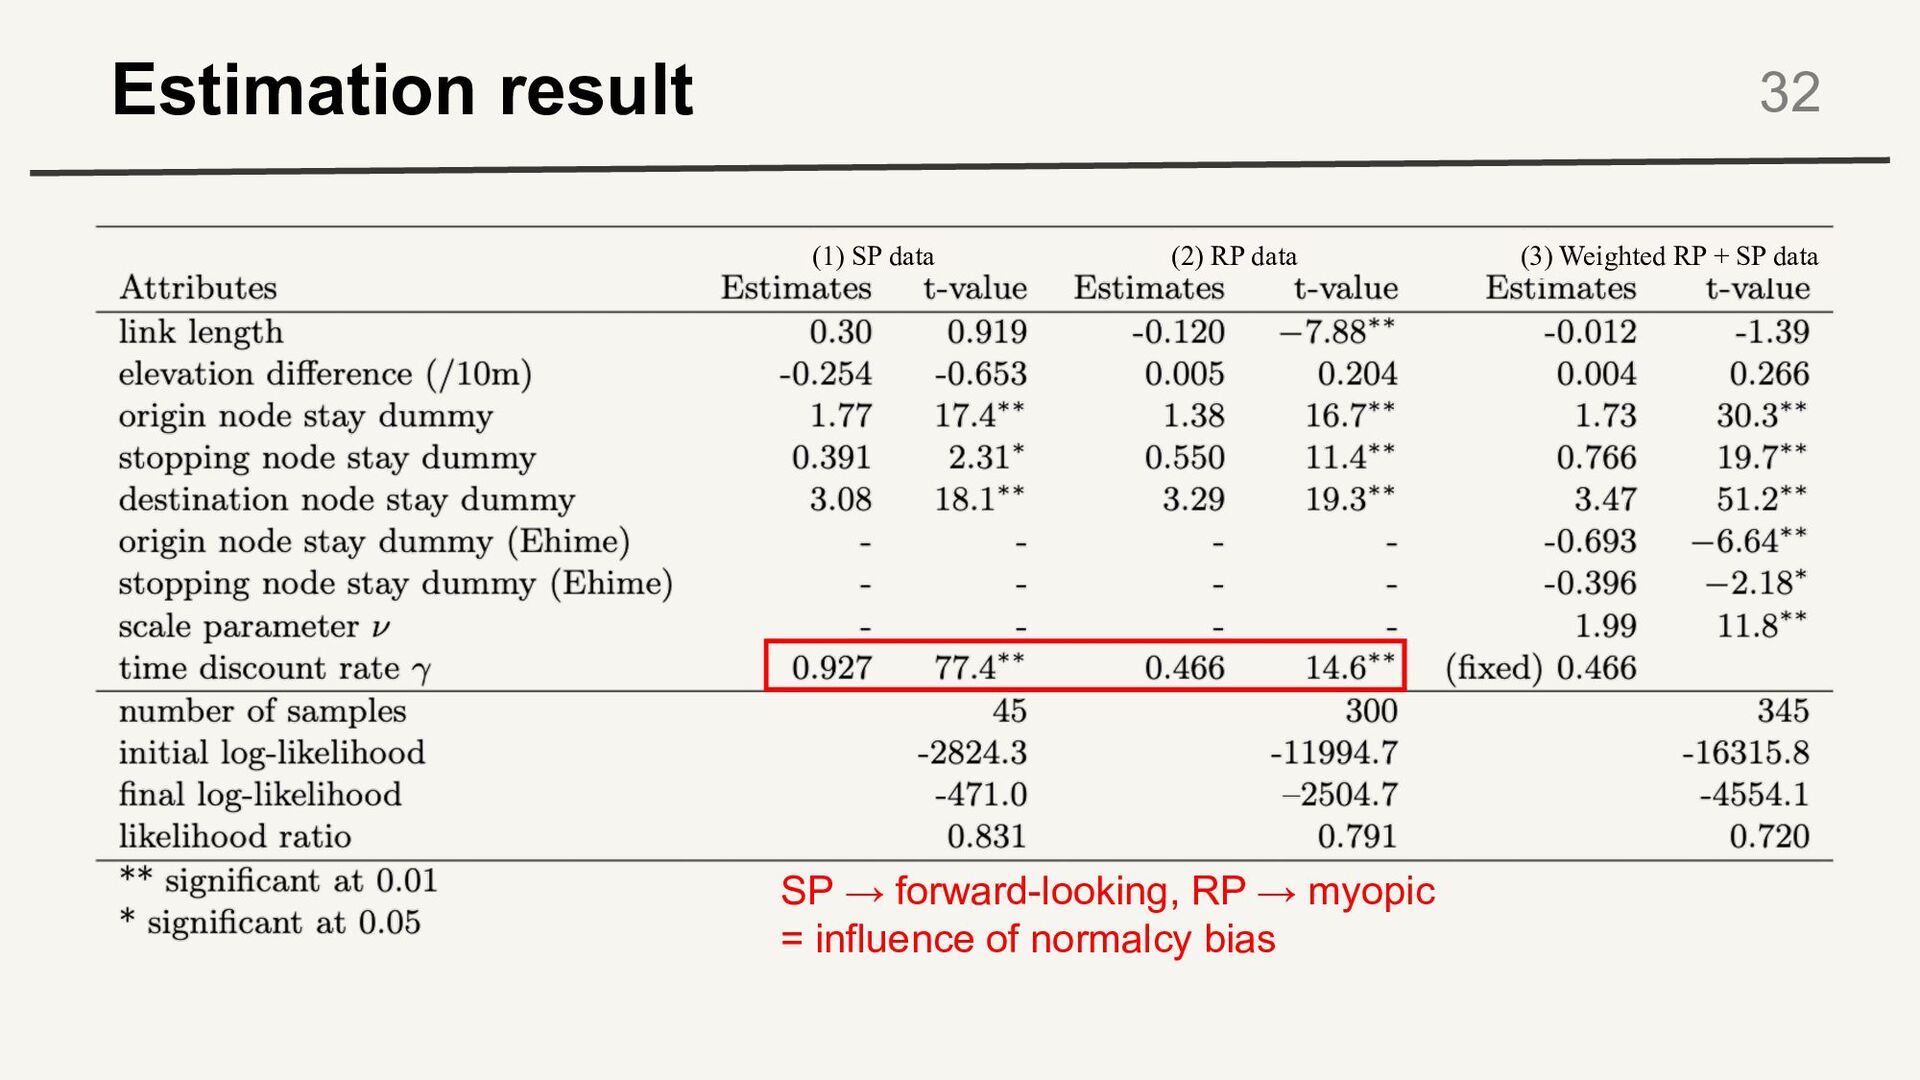
Estimation result 32 (1) SP data (2) RP data (3)
Weighted RP + SP data SP → forward-looking, RP → myopic = influence of normalcy bias -
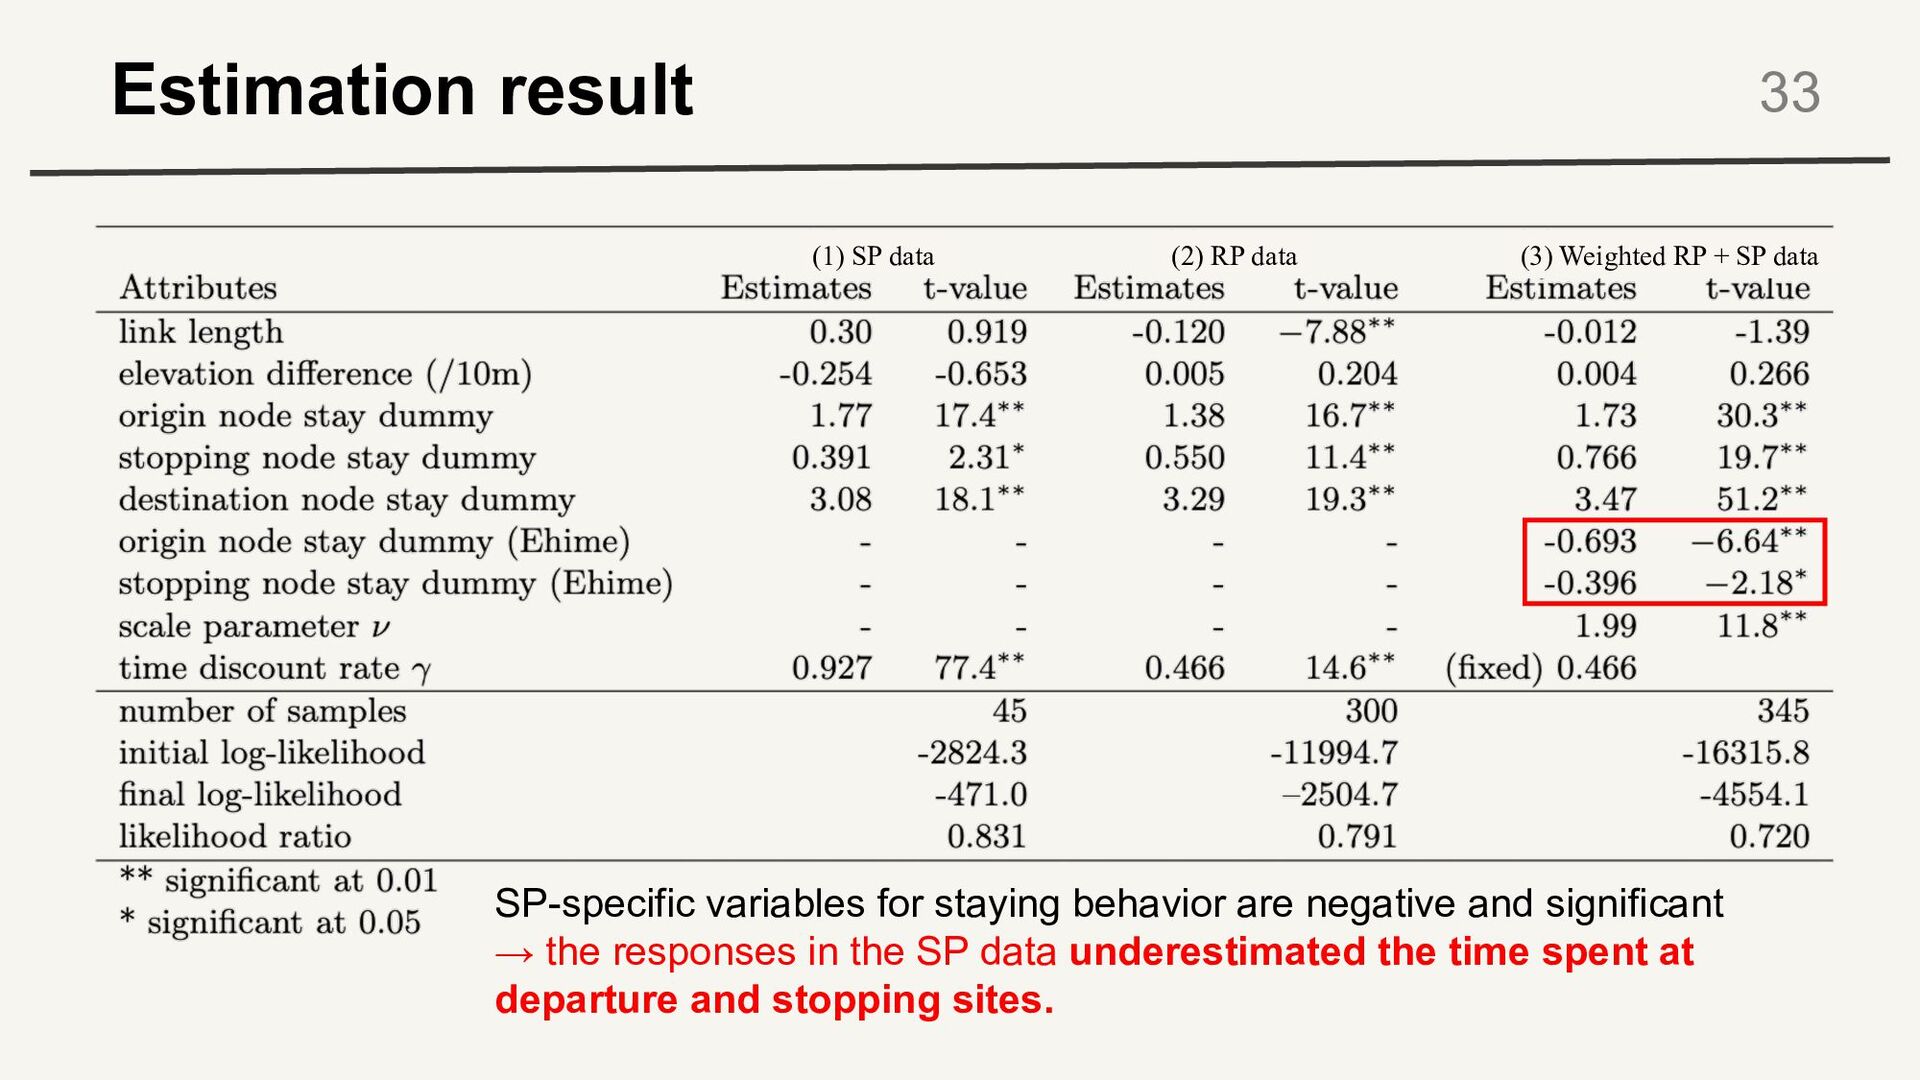
Estimation result 33 (1) SP data (2) RP data (3)
Weighted RP + SP data SP-specific variables for staying behavior are negative and significant → the responses in the SP data underestimated the time spent at departure and stopping sites. -
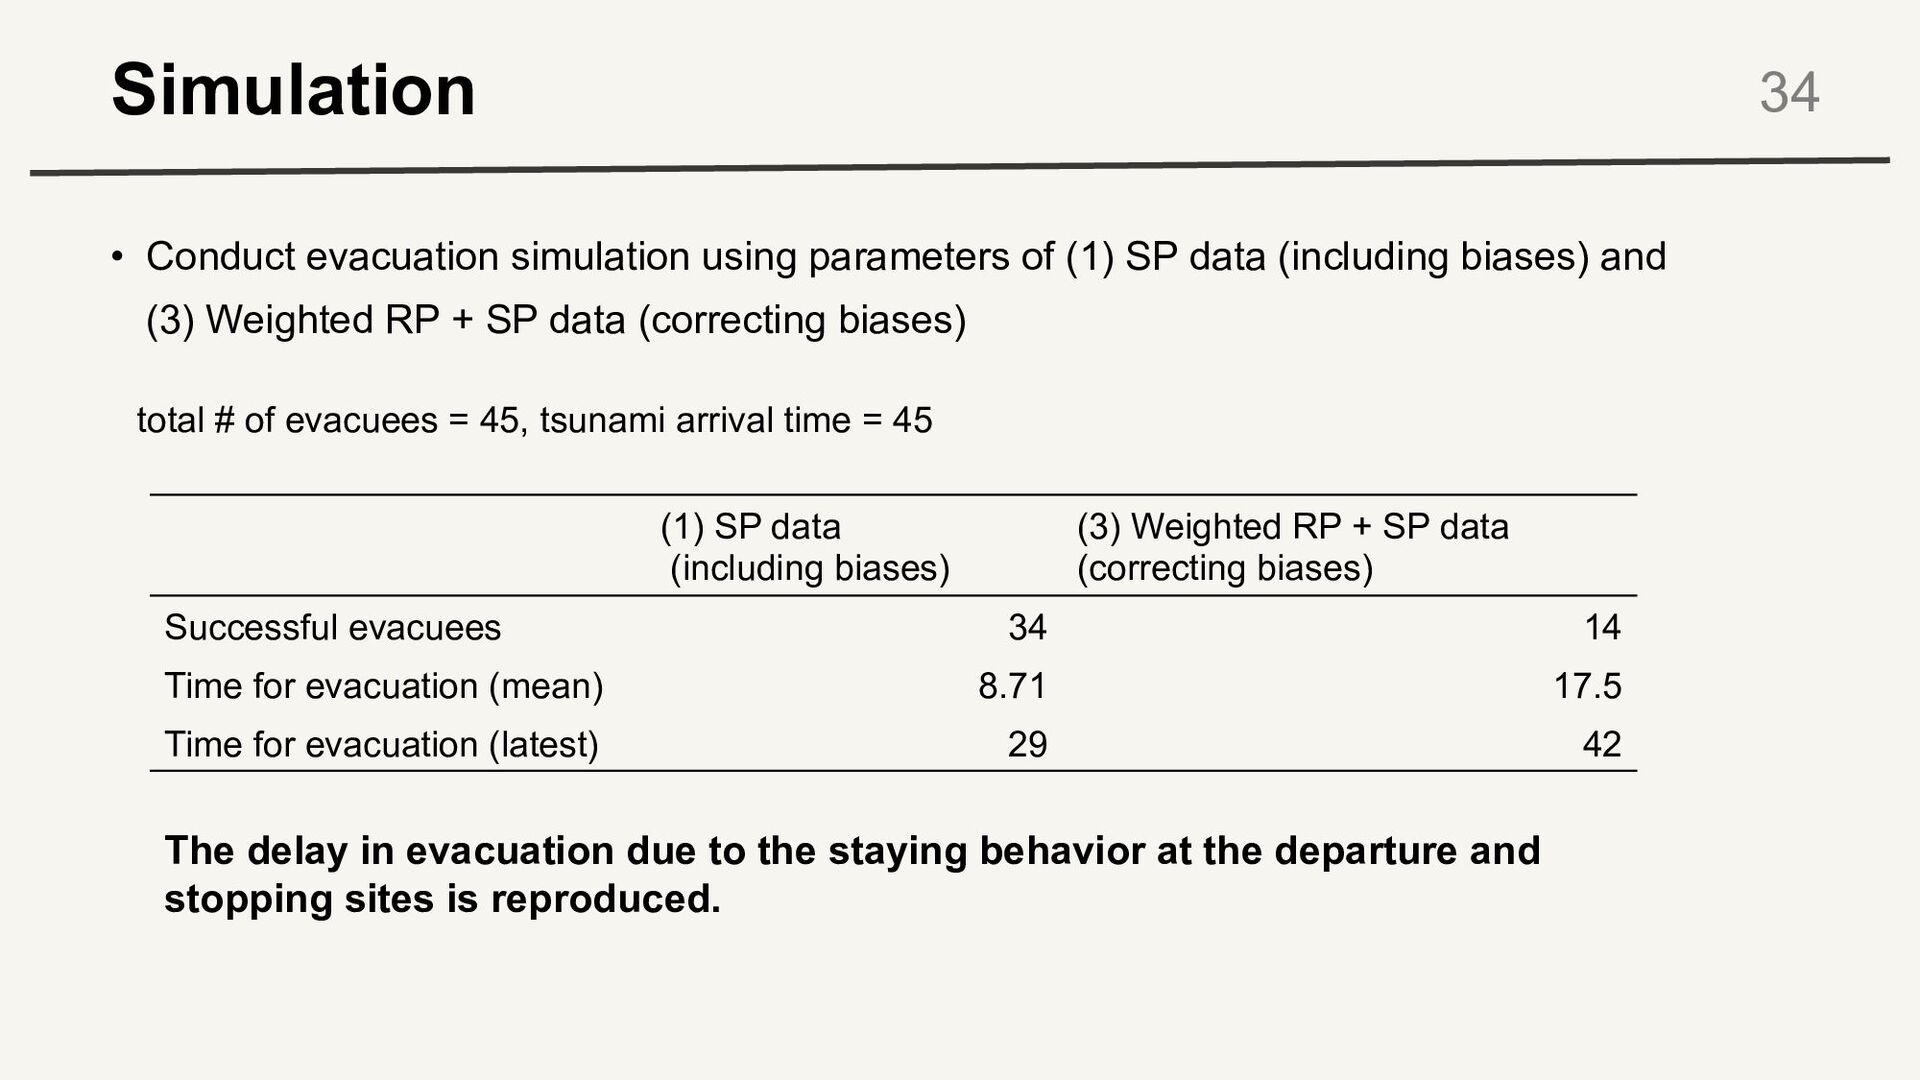
Simulation • Conduct evacuation simulation using parameters of (1) SP
data (including biases) and (3) Weighted RP + SP data (correcting biases) 34 (1) SP data (including biases) (3) Weighted RP + SP data (correcting biases) Successful evacuees 34 14 Time for evacuation (mean) 8.71 17.5 Time for evacuation (latest) 29 42 total # of evacuees = 45, tsunami arrival time = 45 The delay in evacuation due to the staying behavior at the departure and stopping sites is reproduced. -
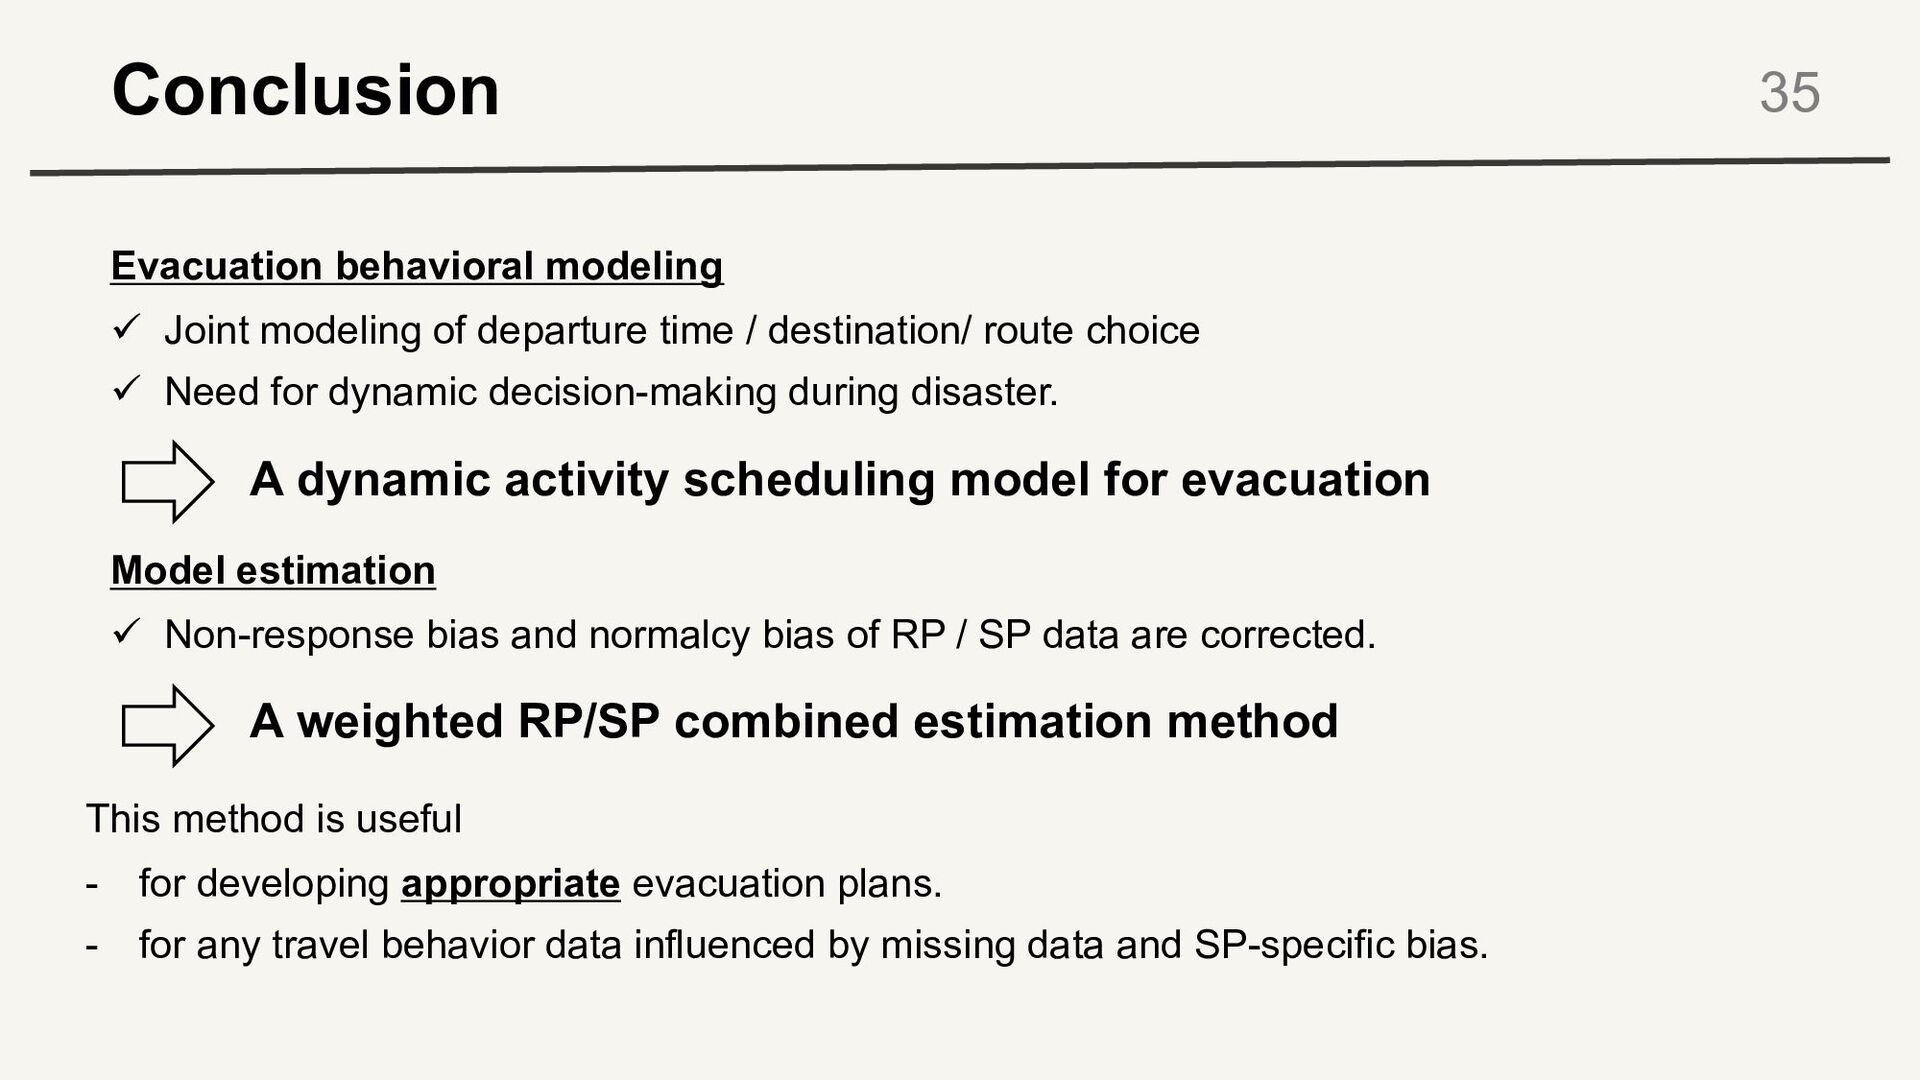
Conclusion 35 Evacuation behavioral modeling ü Joint modeling of departure
time / destination/ route choice ü Need for dynamic decision-making during disaster. Model estimation ü Non-response bias and normalcy bias of RP / SP data are corrected. A dynamic activity scheduling model for evacuation A weighted RP/SP combined estimation method This method is useful - for developing appropriate evacuation plans. - for any travel behavior data influenced by missing data and SP-specific bias.