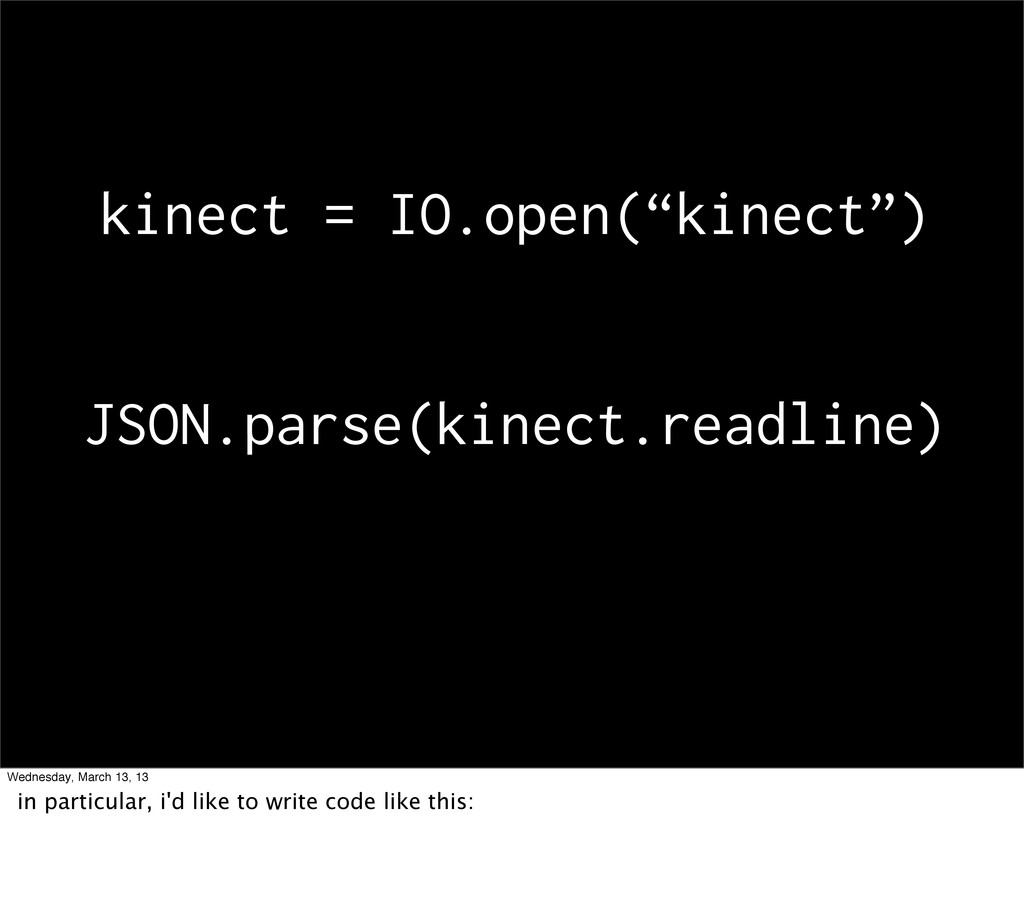
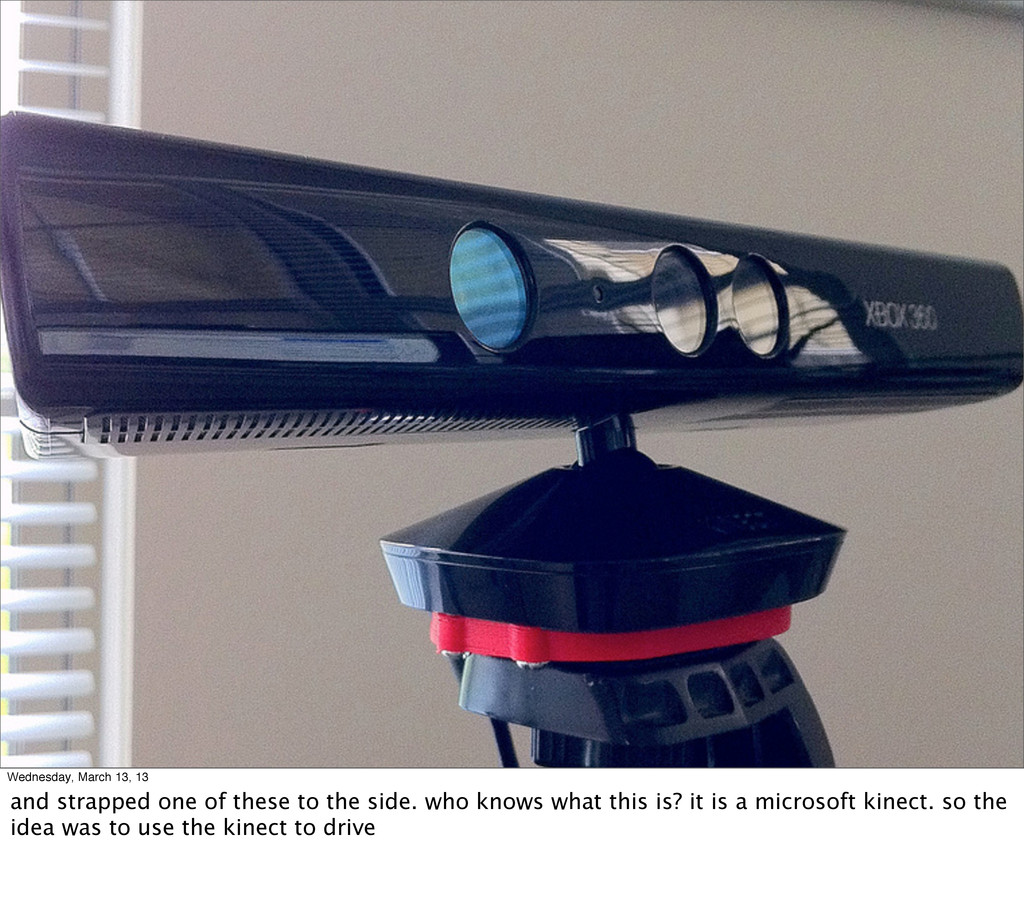
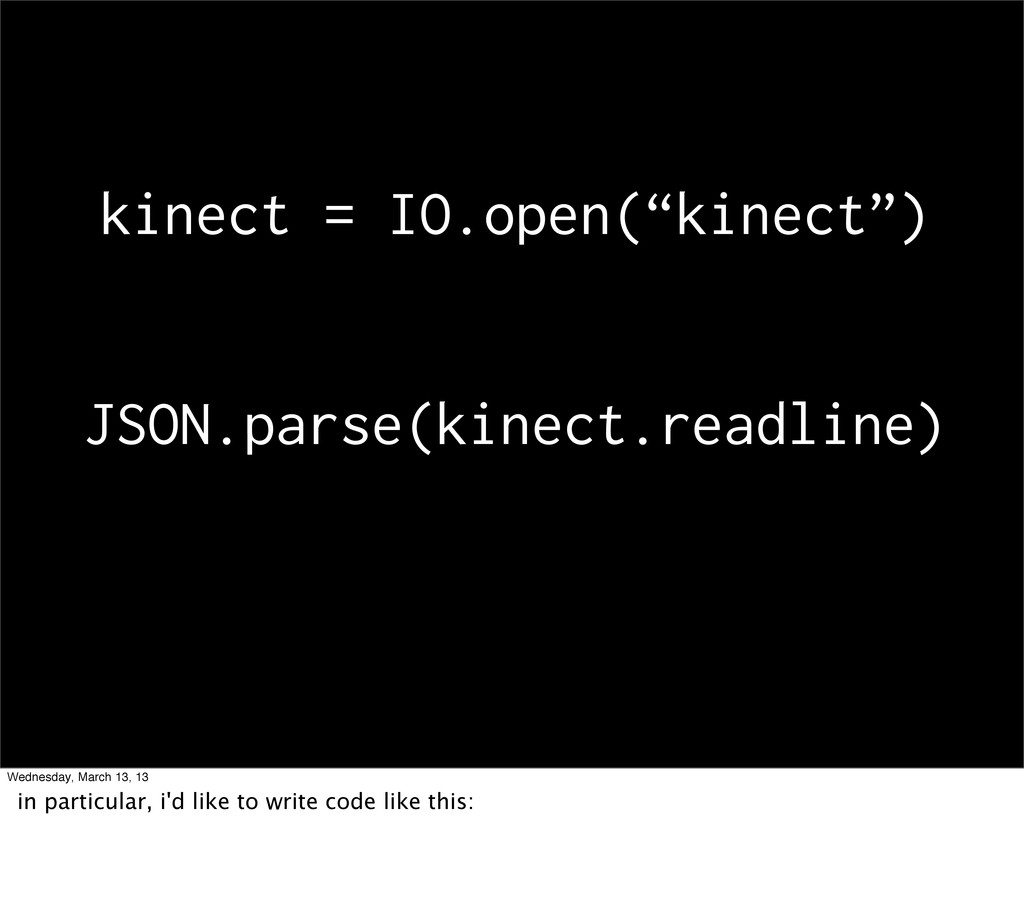
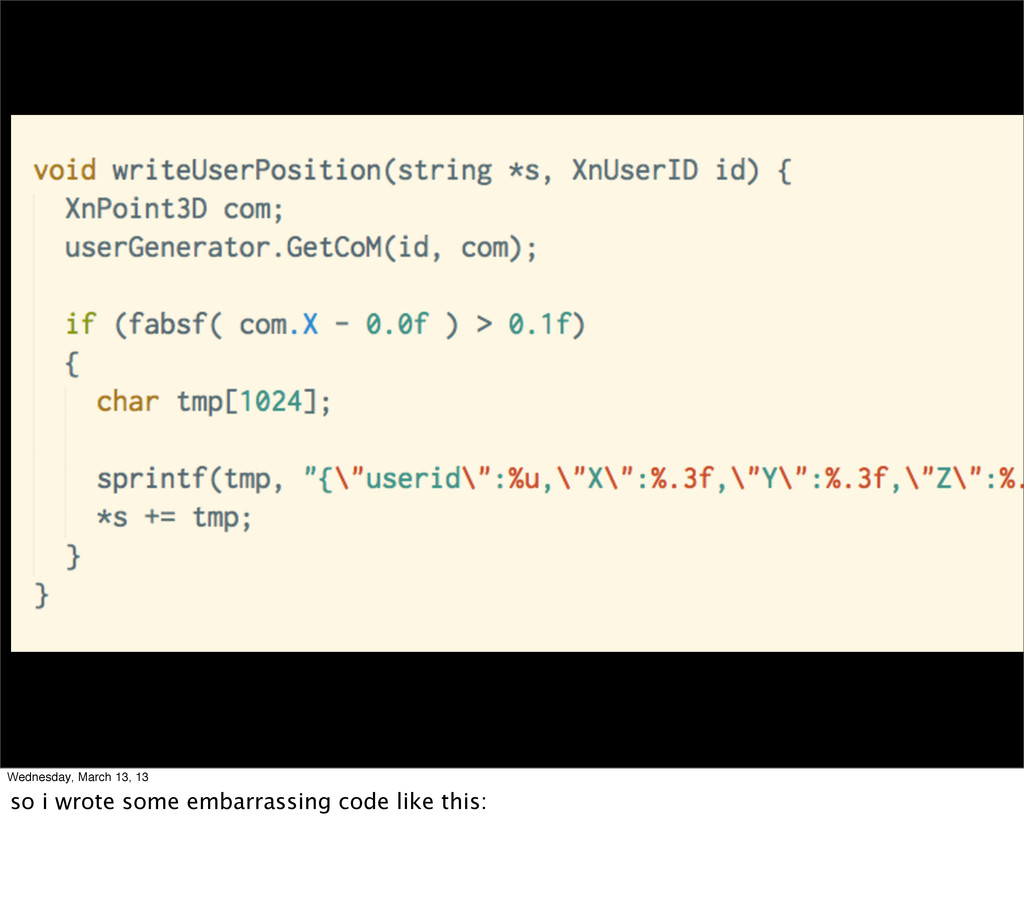
really wanted to release my code under the MIT license. so i needed to solve these two problems so i was thinking that i'd rather treat the kinect under the unix principle of
{"joint":"l_hip","X":-1186.963,"Y":-282.835,"Z":2327.827}, {"joint":"l_knee","X":-907.485,"Y":-726.658,"Z":2194.716}, {"joint":"l_foot","X":-1317.628,"Y":-1062.063,"Z":2362.170}, {"joint":"r_hip","X":-1417.751,"Y":-243.667,"Z":2351.084}, {"joint":"r_knee","X":-1384.755,"Y":-782.376,"Z":2356.604}, {"joint":"r_foot","X":-1126.425,"Y":-548.001,"Z":2231.885}]}],"elapsed":7.745} Wednesday, March 13, 13 so that i could get output like this
{"joint":"l_hip","X":-1186.963,"Y":-282.835,"Z":2327.827}, {"joint":"l_knee","X":-907.485,"Y":-726.658,"Z":2194.716}, {"joint":"l_foot","X":-1317.628,"Y":-1062.063,"Z":2362.170}, {"joint":"r_hip","X":-1417.751,"Y":-243.667,"Z":2351.084}, {"joint":"r_knee","X":-1384.755,"Y":-782.376,"Z":2356.604}, {"joint":"r_foot","X":-1126.425,"Y":-548.001,"Z":2231.885}]}],"elapsed":7.745} Wednesday, March 13, 13 so that i could get output like this


 ryu1013
 sylph01
 ivargrimstad
 dske104
 ichirokano2
 prota
 minodriven
 rshindo
 uyuki234
 kishida
 kasacchiful
 kimpetersen
 inesmontani
 kastner
 addyosmani
 jnunemaker
 tamaranovitovic
 lara
 tessaabrams
 nmsamuel
 tanoku
 maltzj
![{"skeletons":[{"userid":0,"joints":[{"joint":"head","X":-1196.286,"Y":369.161,"Z": 2149.150},{"joint":"neck","X":-1235.722,"Y":191.380,"Z":2235.051}, {"joint":"neck","X":-1235.722,"Y":191.380,"Z":2235.051}, {"joint":"l_shoulder","X":-1182.302,"Y":182.314,"Z":2229.667}, {"joint":"l_elbow","X":-1304.153,"Y":-41.818,"Z":2266.934}, {"joint":"l_hand","X":-1217.129,"Y":-283.542,"Z":2245.302}, {"joint":"r_shoulder","X":-1289.142,"Y":200.446,"Z":2240.434}, {"joint":"r_elbow","X":-1181.441,"Y":89.856,"Z":2358.813}, {"joint":"r_hand","X":-1102.039,"Y":-12.297,"Z":2217.287}, {"joint":"torso","X":-1269.039,"Y":-35.936,"Z":2287.253},](https://files.speakerdeck.com/presentations/f6e58c606e410130d27712313d2a3ab9/slide_18.jpg)
![{"skeletons":[{"userid":0,"joints":[{"joint":"head","X":-1196.286,"Y":369.161,"Z": 2149.150},{"joint":"neck","X":-1235.722,"Y":191.380,"Z":2235.051}, {"joint":"neck","X":-1235.722,"Y":191.380,"Z":2235.051}, {"joint":"l_shoulder","X":-1182.302,"Y":182.314,"Z":2229.667}, {"joint":"l_elbow","X":-1304.153,"Y":-41.818,"Z":2266.934}, {"joint":"l_hand","X":-1217.129,"Y":-283.542,"Z":2245.302}, {"joint":"r_shoulder","X":-1289.142,"Y":200.446,"Z":2240.434}, {"joint":"r_elbow","X":-1181.441,"Y":89.856,"Z":2358.813}, {"joint":"r_hand","X":-1102.039,"Y":-12.297,"Z":2217.287}, {"joint":"torso","X":-1269.039,"Y":-35.936,"Z":2287.253},](https://files.speakerdeck.com/presentations/f6e58c606e410130d27712313d2a3ab9/slide_19.jpg)