Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
[RSJ22] TDP-MAT: Multimodal Language Comprehens...
Search
Sponsored
·
Ship Features Fearlessly
Turn features on and off without deploys. Used by thousands of Ruby developers.
→
Semantic Machine Intelligence Lab., Keio Univ.
PRO
September 05, 2022
Technology
860
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
[RSJ22] TDP-MAT: Multimodal Language Comprehension for Object Manipulation Tasks via Real Images
Semantic Machine Intelligence Lab., Keio Univ.
PRO
September 05, 2022
Transcript
35 slides
1
2
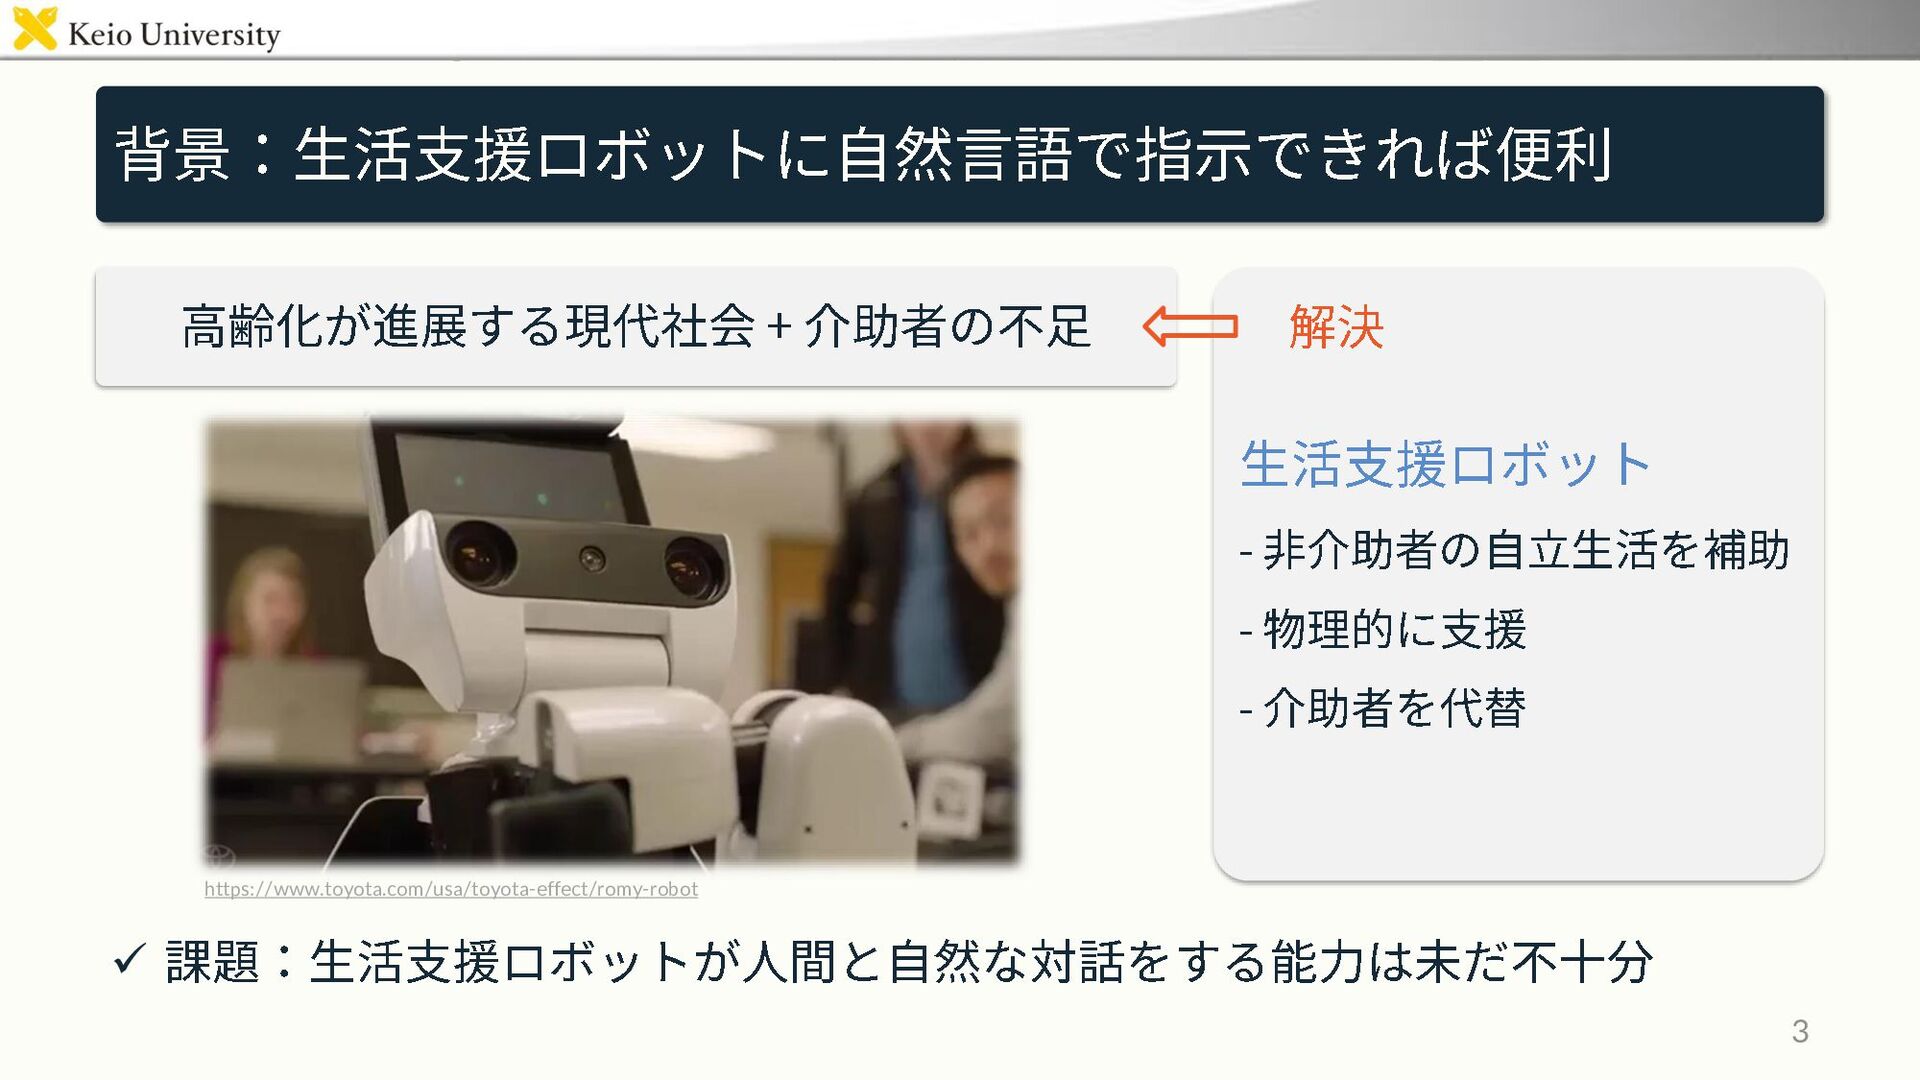
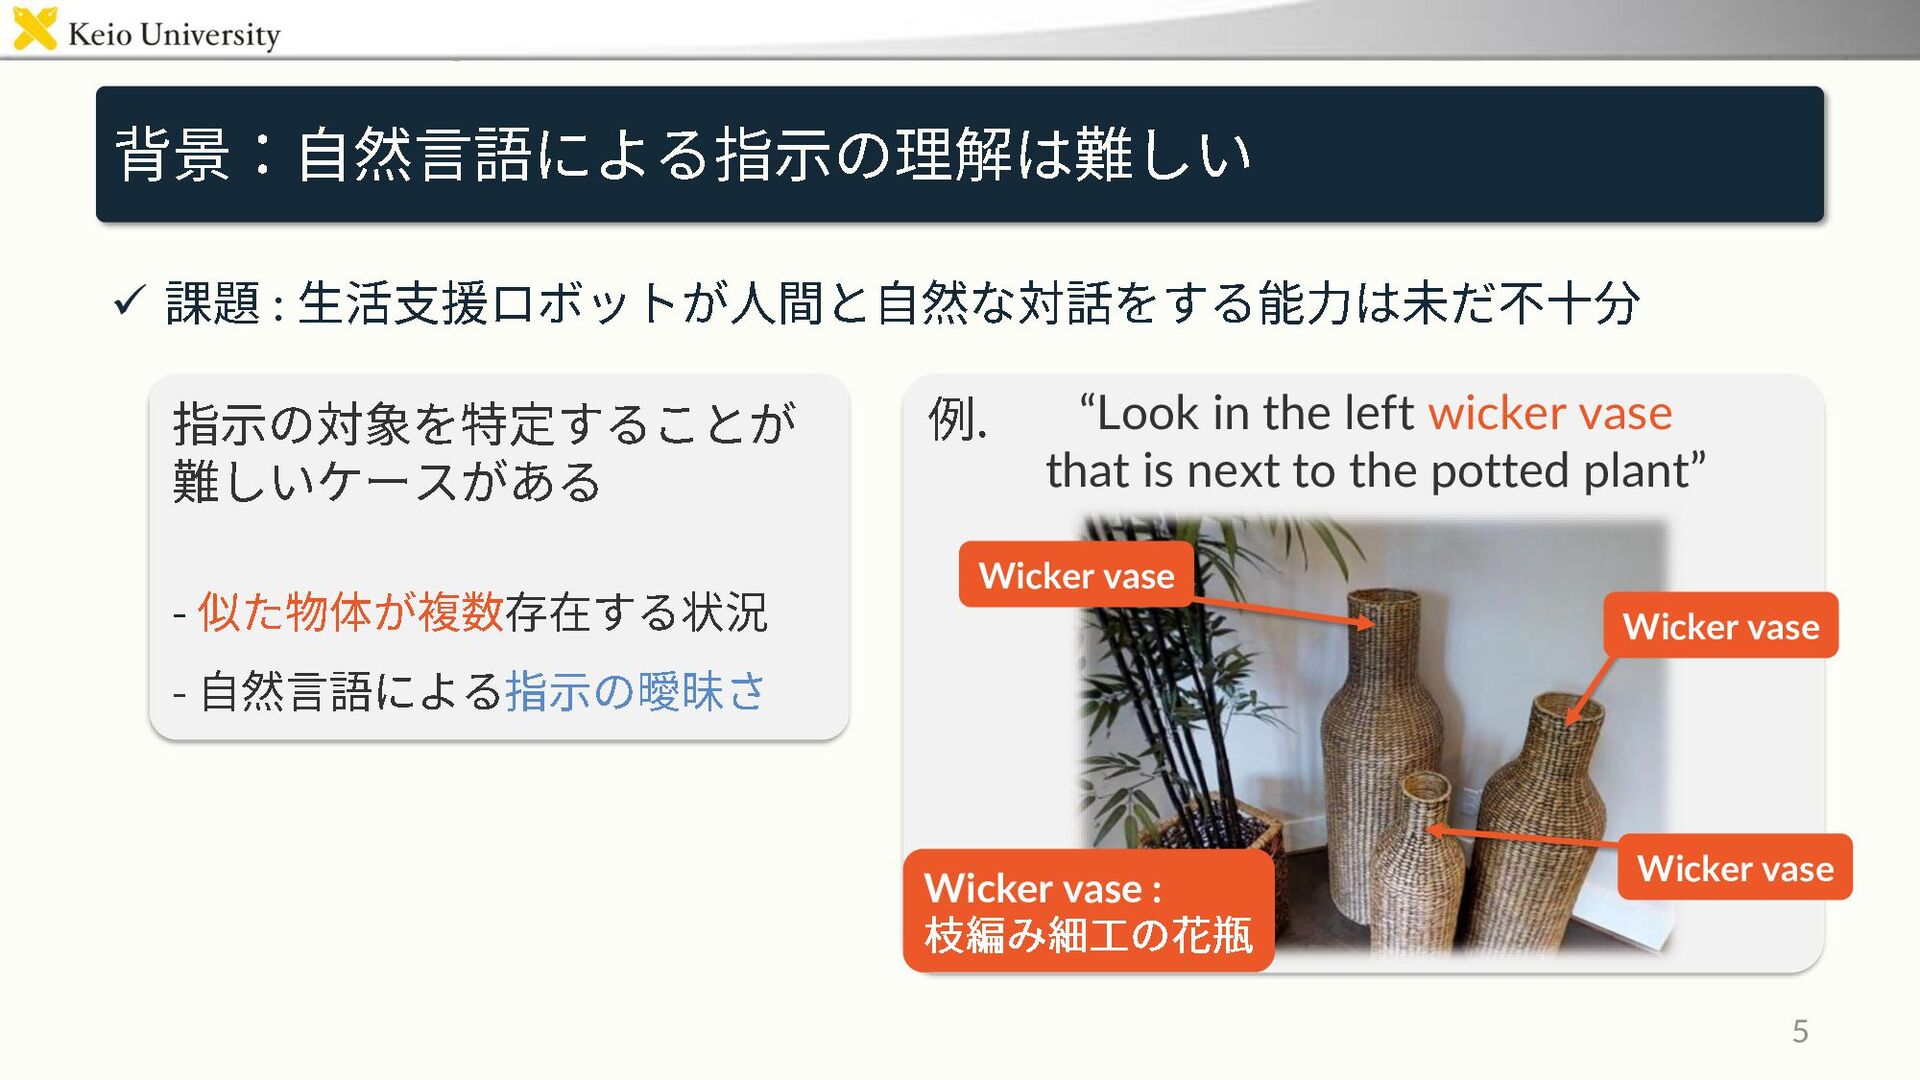
3 ✓ https://www.toyota.com/usa/toyota-effect/romy-robot
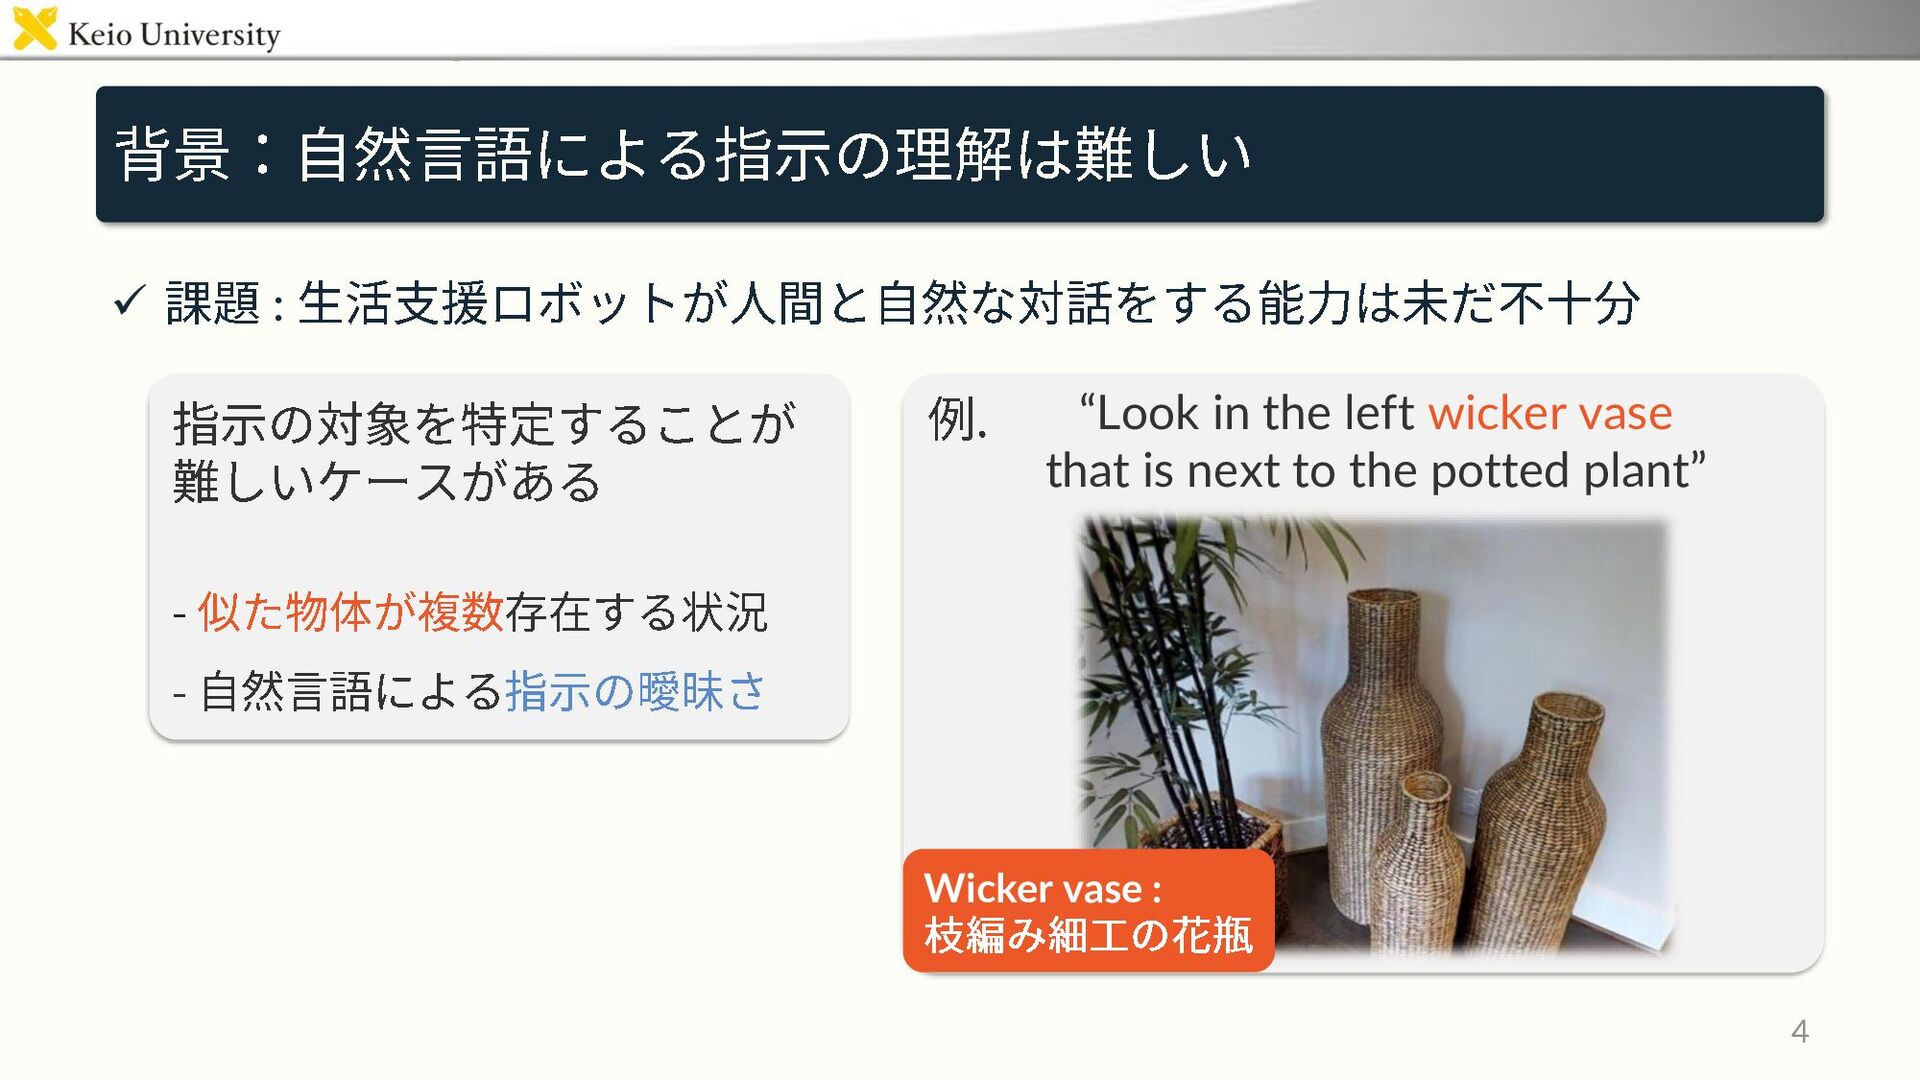
✓ : 4 “Look in the left wicker vase that
is next to the potted plant” Wicker vase :
✓ : “Look in the left wicker vase that is
next to the potted plant” 5 Wicker vase : Wicker vase Wicker vase Wicker vase
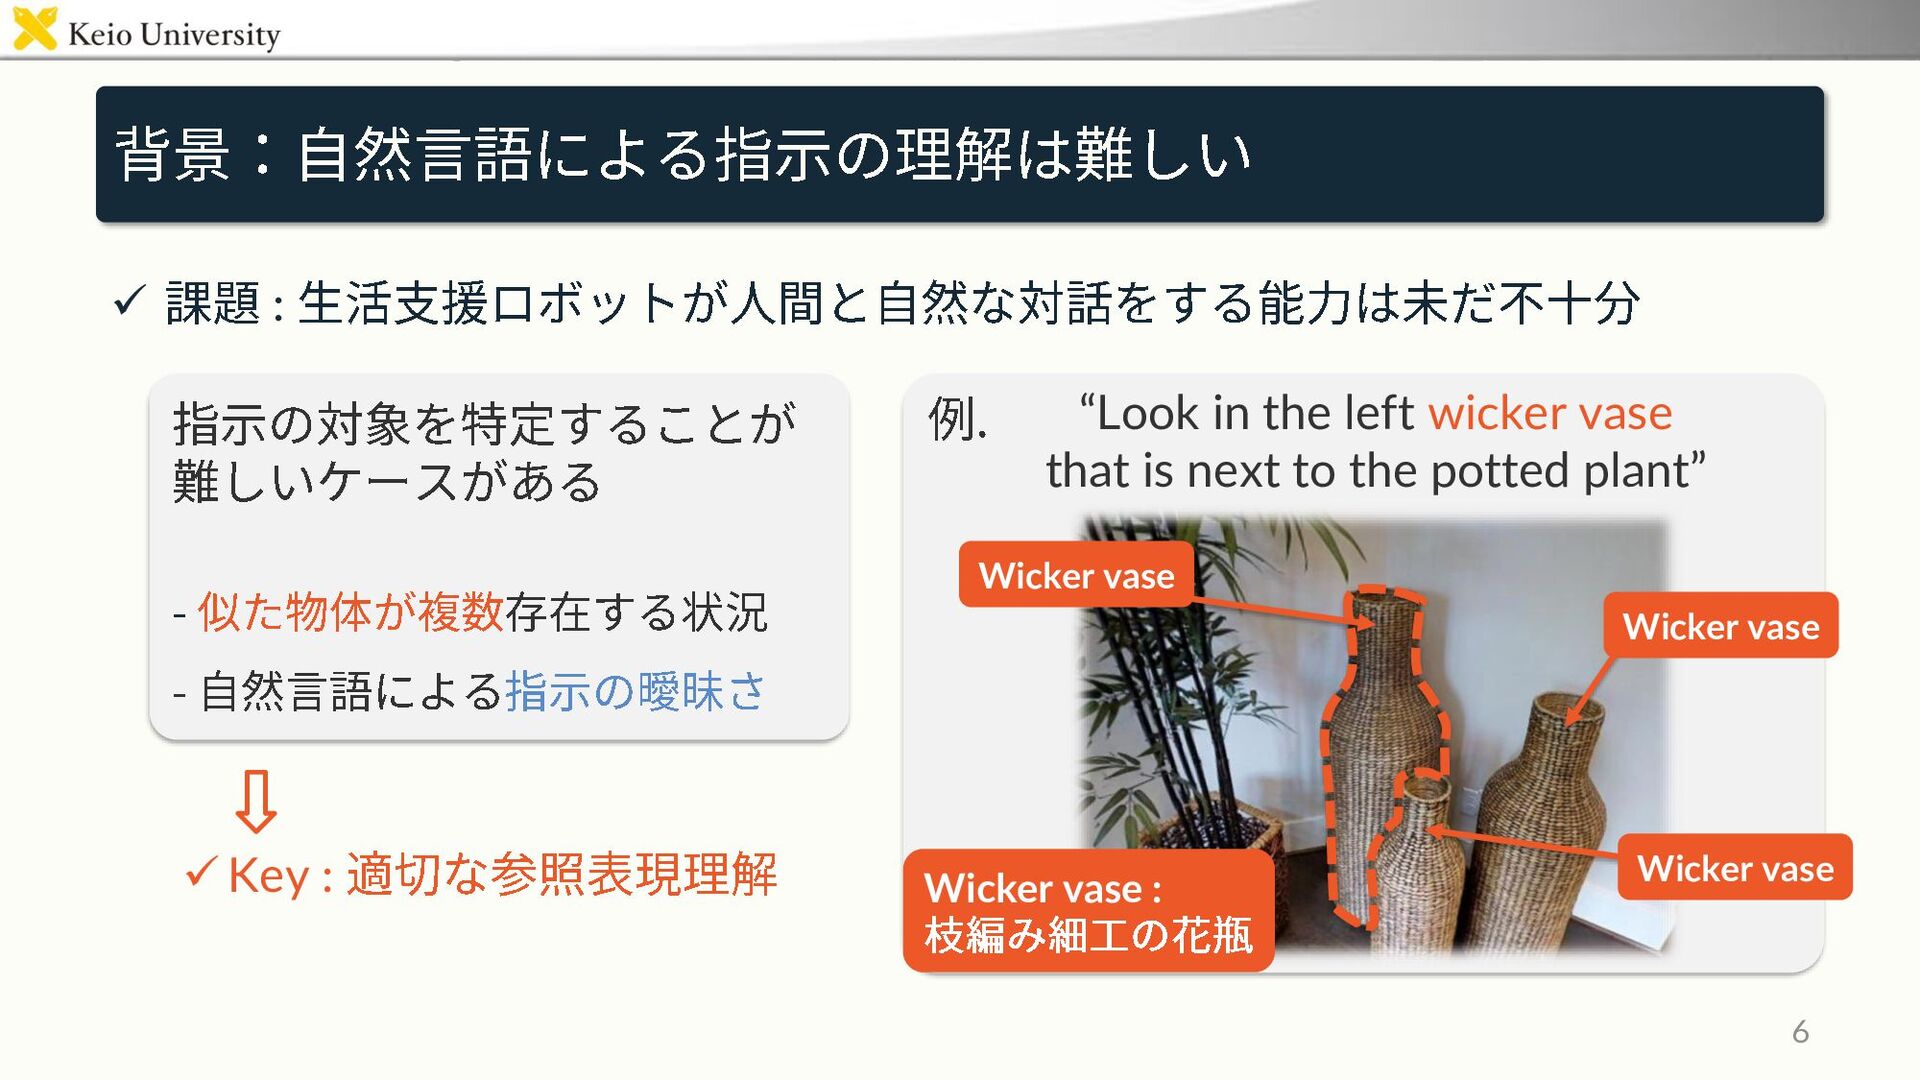
✓ : ✓ Key : “Look in the left wicker
vase that is next to the potted plant” 6 Wicker vase : Wicker vase Wicker vase Wicker vase
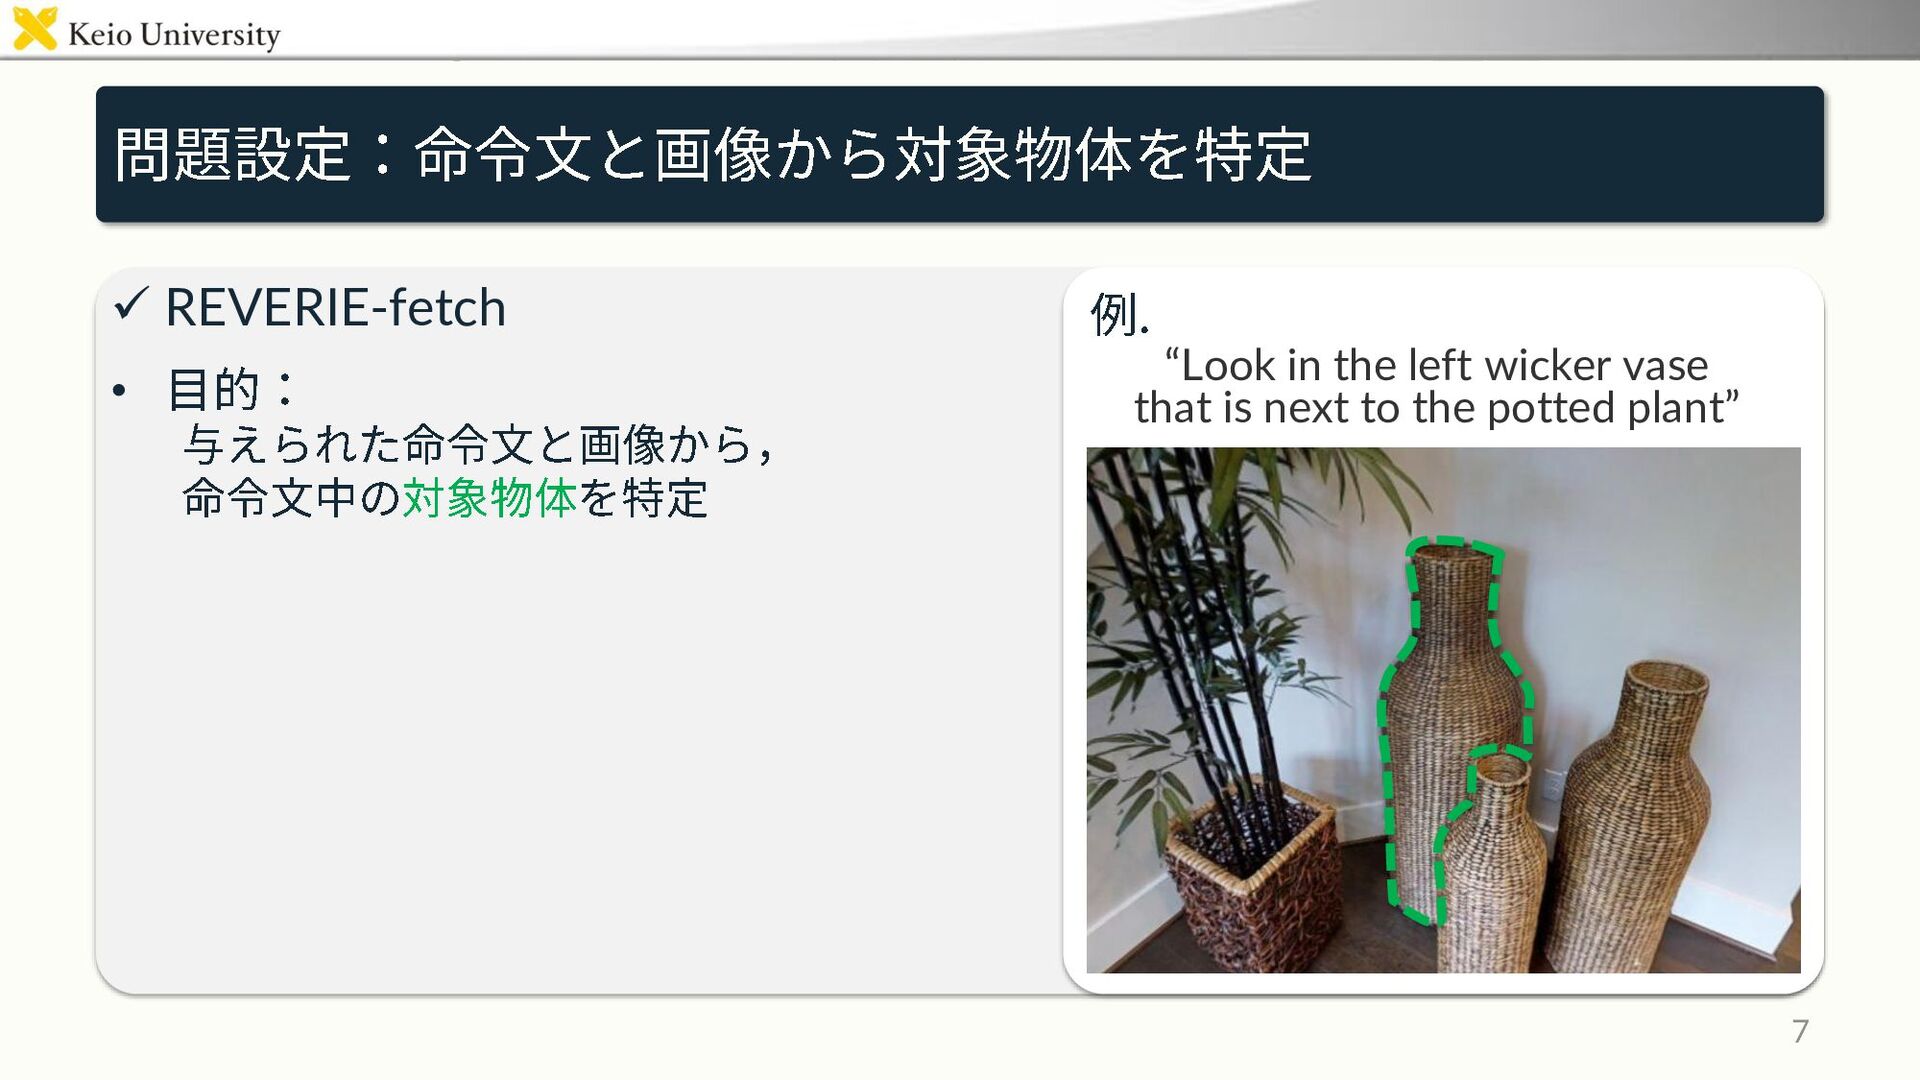
✓ REVERIE-fetch • 7 “Look in the left wicker vase
that is next to the potted plant”
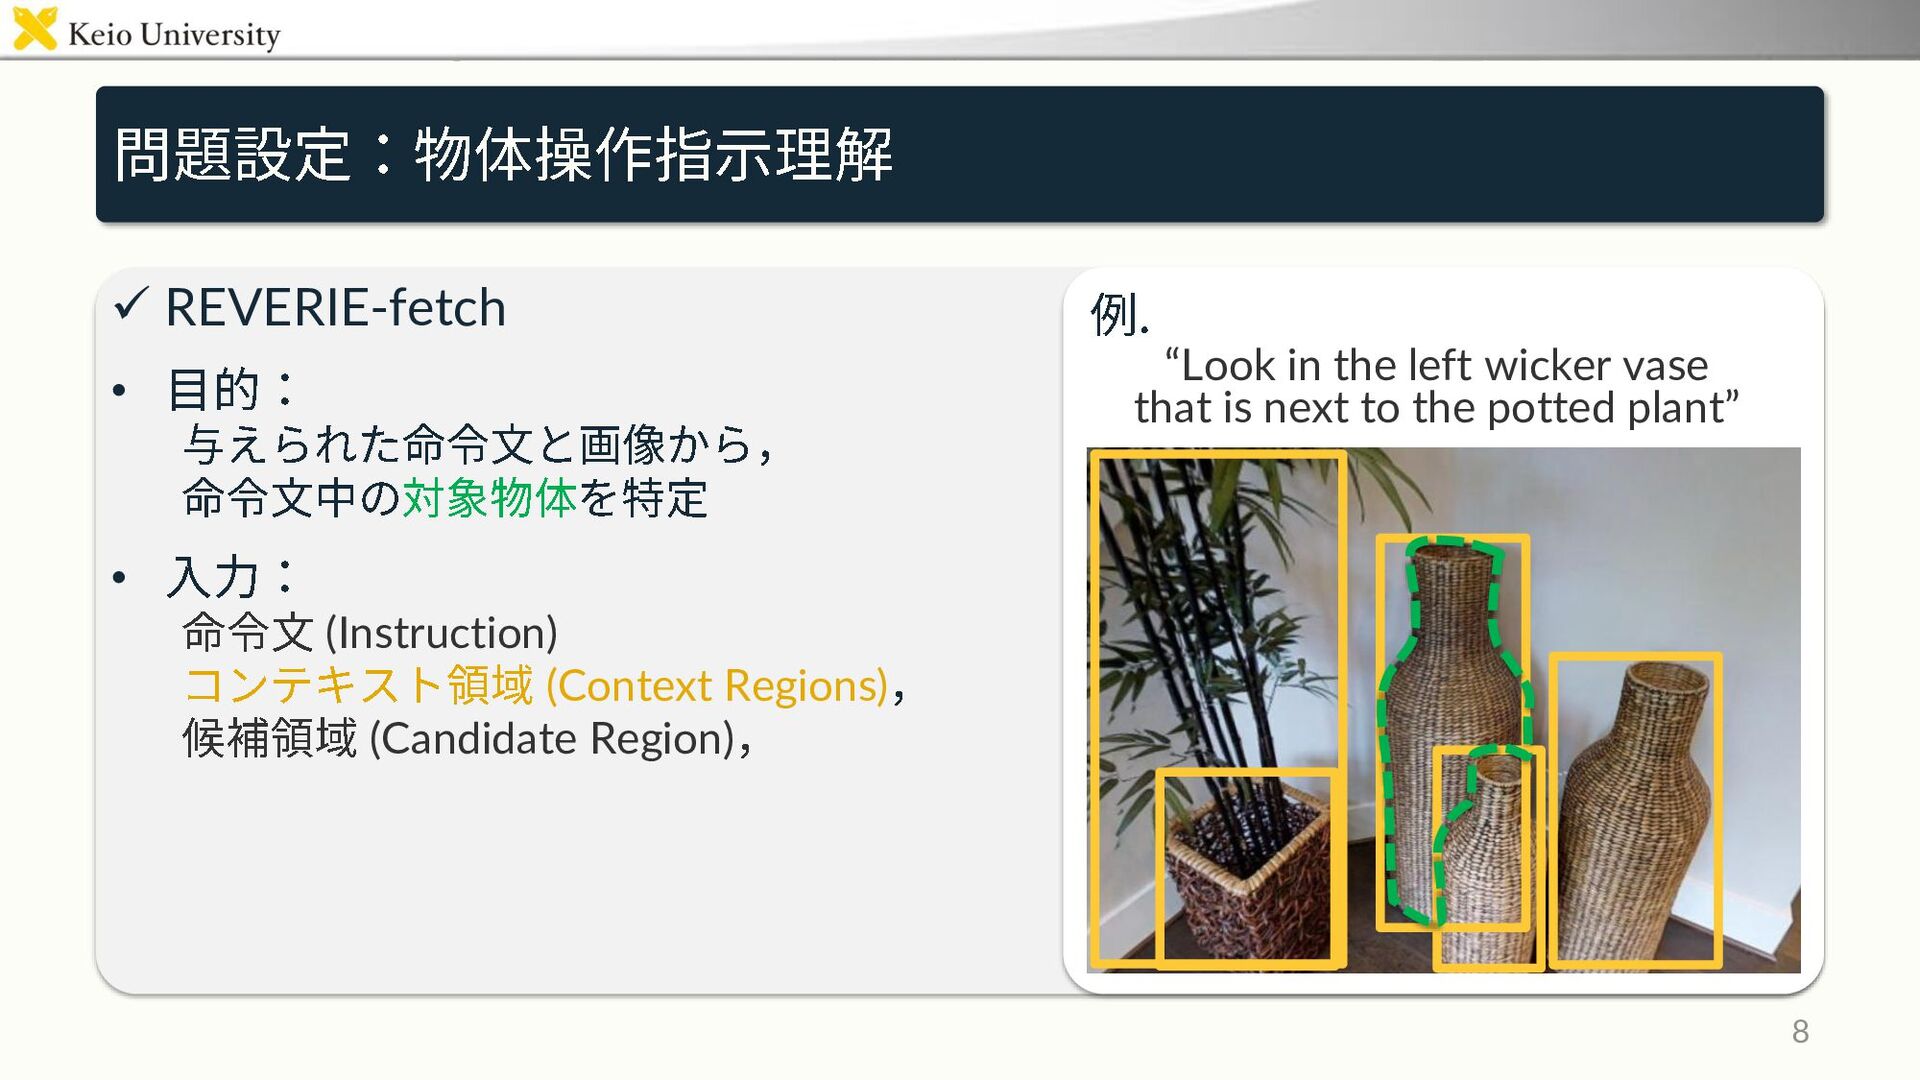
✓ REVERIE-fetch • • (Instruction) (Context Regions) (Candidate Region) 8
“Look in the left wicker vase that is next to the potted plant”
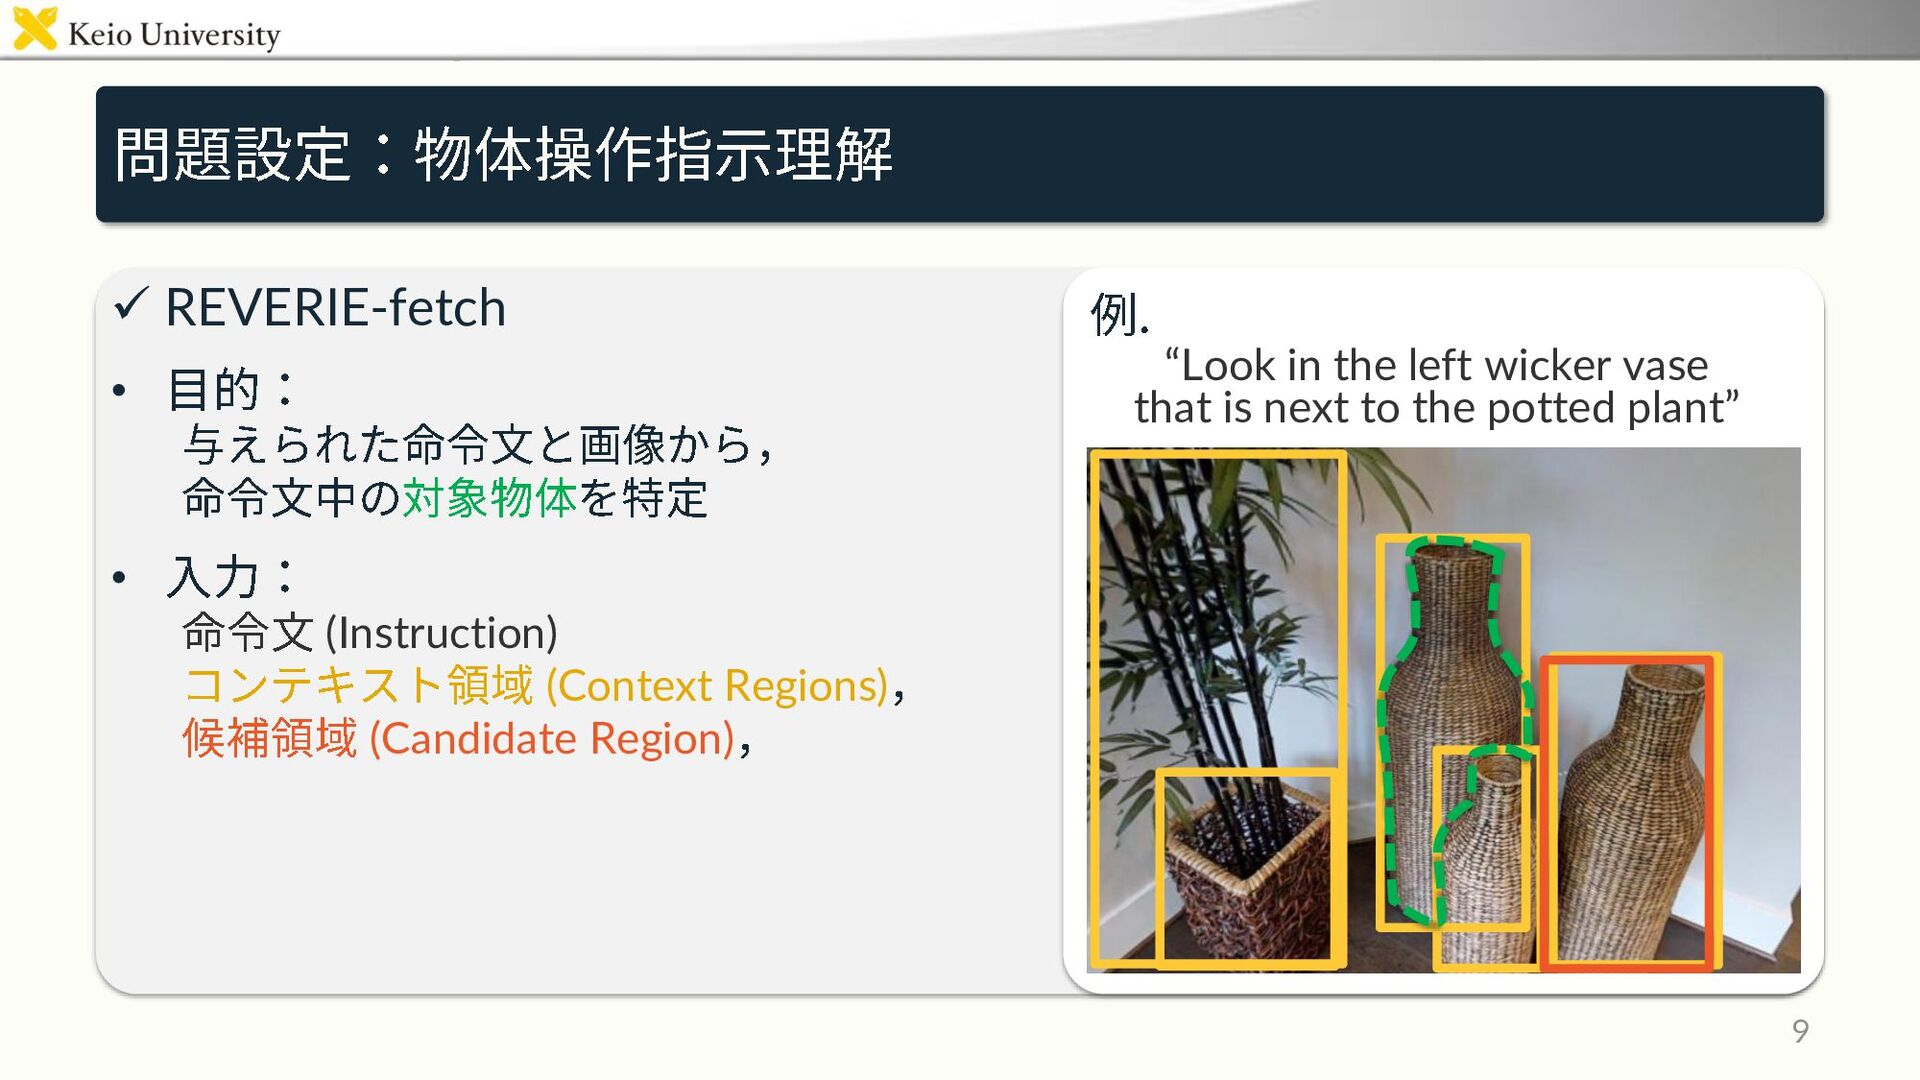
✓ REVERIE-fetch • • (Instruction) (Context Regions) (Candidate Region) 9
“Look in the left wicker vase that is next to the potted plant”
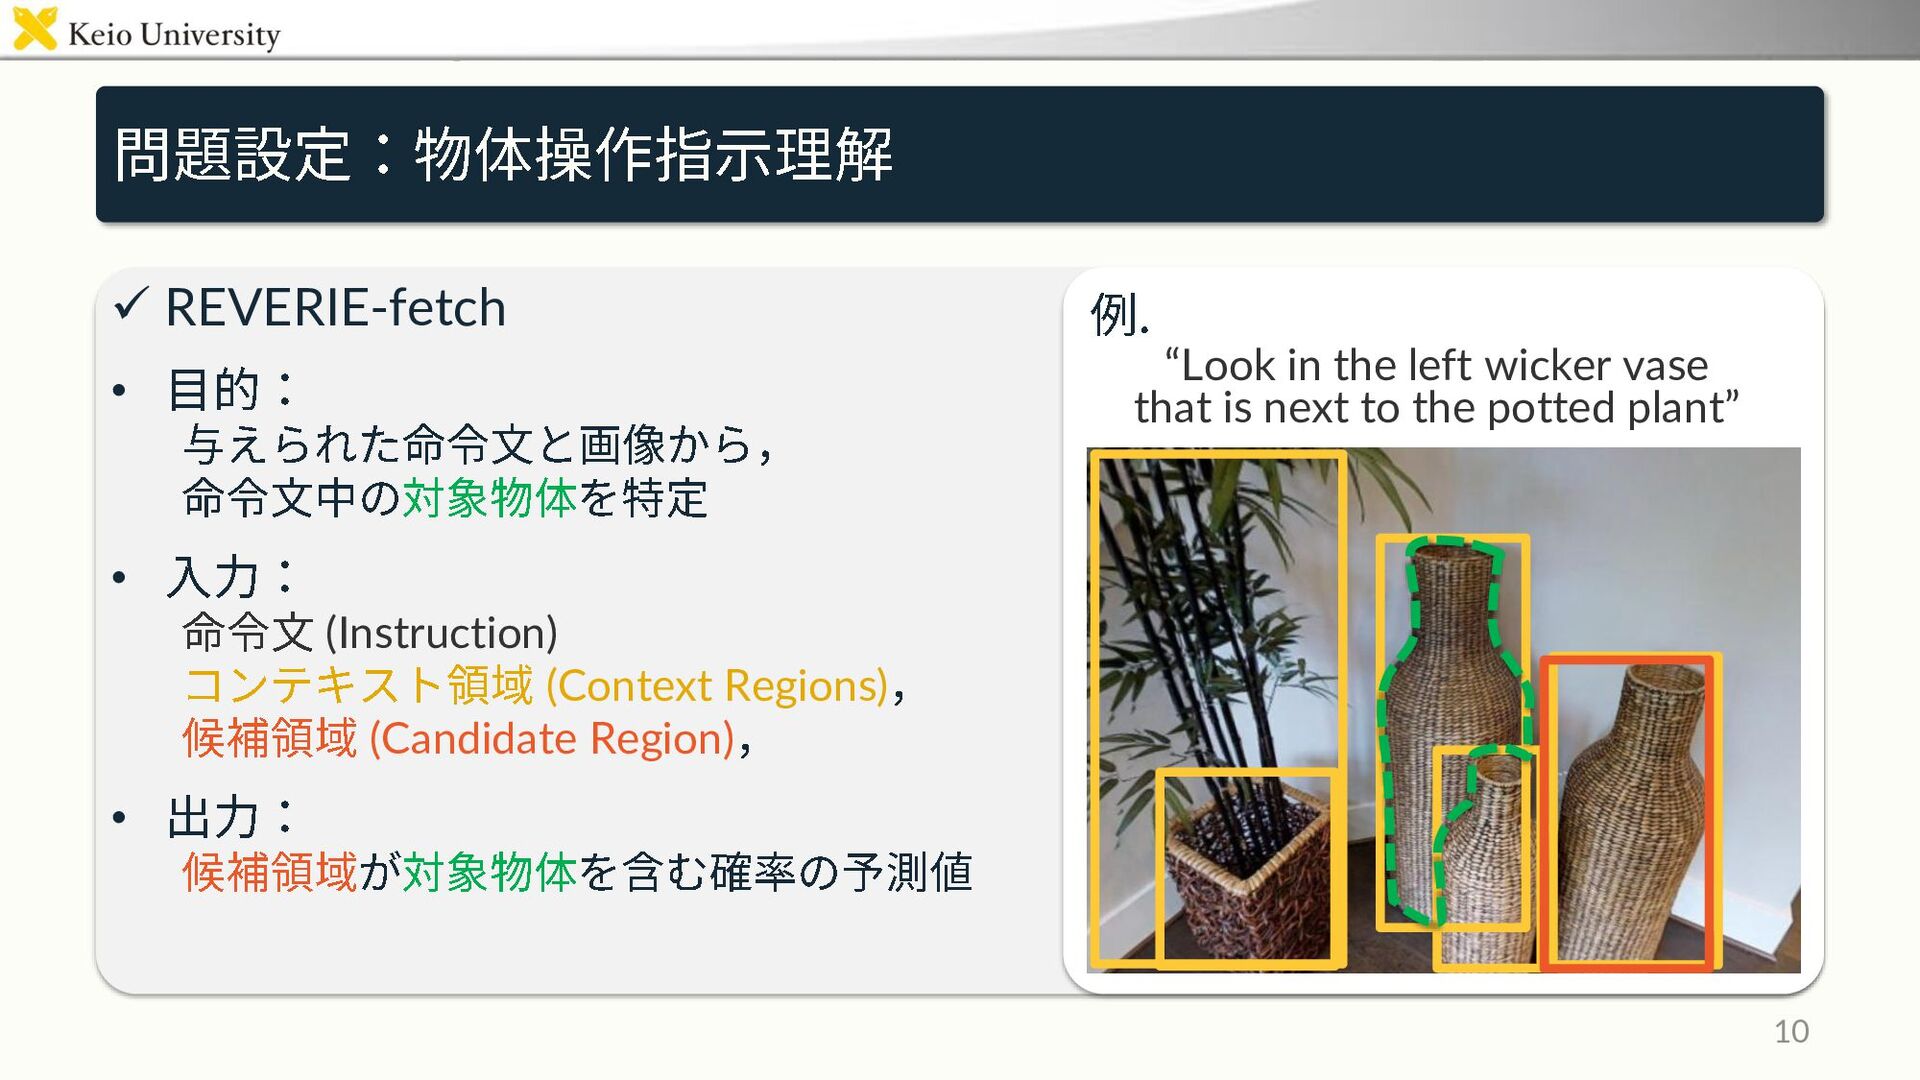
✓ REVERIE-fetch • • (Instruction) (Context Regions) (Candidate Region) •
10 “Look in the left wicker vase that is next to the potted plant”
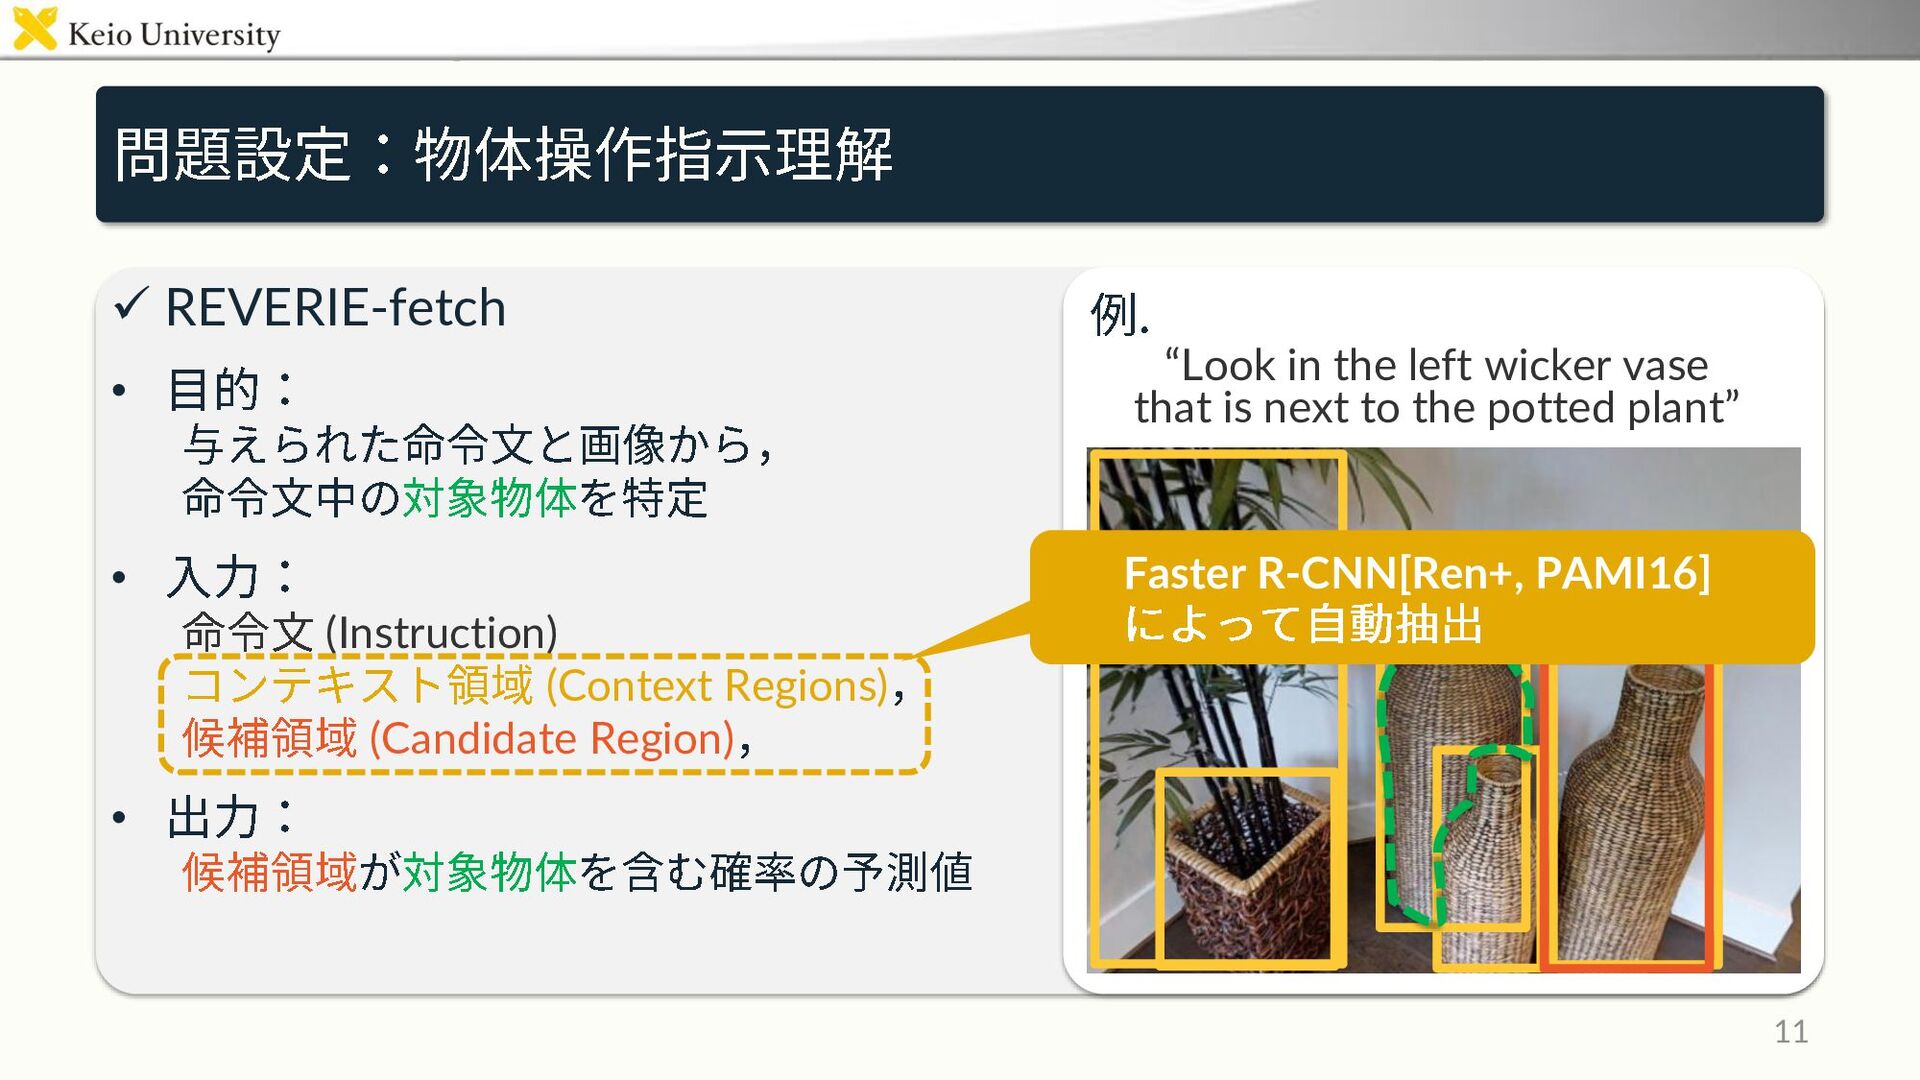
✓ REVERIE-fetch • • (Instruction) (Context Regions) (Candidate Region) •
11 “Look in the left wicker vase that is next to the potted plant” Faster R-CNN[Ren+, PAMI16]
MTCM [Magassouba+, RA-L19] . VGG16LSTM . Target-dependent UNITER (TDU) [Ishikawa+,
RA-L21] UNITER[Chen+, ECCV20] . REVERIE task / dataset [Qi+, CVPR20] , REVERIE 12
• MAT[Ishikawa+, ICPR22] • CLIP[Radford+, ICML21] • Perceiver[Jaegle+, ICML21] 13
• MAT[Ishikawa+, ICPR22] • CLIP[Radford+, ICML21] • Perceiver[Jaegle+, ICML21] 14
• MAT[Ishikawa+, ICPR22] • CLIP[Radford+, ICML21] • Perceiver[Jaegle+, ICML21] 15
• MAT[Ishikawa+, ICPR22] • CLIP[Radford+, ICML21] • Perceiver[Jaegle+, ICML21] 16
• MAT[Ishikawa+, ICPR22] • CLIP[Radford+, ICML21] • Perceiver[Jaegle+, ICML21] 17
2 1 3
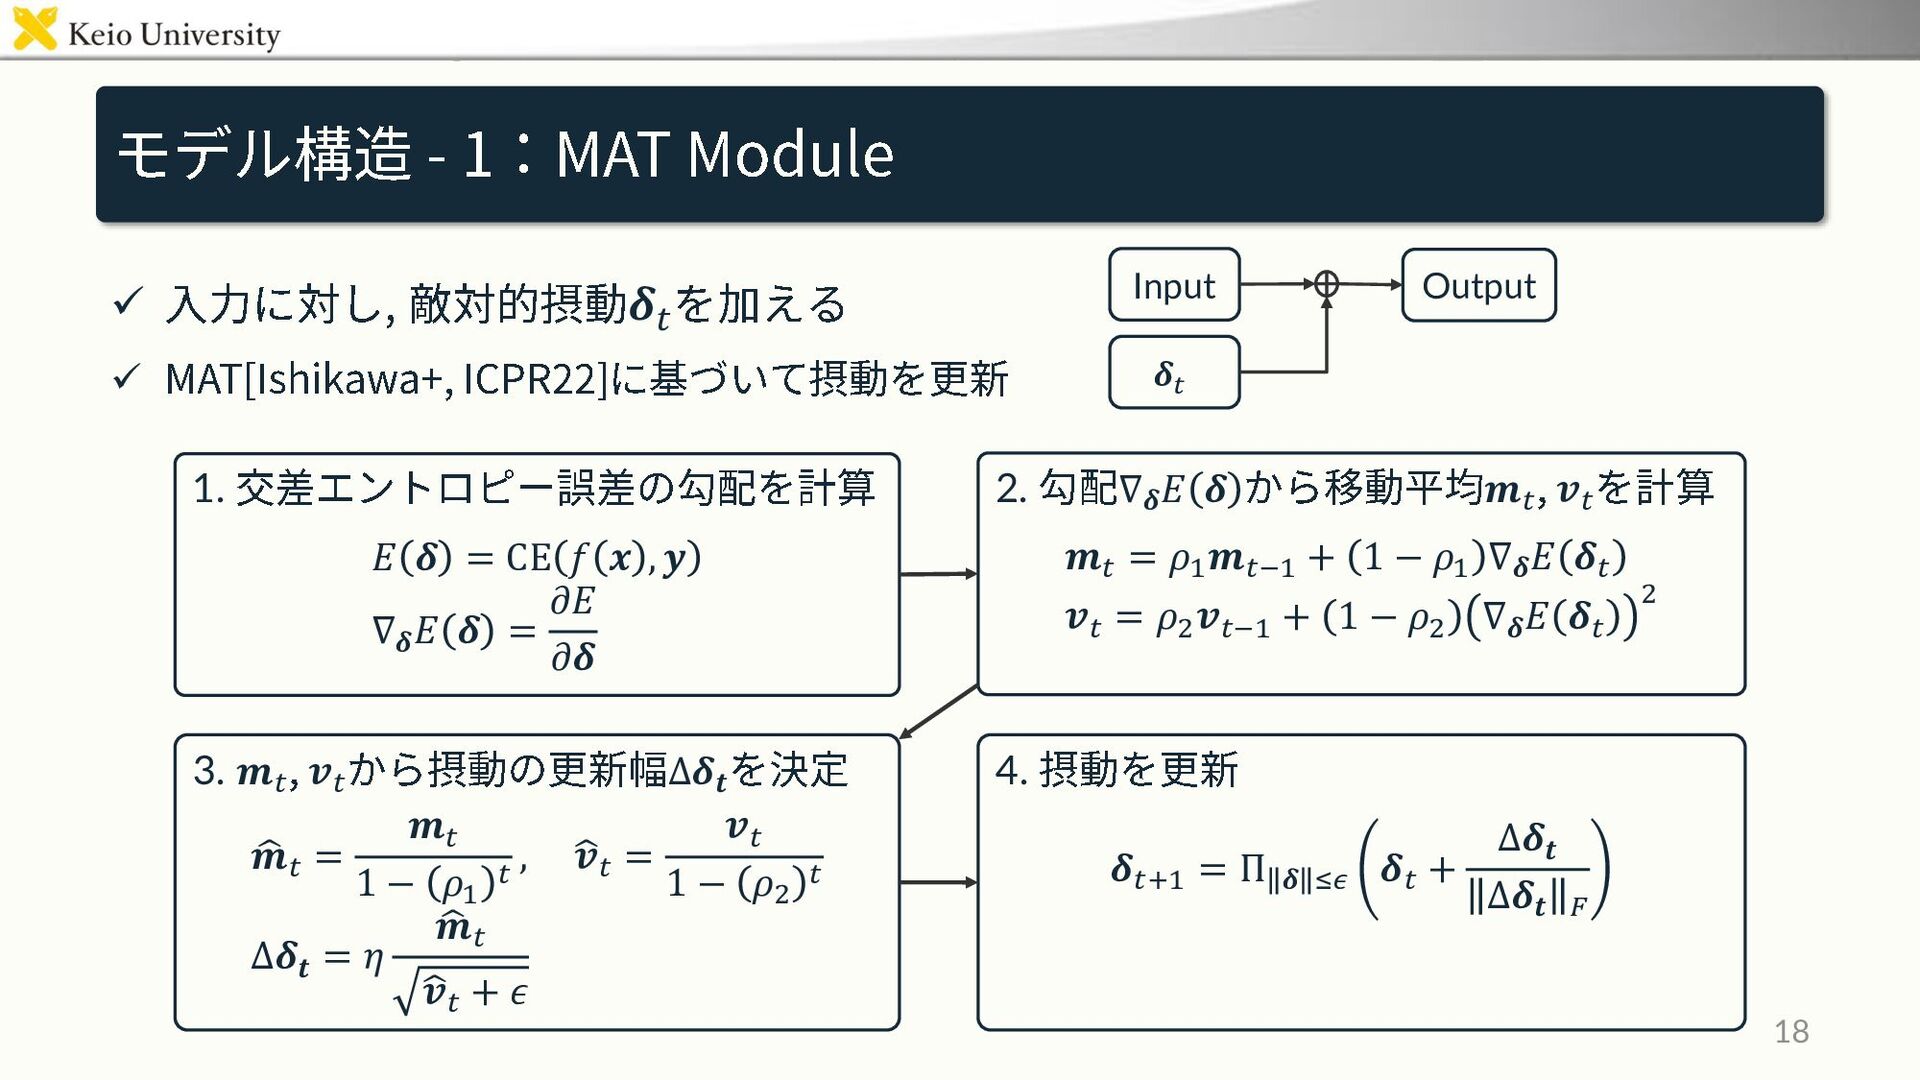
✓ 𝜹𝑡 ✓ 18 Input 𝜹𝑡 Output 1. 𝐸 𝜹
= CE 𝑓 𝒙 , 𝒚 ∇𝜹 𝐸 𝜹 = 𝜕𝐸 𝜕𝜹 2. ∇𝜹 𝐸 𝜹 𝒎𝑡 𝒗𝑡 𝒎𝑡 = 𝜌1 𝒎𝑡−1 + 1 − 𝜌1 ∇𝜹 𝐸 𝜹𝑡 𝒗𝑡 = 𝜌2 𝒗𝑡−1 + 1 − 𝜌2 ∇𝜹 𝐸 𝜹𝑡 2 3. 𝒎𝑡 𝒗𝑡 ∆𝜹𝒕 ෝ 𝒎𝑡 = 𝒎𝑡 1 − 𝜌1 𝑡 , ෝ 𝒗𝑡 = 𝒗𝑡 1 − 𝜌2 𝑡 ∆𝜹𝒕 = 𝜂 ෝ 𝒎𝑡 ෝ 𝒗𝑡 + 𝜖 4. 𝜹𝑡+1 = Π 𝜹 ≤𝜖 𝜹𝑡 + ∆𝜹𝒕 ∆𝜹𝒕 𝐹
✓ CLIP ✓ ViT[Dosovitskiy+, ICLR21] ✓ transformer [EOT] 19 [EOT]
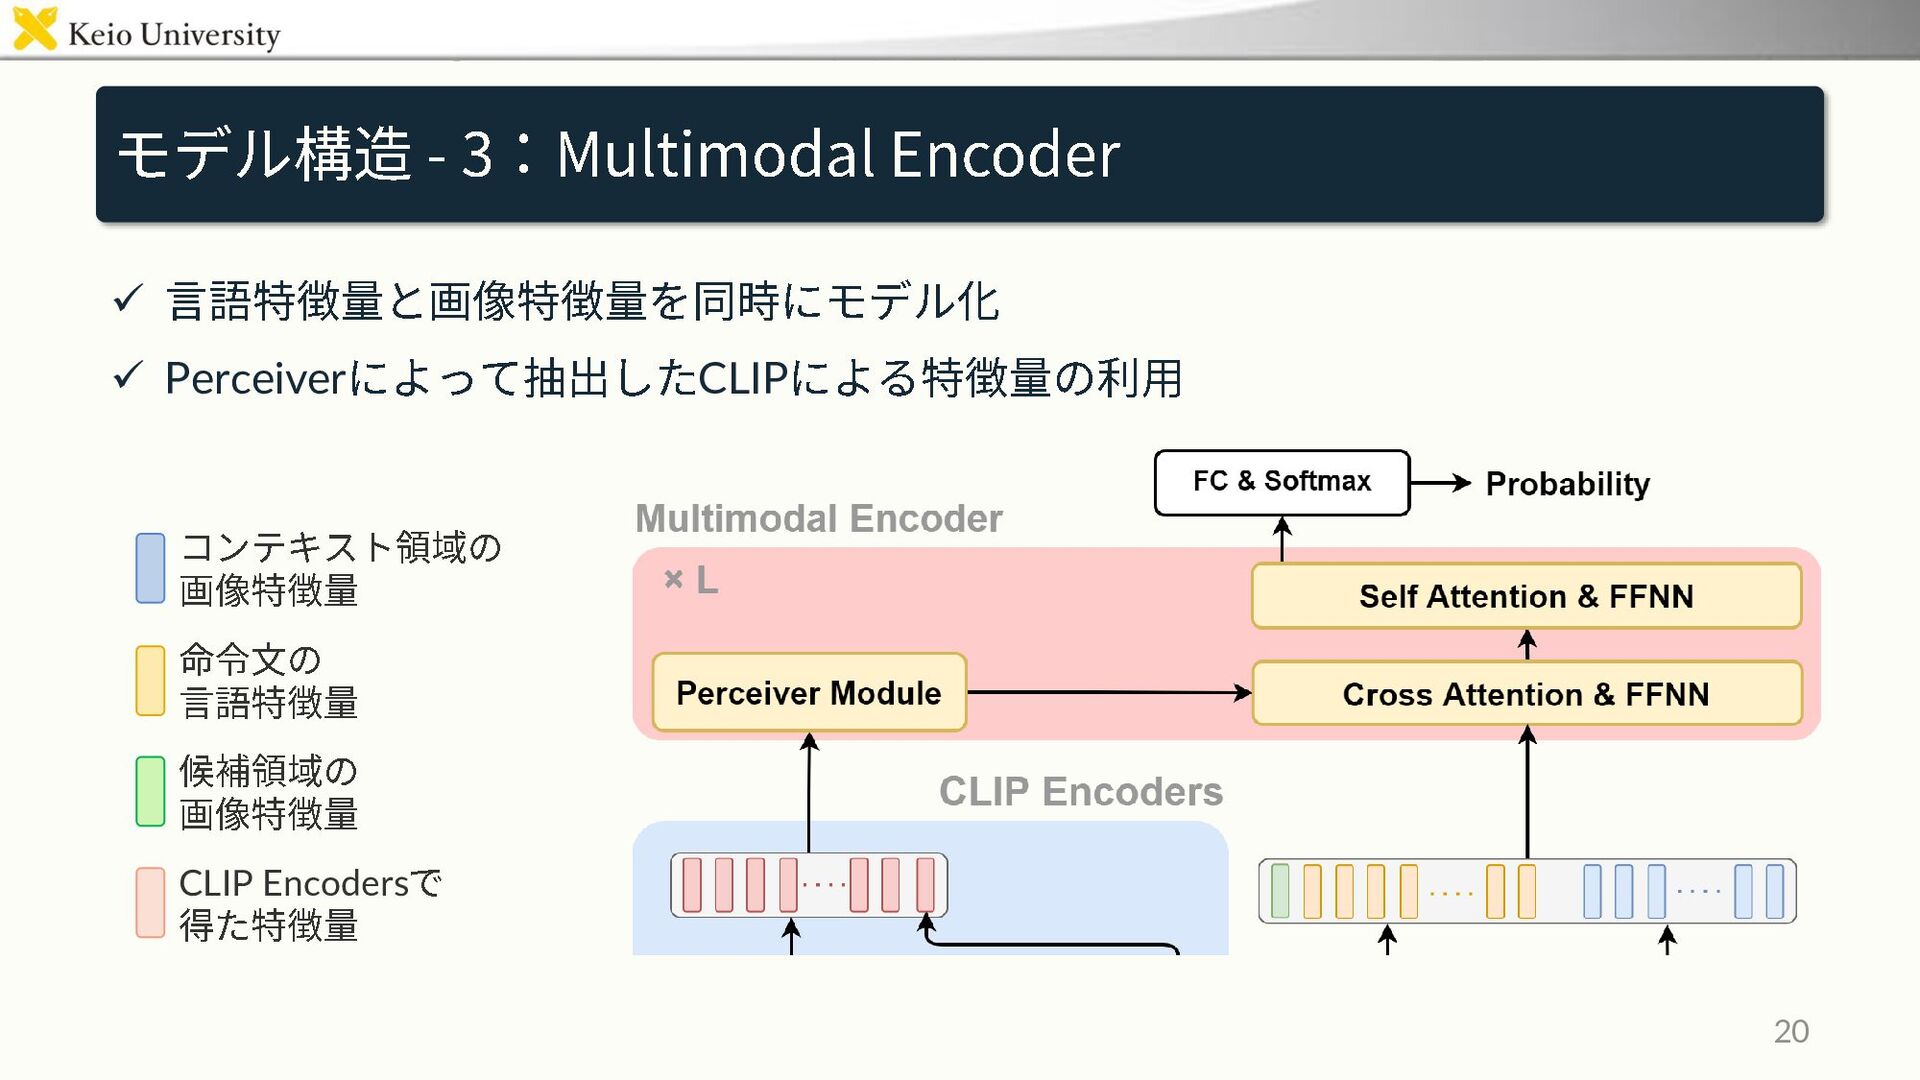
✓ ✓ Perceiver CLIP 20 CLIP Encoders
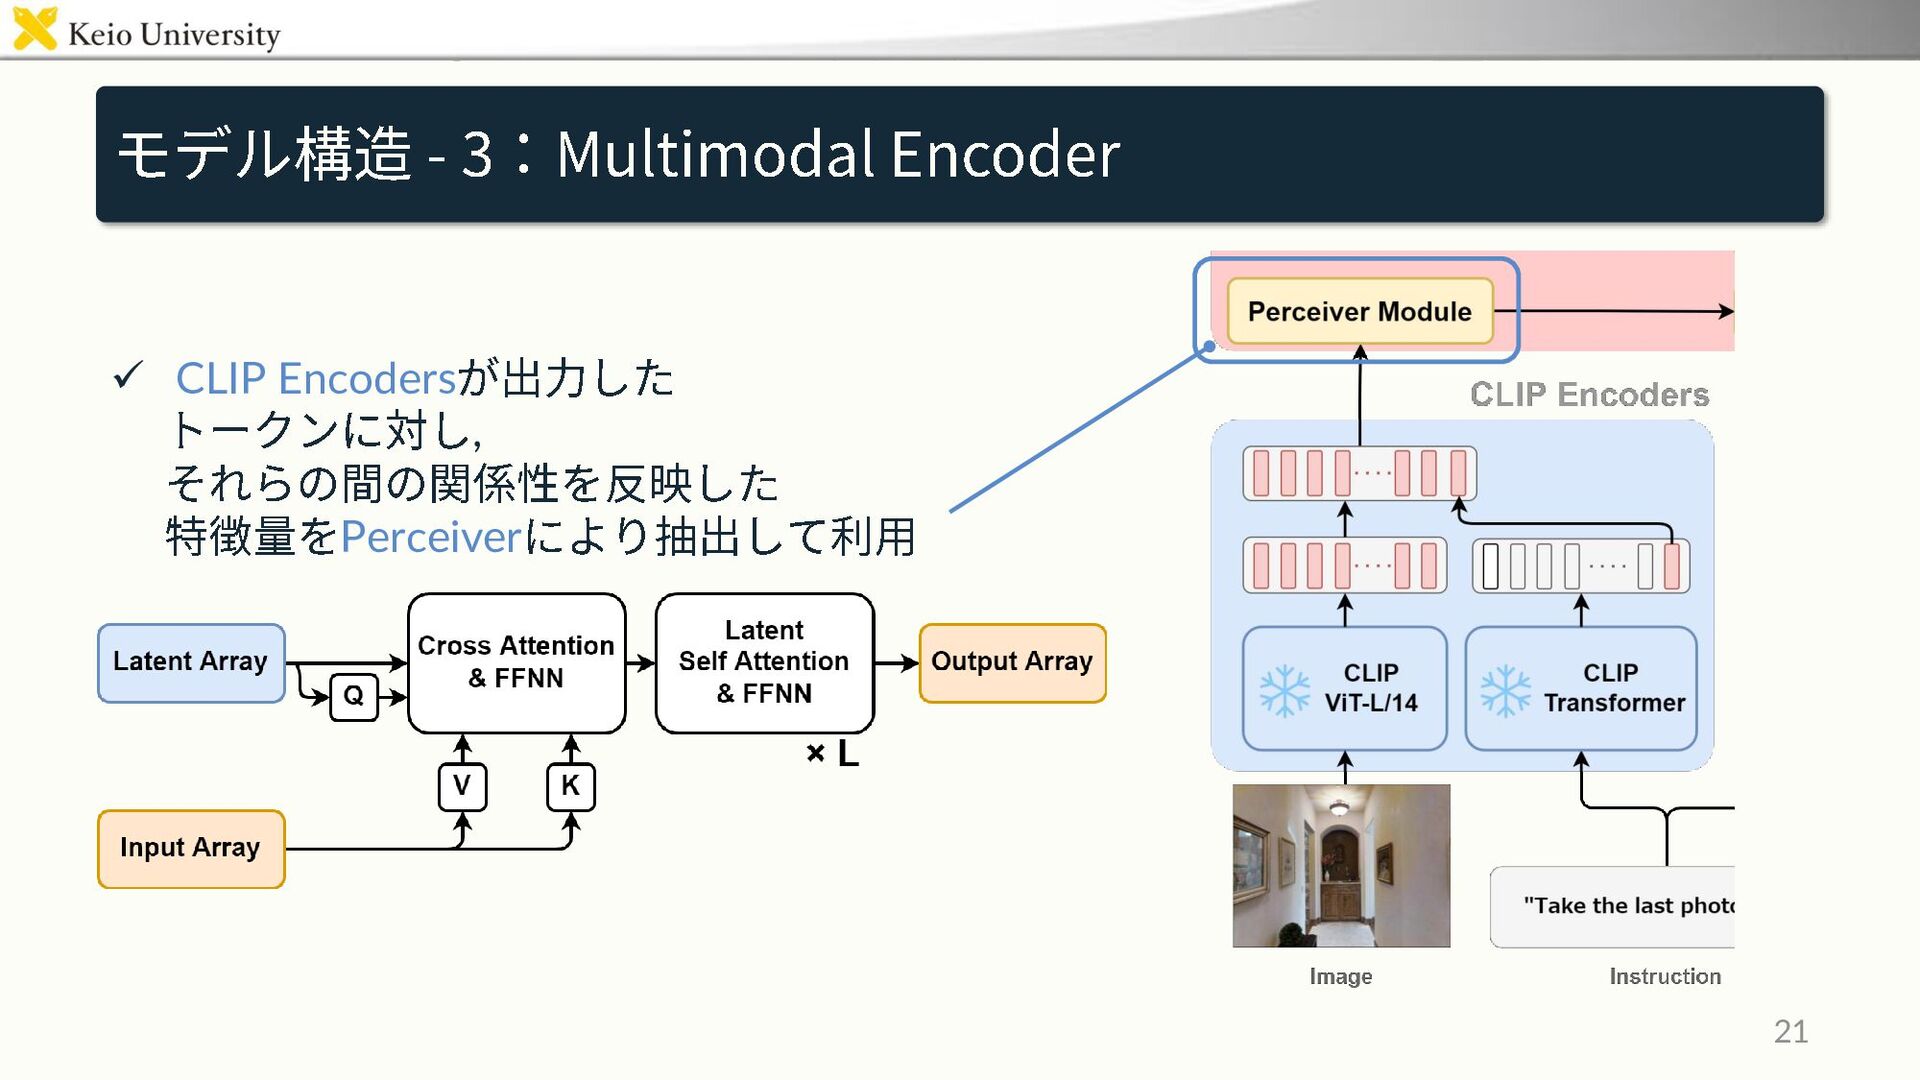
✓ CLIP Encoders , Perceiver 21
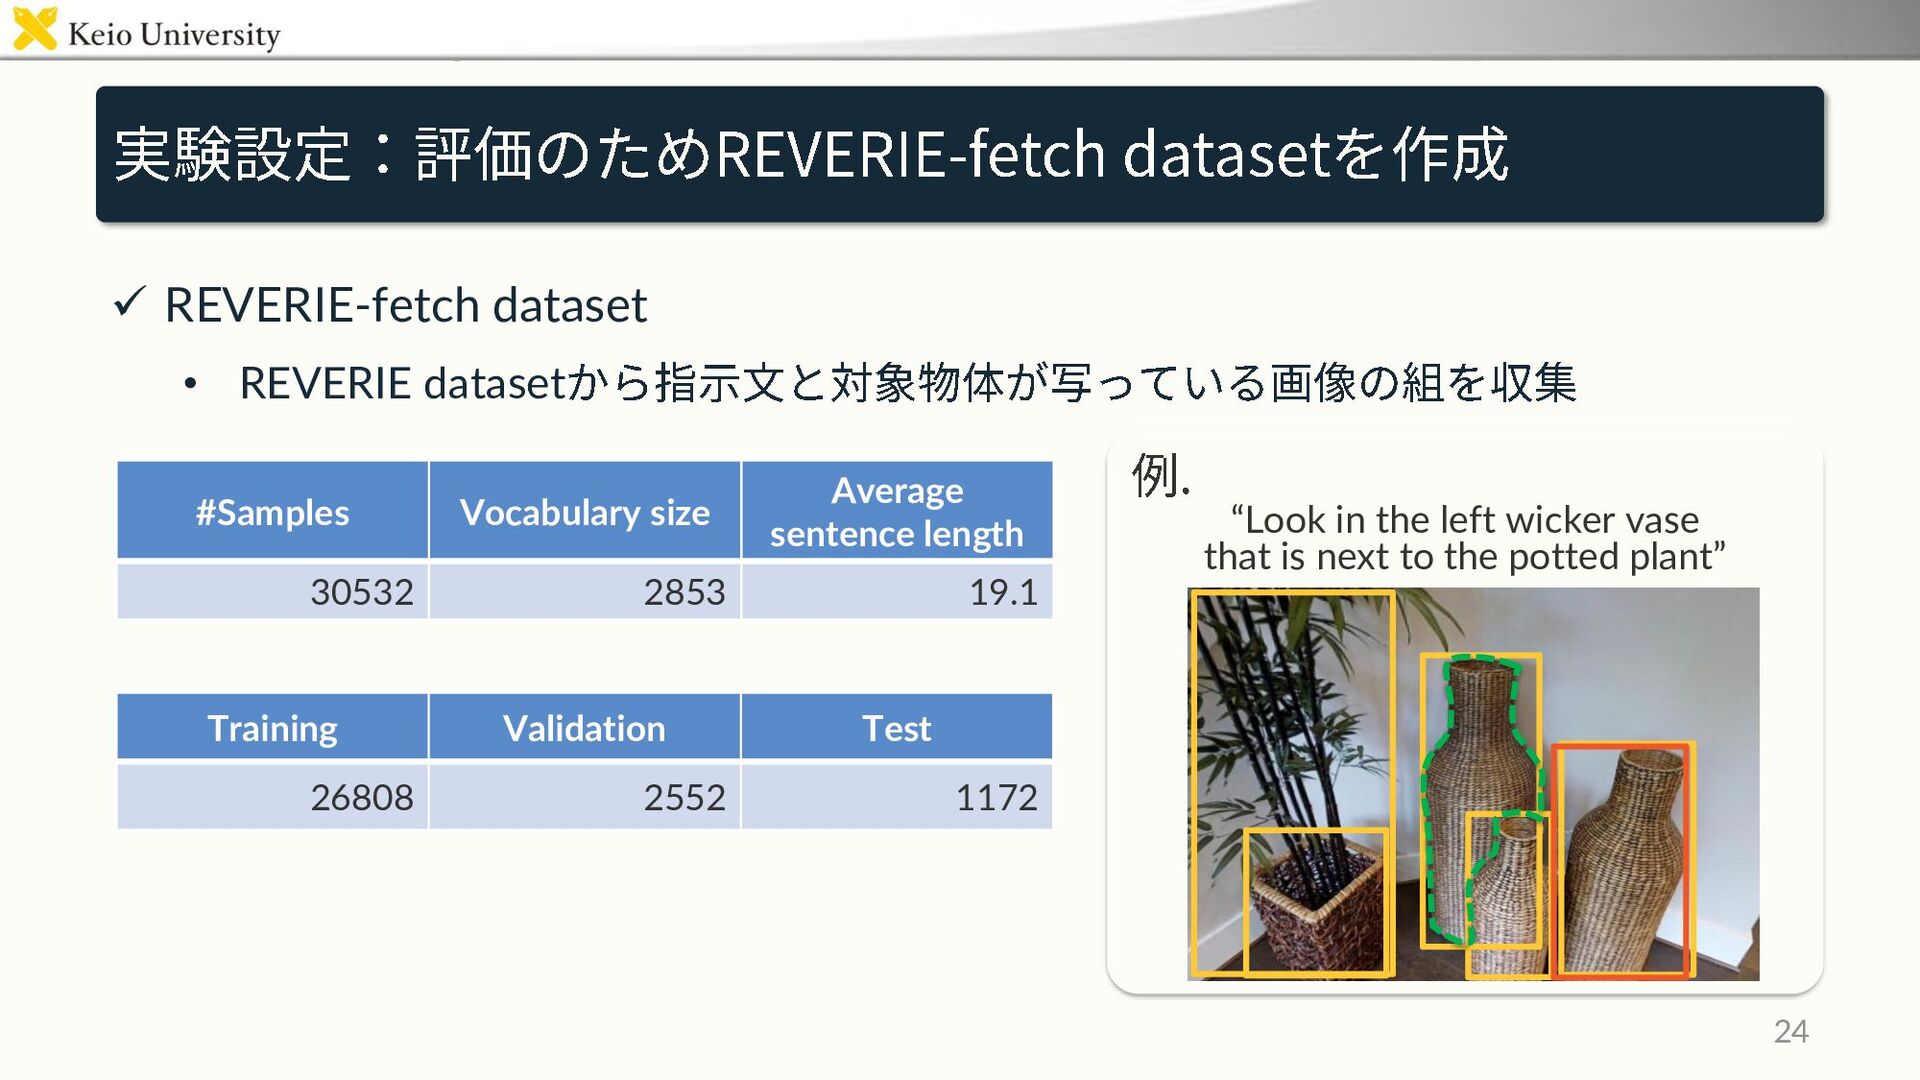
✓ REVERIE-fetch dataset - REVERIE dataset ✓ REVERIE[Qi+, CVPR18] -
→ 1. , 2. https://yuankaiqi.github.io/REVERIE_Challenge/static/img/demo.gif 22 Matterport3D
✓ REVERIE-fetch dataset - REVERIE dataset ✓ REVERIE[Qi+, CVPR18] :
+ 23 , ↓ - REVERIE - - https://yuankaiqi.github.io/REVERIE_Challenge/static/img/demo.gif
✓ REVERIE-fetch dataset • REVERIE dataset #Samples Vocabulary size Average
sentence length 30532 2853 19.1 Training Validation Test 26808 2552 1172 24 “Look in the left wicker vase that is next to the potted plant”
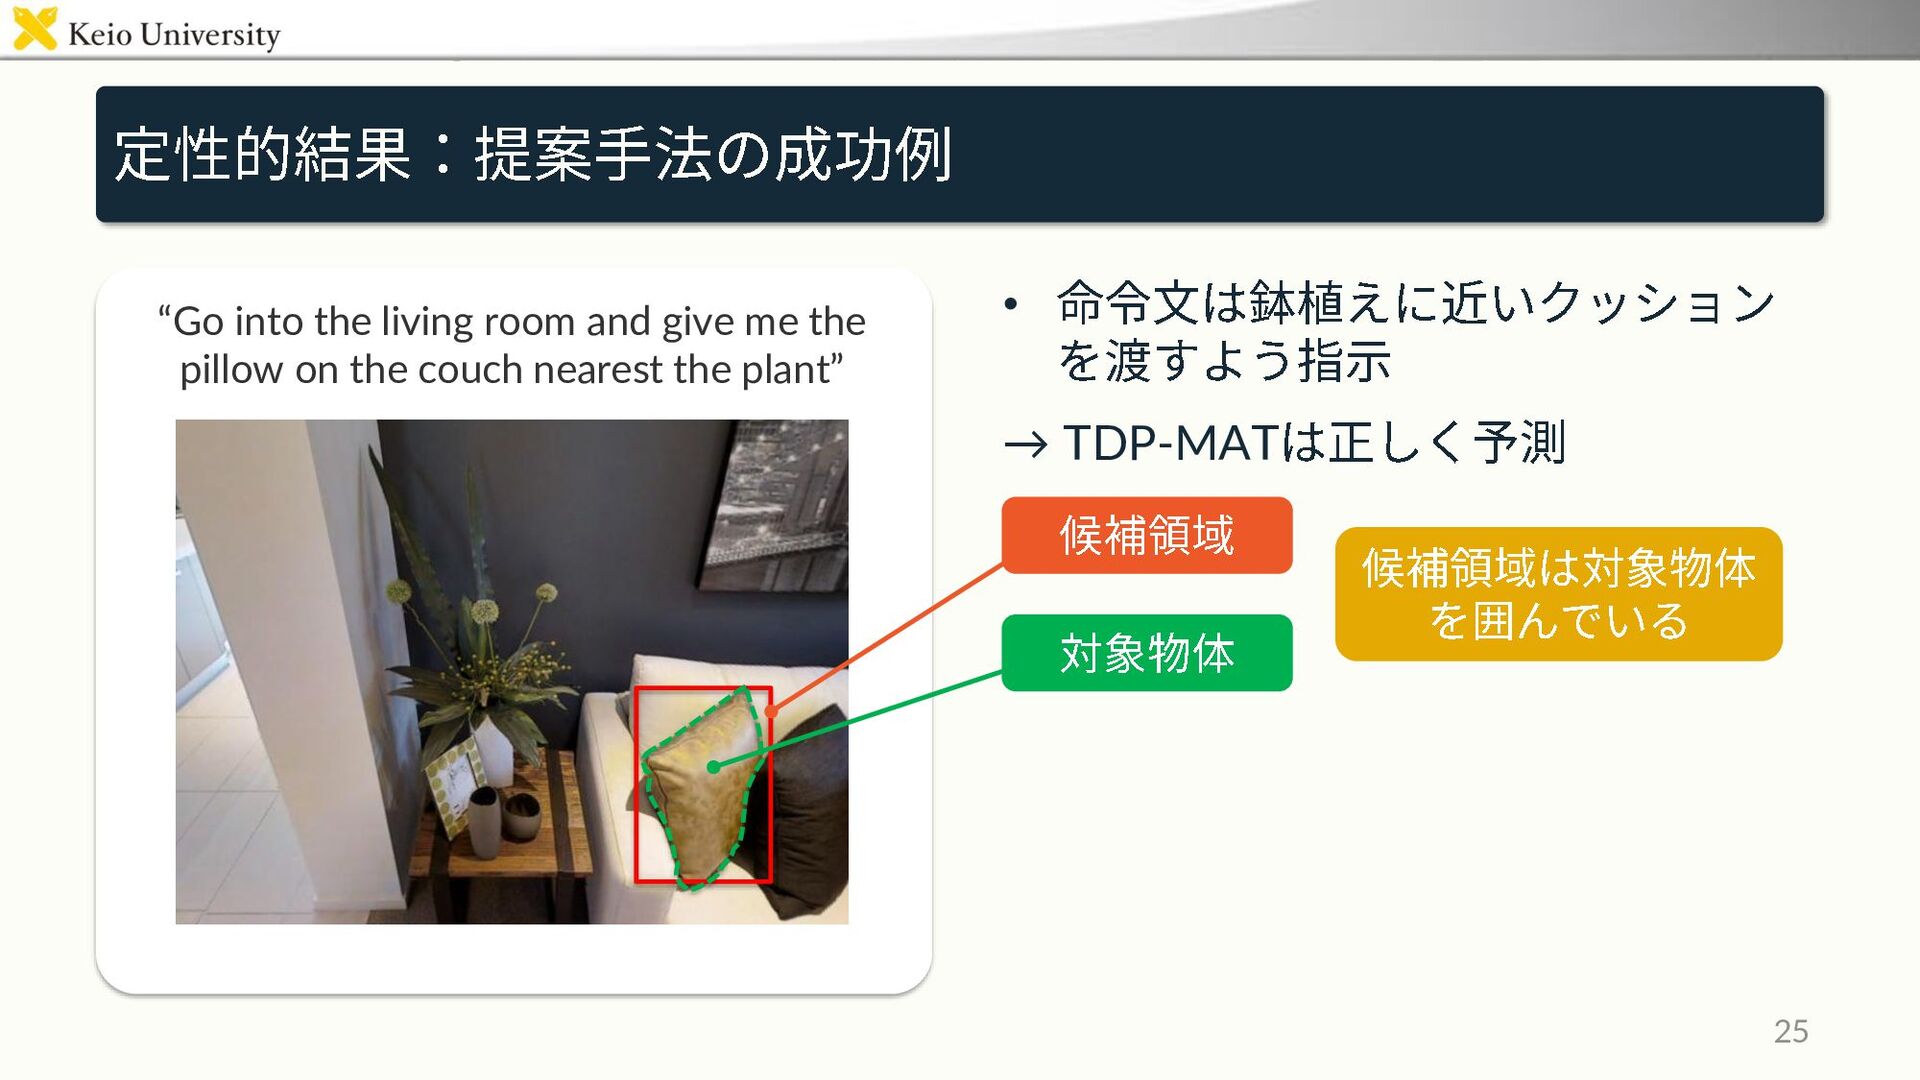
“Go into the living room and give me the pillow
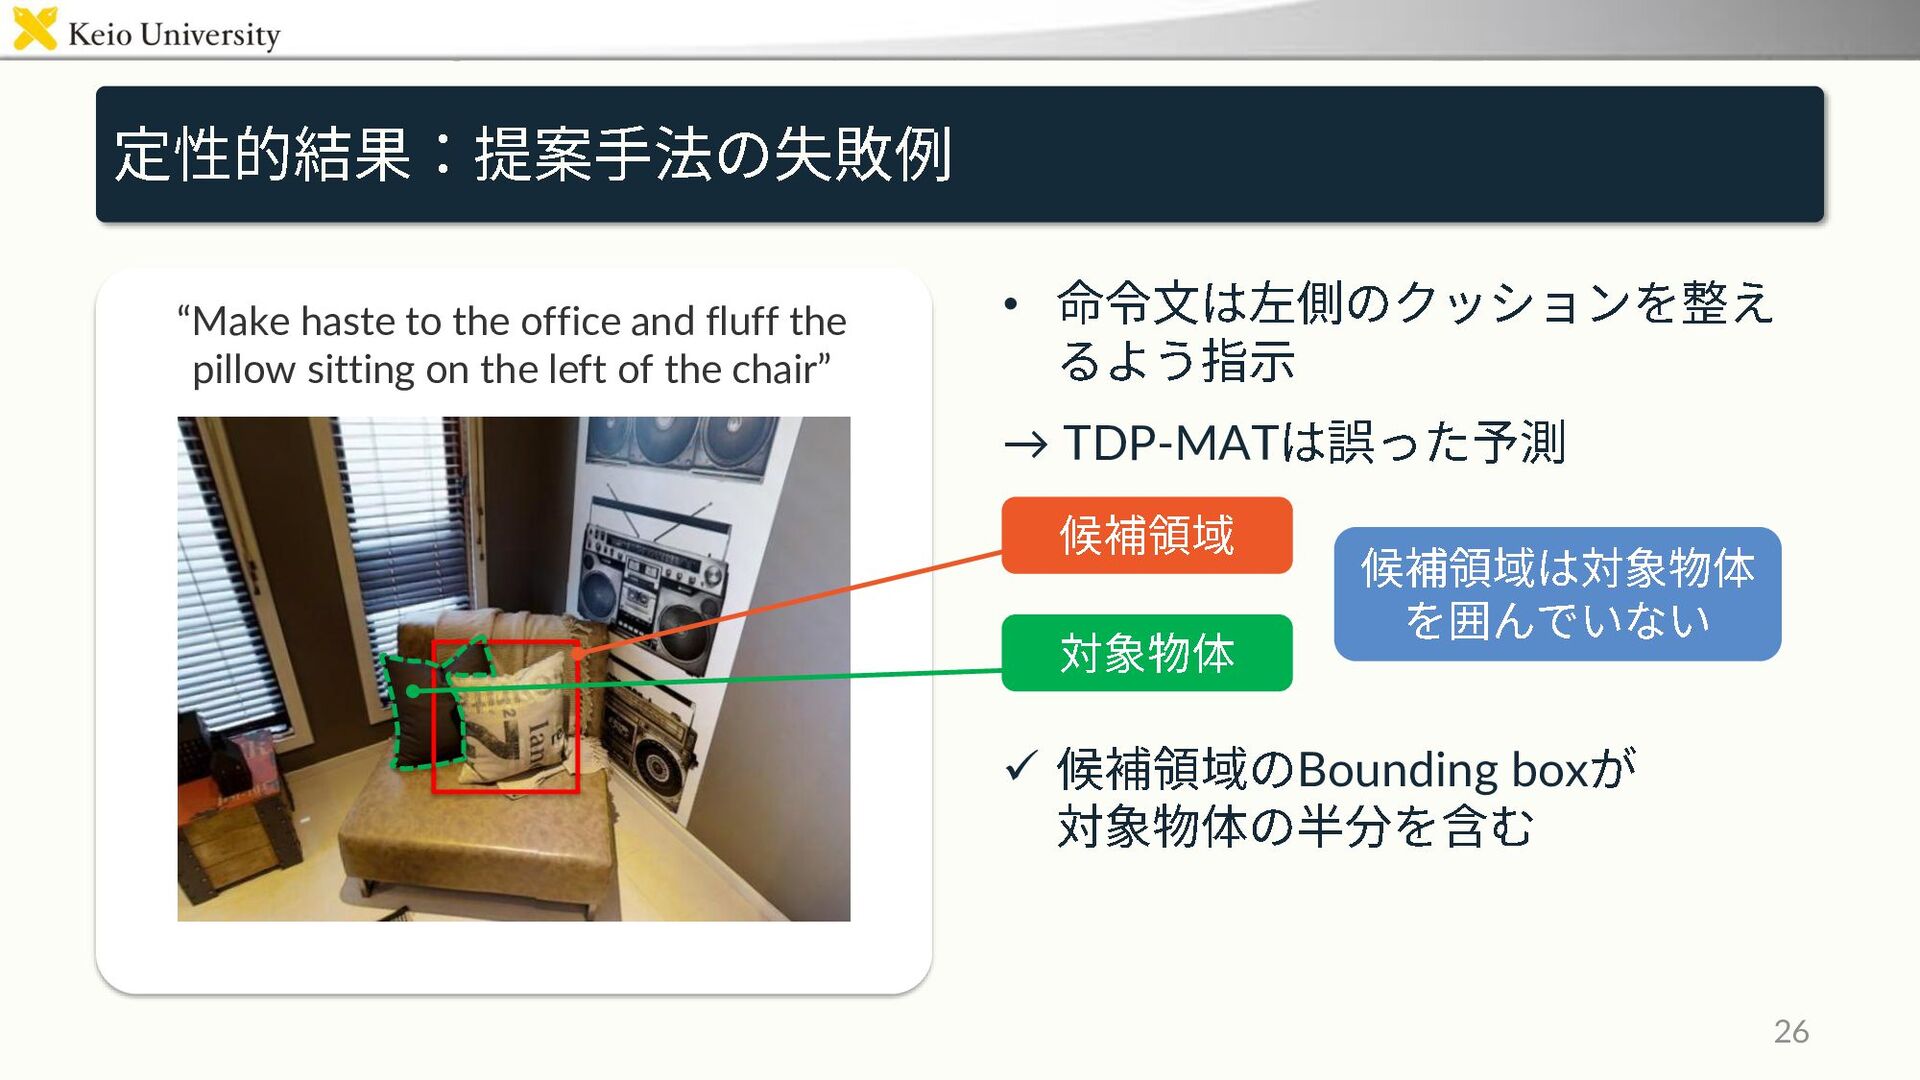
on the couch nearest the plant” 25 • → TDP-MAT
26 • → TDP-MAT ✓ Bounding box “Make haste to
the office and fluff the pillow sitting on the left of the chair”
• Acc [%] : 27 Condition Acc [%] ↑ Baseline
: TDU [Ishikawa+, IROS21] 73.3 0.485 Ours : TDP-MAT W/o MAT 72.5 3.55 W/o MAT + Smaller learning rate 74.4 0.831 W/o CLIP & Perceiver 74.1 1.47 W/o Pretraining 73.1 2.24 Full 75.3 0.691 +2.0
28 Condition Acc [%] ↑ Baseline : TDU [Ishikawa+, IROS21]
73.3 0.485 Ours : TDP-MAT W/o MAT 72.5 3.55 W/o MAT + Smaller learning rate 74.4 0.831 W/o CLIP & Perceiver 74.1 1.47 W/o Pretraining 73.1 2.24 Full 75.3 0.691 +2.8 - - 5 - ( ) - Smaller learning rate : 1/8 -
29 Condition Acc [%] ↑ Baseline : TDU [Ishikawa+, IROS21]
73.3 0.485 Ours : TDP-MAT W/o MAT 72.5 3.55 W/o MAT + Smaller learning rate 74.4 0.831 W/o CLIP & Perceiver 74.1 1.47 W/o Pretraining 73.1 2.24 Full 75.3 0.691 +1.2 - CLIP Encoders, Perceiver Module, - Cross Attention
30 Condition Acc [%] ↑ Baseline : TDU [Ishikawa+, IROS21]
73.3 0.485 Ours : TDP-MAT W/o MAT 72.5 3.55 W/o MAT + Smaller learning rate 74.4 0.831 W/o CLIP & Perceiver 74.1 1.47 W/o Pretraining 73.1 2.24 Full 75.3 0.691 +2.2 - TDU
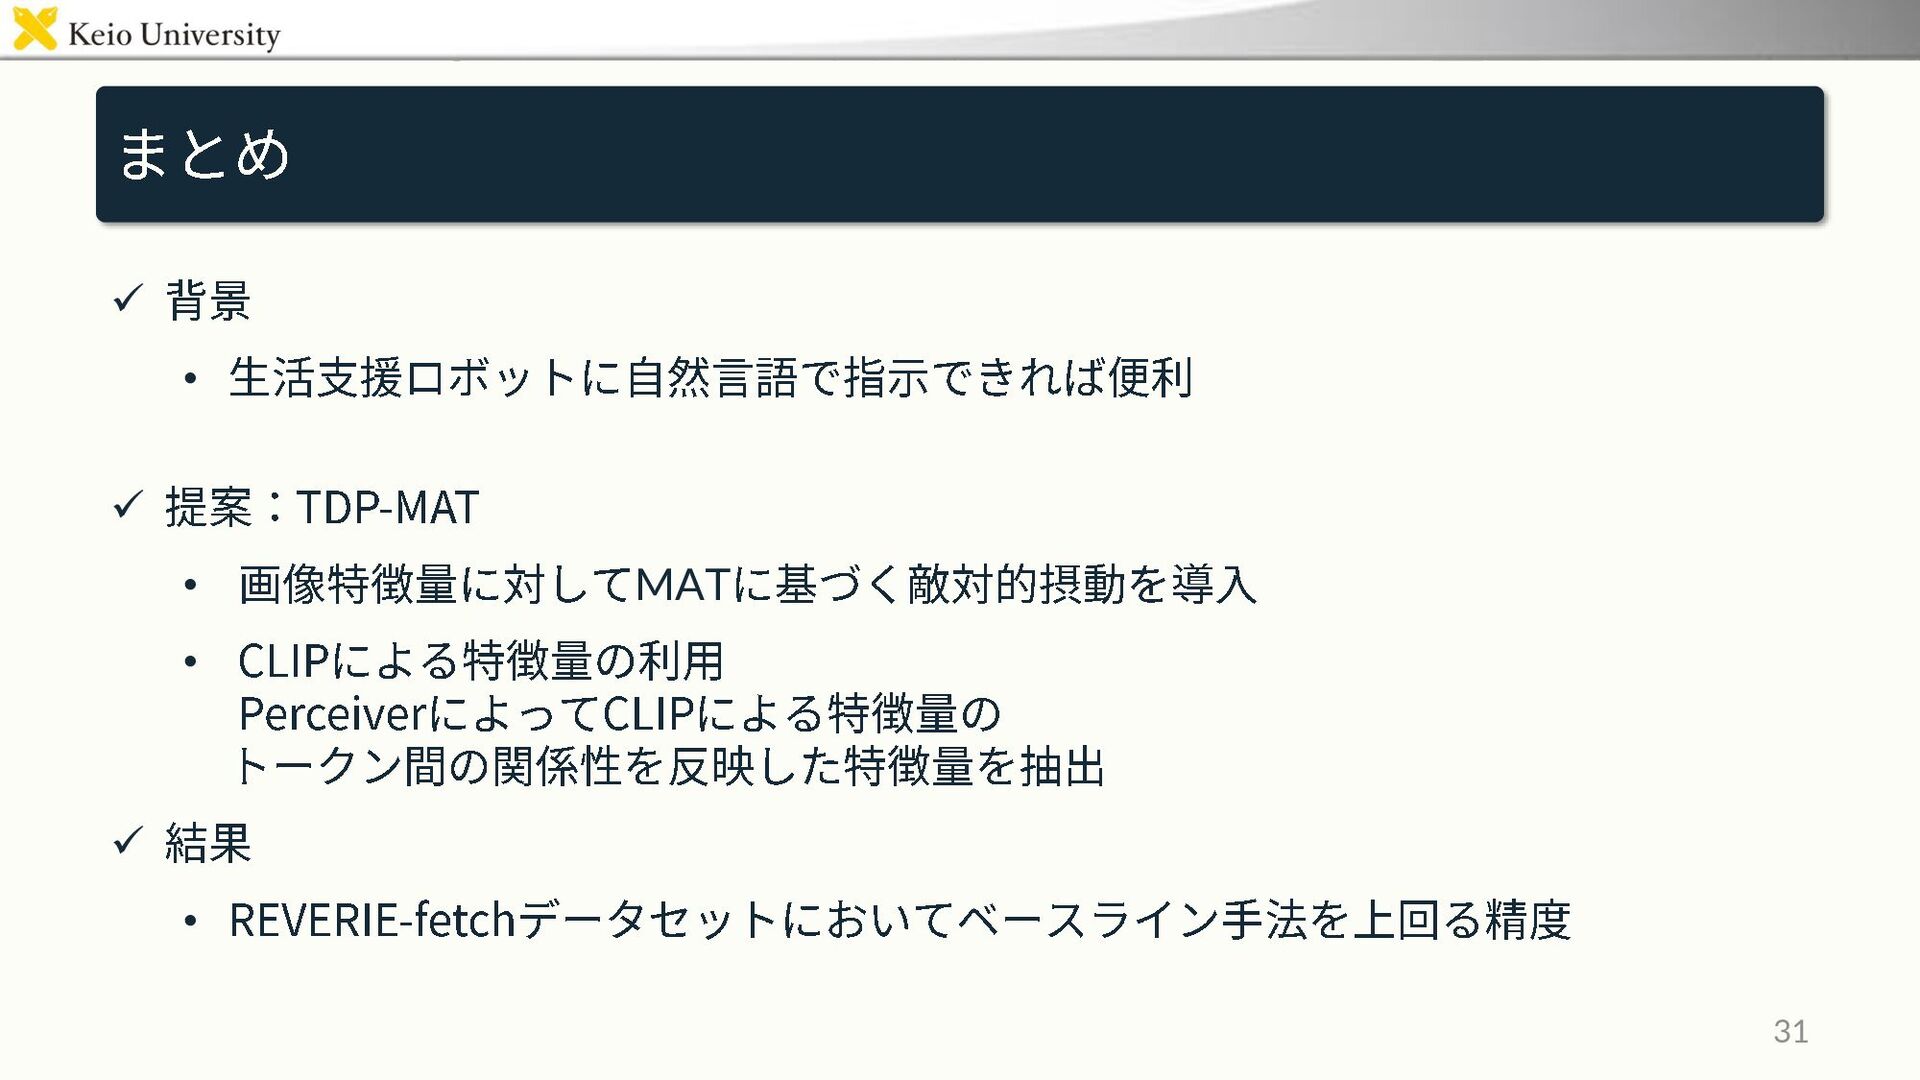
✓ • ✓ • MAT • ✓ • 31
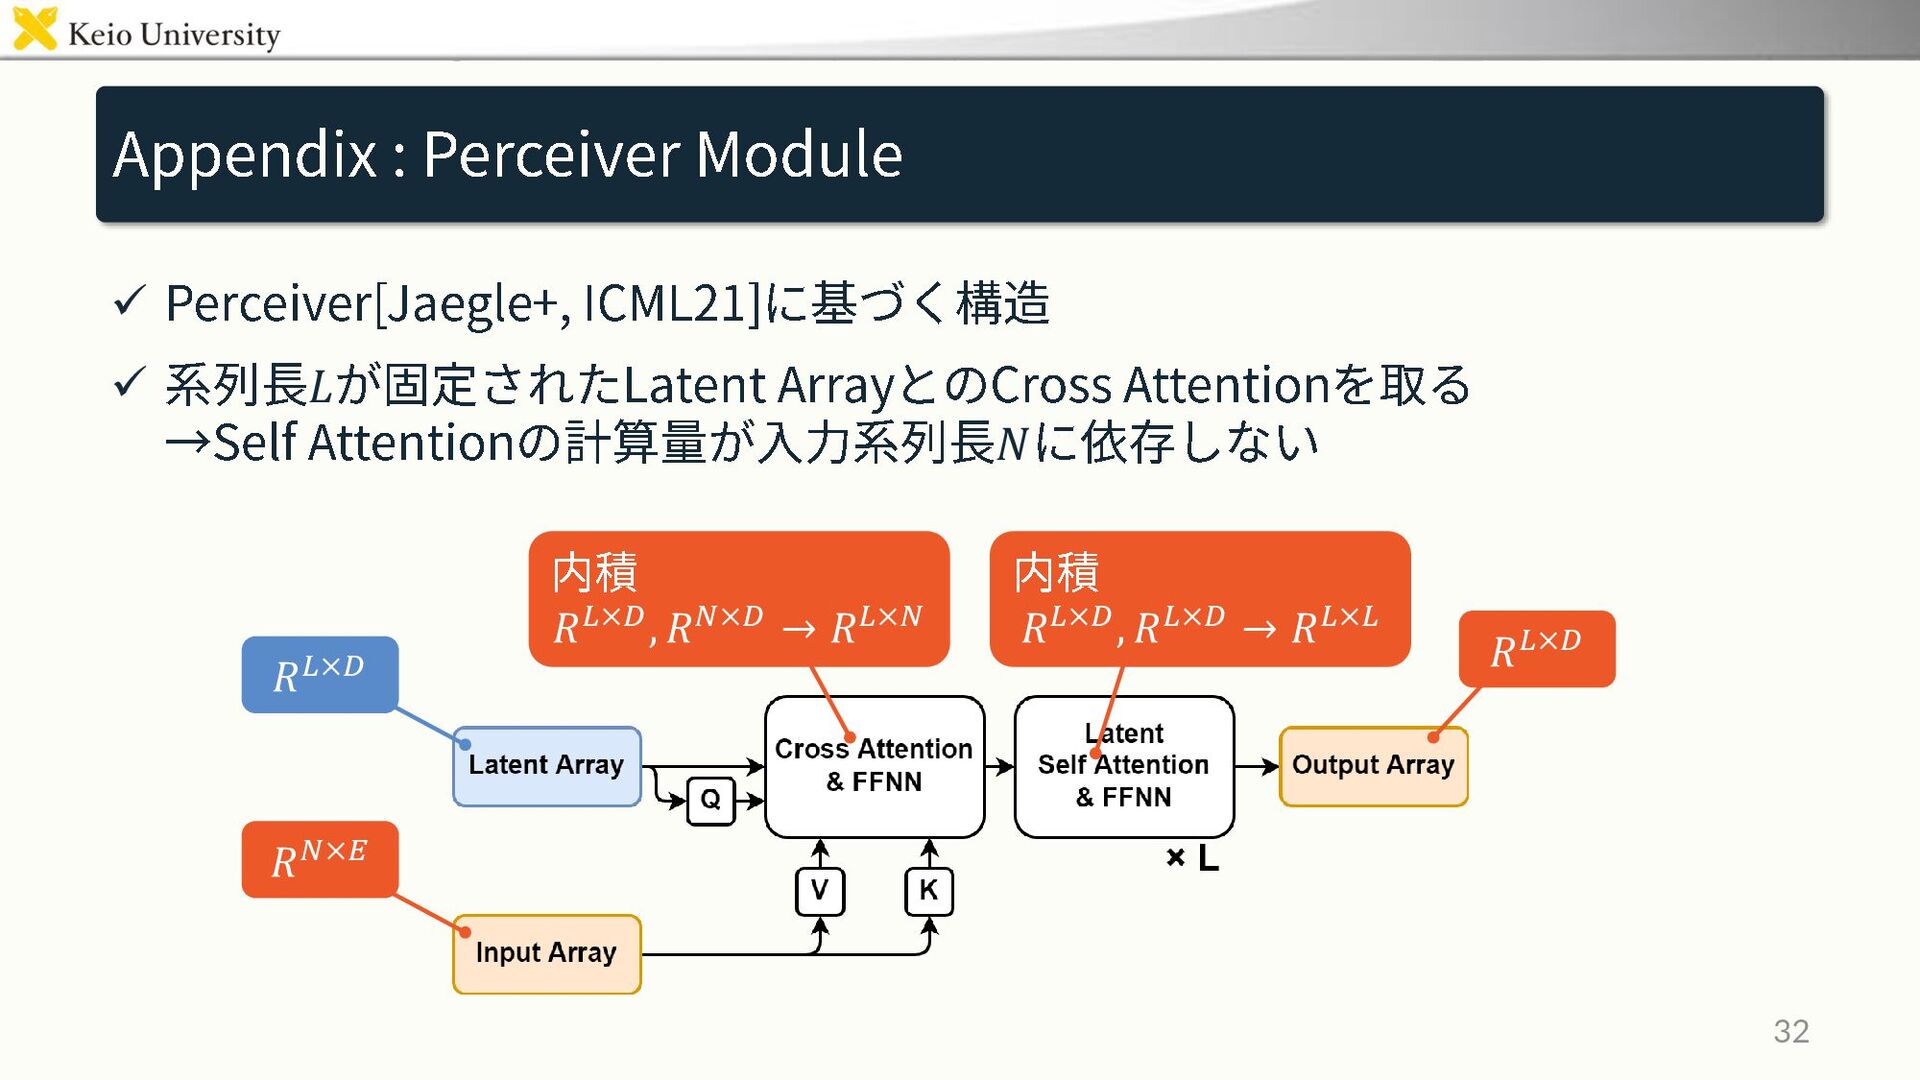
✓ ✓ 𝐿 𝑁 𝑅𝐿×𝐷 𝑅𝑁×𝐸 𝑅𝐿×𝐷, 𝑅𝑁×𝐷 → 𝑅𝐿×𝑁
𝑅𝐿×𝐷 𝑅𝐿×𝐷, 𝑅𝐿×𝐷 → 𝑅𝐿×𝐿 32
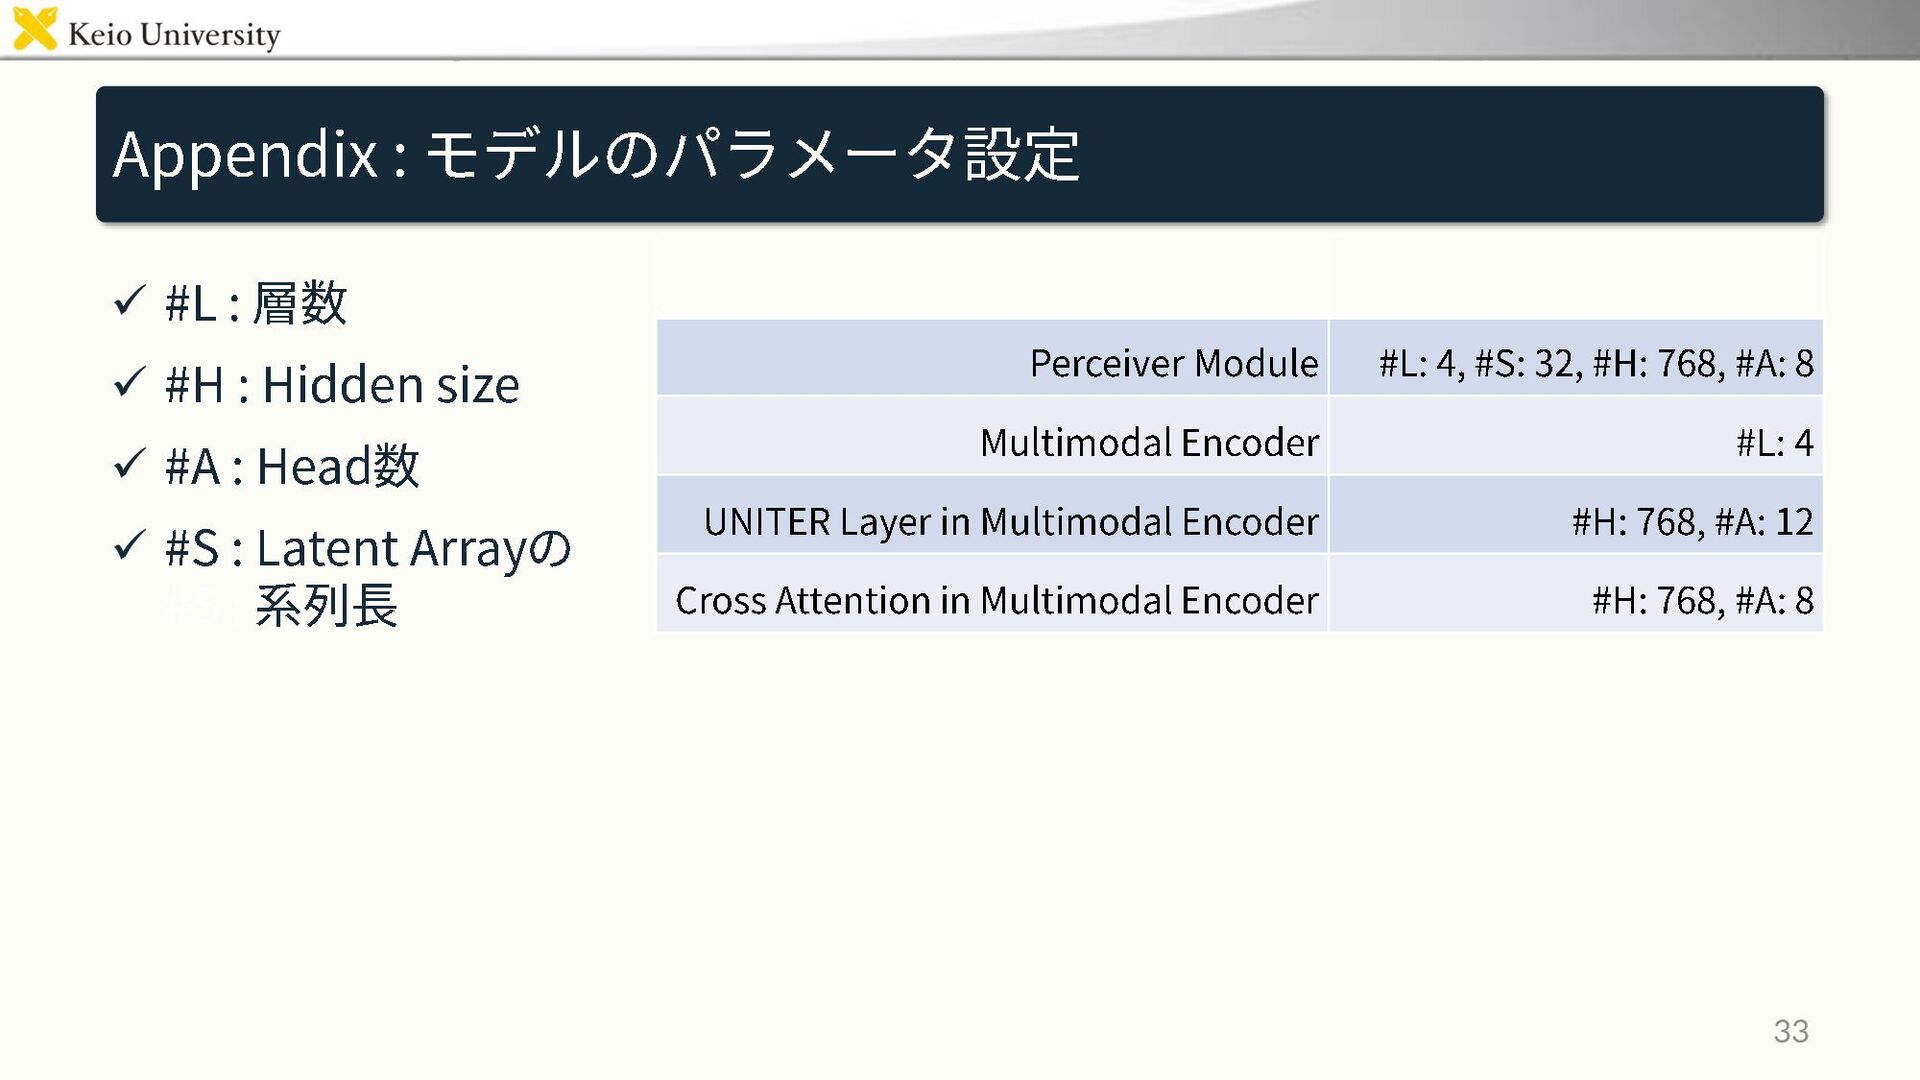
✓ ✓ ✓ ✓ 33
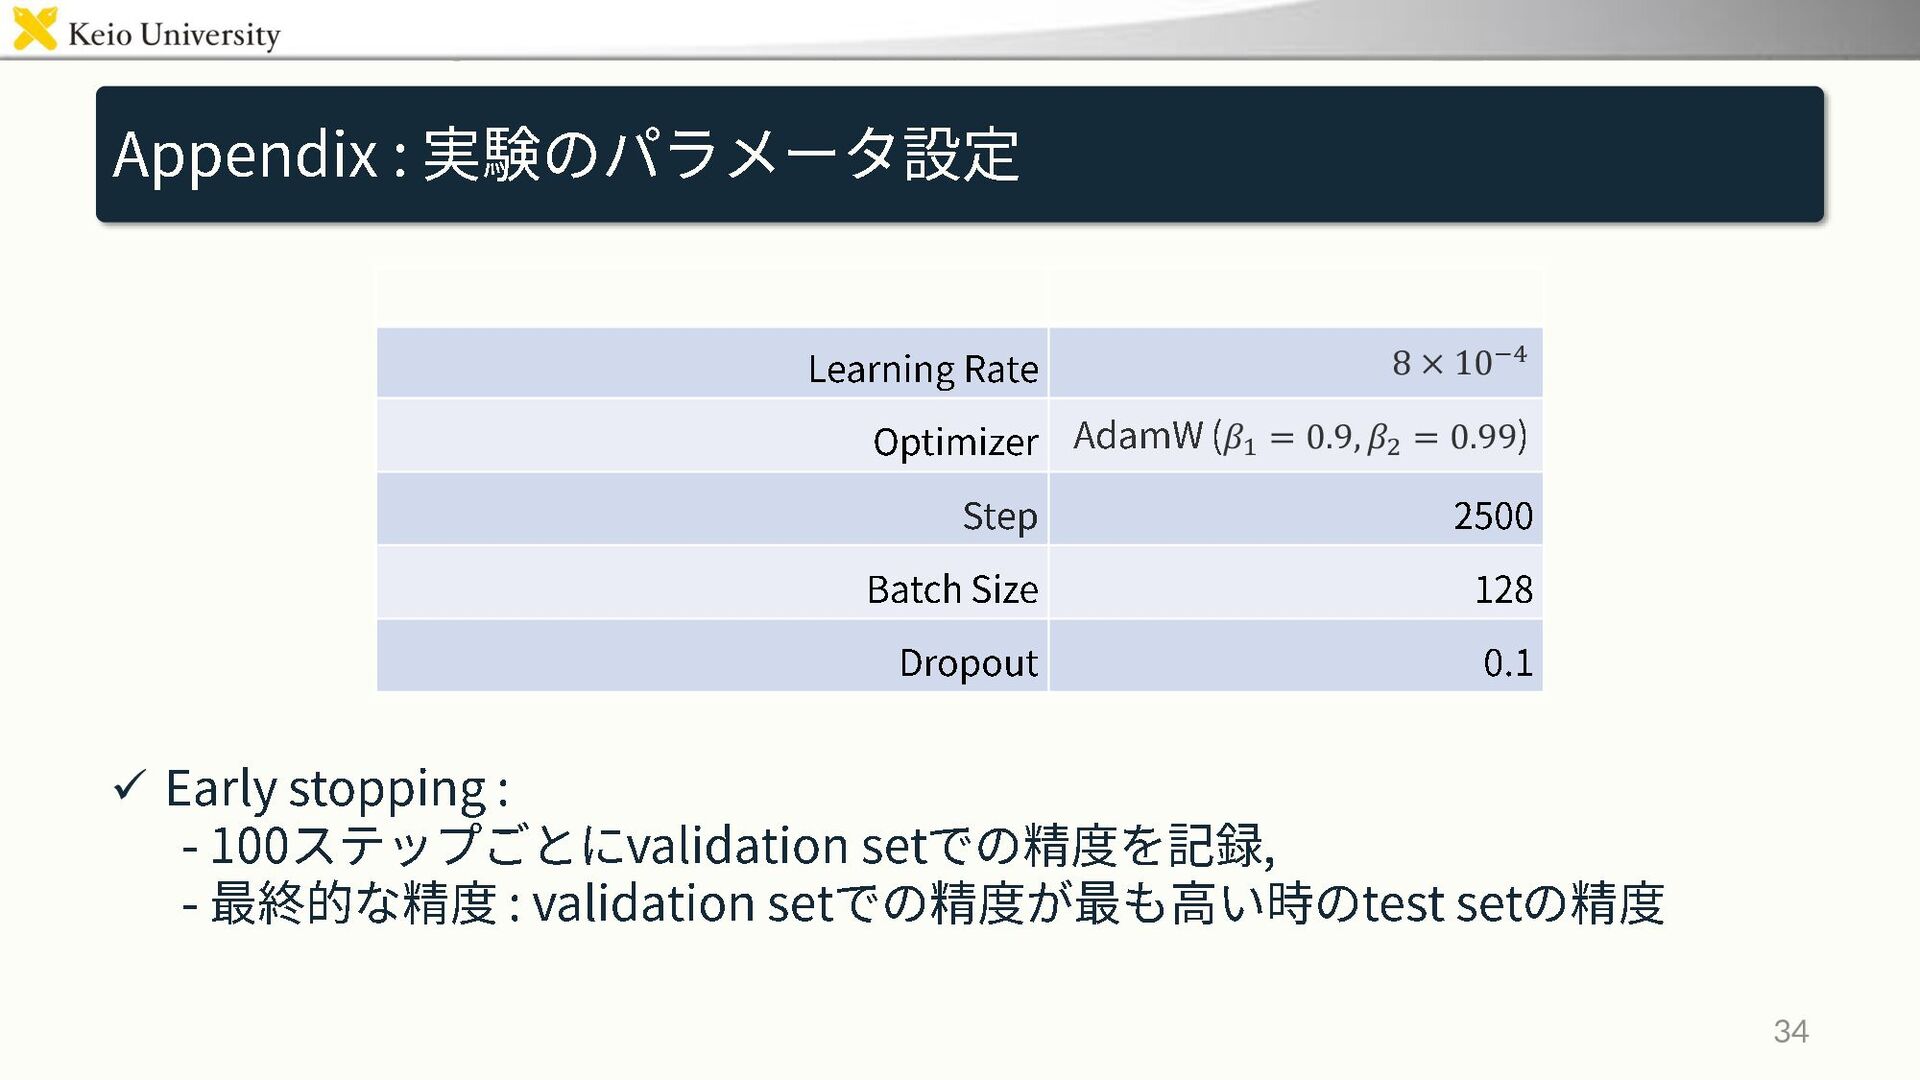
✓ 34 8 × 10⁻⁴ 𝛽1 = 0.9, 𝛽2 =
0.99
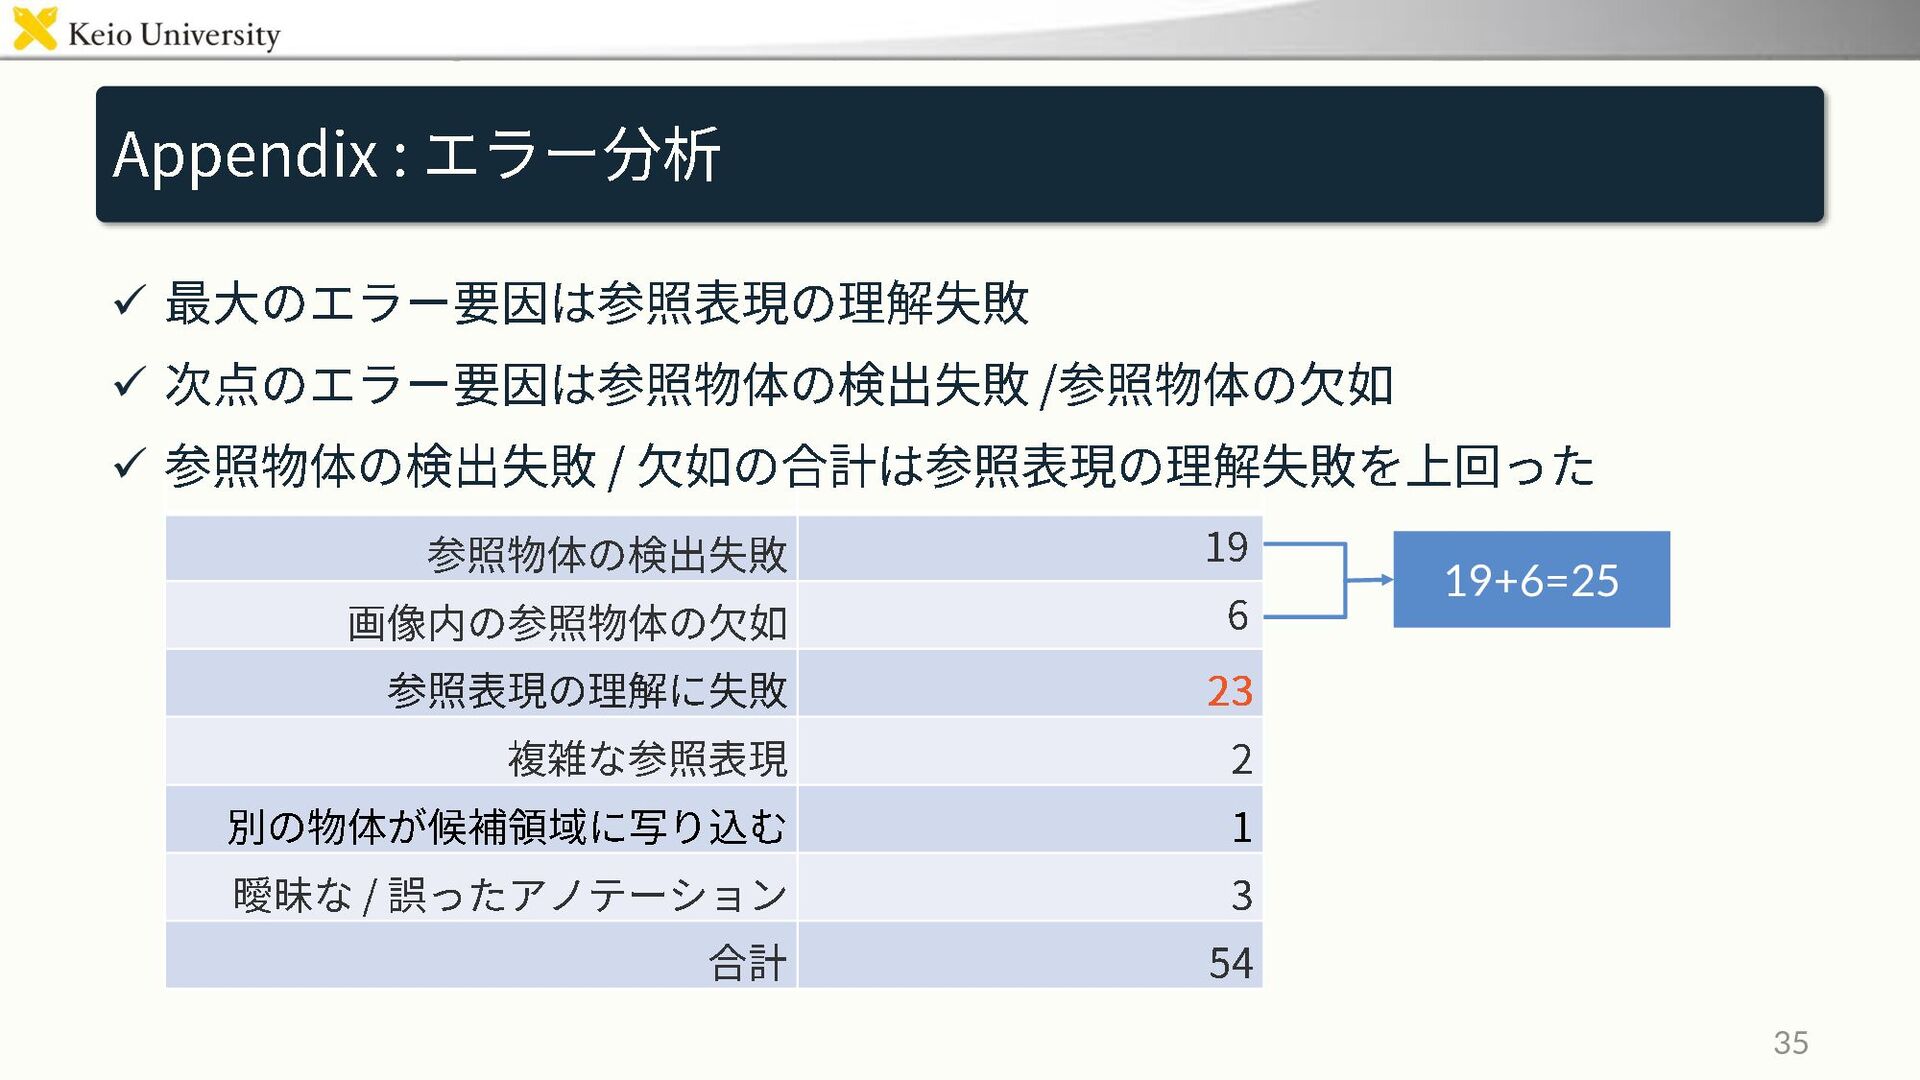
✓ ✓ ✓ 35 19+6=25
More Decks by Semantic Machine Intelligence Lab., Keio Univ.
See All by Semantic Machine Intelligence Lab., Keio Univ.
慶應義塾大学 AI実践05 論文執筆の仕組み化
keio_smilab
PRO
7
3.9k
[EMNLP26] RIGEL: Self-Distilled Score Adaptation for Image and Video Captioning Evaluation
keio_smilab
PRO
0
170
[RSJ26] Building a VLA Model Based on Self-Distilled Classification
keio_smilab
PRO
0
230
[RSJ26] AnoleVLA: Lightweight Vision-Language-Action Model with Deep State Space Models for Mobile Manipulation
keio_smilab
PRO
0
200
[RSJ26] NarrativeFlow: Flow-Based Vision-Language-Action Model Using Robot Velocity Fields
keio_smilab
PRO
0
270
[RSJ26] Flow as Flow: Modeling Robot Velocity Fields as Probability Velocity Fields
keio_smilab
PRO
1
300
[RSJ26] Hierarchy-Aware Multimodal Retrieval-Augmented Generation for Embodied Question Answering
keio_smilab
PRO
1
210
[MIRU26] Open-Vocabulary Intention-Guided Object Detection in Diverse Scenes
keio_smilab
PRO
0
260
[Journal club] Evo-1: Lightweight Vision-Language-Action Model with Preserved Semantic Alignment
keio_smilab
PRO
0
79
Other Decks in Technology
See All in Technology
速くなった開発の効果をどう推し量るのか
bulbulpaul
0
110
Context != Context: One window, many lifecycles (AI Native DevCon, Nov 2026)
birgitta410
0
130
農夫は秘伝のタレを知らない - NOBODY KNOWS THE HIDDEN SOURCE - Kaggriculture 3rd Place Solution
masspeaks
0
290
GCASアップデート(202607-202610)
techniczna
1
330
ゼロから作るWebアプリの新定番!?Amplify Gen 2 × AWS Blocksで実現する「開発速度とRDBの柔軟性のいいとこ取り」
amixedcolor
1
250
Steering と Hook (チームの決まりを守らせる) | 目指せ Kiro マスター 06
inariku
PRO
2
120
Kiro を使うコツ (頼み方、覚えさせ方、任せ方) | 目指せ Kiro マスター 09
inariku
PRO
3
150
小さなエージェントから始めてみよう!実践コンテキストエンジニアリング
iwamot
PRO
0
120
ライフワーク「猫でもわかるDirectConnect」
kentapapa
0
330
サボる子はいねぇがー!AgentCoreハーネスの脆弱性に学ぶ、エージェントの入力バリデーション
iwamot
PRO
5
330
Bots in Kiro Crew (One point of contact for ongoing work) | Kiro: Zero to Hero 12
inariku
PRO
1
130
AI時代に求められる優秀なTechLeadの振る舞い
pospome
11
16k
Featured
See All Featured
Game over? The fight for quality and originality in the time of robots
wayneb77
1
330
StorybookのUI Testing Handbookを読んだ
zakiyama
31
7.1k
JavaScript: Past, Present, and Future - NDC Porto 2020
reverentgeek
52
6.2k
[SF Ruby Conf 2025] Rails X
palkan
3
1.5k
Navigating Weather and Climate Data
rabernat
0
590
HTML-Aware ERB: The Path to Reactive Rendering @ RubyCon 2026, Rimini, Italy
marcoroth
6
920
Large-scale JavaScript Application Architecture
addyosmani
516
110k
16th Malabo Montpellier Forum Presentation
akademiya2063
PRO
0
460
How to Build an AI Search Optimization Roadmap - Criteria and Steps to Take #SEOIRL
aleyda
1
2.2k
Odyssey Design
rkendrick25
PRO
3
940
Between Models and Reality
mayunak
4
580
Fireside Chat
paigeccino
43
4.1k


 keio_smilab
 bulbulpaul
 birgitta410
 masspeaks
 techniczna
 amixedcolor
 inariku
 iwamot
 kentapapa
 pospome
 wayneb77
 zakiyama
 reverentgeek
 palkan
 rabernat
 marcoroth
 addyosmani
 akademiya2063
 aleyda
 rkendrick25
 mayunak
 paigeccino