Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
researchContentsForB4
Search
Sponsored
·
Ship Features Fearlessly
Turn features on and off without deploys. Used by thousands of Ruby developers.
→
k-hasegw
April 24, 2023
Programming
120
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
researchContentsForB4
k-hasegw
April 24, 2023
More Decks by k-hasegw
See All by k-hasegw
progressReport_k-hasegw_20230220.pdf
khasegw0831
0
120
progressReport_k-hasegw_20230131.pdf
khasegw0831
0
370
progressReport_k-hasegw_20230117
khasegw0831
0
390
f-sync_algo
khasegw0831
0
270
Other Decks in Programming
See All in Programming
UnityでSystem.Net.WebSocketsなWebSocketサーバが動かないのでUnity Monoのコードを覗いてみた / about implementing websocket server with unity mono
drumath2237
1
200
cdk deploy JawsSonic #MARATHONしながらAWSリソースをデプロイしてみよう
akihisaikeda
2
140
GKE で Pod の見方を変えたら、スケールアウト時の挙動を真に捉えられた話
stkk
0
130
標準パッケージに uuid が追加された 背景から見る Go らしい意思決定 / go_127_uuid_decision
convto
5
7.5k
The Rails Doctrine Decade
koic
2
160
LoopHub - ローカルで動く GitHub で、AI と共同開発
jugyo
1
560
スマート反転とウェブアクセシビリティ
camiha
0
210
GraphRAGのKnowledge Graphを 直接!見る/View-GraphRAG's-KnowledgeGraph-directly!
tyumugi1113
1
350
Augmenting AI with the Power of Jakarta EE
ivargrimstad
0
220
Snowflakeで業務アプリを作ろう。 Snowflakeのアプリ機能解説&実践ガイド
ayumu_yamaguchi
1
280
仕様駆動開発による爆速プロダクト開発 / Bakusoku Spec Driven Development
kobakei
0
120
thread_parallel_with_free-threaded_Python_and_NumPy.pdf
riku_sakamoto
0
350
Featured
See All Featured
Unlocking the hidden potential of vector embeddings in international SEO
frankvandijk
0
940
The Success of Rails: Ensuring Growth for the Next 100 Years
eileencodes
47
8.3k
The Anti-SEO Checklist Checklist. Pubcon Cyber Week
ryanjones
0
250
The AI Revolution Will Not Be Monopolized: How open-source beats economies of scale, even for LLMs
inesmontani
PRO
3
3.7k
Ten Tips & Tricks for a 🌱 transition
stuffmc
1
230
Designing for humans not robots
tammielis
254
26k
RailsConf & Balkan Ruby 2019: The Past, Present, and Future of Rails at GitHub
eileencodes
141
35k
My Coaching Mixtape
mlcsv
0
320
Code Reviewing Like a Champion
maltzj
528
40k
Mozcon NYC 2025: Stop Losing SEO Traffic
samtorres
1
550
Leveraging LLMs for student feedback in introductory data science courses - posit::conf(2025)
minecr
1
400
Exploring the Power of Turbo Streams & Action Cable | RailsConf2023
kevinliebholz
37
6.6k
Transcript
MASUZAWA LABORATORY – ALGORITHM DESIGN LABORATORY (http://www-masu.ist.osaka-u.ac.jp) Department of Computer
Science, Graduate School of Information Science and Technology, Osaka University. 視野に欠損のある モバイルロボット群の アルゴリズム 増澤研究室 M1 長谷川 和輝
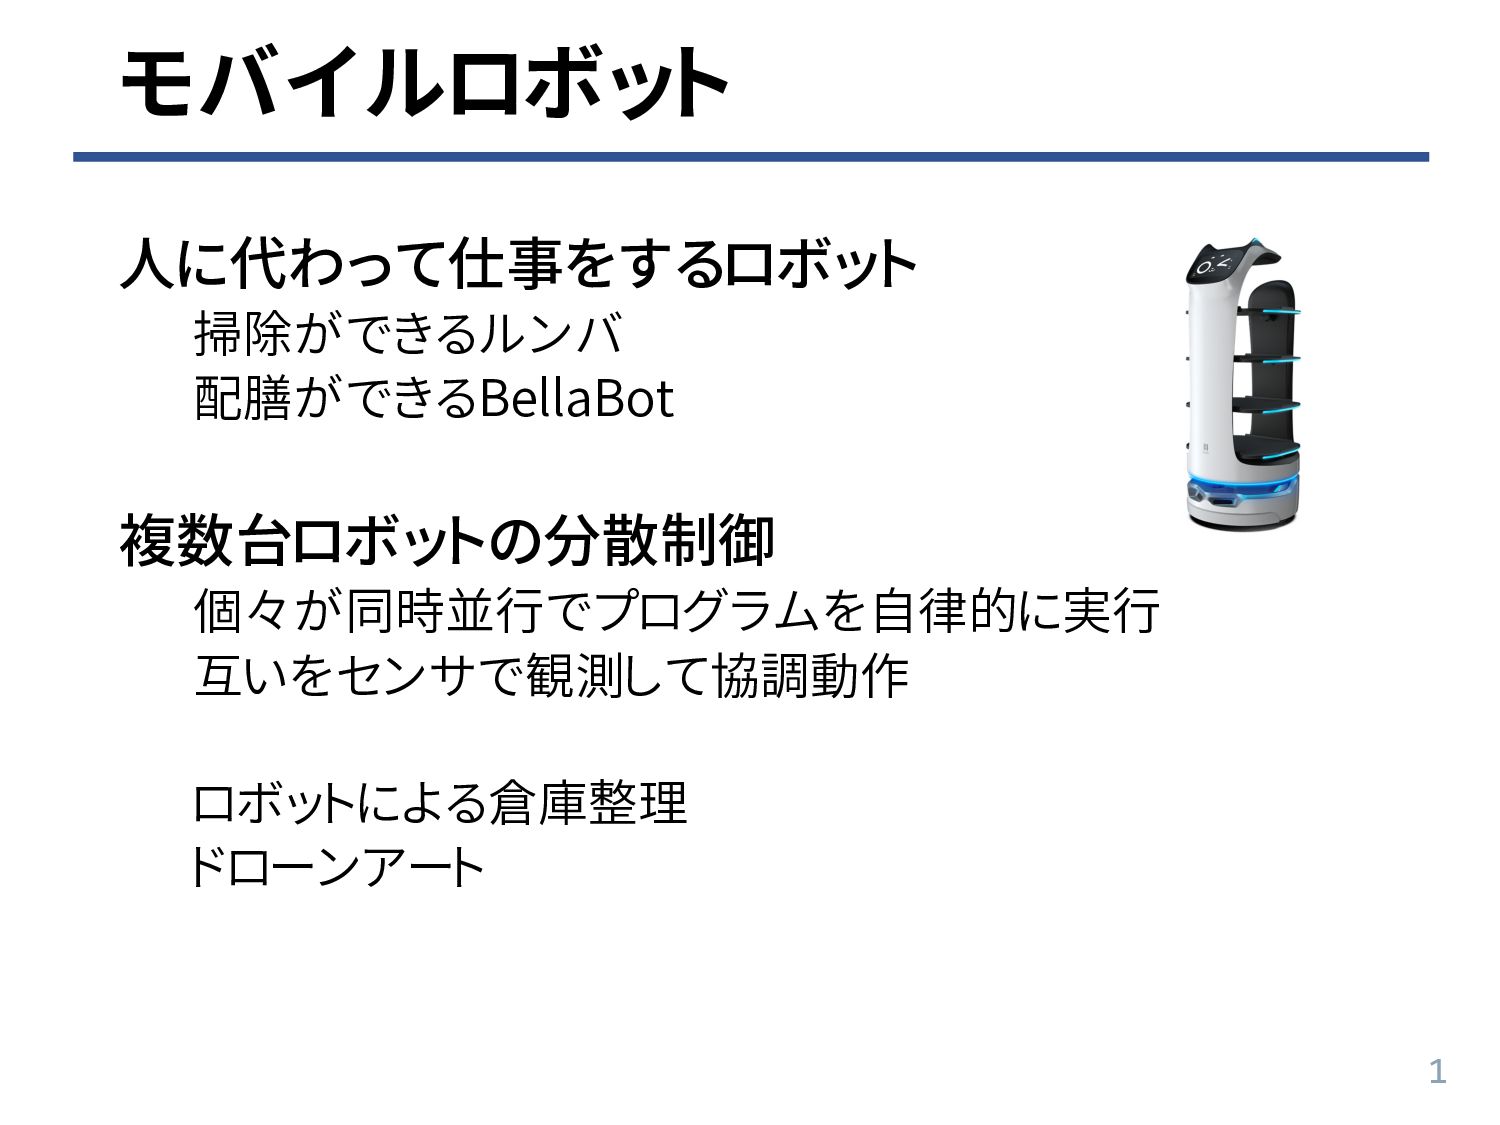
1 モバイルロボット 人に代わって仕事をするロボット 掃除ができるルンバ 配膳ができるBellaBot 複数台ロボットの分散制御 個々が同時並行でプログラムを自律的に実行 互いをセンサで観測して協調動作 ロボットによる倉庫整理 ドローンアート
2 従来のモバイルロボット群モデル 他の全ロボットを観測できることを前提 視野が限定された研究が少ない 実機では全ロボットの観測は困難 観測用センサーの実装コストの高さ 障害物による観測の妨害 故障時に完全に停止してしまうリスク
3 研究概要 目的 視野の欠損したロボット群を制御する アルゴリズムの考案 研究計画 1次元モデルを考える ロボット均一配置問題 1次元モデルを2次元へ拡張 最近接の1体のみ見えるケース
最遠隔の1体のみ見えないケース k体のロボットが見える,見えないケースに拡張
ロボット均一配置問題
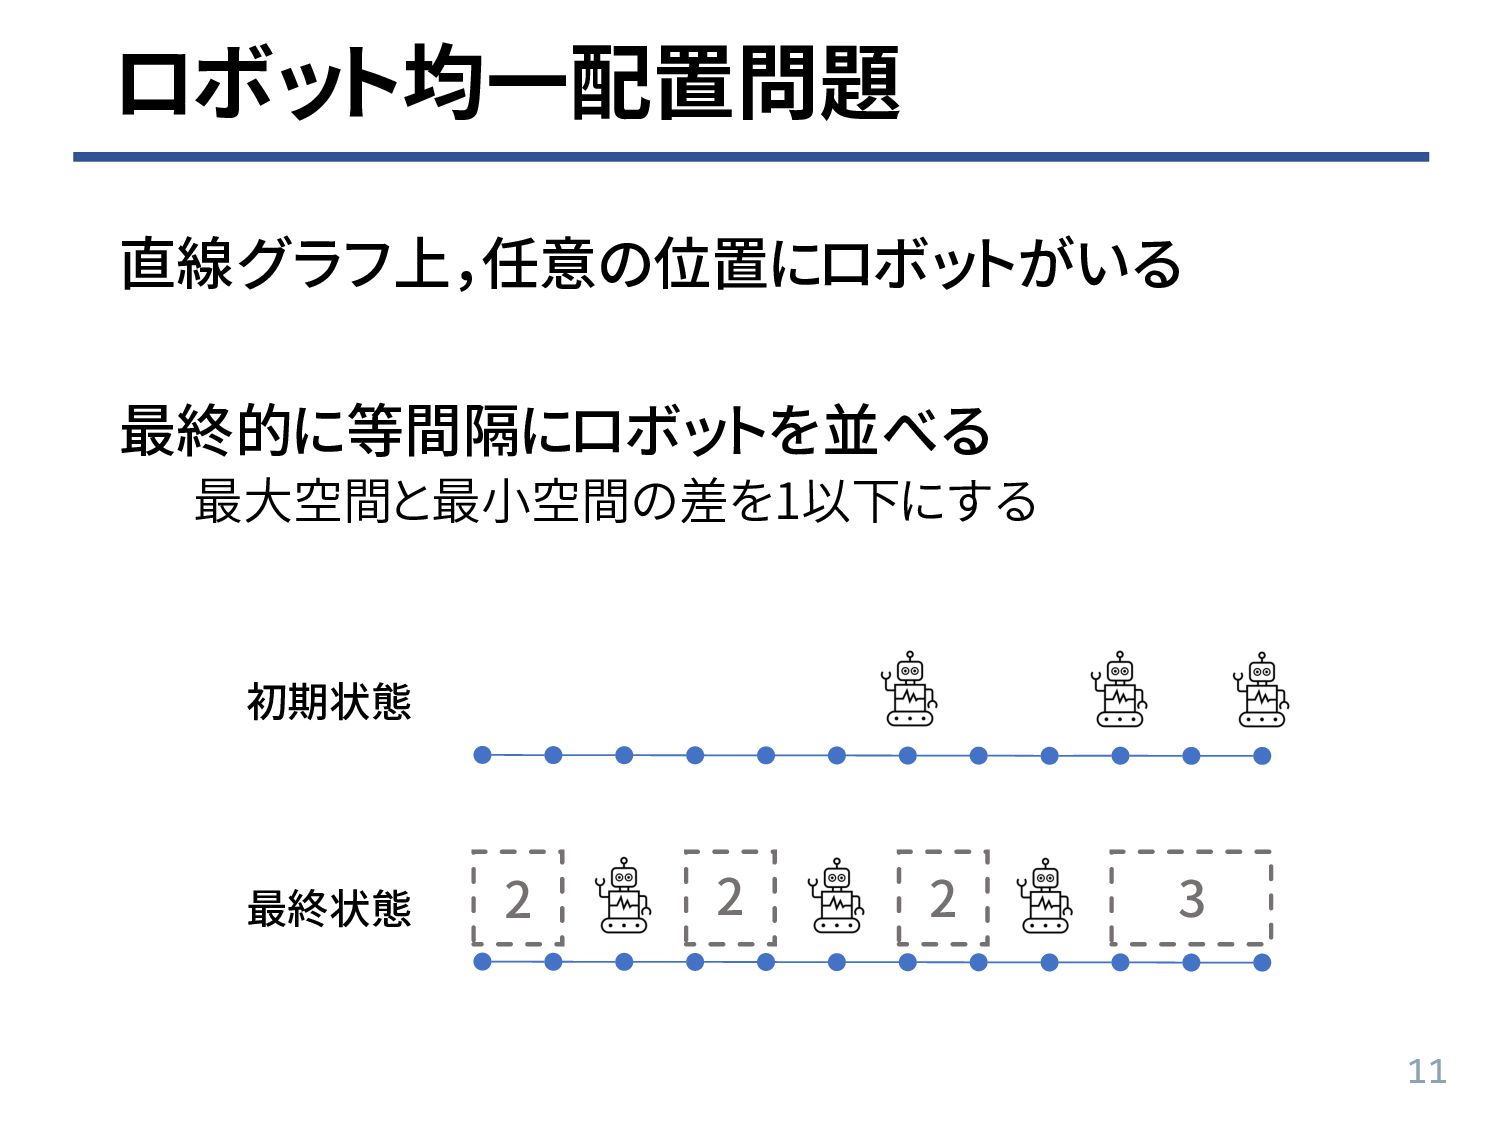
11 ロボット均一配置問題 直線グラフ上,任意の位置にロボットがいる 最終的に等間隔にロボットを並べる 最大空間と最小空間の差を1以下にする 初期状態 最終状態 2 2 2
3
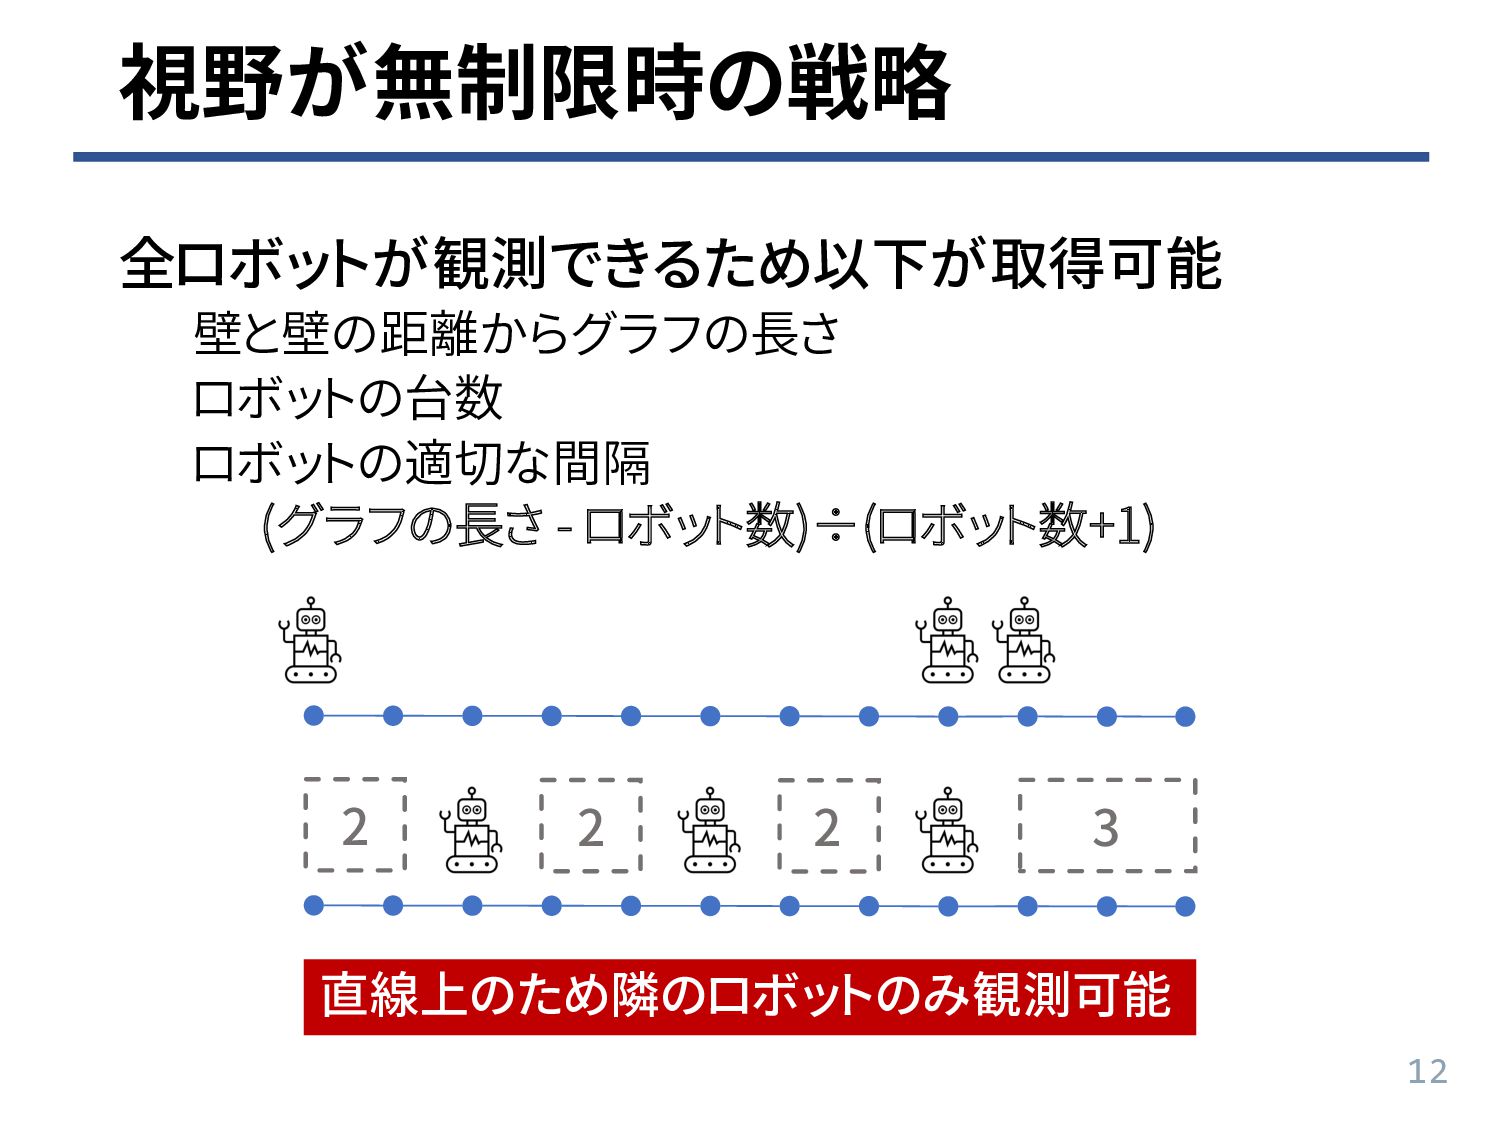
12 視野が無制限時の戦略 全ロボットが観測できるため以下が取得可能 壁と壁の距離からグラフの長さ ロボットの台数 ロボットの適切な間隔 (グラフの長さ - ロボット数)÷(ロボット数+1) 直線上のため隣のロボットのみ観測可能
2 2 2 3
13 視野制限下でのナイーブな戦略 アイデア 左右間隔が等しいことが理想 最大空間と最小空間の差が1の場合も許容 左右の差が2以上であれば差を縮めたい LCMサイクル 1. 左右をLook 2.
左右の差により移動先をCompute 差が2以上:大きい方の間隔を1縮める 差が1以下:動かない 3. Computeに応じてMove
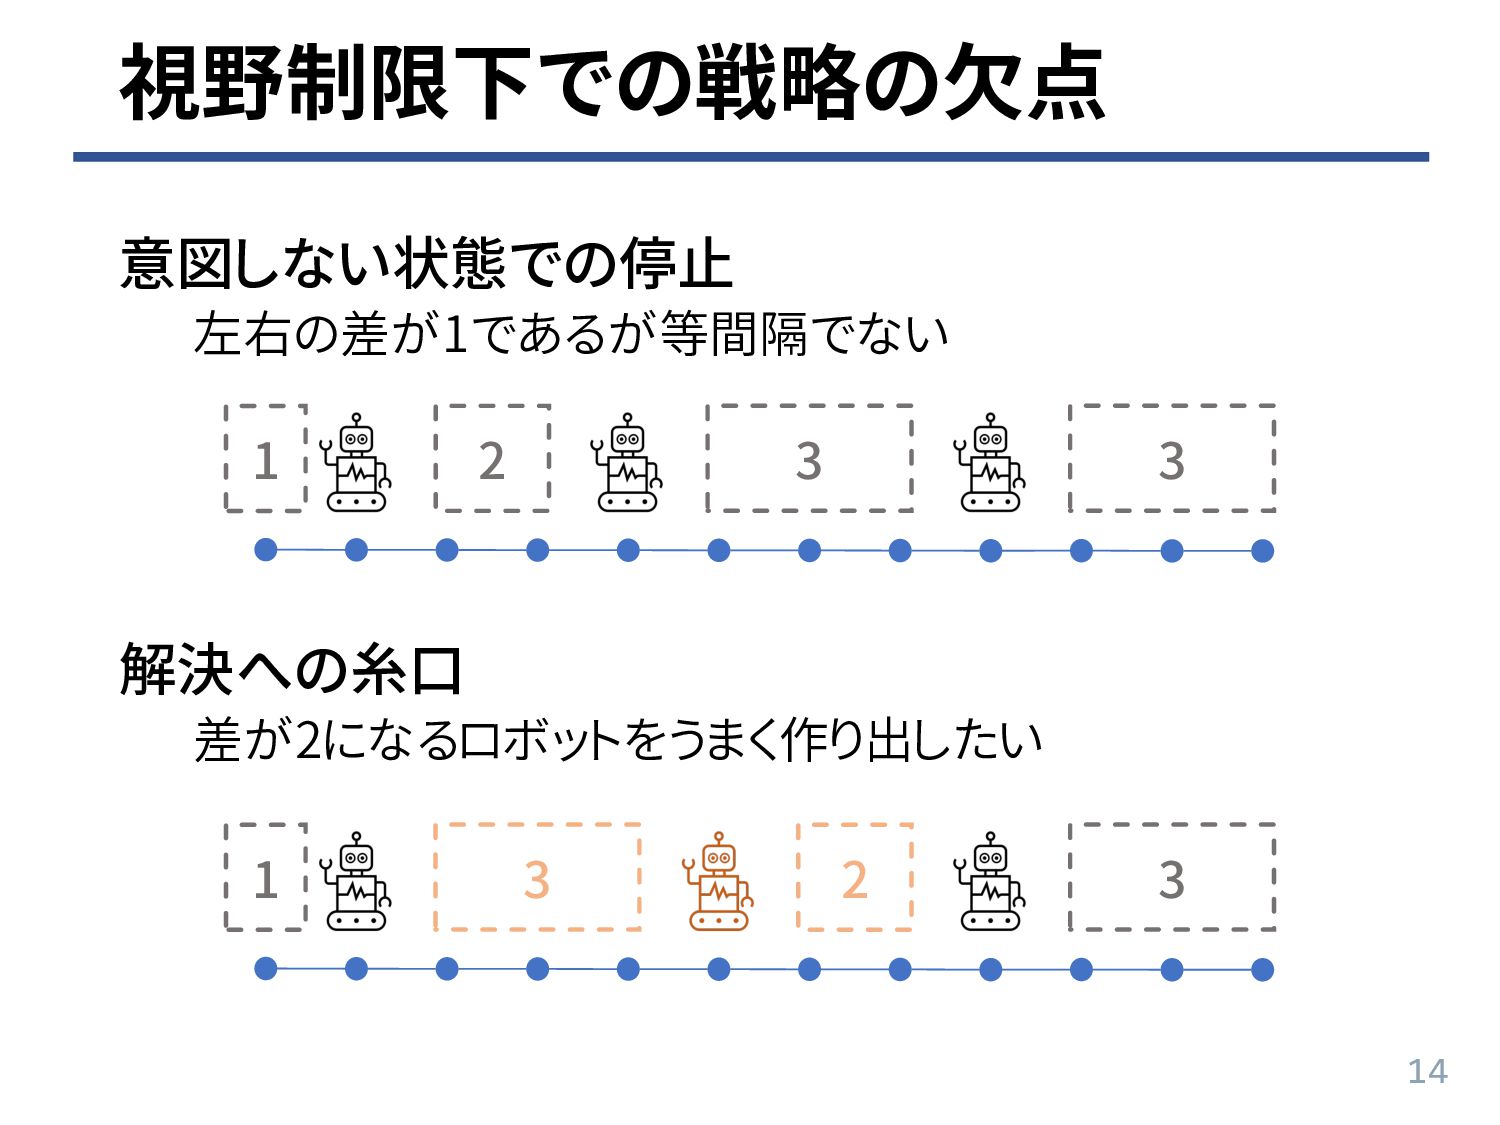
14 視野制限下での戦略の欠点 意図しない状態での停止 左右の差が1であるが等間隔でない 解決への糸口 差が2になるロボットをうまく作り出したい 2 1 3 3
2 1 3 3
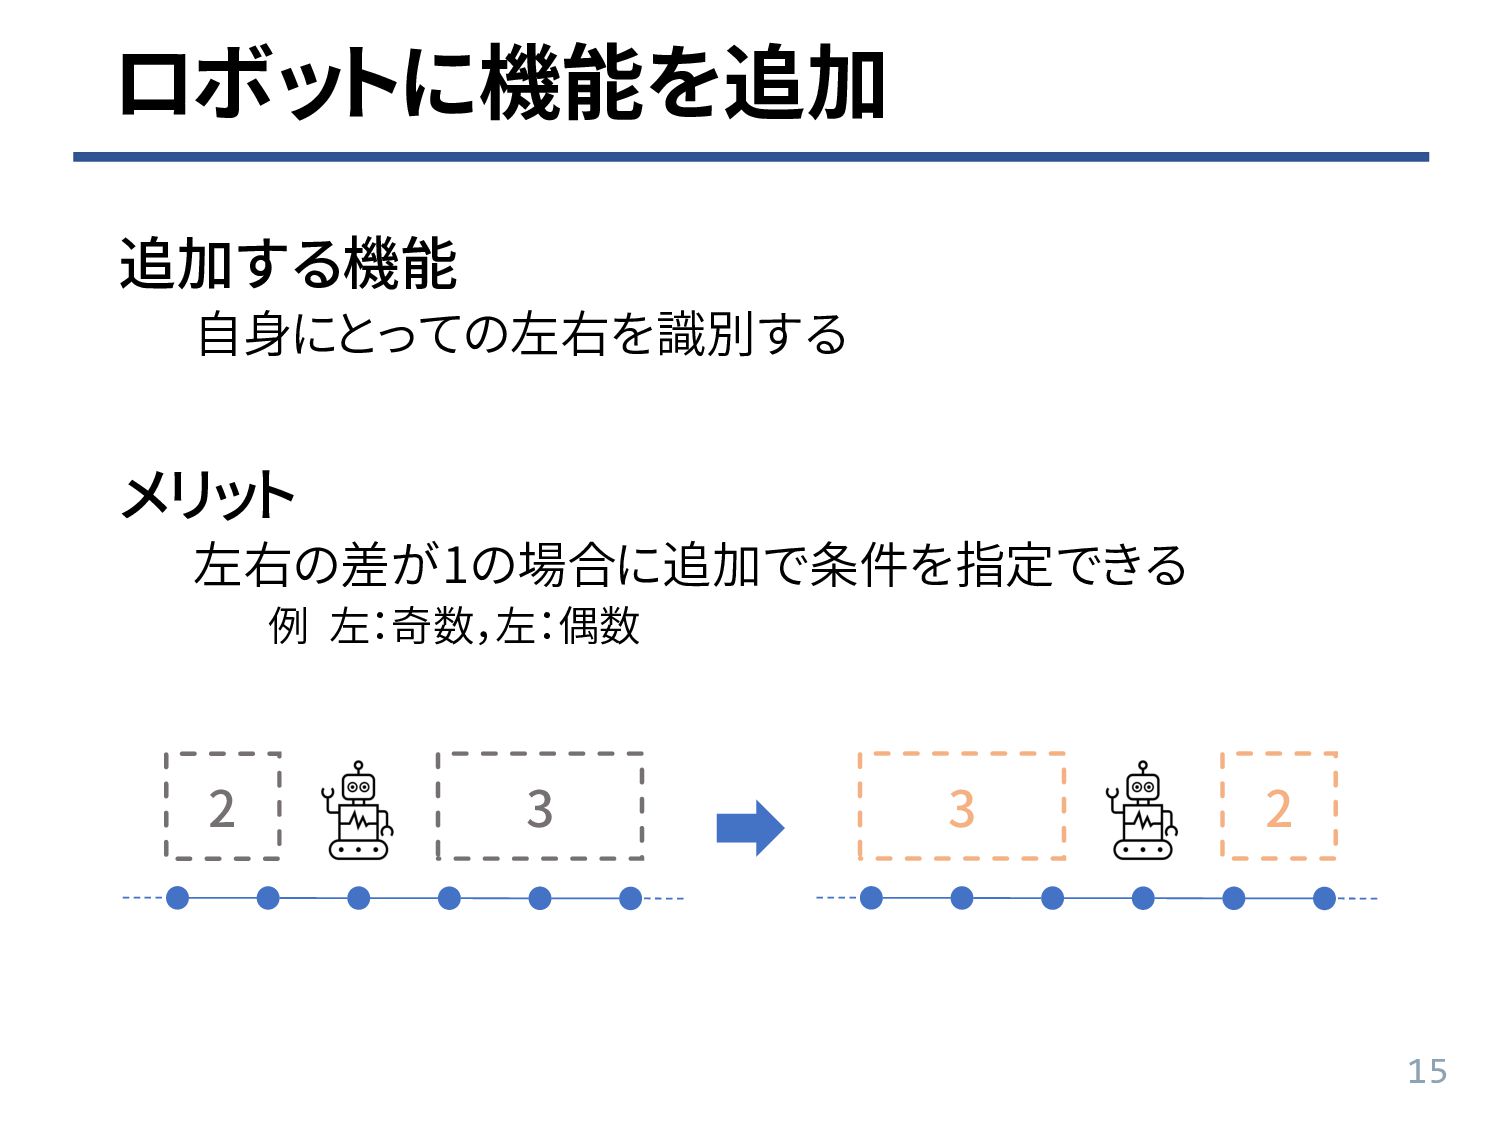
15 ロボットに機能を追加 追加する機能 自身にとっての左右を識別する メリット 左右の差が1の場合に追加で条件を指定できる 例 左:奇数,左:偶数 2 3
2 3
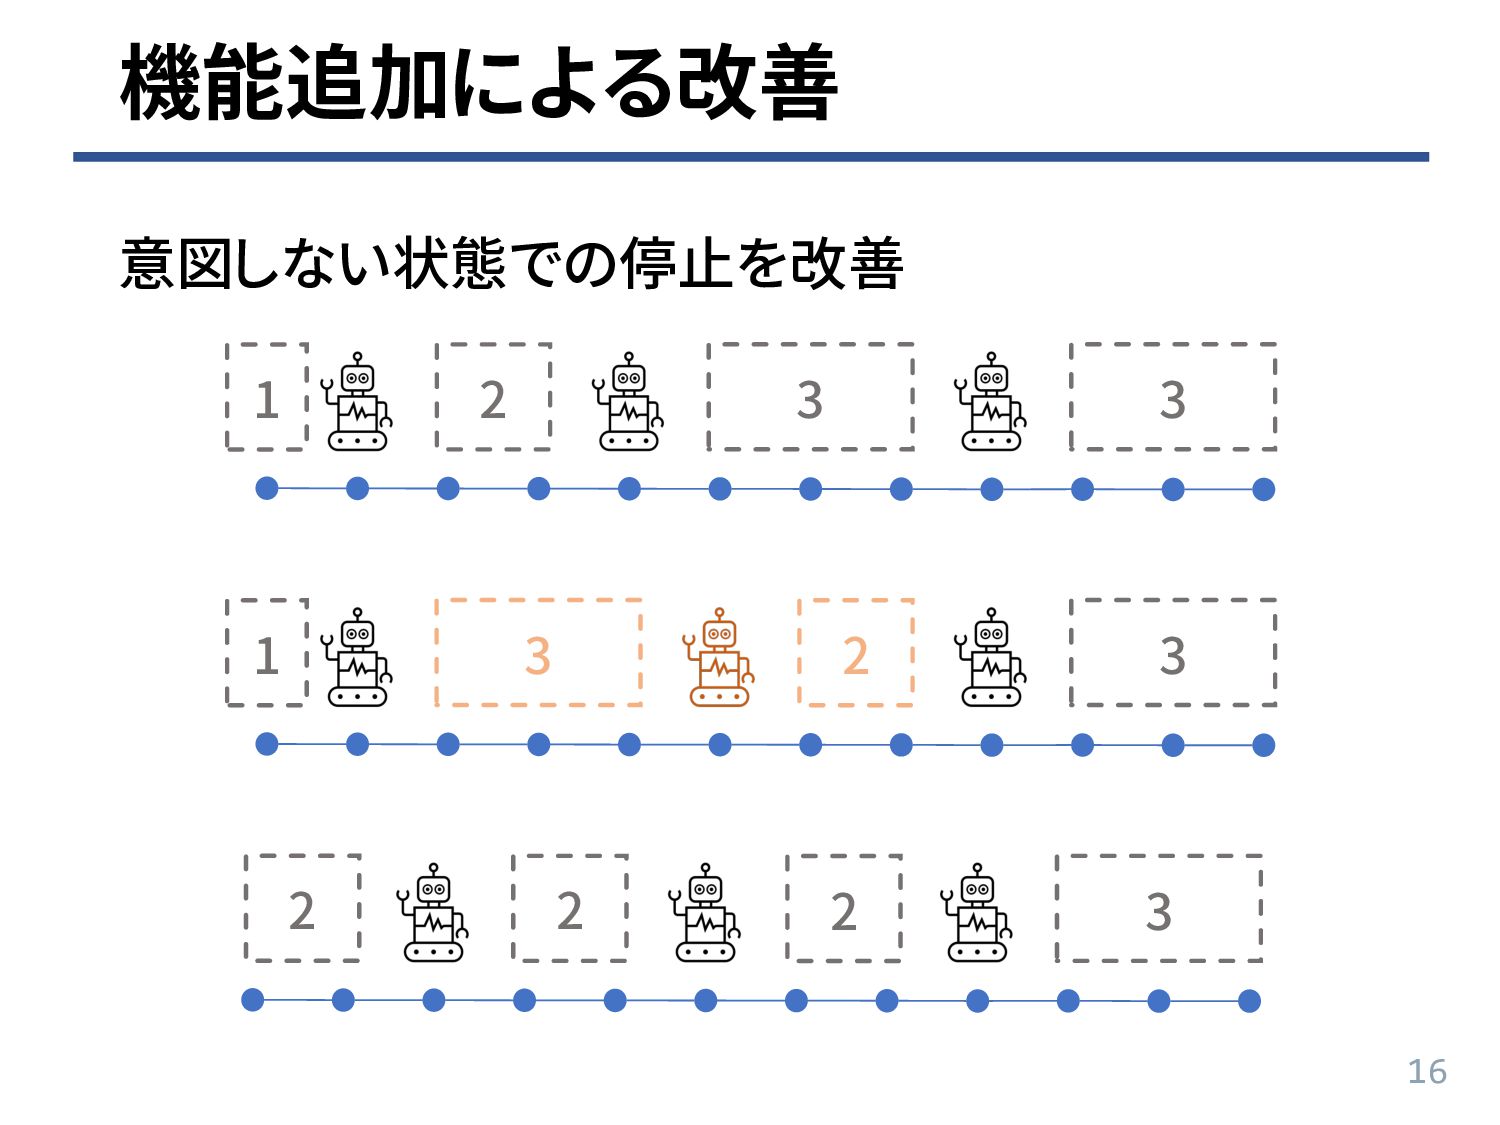
16 機能追加による改善 意図しない状態での停止を改善 2 1 3 3 2 1 3
3 2 3 2 2
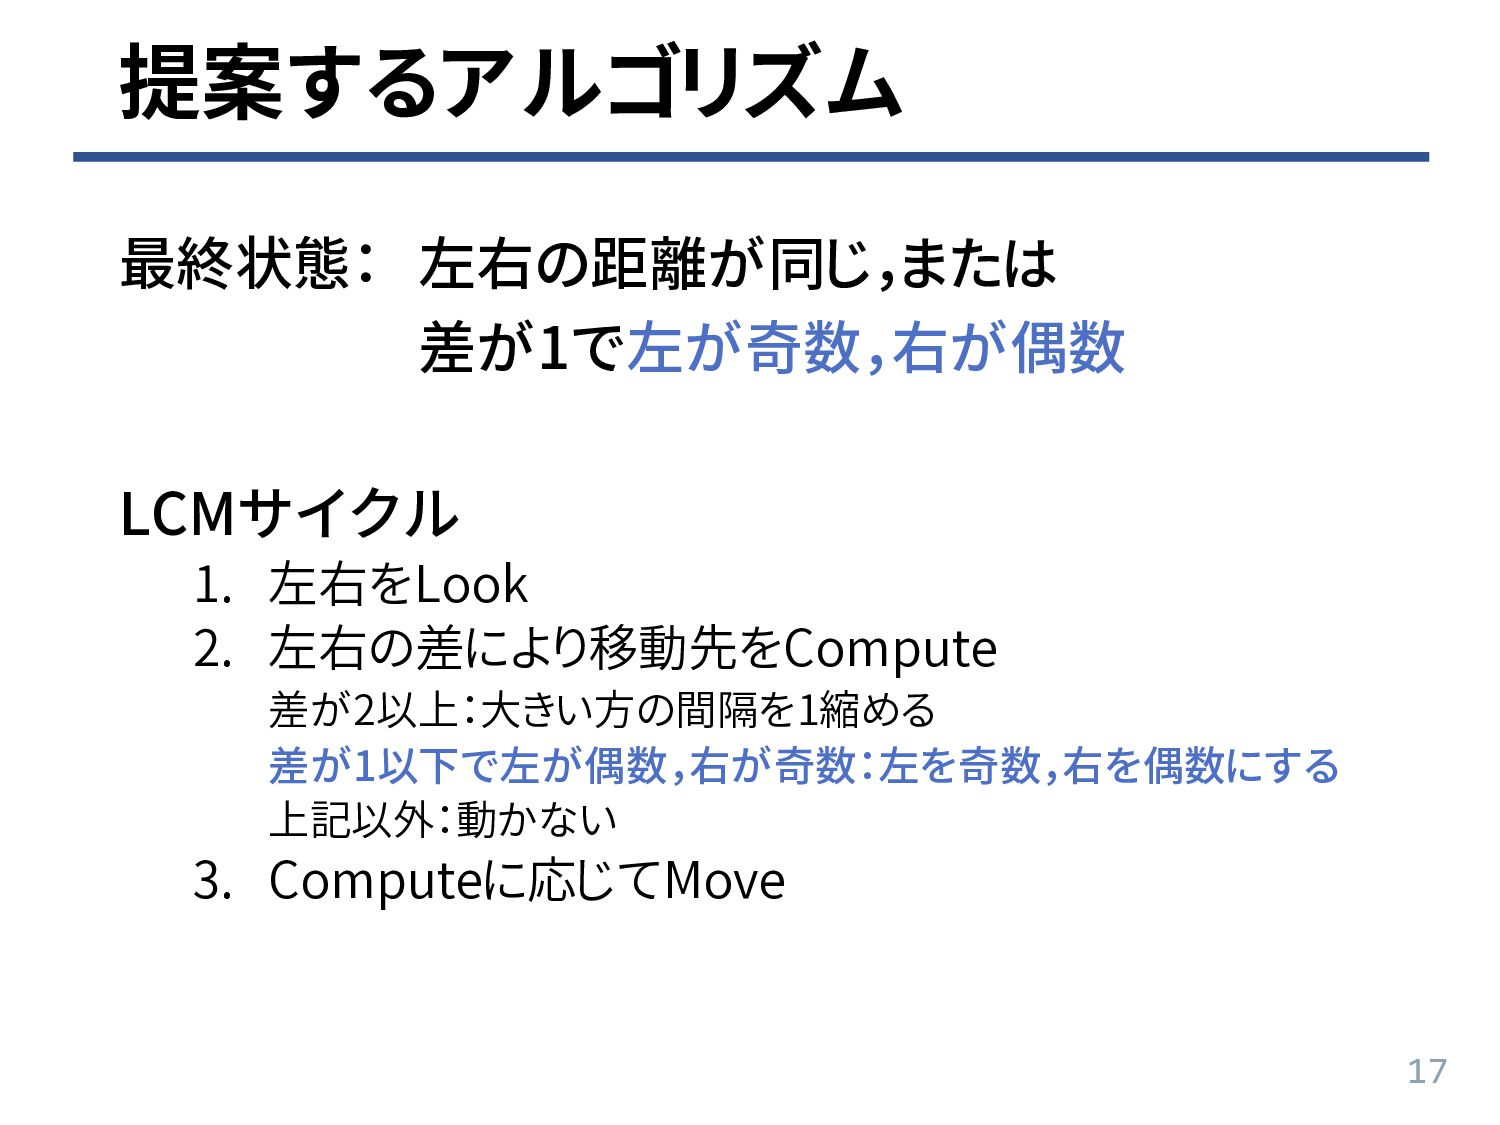
17 提案するアルゴリズム 最終状態: 左右の距離が同じ,または 差が1で左が奇数,右が偶数 LCMサイクル 1. 左右をLook 2. 左右の差により移動先をCompute
差が2以上:大きい方の間隔を1縮める 差が1以下で左が偶数,右が奇数:左を奇数,右を偶数にする 上記以外:動かない 3. Computeに応じてMove


 khasegw0831
 drumath2237
 akihisaikeda
 stkk
 convto
 koic
 jugyo
 camiha
 tyumugi1113
 ivargrimstad
 ayumu_yamaguchi
 kobakei
 riku_sakamoto
 frankvandijk
 eileencodes
 ryanjones
 inesmontani
 stuffmc
 tammielis
 mlcsv
 maltzj
 samtorres
 minecr
 kevinliebholz