Share
Embed
Amoeba Exploration: Coordinated Exploration with Distributed Robots
Keisuke Okumura | 奥村圭祐
July 30, 2021
Transcript
18 slides
-
Amoeba Exploration: Coordinated Exploration with Distributed Robots School of Computing,
Tokyo Institute of Technology , Japan Keisuke Okumura, Yasumasa Tamura, Xavier Défago 2018.9.20, iCAST2018 -
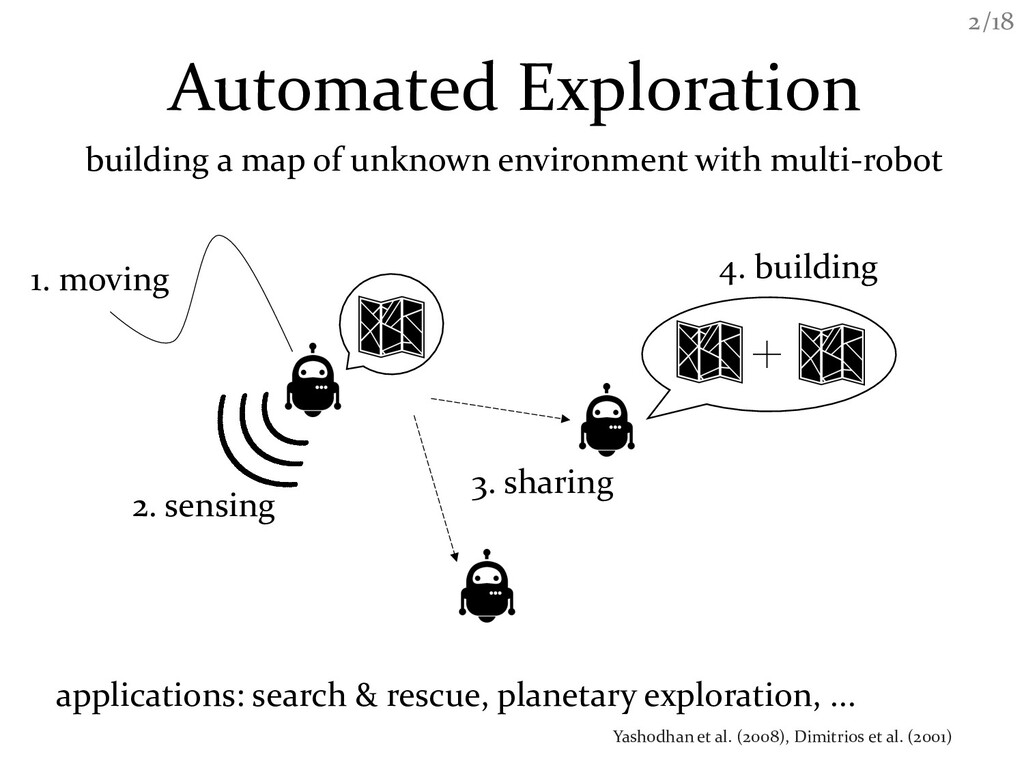
/18 2 Automated Exploration building a map of unknown environment
with multi-robot 2. sensing 1. moving 3. sharing 4. building applications: search & rescue, planetary exploration, ... Yashodhan et al. (2008), Dimitrios et al. (2001) -
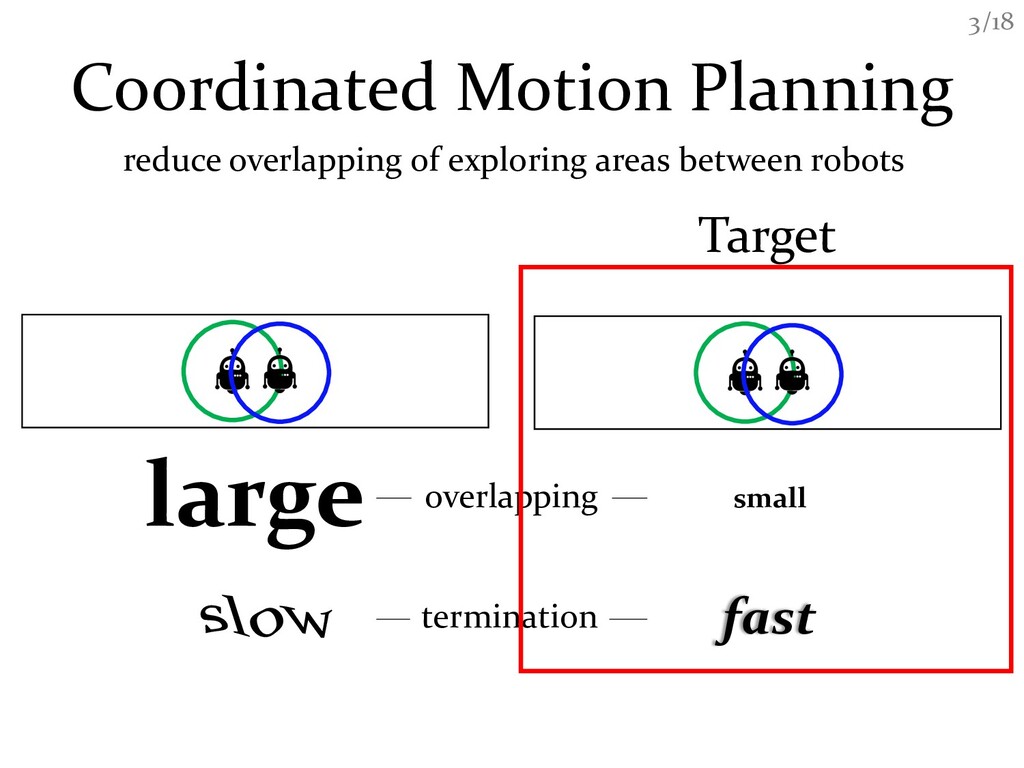
/18 3 Coordinated Motion Planning reduce overlapping of exploring areas
between robots overlapping small large fast termination Target -
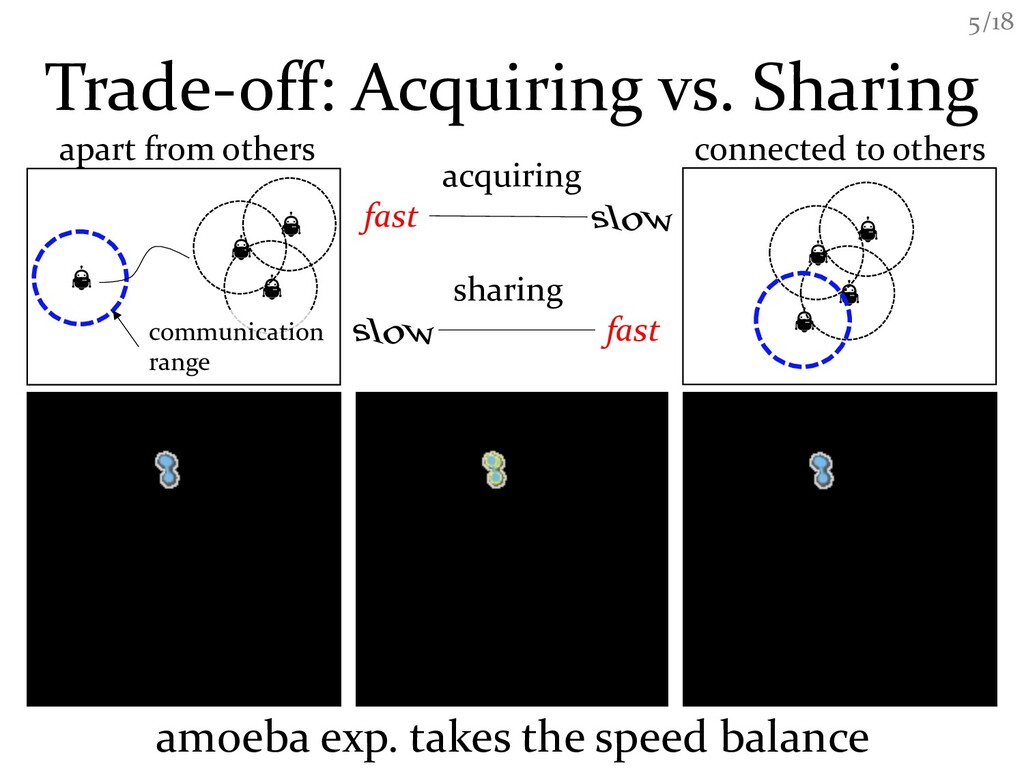
/18 5 Trade-off: Acquiring vs. Sharing apart from others connected
to others amoeba exp. takes the speed balance communication range acquiring fast sharing fast -
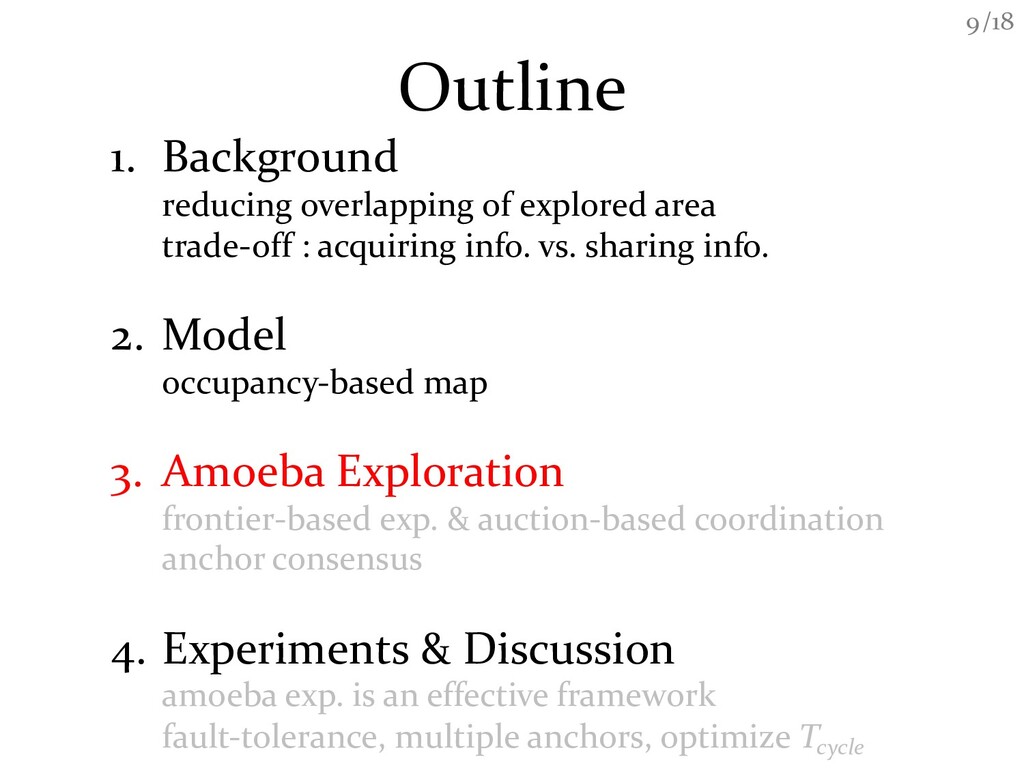
/18 6 Outline 1. Background reducing overlapping of explored area
trade-off : acquiring info. vs. sharing info. 2. Model occupancy-based map 3. Amoeba Exploration frontier-based exp. & auction-based coordination anchor consensus 4. Experiments & Discussion amoeba exp. is an effective framework fault-tolerance, multiple anchors, optimize Tcycle -
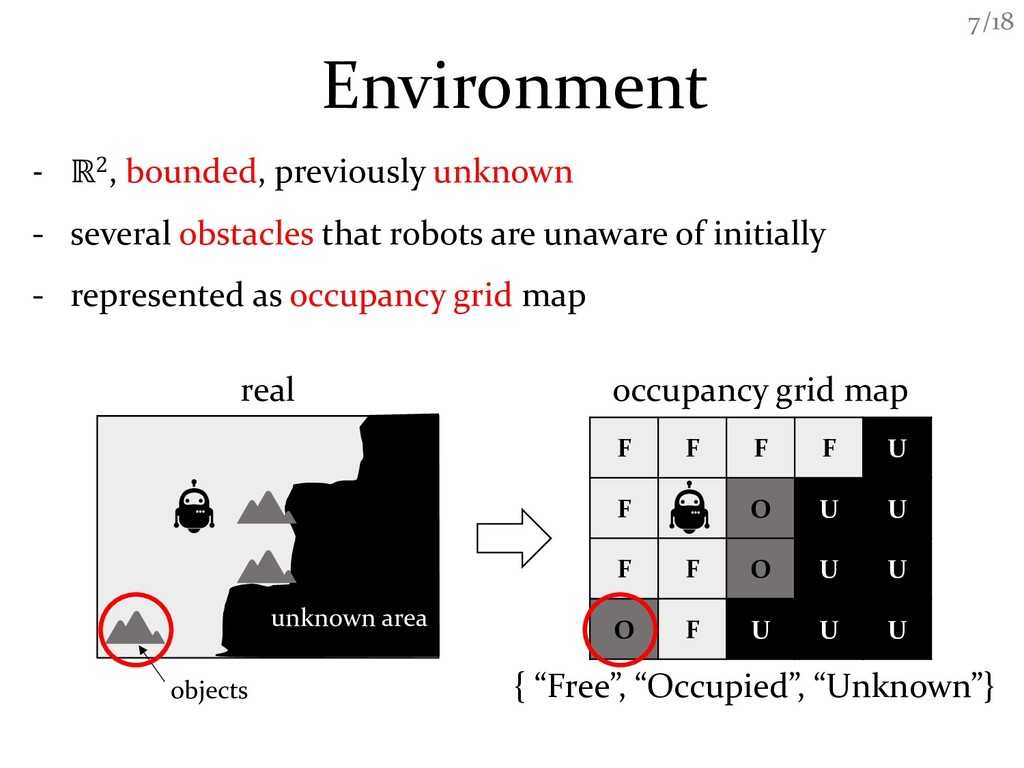
/18 7 Environment - ℝ2, bounded, previously unknown - several
obstacles that robots are unaware of initially - represented as occupancy grid map F F F F U F O U U F F O U U O F U U U occupancy grid map { “Free”, “Occupied”, “Unknown”} real unknown area objects -
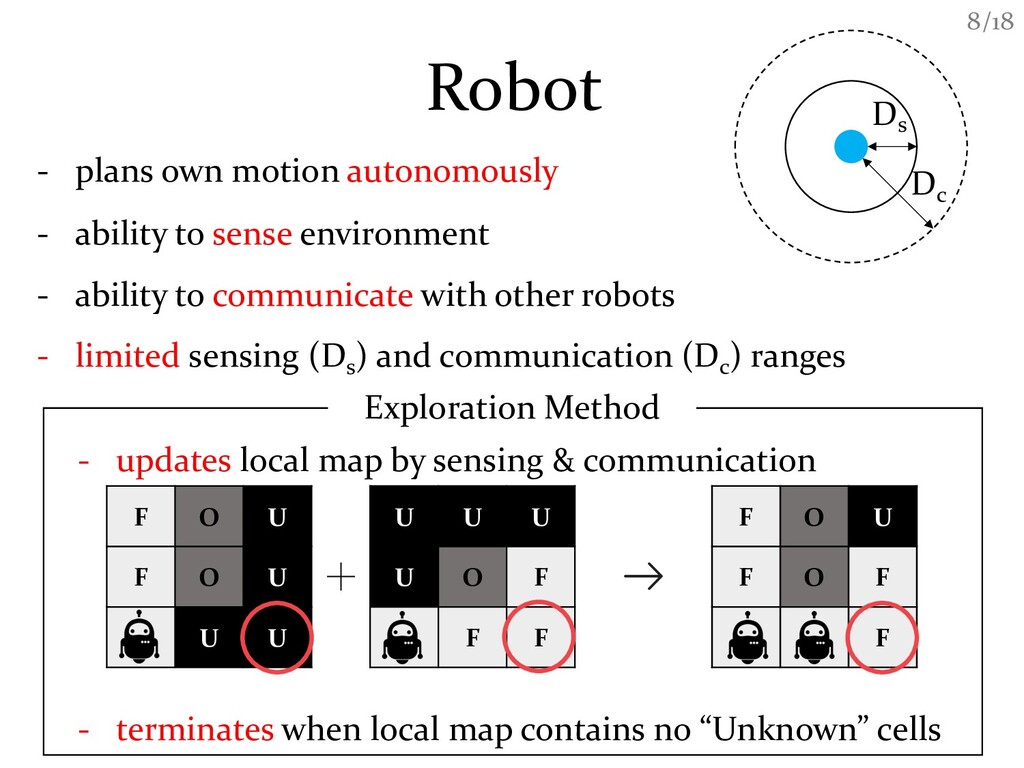
/18 8 Robot Ds Dc - plans own motion autonomously
- ability to sense environment - ability to communicate with other robots - limited sensing (Ds ) and communication (Dc ) ranges Exploration Method - updates local map by sensing & communication F O U F O U U U U U U U O F F F F O U F O F F - terminates when local map contains no “Unknown” cells -
/18 9 Outline 1. Background reducing overlapping of explored area
trade-off : acquiring info. vs. sharing info. 2. Model occupancy-based map 3. Amoeba Exploration frontier-based exp. & auction-based coordination anchor consensus 4. Experiments & Discussion amoeba exp. is an effective framework fault-tolerance, multiple anchors, optimize Tcycle -
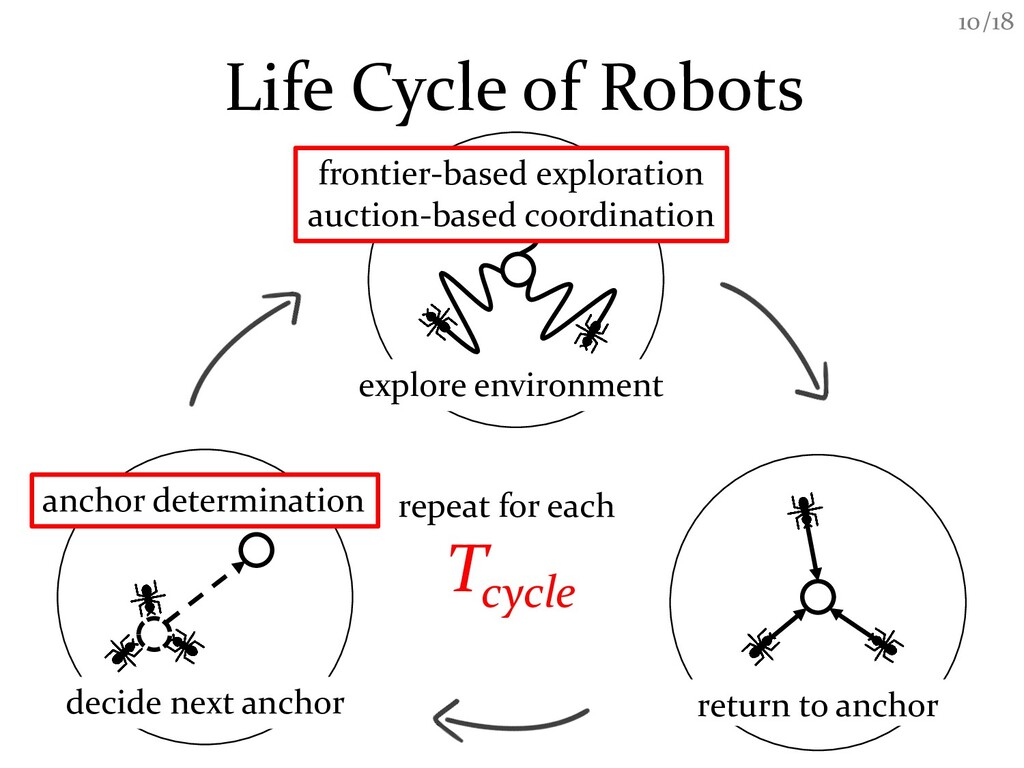
/18 10 Life Cycle of Robots decide next anchor explore
environment return to anchor Tcycle repeat for each frontier-based exploration auction-based coordination anchor determination -
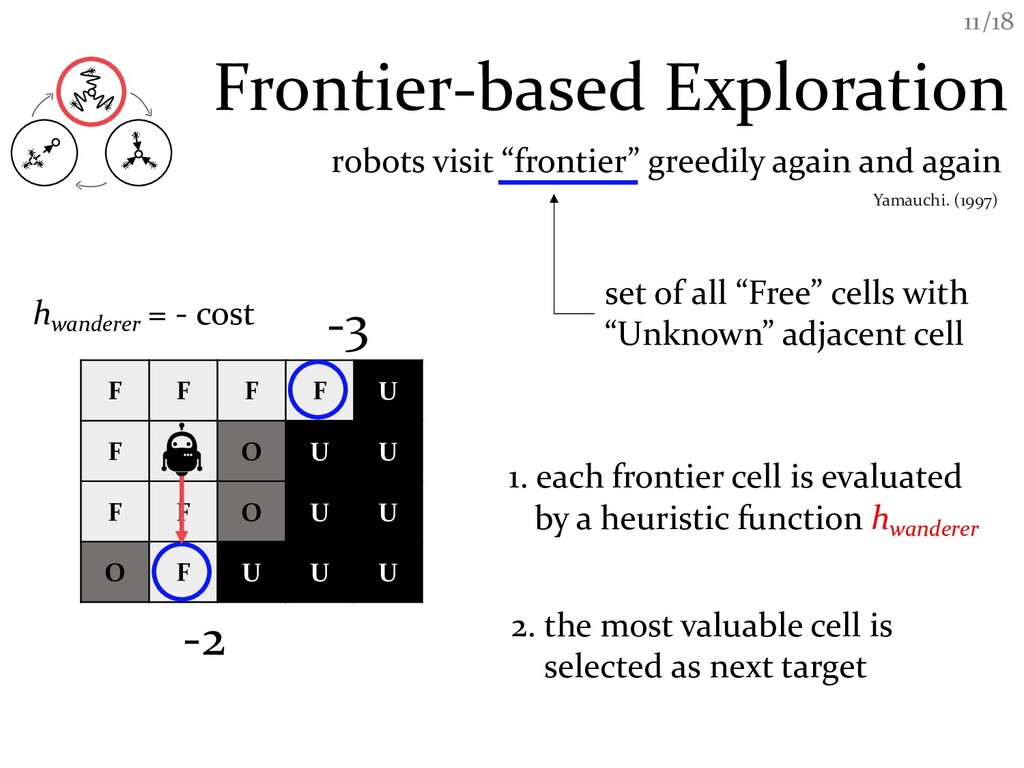
/18 11 Frontier-based Exploration F F F F U F
O U U F F O U U O F U U U robots visit “frontier” greedily again and again Yamauchi. (1997) 1. each frontier cell is evaluated by a heuristic function hwanderer hwanderer = - cost -2 -3 2. the most valuable cell is selected as next target set of all “Free” cells with “Unknown” adjacent cell -
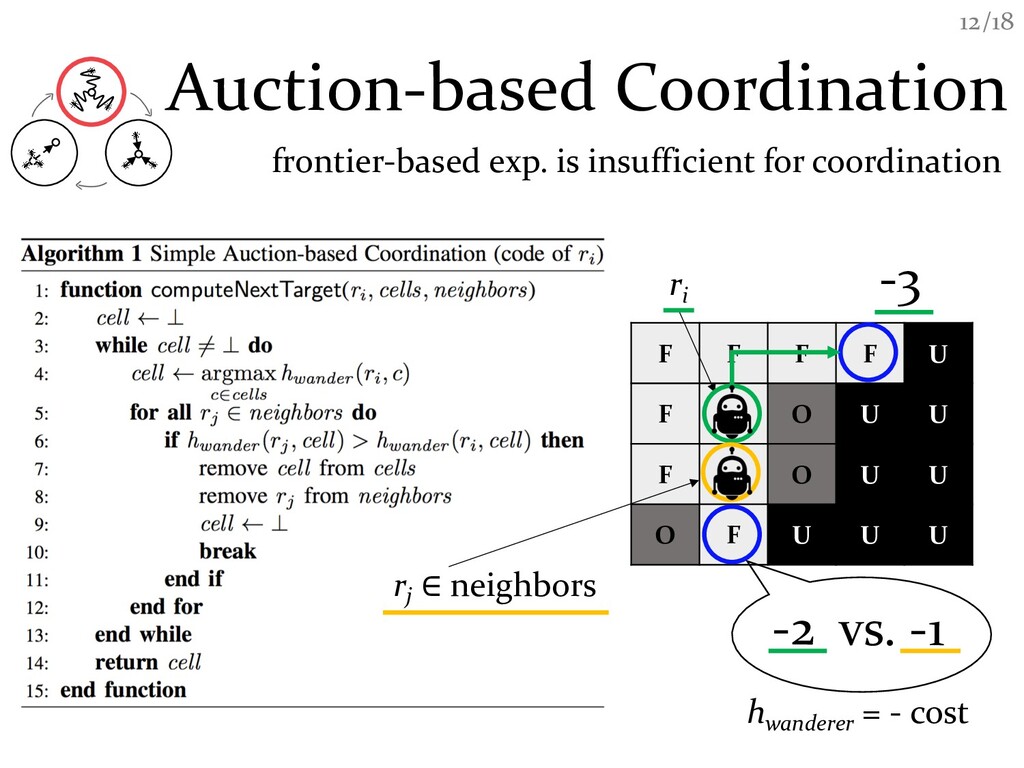
/18 12 F F F F U F O U
U F O U U O F U U U hwanderer = - cost Auction-based Coordination frontier-based exp. is insufficient for coordination rj ∈ neighbors ri -2 vs. -1 -3 -
/18 13 Next Anchor Determination 3. select initial target cell
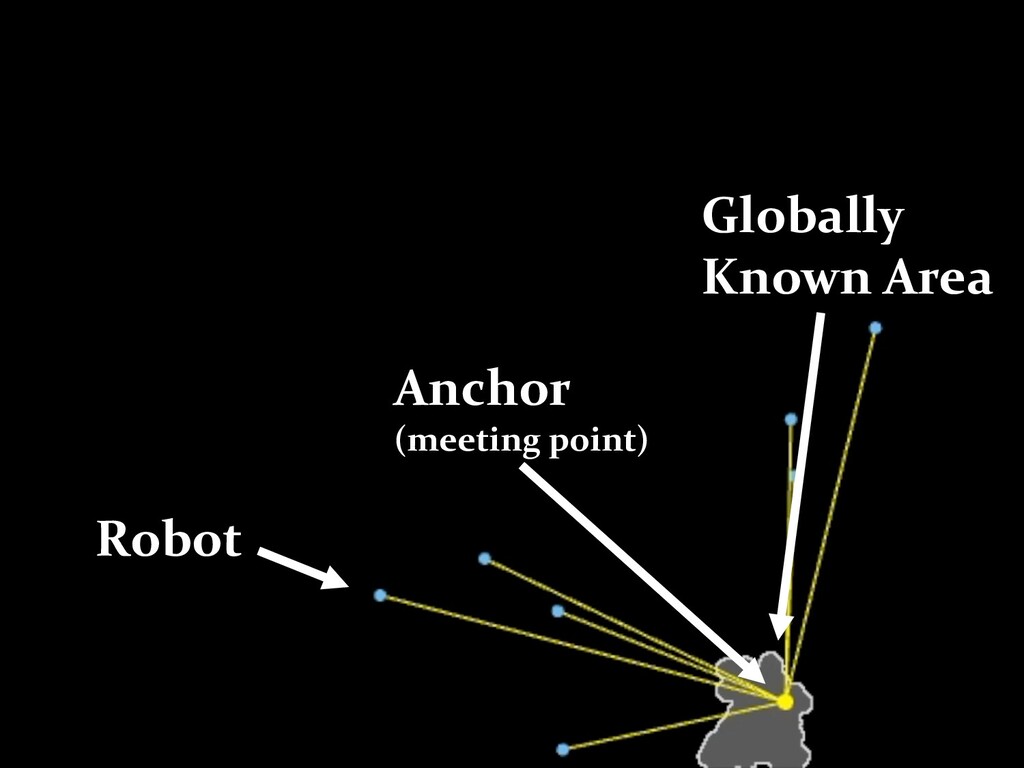
randomly 1. sync local knowledge 2. place anchor on centroid of frontier cells -
/18 14 Outline 1. Background reducing overlapping of explored area
trade-off : acquiring info. vs. sharing info. 2. Model occupancy-based map 3. Amoeba Exploration frontier-based exp. & auction-based coordination anchor consensus 4. Experiments & Discussion amoeba exp. is an effective framework fault-tolerance, multiple anchors, optimize Tcycle -
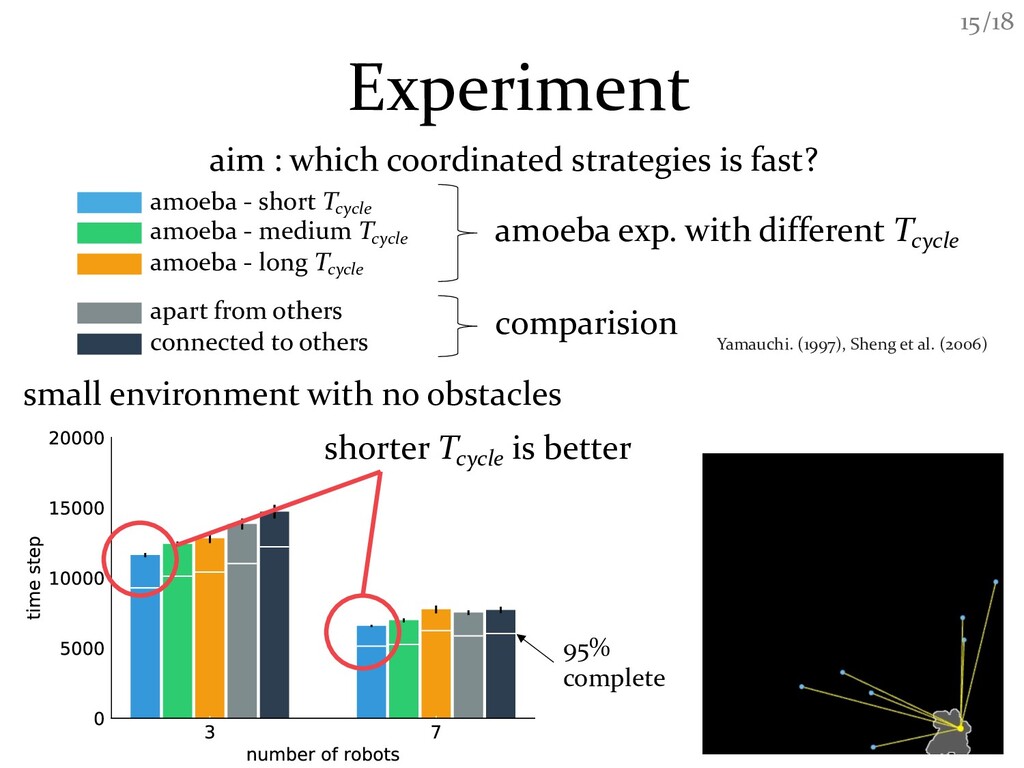
/18 15 Experiment aim : which coordinated strategies is fast?
amoeba - short Tcycle amoeba - medium Tcycle amoeba - long Tcycle apart from others connected to others amoeba exp. with different Tcycle comparision Yamauchi. (1997), Sheng et al. (2006) 95% complete shorter Tcycle is better small environment with no obstacles -
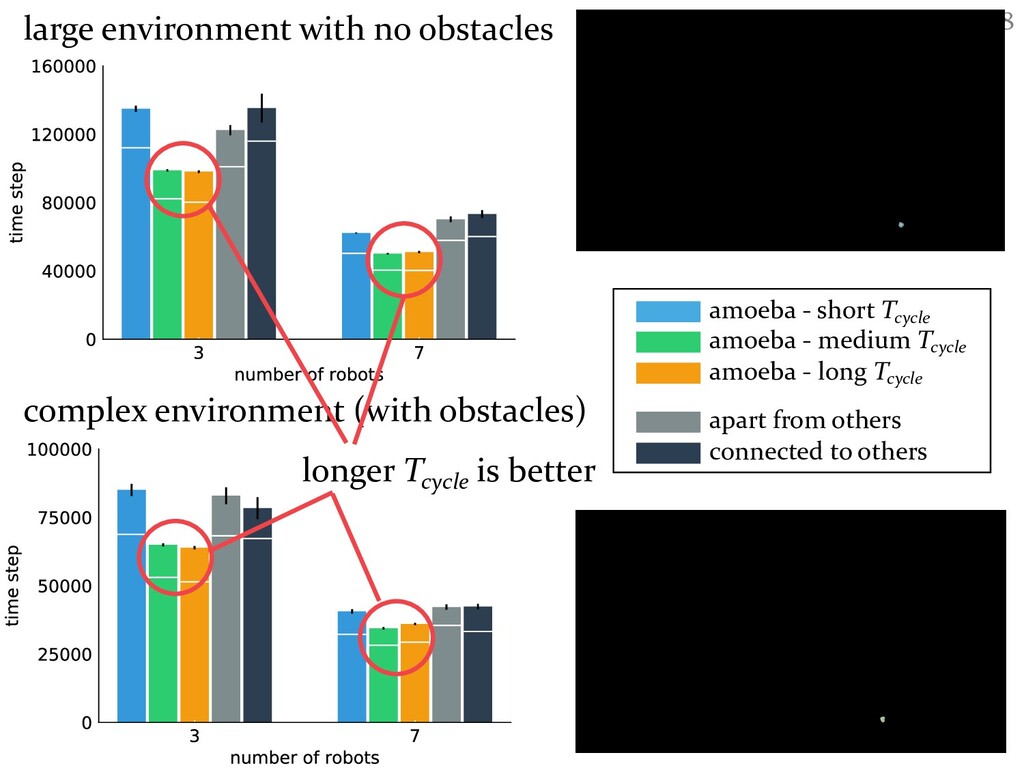
/18 16 large environment with no obstacles complex environment (with
obstacles) amoeba - short Tcycle amoeba - medium Tcycle amoeba - long Tcycle apart from others connected to others longer Tcycle is better -
/18 18 Conclusion Results show that - amoeba exploration is
an effective framework - the effectiveness deeply depends on Tcycle - optimal Tcycle depends on environment Future Work - finding optimal Tcycle - multiple anchors - fault-tolerance Acknowledgements: This research was partly supported by JSPS KAKENHI Grant No. 17K00019 and by Japan Science and Technology Agency (JST) SICORP.