Share
Embed
23_1211 Nonsmooth Modeling of Hydraulic Systems and Its Application to Control of Hydraulic Excavators
Presented at Euromech Colloquium 641: Non-smooth Dynamical Systems
https://euromech.org/colloquia/colloquia-2023/641
https://641.euromech.org/
This is a quick summary of the following four papers;
https://doi.org/10.1115/1.4051894
https://doi.org/10.1109/TAC.2022.3163124
https://doi.org/10.1109/ACCESS.2021.3128215
https://doi.org/10.1109/TASE.2024.3354952
Ryo Kikuuwe
December 25, 2023
Transcript
31 slides
-
1 Nonsmooth Modeling of Nonsmooth Modeling of Hydraulic Systems and
Hydraulic Systems and Its Application to Control of Its Application to Control of Hydraulic Excavators Hydraulic Excavators Machinery Dynamics Laboratory, Hiroshima University, Japan Ryo Kikuuwe https://home.hiroshima-u.ac.jp/kikuuwe/ https://www.youtube.com/user/kikuuwe/ https://speakerdeck.com/kikuuwe -
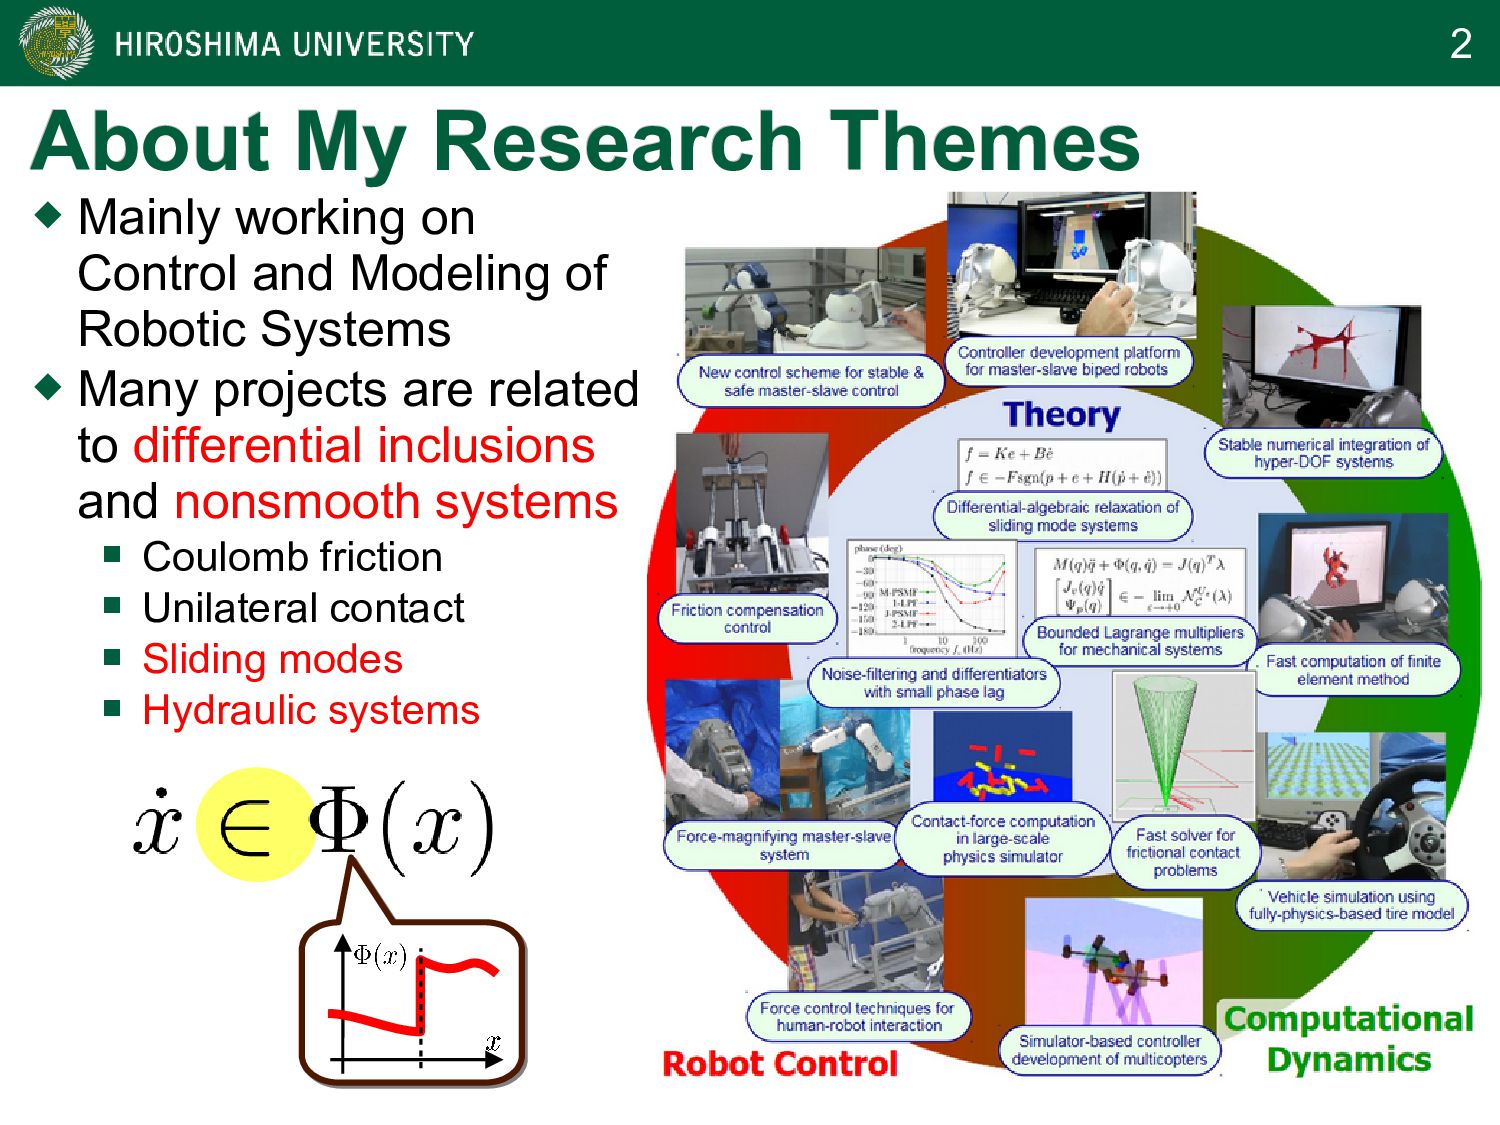
2 Mainly working on Control and Modeling of Robotic
Systems Many projects are related to differential inclusions and nonsmooth systems Coulomb friction Unilateral contact Sliding modes Hydraulic systems About My Research Themes About My Research Themes -
3 Today’s Topics Today’s Topics [1] Modeling of a
Hydraulic Actuator Quasistatic modeling as a Nonsmooth Actuator [2] Sliding-Mode Position Controller A “Model-based” Implementation of Nonsmooth Controller to a Nonsmooth Actuator [3] Sliding-Mode-Like Position Controller B “PD-based” Implementation of Nonsmooth Controller to a Nonsmooth Actuator [ASME-DSMC 2021] [IEEE-TAC 2022] [IEEE Access 2021] [jxiv 2023] -
4 [1] [1] Modeling of a Hydraulic System Modeling of
a Hydraulic System as a “Nonsmooth Actuator” as a “Nonsmooth Actuator” [1] [1] Modeling of a Hydraulic System Modeling of a Hydraulic System as a “Nonsmooth Actuator” as a “Nonsmooth Actuator” Kikuuwe, Okada, Yoshihara, Doi, Nanjo & Yamashita: “A Nonsmooth Quasi-Static Modeling Approach for Hydraulic Actuators,” Trans ASME: J. Dynamic Systems, Measurement, and Control, vol.143, no.12, p.121002, 2021. -
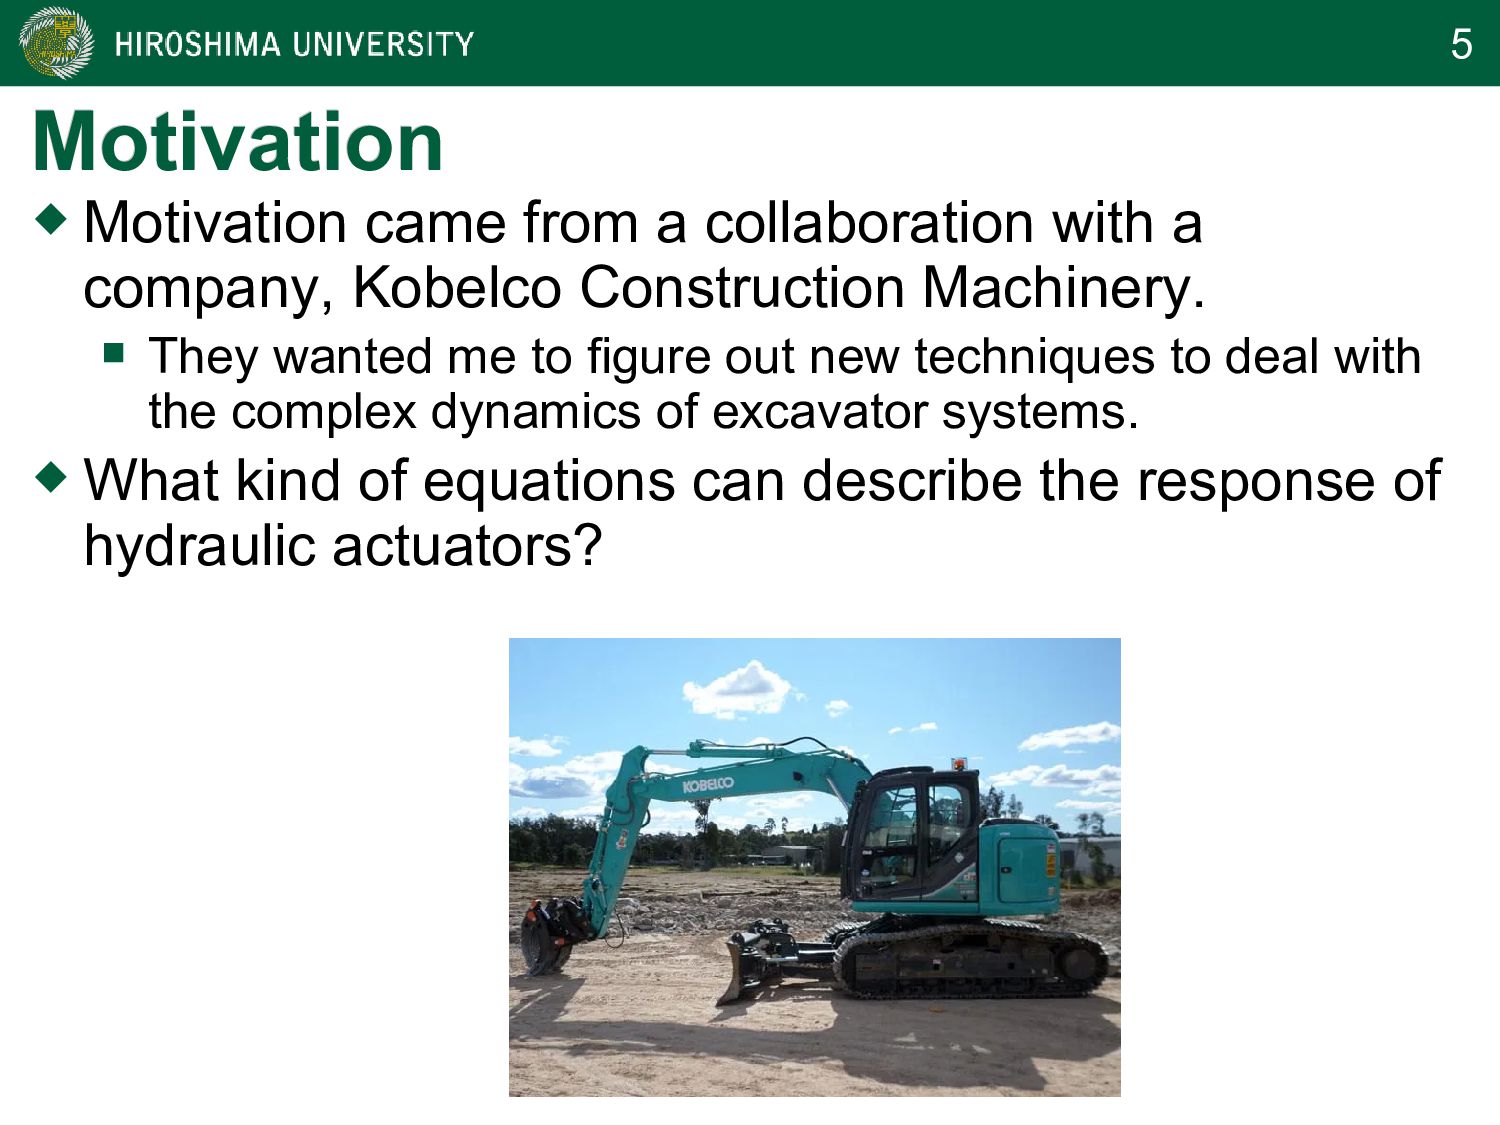
5 Motivation Motivation Motivation came from a collaboration with
a company, Kobelco Construction Machinery. They wanted me to figure out new techniques to deal with the complex dynamics of excavator systems. What kind of equations can describe the response of hydraulic actuators? -
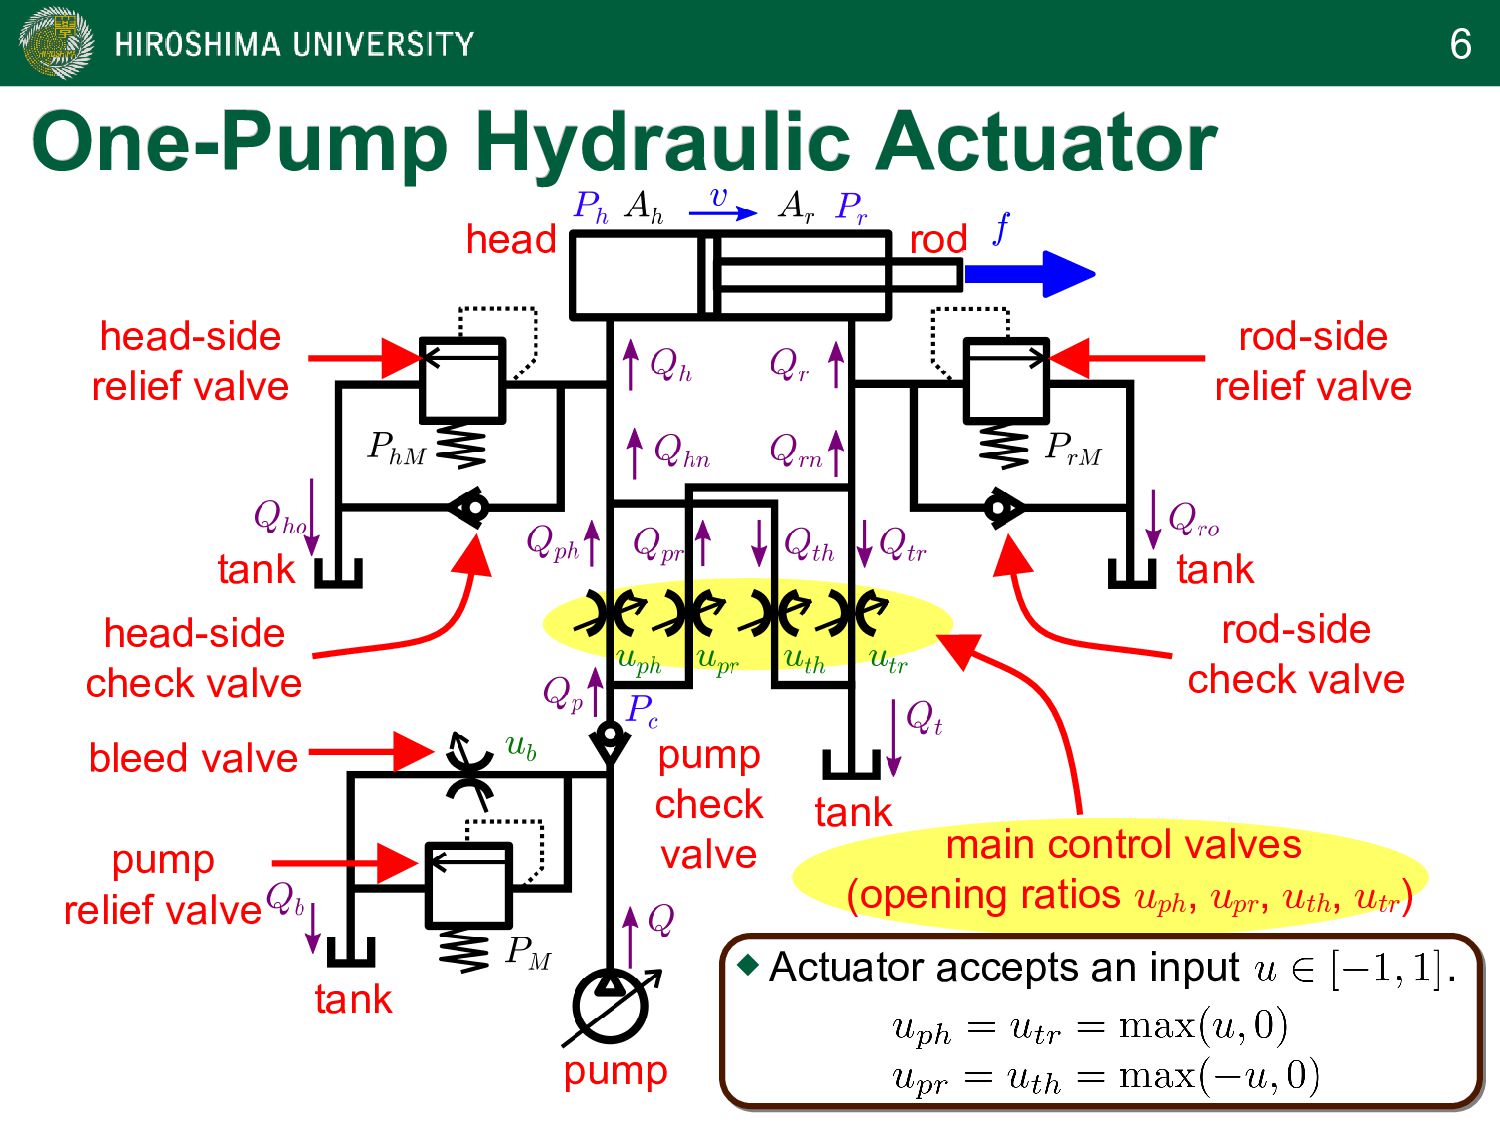
6 One-Pump Hydraulic Actuator One-Pump Hydraulic Actuator bleed valve pump
relief valve rod head main control valves (opening ratios uph , upr , uth , utr ) tank pump rod-side relief valve head-side relief valve pump check valve tank rod-side check valve head-side check valve tank tank Actuator accepts an input . -
7 It is Nonsmooth, i.e., Set-Valued It is Nonsmooth, i.e.,
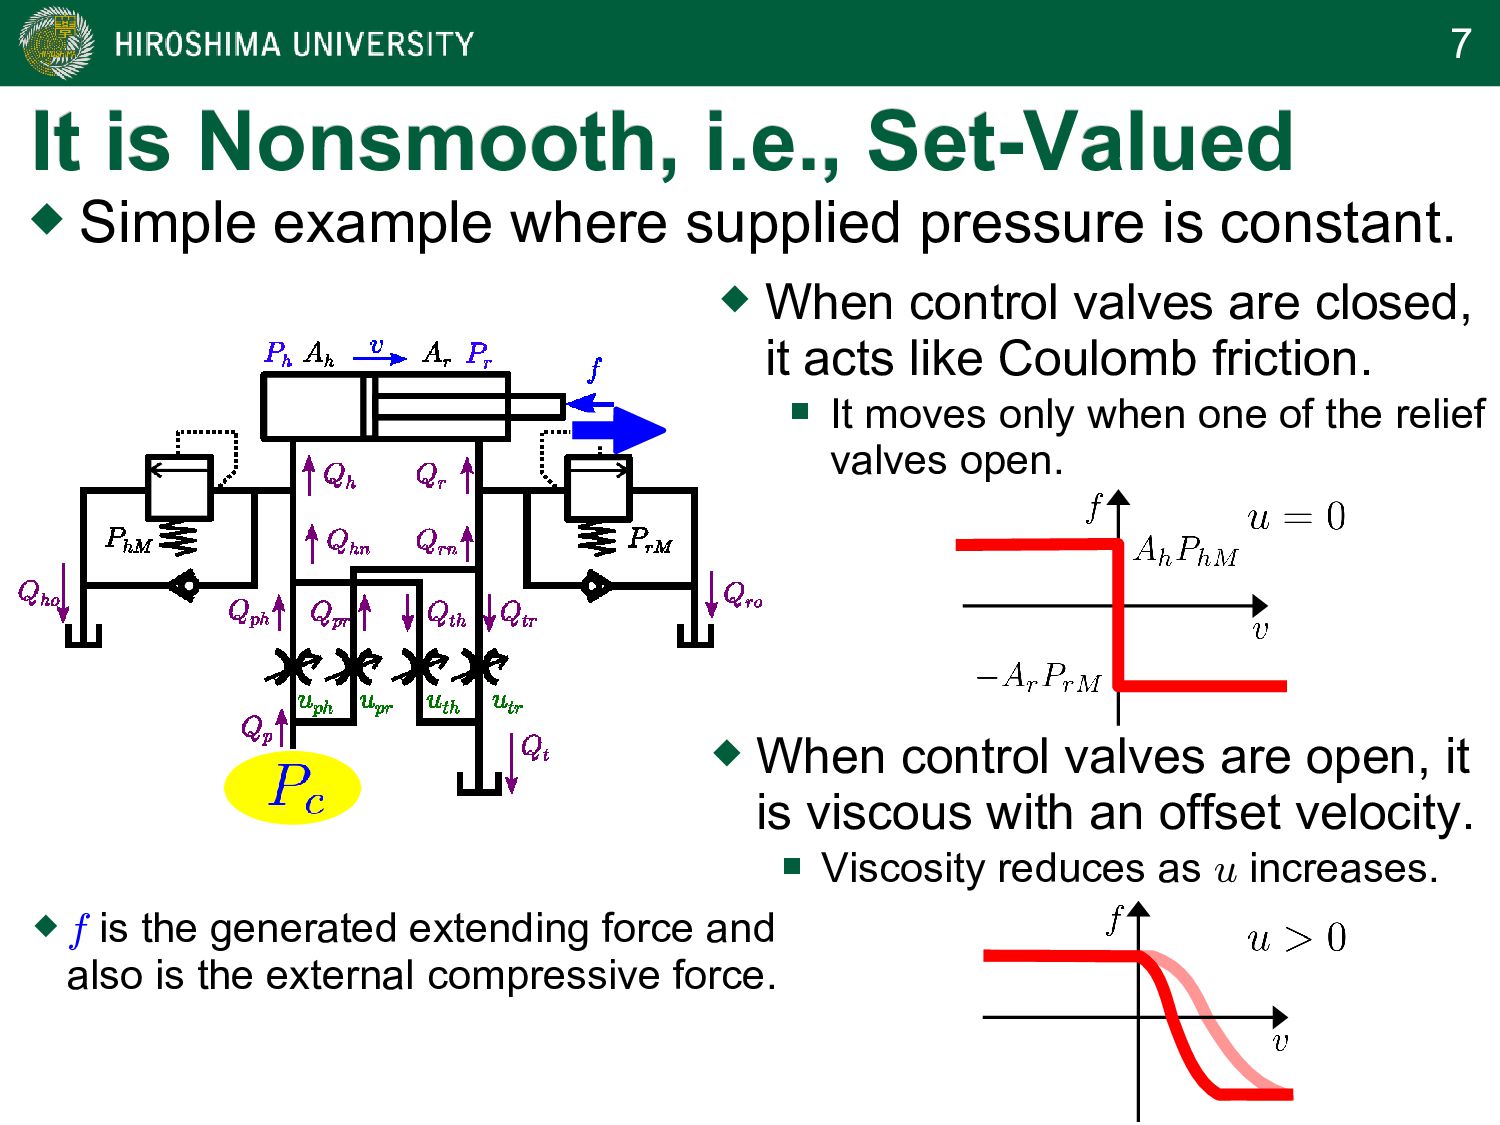
Set-Valued Simple example where supplied pressure is constant. When control valves are closed, it acts like Coulomb friction. It moves only when one of the relief valves open. When control valves are open, it is viscous with an offset velocity. Viscosity reduces as u increases. f is the generated extending force and also is the external compressive force. -
8 Flowrate vs Pressure at Valves Flowrate vs Pressure at
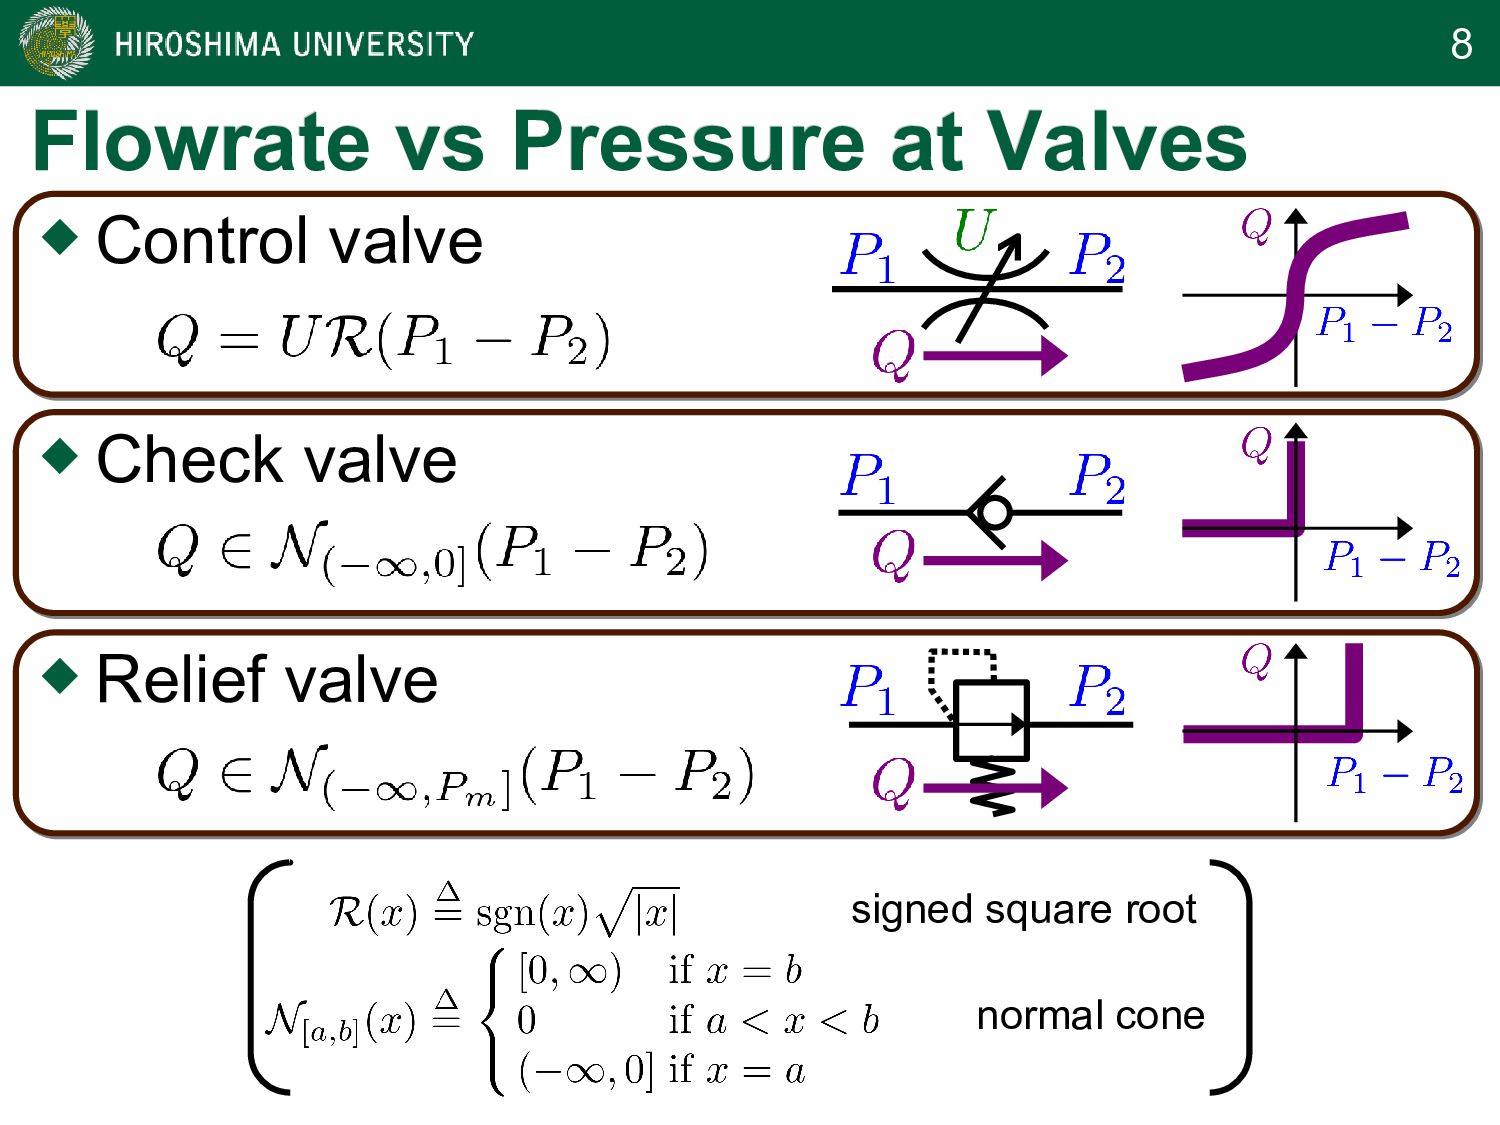
Valves Control valve Check valve Relief valve signed square root normal cone -
9 18 Equations, 19 Variables 18 Equations, 19 Variables continuity
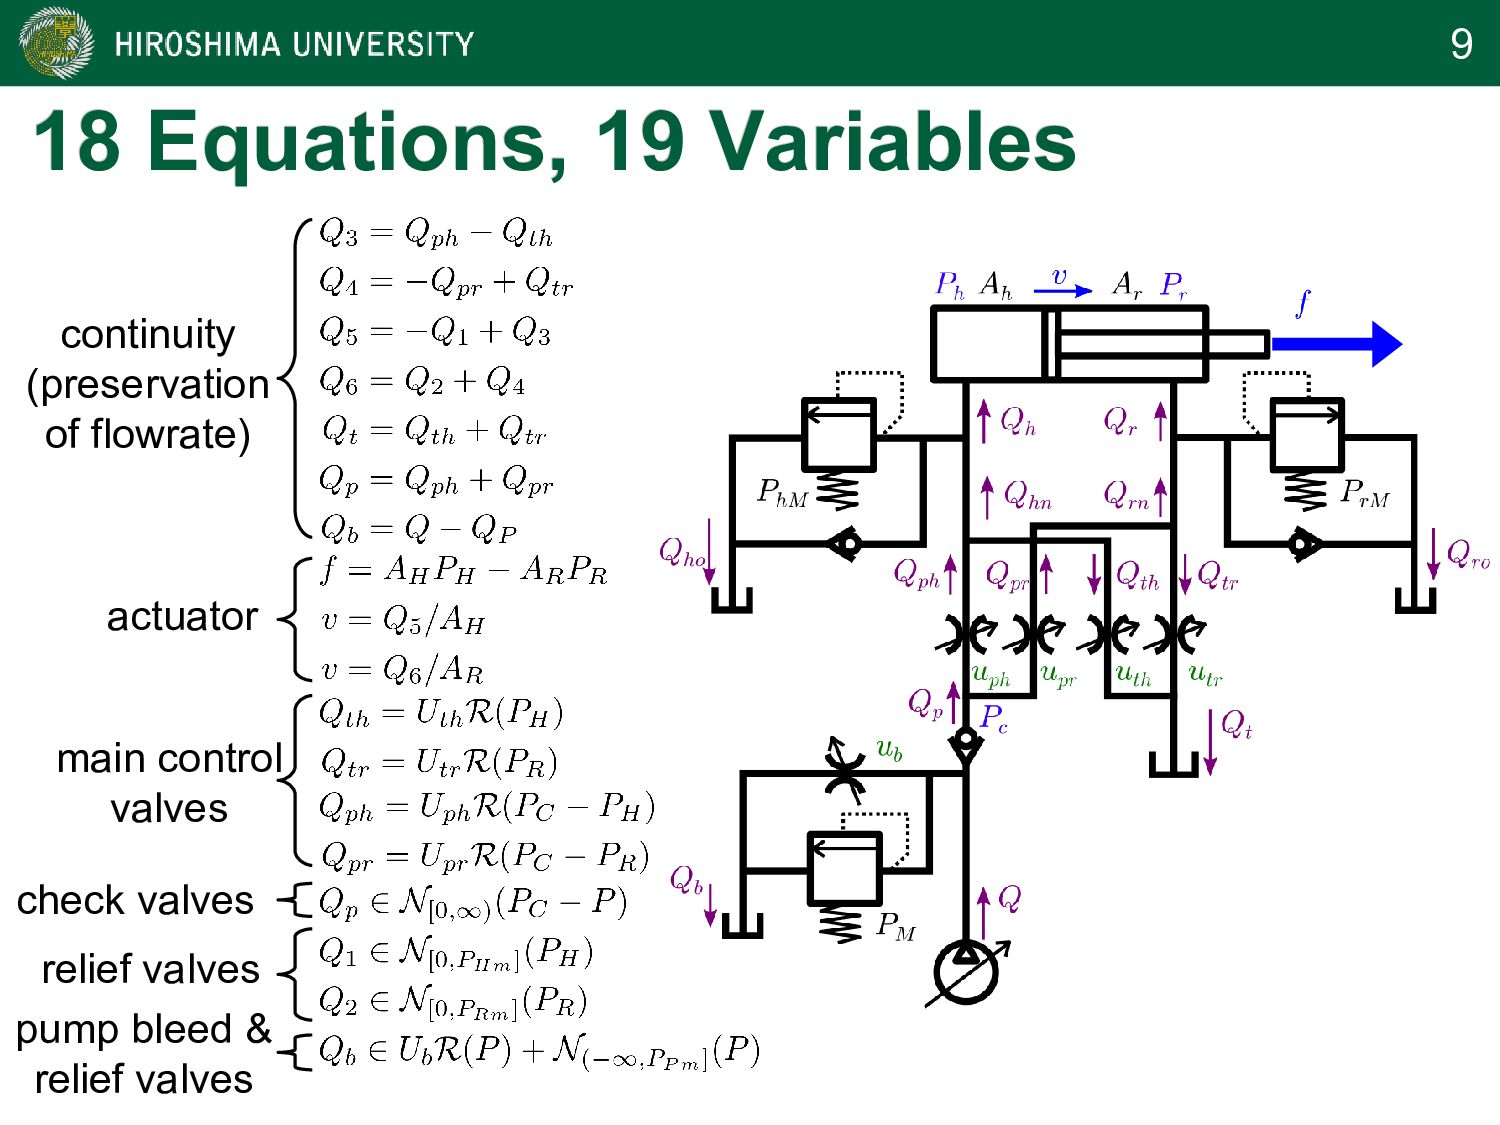
(preservation of flowrate) pump bleed & relief valves check valves main control valves actuator relief valves -
10 Derivation of Derivation of v v- -f f Relation
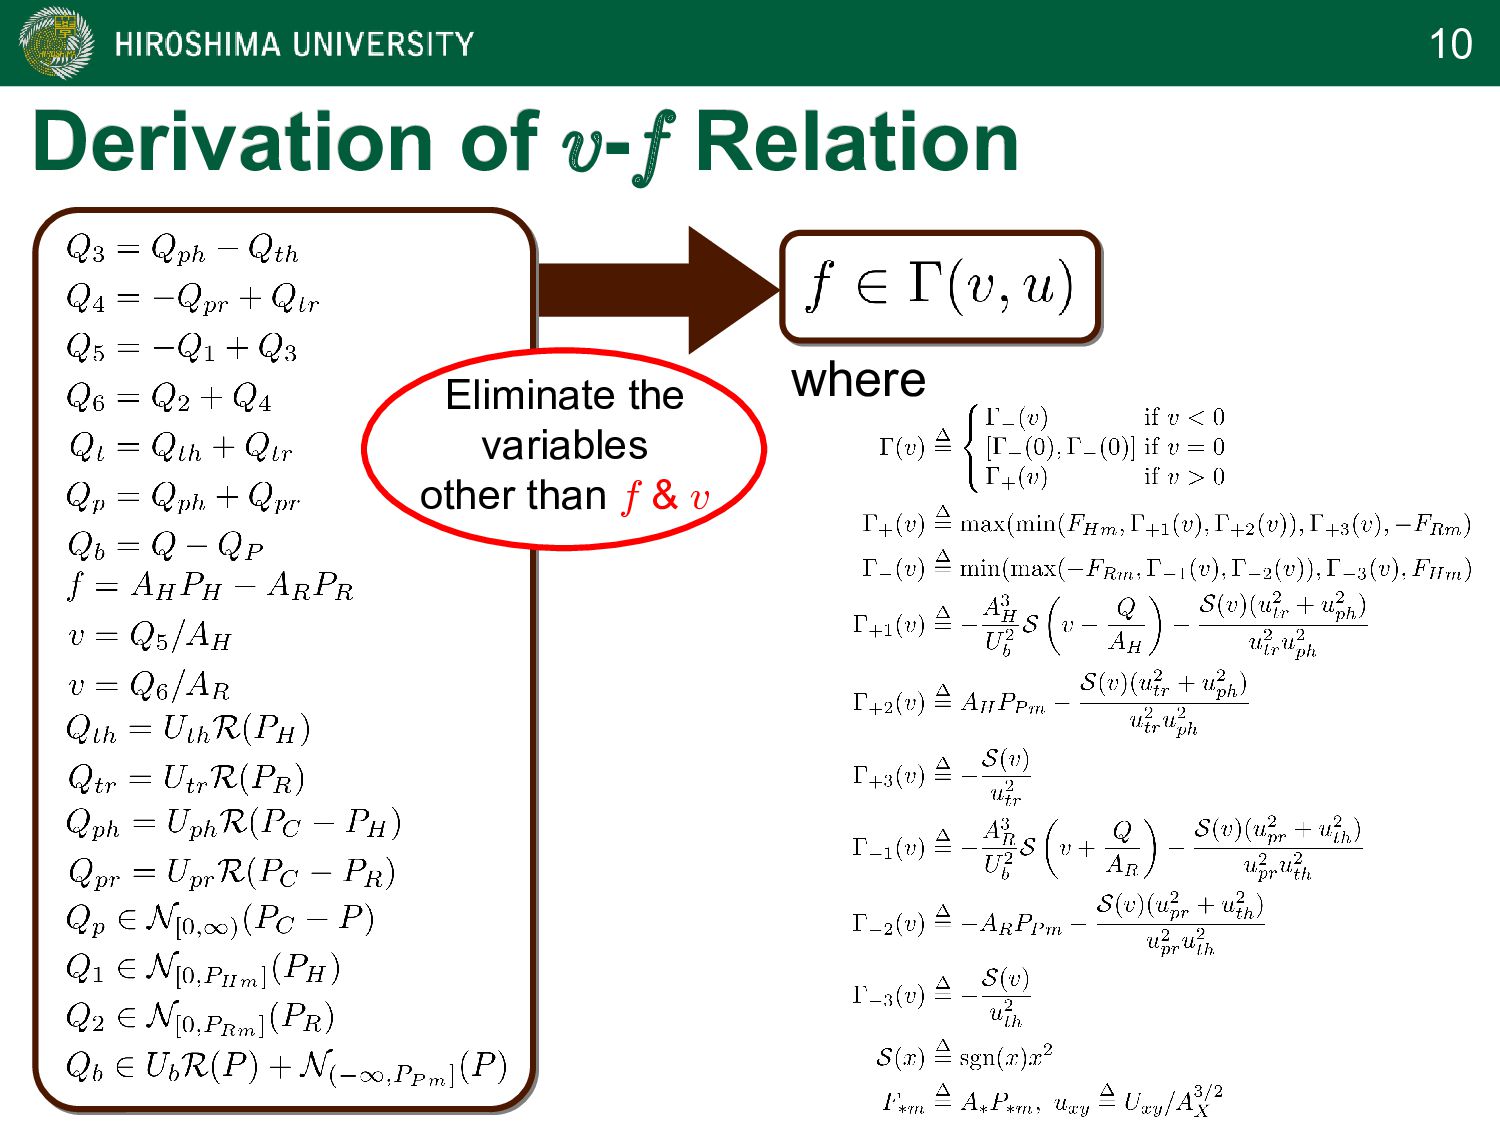
Relation where Eliminate the variables other than f & v -
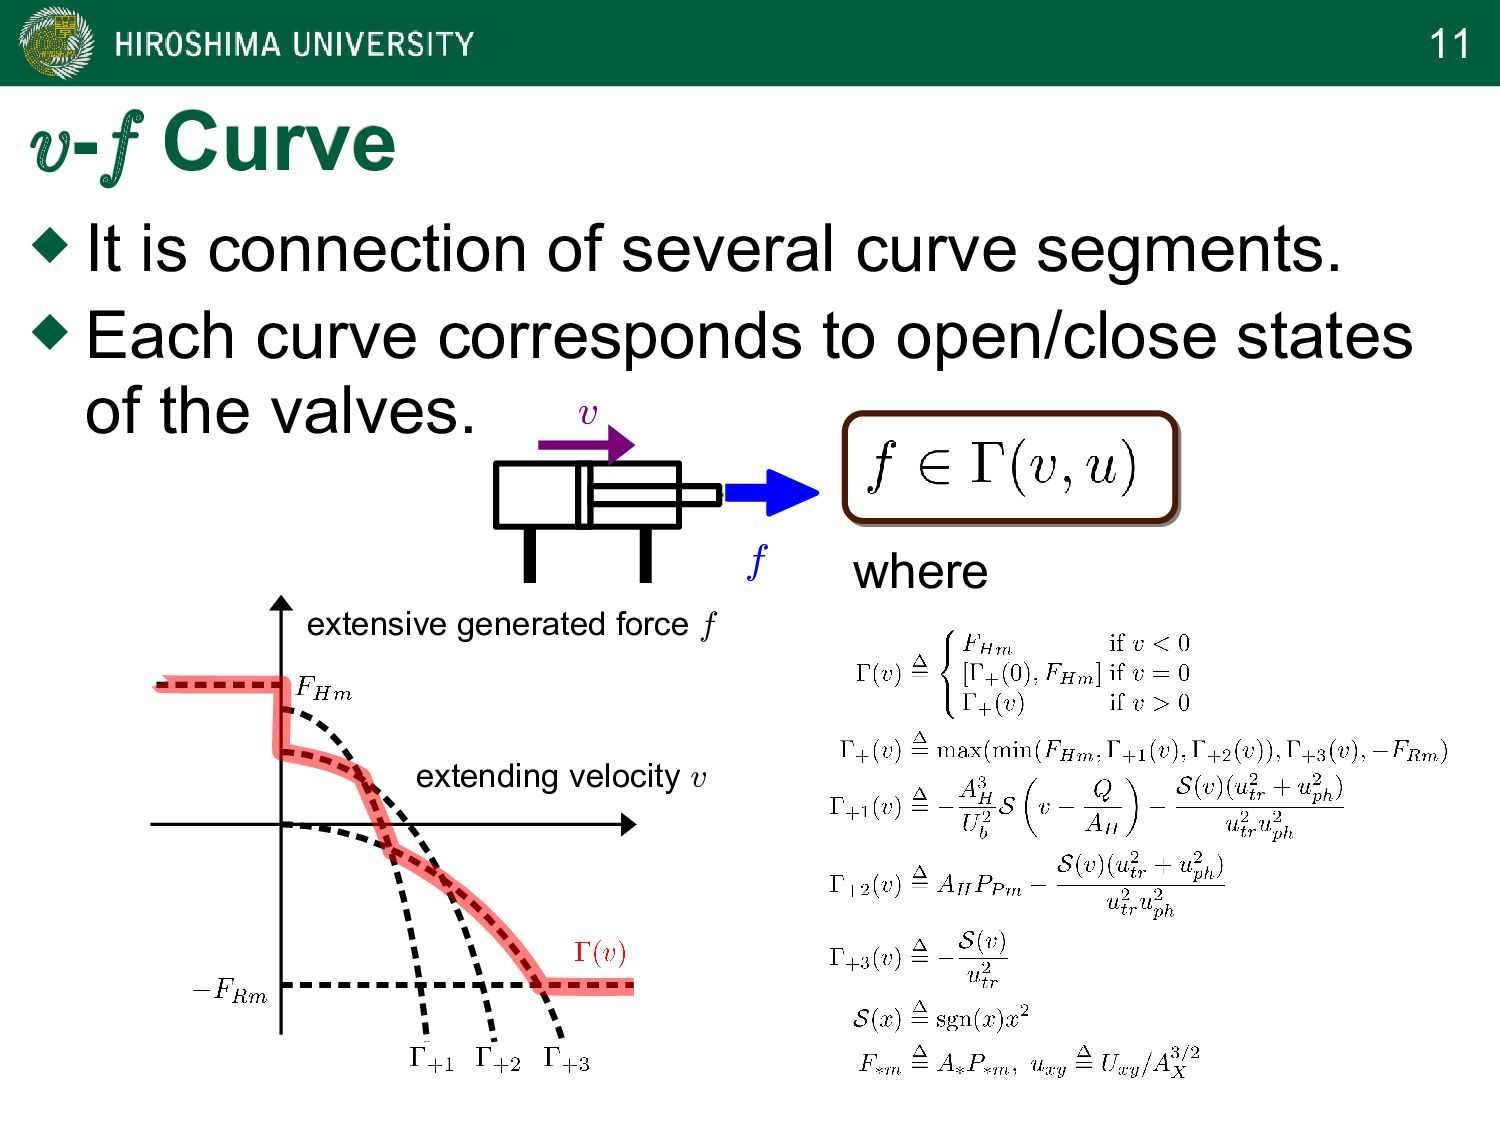
11 v v- -f f Curve Curve It is
connection of several curve segments. Each curve corresponds to open/close states of the valves. extending velocity v extensive generated force f where v f -
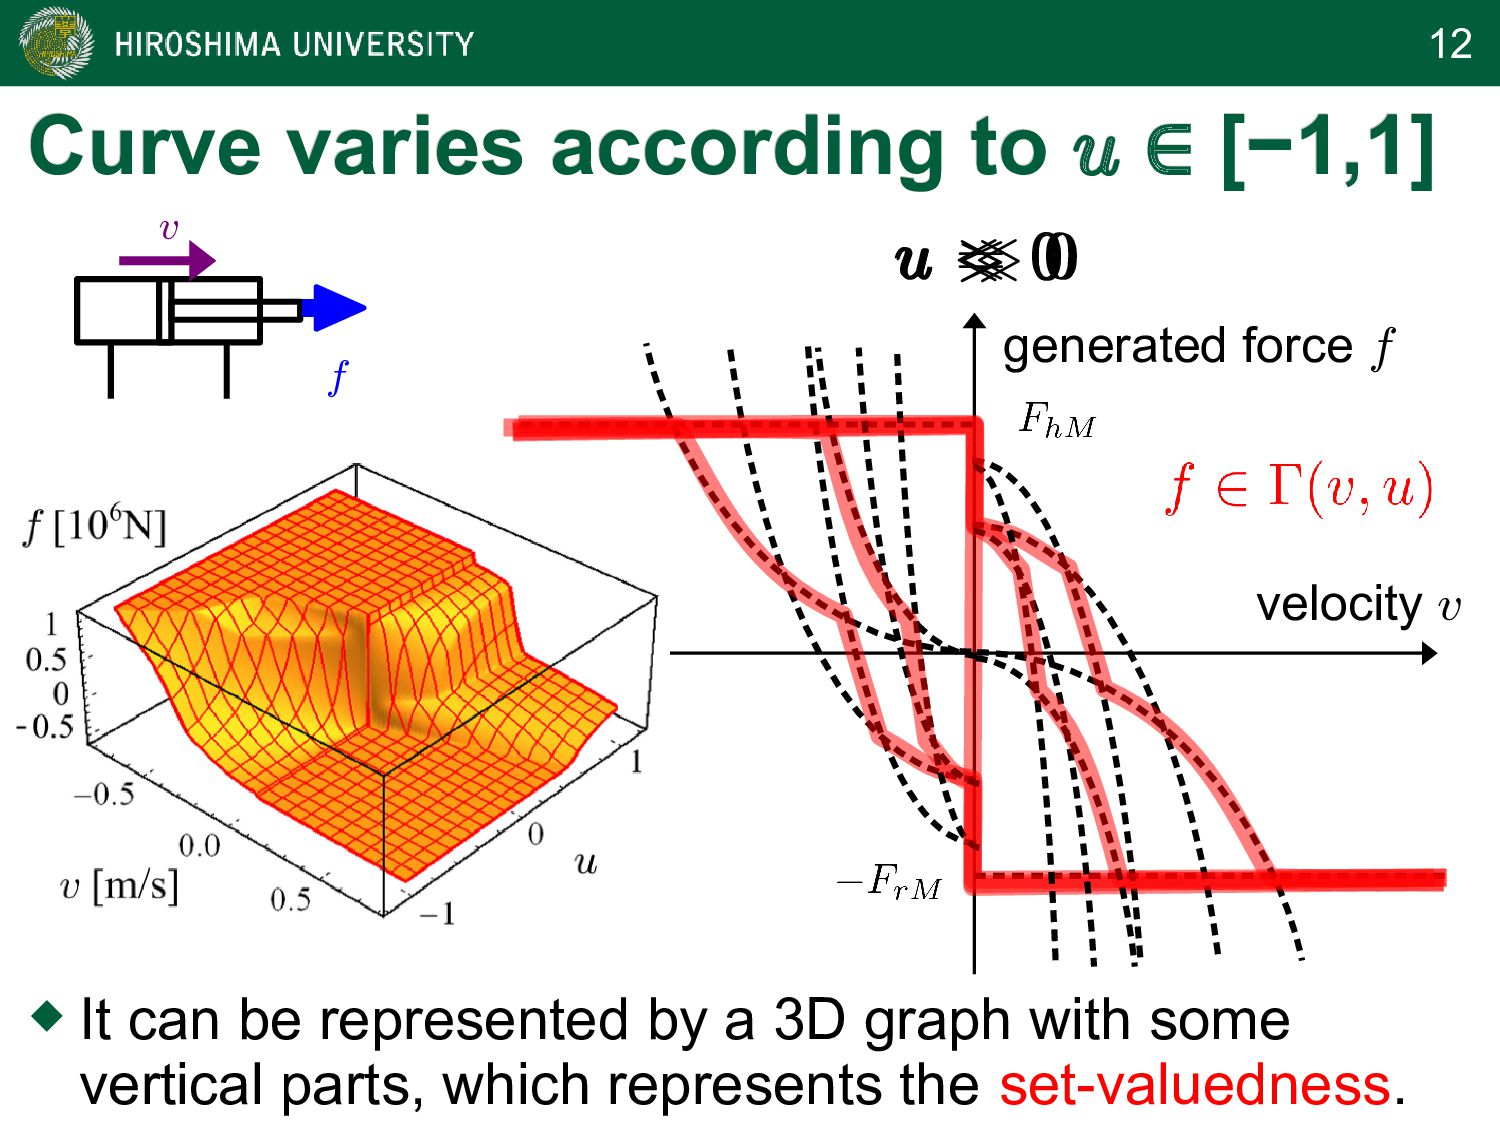
12 generated force f velocity v u = 0 Curve
varies according to Curve varies according to u u ∈ ∈ [−1,1] [−1,1] u ¿ 0 u À 0 v f u < 0 u > 0 It can be represented by a 3D graph with some vertical parts, which represents the set-valuedness. -
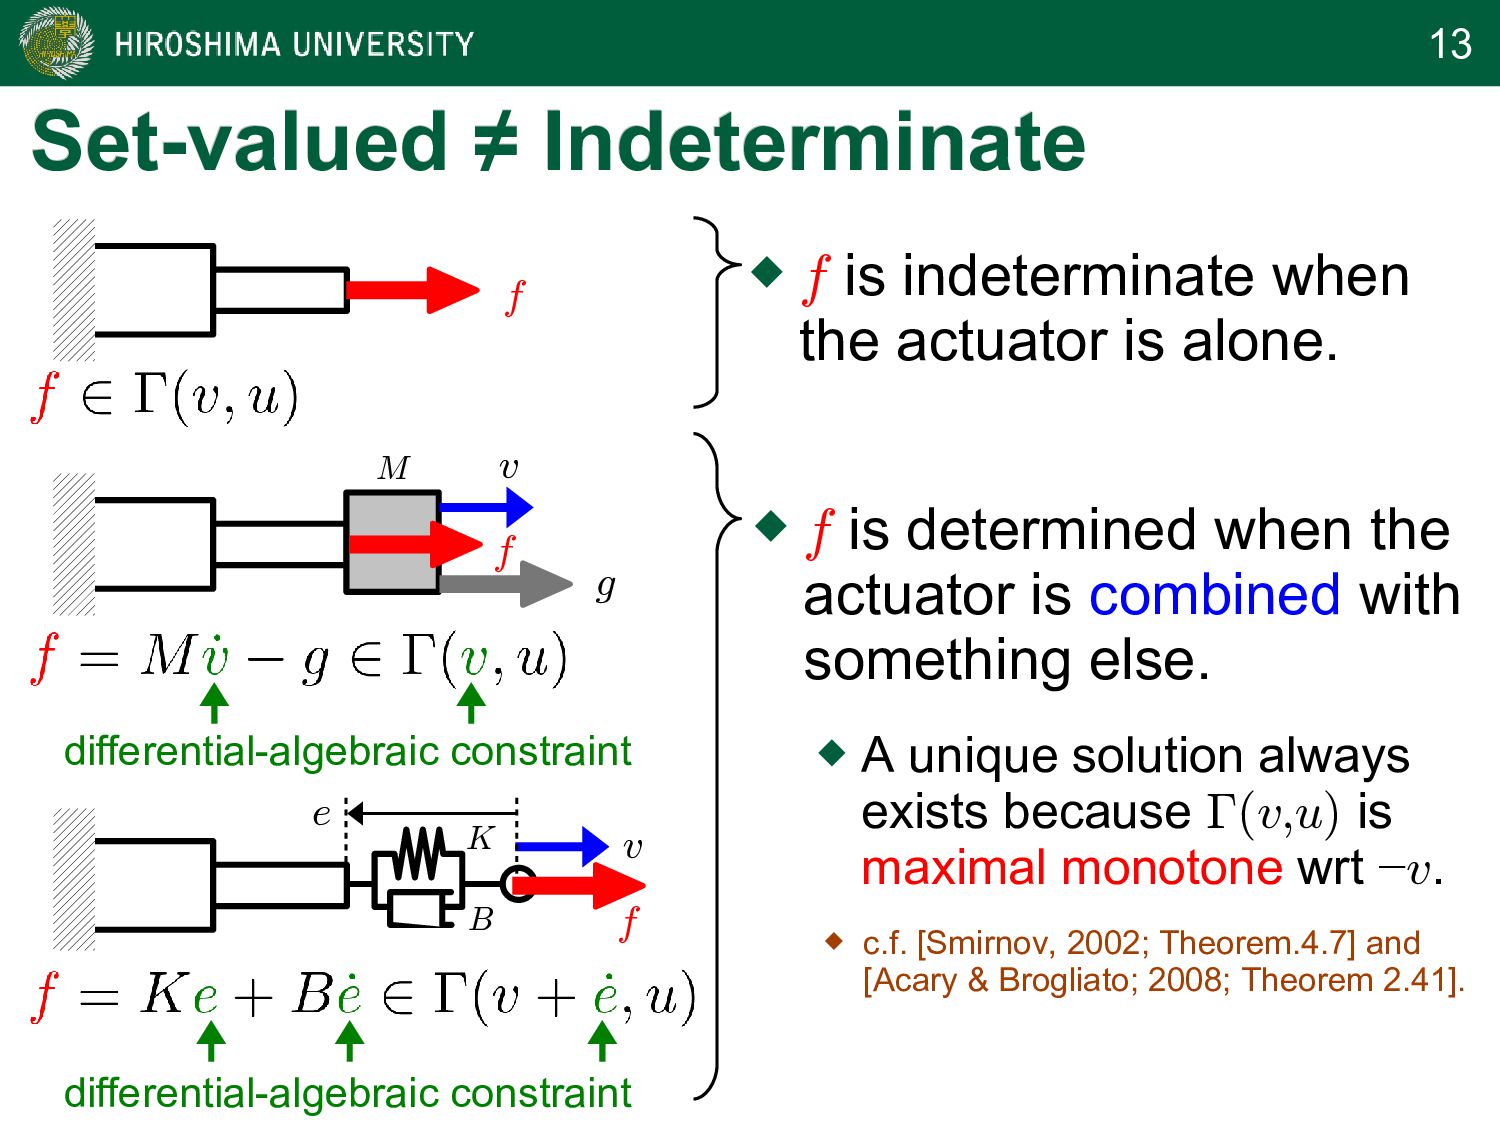
13 Set-valued ≠ Indeterminate Set-valued ≠ Indeterminate f is
indeterminate when the actuator is alone. f is determined when the actuator is combined with something else. differential-algebraic constraint A unique solution always exists because ¡(v,u) is maximal monotone wrt −v. f c.f. [Smirnov, 2002; Theorem.4.7] and [Acary & Brogliato; 2008; Theorem 2.41]. v M f g f B K e v differential-algebraic constraint -
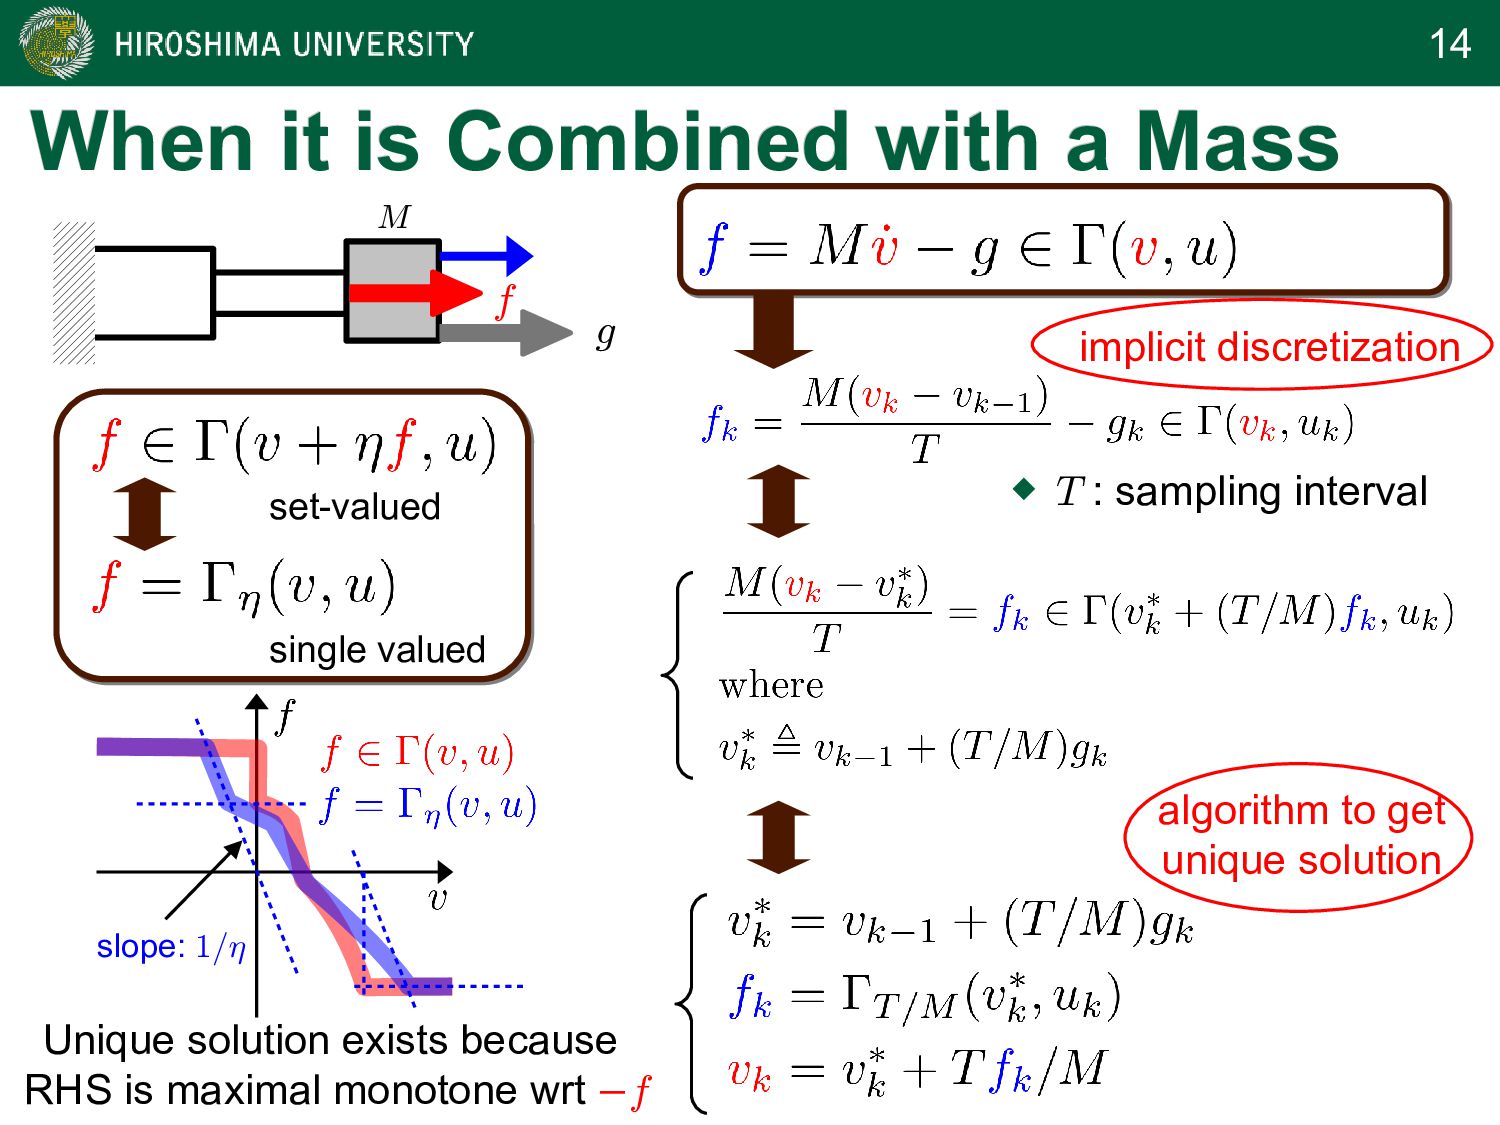
14 When it is Combined with a Mass When it
is Combined with a Mass single valued set-valued M f g slope: 1/´ algorithm to get unique solution Unique solution exists because RHS is maximal monotone wrt −f implicit discretization T : sampling interval -
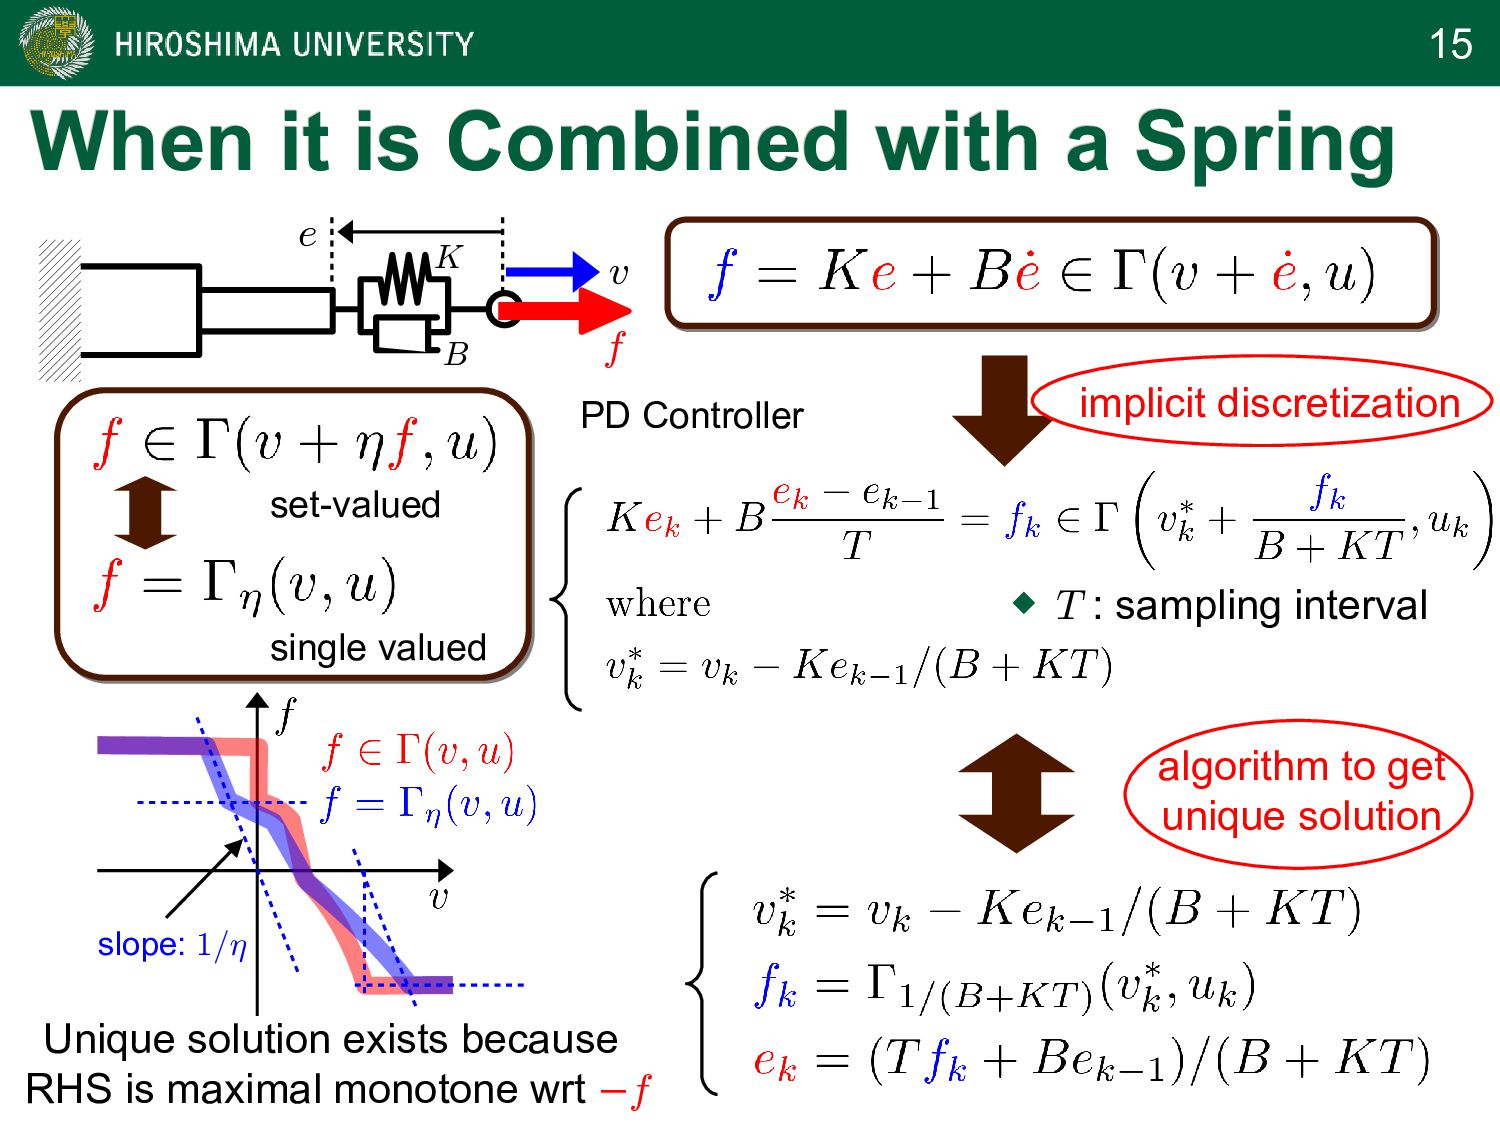
15 When it is Combined with a Spring When it
is Combined with a Spring f B K e v single valued set-valued slope: 1/´ Unique solution exists because RHS is maximal monotone wrt −f implicit discretization PD Controller T : sampling interval algorithm to get unique solution -
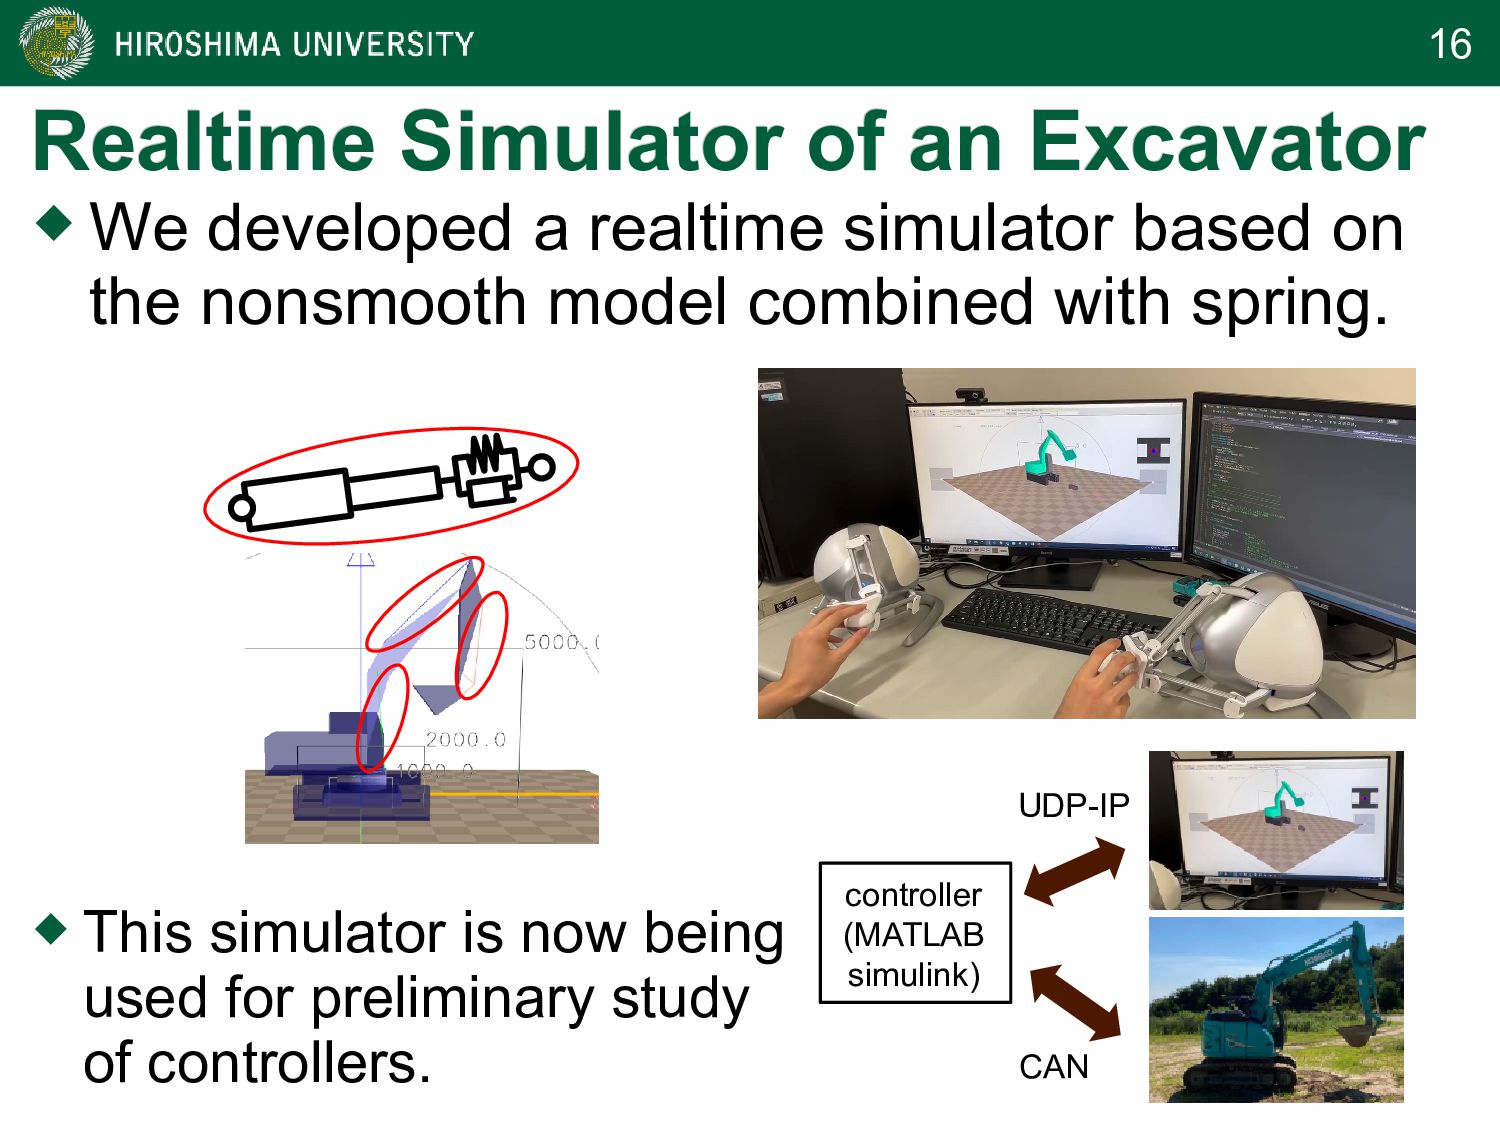
16 Realtime Simulator of an Excavator Realtime Simulator of an
Excavator We developed a realtime simulator based on the nonsmooth model combined with spring. This simulator is now being used for preliminary study of controllers. controller (MATLAB simulink) UDP-IP CAN -
17 [2] [2] Position Controller A: Position Controller A: “
“Model-based” Implementation Model-based” Implementation of Sliding-Mode Controller of Sliding-Mode Controller to Nonsmooth Actuator to Nonsmooth Actuator [2] [2] Position Controller A: Position Controller A: “ “Model-based” Implementation Model-based” Implementation of Sliding-Mode Controller of Sliding-Mode Controller to Nonsmooth Actuator to Nonsmooth Actuator Kikuuwe, Yamamoto & Brogliato: “Implicit Implementation of Nonsmooth Controllers to Nonsmooth Actuators,” IEEE Trans Automatic Control, vol.67, no.9, pp.4645-4657, 2022. Yamamoto, Qiu, Munemasa, Doi, Nanjo, Yamashita & Kikuuwe:“A Sliding-Mode Set-Point Position Controller for Hydraulic Excavators,” IEEE Access, vol.9, pp.153735-153749, 2021. -
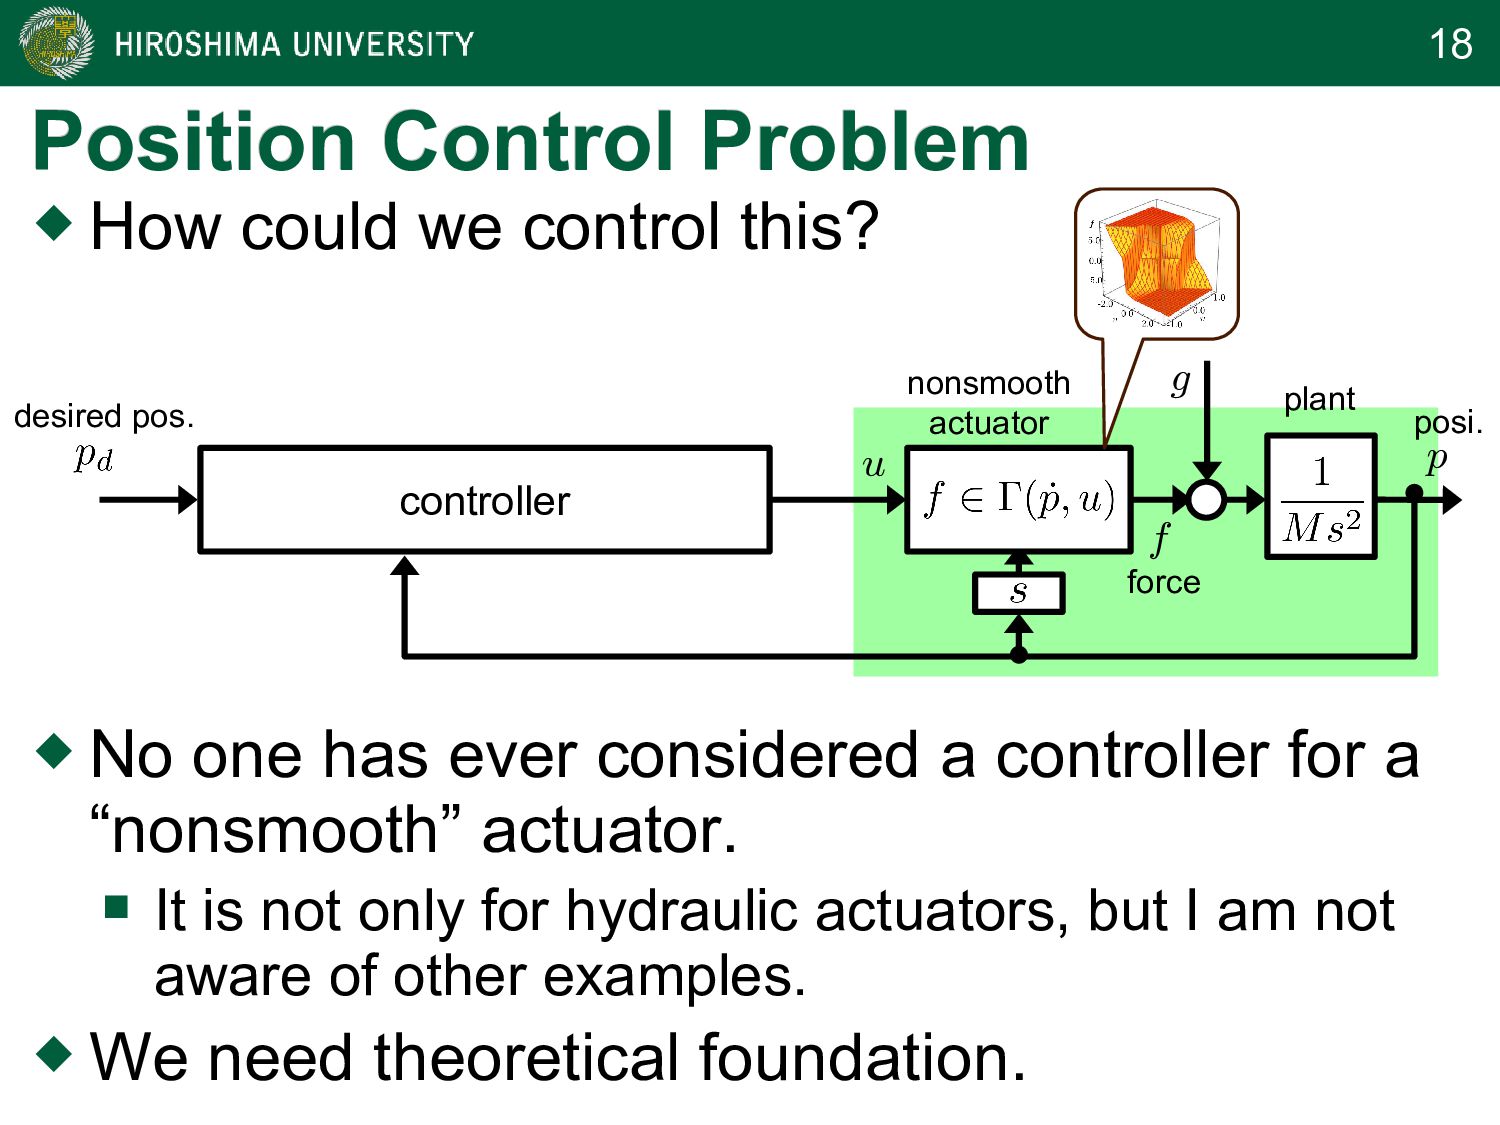
18 Position Control Problem Position Control Problem How could
we control this? No one has ever considered a controller for a “nonsmooth” actuator. It is not only for hydraulic actuators, but I am not aware of other examples. We need theoretical foundation. f u g nonsmooth actuator plant p force posi. desired pos. controller -
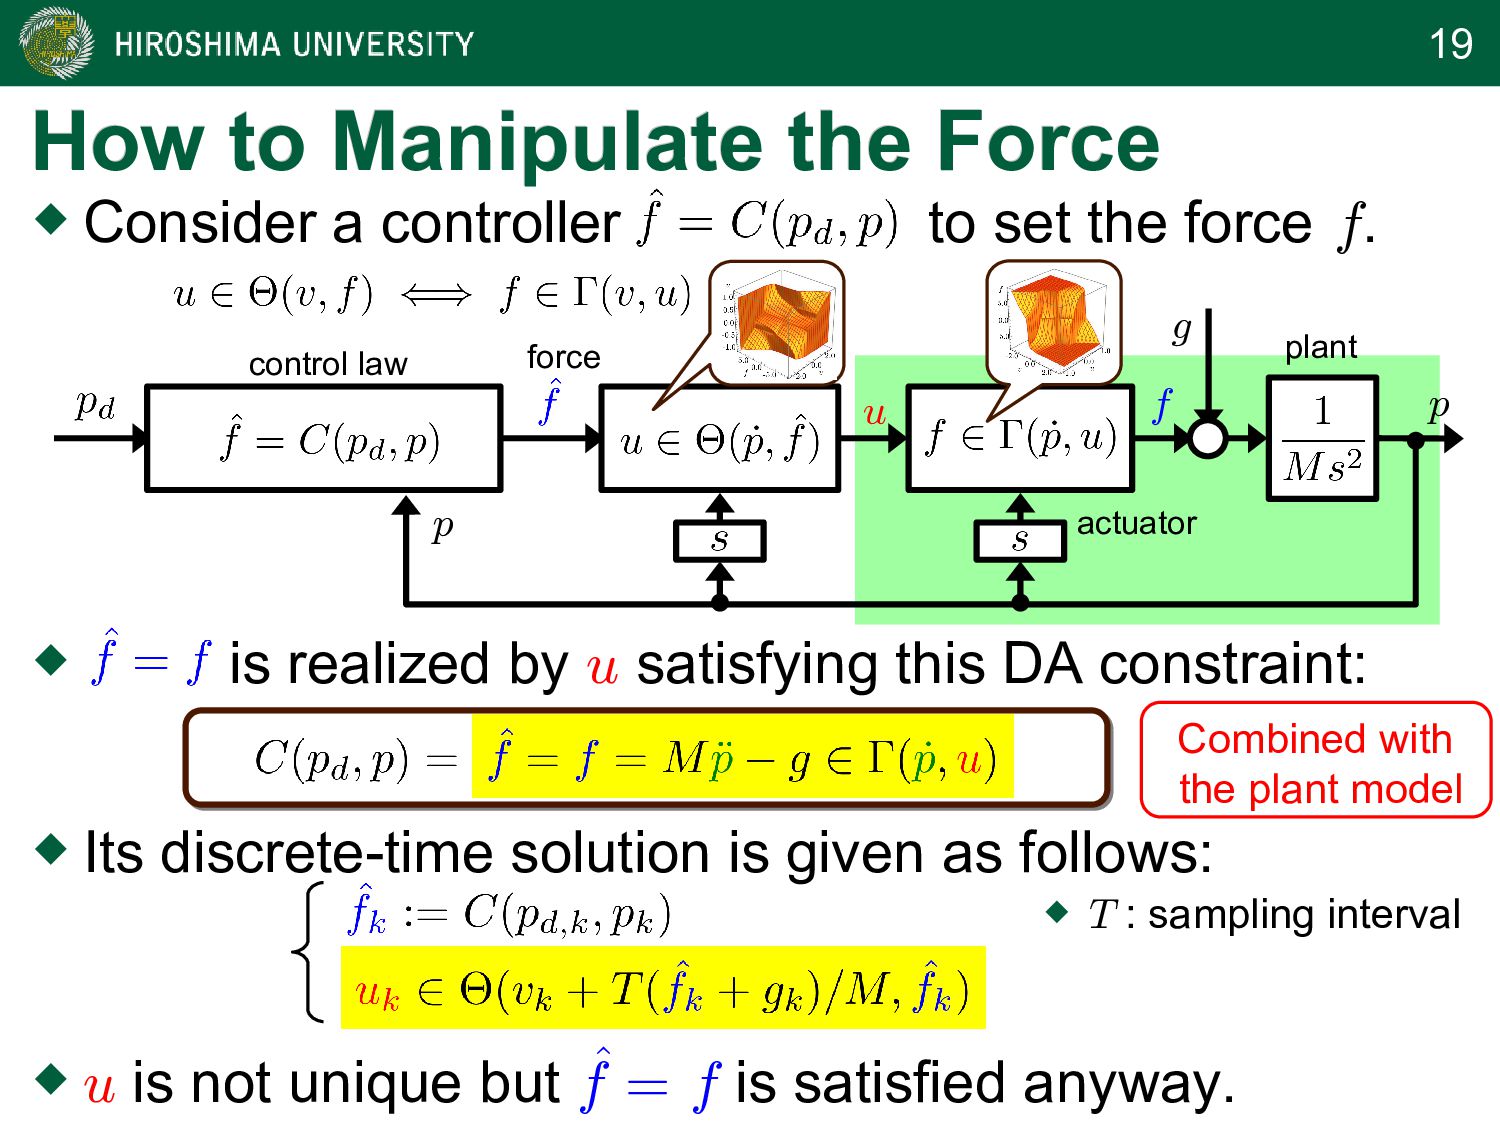
19 How to Manipulate the Force How to Manipulate the
Force Consider a controller to set the force f. p f u g actuator plant p control law force is realized by u satisfying this DA constraint: u is not unique but f = f is satisfied anyway. ^ Its discrete-time solution is given as follows: T : sampling interval Combined with the plant model -
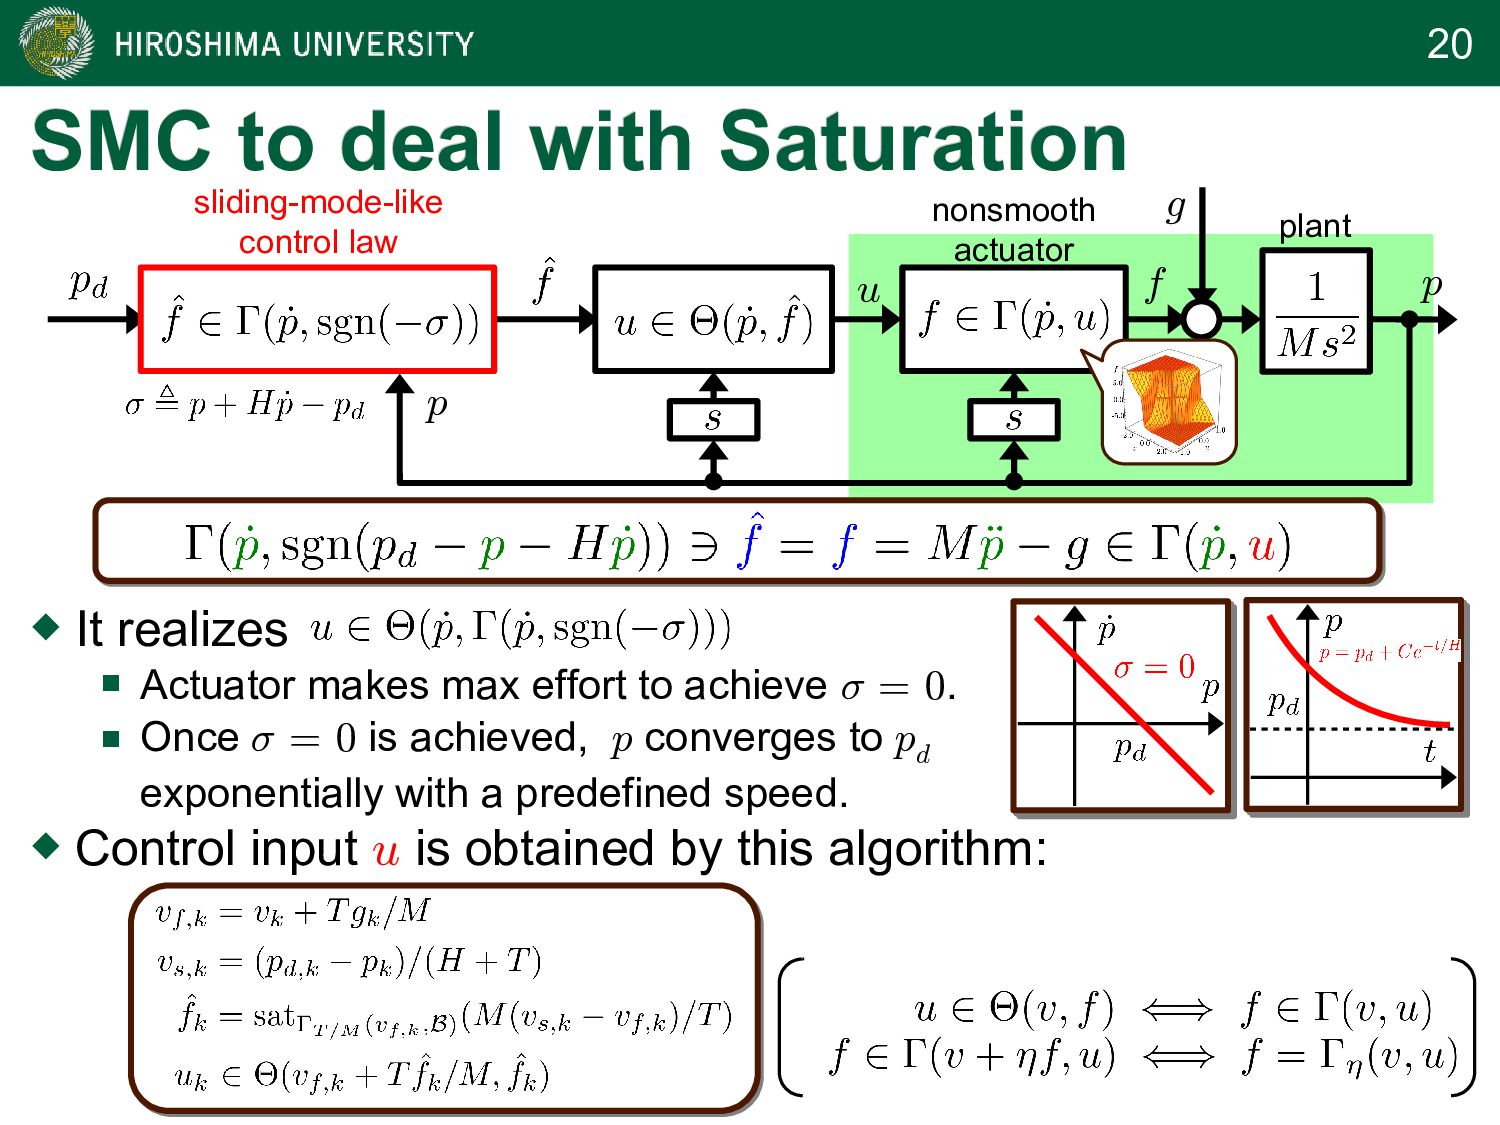
20 SMC to deal with Saturation SMC to deal with
Saturation p f u g nonsmooth actuator plant p It realizes Actuator makes max effort to achieve ¾ = 0. Once ¾ = 0 is achieved, p converges to p d exponentially with a predefined speed. Control input u is obtained by this algorithm: sliding-mode-like control law -
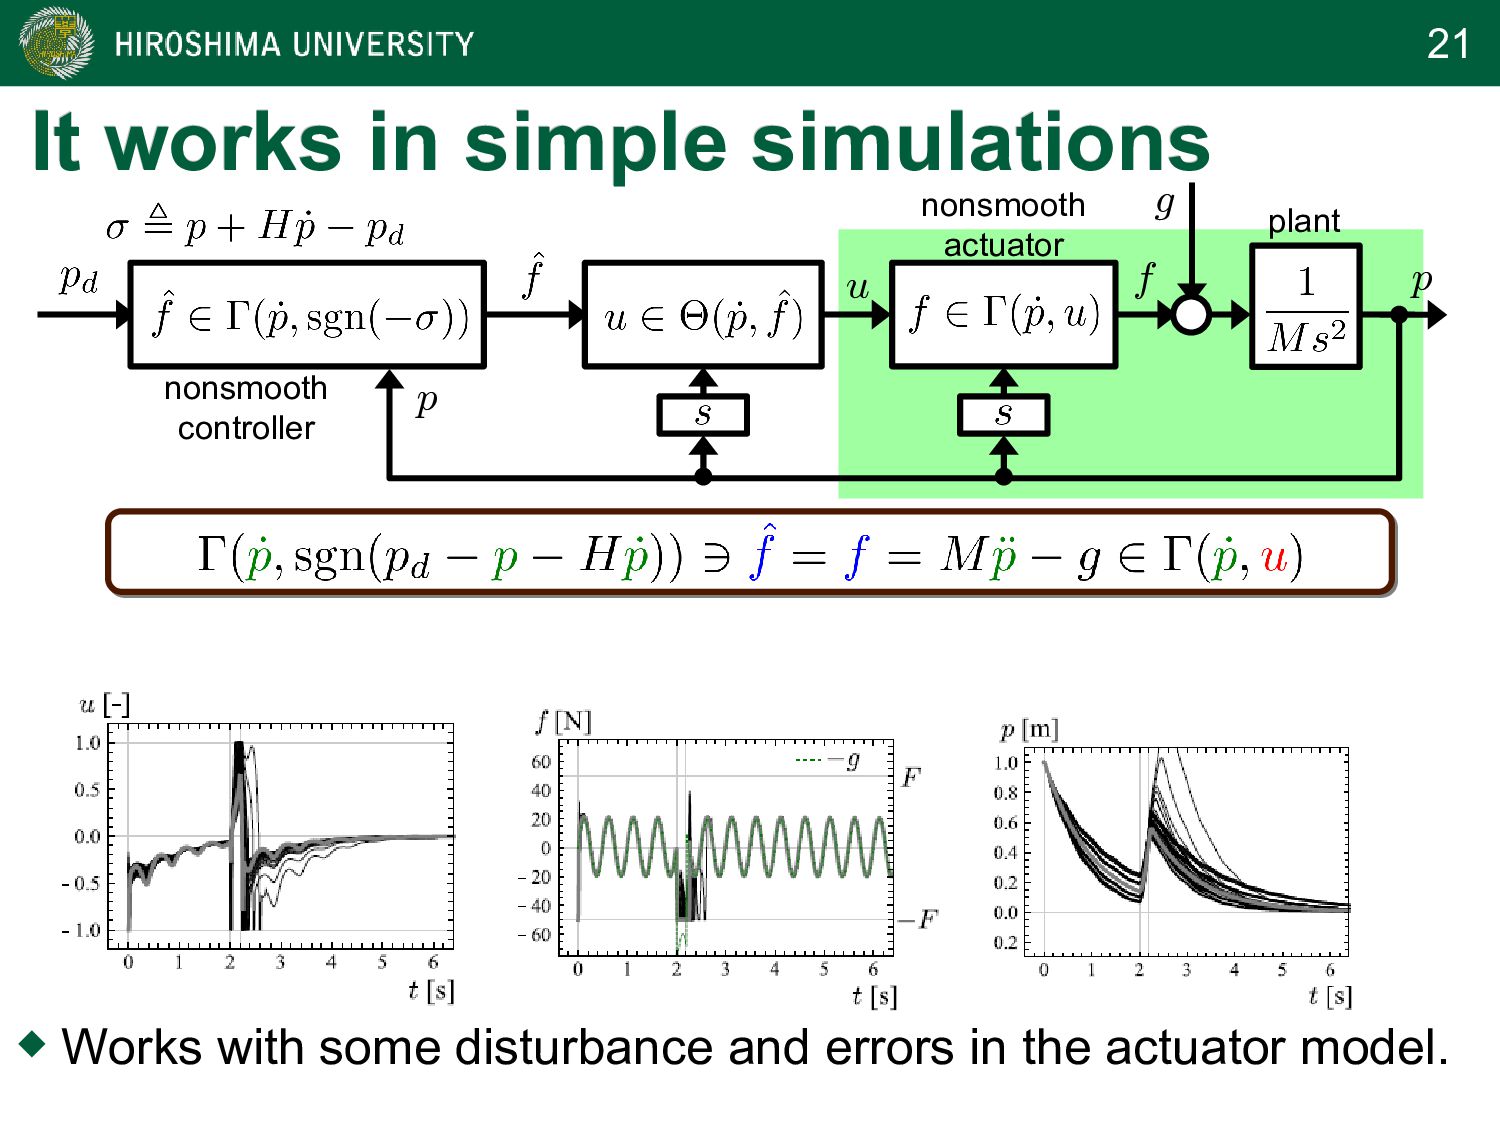
21 It works in simple simulations It works in simple
simulations Works with some disturbance and errors in the actuator model. p f u g nonsmooth actuator plant p nonsmooth controller -
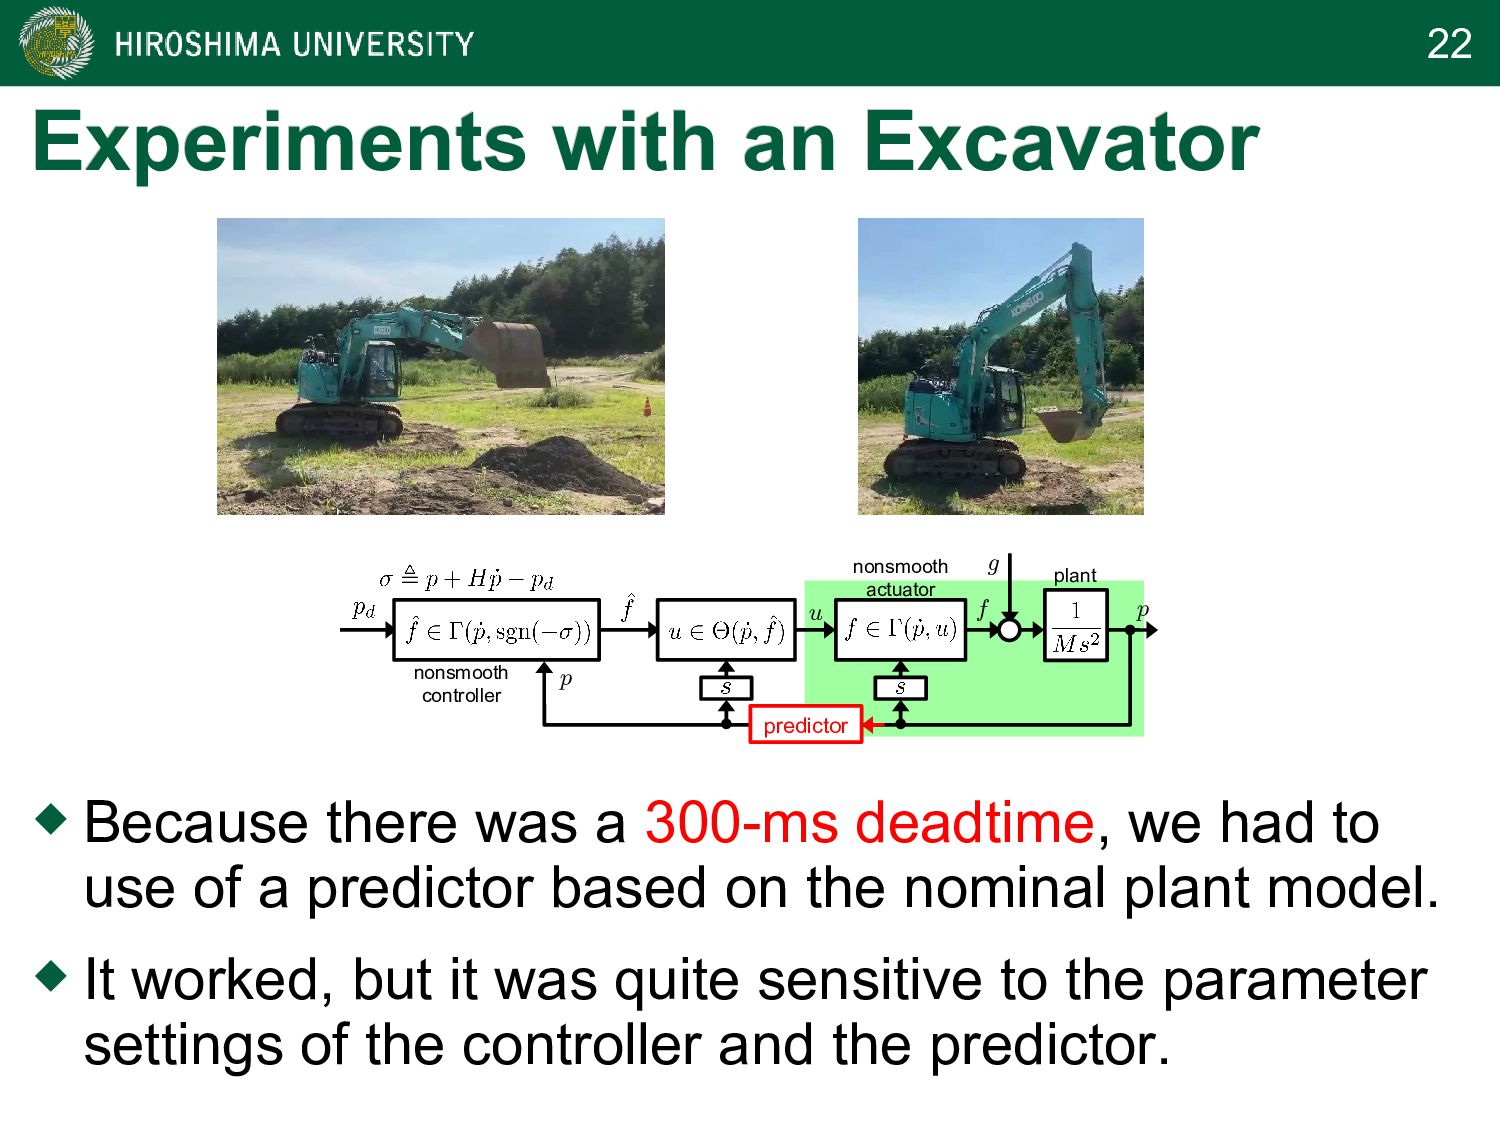
22 Experiments with an Excavator Experiments with an Excavator
Because there was a 300-ms deadtime, we had to use of a predictor based on the nominal plant model. p f u g nonsmooth actuator plant p nonsmooth controller predictor It worked, but it was quite sensitive to the parameter settings of the controller and the predictor. -
23 [3] [3] Position Controller B: Position Controller B: “
“PD-based” Implementation PD-based” Implementation of Sliding-Mode-Like Controller of Sliding-Mode-Like Controller to Nonsmooth Actuator to Nonsmooth Actuator [3] [3] Position Controller B: Position Controller B: “ “PD-based” Implementation PD-based” Implementation of Sliding-Mode-Like Controller of Sliding-Mode-Like Controller to Nonsmooth Actuator to Nonsmooth Actuator Yamamoto, Qiu, Doi, Nanjo, Yamashita & Kikuuwe:“A Position Controller for Hydraulic Excavators with Deadtime and Regenerative Pipelines,” preprint, jxiv.440, 2023. -
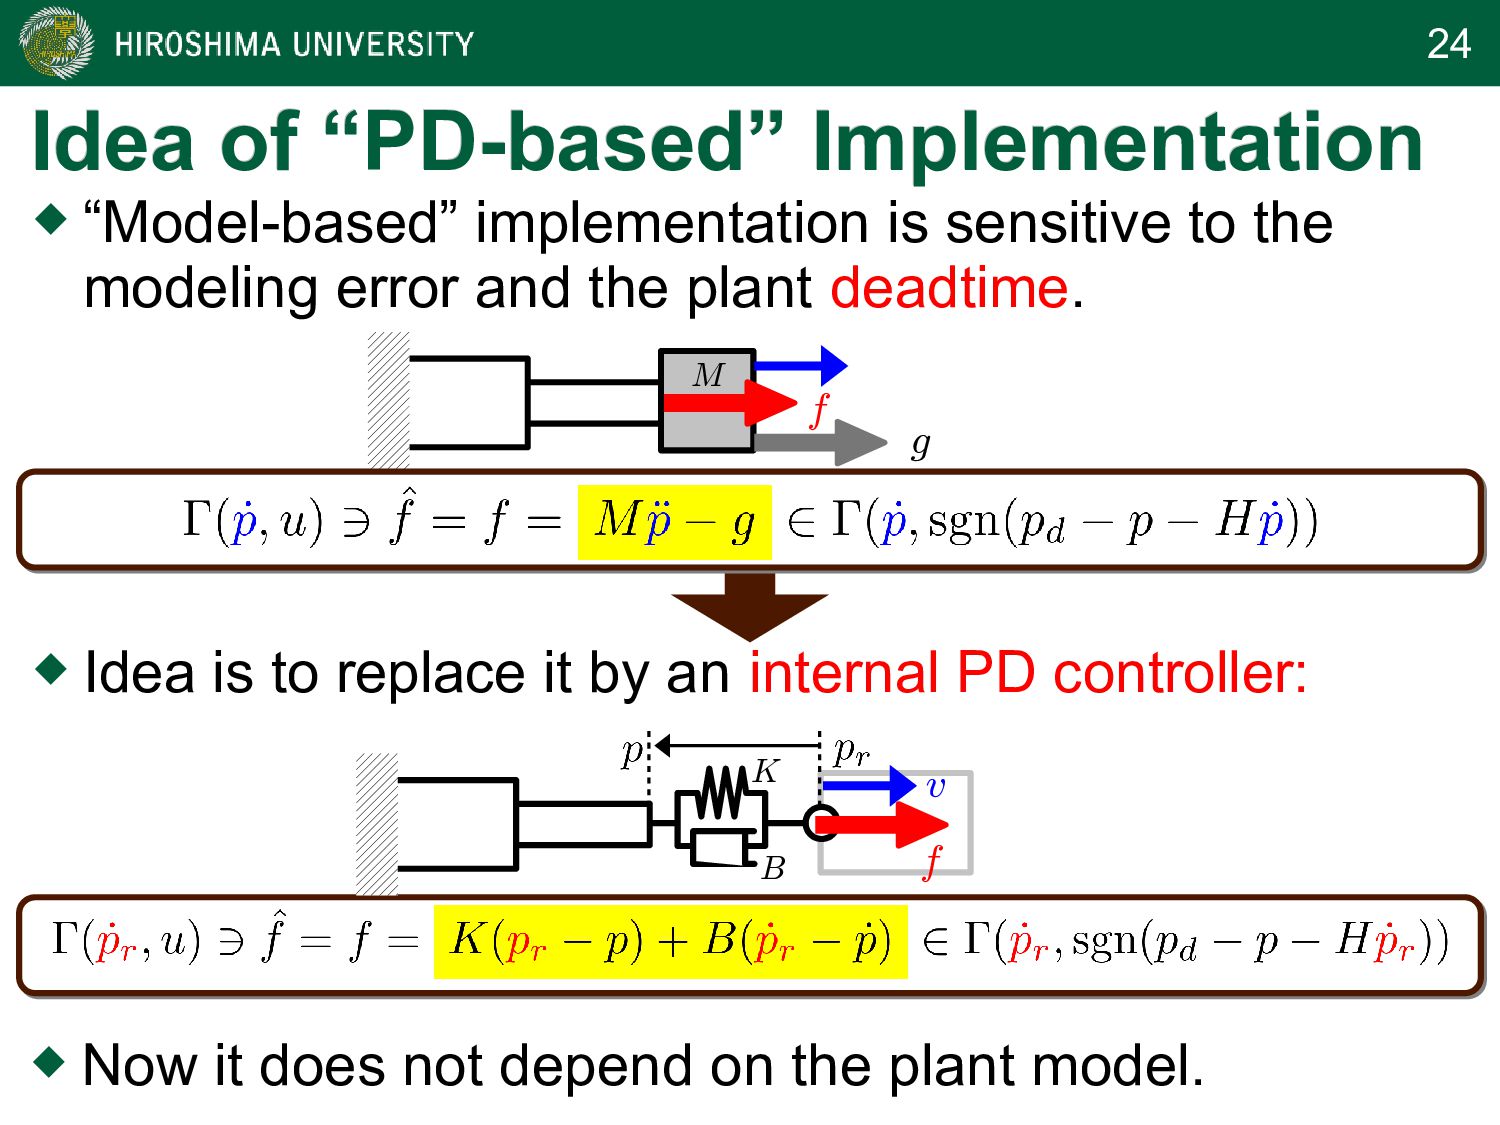
24 M f g Idea of “PD-based” Implementation Idea of
“PD-based” Implementation “Model-based” implementation is sensitive to the modeling error and the plant deadtime. f B K v Idea is to replace it by an internal PD controller: Now it does not depend on the plant model. -
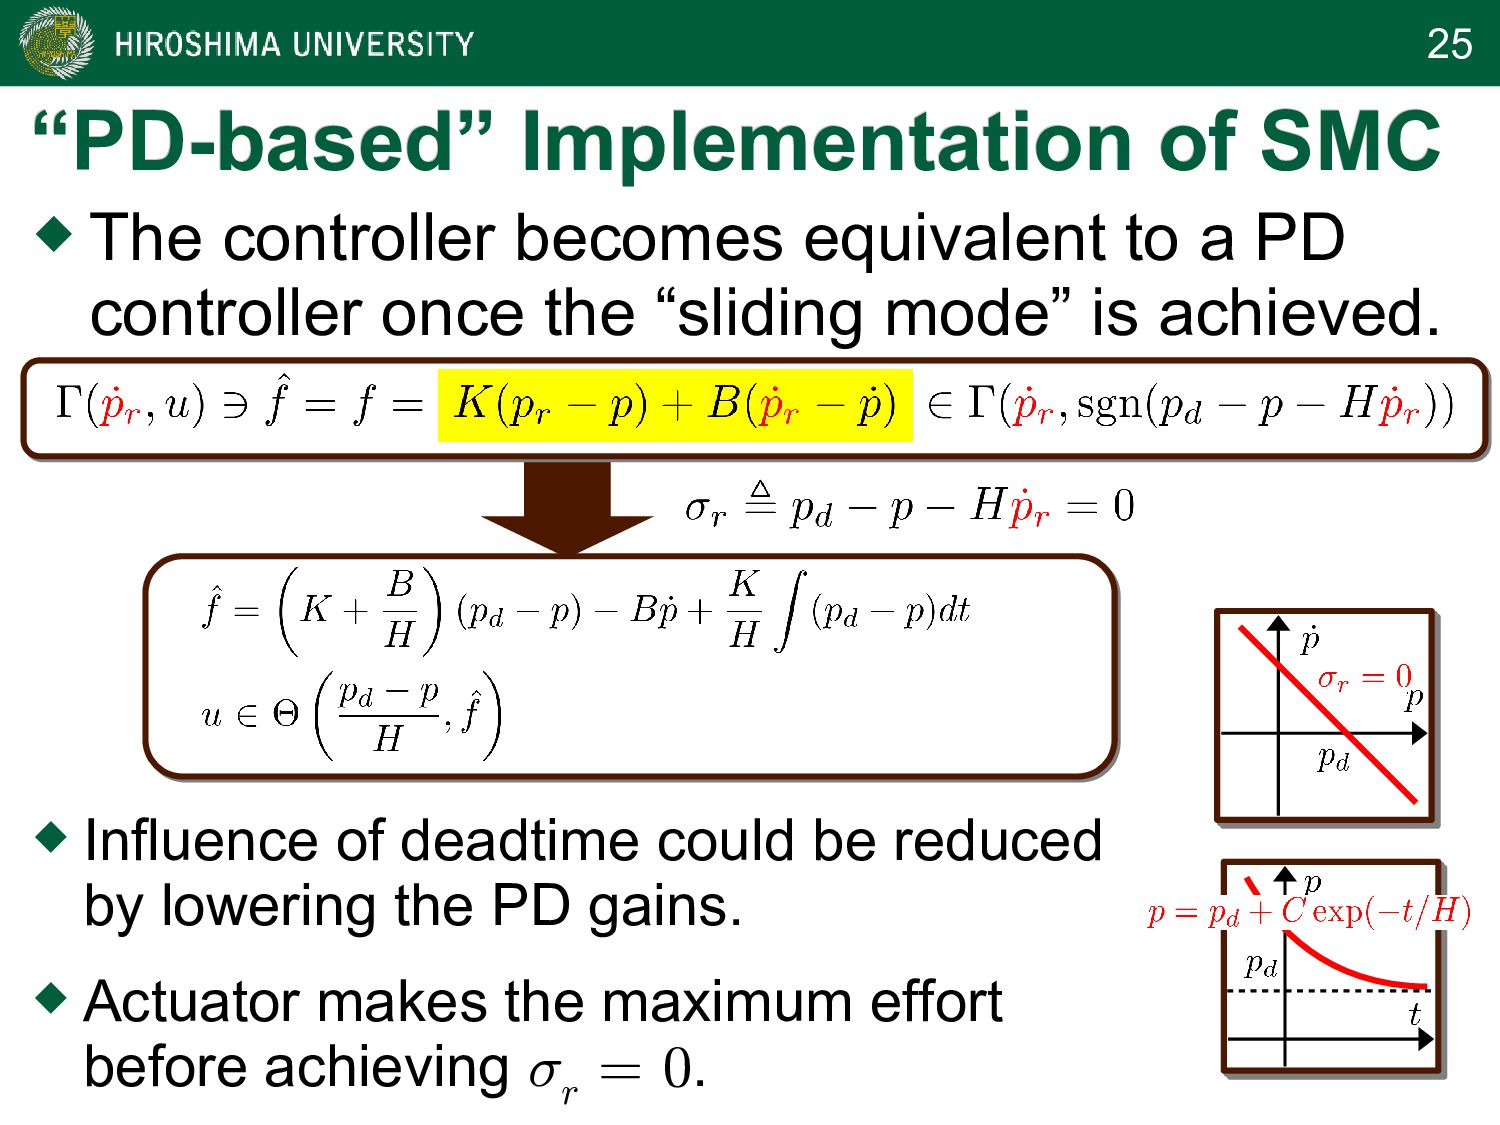
25 “ “PD-based” Implementation of SMC PD-based” Implementation of SMC
Influence of deadtime could be reduced by lowering the PD gains. The controller becomes equivalent to a PD controller once the “sliding mode” is achieved. Actuator makes the maximum effort before achieving ¾ r = 0. -
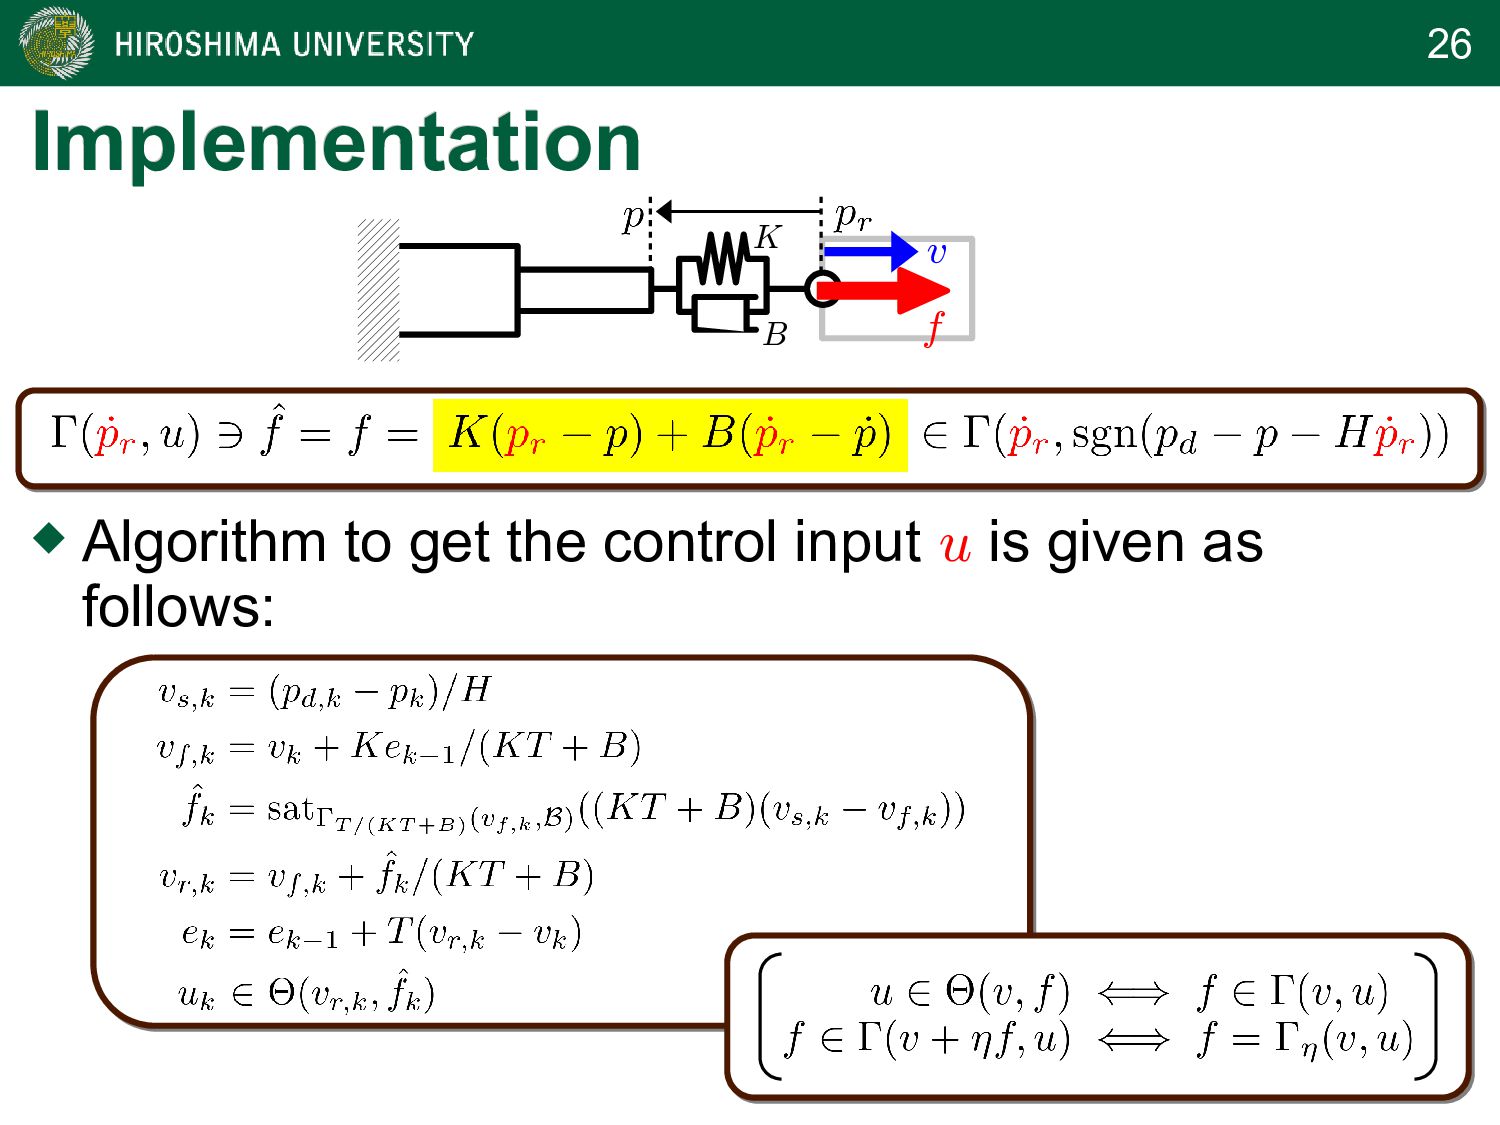
26 Implementation Implementation Algorithm to get the control input
u is given as follows: f B K v -
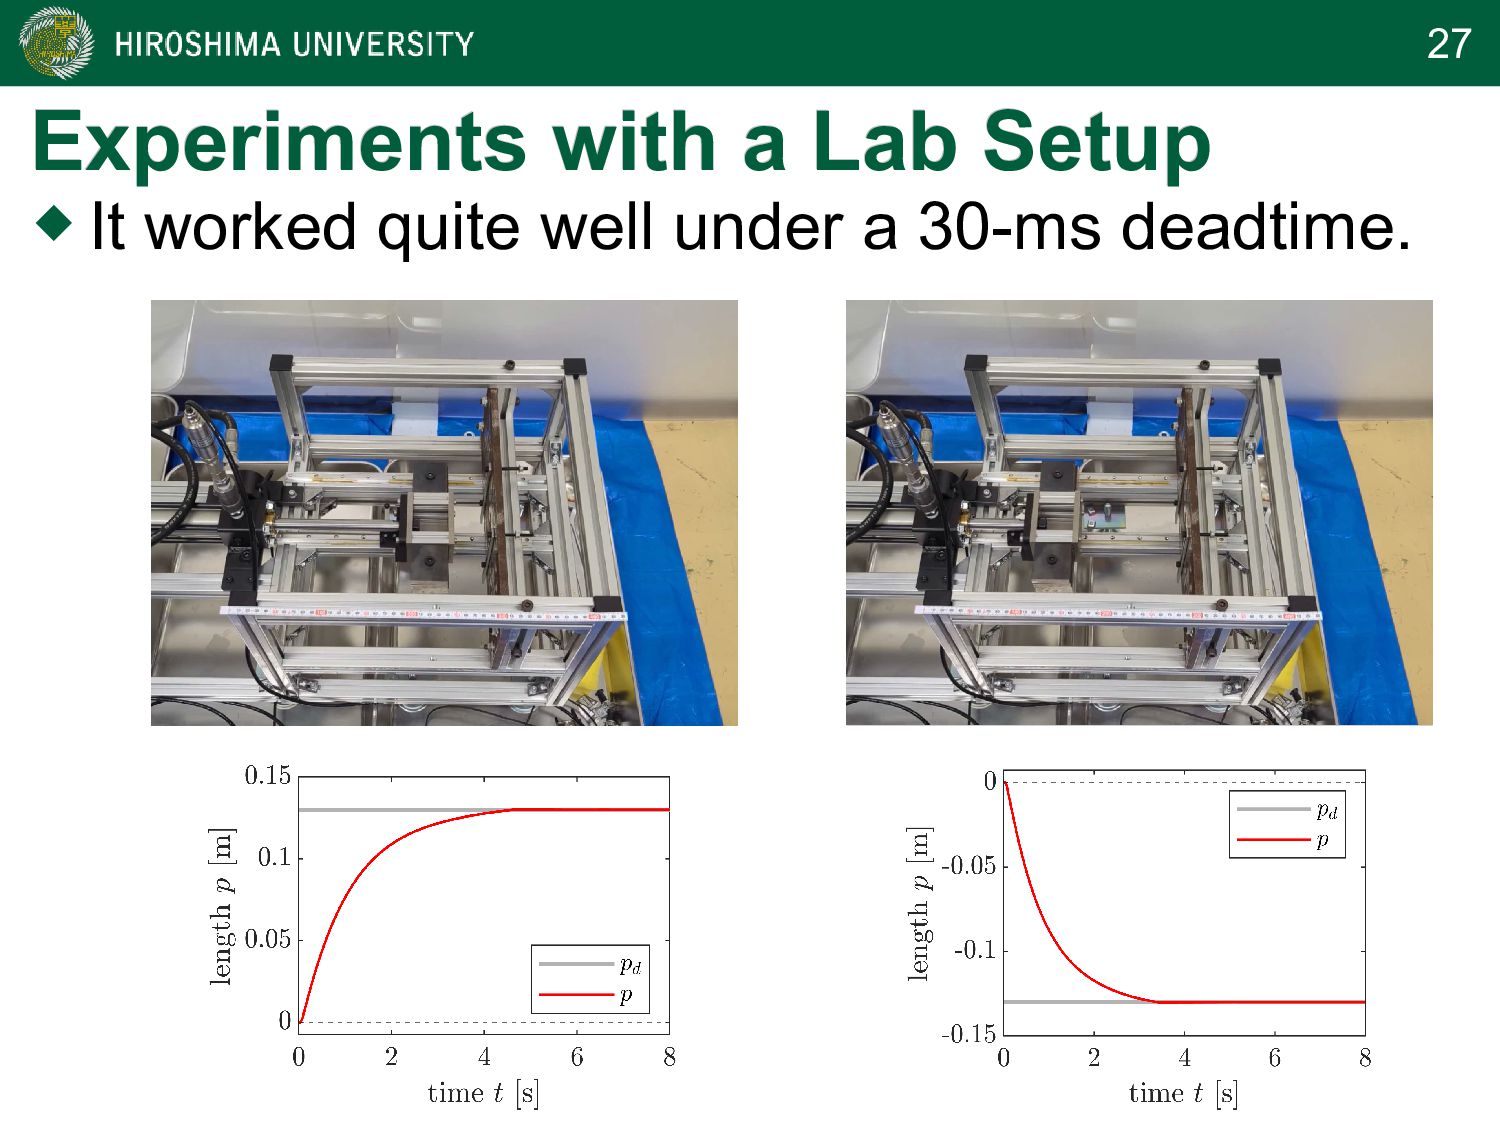
27 Experiments with a Lab Setup Experiments with a Lab
Setup It worked quite well under a 30-ms deadtime. -
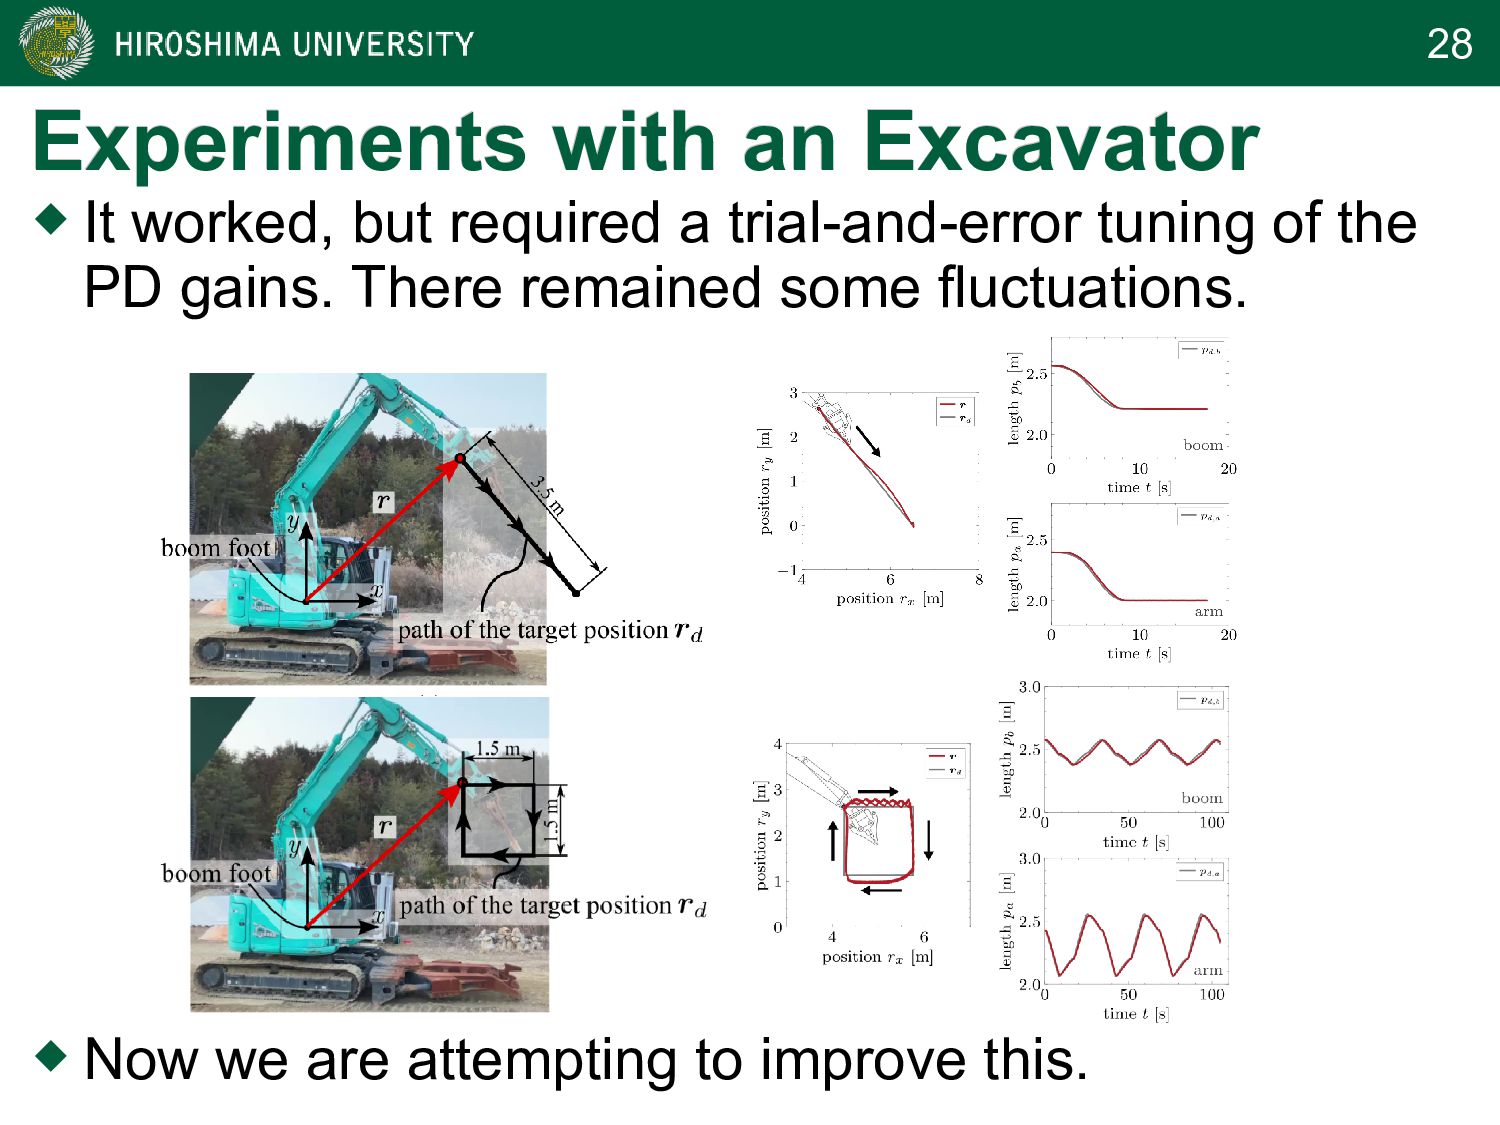
28 Experiments with an Excavator Experiments with an Excavator
It worked, but required a trial-and-error tuning of the PD gains. There remained some fluctuations. Now we are attempting to improve this. -
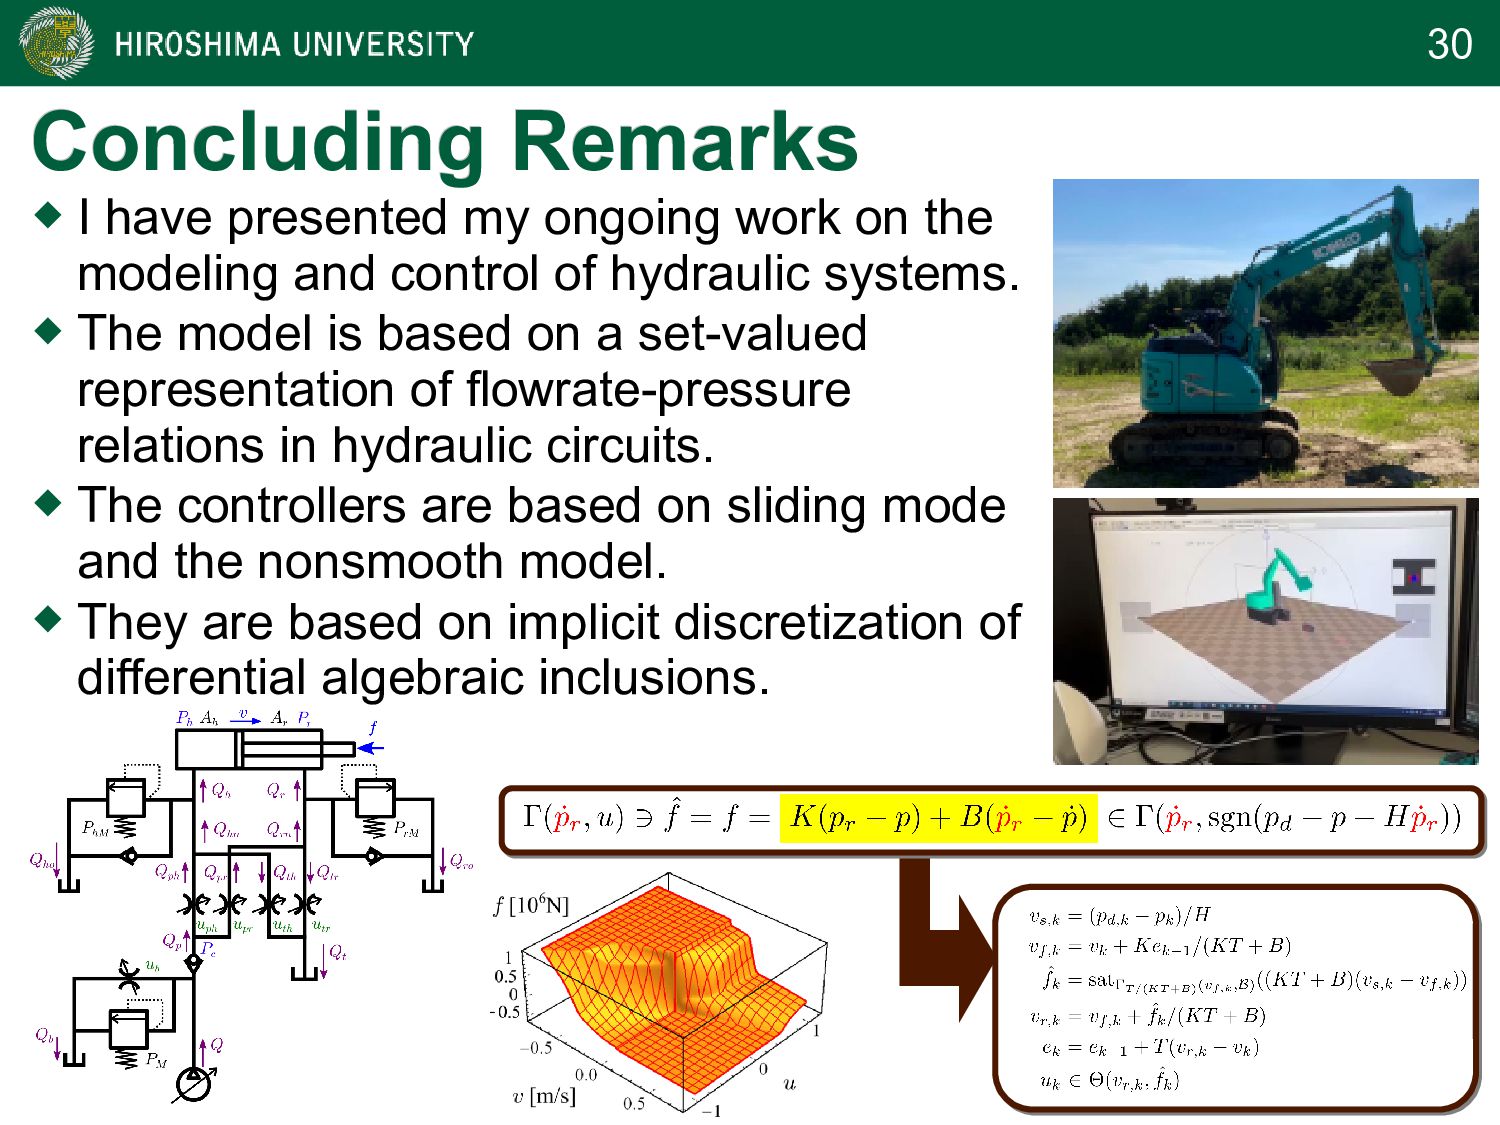
30 Concluding Remarks Concluding Remarks I have presented my
ongoing work on the modeling and control of hydraulic systems. The model is based on a set-valued representation of flowrate-pressure relations in hydraulic circuits. The controllers are based on sliding mode and the nonsmooth model. They are based on implicit discretization of differential algebraic inclusions. -
31 Acknowledgment Acknowledgment This work would have been impossible
without the contributions of the coauthors. I thank; Kobelco engineers and researchers for motivating me into this work, sharing their knowledge on hydraulic systems, and their efforts in excavator experiments. Dr. Bernard Brogliato for sharing his vast expertise on the theory of nonsmooth systems. Mr. Yuki Yamamoto, a PhD candidate, for his continuing contribution spanning from theory to hardware. Kikuuwe, Okada, Yoshihara, Doi, Nanjo & Yamashita: “A Nonsmooth Quasi-Static Modeling Approach for Hydraulic Actuators,” Trans ASME: J. Dynamic Systems, Measurement, and Control, vol.143, no.12, p.121002, 2021. Yamamoto, Qiu, Munemasa, Doi, Nanjo, Yamashita & Kikuuwe:“A Sliding-Mode Set-Point Position Controller for Hydraulic Excavators,” IEEE Access, vol.9, pp.153735-153749, 2021. Kikuuwe, Yamamoto & Brogliato: “Implicit Implementation of Nonsmooth Controllers to Nonsmooth Actuators,” IEEE Trans Automatic Control, vol.67, no.9, pp.4645-4657, 2022. Yamamoto, Qiu, Doi, Nanjo, Yamashita & Kikuuwe:“A Position Controller for Hydraulic Excavators with Deadtime and Regenerative Pipelines,” preprint, jxiv.440, 2023.