Share
Embed
19_0906 A First-Order Differentiator with First-Order Sliding Mode Filtering
Presented at the 11th IFAC Symposium on Nonlinear Control Systems (NOLCOS 2019), Vienna, Austria, September 06, 2019.
Ryo Kikuuwe
September 06, 2019
Transcript
16 slides
-
1 https://home.hiroshima-u.ac.jp/kikuuwe/ https://www.youtube.com/user/kikuuwe/ Hiroshima Univ., Japan Ryo Kikuuwe Kyushu Univ.,
Japan Bandung Inst. Tech., Indonesia Gyuho Byun Rainhart Pasaribu A First-Order Differentiator with A First-Order Differentiator with First-Order Sliding Mode Filtering First-Order Sliding Mode Filtering -
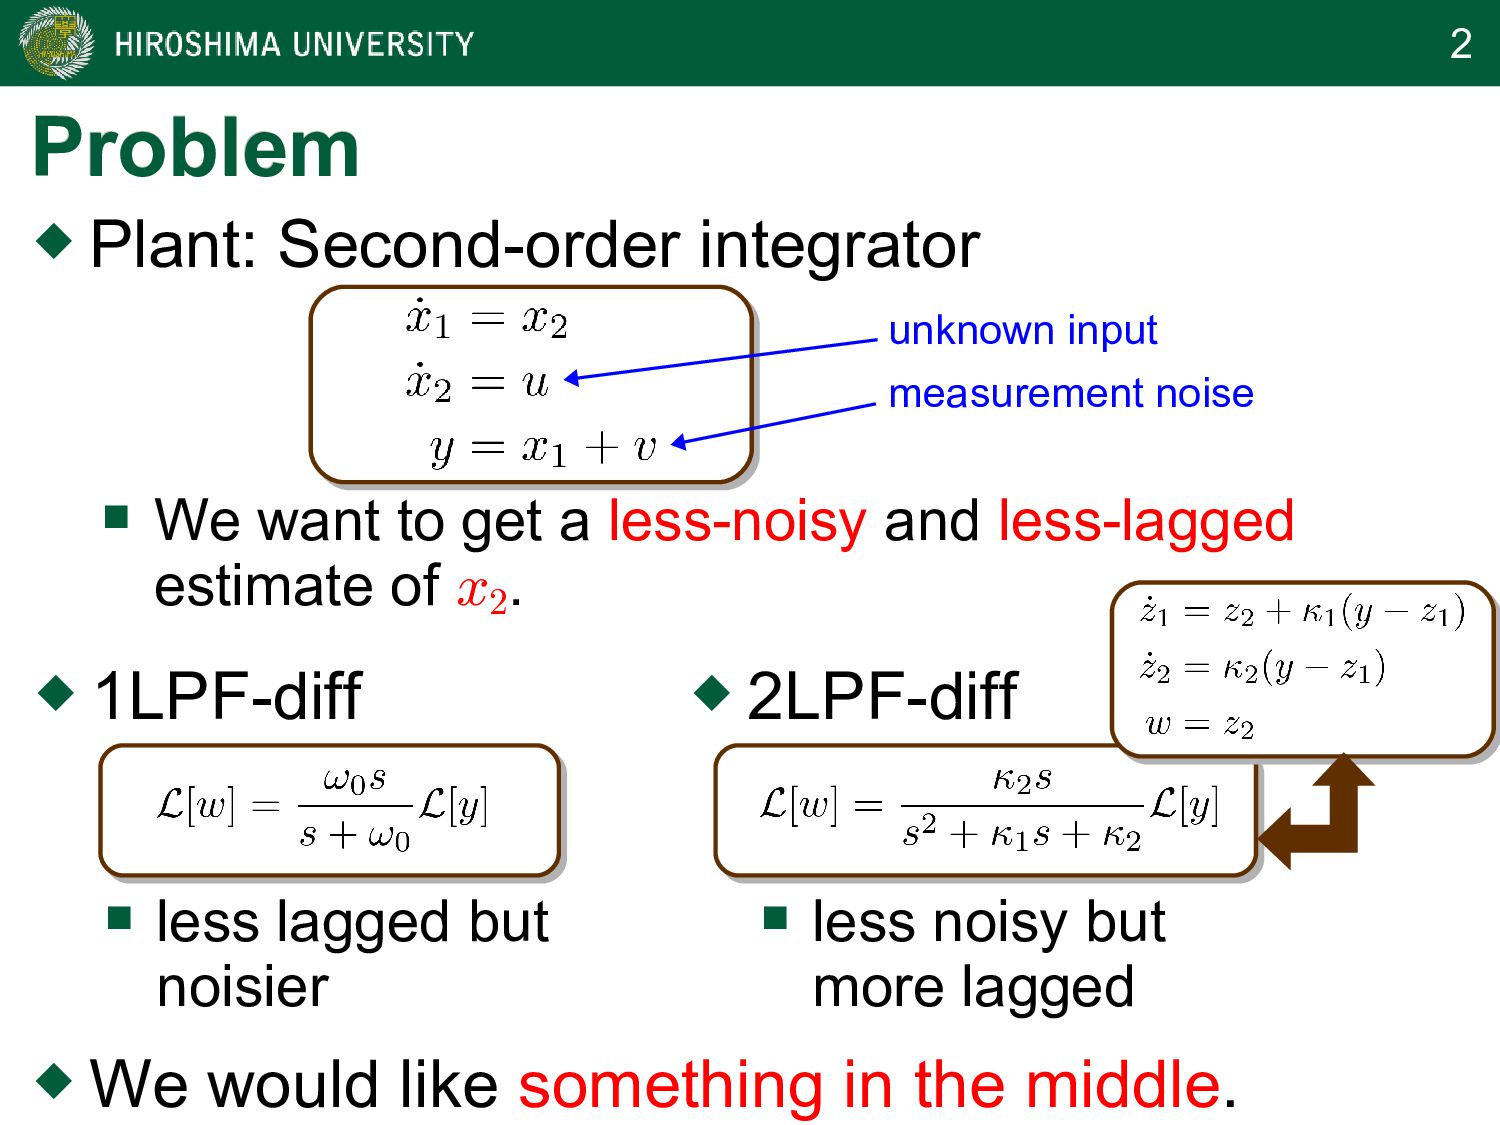
2 We would like something in the middle. Problem
Problem Plant: Second-order integrator less noisy but more lagged 1LPF-diff measurement noise unknown input We want to get a less-noisy and less-lagged estimate of x2 . less lagged but noisier 2LPF-diff -
3 Outline Outline Slotine-type observer and its properties
New “non-Lipschitz” variant of Slotine-type observer and its properties Discrete-time Implementation based on implicit discretization Some Simulation Results Conclusions -
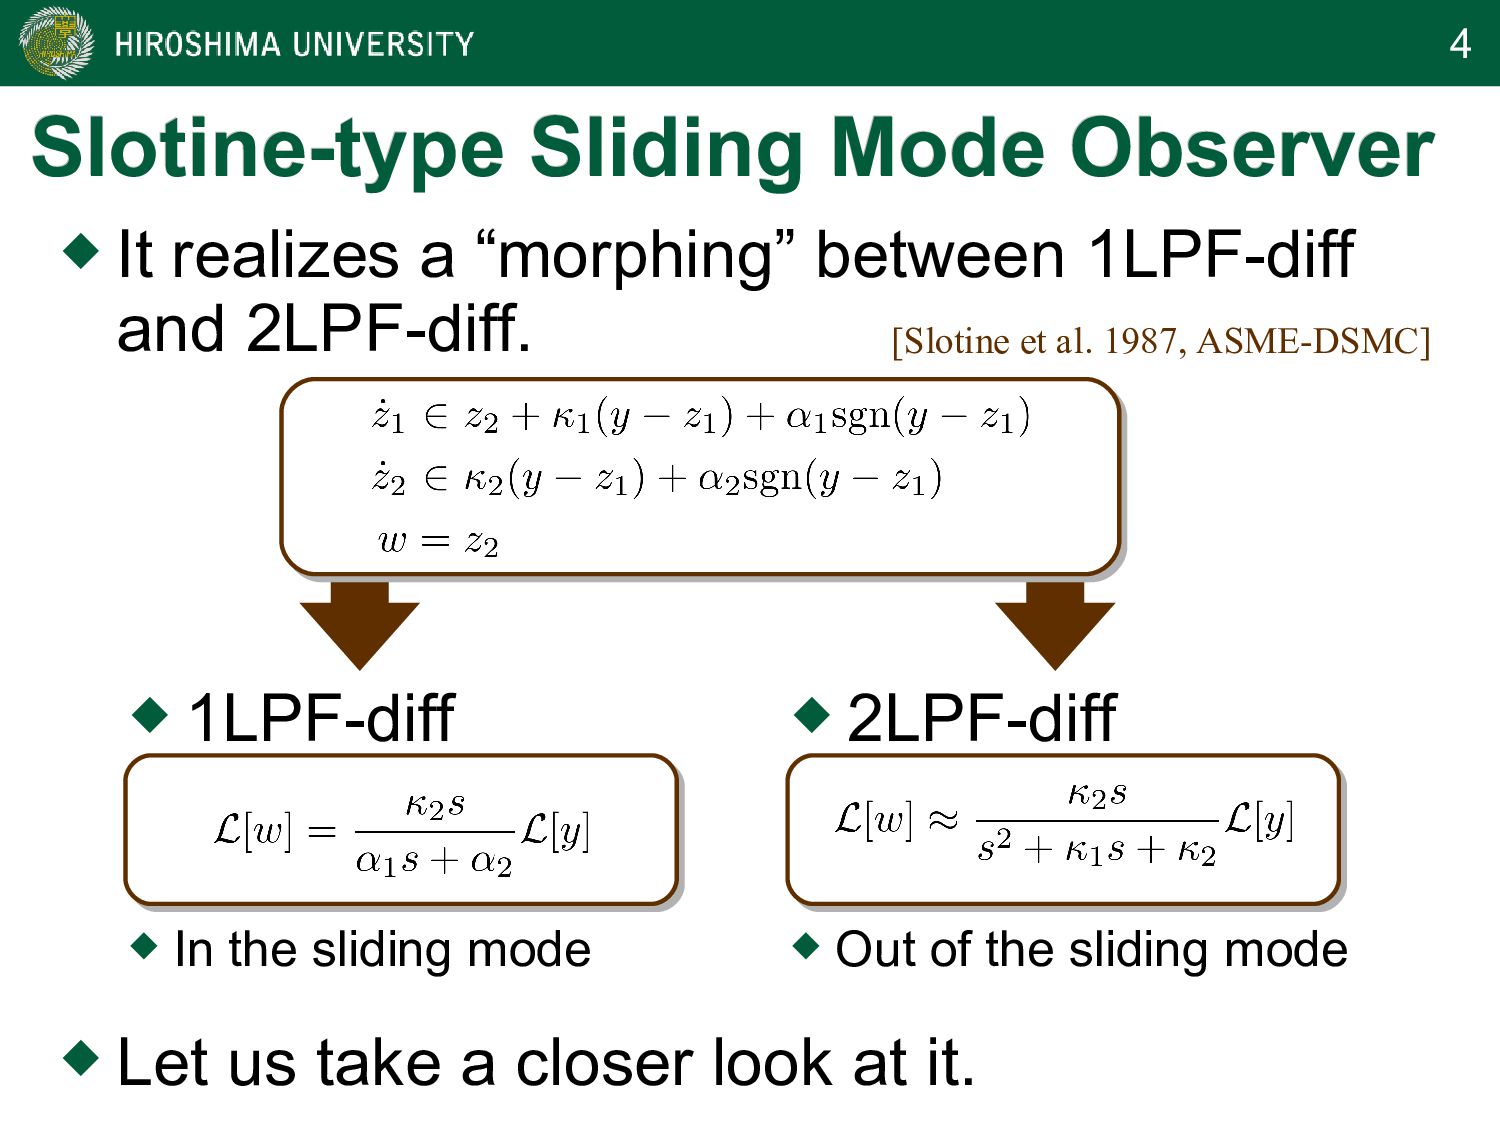
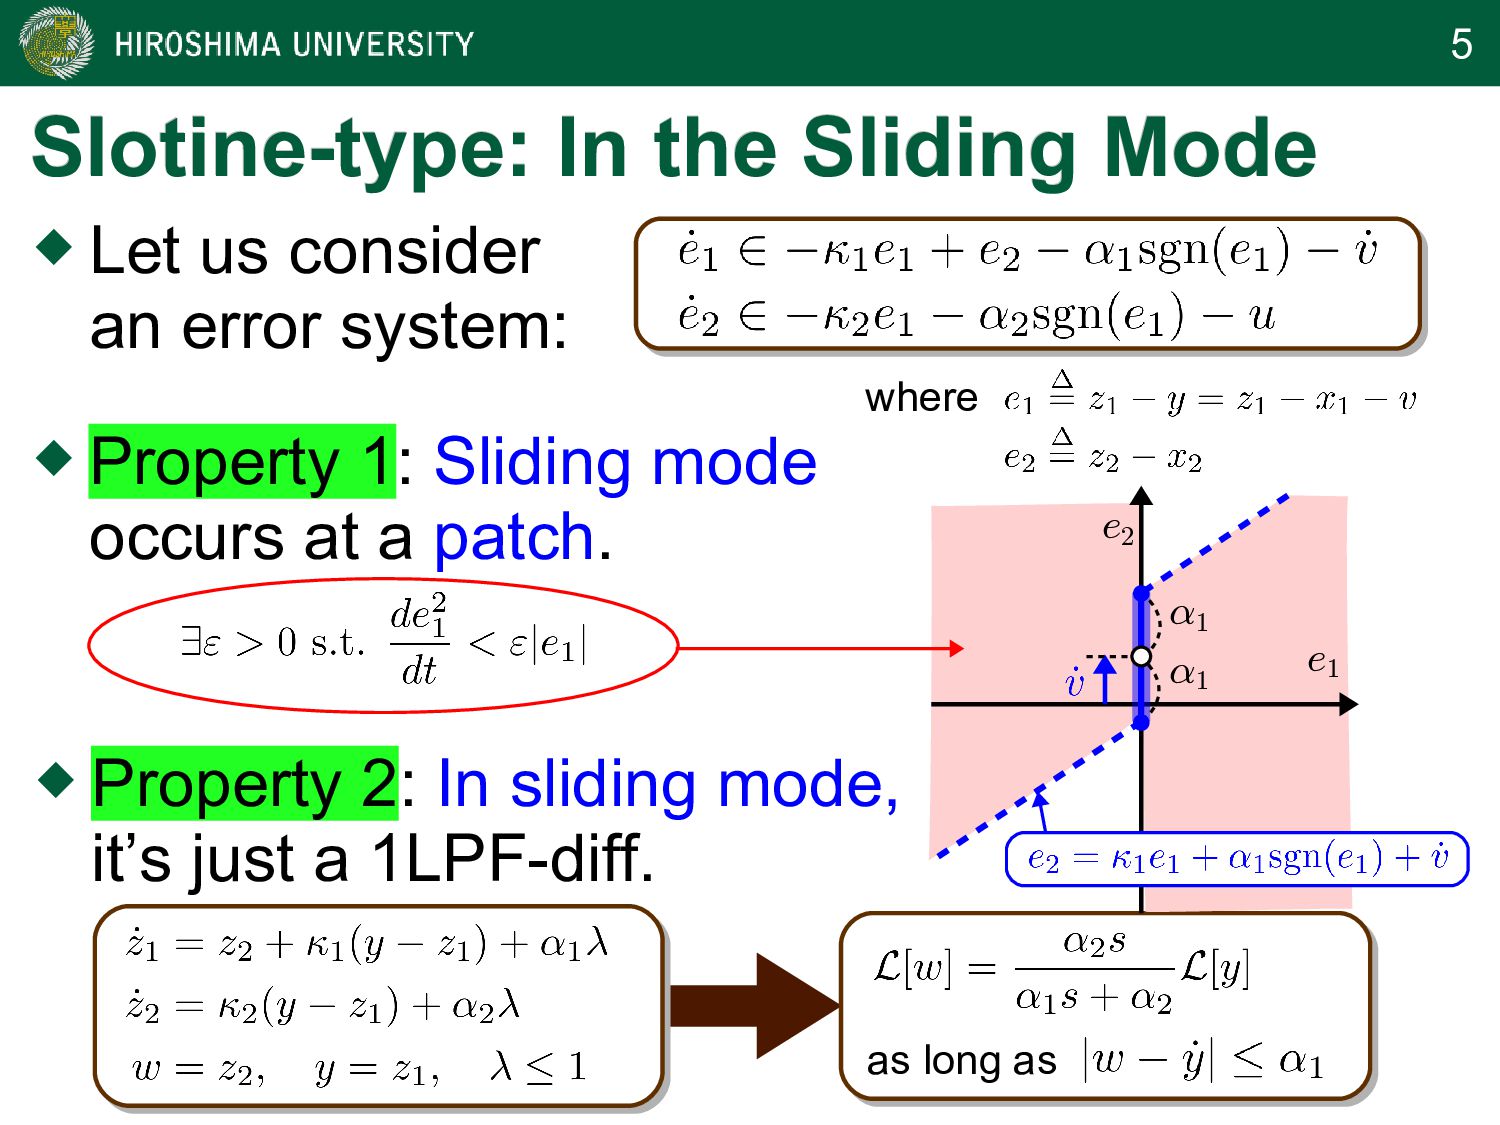
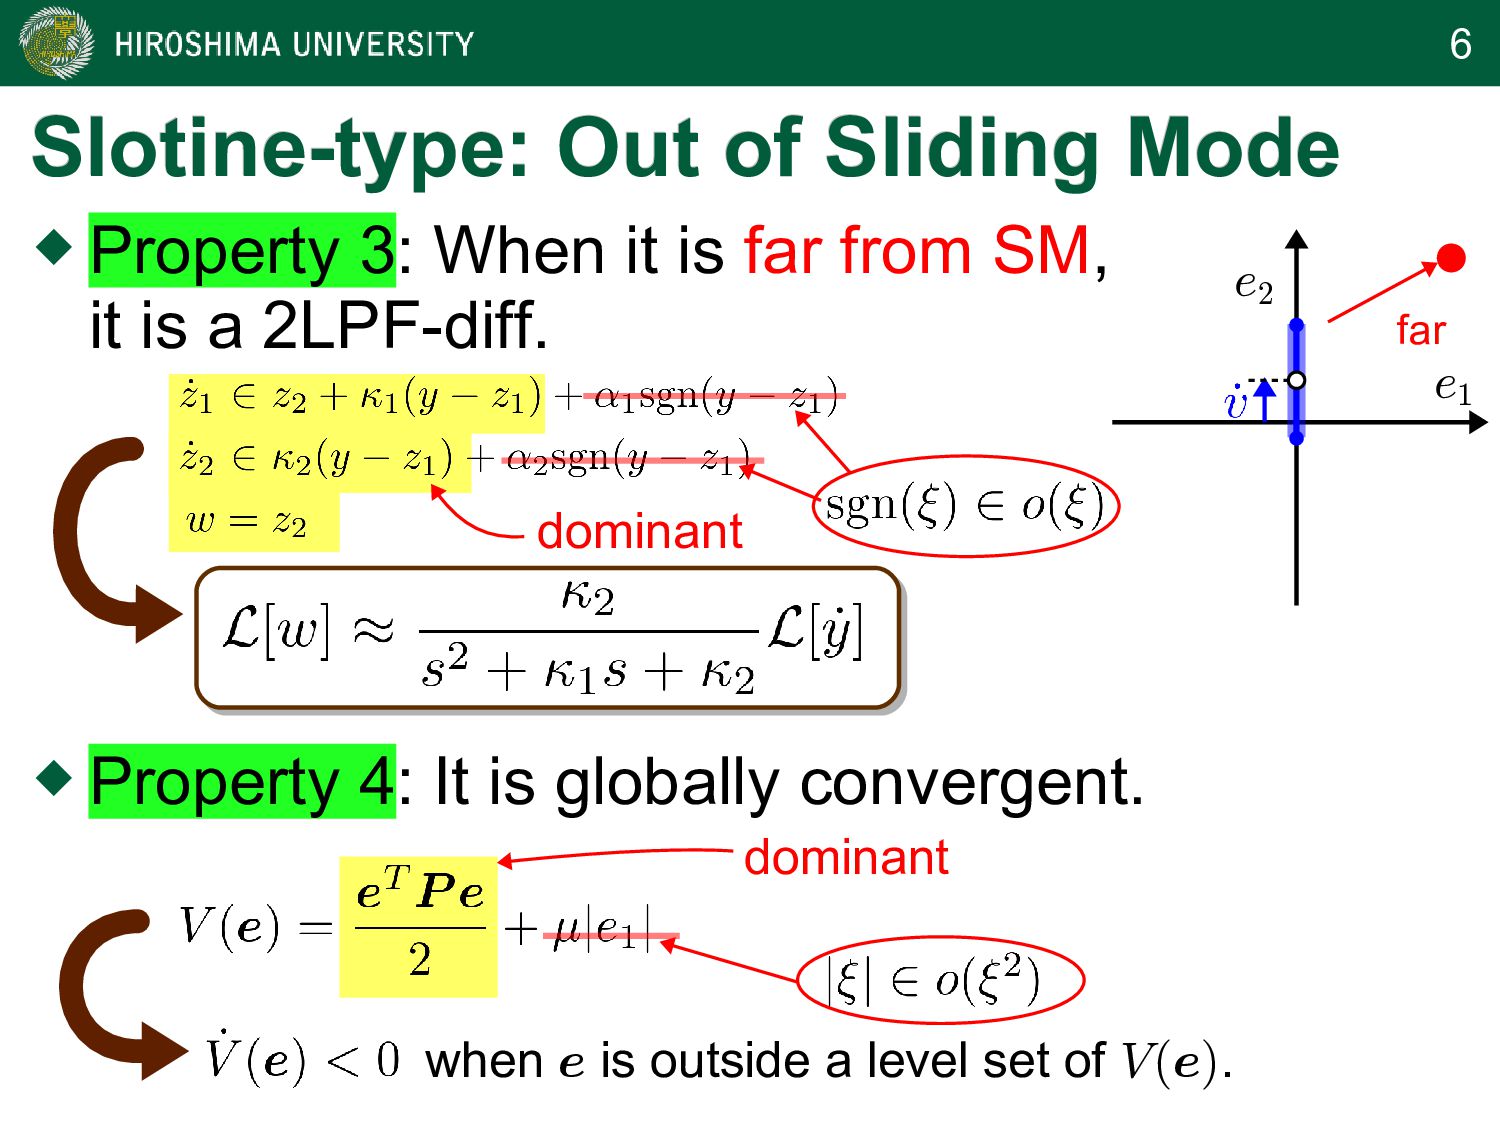
4 Slotine-type Sliding Mode Observer Slotine-type Sliding Mode Observer [Slotine
et al. 1987, ASME-DSMC] It realizes a “morphing” between 1LPF-diff and 2LPF-diff. In the sliding mode Out of the sliding mode 1LPF-diff 2LPF-diff Let us take a closer look at it. -
5 Slotine-type: In the Sliding Mode Slotine-type: In the Sliding
Mode as long as e1 e2 ®1 ®1 Let us consider an error system: Property 2: In sliding mode, it’s just a 1LPF-diff. Property 1: Sliding mode occurs at a patch. where -
6 Slotine-type: Out of Sliding Mode Slotine-type: Out of Sliding
Mode Property 3: When it is far from SM, it is a 2LPF-diff. Property 4: It is globally convergent. dominant e1 e2 far when e is outside a level set of V(e). dominant -
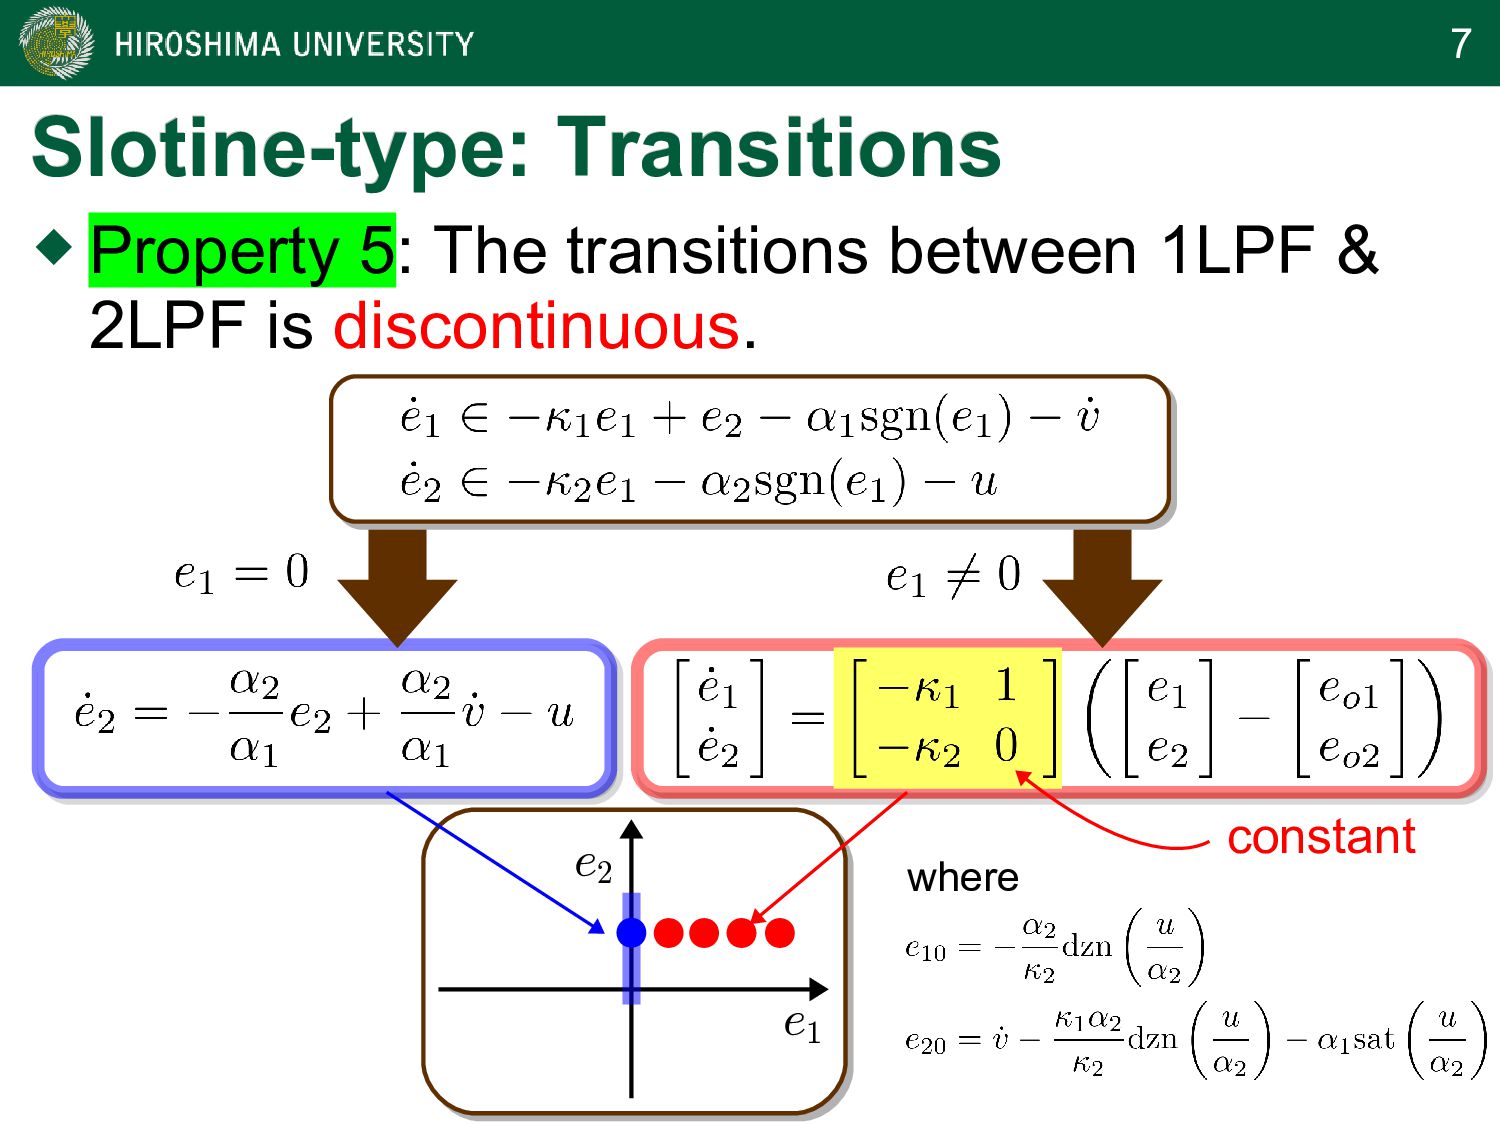
7 where Slotine-type: Transitions Slotine-type: Transitions Property 5: The
transitions between 1LPF & 2LPF is discontinuous. e1 e2 constant -
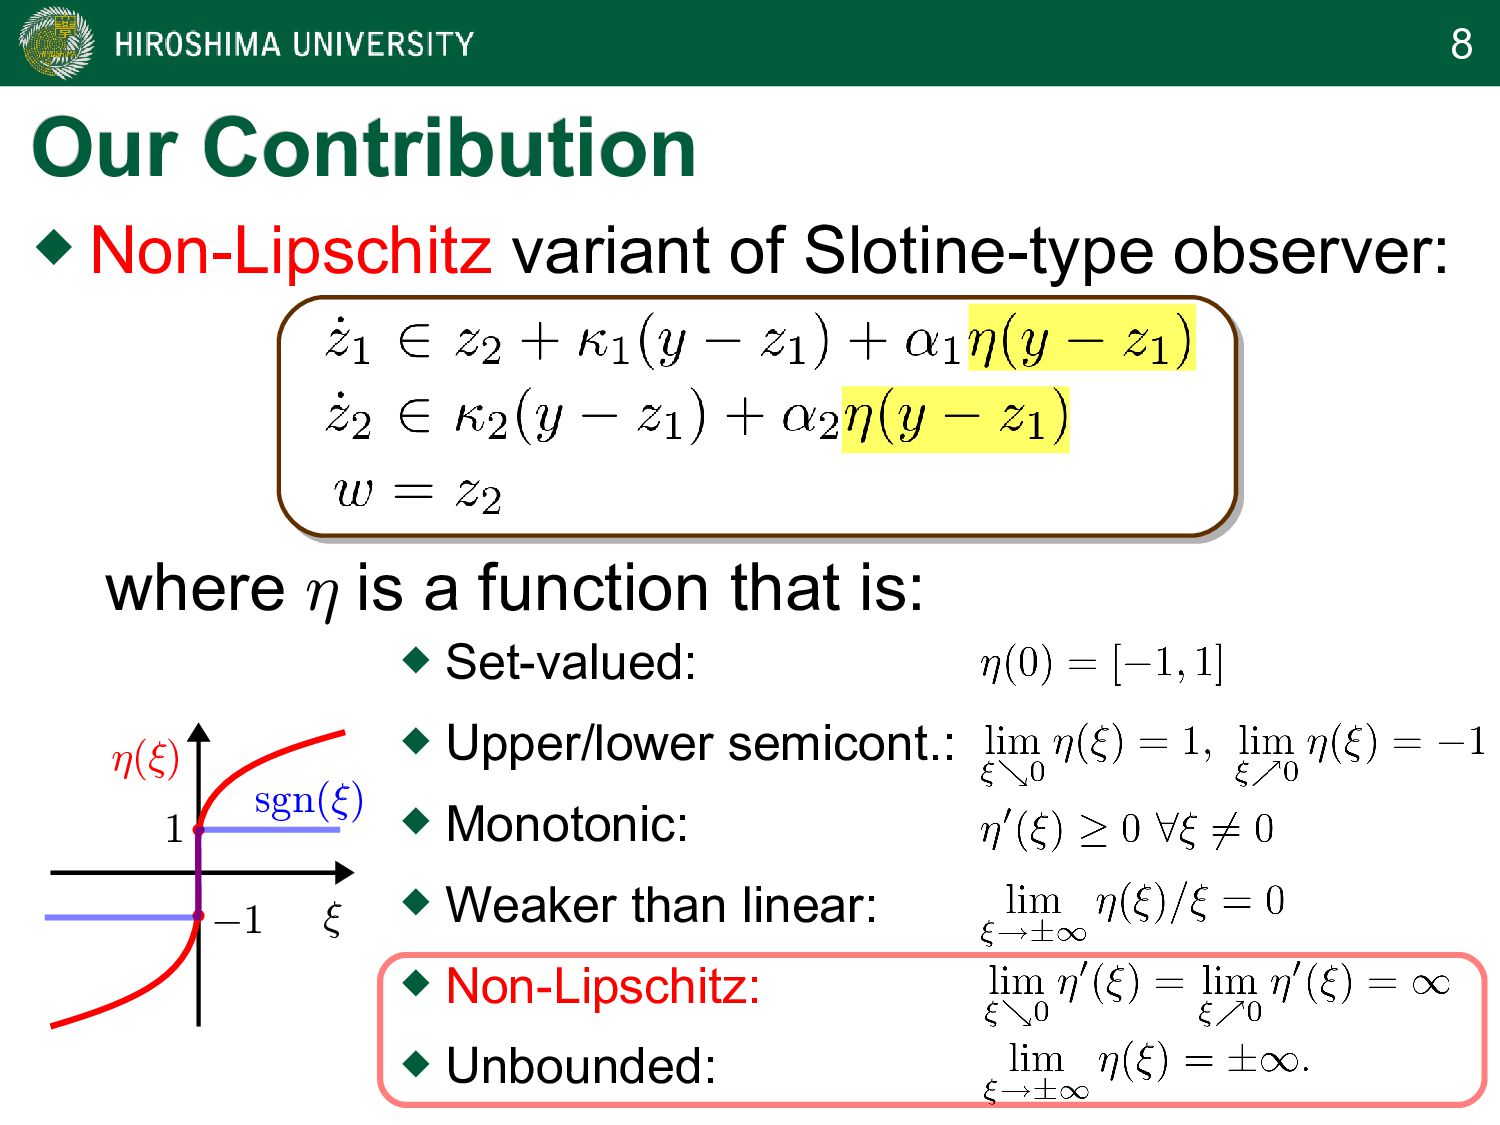
8 Set-valued: Upper/lower semicont.: Monotonic: Weaker
than linear: Non-Lipschitz: Unbounded: Our Contribution Our Contribution Non-Lipschitz variant of Slotine-type observer: » ´(») 1 ¡1 sgn(») where ´ is a function that is: -
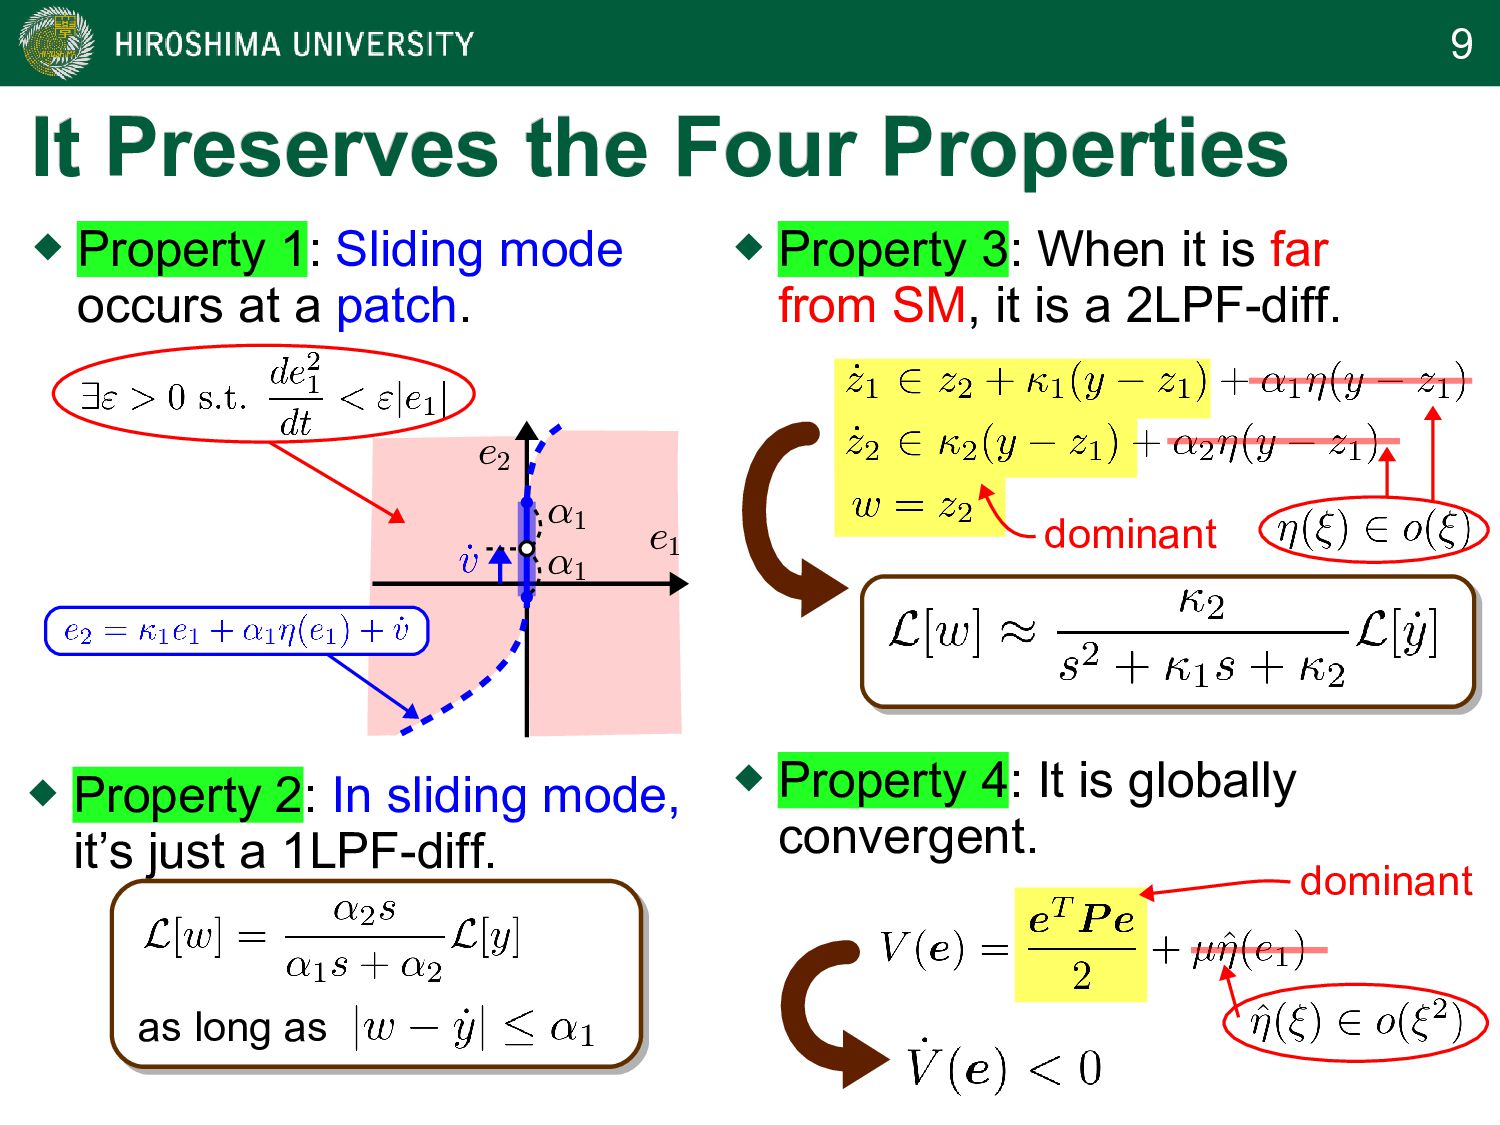
9 e1 e2 ®1 ®1 It Preserves the Four Properties
It Preserves the Four Properties as long as Property 2: In sliding mode, it’s just a 1LPF-diff. Property 1: Sliding mode occurs at a patch. Property 3: When it is far from SM, it is a 2LPF-diff. Property 4: It is globally convergent. dominant dominant -
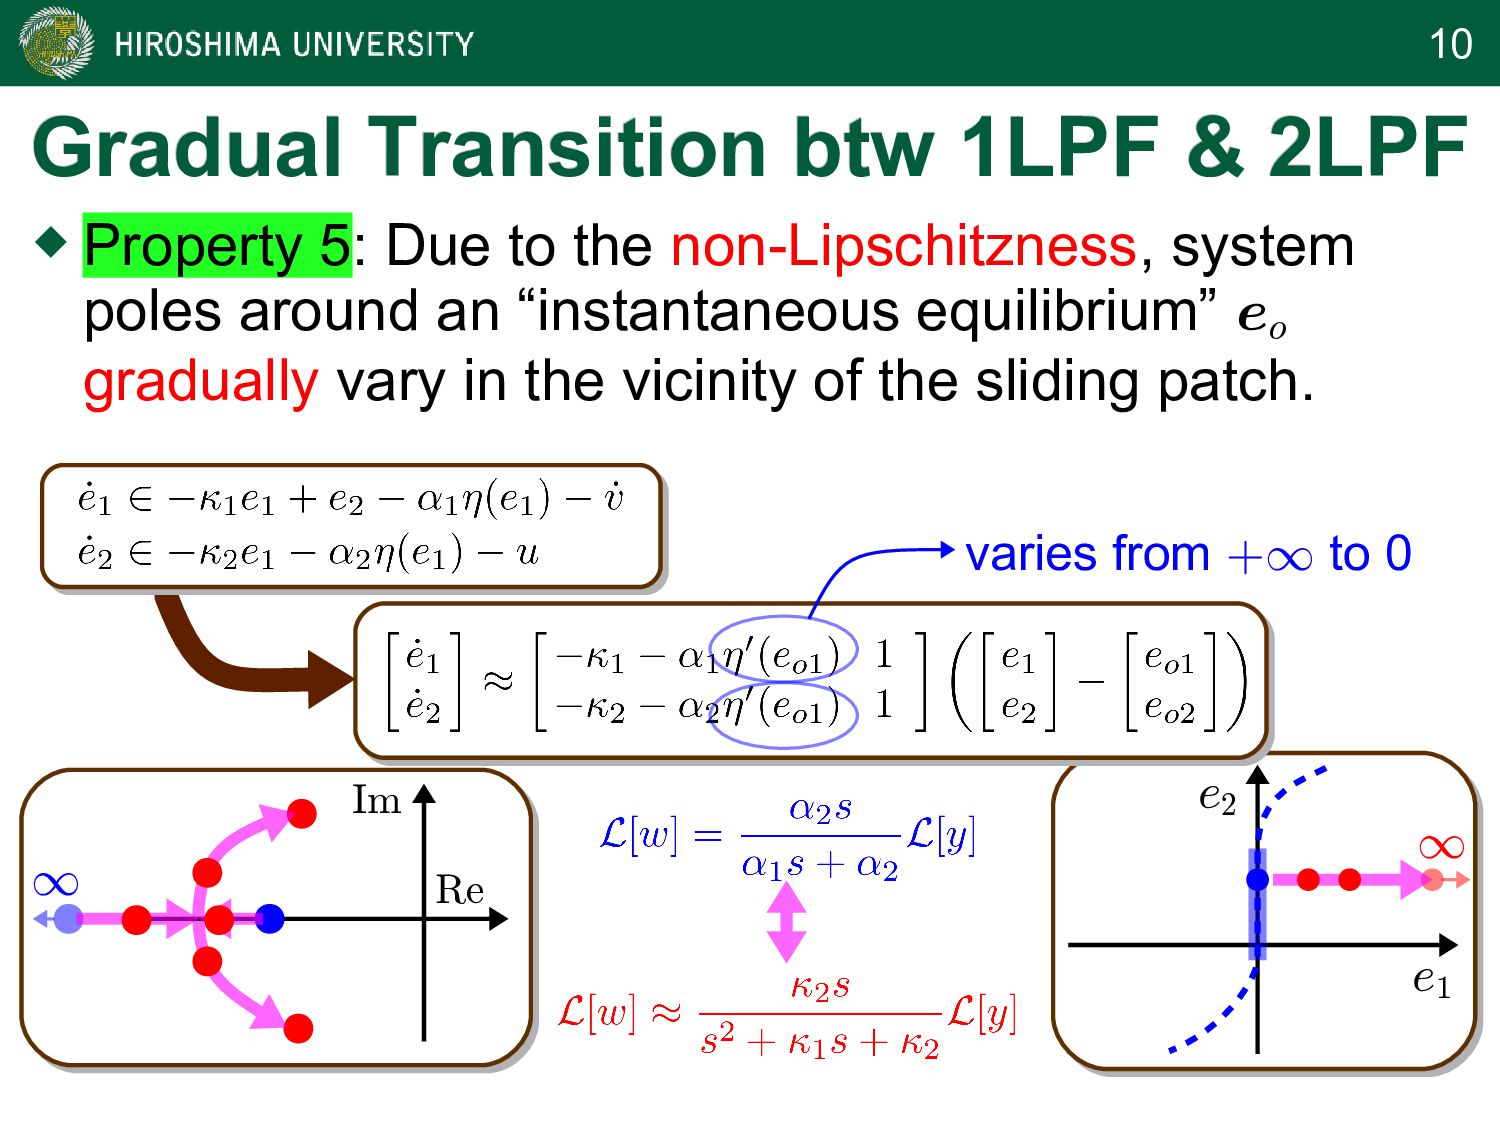
10 e1 e2 1 Gradual Transition btw 1LPF & 2LPF
Gradual Transition btw 1LPF & 2LPF Property 5: Due to the non-Lipschitzness, system poles around an “instantaneous equilibrium” eo gradually vary in the vicinity of the sliding patch. varies from +1 to 0 Re Im 1 -
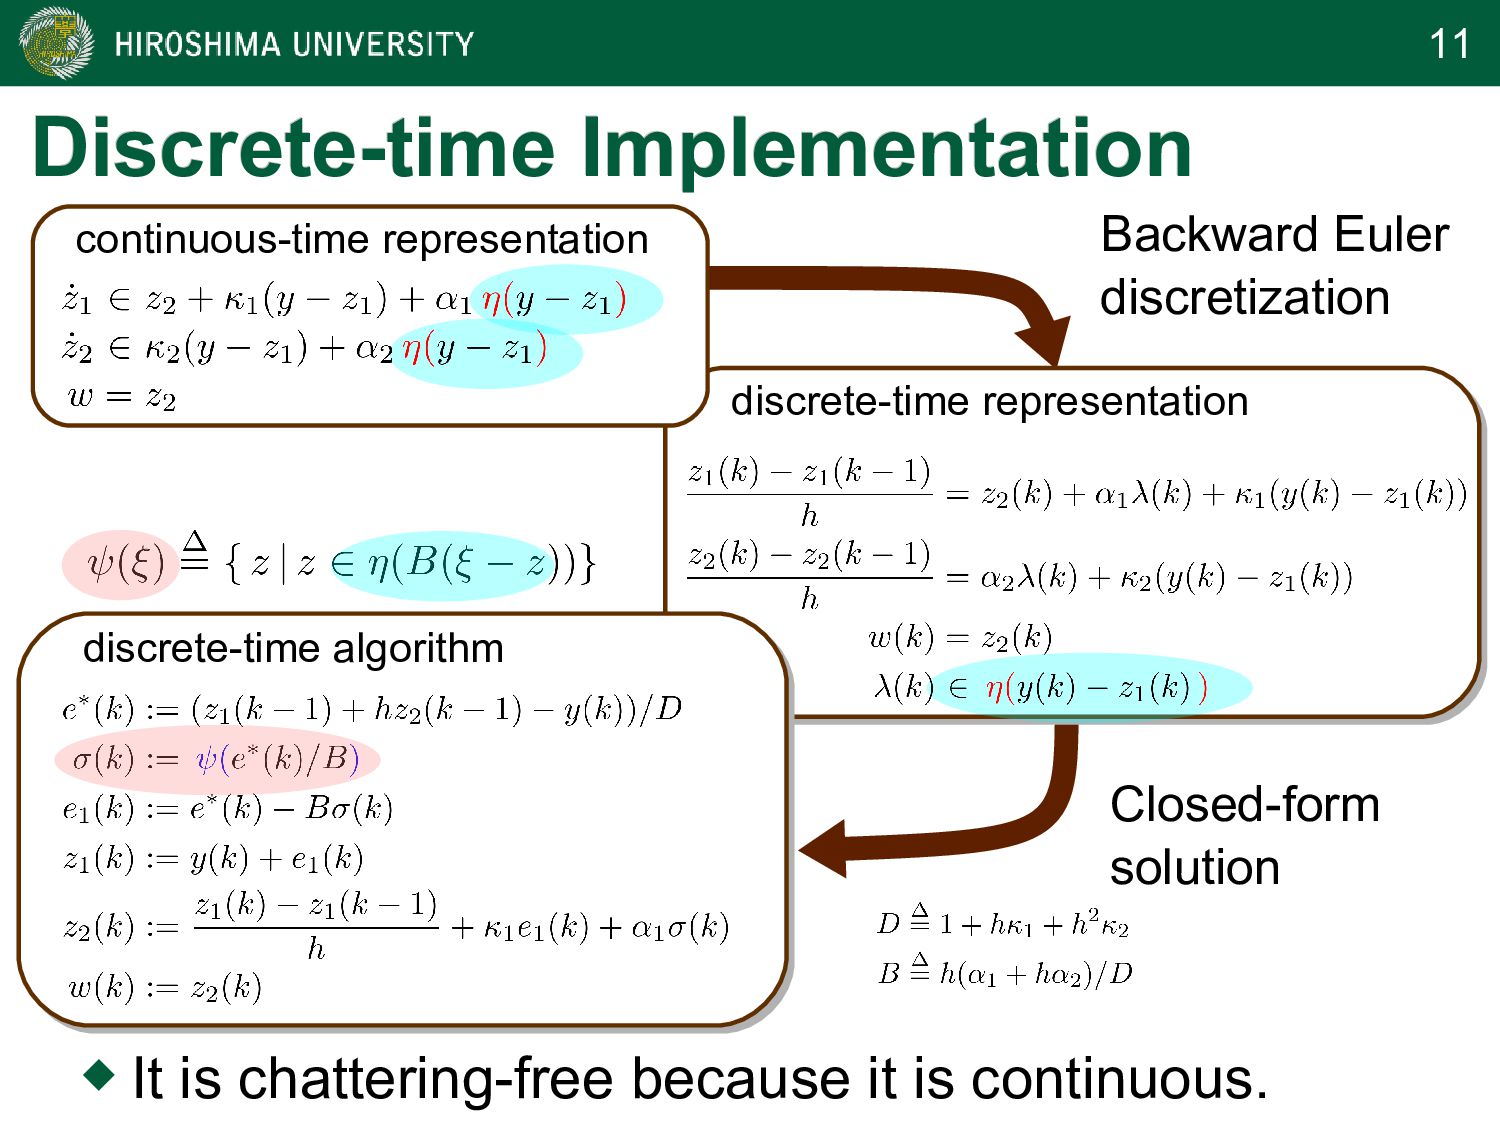
11 Discrete-time Implementation Discrete-time Implementation Backward Euler discretization discrete-time representation
continuous-time representation discrete-time algorithm Closed-form solution It is chattering-free because it is continuous. -
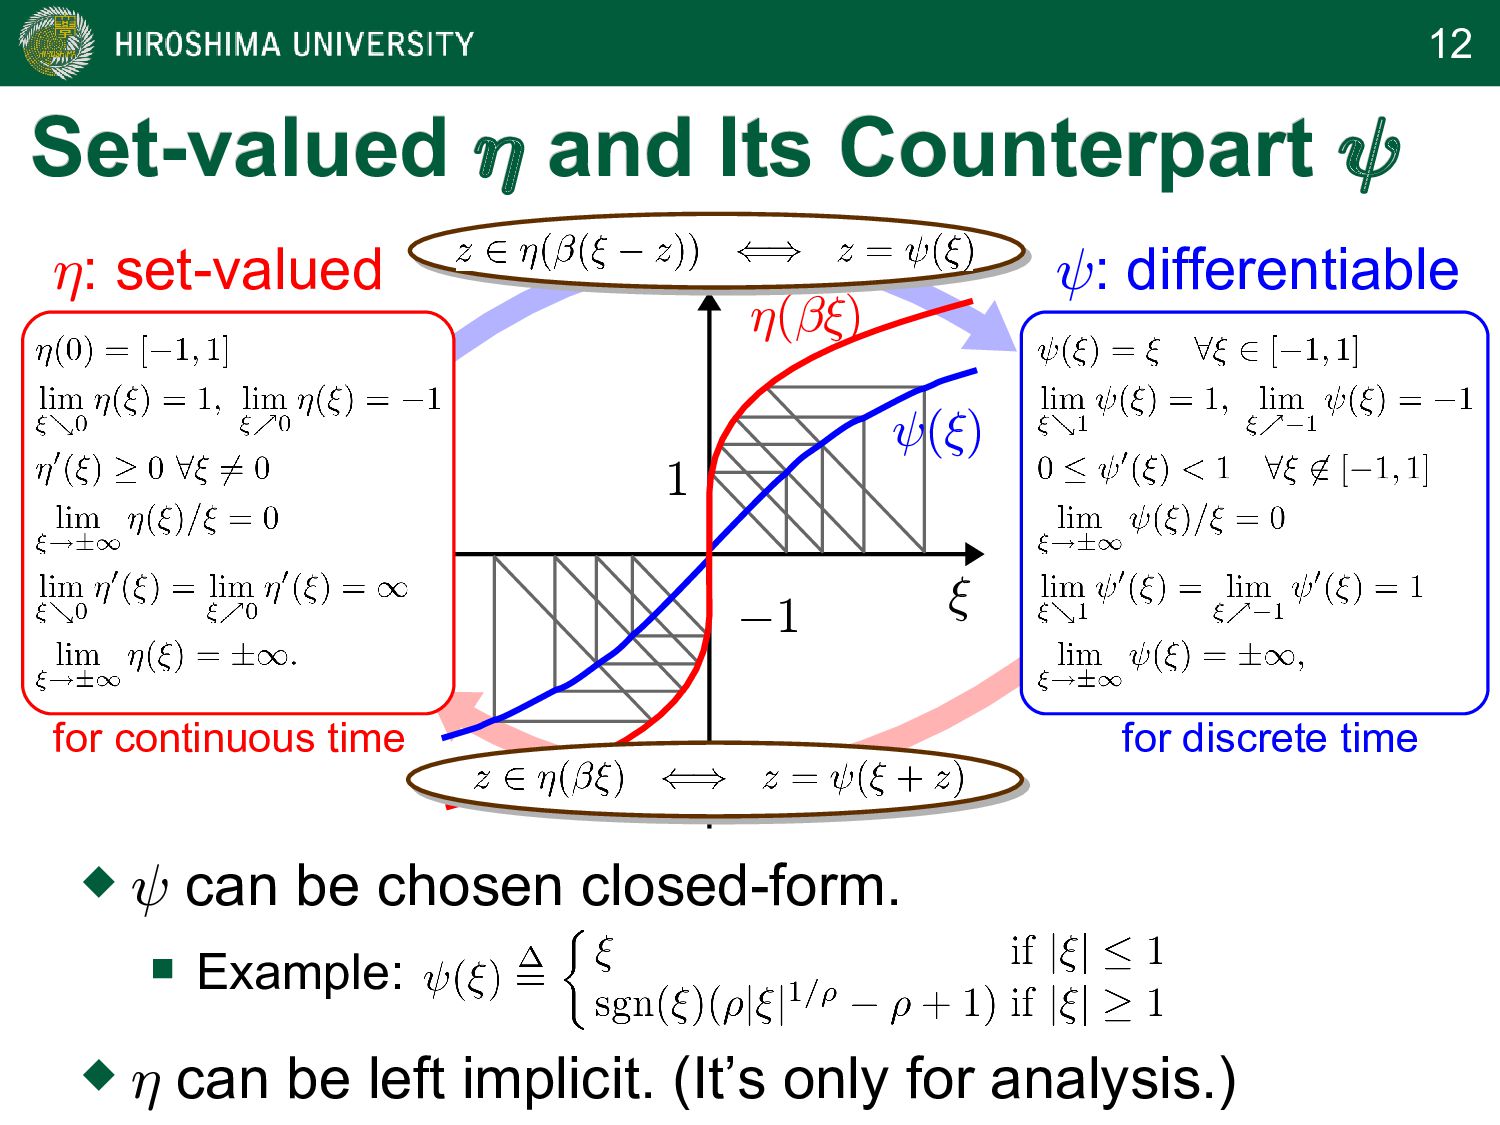
12 Set-valued Set-valued ´ ´ and Its Counterpart and Its
Counterpart à à à can be chosen closed-form. Example: ´ can be left implicit. (It’s only for analysis.) » 1 ¡1 Ã(») ´(¯») Ã: differentiable ´: set-valued for continuous time for discrete time -
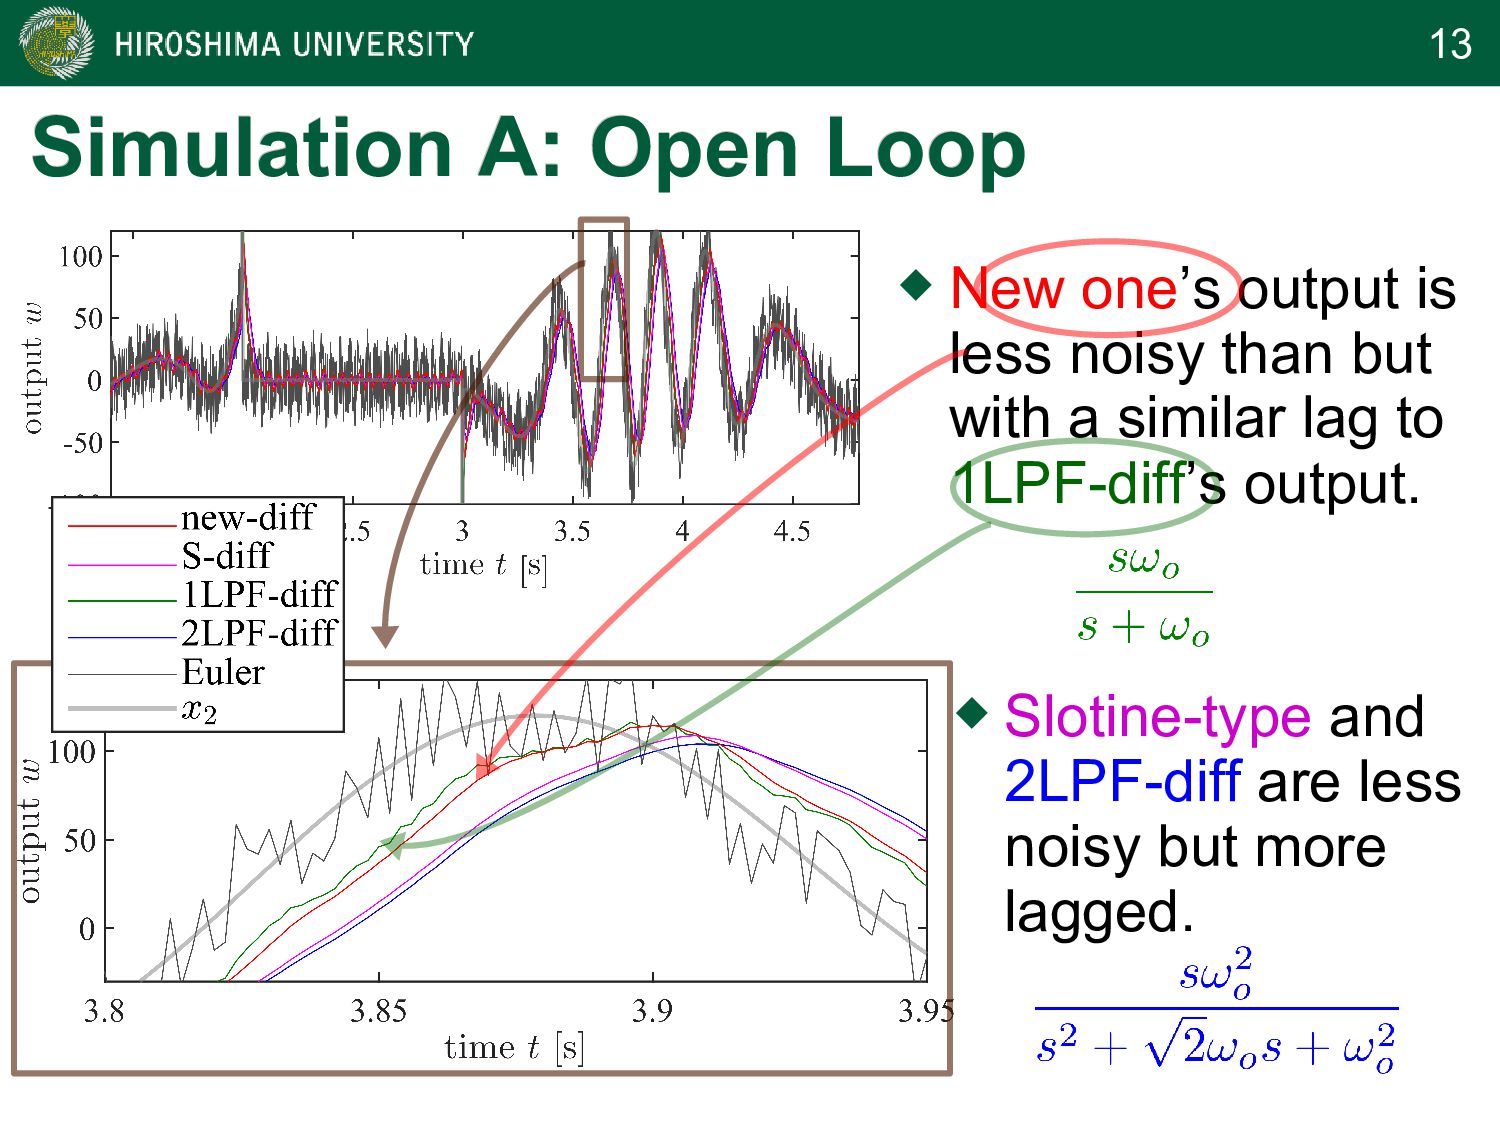
13 Simulation A: Open Loop Simulation A: Open Loop
New one’s output is less noisy than but with a similar lag to 1LPF-diff’s output. Slotine-type and 2LPF-diff are less noisy but more lagged. -
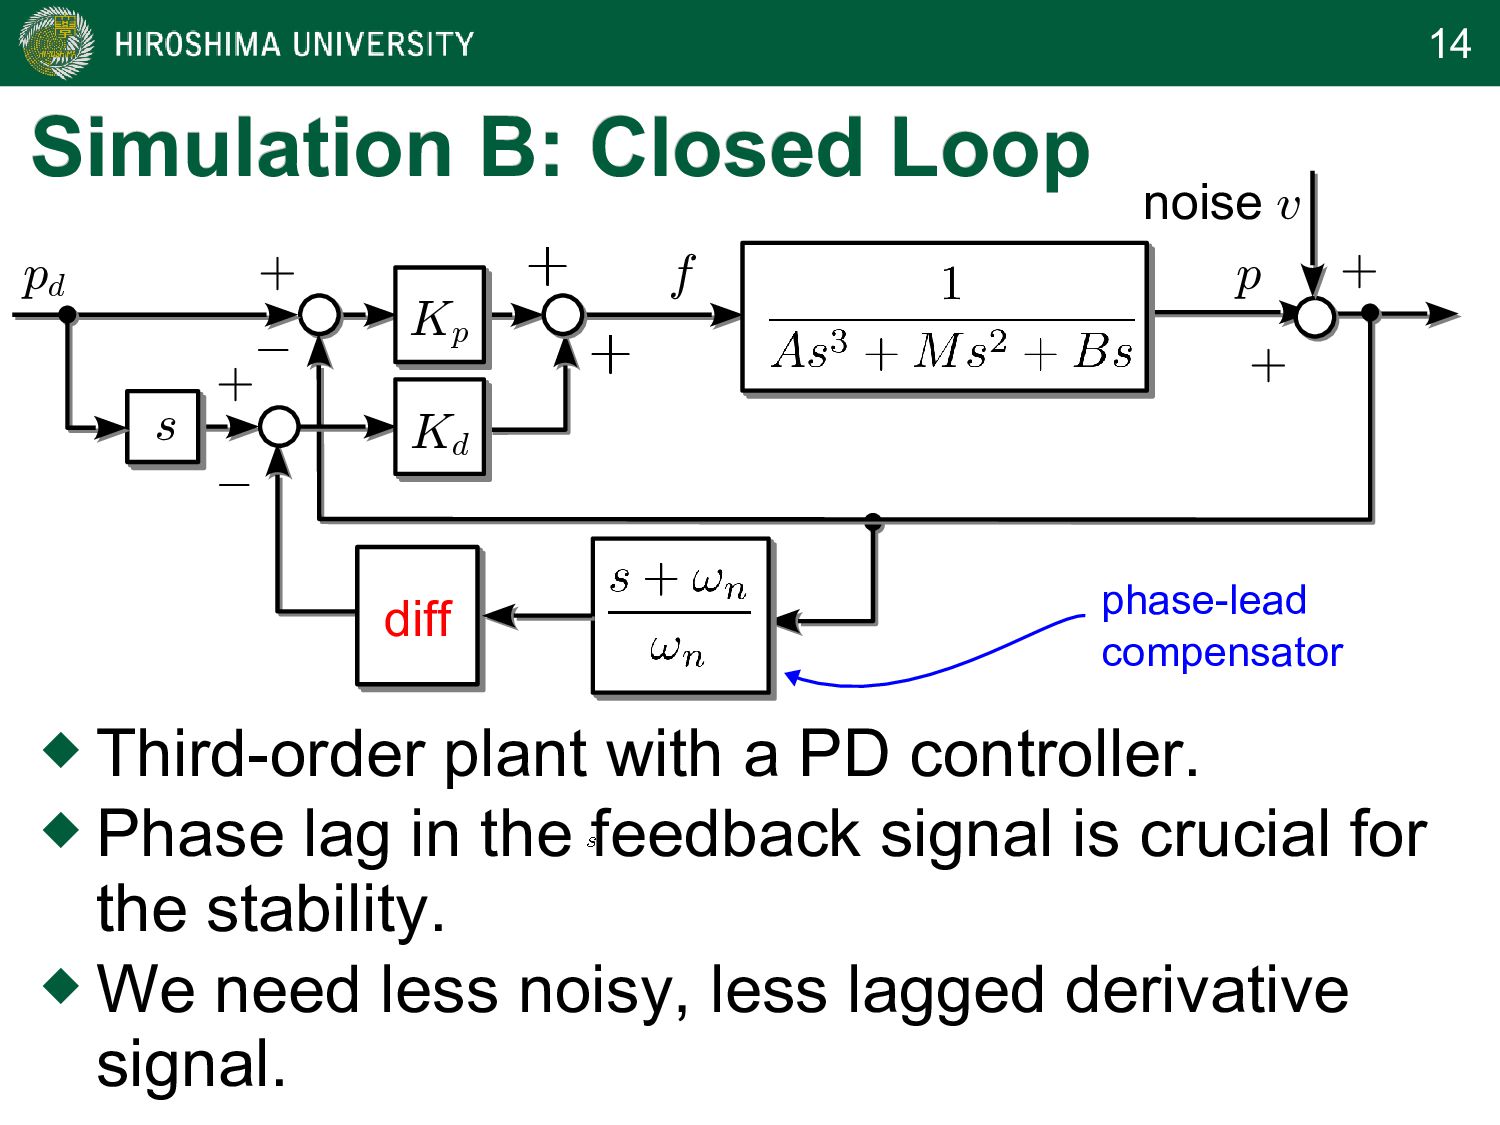
14 Simulation B: Closed Loop Simulation B: Closed Loop
Third-order plant with a PD controller. Phase lag in the feedback signal is crucial for the stability. We need less noisy, less lagged derivative signal. diff diff Kd Kp f s pd p ¡ ¡ + + + + phase-lead compensator noise v -
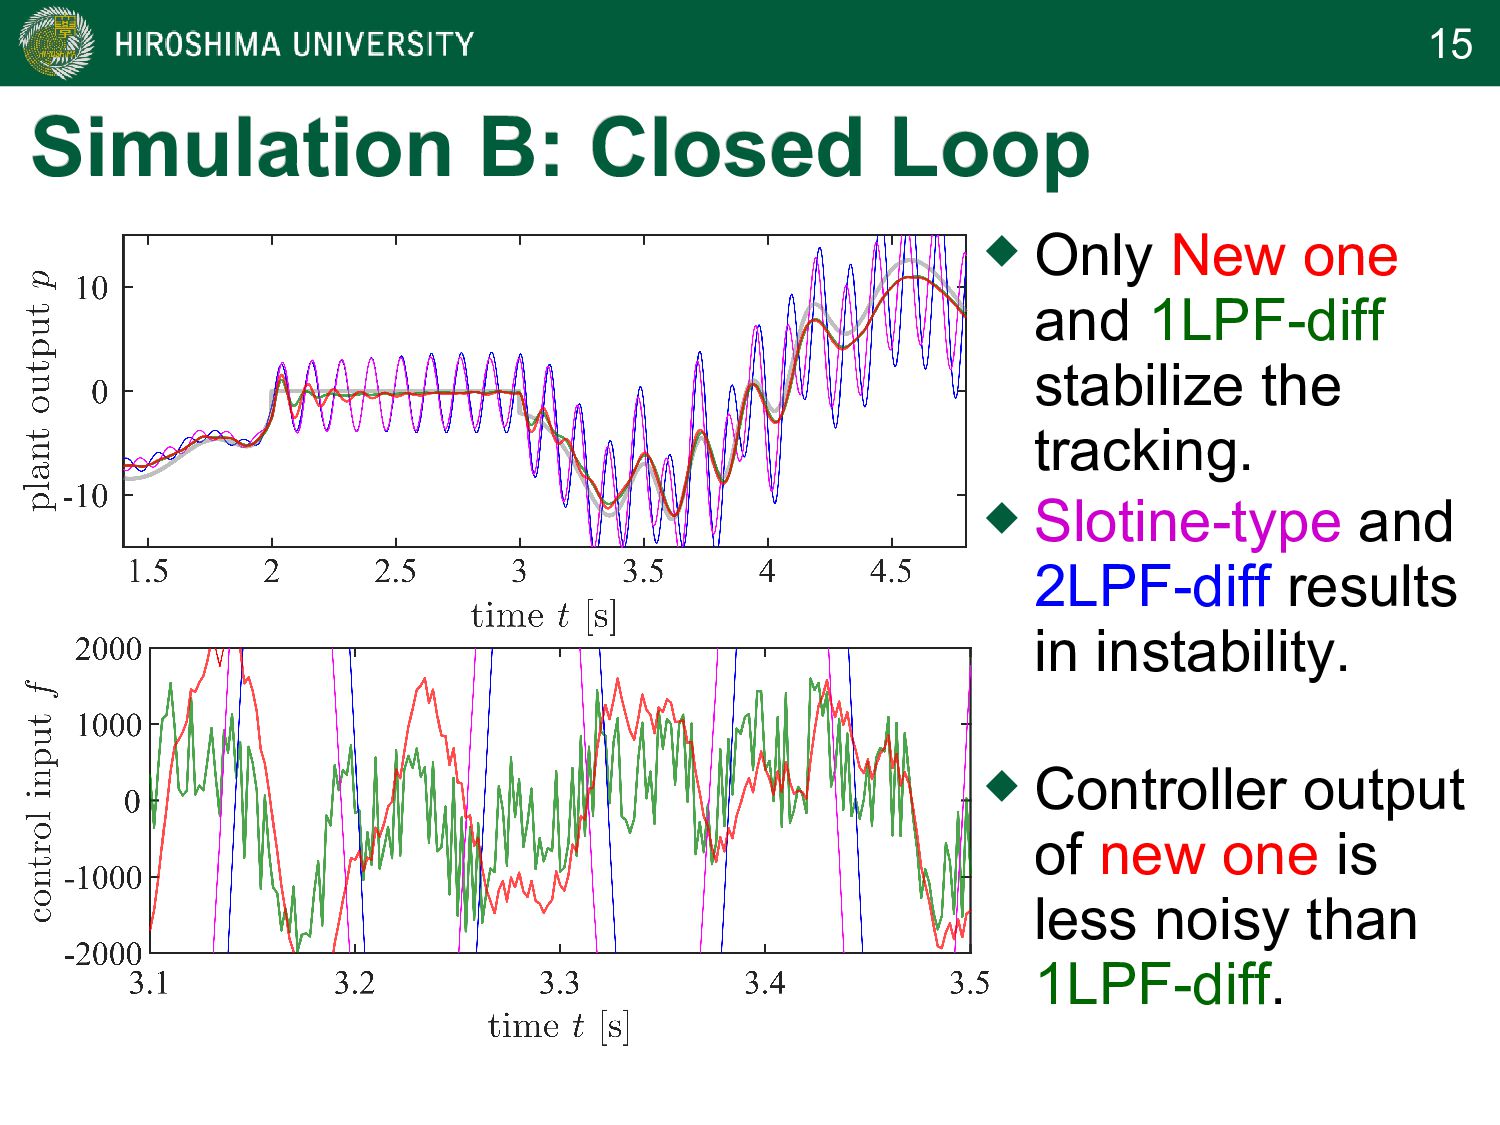
15 Simulation B: Closed Loop Simulation B: Closed Loop
Only New one and 1LPF-diff stabilize the tracking. Slotine-type and 2LPF-diff results in instability. Controller output of new one is less noisy than 1LPF-diff. -
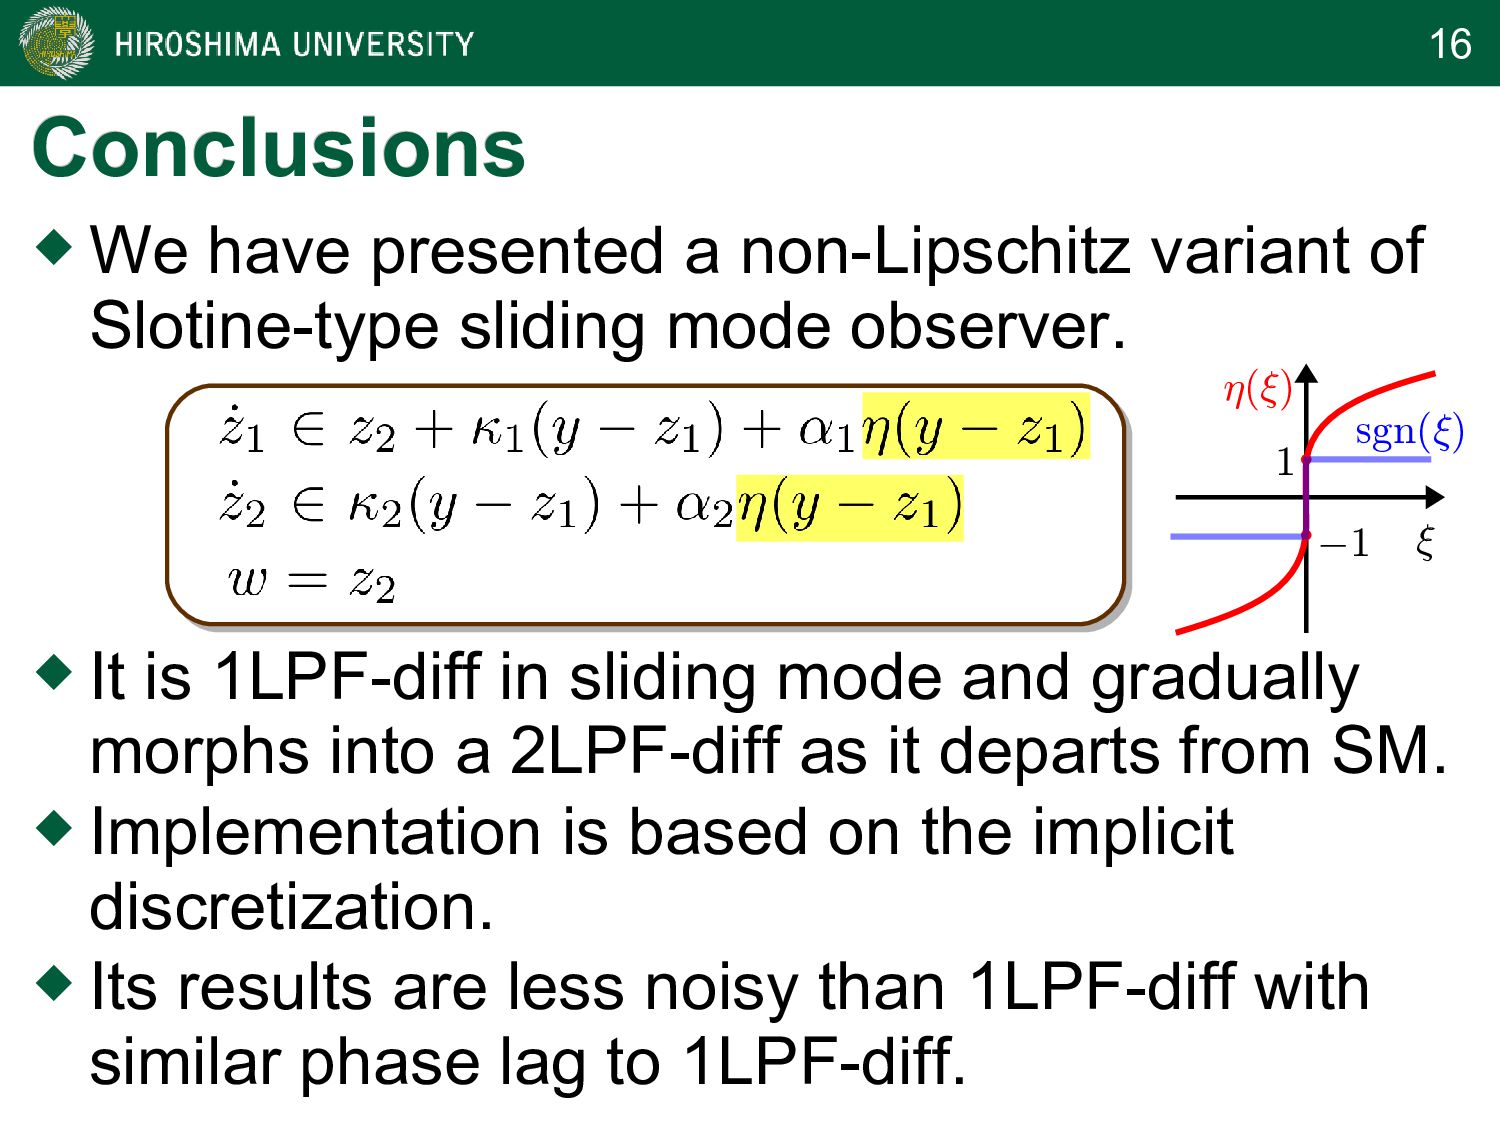
16 Conclusions Conclusions We have presented a non-Lipschitz variant
of Slotine-type sliding mode observer. It is 1LPF-diff in sliding mode and gradually morphs into a 2LPF-diff as it departs from SM. Implementation is based on the implicit discretization. Its results are less noisy than 1LPF-diff with similar phase lag to 1LPF-diff. » ´(») 1 ¡1 sgn(»)