Share
Embed
Golang Meetup Prague - GOBOT
Talk was about using GoCV and Gobot with Drone DJ Tello.
Examples from talk - https://github.com/abtris/gobot-examples
Ladislav Prskavec
September 13, 2018
Transcript
27 slides
-
Who am I? 4 Ladislav Prskavec (@abtris) 4 Developer &
SRE in Oracle Apiary 4 Ruby & Node.js & Go 4 Follow Golang meetup on twitter @GoMeetupPrague -
Why you should use Go for computer vision 4 Concurrency
4 Portability 4 Performance -
Frameworks 4 GoCV - wrap up around OpenCV 4 Gobot
- framework for robots, drones, and the Internet of Things (IoT) -
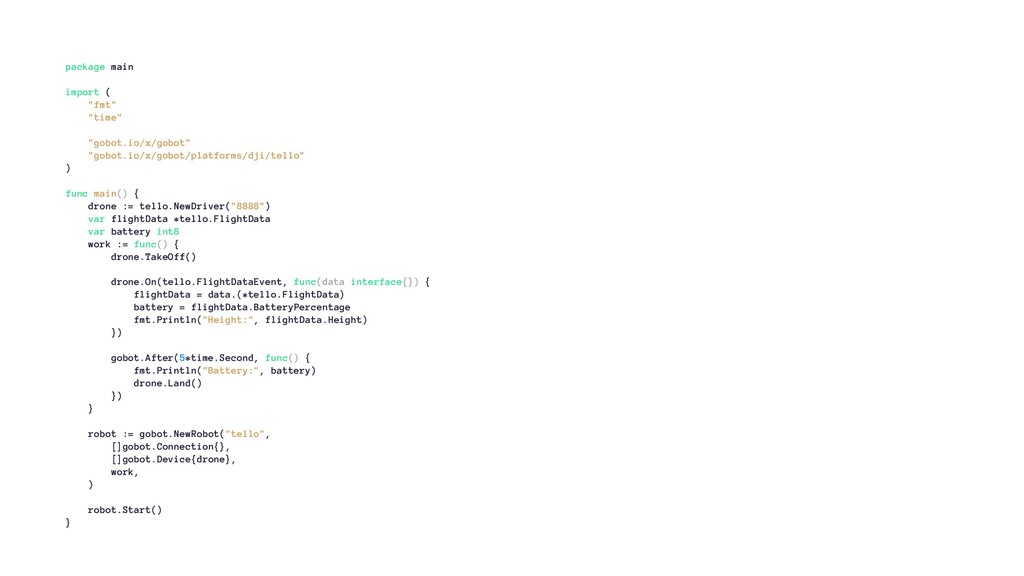
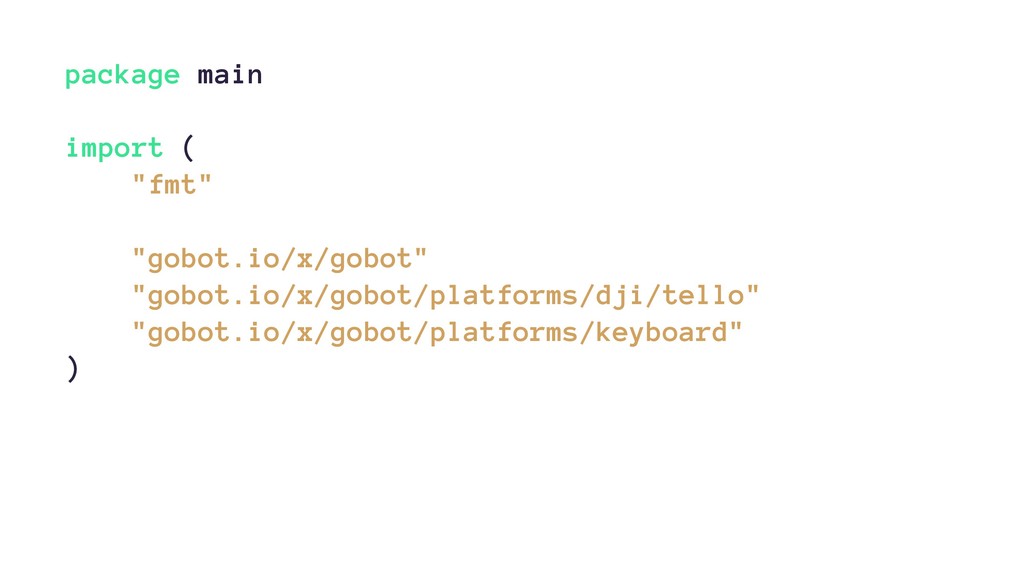
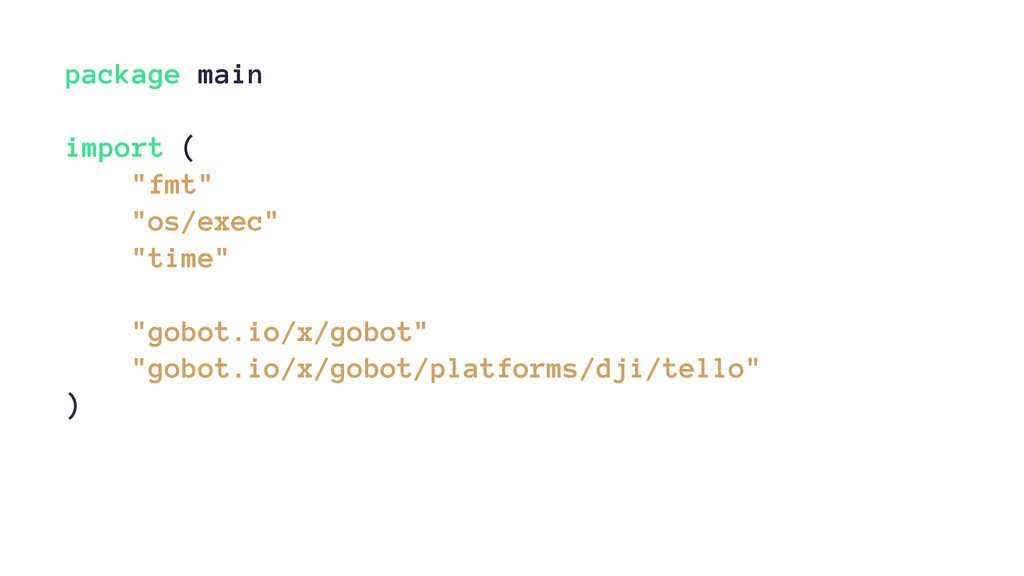
package main import ( "fmt" "time" "gobot.io/x/gobot" "gobot.io/x/gobot/platforms/dji/tello" ) func
main() { drone := tello.NewDriver("8888") var flightData *tello.FlightData var battery int8 work := func() { drone.TakeOff() drone.On(tello.FlightDataEvent, func(data interface{}) { flightData = data.(*tello.FlightData) battery = flightData.BatteryPercentage fmt.Println("Height:", flightData.Height) }) gobot.After(5*time.Second, func() { fmt.Println("Battery:", battery) drone.Land() }) } robot := gobot.NewRobot("tello", []gobot.Connection{}, []gobot.Device{drone}, work, ) robot.Start() } -
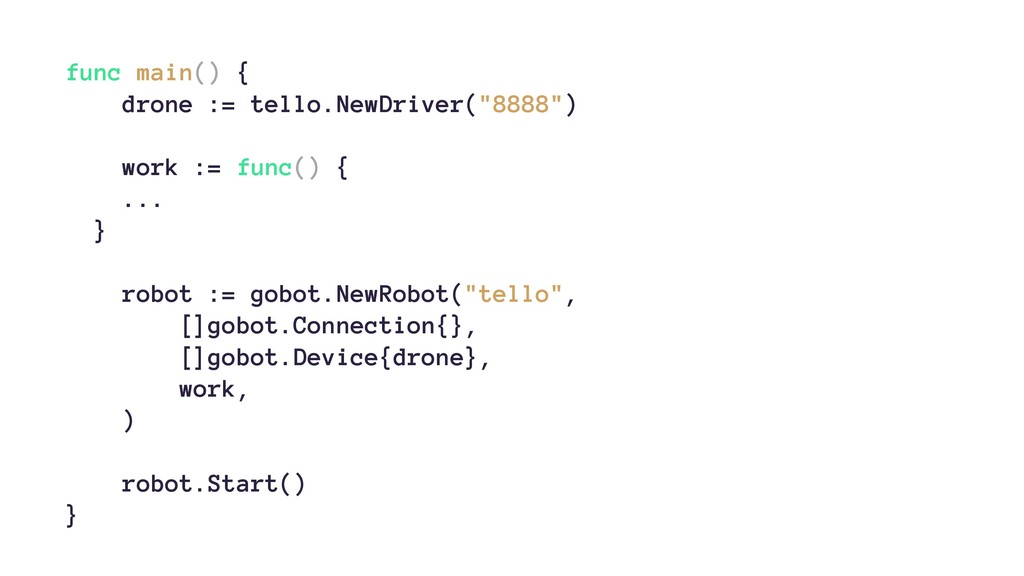
func main() { drone := tello.NewDriver("8888") work := func() {
... } robot := gobot.NewRobot("tello", []gobot.Connection{}, []gobot.Device{drone}, work, ) robot.Start() } -
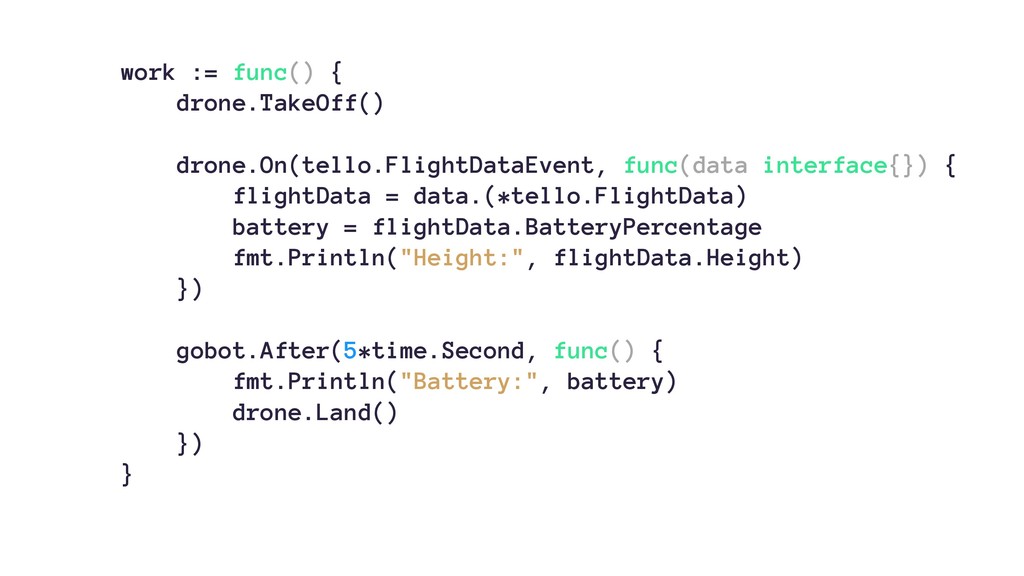
work := func() { drone.TakeOff() drone.On(tello.FlightDataEvent, func(data interface{}) { flightData
= data.(*tello.FlightData) battery = flightData.BatteryPercentage fmt.Println("Height:", flightData.Height) }) gobot.After(5*time.Second, func() { fmt.Println("Battery:", battery) drone.Land() }) } -
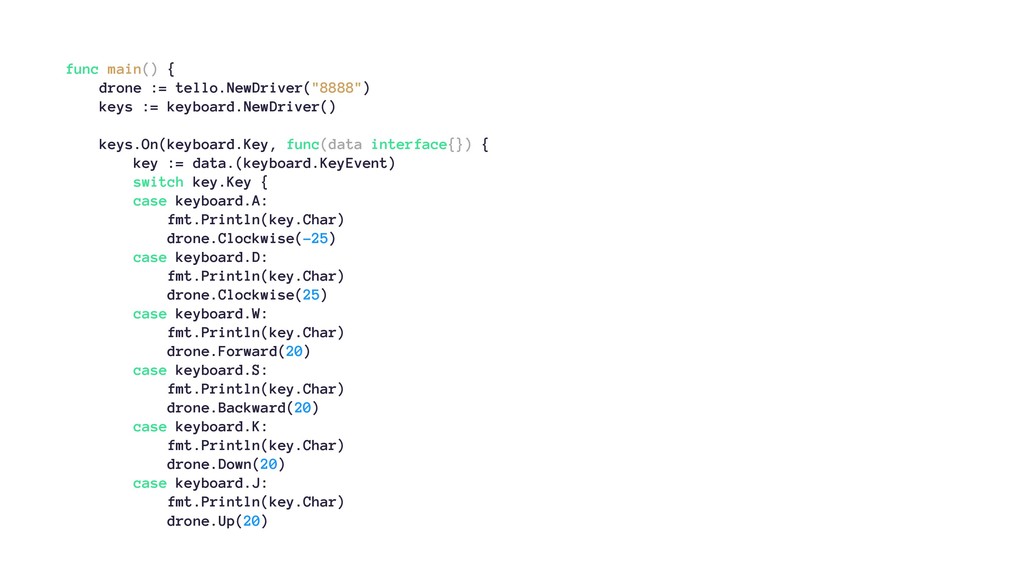
func main() { drone := tello.NewDriver("8888") keys := keyboard.NewDriver() keys.On(keyboard.Key,
func(data interface{}) { key := data.(keyboard.KeyEvent) switch key.Key { case keyboard.A: fmt.Println(key.Char) drone.Clockwise(-25) case keyboard.D: fmt.Println(key.Char) drone.Clockwise(25) case keyboard.W: fmt.Println(key.Char) drone.Forward(20) case keyboard.S: fmt.Println(key.Char) drone.Backward(20) case keyboard.K: fmt.Println(key.Char) drone.Down(20) case keyboard.J: fmt.Println(key.Char) drone.Up(20) -
case keyboard.Q: fmt.Println(key.Char) drone.Land() case keyboard.P: fmt.Println(key.Char) drone.TakeOff() case keyboard.ArrowUp:
fmt.Println(key.Char) drone.FrontFlip() case keyboard.ArrowDown: fmt.Println(key.Char) drone.BackFlip() case keyboard.ArrowLeft: fmt.Println(key.Char) drone.LeftFlip() case keyboard.ArrowRight: fmt.Println(key.Char) drone.RightFlip() case keyboard.Escape: resetDronePostion(drone) } }) -
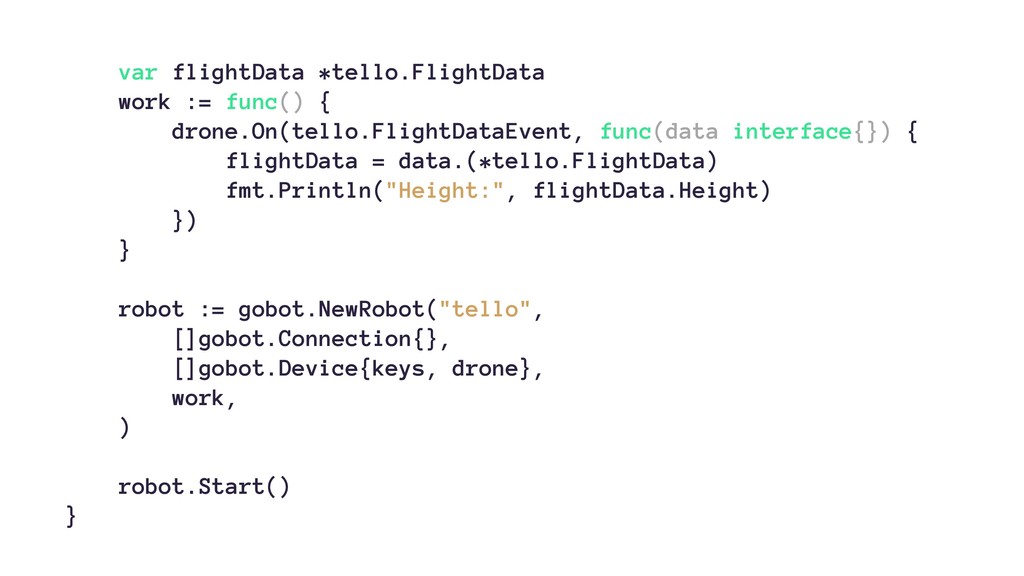
var flightData *tello.FlightData work := func() { drone.On(tello.FlightDataEvent, func(data interface{})
{ flightData = data.(*tello.FlightData) fmt.Println("Height:", flightData.Height) }) } robot := gobot.NewRobot("tello", []gobot.Connection{}, []gobot.Device{keys, drone}, work, ) robot.Start() } -
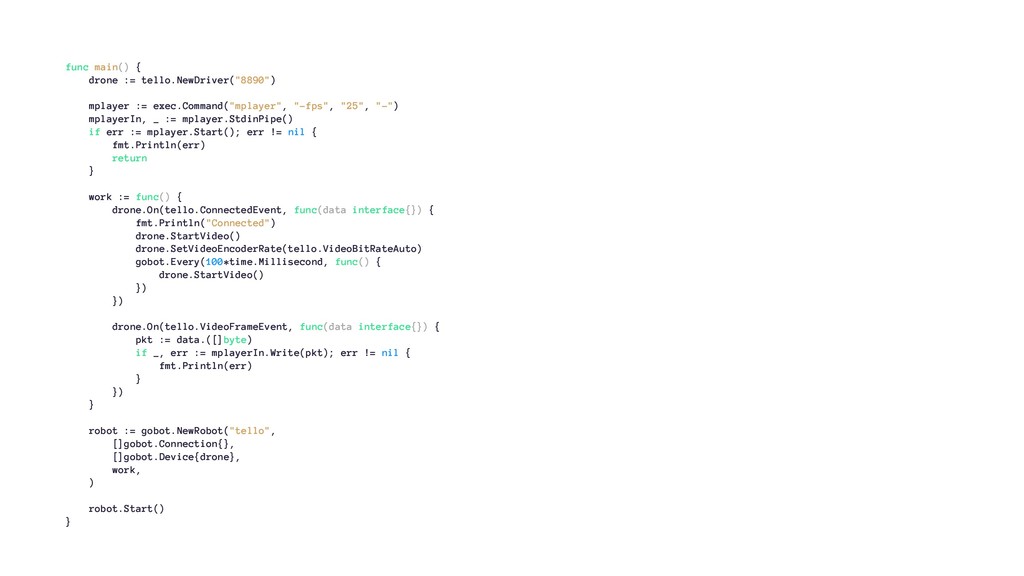
func main() { drone := tello.NewDriver("8890") mplayer := exec.Command("mplayer", "-fps",
"25", "-") mplayerIn, _ := mplayer.StdinPipe() if err := mplayer.Start(); err != nil { fmt.Println(err) return } work := func() { drone.On(tello.ConnectedEvent, func(data interface{}) { fmt.Println("Connected") drone.StartVideo() drone.SetVideoEncoderRate(tello.VideoBitRateAuto) gobot.Every(100*time.Millisecond, func() { drone.StartVideo() }) }) drone.On(tello.VideoFrameEvent, func(data interface{}) { pkt := data.([]byte) if _, err := mplayerIn.Write(pkt); err != nil { fmt.Println(err) } }) } robot := gobot.NewRobot("tello", []gobot.Connection{}, []gobot.Device{drone}, work, ) robot.Start() } -
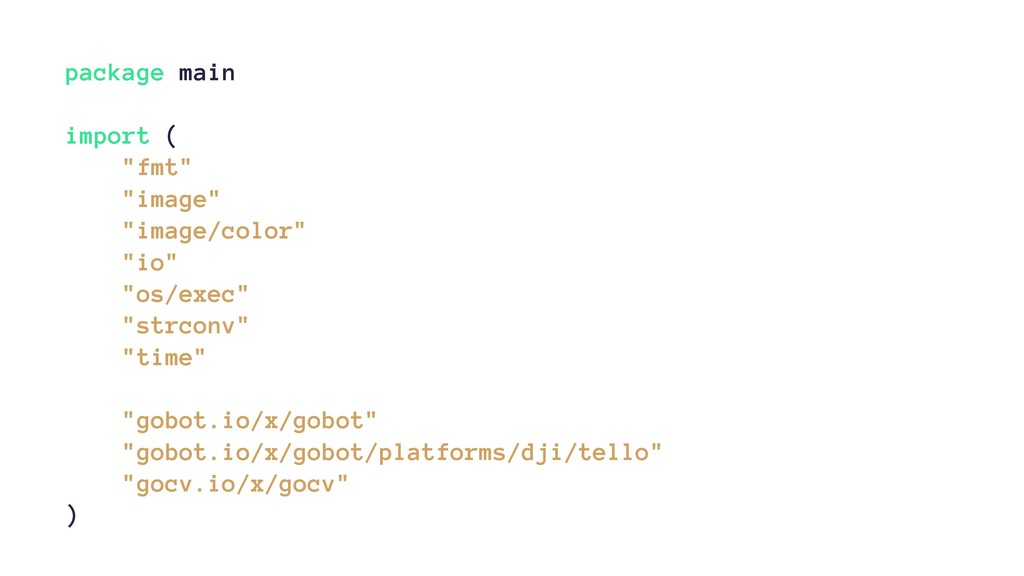
package main import ( "fmt" "image" "image/color" "io" "os/exec" "strconv"
"time" "gobot.io/x/gobot" "gobot.io/x/gobot/platforms/dji/tello" "gocv.io/x/gocv" ) -
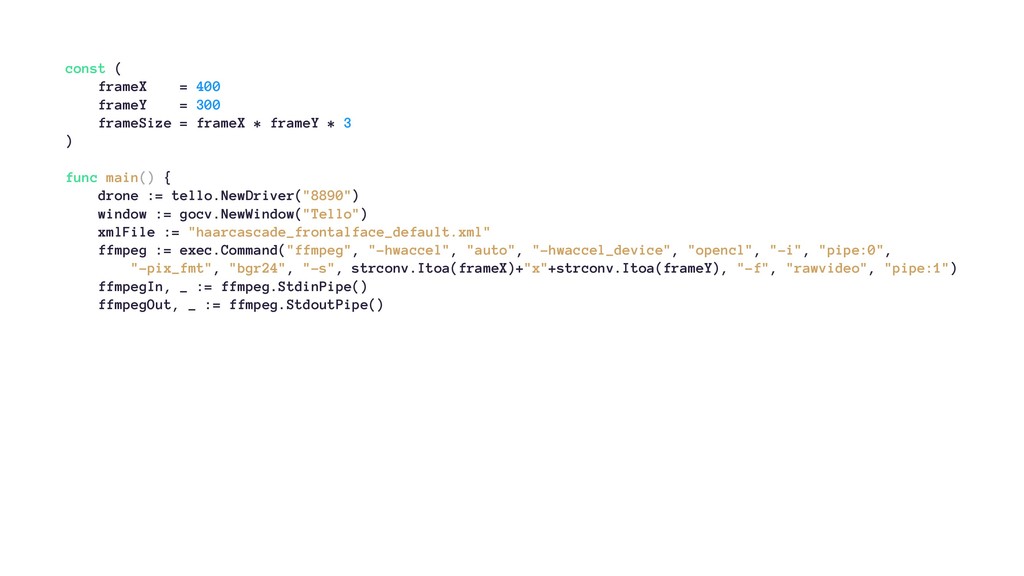
const ( frameX = 400 frameY = 300 frameSize =
frameX * frameY * 3 ) func main() { drone := tello.NewDriver("8890") window := gocv.NewWindow("Tello") xmlFile := "haarcascade_frontalface_default.xml" ffmpeg := exec.Command("ffmpeg", "-hwaccel", "auto", "-hwaccel_device", "opencl", "-i", "pipe:0", "-pix_fmt", "bgr24", "-s", strconv.Itoa(frameX)+"x"+strconv.Itoa(frameY), "-f", "rawvideo", "pipe:1") ffmpegIn, _ := ffmpeg.StdinPipe() ffmpegOut, _ := ffmpeg.StdoutPipe() -
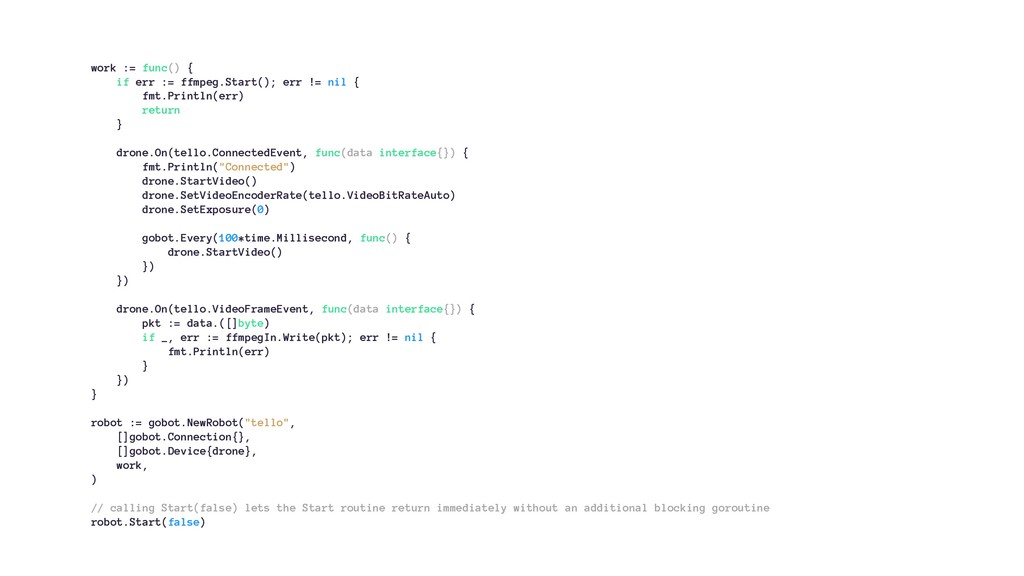
work := func() { if err := ffmpeg.Start(); err !=
nil { fmt.Println(err) return } drone.On(tello.ConnectedEvent, func(data interface{}) { fmt.Println("Connected") drone.StartVideo() drone.SetVideoEncoderRate(tello.VideoBitRateAuto) drone.SetExposure(0) gobot.Every(100*time.Millisecond, func() { drone.StartVideo() }) }) drone.On(tello.VideoFrameEvent, func(data interface{}) { pkt := data.([]byte) if _, err := ffmpegIn.Write(pkt); err != nil { fmt.Println(err) } }) } robot := gobot.NewRobot("tello", []gobot.Connection{}, []gobot.Device{drone}, work, ) // calling Start(false) lets the Start routine return immediately without an additional blocking goroutine robot.Start(false) -
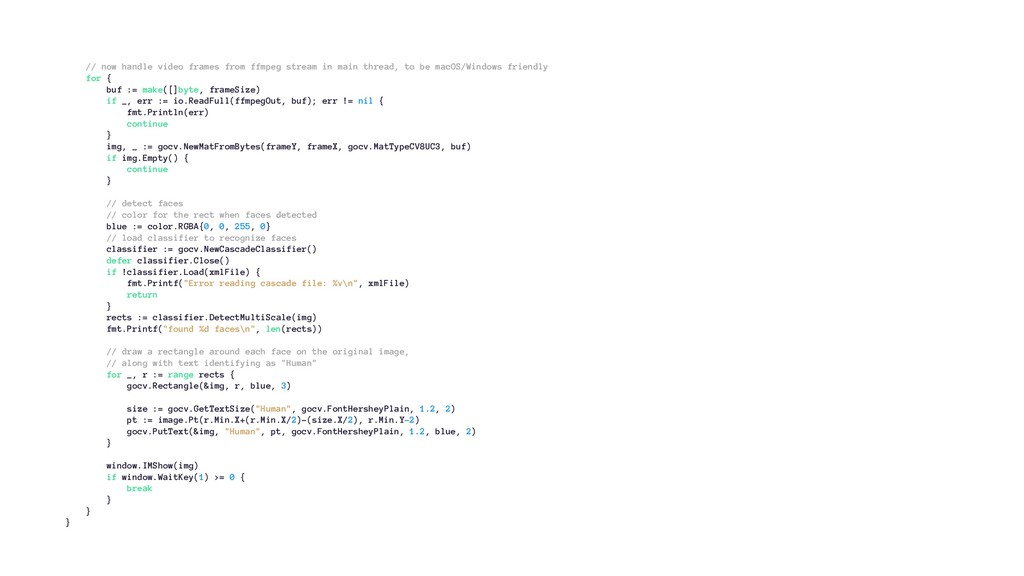
// now handle video frames from ffmpeg stream in main
thread, to be macOS/Windows friendly for { buf := make([]byte, frameSize) if _, err := io.ReadFull(ffmpegOut, buf); err != nil { fmt.Println(err) continue } img, _ := gocv.NewMatFromBytes(frameY, frameX, gocv.MatTypeCV8UC3, buf) if img.Empty() { continue } // detect faces // color for the rect when faces detected blue := color.RGBA{0, 0, 255, 0} // load classifier to recognize faces classifier := gocv.NewCascadeClassifier() defer classifier.Close() if !classifier.Load(xmlFile) { fmt.Printf("Error reading cascade file: %v\n", xmlFile) return } rects := classifier.DetectMultiScale(img) fmt.Printf("found %d faces\n", len(rects)) // draw a rectangle around each face on the original image, // along with text identifying as "Human" for _, r := range rects { gocv.Rectangle(&img, r, blue, 3) size := gocv.GetTextSize("Human", gocv.FontHersheyPlain, 1.2, 2) pt := image.Pt(r.Min.X+(r.Min.X/2)-(size.X/2), r.Min.Y-2) gocv.PutText(&img, "Human", pt, gocv.FontHersheyPlain, 1.2, blue, 2) } window.IMShow(img) if window.WaitKey(1) >= 0 { break } } } -
Workshop at Webexpo 4 Control Drone Using Your Computer -
Golang, Node.js 4 Examples from talk - https://github.com/abtris/ gobot-examples