Upgrade to Pro — share decks privately, control downloads, hide ads and more …

How I built an autonomous drone using open-sour...

How I built an autonomous drone using open-source software

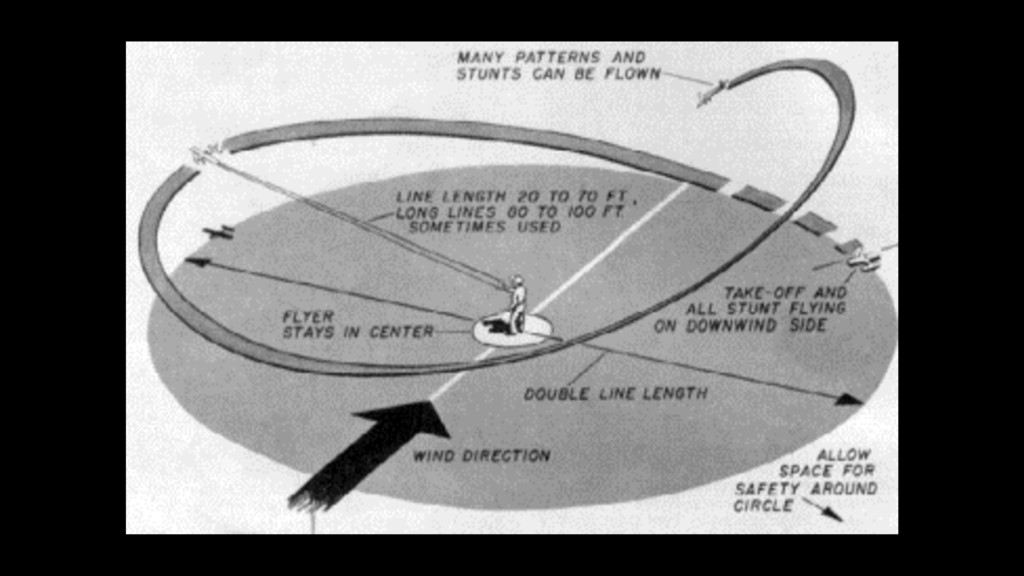
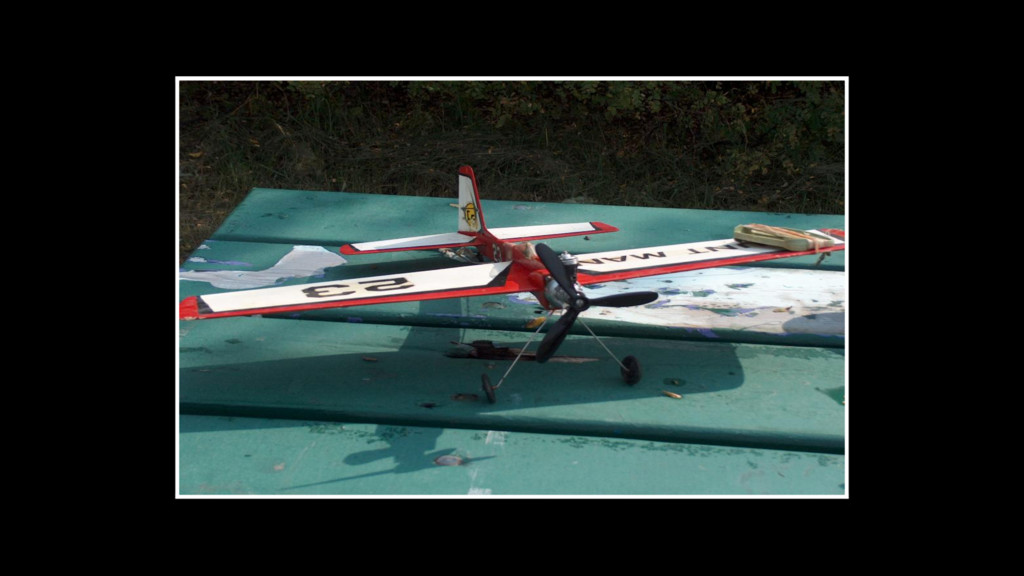
As a boy flying line-control RC planes in my front yard, I would spend hours spinning in a dizzying circle perfecting the art of line-control flight. Eventually, I graduated to gas and battery powered, wireless RC aircraft. Fast-forward to adulthood… and an interest in software and mutli-rotor quadcopters. I built many (dozens actually) RC controlled quadcopters… but autonomy kept calling. For a drone to fly autonomously… sensors, processing power, and communication chips must be on-board. While that may not seem like much, it actually requires a considerably powerful flight controller and associated sensors. In this presentation, the necessary steps required to build an autonomous drone using custom and open-source software will be discussed. All of the failures and the eventual success will be demonstrated.

DJ Daugherty

January 09, 2016

Transcript

152 slides
  1. drones? why I’m a kid trapped in an adult’s body!
    It irritates my wife It’s my job.
  2. drones? why I’m a kid trapped in an adult’s body!
    It irritates my wife It’s my job.
  3. As a boy flying line-control RC planes in my front

    yard, I would spend hours spinning in a dizzying circle perfecting the art of line-control flight. Eventually, I graduated to gas and battery powered, wireless RC aircraft. Fast-forward to adulthood… and an interest in software and mutli-rotor quadcopters. I built many (dozens actually) RC controlled quadcopters… but autonomy kept calling. For a drone to fly autonomously… sensors, processing power, and communication chips must be on-board. While that may not seem like much, it actually requires a considerably powerful flight controller and associated sensors. In this presentation, the necessary steps required to build an autonomous drone using custom and open-source software will be discussed. All of the failures and the eventual success will be demonstrated.
  4. As a boy flying line-control RC planes in my front

    yard, I would spend hours spinning in a dizzying circle perfecting the art of line-control flight. Eventually, I graduated to gas and battery powered, wireless RC aircraft. Fast-forward to adulthood… and an interest in software and mutli-rotor quadcopters. I built many (dozens actually) RC controlled quadcopters… but autonomy kept calling. For a drone to fly autonomously… sensors, processing power, and communication chips must be on-board. While that may not seem like much, it actually requires a considerably powerful flight controller and associated sensors. In this presentation, the necessary steps required to build an autonomous drone using custom and open-source software will be discussed. All of the failures and the eventual success will be demonstrated.
  5. As a boy flying line-control RC planes in my front

    yard, I would spend hours spinning in a dizzying circle perfecting the art of line-control flight. Eventually, I graduated to gas and battery powered, wireless RC aircraft. Fast-forward to adulthood… and an interest in software and mutli-rotor quadcopters. I built many (dozens actually) RC controlled quadcopters… but autonomy kept calling. For a drone to fly autonomously… sensors, processing power, and communication chips must be on-board. While that may not seem like much, it actually requires a considerably powerful flight controller and associated sensors. In this presentation, the necessary steps required to build an autonomous drone using custom and open-source software will be discussed. All of the failures and the eventual success will be demonstrated.
  6. As a boy flying line-control RC planes in my front

    yard, I would spend hours spinning in a dizzying circle perfecting the art of line-control flight. Eventually, I graduated to gas and battery powered, wireless RC aircraft. Fast-forward to adulthood… and an interest in software and mutli-rotor quadcopters. I built many (dozens actually) RC controlled quadcopters… but autonomy kept calling. For a drone to fly autonomously… sensors, processing power, and communication chips must be on-board. While that may not seem like much, it actually requires a considerably powerful flight controller and associated sensors. In this presentation, the necessary steps required to build an autonomous drone using custom and open-source software will be discussed. All of the failures and the eventual success will be demonstrated.
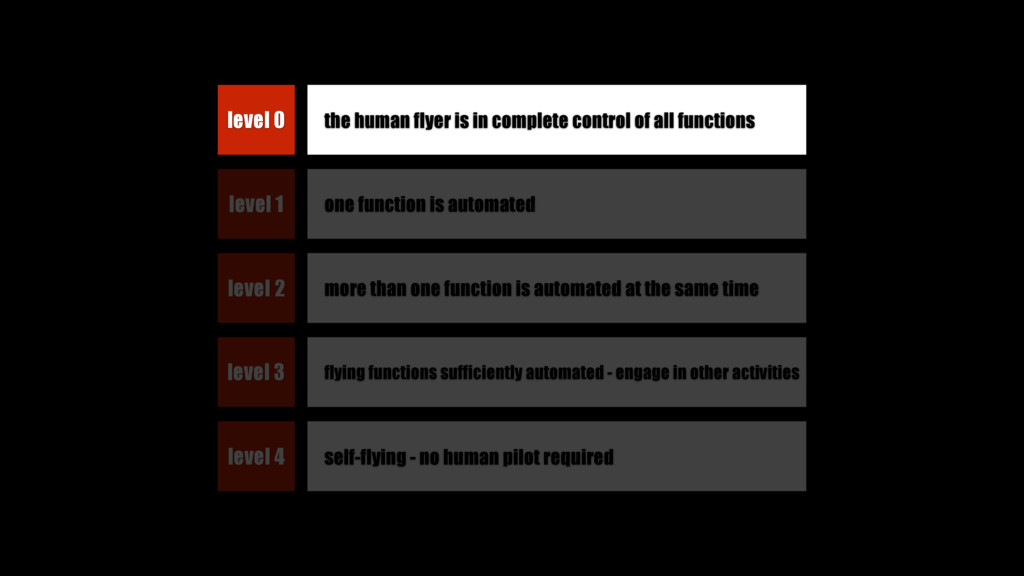
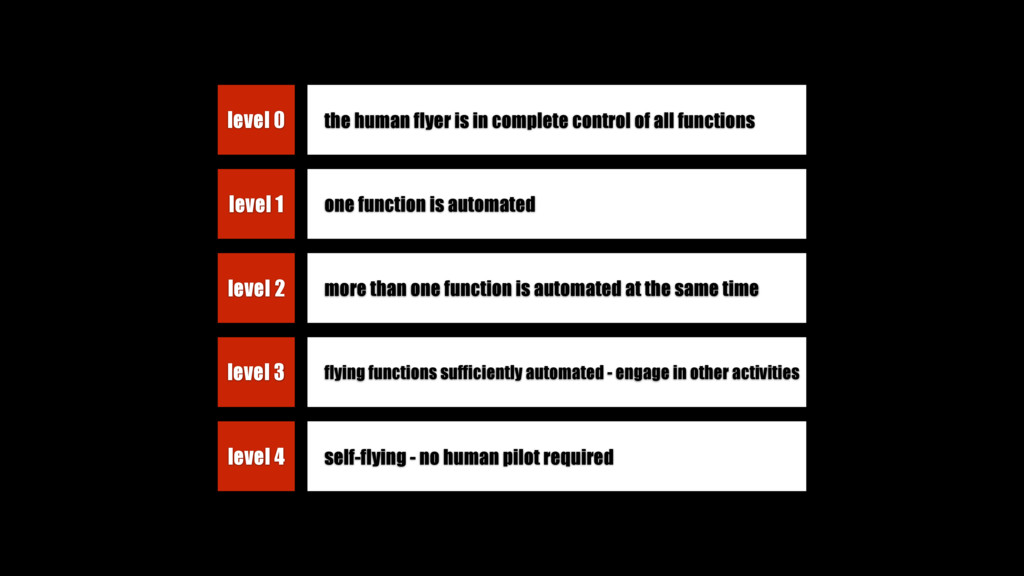
  7. the human flyer is in complete control of all functions

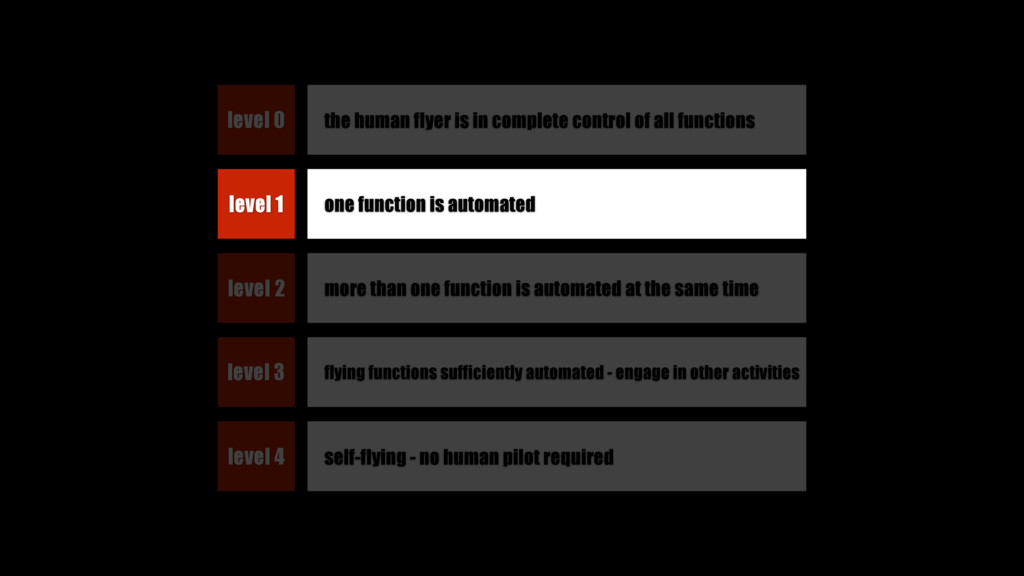
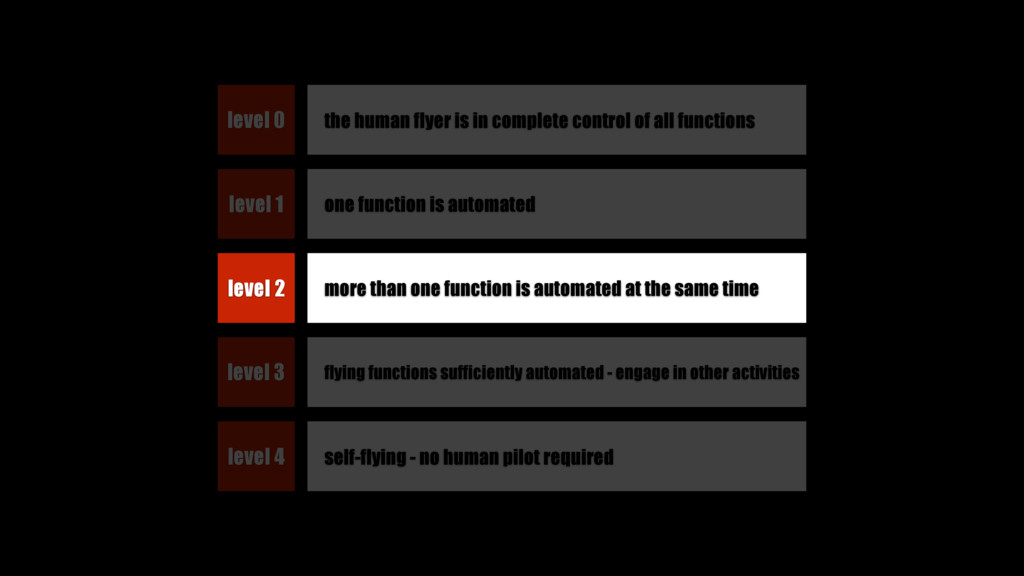
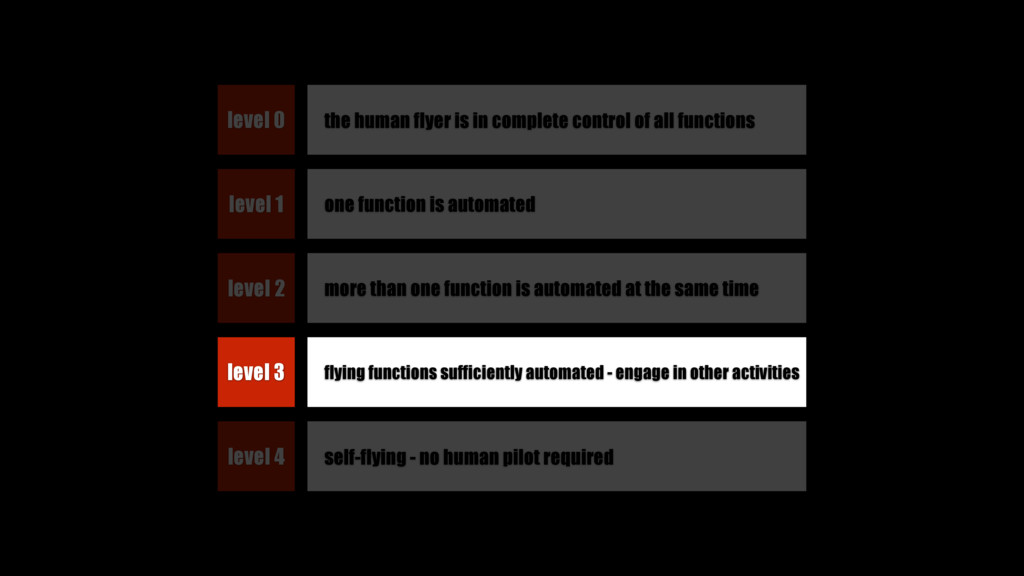
    level 0 one function is automated level 1 more than one function is automated at the same time level 2 flying functions sufficiently automated - engage in other activities level 3 self-flying - no human pilot required level 4
  8. the human flyer is in complete control of all functions

    level 0 one function is automated level 1 more than one function is automated at the same time level 2 flying functions sufficiently automated - engage in other activities level 3 self-flying - no human pilot required level 4
  9. the human flyer is in complete control of all functions

    level 0 one function is automated level 1 more than one function is automated at the same time level 2 flying functions sufficiently automated - engage in other activities level 3 self-flying - no human pilot required level 4
  10. the human flyer is in complete control of all functions

    level 0 one function is automated level 1 more than one function is automated at the same time level 2 flying functions sufficiently automated - engage in other activities level 3 self-flying - no human pilot required level 4
  11. the human flyer is in complete control of all functions

    level 0 one function is automated level 1 more than one function is automated at the same time level 2 flying functions sufficiently automated - engage in other activities level 3 self-flying - no human pilot required level 4
  12. the human flyer is in complete control of all functions

    level 0 one function is automated level 1 more than one function is automated at the same time level 2 flying functions sufficiently automated - engage in other activities level 3 self-flying - no human pilot required level 4
  13. the human flyer is in complete control of all functions

    level 0 one function is automated level 1 more than one function is automated at the same time level 2 flying functions sufficiently automated - engage in other activities level 3 self-flying - no human pilot required level 4
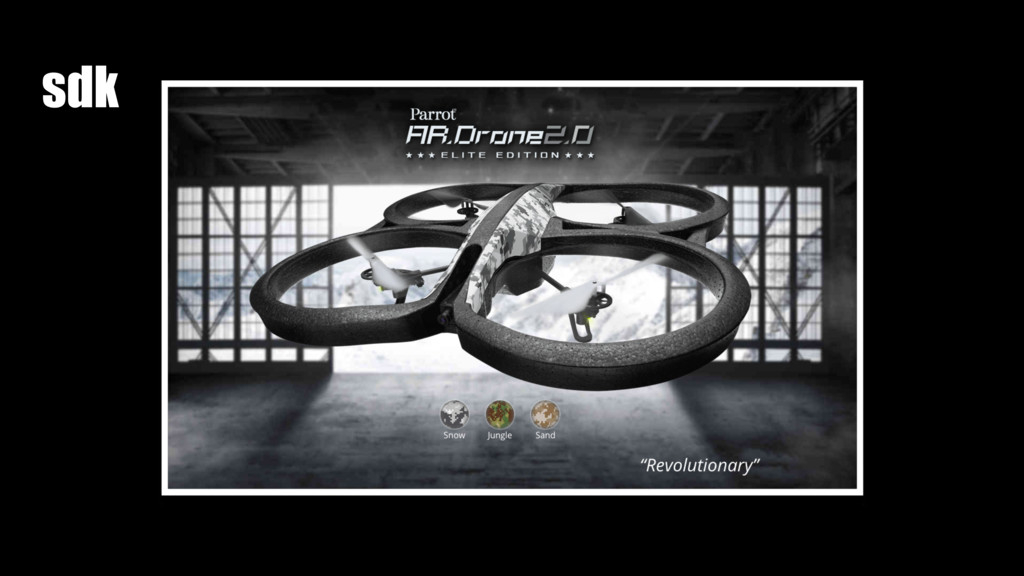
  14. sdk

  15. direct and inverse solutions of geodesics on the ellipsoid with

    application of nested equations http://ddaugher.github.io/oss/groovy_vincenty.html

More Decks by DJ Daugherty

Other Decks in Technology