Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
Creating Crazy Robotic Librarians
Search
Marwan Alsabbagh
May 26, 2019
Programming
200
1
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
Creating Crazy Robotic Librarians
Marwan Alsabbagh
May 26, 2019
More Decks by Marwan Alsabbagh
See All by Marwan Alsabbagh
PyCon India 2018 - Executing scripts in a few milliseconds with MicroPython
marwano
2
210
Snow globe intruder alert system
marwano
0
530
Executing scripts in a few milliseconds with MicroPython
marwano
1
490
Other Decks in Programming
See All in Programming
HTML-in-Canvasで作る未来のWeb UI表現
clockmaker
5
6.2k
Apple Intelligenceとオンデバイス時代の到来
yahir0
0
190
Lambda durable functionsでHuman in the Loopを楽に…楽に……
har1101
2
250
Railsバージョンを4倍にした話
optim
0
920
SODA - FACT BOOK(JP)
sodainc
1
40k
Materialが消えた日 〜真っ白なFlutterキャンバスにRenderObjectで絵を描く〜
umigishiaoi
0
140
느린 네트워크와 저사양 디바이스 사용자를 위한 웹뷰 로딩 시간 개선기
kmkim
0
140
React Native에 현대적인 빌드 도구 더하기: Rollipop 구현기
leegeunhyeok
0
180
DroidKnights 2026 Android A2UI Jetpack Compose 기반의 안전한 AI UI 렌더링 - 박제창
itsmedreamwalker
0
110
Coding with AI: How to trust the storyteller (AWS Community Day Adria, Ljubljana 2026)
slobodan
0
140
オーケストレーション記述言語 Katari
yukikurage
0
220
AIで開発が速くなった先で、開発チームは何を目指すか
shihochan
1
2k
Featured
See All Featured
Information Architects: The Missing Link in Design Systems
soysaucechin
1
1.2k
The Web Performance Landscape in 2024 [PerfNow 2024]
tammyeverts
12
1.4k
New Earth Scene 8
popppiees
4
2.8k
Fight the Zombie Pattern Library - RWD Summit 2016
marcelosomers
234
18k
Principles of Awesome APIs and How to Build Them.
keavy
128
18k
Discover your Explorer Soul
emna__ayadi
2
1.3k
How Software Deployment tools have changed in the past 20 years
geshan
2
35k
Large-scale JavaScript Application Architecture
addyosmani
516
110k
It's Worth the Effort
3n
188
29k
Design and Strategy: How to Deal with People Who Don’t "Get" Design
morganepeng
133
20k
Unsuck your backbone
ammeep
672
58k
Let's Do A Bunch of Simple Stuff to Make Websites Faster
chriscoyier
508
140k
Transcript
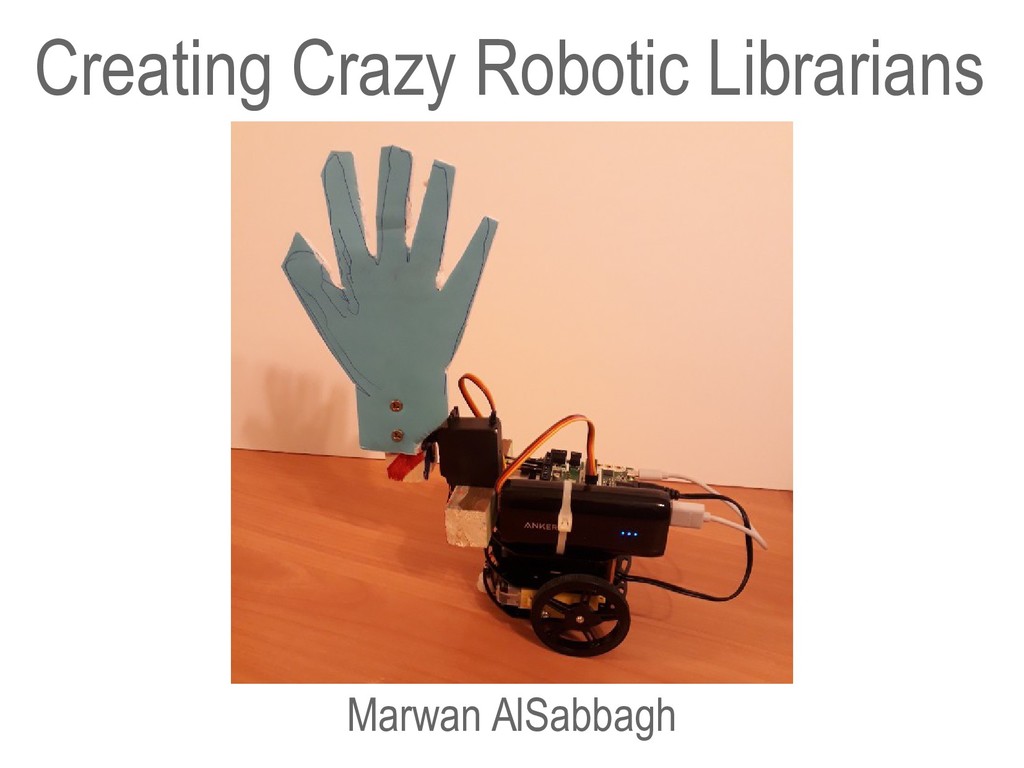
Creating Crazy Robotic Librarians Marwan AlSabbagh
1. Building 2. Teaching 3. Controlling Robots 4. Pushing Books
Outline
1. Building
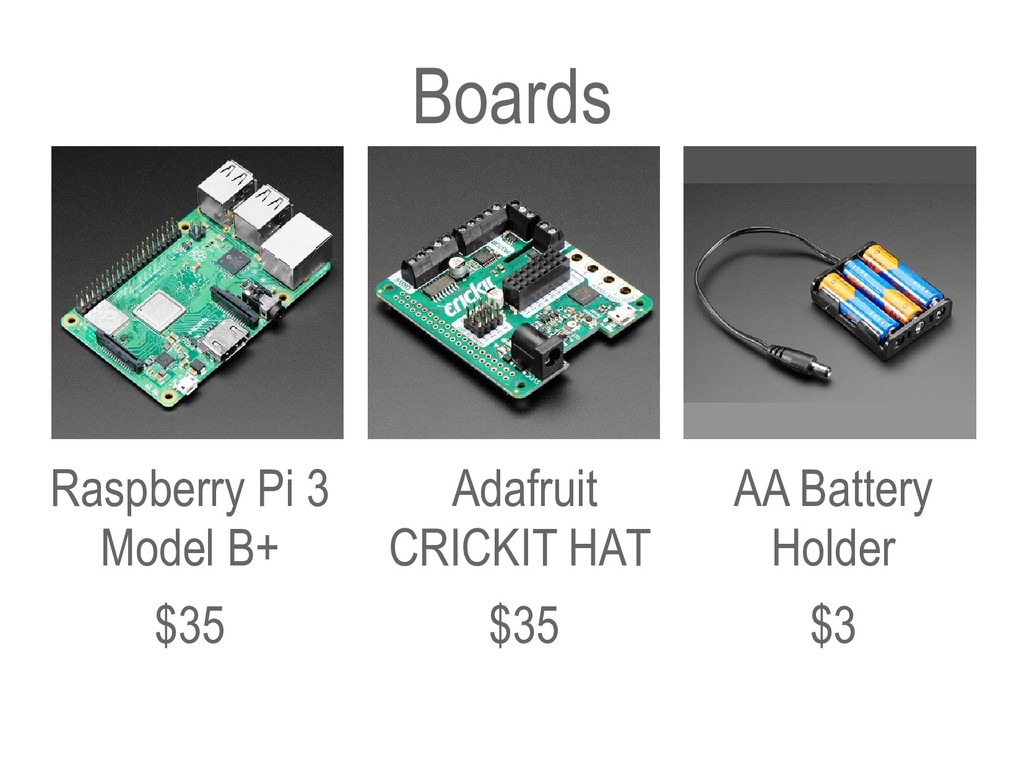
Boards Adafruit CRICKIT HAT $35 Raspberry Pi 3 Model B+
$35 AA Battery Holder $3
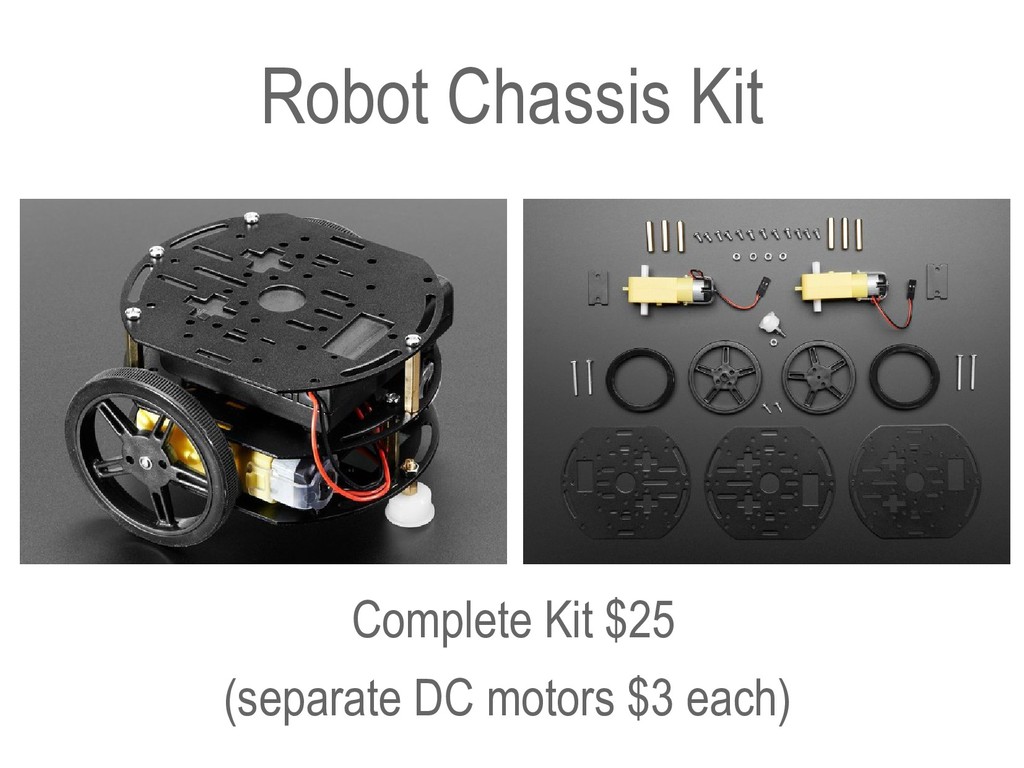
Robot Chassis Kit Complete Kit $25 (separate DC motors $3
each)
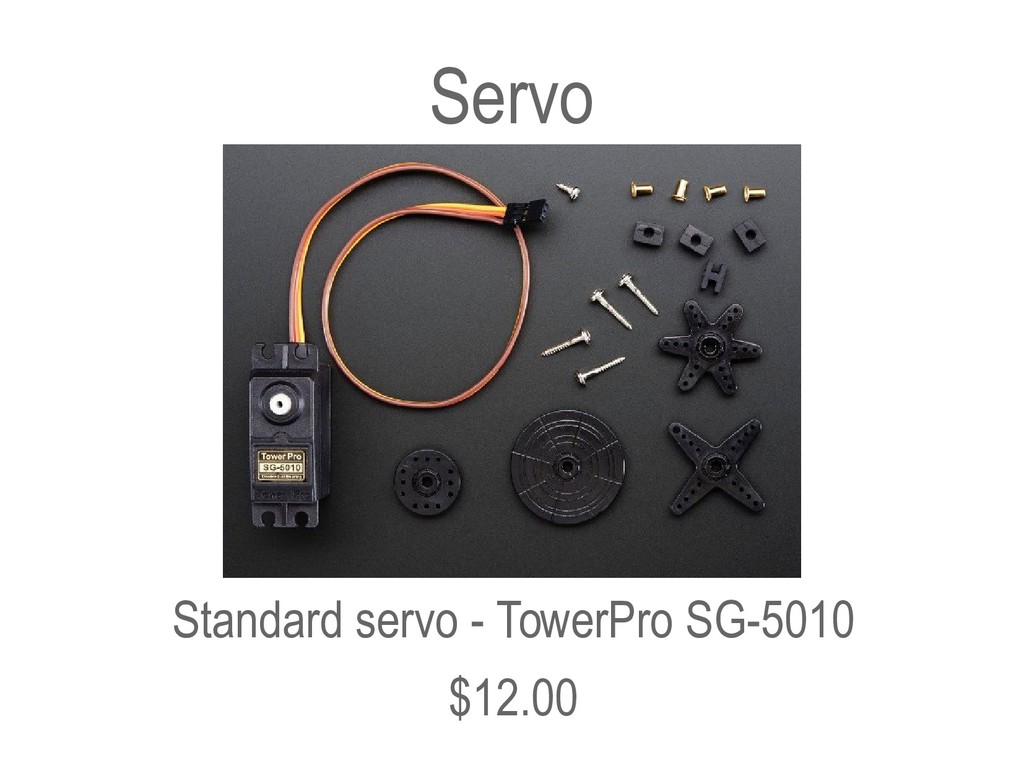
Servo Standard servo - TowerPro SG-5010 $12.00
Exploded View
2. Teaching
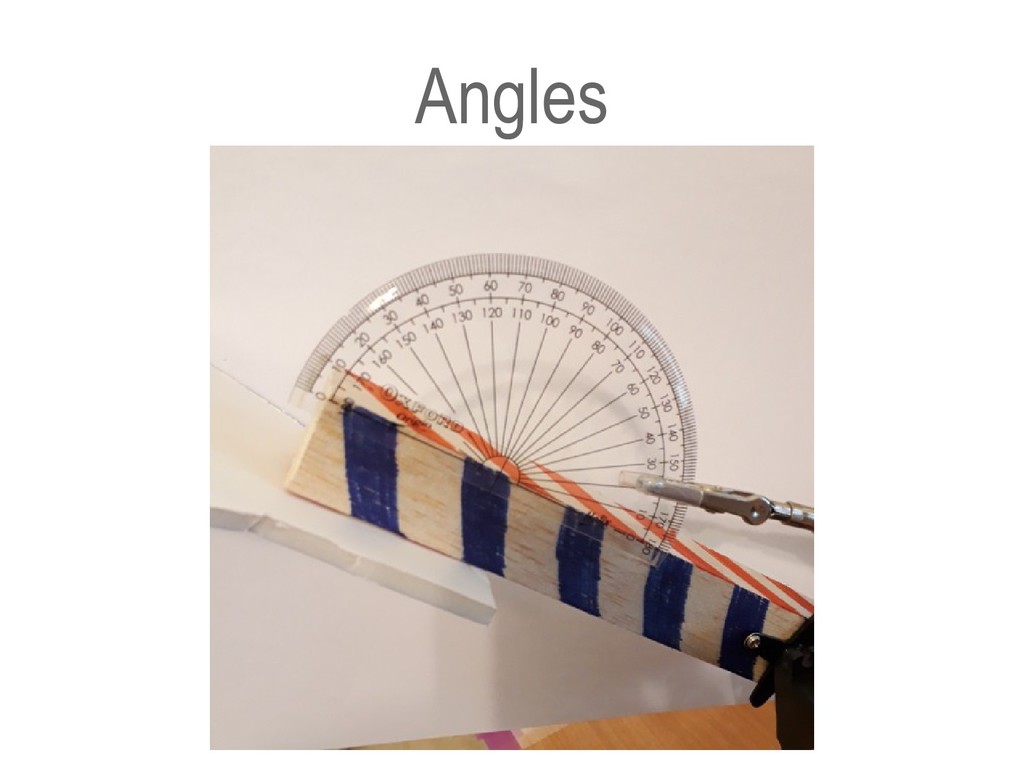
Angles
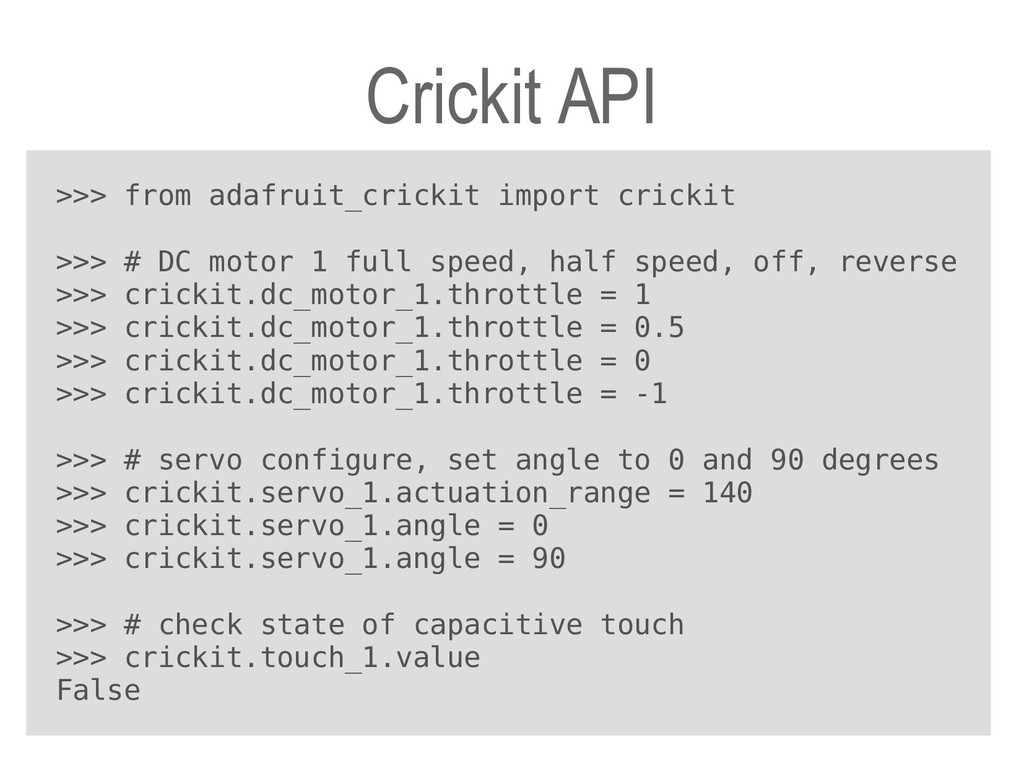
Crickit API >>> from adafruit_crickit import crickit >>> # DC
motor 1 full speed, half speed, off, reverse >>> crickit.dc_motor_1.throttle = 1 >>> crickit.dc_motor_1.throttle = 0.5 >>> crickit.dc_motor_1.throttle = 0 >>> crickit.dc_motor_1.throttle = -1 >>> # servo configure, set angle to 0 and 90 degrees >>> crickit.servo_1.actuation_range = 140 >>> crickit.servo_1.angle = 0 >>> crickit.servo_1.angle = 90 >>> # check state of capacitive touch >>> crickit.touch_1.value False
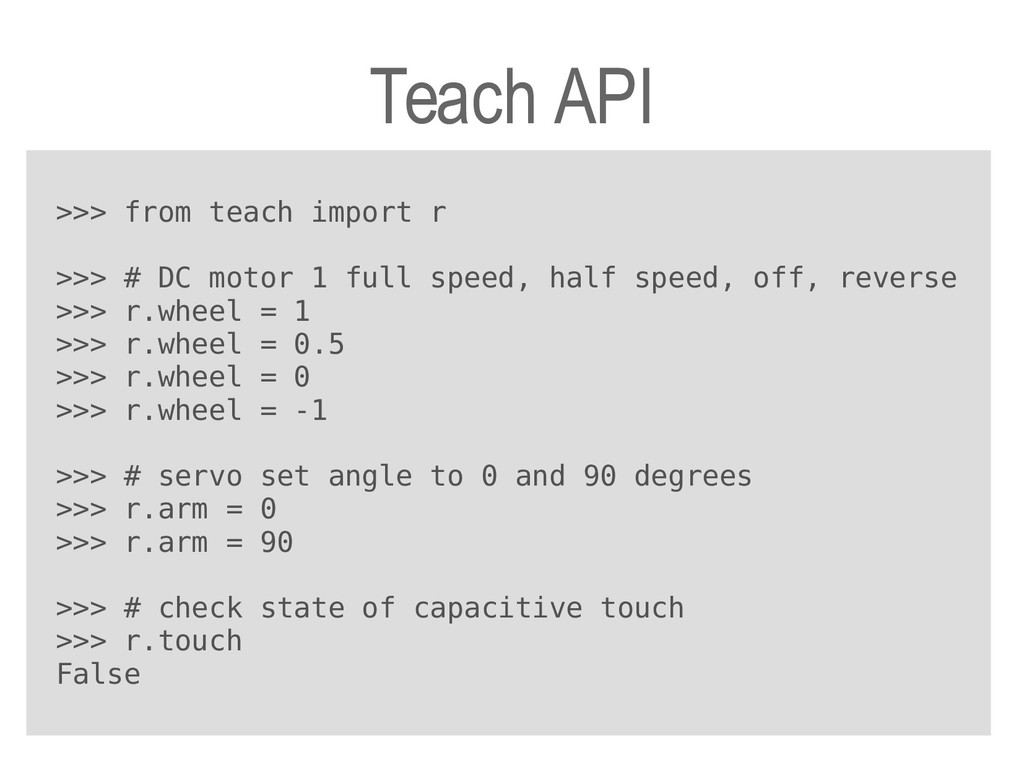
Teach API >>> from teach import r >>> # DC
motor 1 full speed, half speed, off, reverse >>> r.wheel = 1 >>> r.wheel = 0.5 >>> r.wheel = 0 >>> r.wheel = -1 >>> # servo set angle to 0 and 90 degrees >>> r.arm = 0 >>> r.arm = 90 >>> # check state of capacitive touch >>> r.touch False
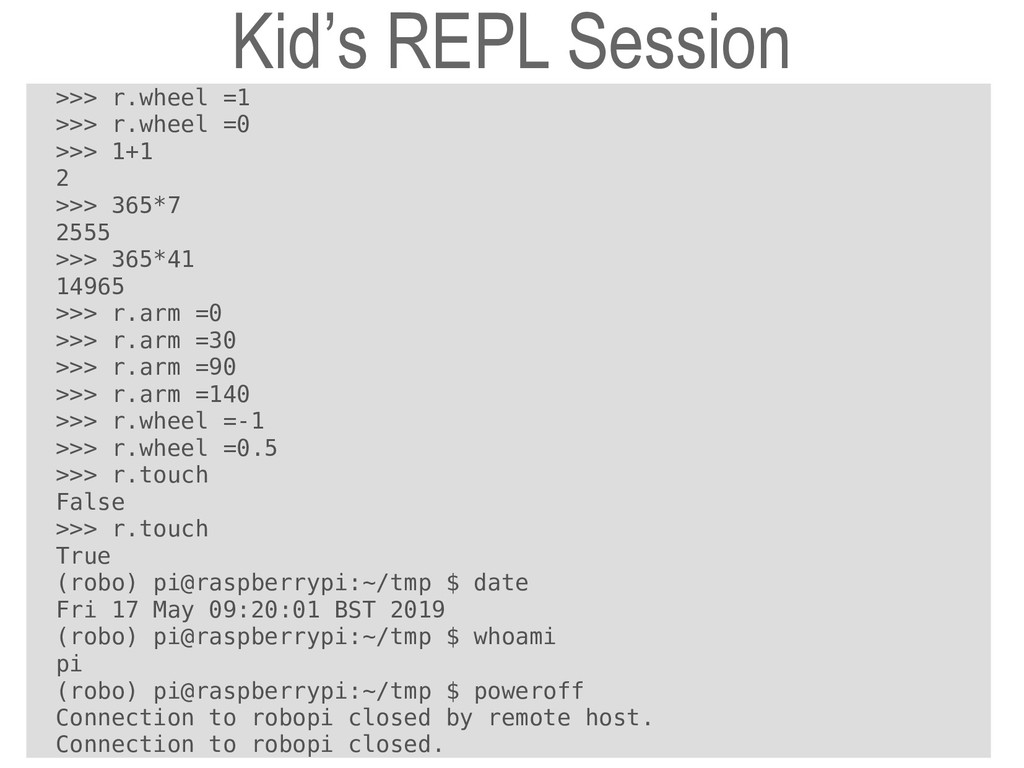
Kid’s REPL Session >>> r.wheel =1 >>> r.wheel =0 >>>
1+1 2 >>> 365*7 2555 >>> 365*41 14965 >>> r.arm =0 >>> r.arm =30 >>> r.arm =90 >>> r.arm =140 >>> r.wheel =-1 >>> r.wheel =0.5 >>> r.touch False >>> r.touch True (robo) pi@raspberrypi:~/tmp $ date Fri 17 May 09:20:01 BST 2019 (robo) pi@raspberrypi:~/tmp $ whoami pi (robo) pi@raspberrypi:~/tmp $ poweroff Connection to robopi closed by remote host. Connection to robopi closed.
3. Controlling Robots
Setup • Install Raspbian on Raspberry Pi • Enable ssh
and I2C in Raspbian • pip install adafruit-circuitpython-crickit tornado
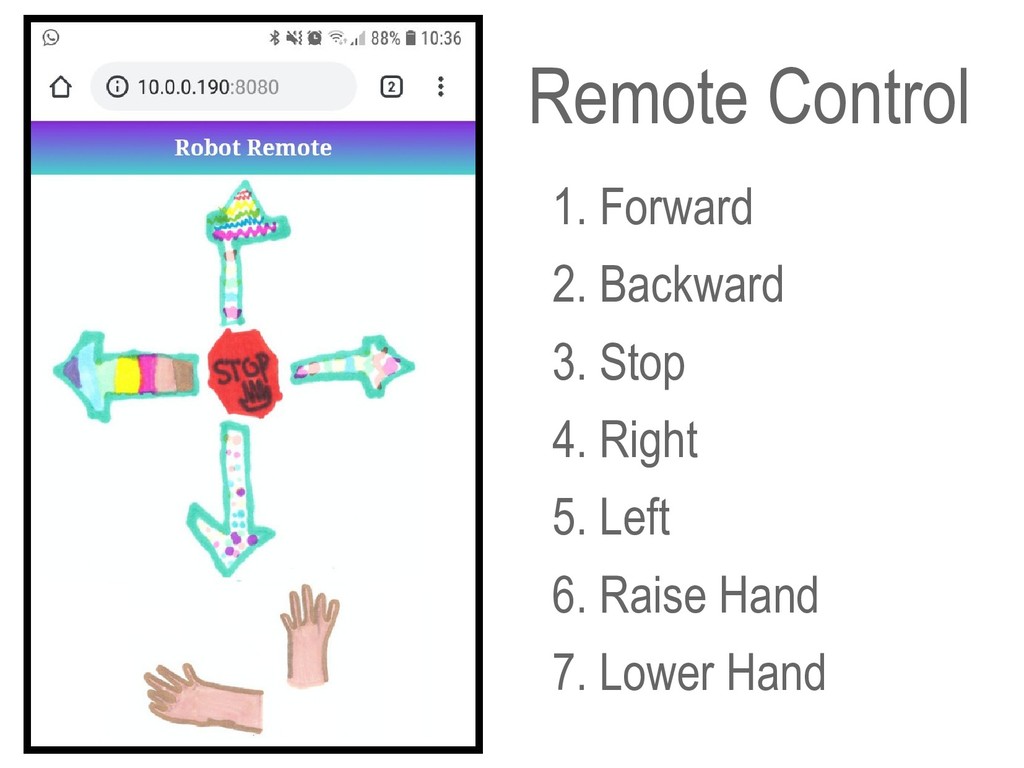
Remote Control 1. Forward 2. Backward 3. Stop 4. Right
5. Left 6. Raise Hand 7. Lower Hand
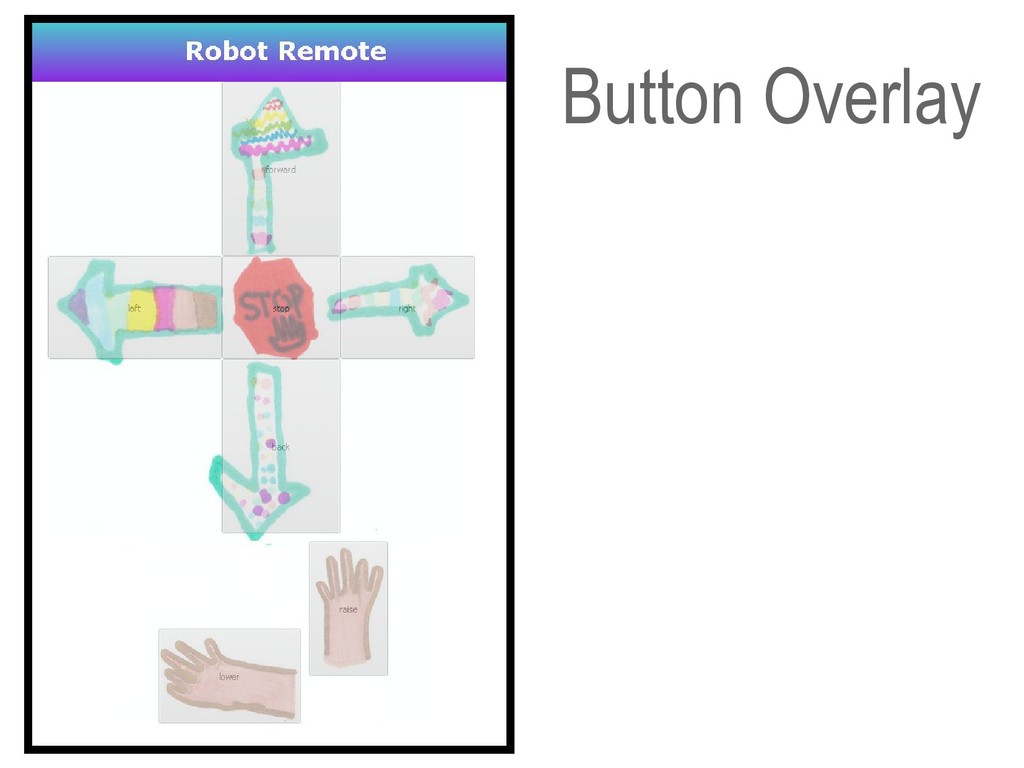
Button Overlay
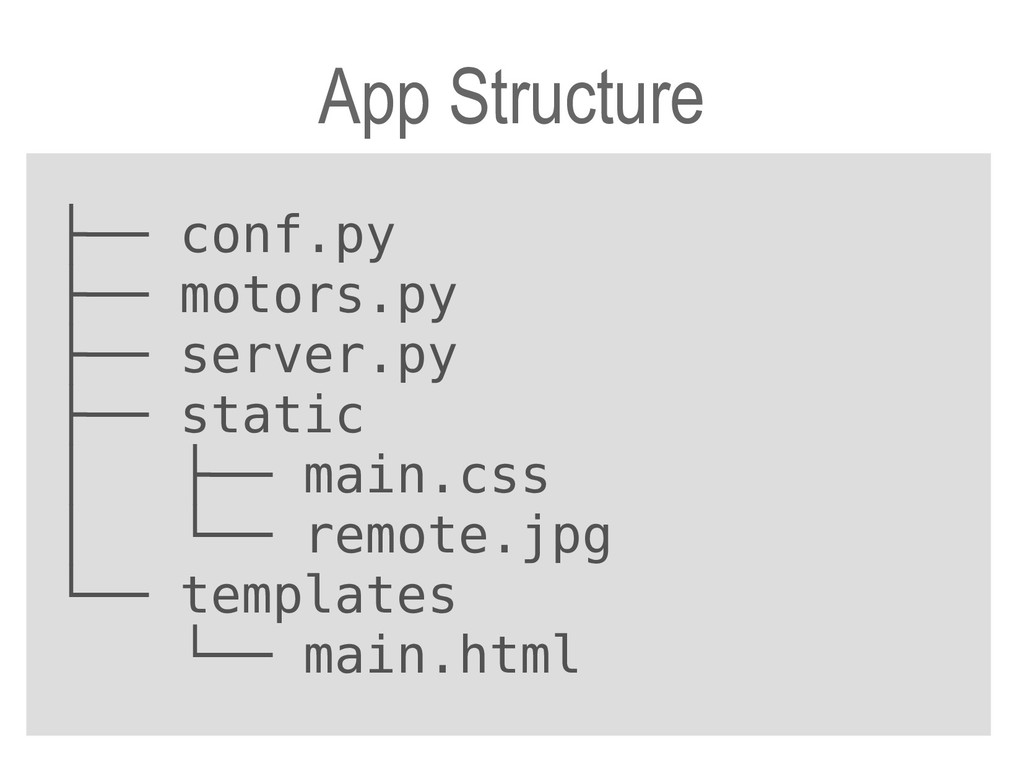
App Structure ├── conf.py ├── motors.py ├── server.py ├── static
│ ├── main.css │ └── remote.jpg └── templates └── main.html
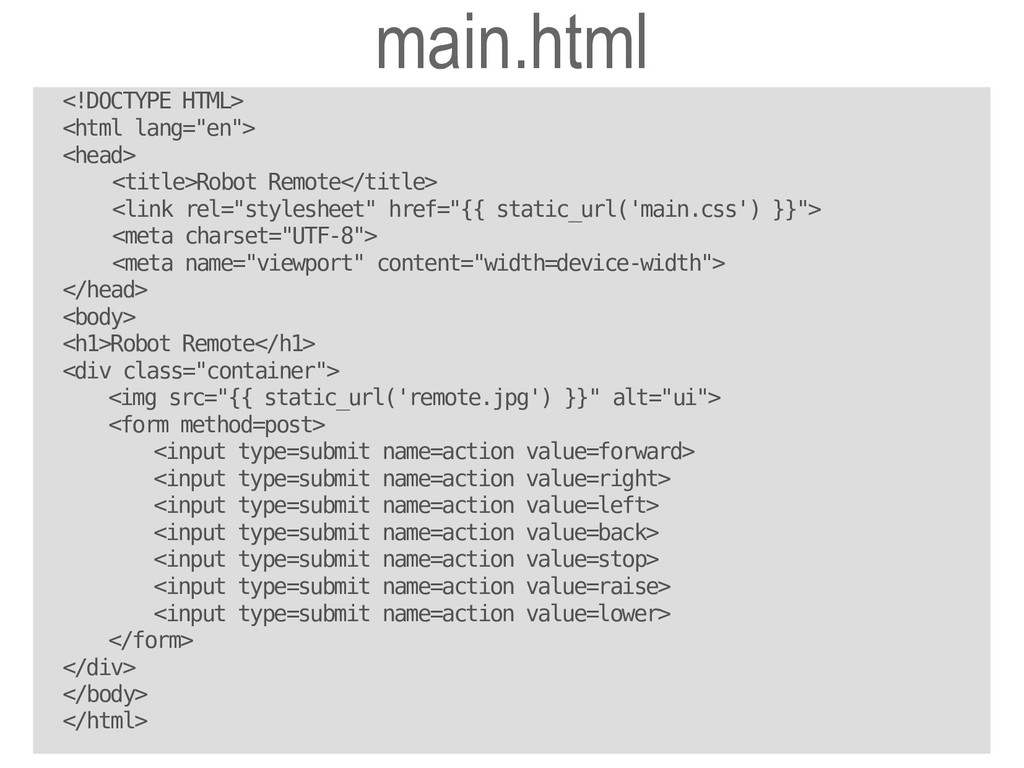
main.html <!DOCTYPE HTML> <html lang="en"> <head> <title>Robot Remote</title> <link rel="stylesheet"
href="{{ static_url('main.css') }}"> <meta charset="UTF-8"> <meta name="viewport" content="width=device-width"> </head> <body> <h1>Robot Remote</h1> <div class="container"> <img src="{{ static_url('remote.jpg') }}" alt="ui"> <form method=post> <input type=submit name=action value=forward> <input type=submit name=action value=right> <input type=submit name=action value=left> <input type=submit name=action value=back> <input type=submit name=action value=stop> <input type=submit name=action value=raise> <input type=submit name=action value=lower> </form> </div> </body> </html>
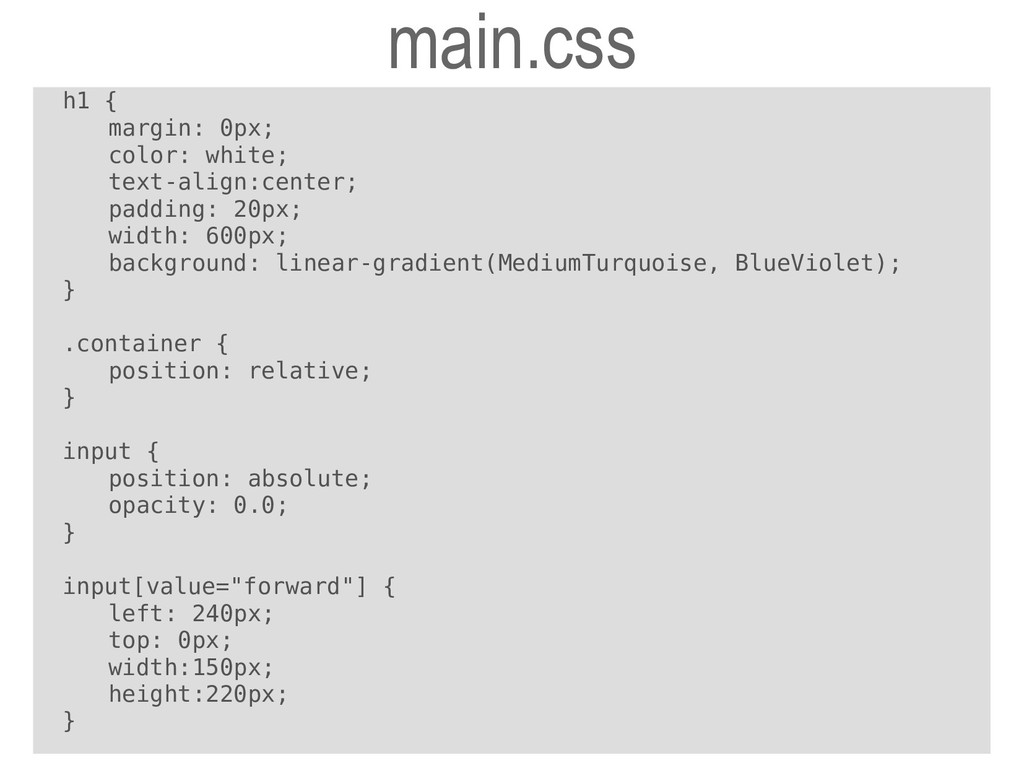
main.css h1 { margin: 0px; color: white; text-align:center; padding: 20px;
width: 600px; background: linear-gradient(MediumTurquoise, BlueViolet); } .container { position: relative; } input { position: absolute; opacity: 0.0; } input[value="forward"] { left: 240px; top: 0px; width:150px; height:220px; }
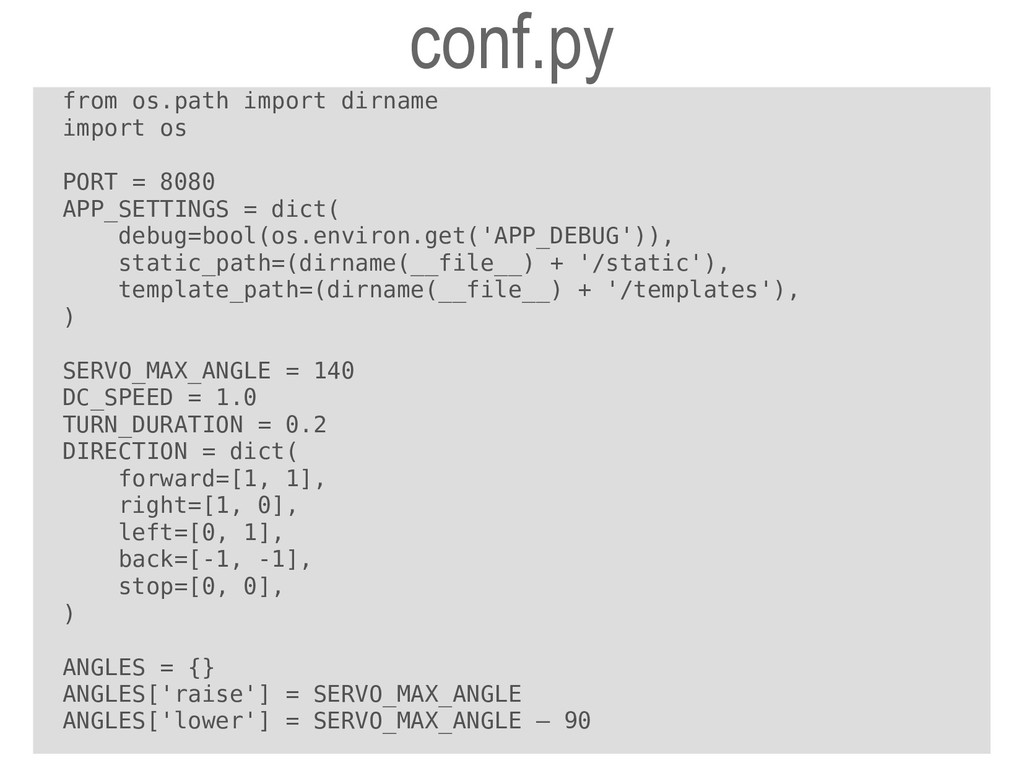
conf.py from os.path import dirname import os PORT = 8080
APP_SETTINGS = dict( debug=bool(os.environ.get('APP_DEBUG')), static_path=(dirname(__file__) + '/static'), template_path=(dirname(__file__) + '/templates'), ) SERVO_MAX_ANGLE = 140 DC_SPEED = 1.0 TURN_DURATION = 0.2 DIRECTION = dict( forward=[1, 1], right=[1, 0], left=[0, 1], back=[-1, -1], stop=[0, 0], ) ANGLES = {} ANGLES['raise'] = SERVO_MAX_ANGLE ANGLES['lower'] = SERVO_MAX_ANGLE – 90
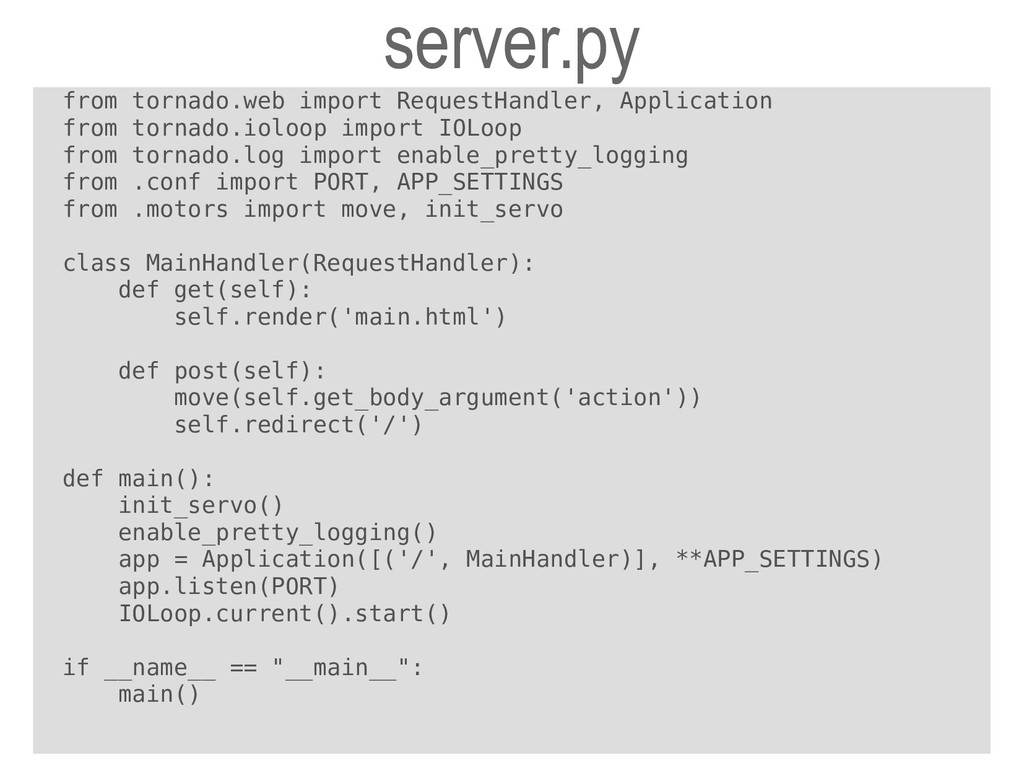
server.py from tornado.web import RequestHandler, Application from tornado.ioloop import IOLoop
from tornado.log import enable_pretty_logging from .conf import PORT, APP_SETTINGS from .motors import move, init_servo class MainHandler(RequestHandler): def get(self): self.render('main.html') def post(self): move(self.get_body_argument('action')) self.redirect('/') def main(): init_servo() enable_pretty_logging() app = Application([('/', MainHandler)], **APP_SETTINGS) app.listen(PORT) IOLoop.current().start() if __name__ == "__main__": main()
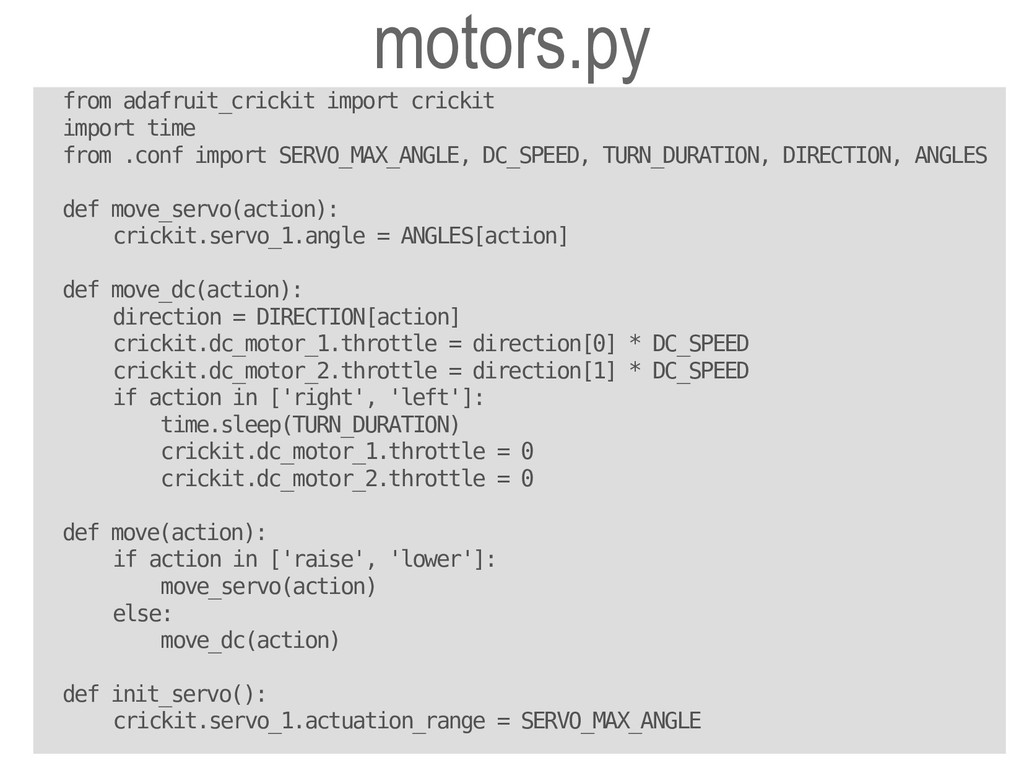
motors.py from adafruit_crickit import crickit import time from .conf import
SERVO_MAX_ANGLE, DC_SPEED, TURN_DURATION, DIRECTION, ANGLES def move_servo(action): crickit.servo_1.angle = ANGLES[action] def move_dc(action): direction = DIRECTION[action] crickit.dc_motor_1.throttle = direction[0] * DC_SPEED crickit.dc_motor_2.throttle = direction[1] * DC_SPEED if action in ['right', 'left']: time.sleep(TURN_DURATION) crickit.dc_motor_1.throttle = 0 crickit.dc_motor_2.throttle = 0 def move(action): if action in ['raise', 'lower']: move_servo(action) else: move_dc(action) def init_servo(): crickit.servo_1.actuation_range = SERVO_MAX_ANGLE
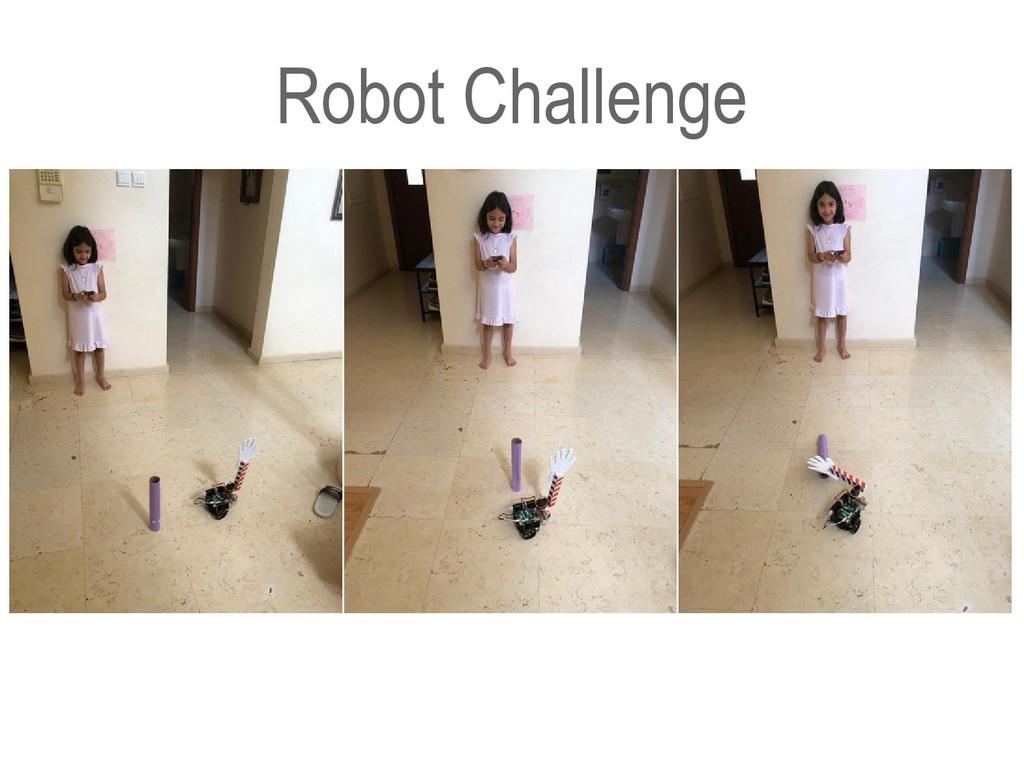
Robot Challenge
4. Pushing Books
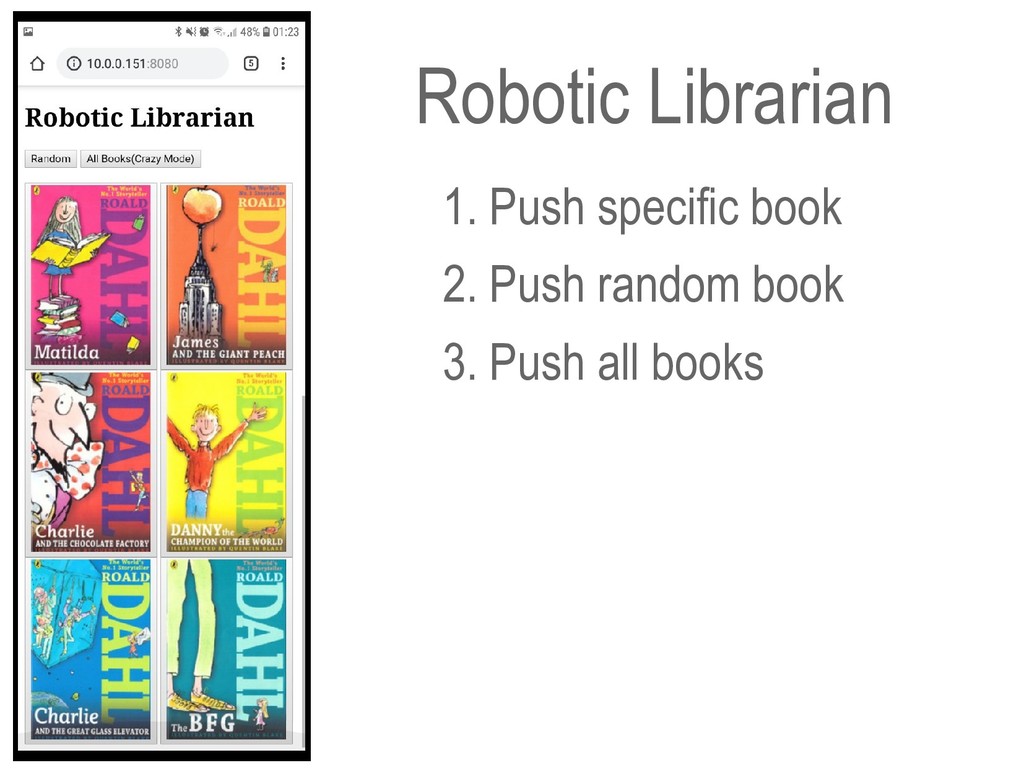
Robotic Librarian 1. Push specific book 2. Push random book
3. Push all books
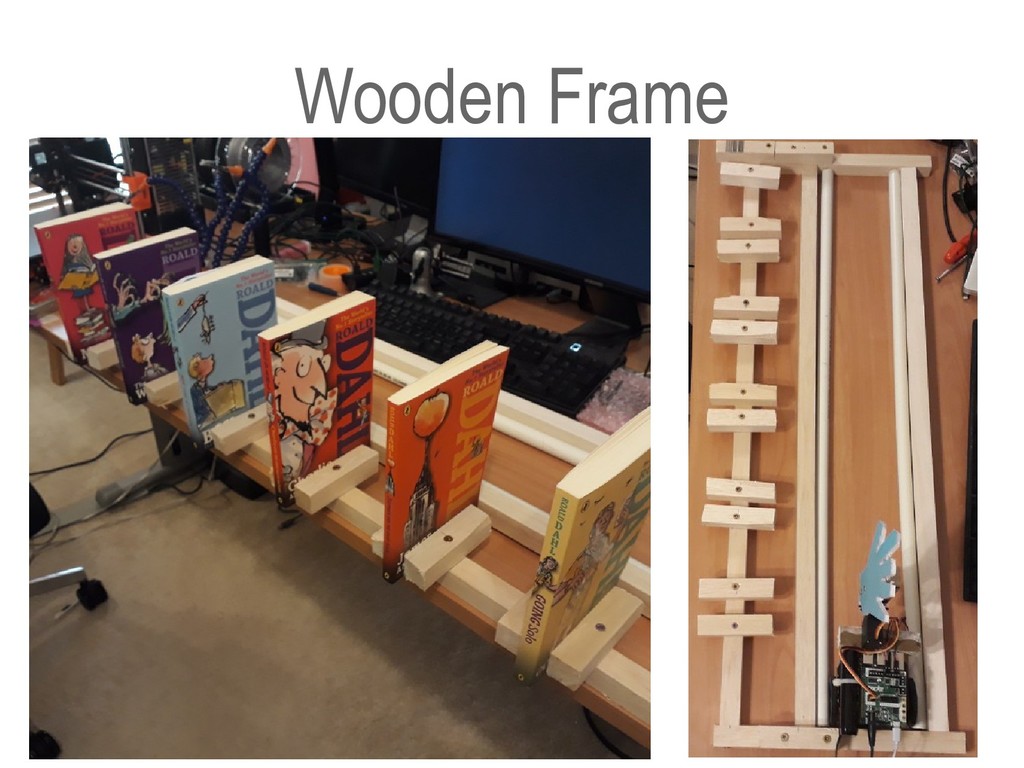
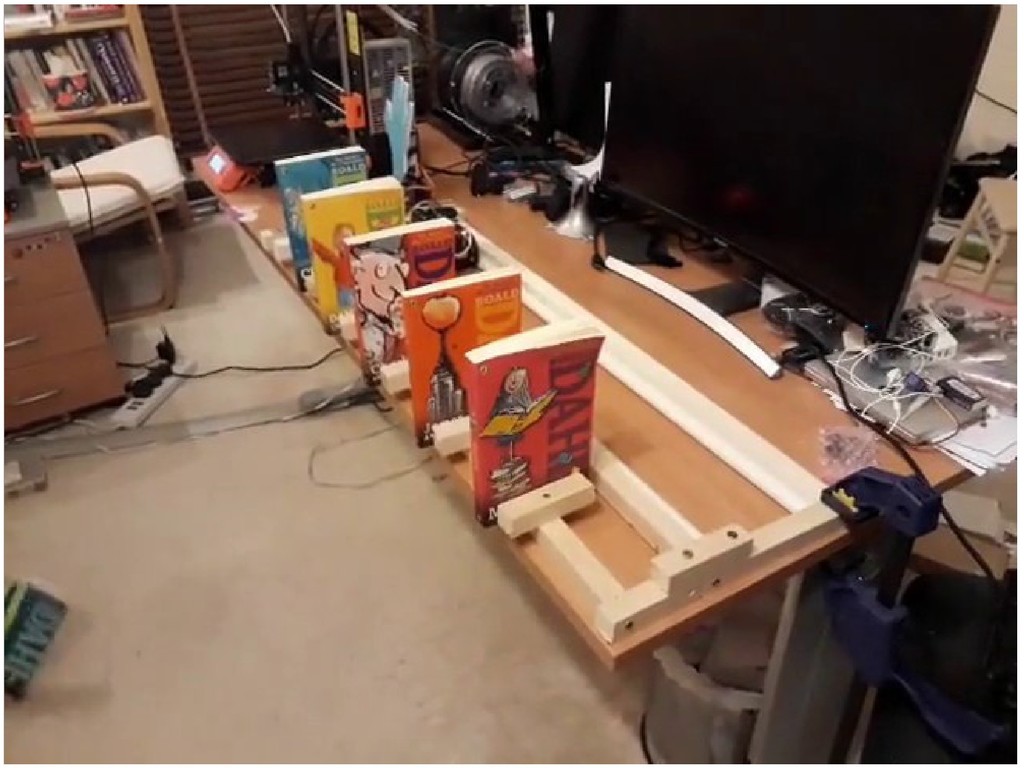
Wooden Frame
None
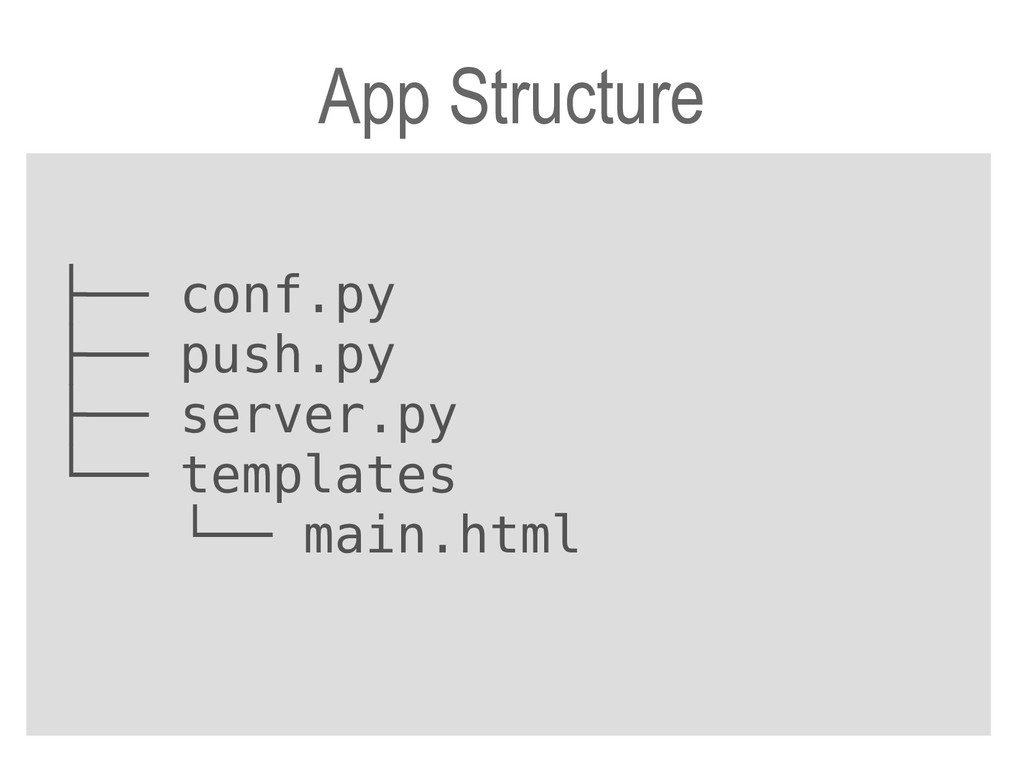
App Structure ├── conf.py ├── push.py ├── server.py └── templates
└── main.html
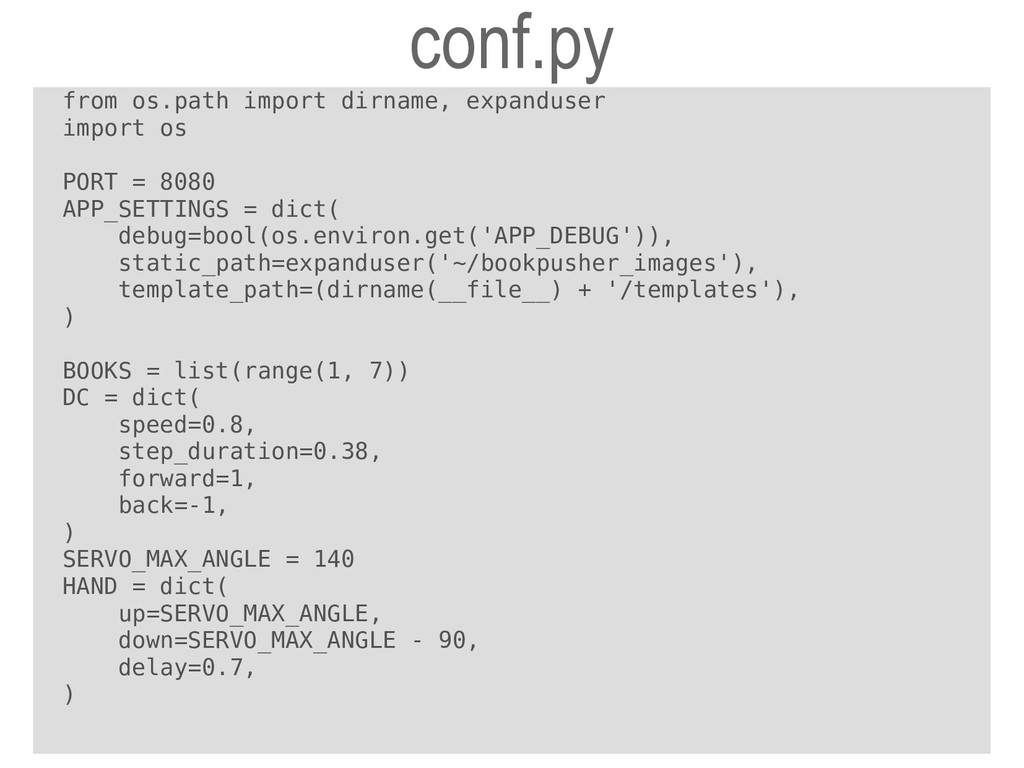
conf.py from os.path import dirname, expanduser import os PORT =
8080 APP_SETTINGS = dict( debug=bool(os.environ.get('APP_DEBUG')), static_path=expanduser('~/bookpusher_images'), template_path=(dirname(__file__) + '/templates'), ) BOOKS = list(range(1, 7)) DC = dict( speed=0.8, step_duration=0.38, forward=1, back=-1, ) SERVO_MAX_ANGLE = 140 HAND = dict( up=SERVO_MAX_ANGLE, down=SERVO_MAX_ANGLE - 90, delay=0.7, )
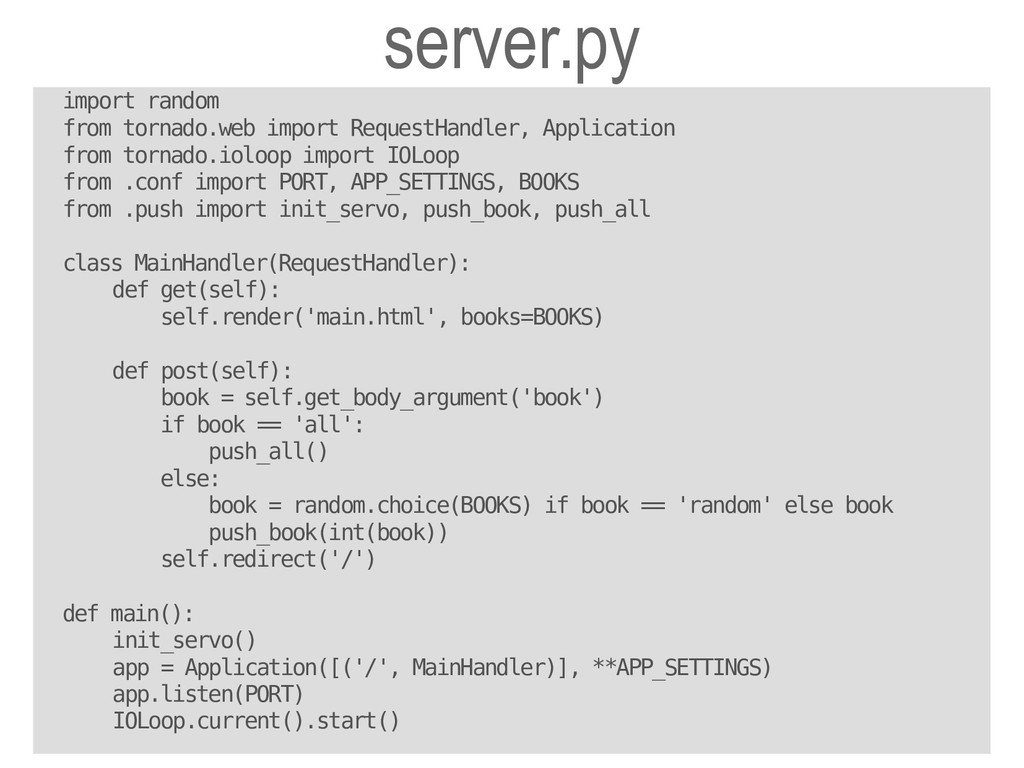
server.py import random from tornado.web import RequestHandler, Application from tornado.ioloop
import IOLoop from .conf import PORT, APP_SETTINGS, BOOKS from .push import init_servo, push_book, push_all class MainHandler(RequestHandler): def get(self): self.render('main.html', books=BOOKS) def post(self): book = self.get_body_argument('book') if book == 'all': push_all() else: book = random.choice(BOOKS) if book == 'random' else book push_book(int(book)) self.redirect('/') def main(): init_servo() app = Application([('/', MainHandler)], **APP_SETTINGS) app.listen(PORT) IOLoop.current().start()
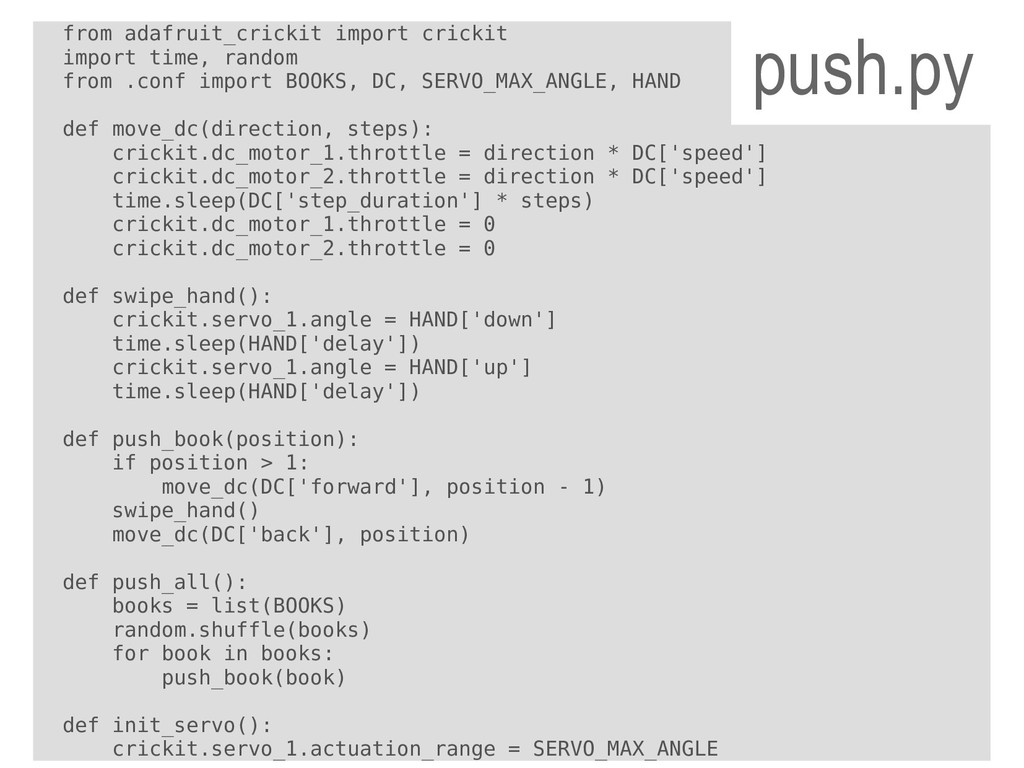
from adafruit_crickit import crickit import time, random from .conf import
BOOKS, DC, SERVO_MAX_ANGLE, HAND def move_dc(direction, steps): crickit.dc_motor_1.throttle = direction * DC['speed'] crickit.dc_motor_2.throttle = direction * DC['speed'] time.sleep(DC['step_duration'] * steps) crickit.dc_motor_1.throttle = 0 crickit.dc_motor_2.throttle = 0 def swipe_hand(): crickit.servo_1.angle = HAND['down'] time.sleep(HAND['delay']) crickit.servo_1.angle = HAND['up'] time.sleep(HAND['delay']) def push_book(position): if position > 1: move_dc(DC['forward'], position - 1) swipe_hand() move_dc(DC['back'], position) def push_all(): books = list(BOOKS) random.shuffle(books) for book in books: push_book(book) def init_servo(): crickit.servo_1.actuation_range = SERVO_MAX_ANGLE push.py
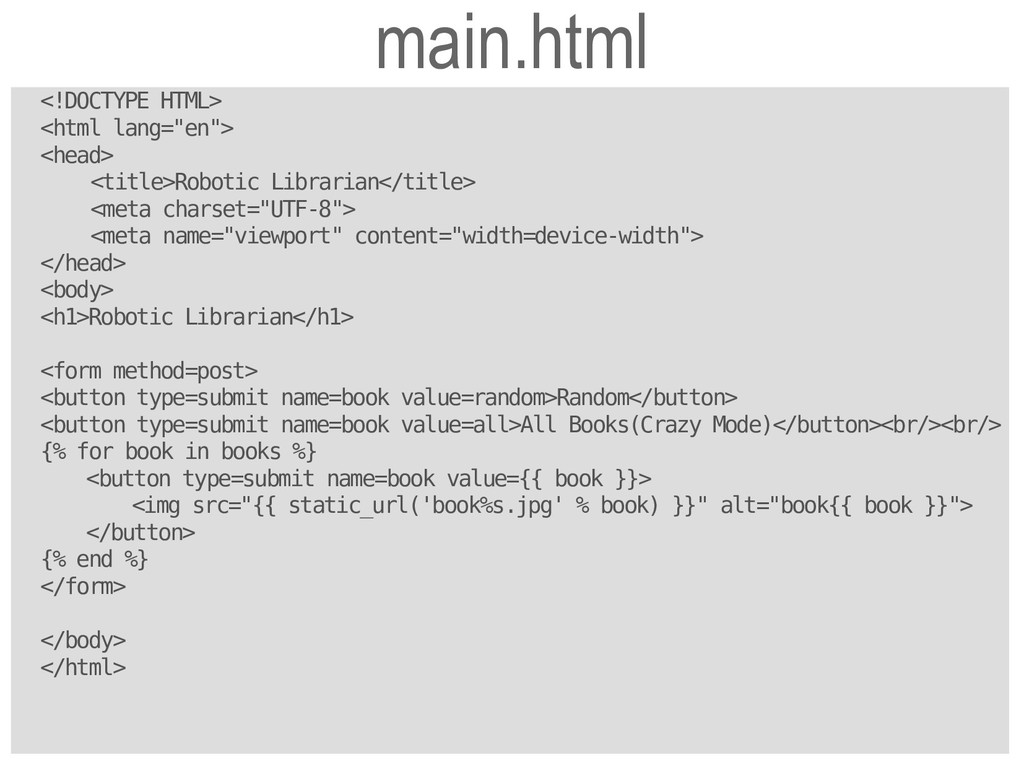
main.html <!DOCTYPE HTML> <html lang="en"> <head> <title>Robotic Librarian</title> <meta charset="UTF-8">
<meta name="viewport" content="width=device-width"> </head> <body> <h1>Robotic Librarian</h1> <form method=post> <button type=submit name=book value=random>Random</button> <button type=submit name=book value=all>All Books(Crazy Mode)</button><br/><br/> {% for book in books %} <button type=submit name=book value={{ book }}> <img src="{{ static_url('book%s.jpg' % book) }}" alt="book{{ book }}"> </button> {% end %} </form> </body> </html>
None
None
The End https://marwano.com/


 marwano
 clockmaker
 yahir0
 har1101
 optim
 sodainc
 umigishiaoi
 kmkim
 leegeunhyeok
 itsmedreamwalker
 slobodan
 yukikurage
 shihochan
 soysaucechin
 tammyeverts
 popppiees
 marcelosomers
 keavy
 emna__ayadi
 geshan
 addyosmani
 3n
 morganepeng
 ammeep
 chriscoyier