Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
公大高専土井研_なかチャレシンポ20230121
Search
Sponsored
·
Ship Features Fearlessly
Turn features on and off without deploys. Used by thousands of Ruby developers.
→
Tmhr_Doi
January 21, 2023
Technology
160
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
公大高専土井研_なかチャレシンポ20230121
Tmhr_Doi
January 21, 2023
Transcript
21 slides
⼤阪公⽴⼤学⾼専 ⼟井研究室チームの活動報告 ―2020年度から2022年度まで― 公⽴⼤学法⼈⼤阪 ⼤阪公⽴⼤学⼯業⾼等専⾨学校 ⼟井研究室 ◦⼟井智晴 梅阪稜⾺ 清家陸翔 ⾹川恭碩
⼤⻄智輝 兵頭元晴 ⼤坪憲弘 古賀健朗
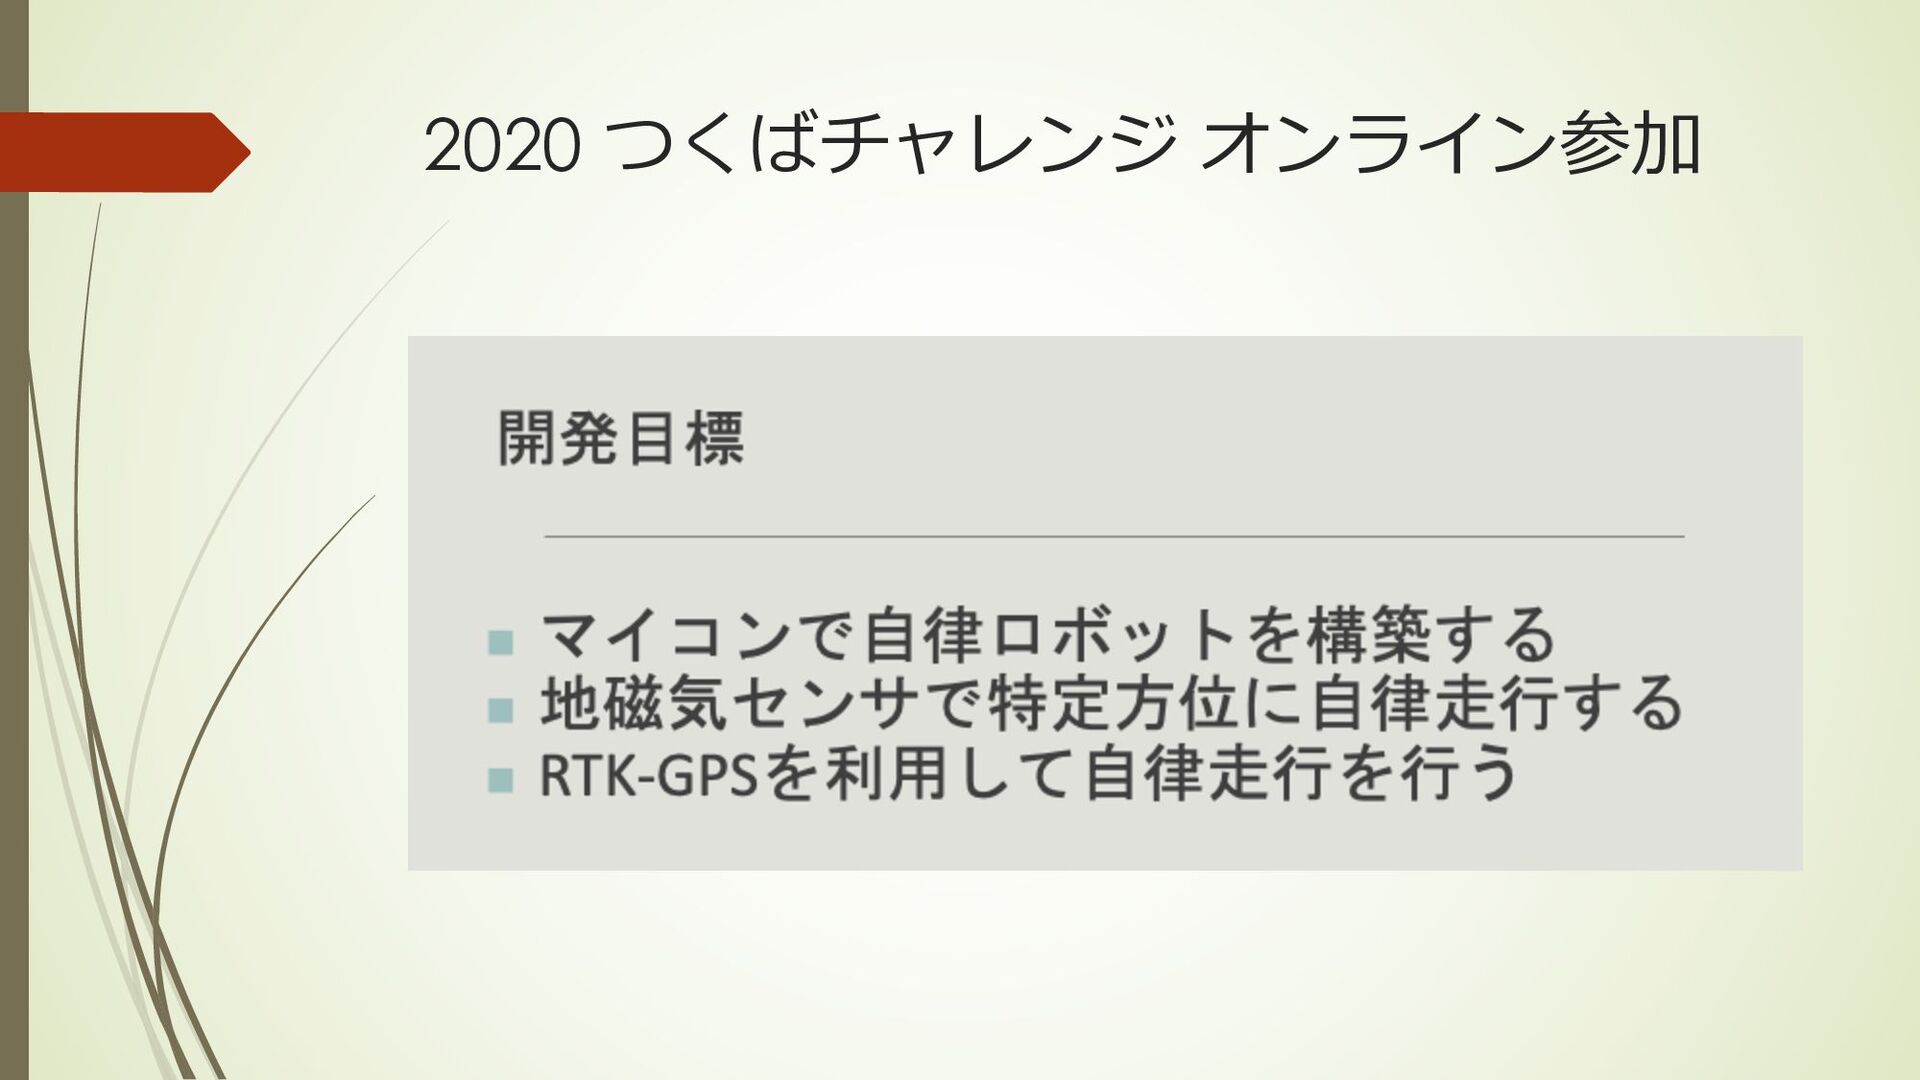
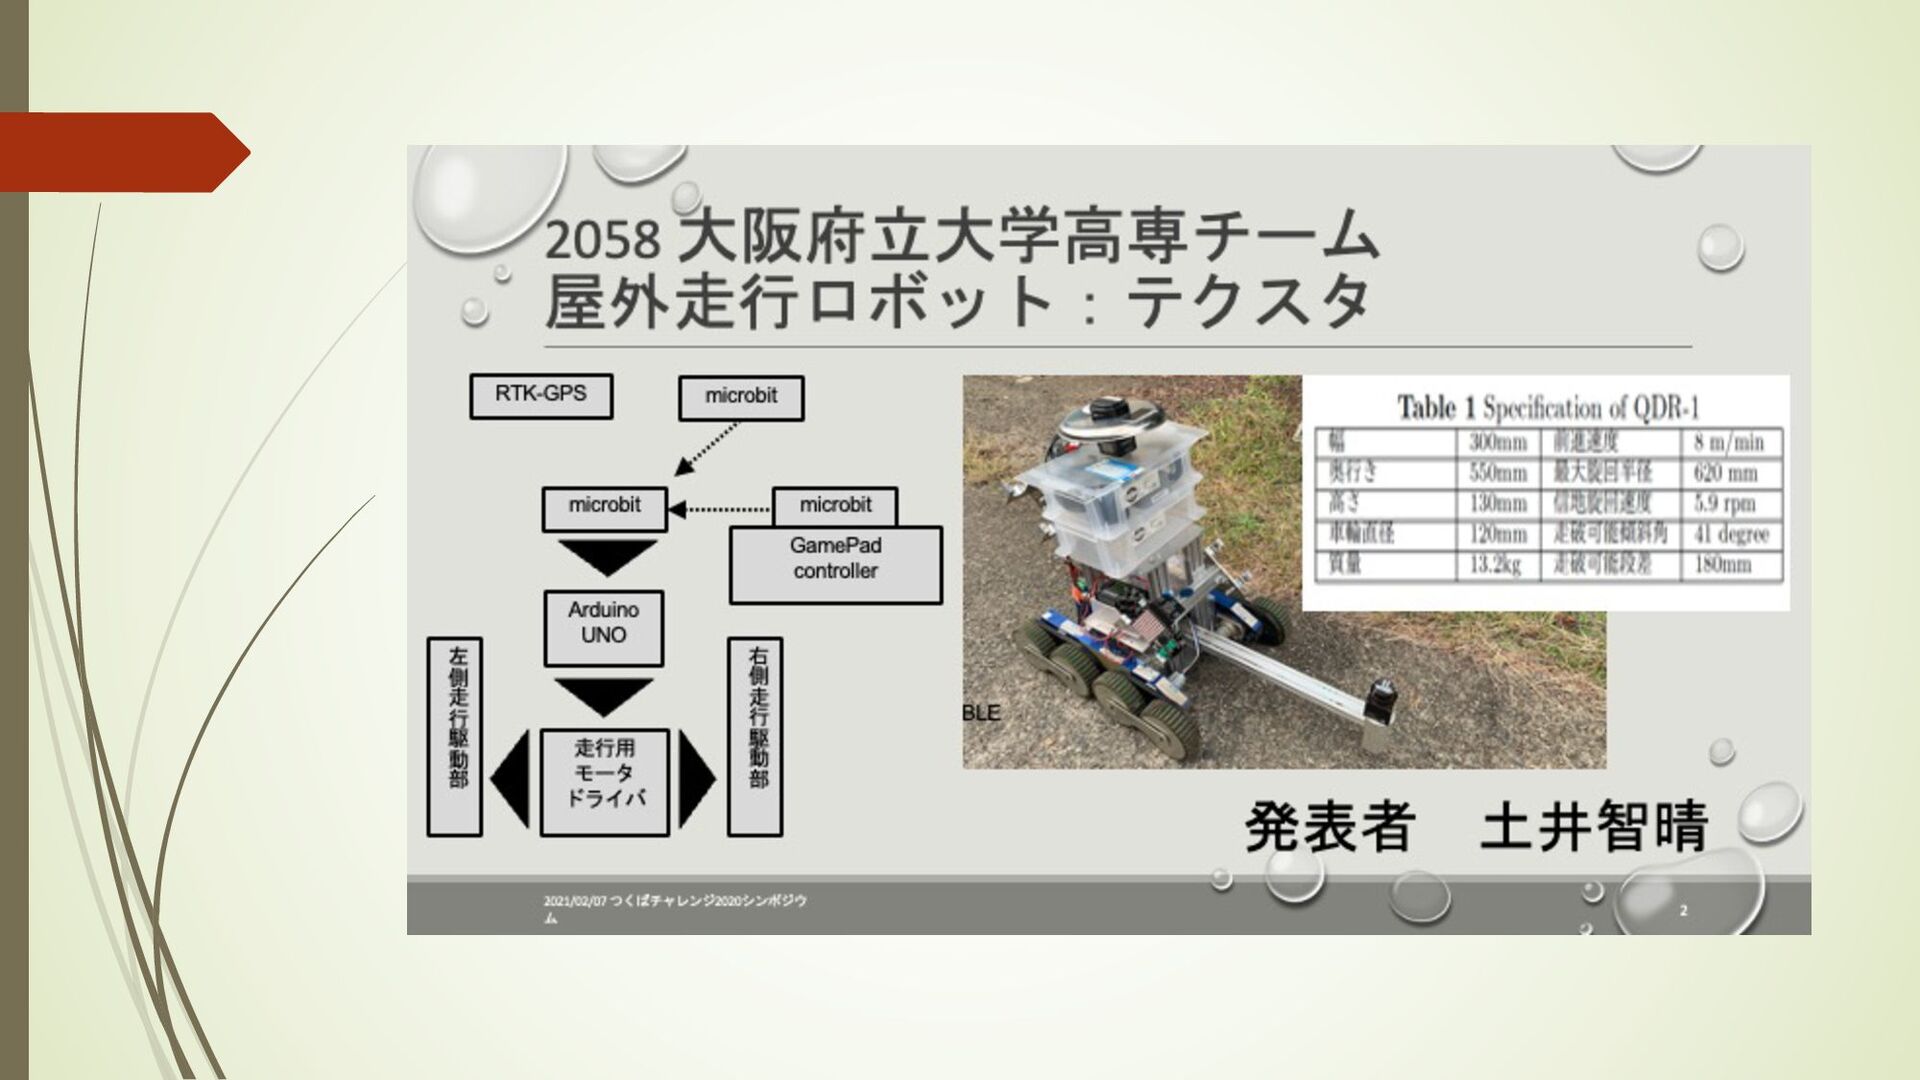
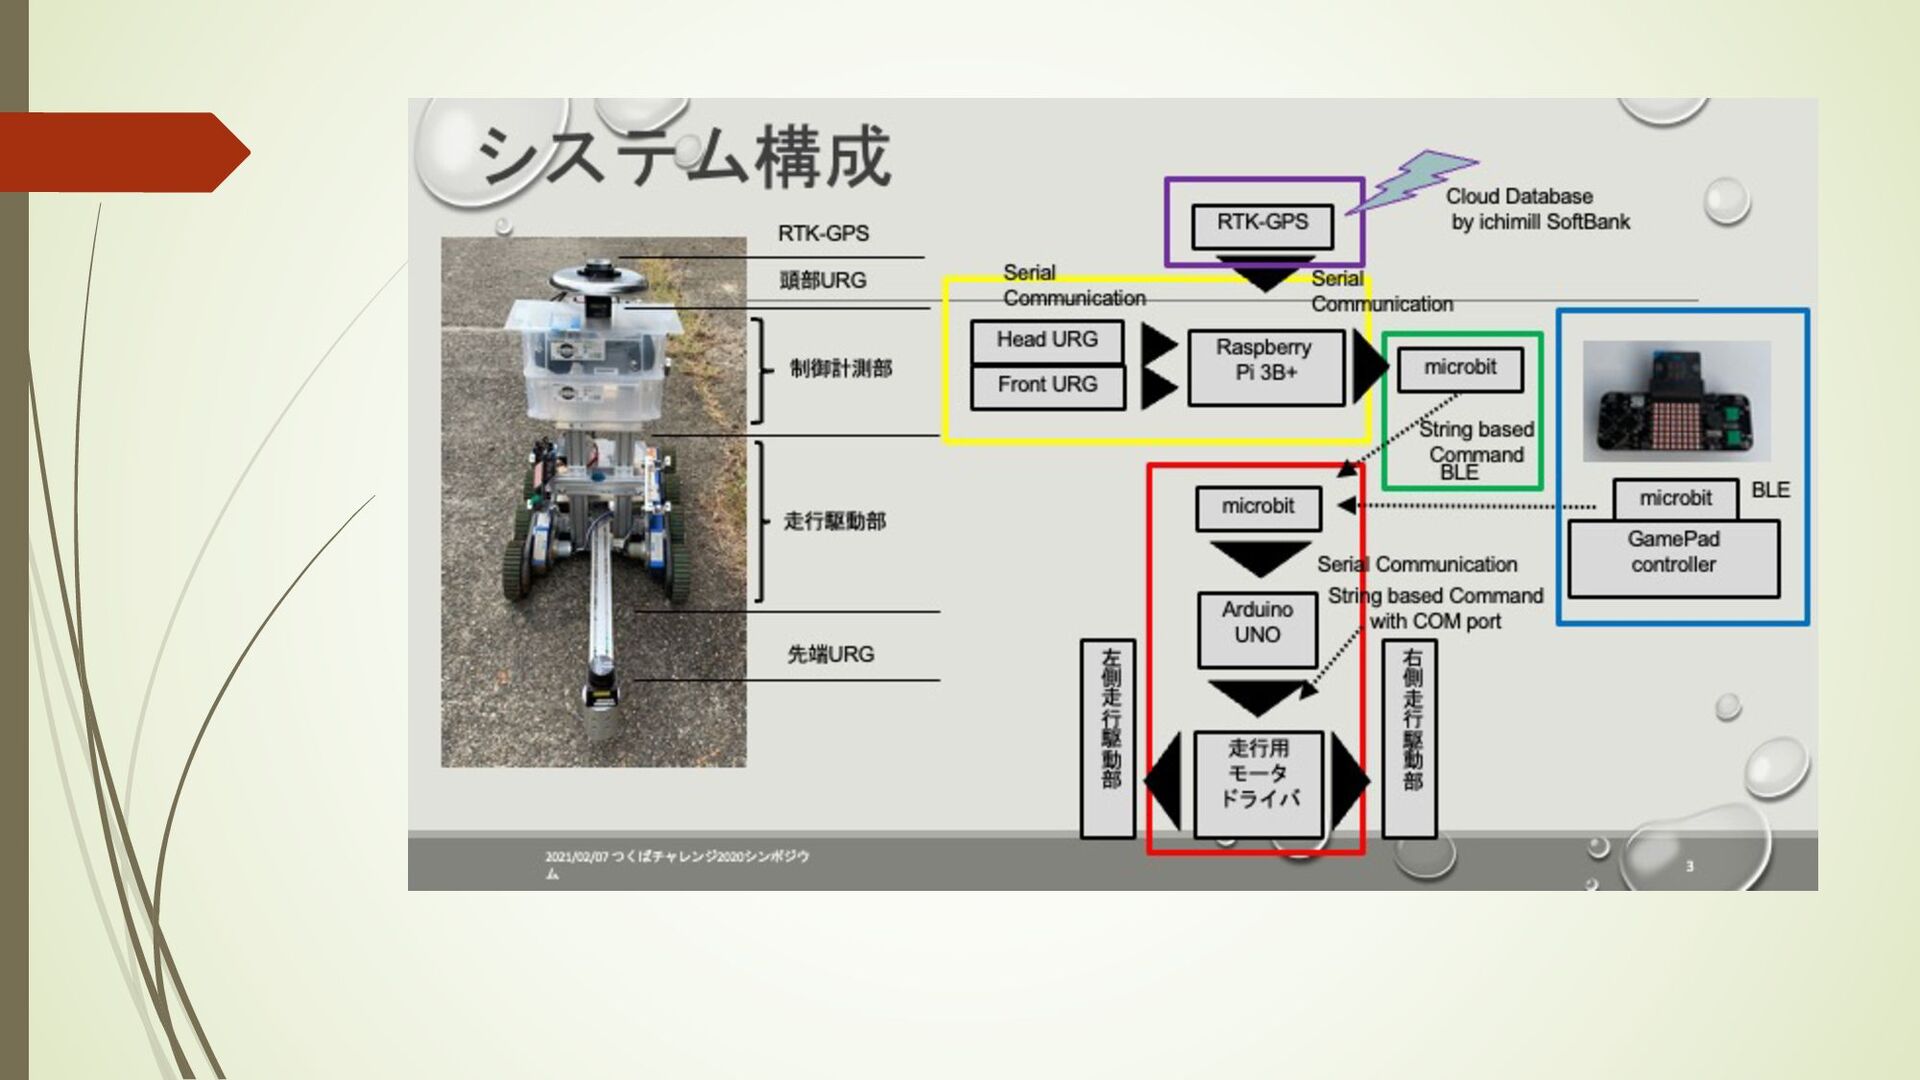
2020 つくばチャレンジ オンライン参加
None
None
None
None
2021 中之島チャレンジ 初参加 項⽬ 諸元 全⻑×全幅×全⾼ 550×540×720[mm] 重量 21.9[kg] コントローラ
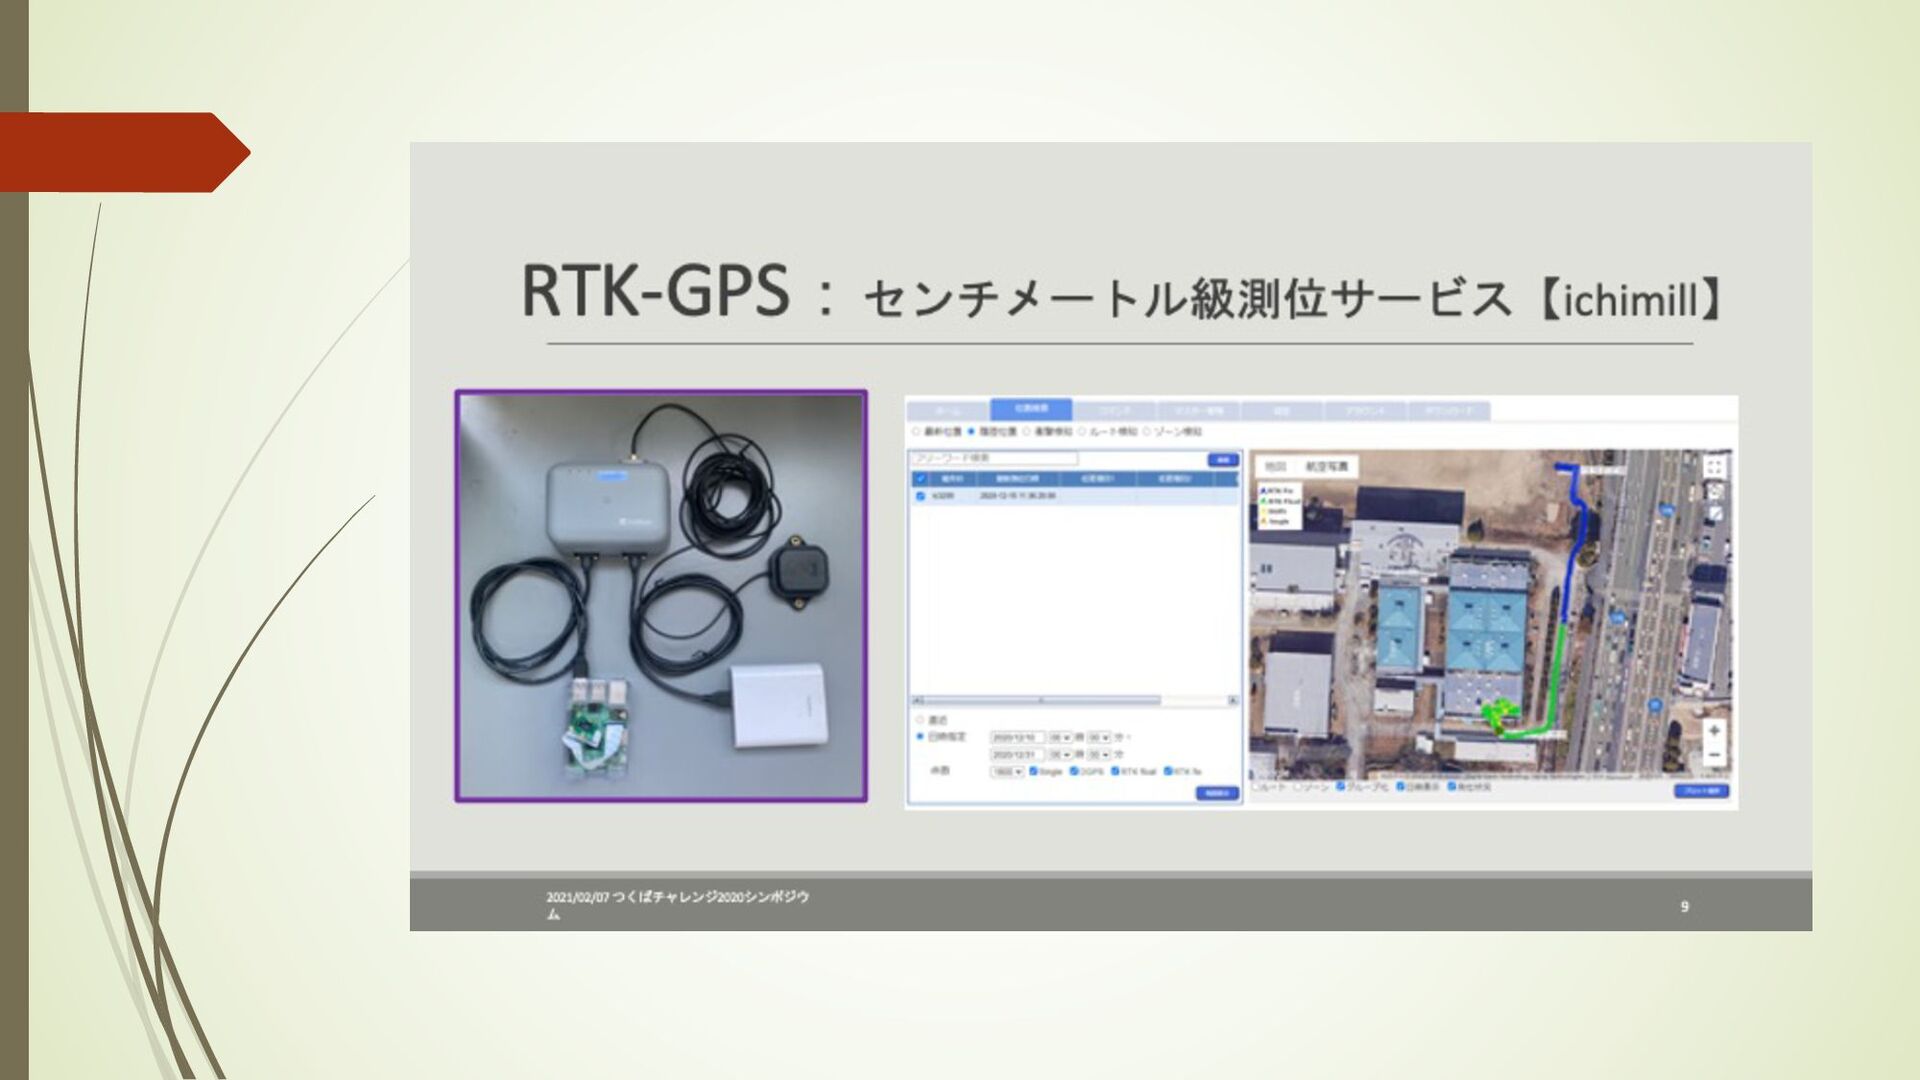
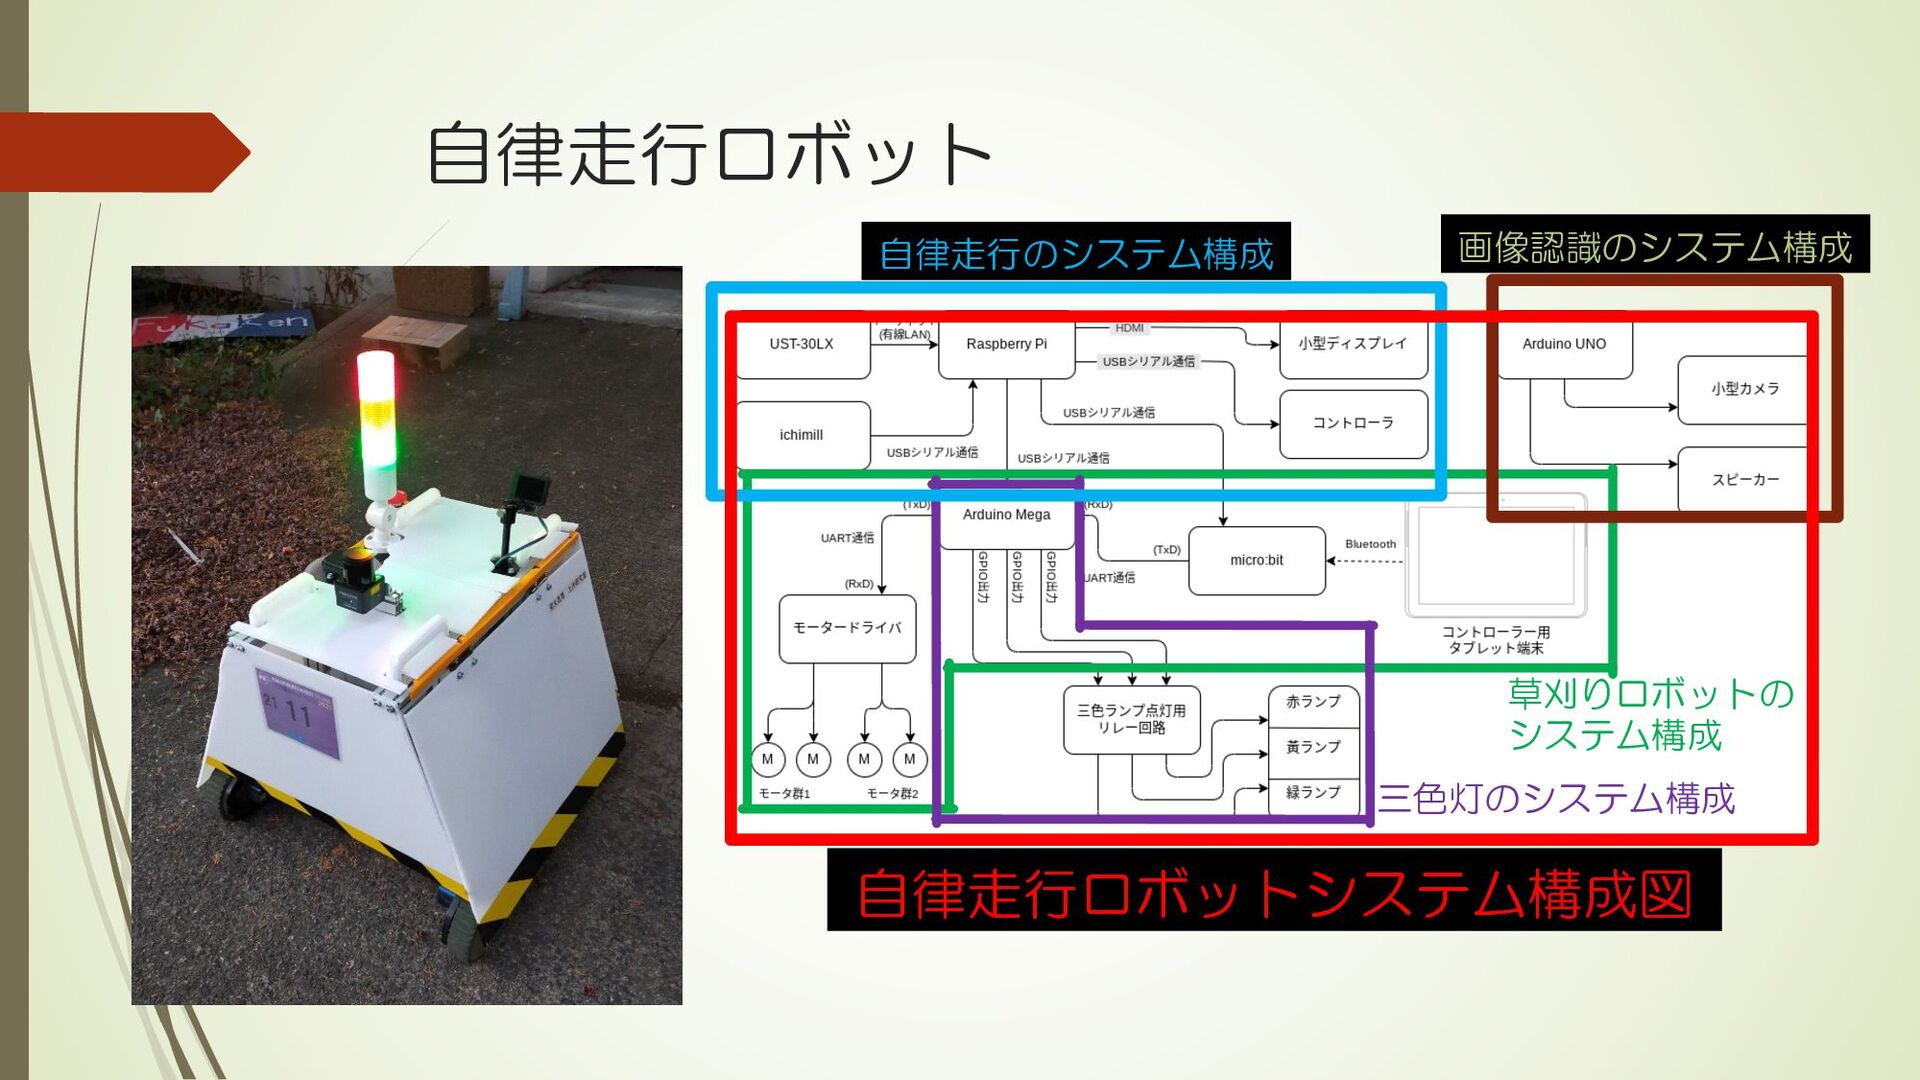
micro:bit(拡張基板), Androidタブレット, 有線USBコントローラ, Raspberry Pi(⾃律制御) マイコン micro:bit, Arduino,RaspberryPi 無線通信⽅法 Bluetooth GPS ichimill 2次元測位センサ UST-30LX 自律走行ロボット仕様
自律走行ロボット 自律走行ロボットシステム構成図 草刈りロボットの システム構成 三色灯のシステム構成 画像認識のシステム構成 自律走行のシステム構成
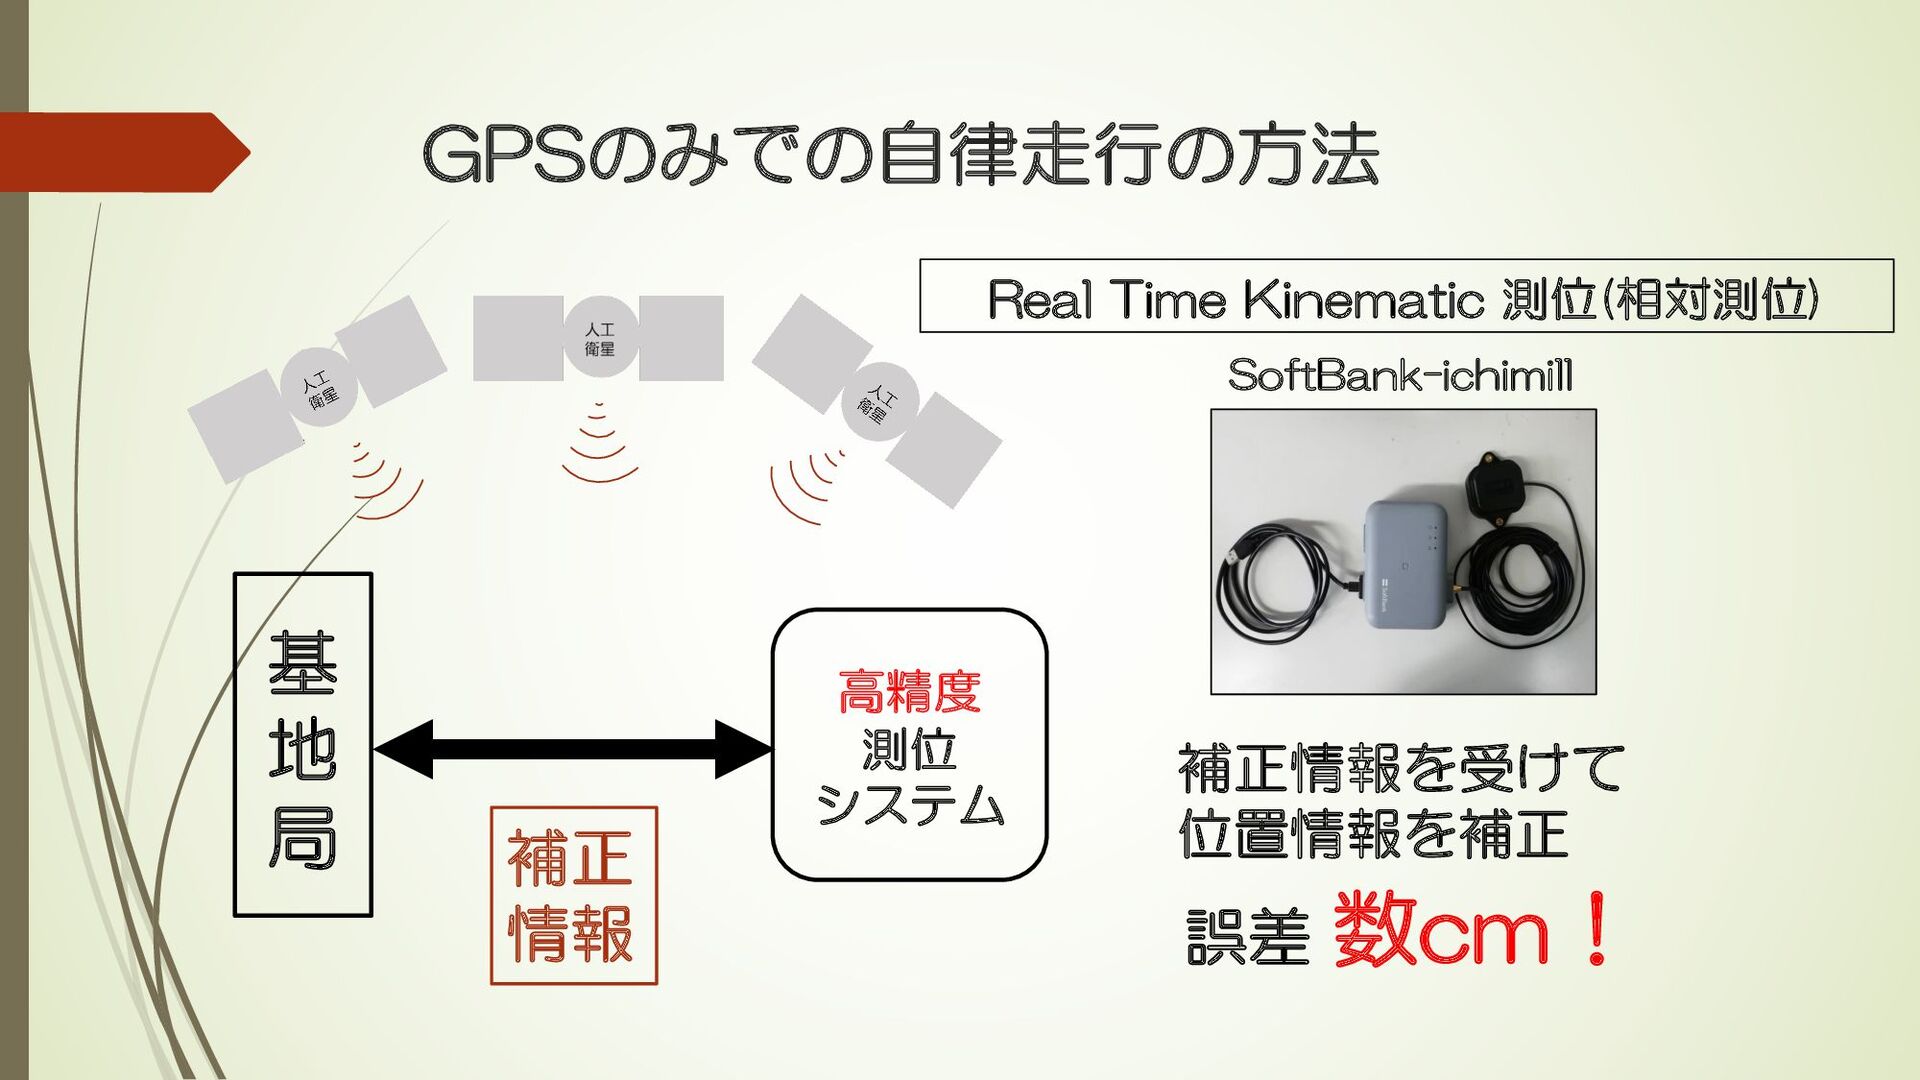
GPSのみでの自律走行の方法 高精度 測位 システム 基 地 局 補正 情報 Real
Time Kinematic 測位(相対測位) 誤差 数cm! SoftBank-ichimill 補正情報を受けて 位置情報を補正
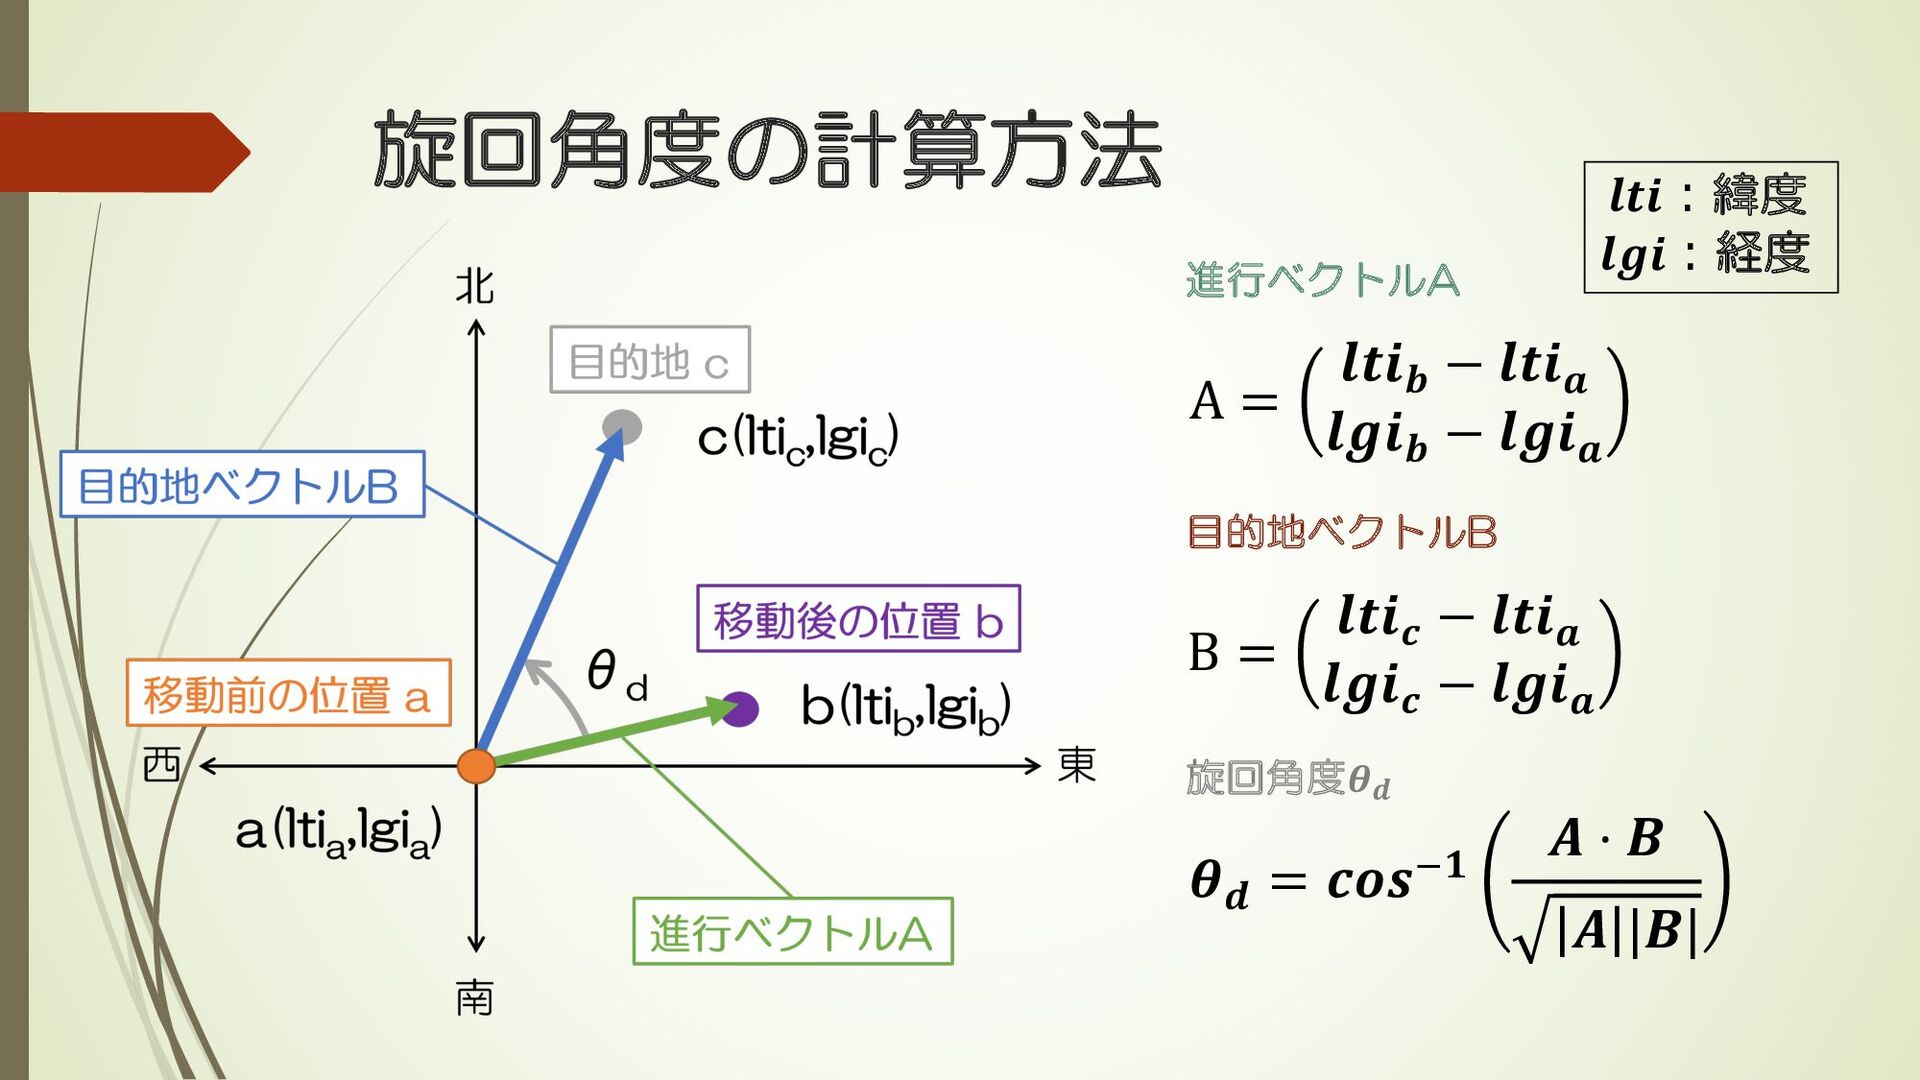
旋回角度の計算方法 進行ベクトルA A = 𝒍𝒕𝒊𝒃 − 𝒍𝒕𝒊𝒂 𝒍𝒈𝒊𝒃 − 𝒍𝒈𝒊𝒂
目的地ベクトルB B = 𝒍𝒕𝒊𝒄 − 𝒍𝒕𝒊𝒂 𝒍𝒈𝒊𝒄 − 𝒍𝒈𝒊𝒂 旋回角度𝜽𝒅 𝜽𝒅 = 𝒄𝒐𝒔&𝟏 𝑨 ⋅ 𝑩 𝑨 |𝑩| 𝒍𝒕𝒊︓緯度 𝒍𝒈𝒊︓経度
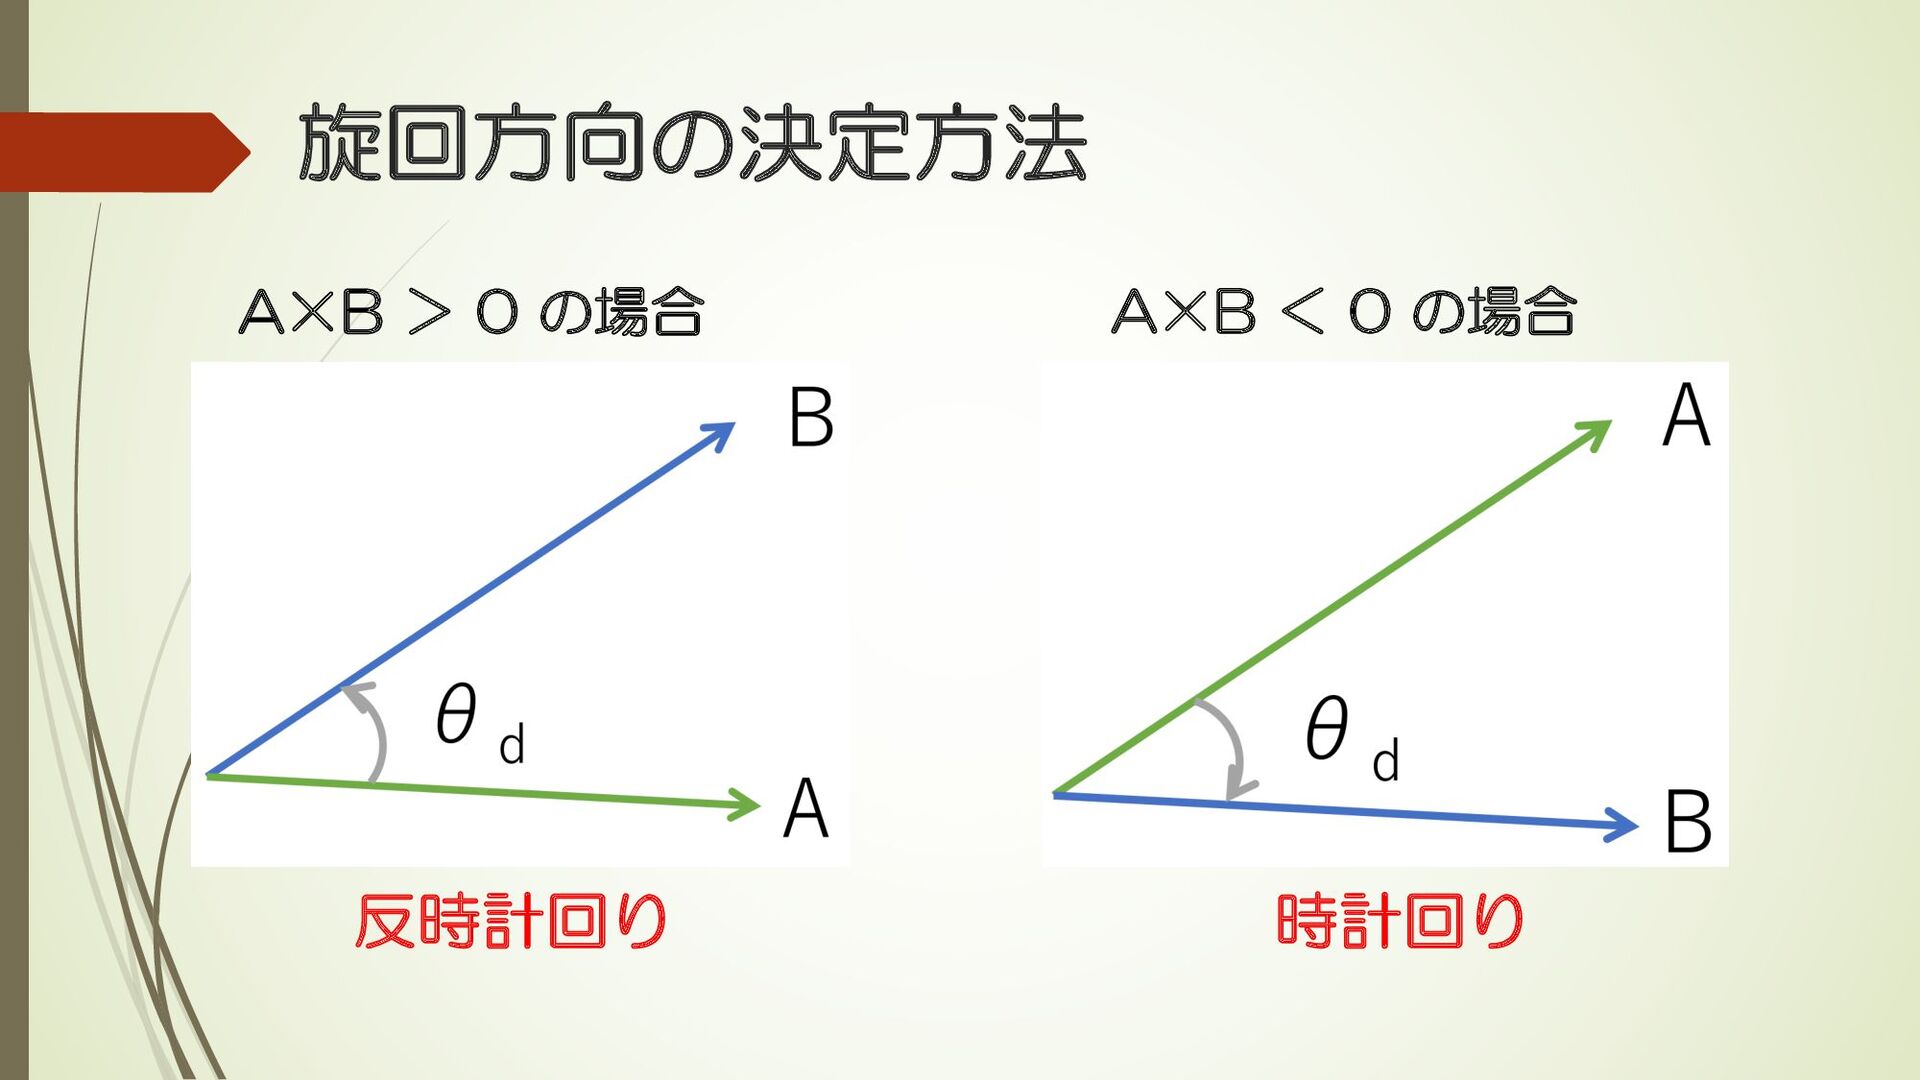
旋回方向の決定方法 A×B > 0 の場合 反時計回り A×B < 0 の場合
時計回り
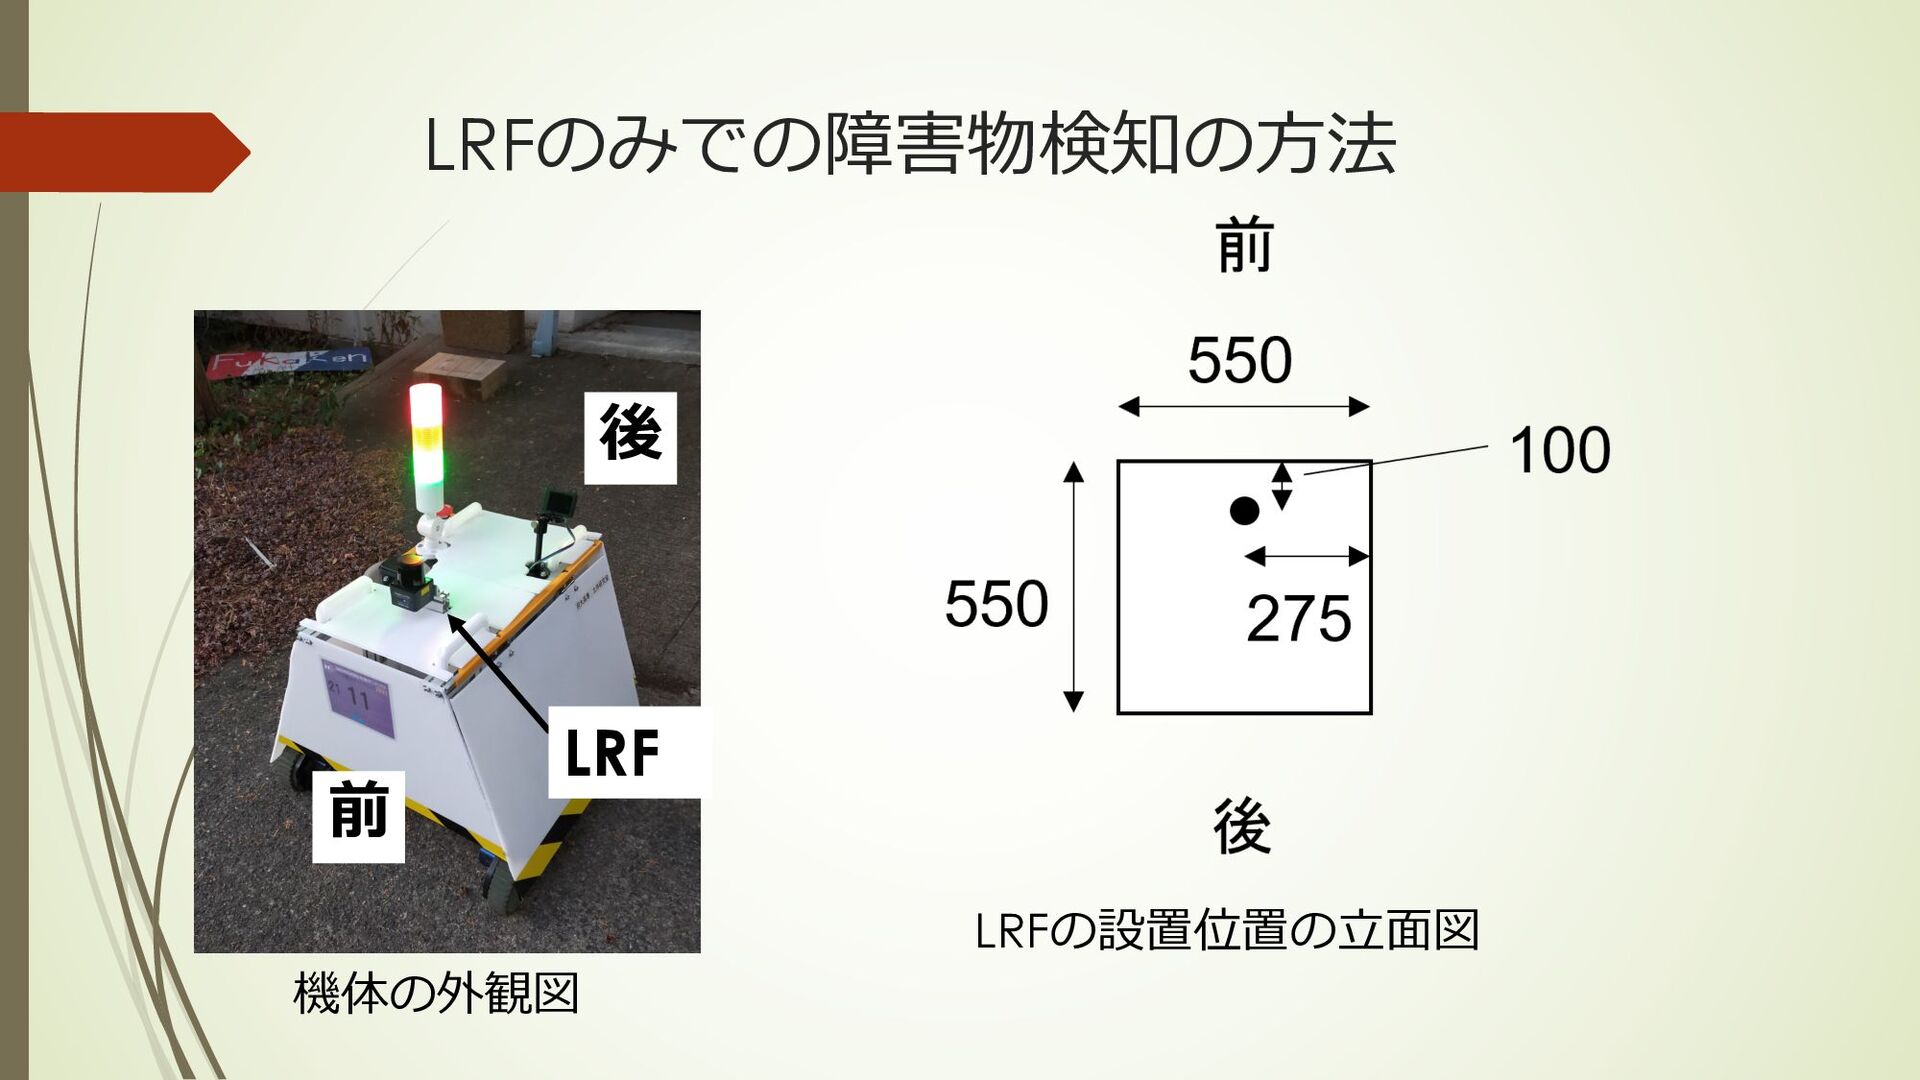
LRFのみでの障害物検知の⽅法 前 後 LRF LRFの設置位置の⽴⾯図 機体の外観図
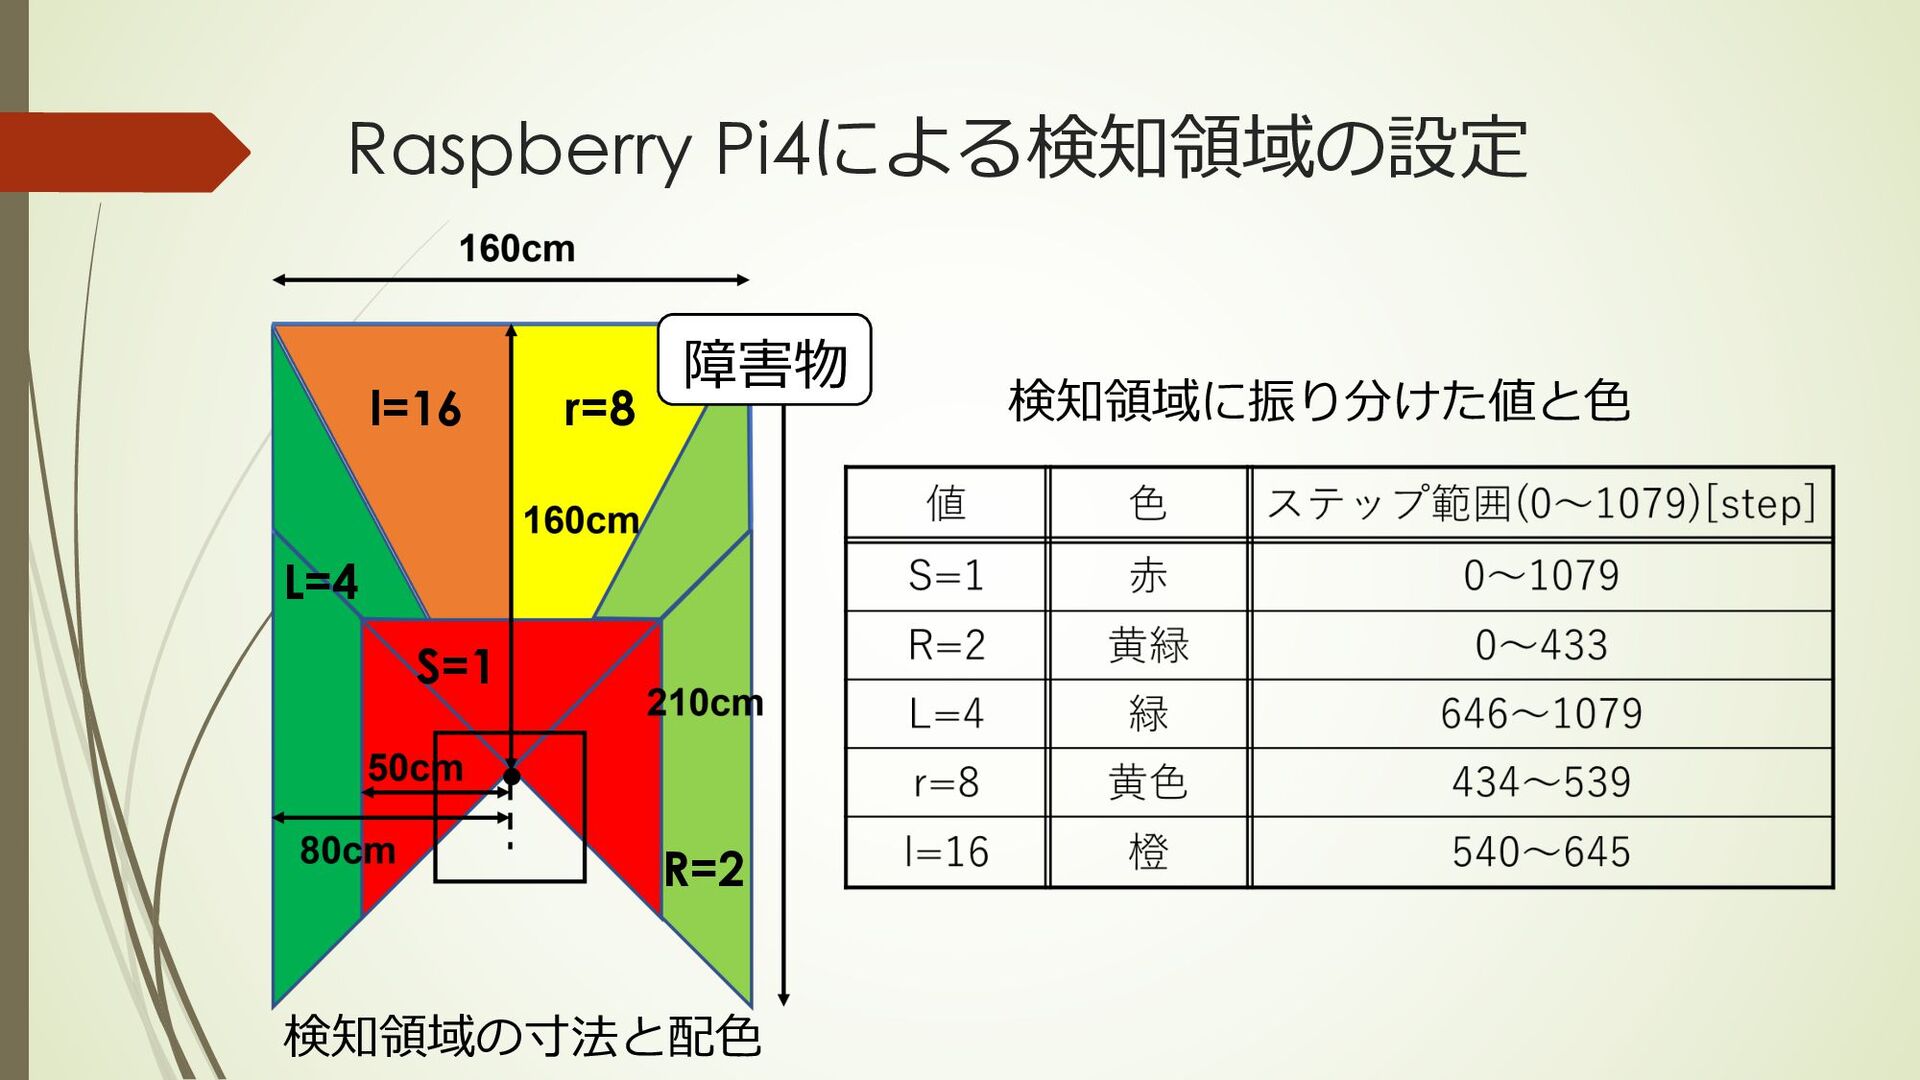
Raspberry Pi4による検知領域の設定 検知領域に振り分けた値と⾊ 検知領域の⼨法と配⾊ S=1 R=2 L=4 r=8 l=16 障害物
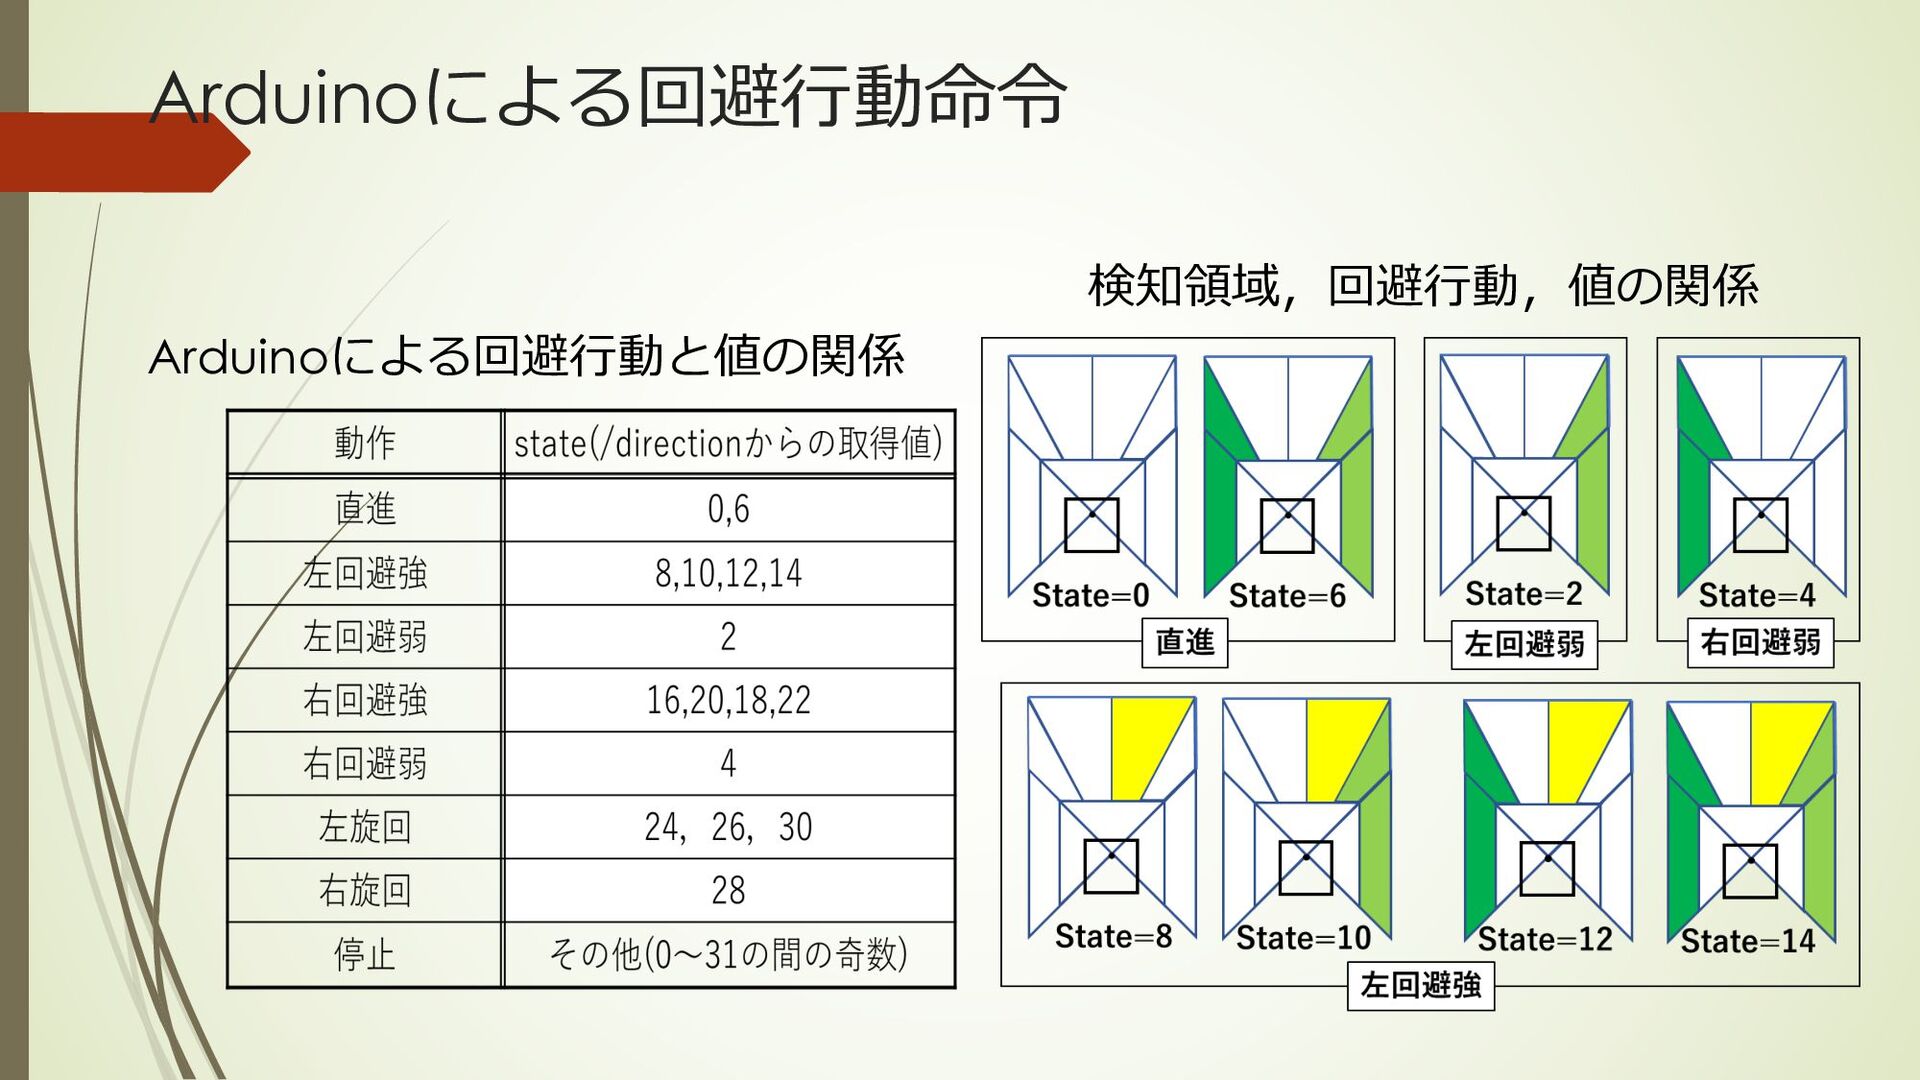
Arduinoによる回避⾏動命令 Arduinoによる回避⾏動と値の関係 検知領域,回避⾏動,値の関係
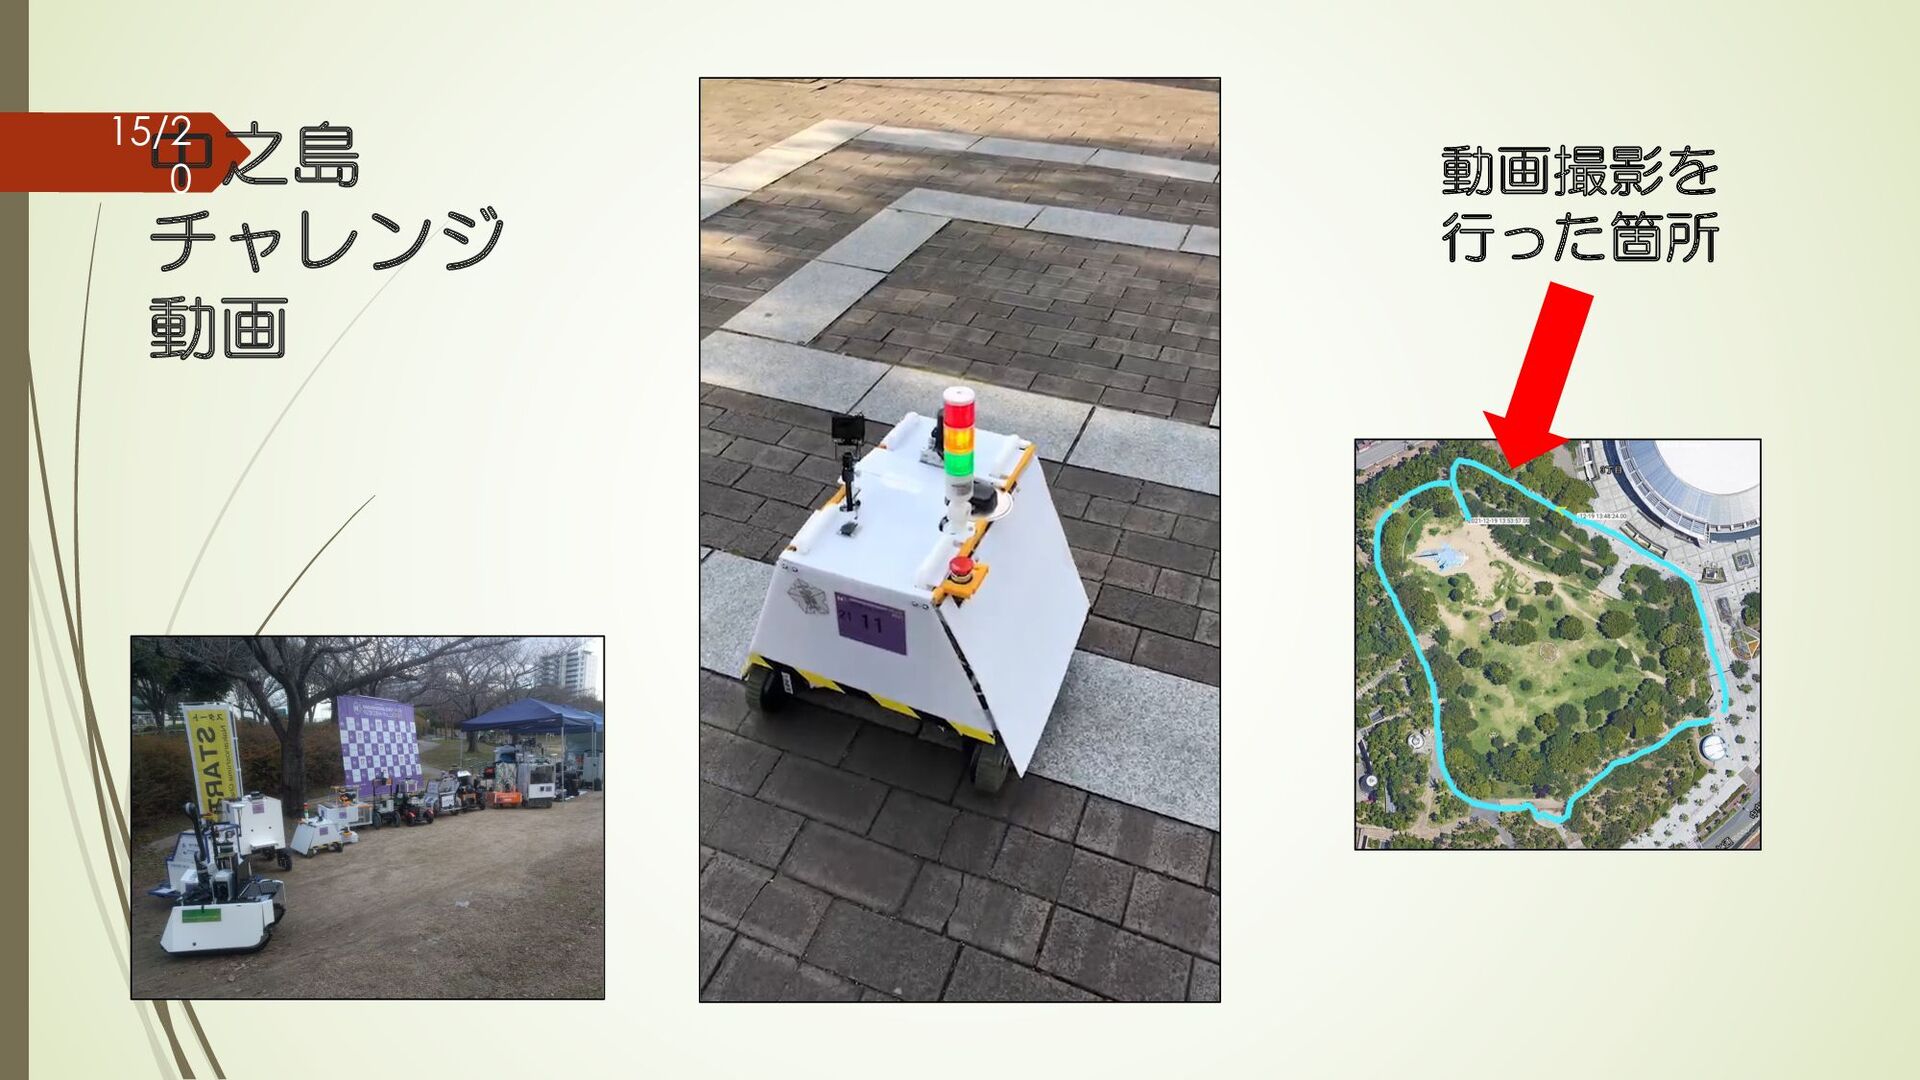
中之島 チャレンジ 動画 動画撮影を 行った箇所 15/2 0
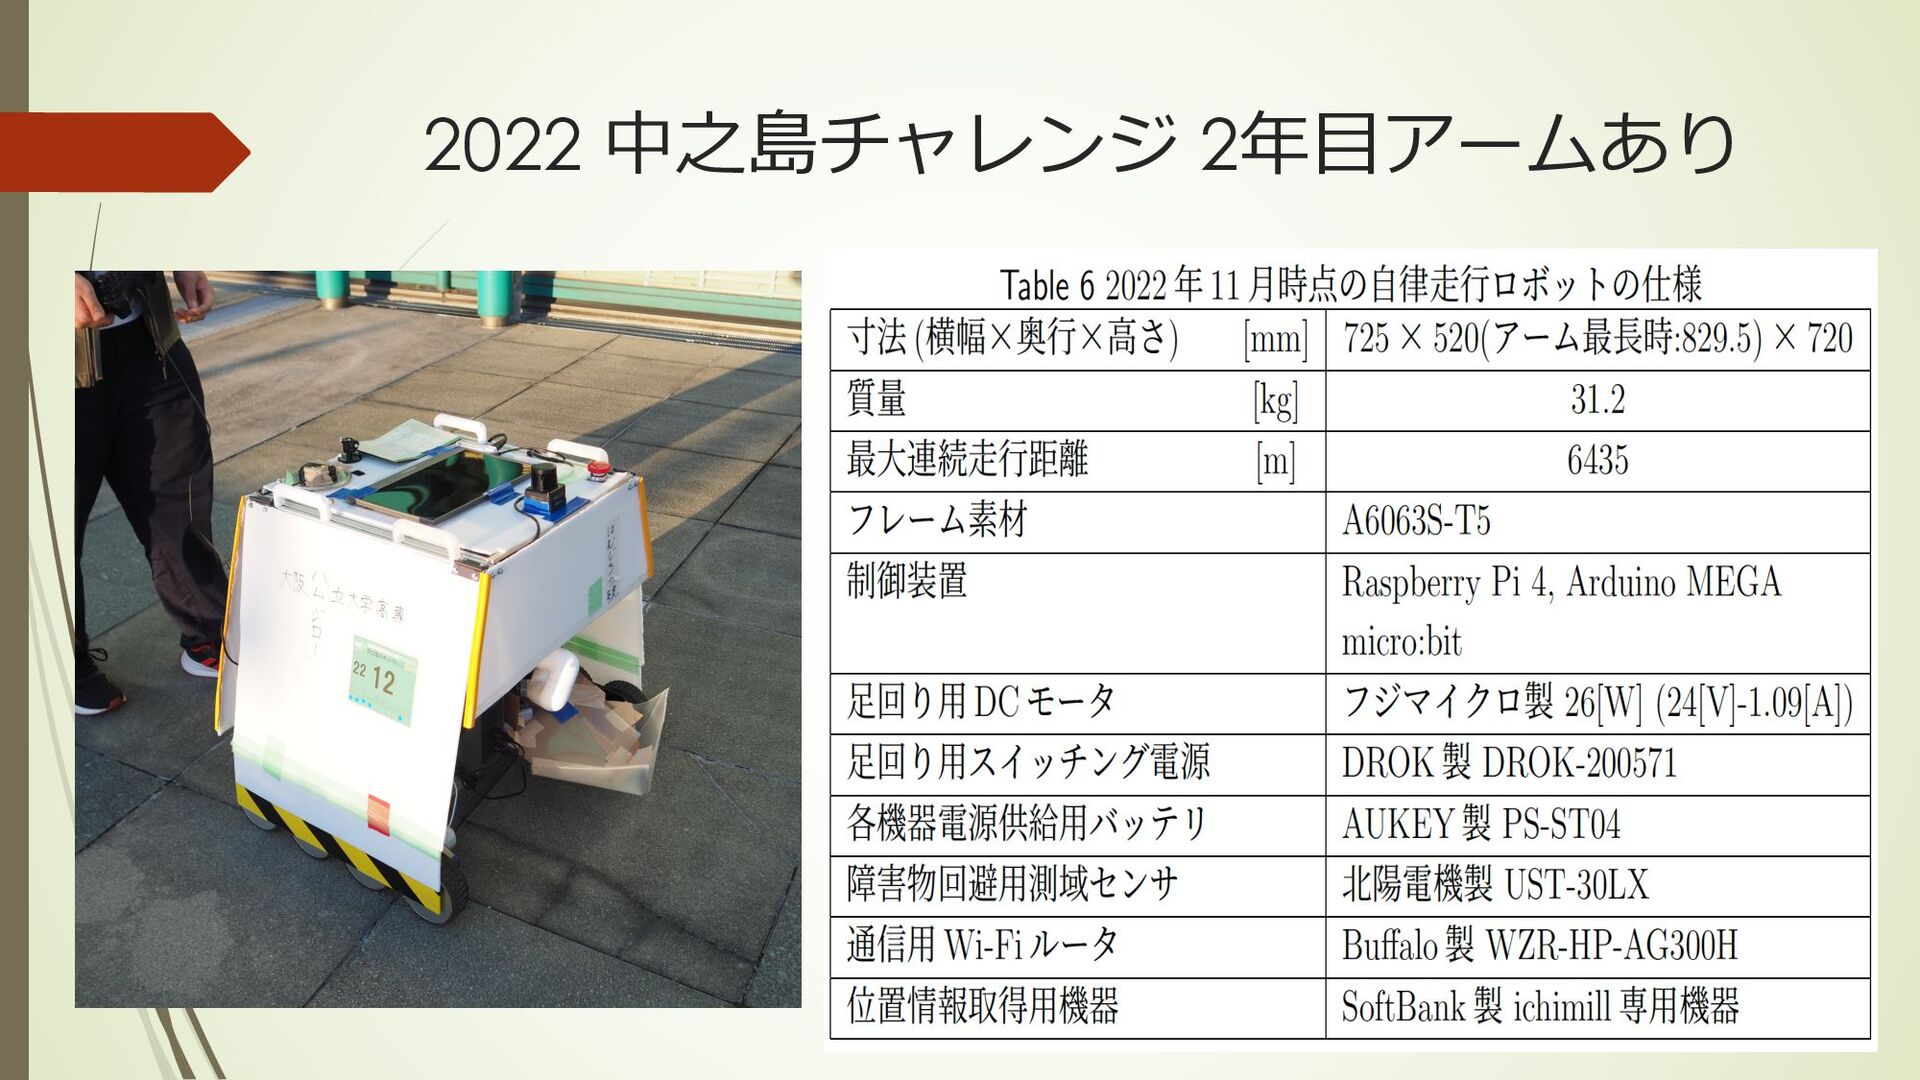
2022 中之島チャレンジ 2年⽬アームあり
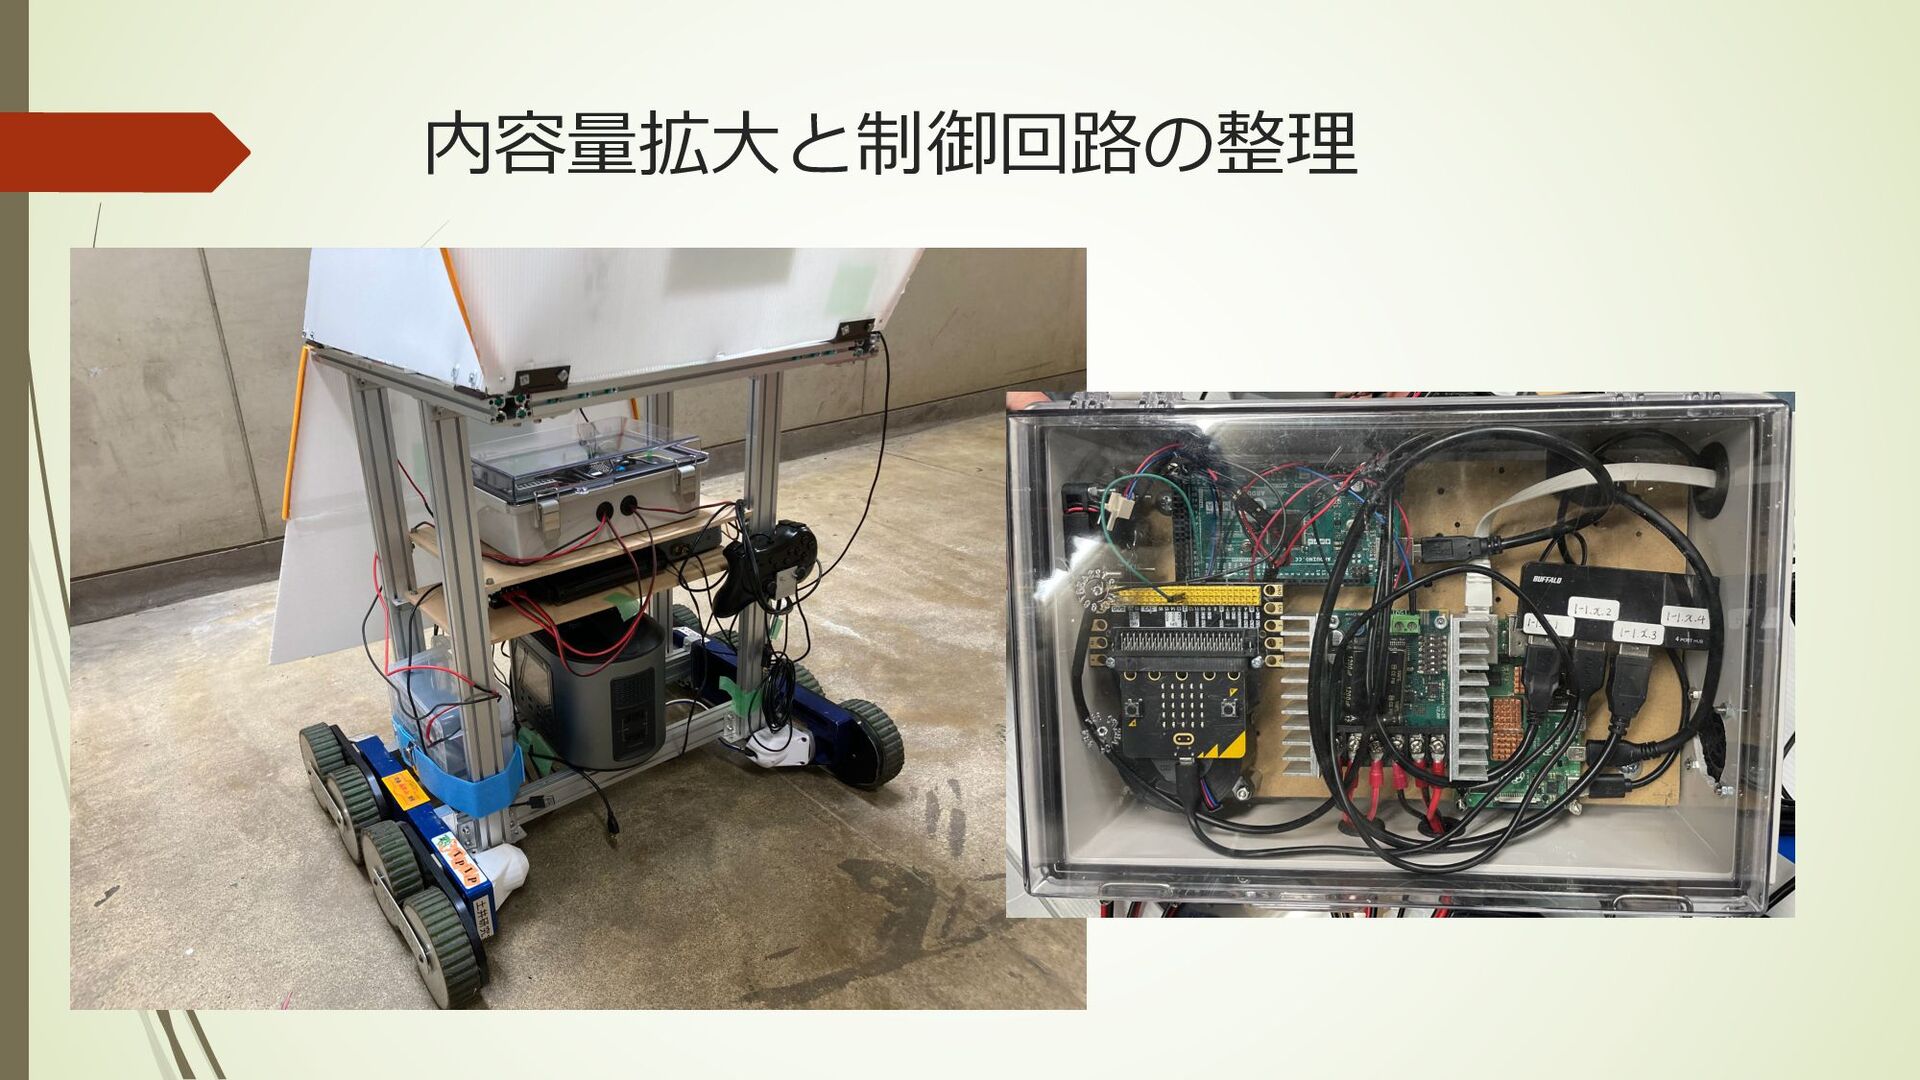
内容量拡⼤と制御回路の整理
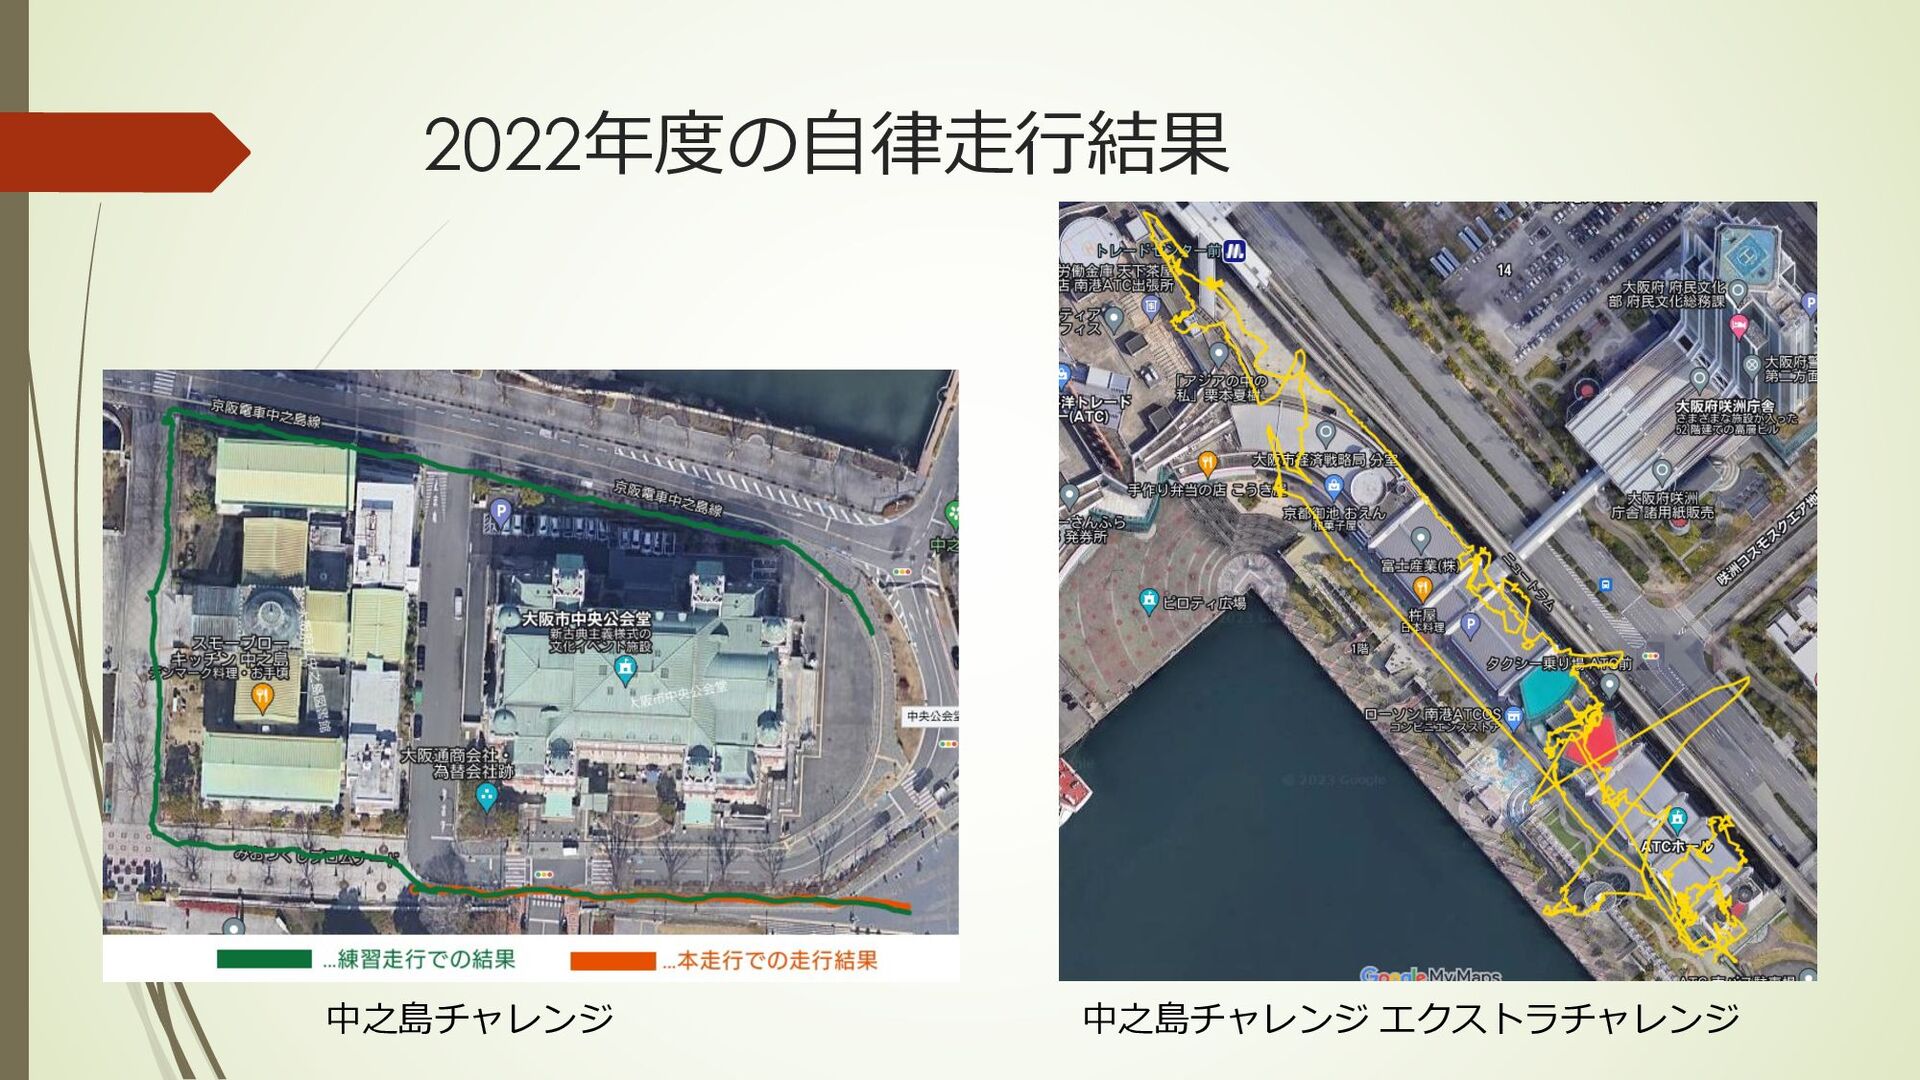
2022年度の⾃律⾛⾏結果 中之島チャレンジ 中之島チャレンジ エクストラチャレンジ
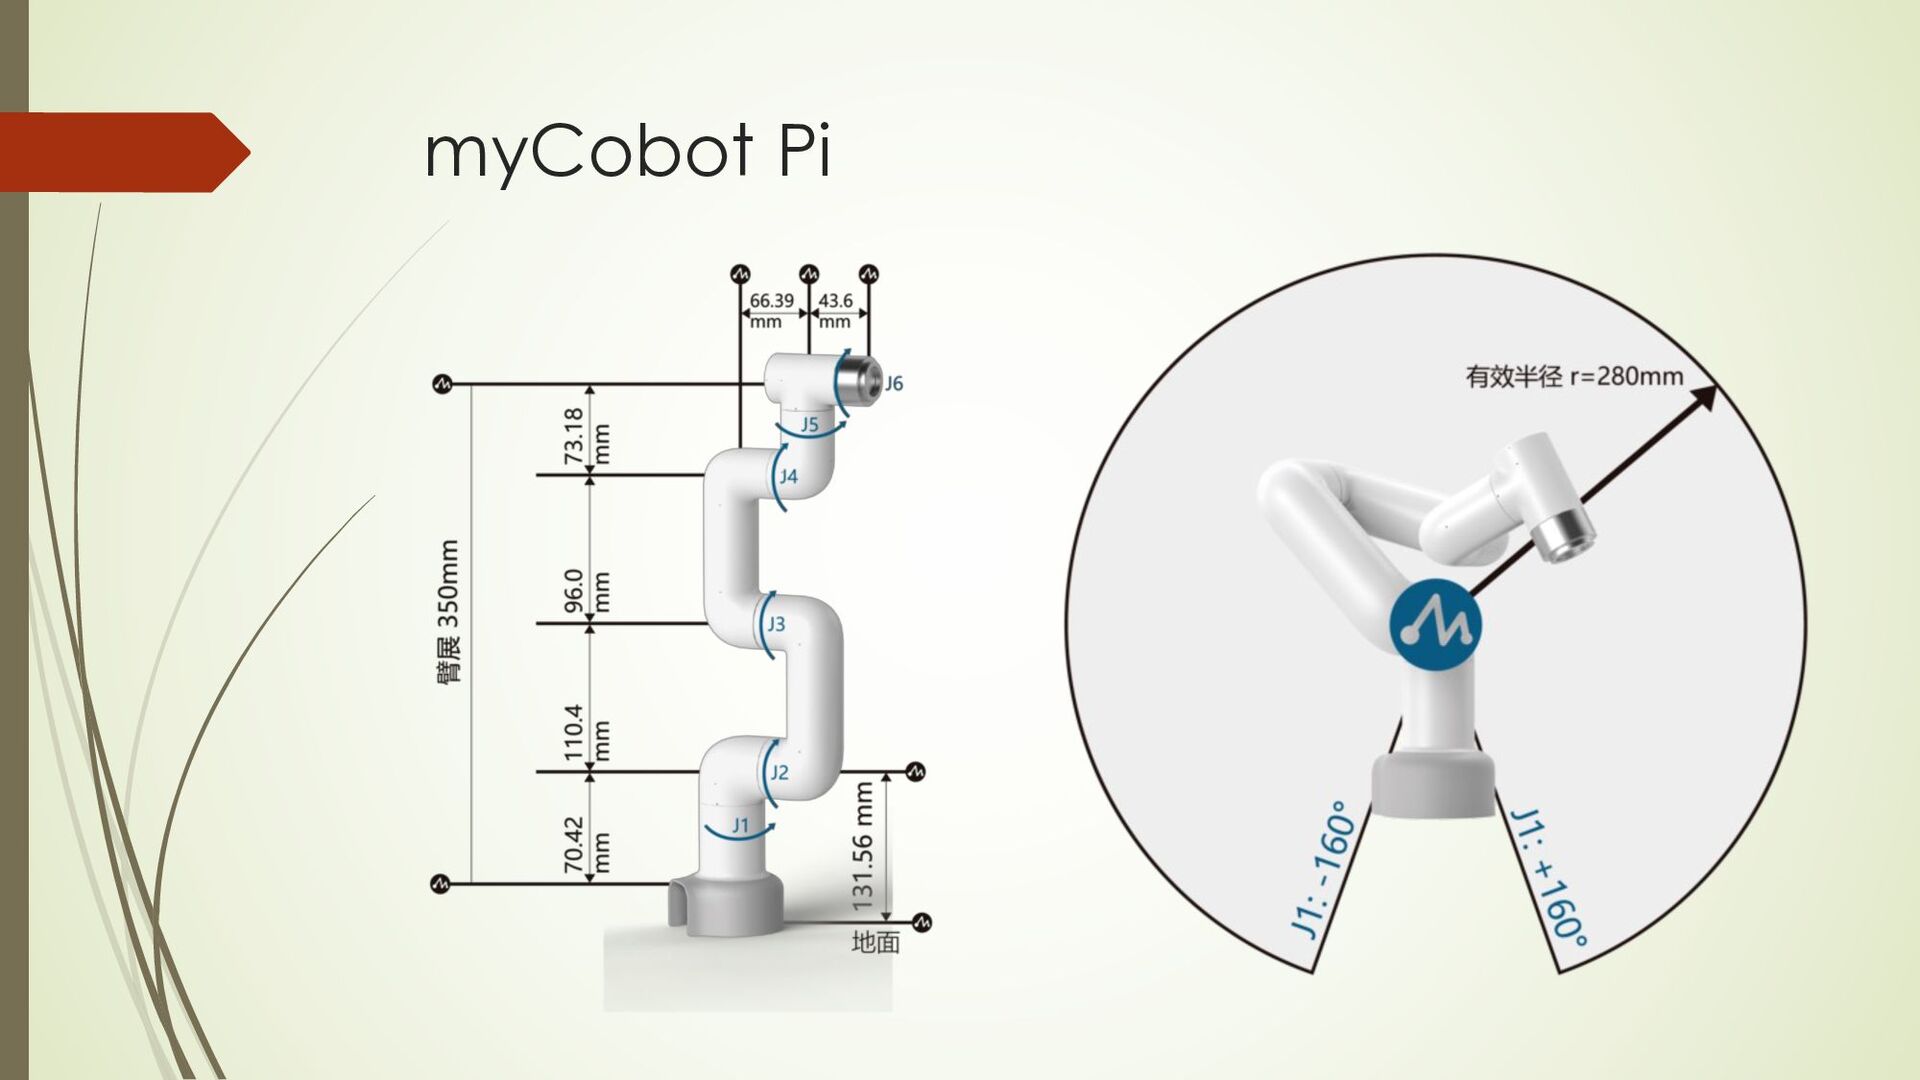
myCobot Pi
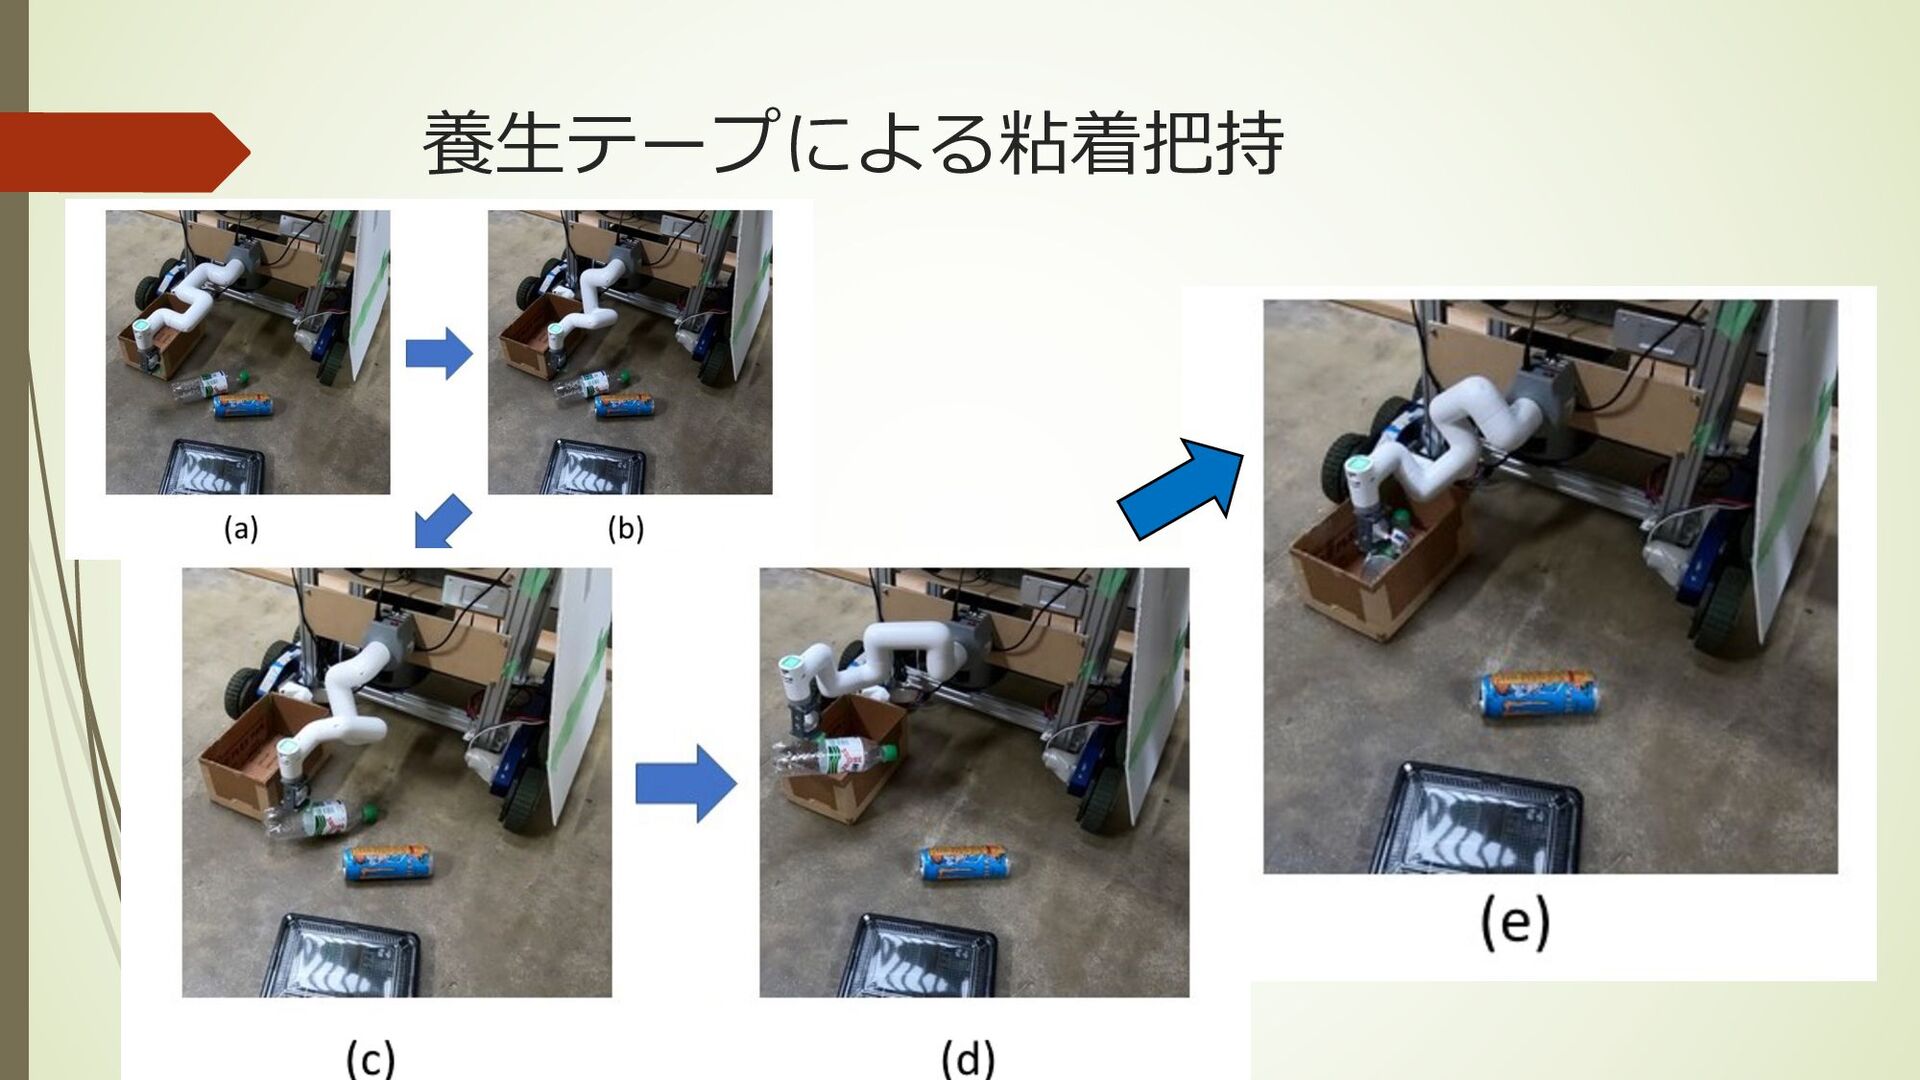
養⽣テープによる粘着把持
まとめ 1. 2020年度 つくチャレ 1. システムの構想を提⽰した 2. 2021年度 なかチャレ 1.
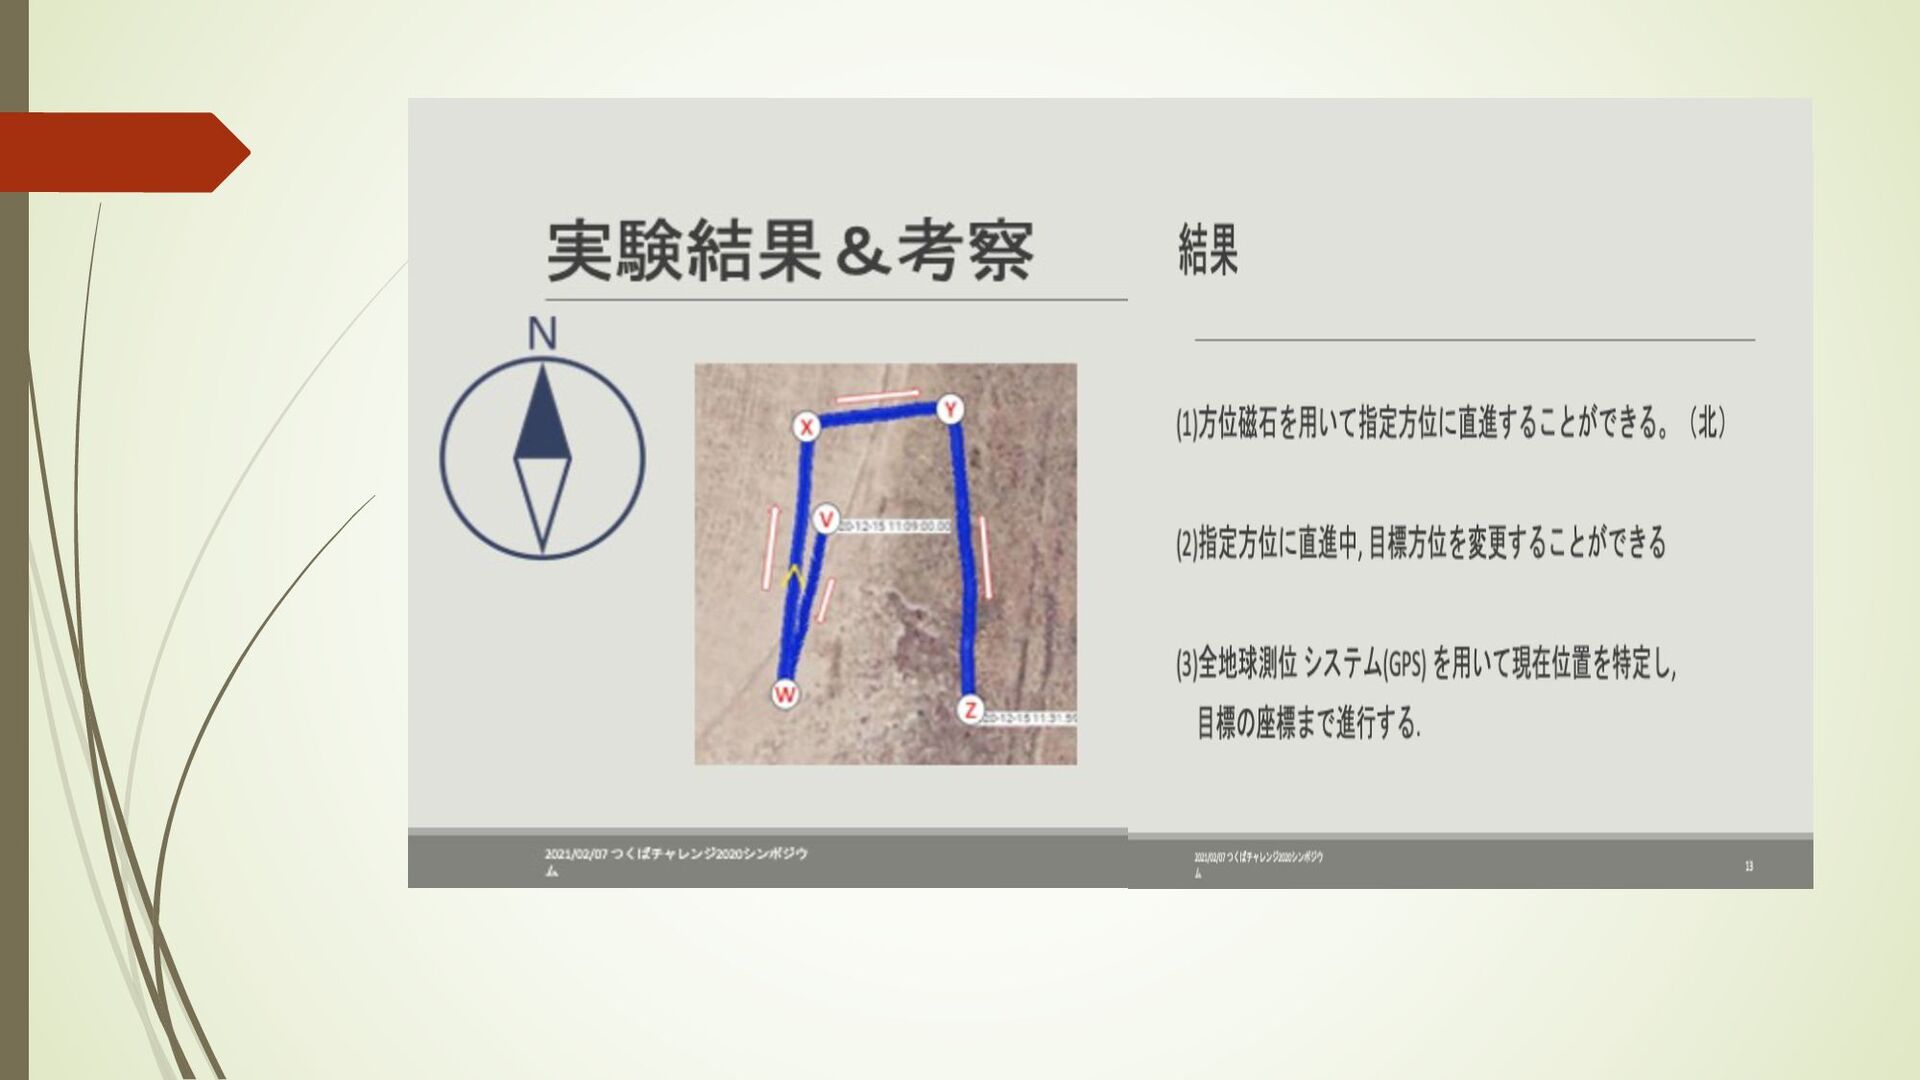
GPSとLRFで⾃律⾛⾏できた 3. 2022年度 なかチャレ 1. 屋内⾛⾏は現状システムでは難しい 2. アームを搭載して床のゴミ回収を確認した 4. 2023年度 なかチャレ 1. 新たなコンセプトで参加予定 2. ★⾃作の多脚ロボットを設計・試作中
More Decks by Tmhr_Doi
See All by Tmhr_Doi
Slide for Conference: TSUKUBA Challenge 2020
tmdoi
0
820
府大高専チームの現状・つくばチャレンジ2020第2回LT大会
tmdoi
0
1k
府大高専チーム自己紹介・つくばチャレンジ2020第1回LT大会
tmdoi
0
1k
Other Decks in Technology
See All in Technology
AI-DLCでソフトウェア開発の速さは 上がったのか?
rfdnxbro
0
150
AWS Well-Arhitected Frameworkセキュリティの柱 について
miu_crescent
PRO
2
260
みん強Lightning! データ基盤ひとりでできるかな
endonanana
0
200
ワークフローからハーネスへ — Web フレームワークの作者たちが AI エージェントに向かう理由
azukiazusa1
2
1.1k
Context parameters で作る!はじめての型クラス
kworkdev
PRO
1
180
Re:ゼロから始めるシェアハウスのペットな鯖
silmin_
0
270
メルカリの小規模チーム「Pod」で、 エンジニアがデータアナリストなしで、 AIを使ってデータ分析の自走を目指す取り組み
jackojacko_
1
350
新規事業開発でのAWS活用成功談&失敗談! 〜新規事業開発を専門に行うRelicならではのAWS活用〜
amixedcolor
1
140
NutanixへのSSHアクセスの今後について
shadowhat
0
170
Web Performance Is a Journey [PerfNow 2026]
tammyeverts
2
150
信頼性を犠牲にせず、PR マージからデプロイまで人の介入を完全にゼロにするまでの道のり
knwoop
4
2.1k
人の努力に頼らないセキュリティをエンジニアリングする在り方 / An approach to engineering security that does not rely on human effort
carta_engineering
0
240
Featured
See All Featured
Keith and Marios Guide to Fast Websites
keithpitt
413
23k
So, you think you're a good person
axbom
PRO
2
2.3k
Become a Pro
speakerdeck
PRO
31
6.4k
WENDY [Excerpt]
tessaabrams
15
41k
Automating Front-end Workflow
addyosmani
1370
210k
Data-driven link building: lessons from a $708K investment (BrightonSEO talk)
szymonslowik
1
1.5k
Accessibility Awareness
sabderemane
1
310
How to Create Impact in a Changing Tech Landscape [PerfNow 2023]
tammyeverts
56
3.5k
Raft: Consensus for Rubyists
vanstee
143
7.9k
Creating an realtime collaboration tool: Agile Flush - .NET Oxford
marcduiker
35
2.6k
The Organizational Zoo: Understanding Human Behavior Agility Through Metaphoric Constructive Conversations (based on the works of Arthur Shelley, Ph.D)
kimpetersen
PRO
0
550
GraphQLの誤解/rethinking-graphql
sonatard
75
12k


 tmdoi
 rfdnxbro
 miu_crescent
 endonanana
 azukiazusa1
 kworkdev
 silmin_
 jackojacko_
 amixedcolor
 shadowhat
 tammyeverts
 knwoop
 carta_engineering
 keithpitt
 axbom
 speakerdeck
 tessaabrams
 addyosmani
 szymonslowik
 sabderemane
 vanstee
 marcduiker
 kimpetersen
 sonatard