Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
Physical computing with GPIO Zero - Peterboroug...
Search
Sponsored
·
Your Podcast. Everywhere. Effortlessly.
Share. Educate. Inspire. Entertain. You do you. We'll handle the rest.
→
Ben Nuttall
November 24, 2015
Programming
6.8k
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
Physical computing with GPIO Zero - Peterborough coding evening
GPIO Zero talk given at Peterborough coding evening
Ben Nuttall
November 24, 2015
More Decks by Ben Nuttall
See All by Ben Nuttall
Numeronyms are obnoxious
bennuttall
1
760
Live Highlights in BBC iPlayer
bennuttall
0
190
Rapid prototyping in BBC News with Python and AWS
bennuttall
0
250
Rapid prototyping in BBC News with Python and AWS
bennuttall
0
190
Running a Python Package Index for Raspberry Pi
bennuttall
0
210
From Acorns to Raspberries
bennuttall
0
180
Innovation in the newsroom
bennuttall
0
240
Innovation in the newsroom - MOS Running Order Manager
bennuttall
0
260
How to market your open source project
bennuttall
0
300
Other Decks in Programming
See All in Programming
更なる可用性を求めて、5年間運用したKotlinのアプリケーションをGoでリプレイスする話
ken_tunc
0
430
なぜCTOを降りてFDEを選んだのか?〜なぜプロダクト企業がFDEで顧客の現場に踏み込むのか〜
gonta
1
130
Security issues being discussed on Web Platforms
petamoriken
0
1.4k
動作中のプログラムの中身をリアルタイムに覗く / Realtime Debugger for CSharp with Roslyn
prota
1
1.7k
20260914 AIエージェント時代のPlatform Engineering LLM基盤とプロダクトの責務境界線
kanfab1
7
2.4k
巨大モノリシックアプリ モダン化大作戦
ktcryomm
1
1.3k
iOSDC2026登壇資料.pdf
riofujimon
0
200
Unity6 URPによる海底をテーマにしたVJシステムの解説 | Unity Shader 完全に理解した 勉強会
gam0022
0
310
Apple Intelligence を用いた個人情報誤送信防止、及びユーザーリクエスト体験の改善について
yukiny
0
290
Java 27新機能 / Java 27 new features
kishida
2
190
マイコン向けの軽量Ruby「PicoRuby」で各種デバイスを制御するネイティブアプリの実現手法
bash0c7
0
470
JPUG勉強会 OSSデータベースの内部構造を理解しよう(第2回)
oga5
0
290
Featured
See All Featured
The Cult of Friendly URLs
andyhume
79
7k
技術選定の審美眼(2025年版) / Understanding the Spiral of Technologies 2025 edition
twada
PRO
120
120k
Are puppies a ranking factor?
jonoalderson
2
4k
The Limits of Empathy - UXLibs8
cassininazir
1
700
Lightning Talk: Beautiful Slides for Beginners
inesmontani
PRO
2
710
GraphQLとの向き合い方2022年版
quramy
50
15k
The AI Search Optimization Roadmap by Aleyda Solis
aleyda
2
6.3k
Dominate Local Search Results - an insider guide to GBP, reviews, and Local SEO
greggifford
PRO
0
350
A Modern Web Designer's Workflow
chriscoyier
699
190k
Why Your Marketing Sucks and What You Can Do About It - Sophie Logan
marketingsoph
0
420
I Don’t Have Time: Getting Over the Fear to Launch Your Podcast
jcasabona
35
2.9k
Build The Right Thing And Hit Your Dates
maggiecrowley
39
3.5k
Transcript
Physical computing with GPIO Zero Ben Nuttall Raspberry Pi Foundation
UK Charity 1129409
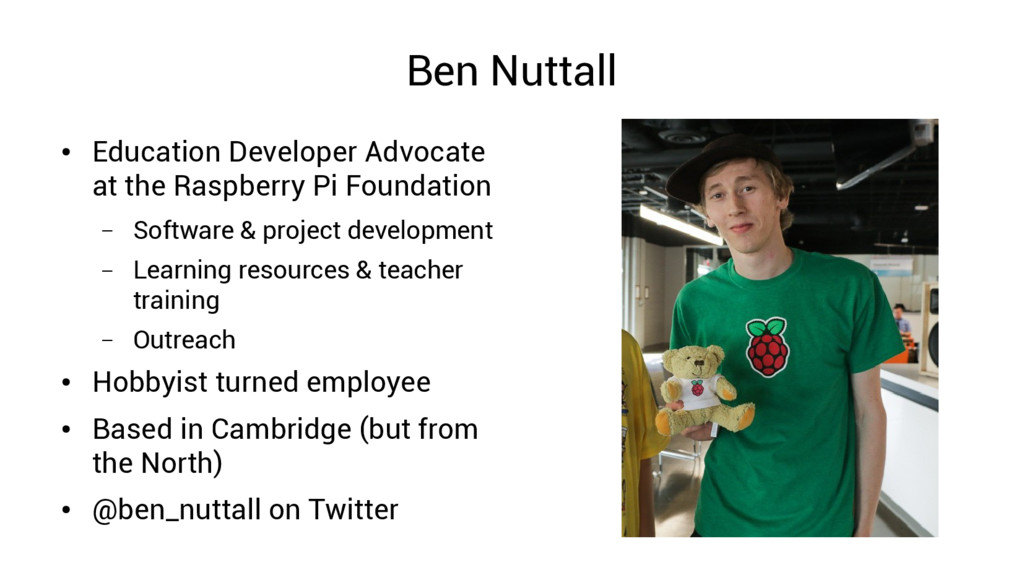
Ben Nuttall • Education Developer Advocate at the Raspberry Pi
Foundation – Software & project development – Learning resources & teacher training – Outreach • Hobbyist turned employee • Based in Cambridge (but from the North) • @ben_nuttall on Twitter
Python – RPi.GPIO import RPi.GPIO as GPIO from time import
sleep GPIO.setmode(GPIO.BCM) GPIO.setwarnings(False) led = 17 GPIO.setup(led, GPIO.OUT) while True: GPIO.output(led, True) sleep(1) GPIO.output(led, False) sleep(1)
Python – GPIO Zero from gpiozero import LED from time
import sleep led = LED(17) while True: led.on() sleep(1) led.off() sleep(1)
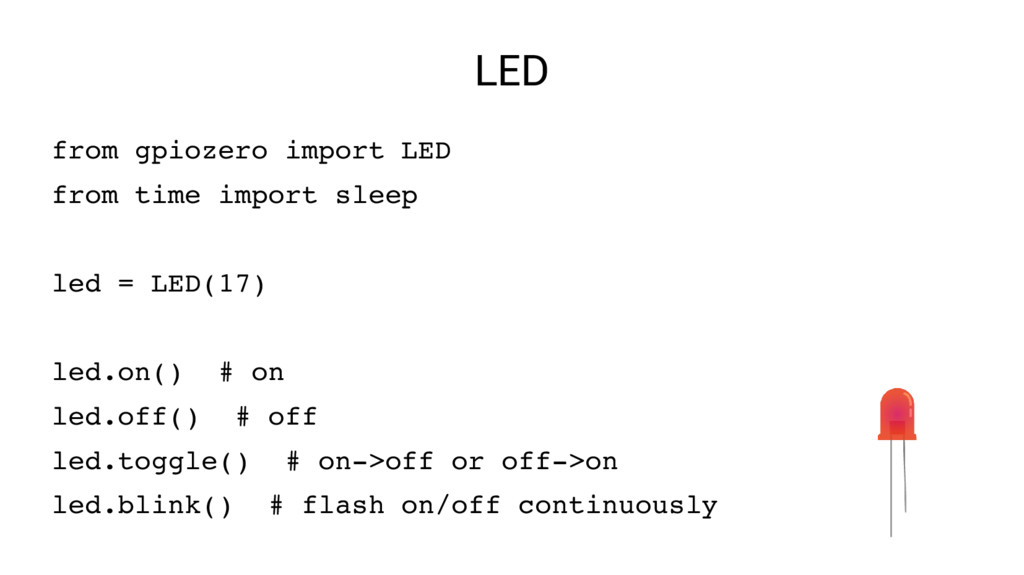
LED from gpiozero import LED from time import sleep led
= LED(17) led.on() # on led.off() # off led.toggle() # on>off or off>on led.blink() # flash on/off continuously
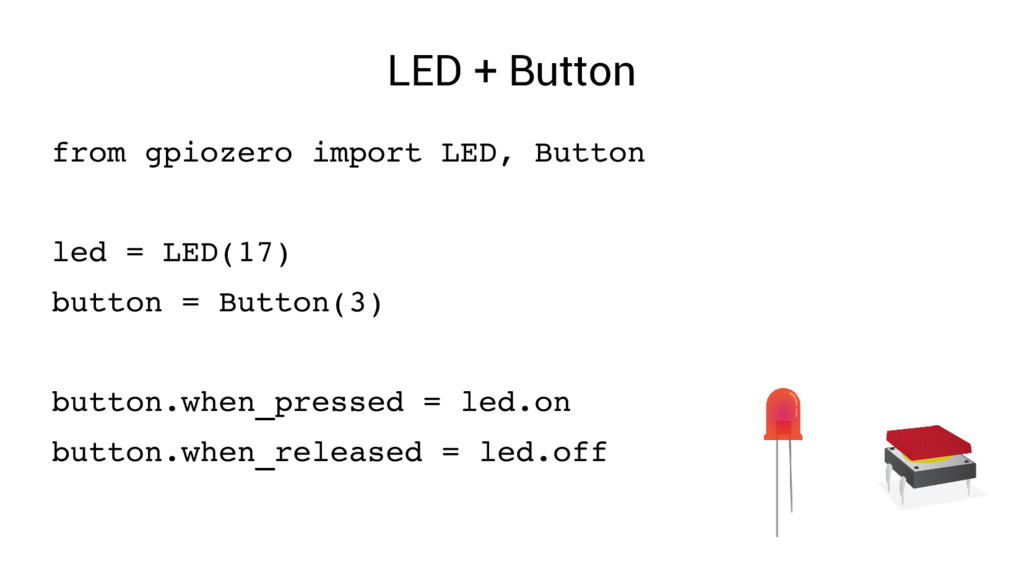
LED + Button from gpiozero import LED, Button led =
LED(17) button = Button(3) button.when_pressed = led.on button.when_released = led.off
Source + Values from gpiozero import LED, Button led =
LED(17) button = Button(3) led.source = button.values
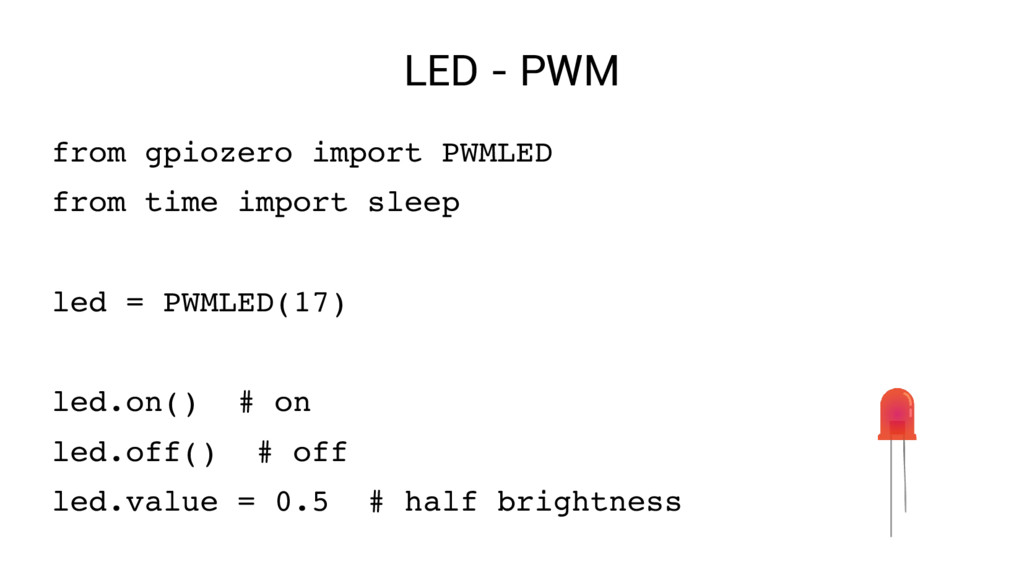
LED - PWM from gpiozero import PWMLED from time import
sleep led = PWMLED(17) led.on() # on led.off() # off led.value = 0.5 # half brightness
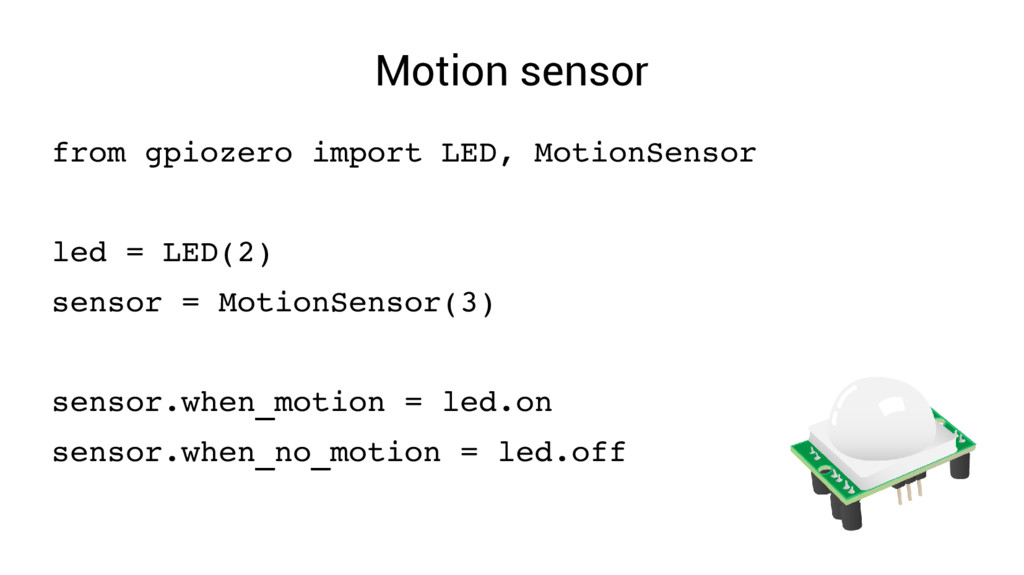
Motion sensor from gpiozero import LED, MotionSensor led = LED(2)
sensor = MotionSensor(3) sensor.when_motion = led.on sensor.when_no_motion = led.off
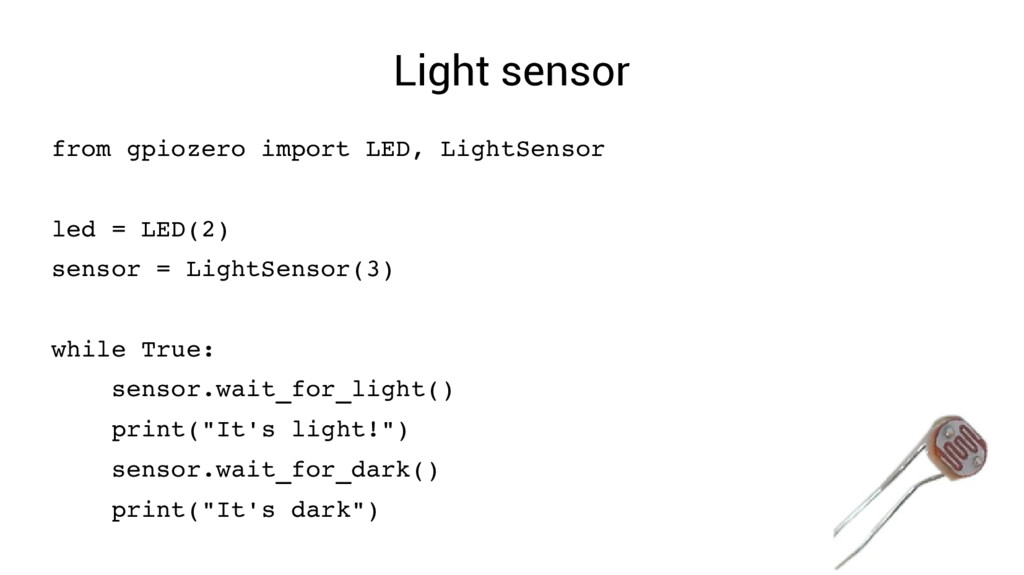
Light sensor from gpiozero import LED, LightSensor led = LED(2)
sensor = LightSensor(3) while True: sensor.wait_for_light() print("It's light!") sensor.wait_for_dark() print("It's dark")
Traffic Lights from gpiozero import TrafficLights lights = TrafficLights(9, 10,
11) lights.on() # all on lights.off() # all off lights.red.on() # red on lights.toggle() # swap state of all lights
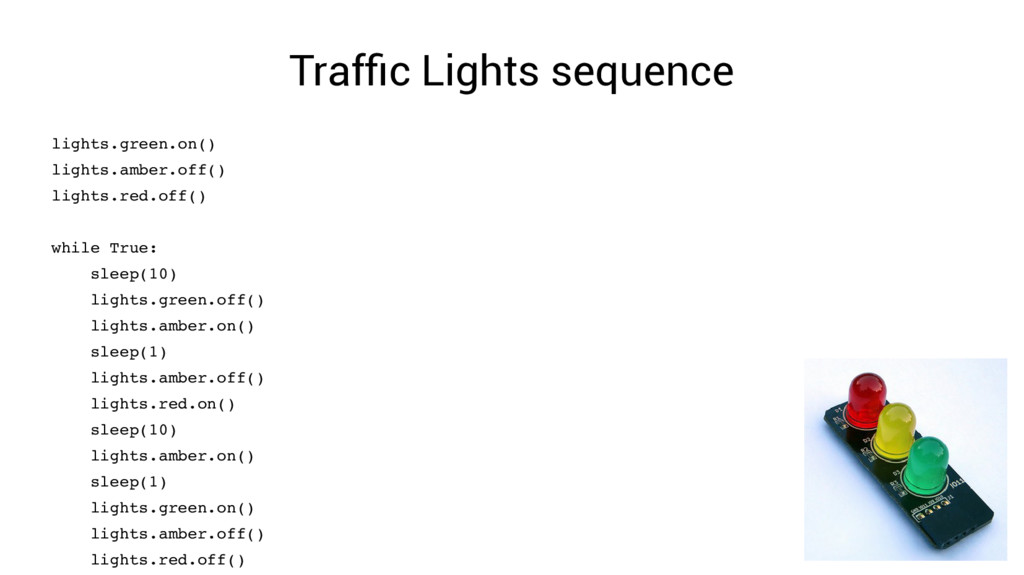
Traffic Lights sequence lights.green.on() lights.amber.off() lights.red.off() while True: sleep(10) lights.green.off()
lights.amber.on() sleep(1) lights.amber.off() lights.red.on() sleep(10) lights.amber.on() sleep(1) lights.green.on() lights.amber.off() lights.red.off()
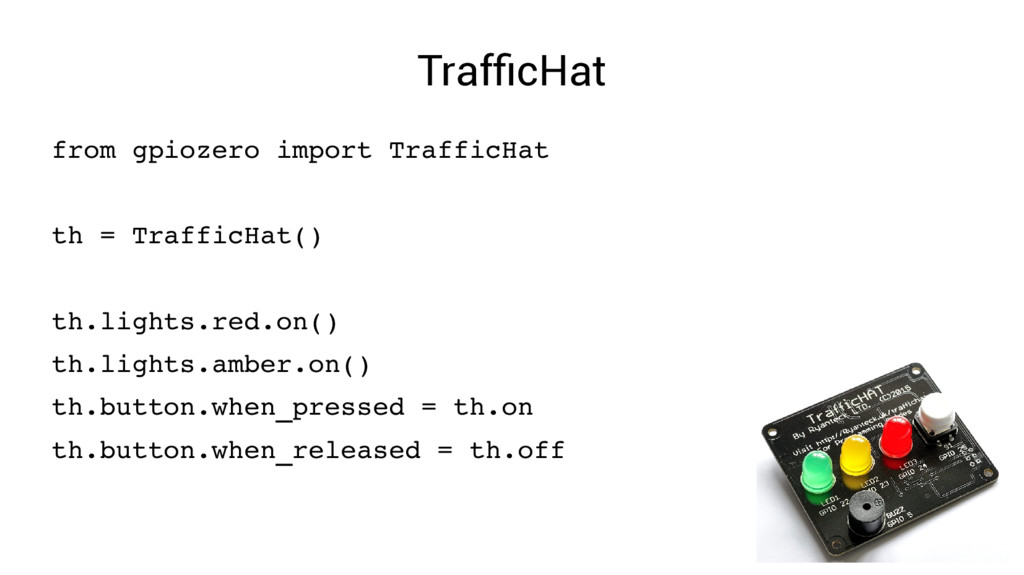
TrafficHat from gpiozero import TrafficHat th = TrafficHat() th.lights.red.on() th.lights.amber.on()
th.button.when_pressed = th.on th.button.when_released = th.off
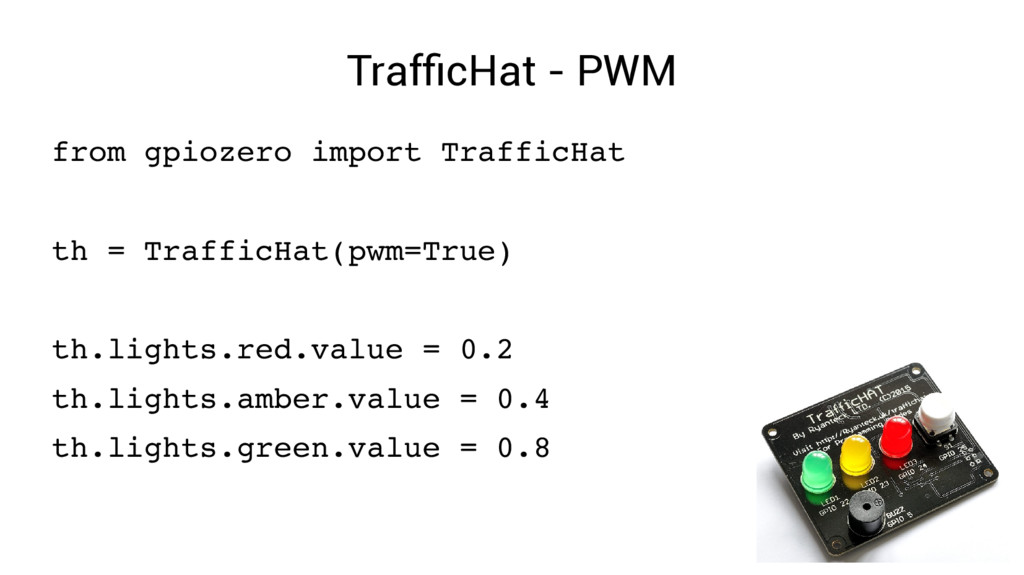
TrafficHat - PWM from gpiozero import TrafficHat th = TrafficHat(pwm=True)
th.lights.red.value = 0.2 th.lights.amber.value = 0.4 th.lights.green.value = 0.8
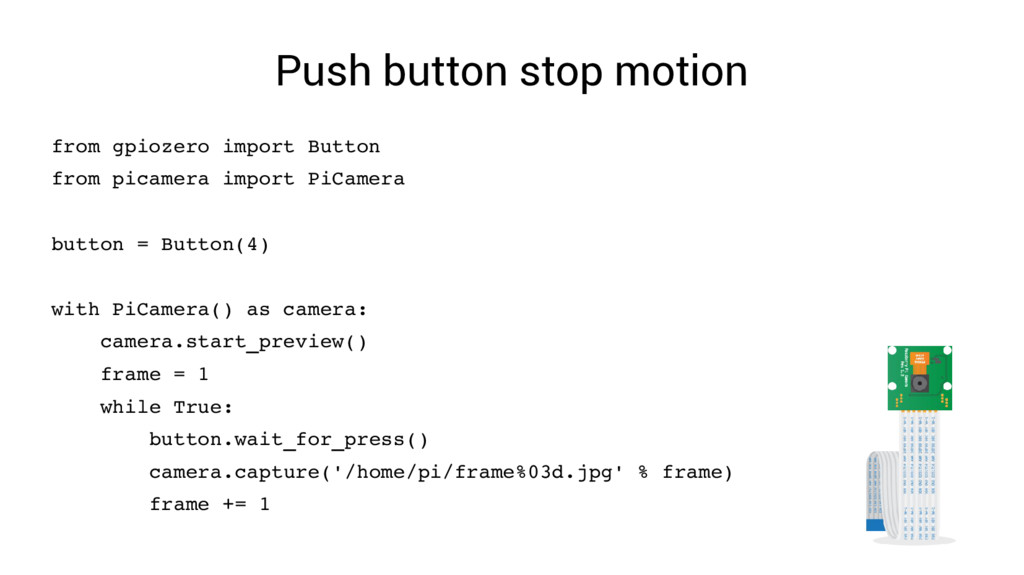
Push button stop motion from gpiozero import Button from picamera
import PiCamera button = Button(4) with PiCamera() as camera: camera.start_preview() frame = 1 while True: button.wait_for_press() camera.capture('/home/pi/frame%03d.jpg' % frame) frame += 1
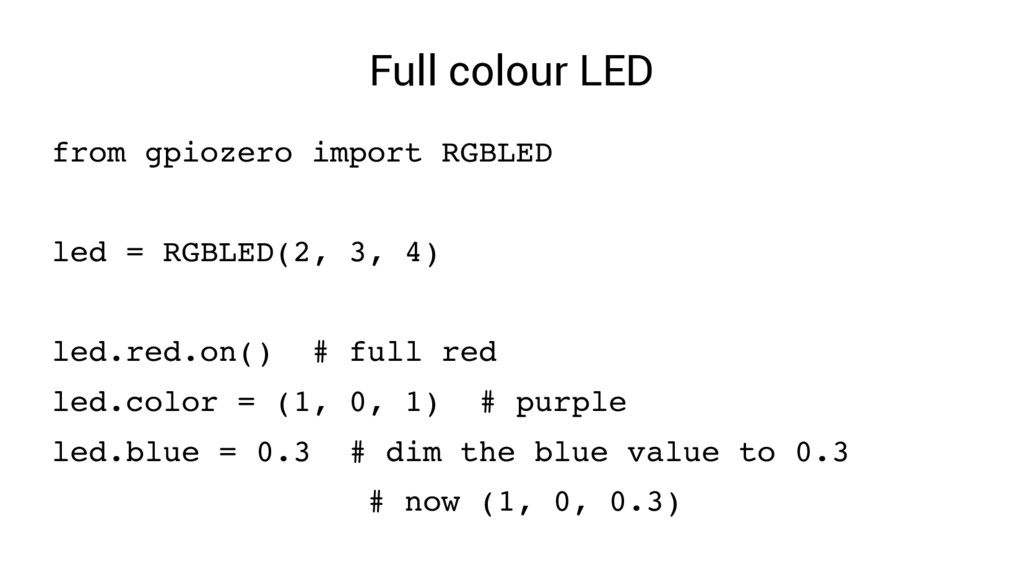
Full colour LED from gpiozero import RGBLED led = RGBLED(2,
3, 4) led.red.on() # full red led.color = (1, 0, 1) # purple led.blue = 0.3 # dim the blue value to 0.3 # now (1, 0, 0.3)
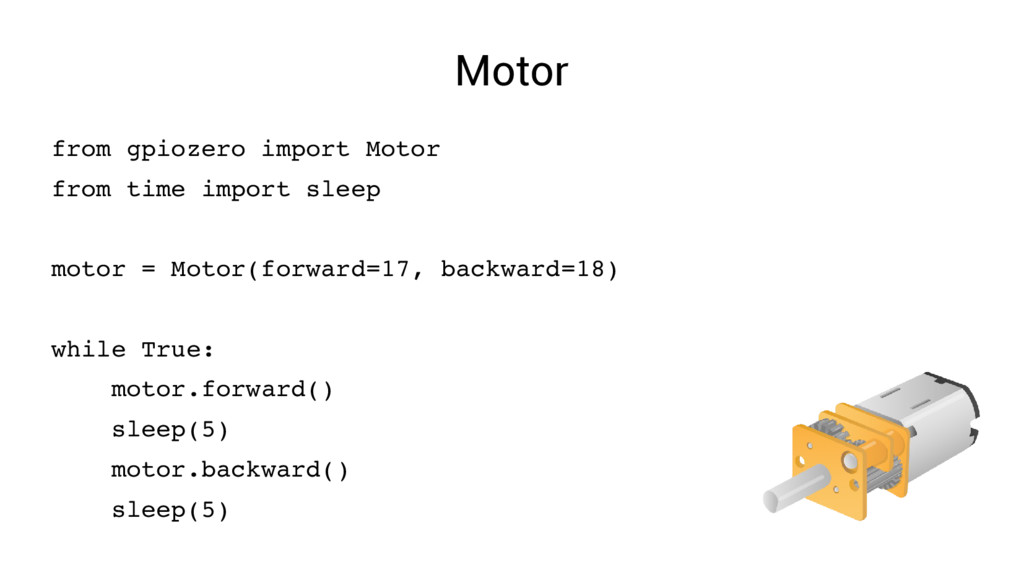
Motor from gpiozero import Motor from time import sleep motor
= Motor(forward=17, backward=18) while True: motor.forward() sleep(5) motor.backward() sleep(5)
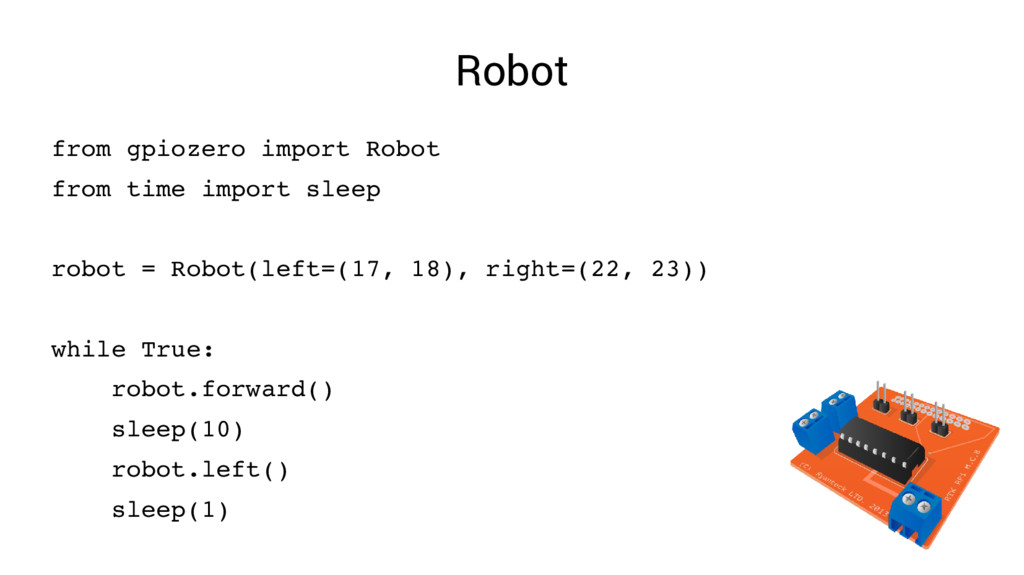
Robot from gpiozero import Robot from time import sleep robot
= Robot(left=(17, 18), right=(22, 23)) while True: robot.forward() sleep(10) robot.left() sleep(1)
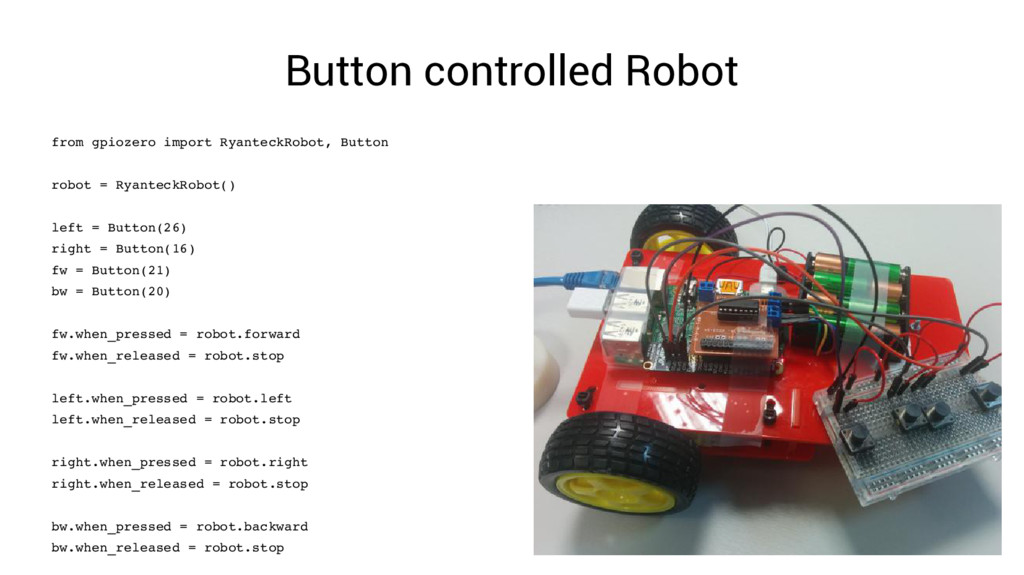
Button controlled Robot from gpiozero import RyanteckRobot, Button robot =
RyanteckRobot() left = Button(26) right = Button(16) fw = Button(21) bw = Button(20) fw.when_pressed = robot.forward fw.when_released = robot.stop left.when_pressed = robot.left left.when_released = robot.stop right.when_pressed = robot.right right.when_released = robot.stop bw.when_pressed = robot.backward bw.when_released = robot.stop
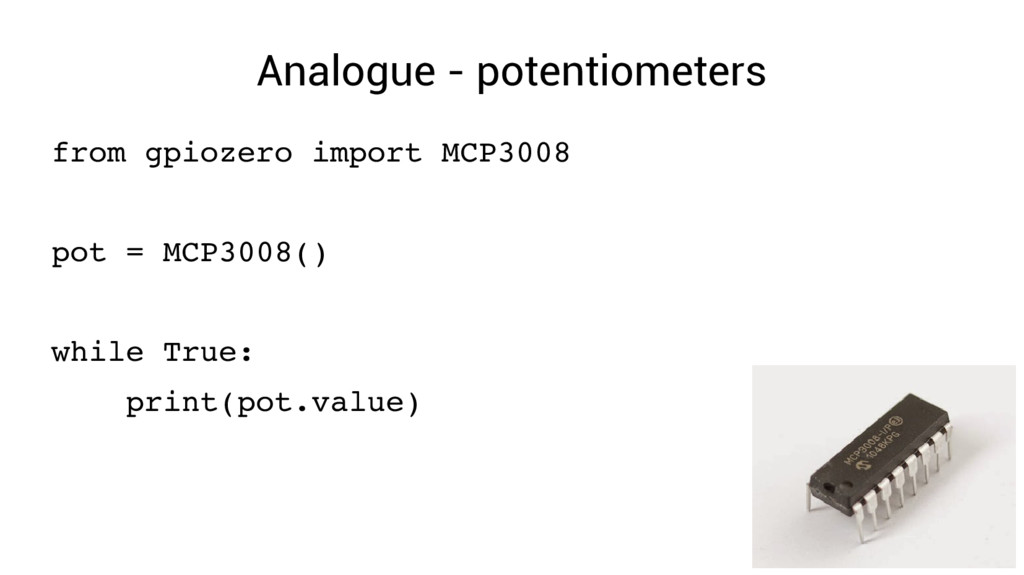
Analogue - potentiometers from gpiozero import MCP3008 pot = MCP3008()
while True: print(pot.value)
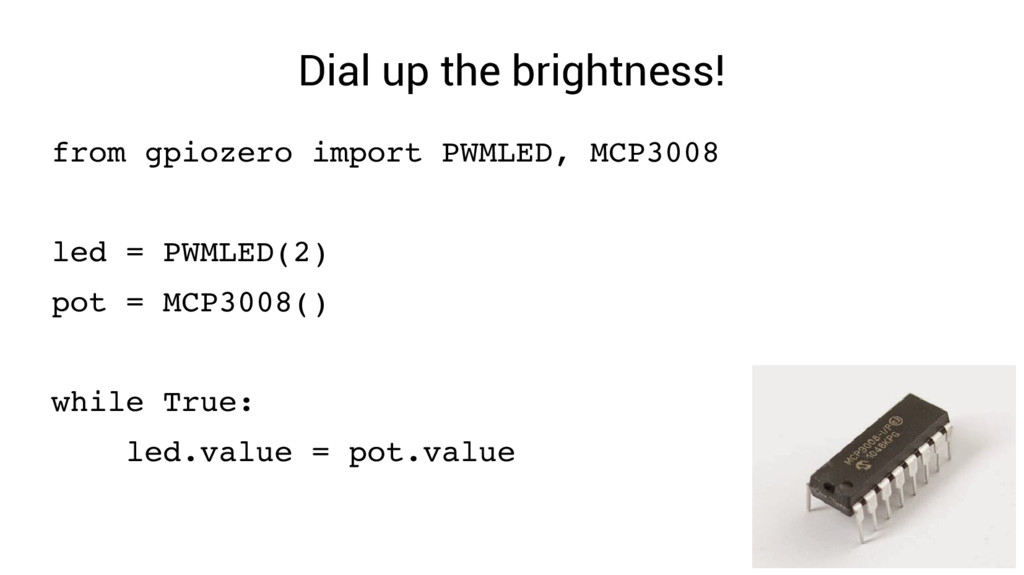
Dial up the brightness! from gpiozero import PWMLED, MCP3008 led
= PWMLED(2) pot = MCP3008() while True: led.value = pot.value
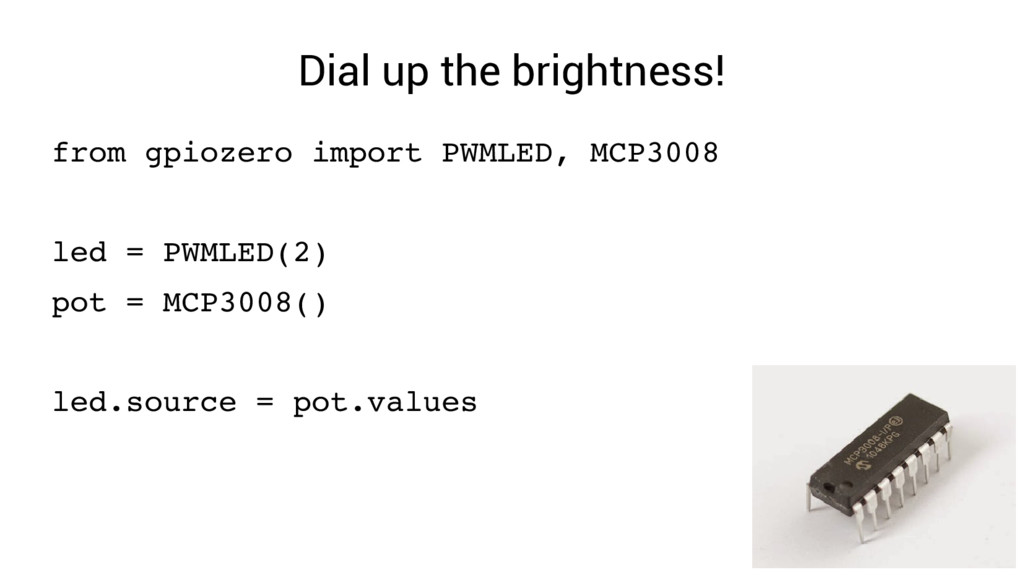
Dial up the brightness! from gpiozero import PWMLED, MCP3008 led
= PWMLED(2) pot = MCP3008() led.source = pot.values
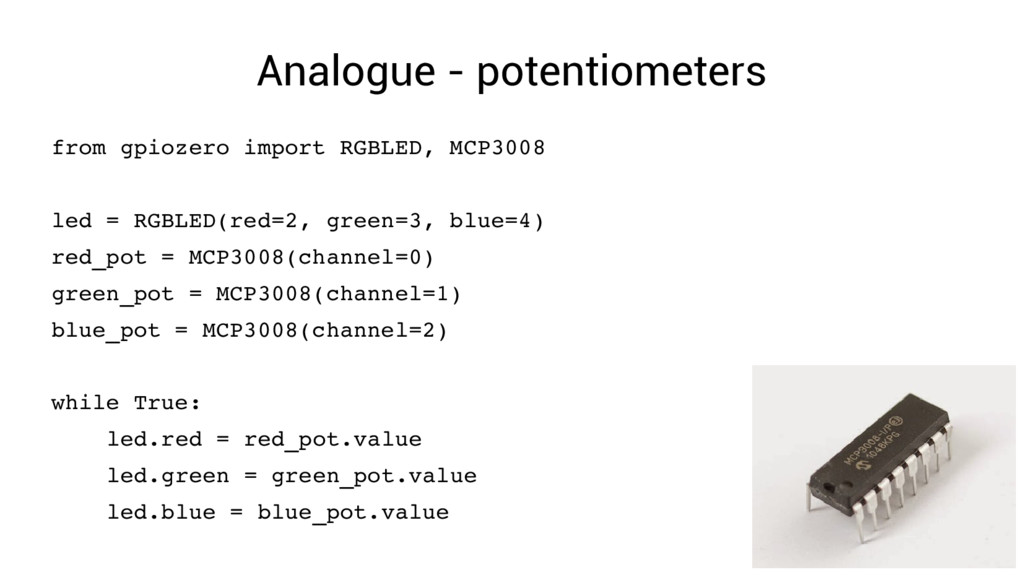
Analogue - potentiometers from gpiozero import RGBLED, MCP3008 led =
RGBLED(red=2, green=3, blue=4) red_pot = MCP3008(channel=0) green_pot = MCP3008(channel=1) blue_pot = MCP3008(channel=2) while True: led.red = red_pot.value led.green = green_pot.value led.blue = blue_pot.value
Analogue - potentiometers from gpiozero import RGBLED, MCP3008 led =
RGBLED(red=2, green=3, blue=4) red_pot = MCP3008(channel=0) green_pot = MCP3008(channel=1) blue_pot = MCP3008(channel=2) led.red.source = red_pot.values led.green.source = green_pot.values led.blue.source = blue_pot.values
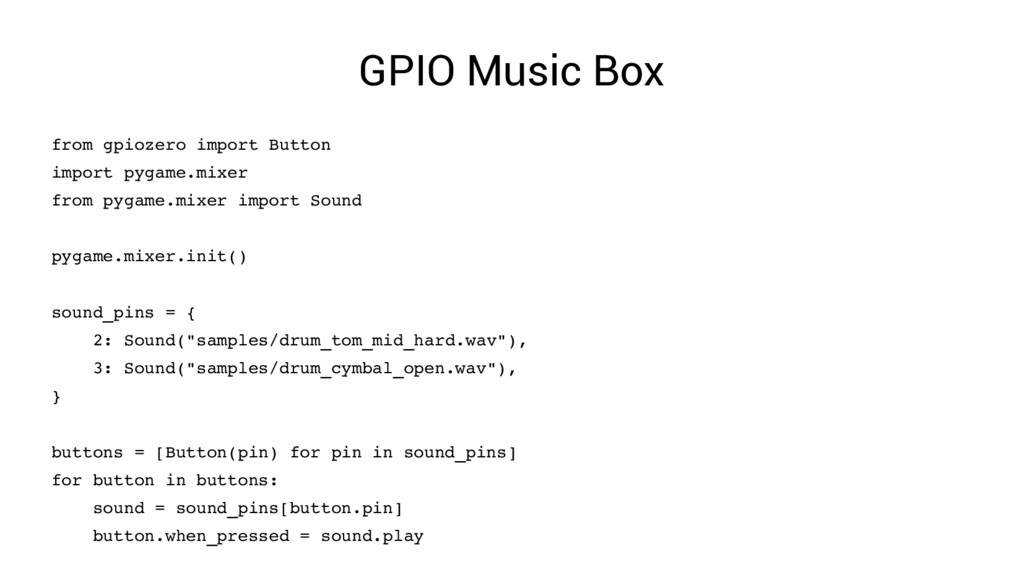
GPIO Music Box from gpiozero import Button import pygame.mixer from
pygame.mixer import Sound pygame.mixer.init() sound_pins = { 2: Sound("samples/drum_tom_mid_hard.wav"), 3: Sound("samples/drum_cymbal_open.wav"), } buttons = [Button(pin) for pin in sound_pins] for button in buttons: sound = sound_pins[button.pin] button.when_pressed = sound.play
GPIO Zero - beta • www.pythonhosted.org/gpiozero – Installation instructions –
Documentation – Examples • GitHub Issues – Suggestions – Feedback • Contact me –
[email protected]
– @ben_nuttall on Twitter • #gpiozero on Twitter
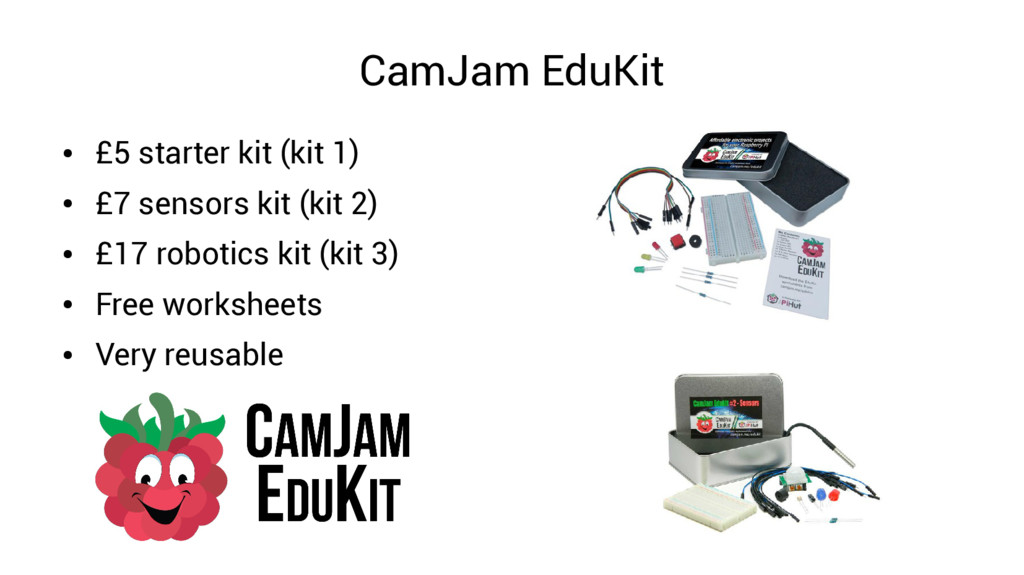
CamJam EduKit • £5 starter kit (kit 1) • £7
sensors kit (kit 2) • £17 robotics kit (kit 3) • Free worksheets • Very reusable
Raspberry Pi blog
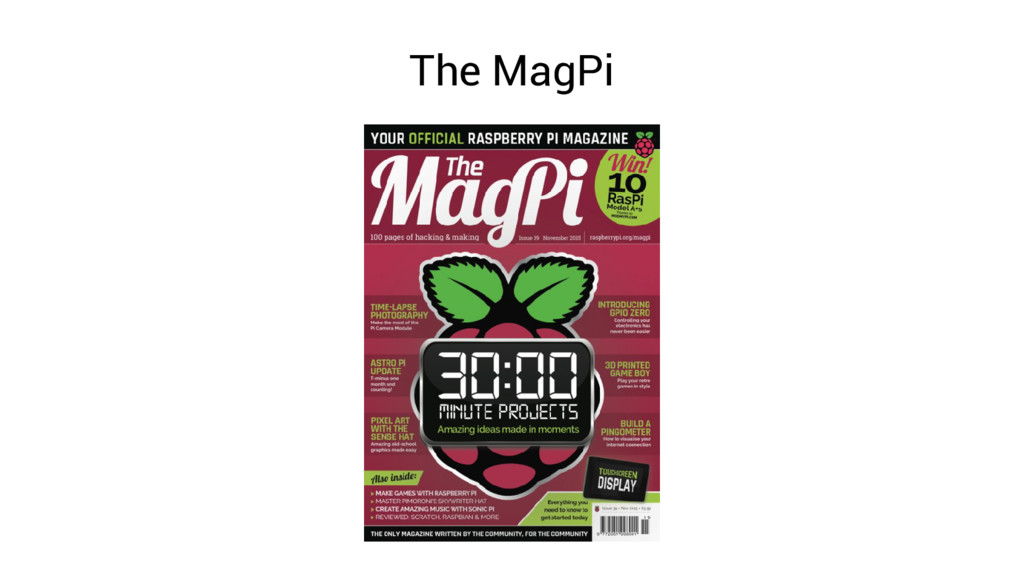
The MagPi
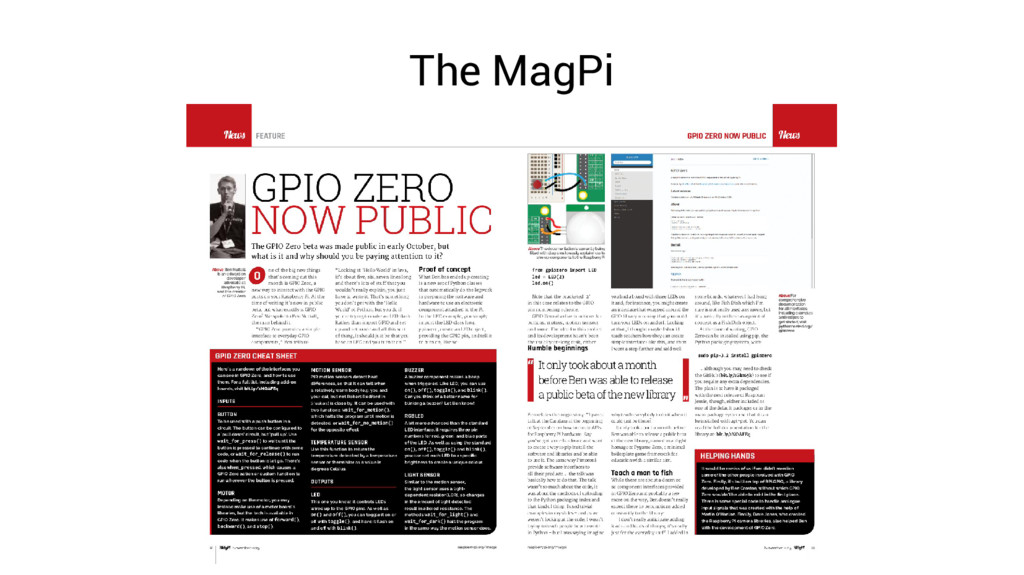
The MagPi
The MagPi
Physical computing with GPIO Zero Ben Nuttall Raspberry Pi Foundation
UK Charity 1129409


 bennuttall
 ken_tunc
 gonta
 petamoriken
 prota
 kanfab1
 ktcryomm
 riofujimon
 gam0022
 yukiny
 kishida
 bash0c7
 oga5
 andyhume
 twada
 jonoalderson
 cassininazir
 inesmontani
 quramy
 aleyda
 greggifford
 chriscoyier
 marketingsoph
 jcasabona
 maggiecrowley