Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
ミニ四駆チキンレース参戦記(敗)
Search
Sponsored
·
Your Podcast. Everywhere. Effortlessly.
Share. Educate. Inspire. Entertain. You do you. We'll handle the rest.
→
Google Homer
June 21, 2019
Technology
1.3k
1
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
ミニ四駆チキンレース参戦記(敗)
Google Homer
June 21, 2019
More Decks by Google Homer
See All by Google Homer
意外とお手軽Donkey AI Car(ありがとうIoTLT)
googlehomer
0
780
ゆるふわマシンラーニング×ゆるメカトロでDonkey AI Car
googlehomer
0
340
私Servoですけど、ぐるぐる回りますが 何か ?!
googlehomer
0
430
The latest information on obniz for all of IoTLT’s
googlehomer
1
340
IoTLT vol.58@SoftBank IoTLT木曜サスペンス劇場
googlehomer
0
830
micro:bitはobnizの夢をみるか?
googlehomer
1
880
Invitation for RPA next stage @UiPathFriendsライトニングトークナイト2019
googlehomer
0
130
M5StickC Block Programming UiFLOW @ ビジュアルプログラミング交流会
googlehomer
1
750
Smart Speaker & IoT @東北TECH道場 八戸道場
googlehomer
0
160
Other Decks in Technology
See All in Technology
僕のハーネスを紹介します
watany
3
880
LLM Content Moderationを支える評価・改善ループの実践
suikabar
1
130
CloudWatch Logsのコスト最適化:どこまでAIに任せてどこから人間が承認すべきか
yama3133
0
120
Refining Active Record
shugo
0
170
専門領域のAIをどう評価するか
bengo4com
2
330
フロントエンドカンファレンス関西2026 - 速すぎるUIに、待ち時間を
teamlab
PRO
0
200
Railsで挑む大量データ永続化 〜600億件を永続化するための設計とボトルネックとの戦い〜
occhi
1
950
SAENM ~Jupyterで残すPoCの試行錯誤、未来の自分と仲間を助ける記録!~
terapyon
0
160
会社説明資料
persolserverworks
0
9.8k
Claude の新機能を、 出た日に触って社内に届けるまで
rfdnxbro
1
200
dbt Semantic Layerで進めるenechainのデータ民主化
akizhou
1
110
DBについての基礎説明(MySQL編) - コロプラ 2026年度 新卒研修
colopl
0
140
Featured
See All Featured
Git: the NoSQL Database
bkeepers
PRO
433
67k
Gemini Prompt Engineering: Practical Techniques for Tangible AI Outcomes
mfonobong
2
590
Intergalactic Javascript Robots from Outer Space
tanoku
273
28k
Crafting Experiences
bethany
1
390
Art, The Web, and Tiny UX
lynnandtonic
304
22k
Practical Tips for Bootstrapping Information Extraction Pipelines
honnibal
25
2.1k
The AI Search Optimization Roadmap by Aleyda Solis
aleyda
2
6.3k
Hiding What from Whom? A Critical Review of the History of Programming languages for Music
tomoyanonymous
3
1.4k
Mozcon NYC 2025: Stop Losing SEO Traffic
samtorres
1
580
What does AI have to do with Human Rights?
axbom
PRO
1
2.5k
Information Architects: The Missing Link in Design Systems
soysaucechin
1
1.2k
How STYLIGHT went responsive
nonsquared
100
6.3k
Transcript
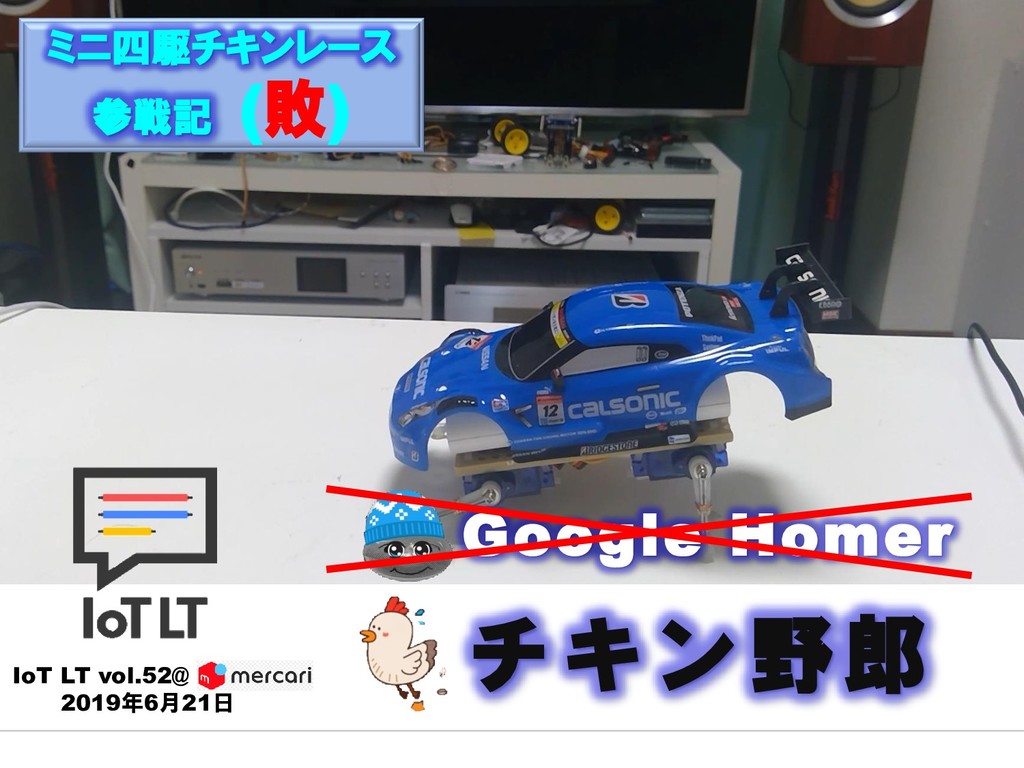
Google Homer IoT LT vol.52@ 2019年6月21日 チキン野郎 ミニ四駆チキンレース 参戦記 (敗)
こだわったこと ミニ四駆 速く、カッコよく !
小型化 : obniz 大貢献 距離センサー、DC Motor直挿し
いざ 爆走
0 500 1000 1500 2000 2500 3000 3500 4000 1
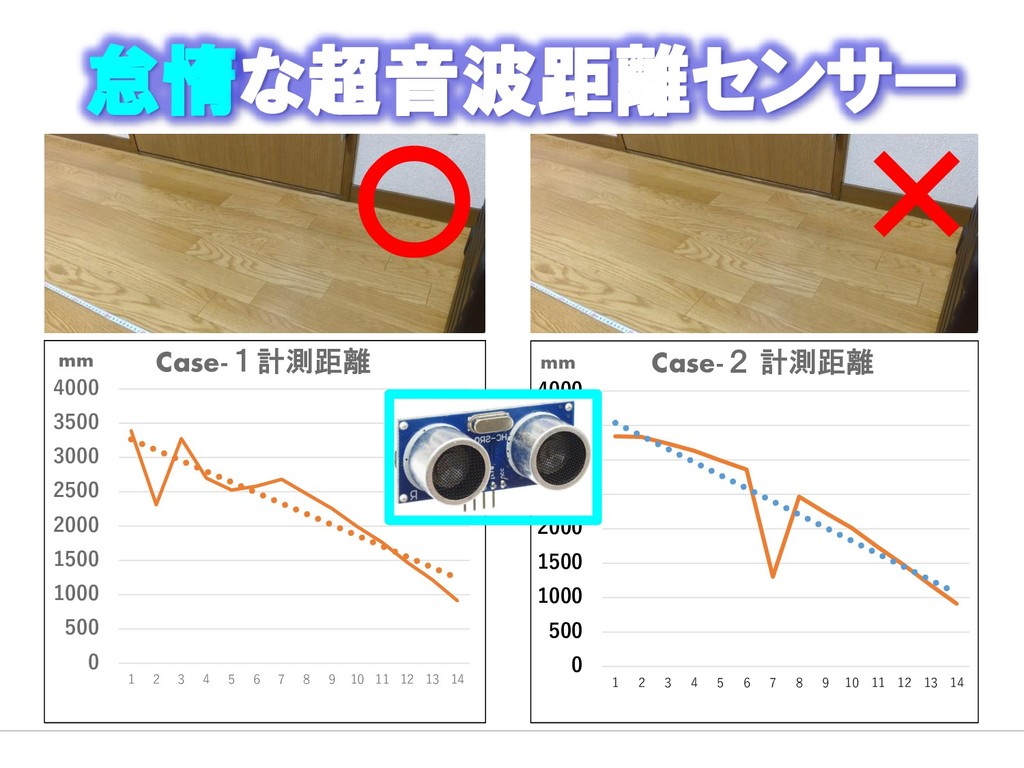
2 3 4 5 6 7 8 9 10 11 12 13 14 mm Case-1計測距離 〇 怠惰な超音波距離センサー 0 500 1000 1500 2000 2500 3000 3500 4000 1 2 3 4 5 6 7 8 9 10 11 12 13 14 Case-2 計測距離 mm ×
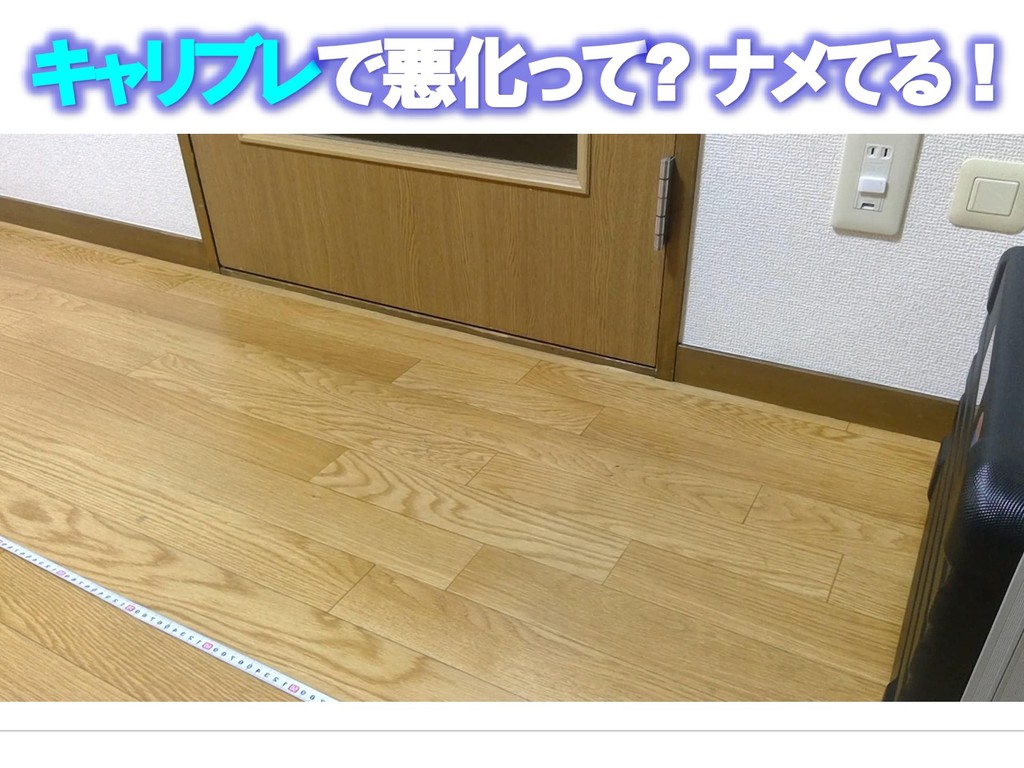
キャリブレで悪化って? ナメてる !
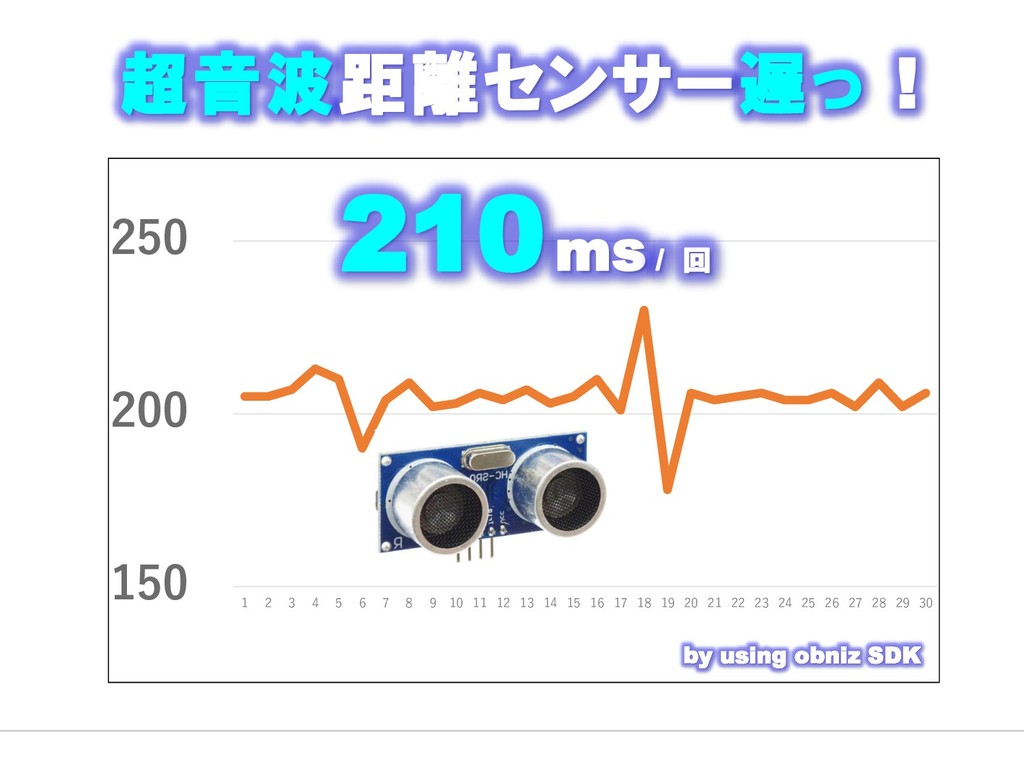
150 200 250 1 2 3 4 5 6 7
8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 27 28 29 30 超音波距離センサー遅っ ! 210ms / 回 by using obniz SDK
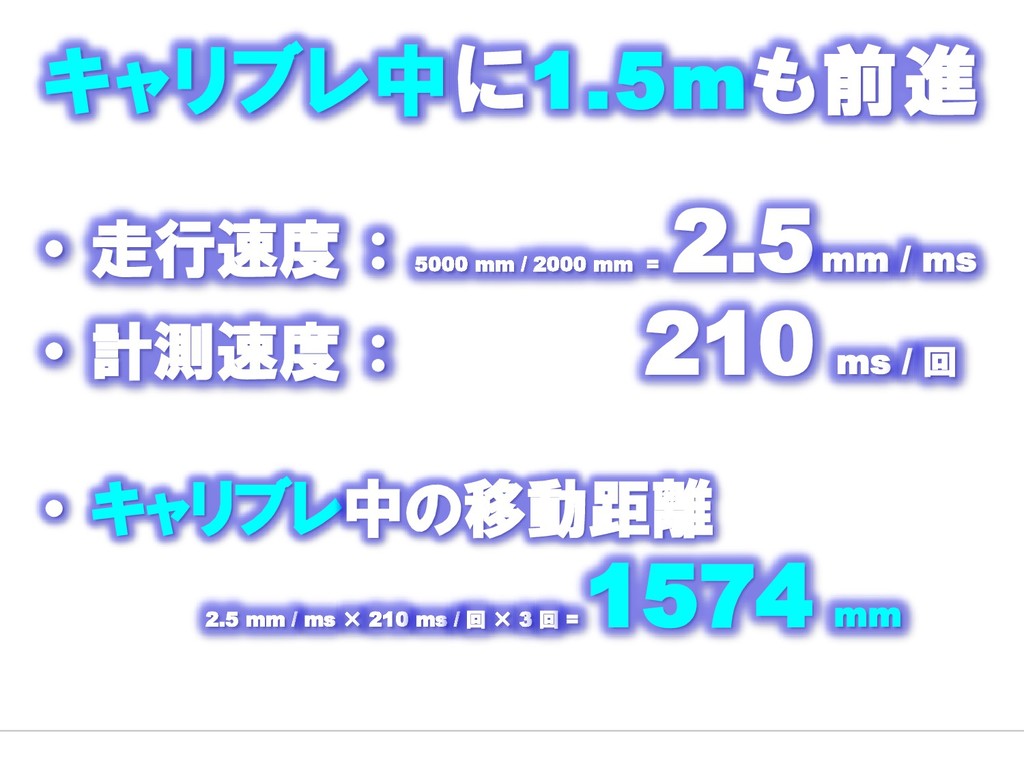
・ 走行速度 : 5000 mm / 2000 mm = 2.5mm
/ ms ・ 計測速度 : 210 ms / 回 ・ キャリブレ中の移動距離 2.5 mm / ms × 210 ms / 回 × 3 回 = 1574 mm キャリブレ中に1.5mも前進
フィードバック 制御不可 作戦変更へ
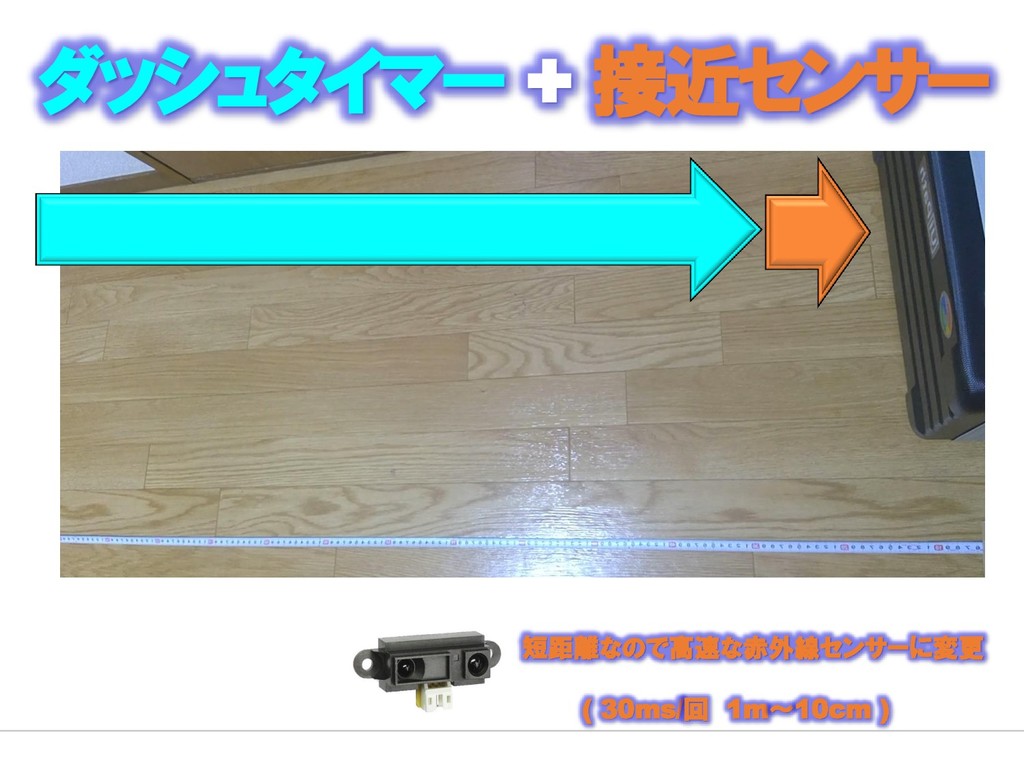
ダッシュタイマー + 接近センサー 短距離なので高速な赤外線センサーに変更 ( 30ms/回 1m~10cm )
追い込 み開始
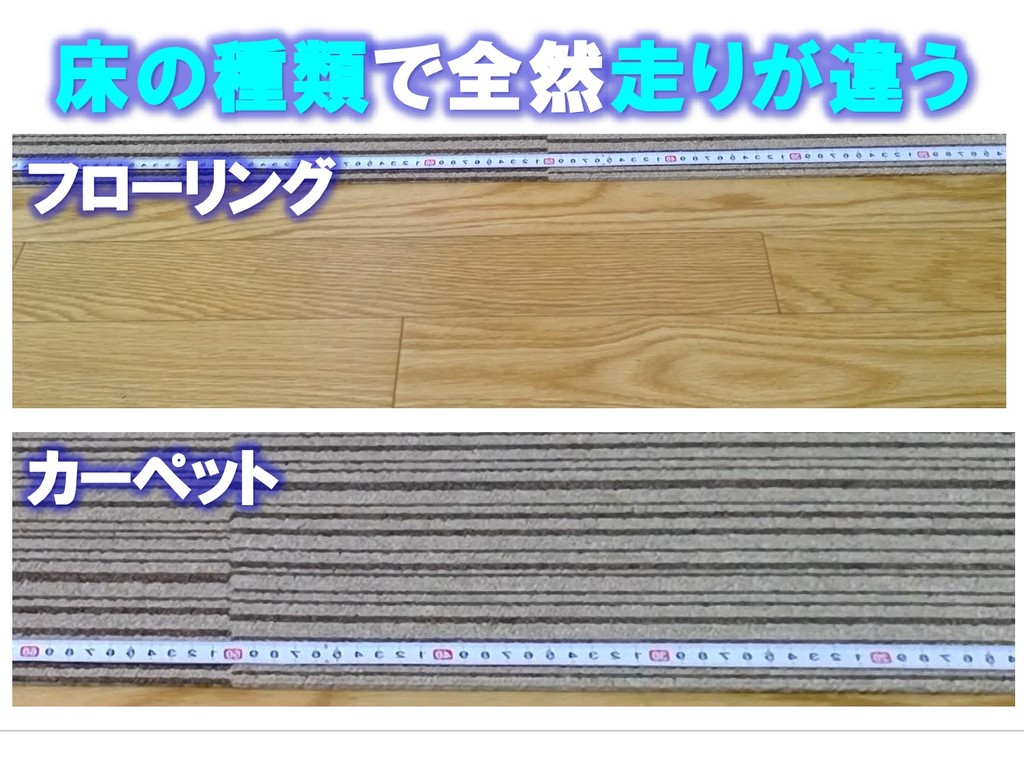
フローリング カーペット 床の種類で全然走りが違う
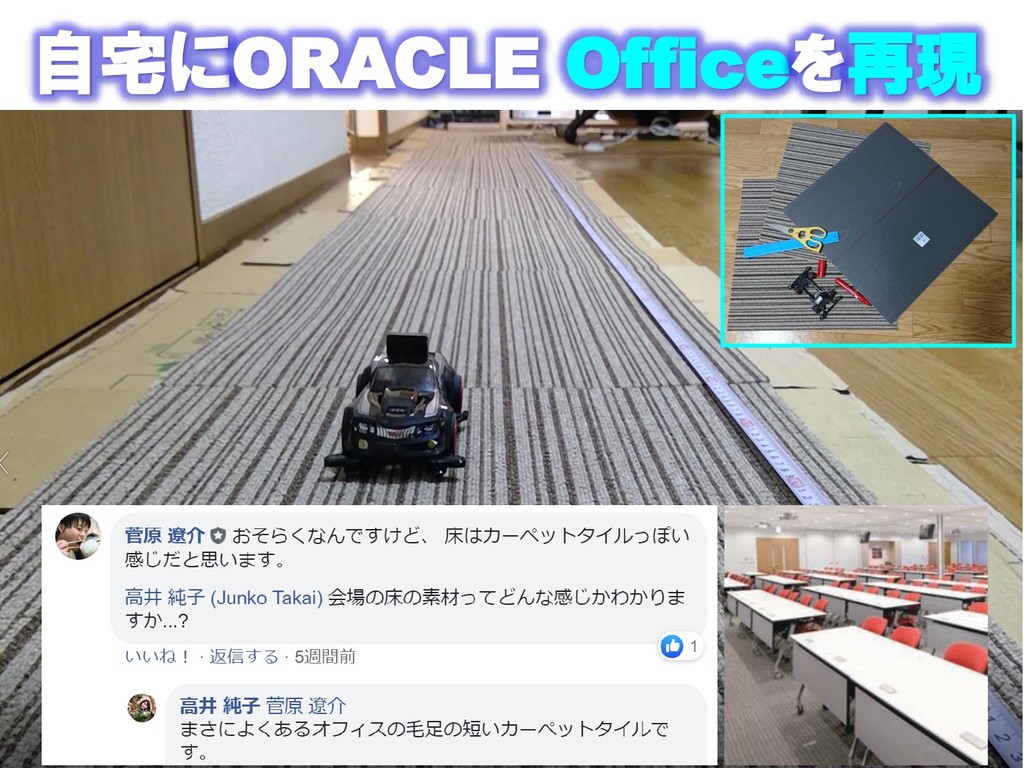
自宅にORACLE Officeを再現
90g 増 (単四×4本) で速度20%低下 1100mm/500ms = 2.2mm/ms 1400mm/500ms = 2.8mm/ms
DC Motor ネイティブ obniz&Li-Po 軽量化に大貢献 Li-Po 7.4V 400mAh DDC 5V
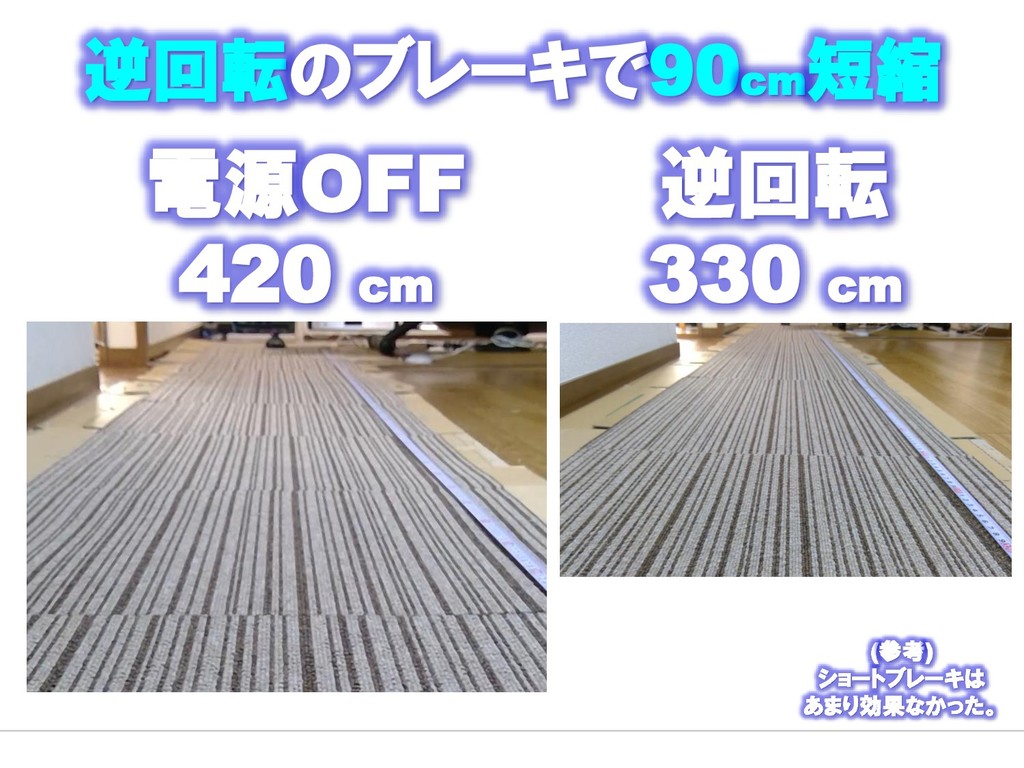
逆回転のブレーキで90cm 短縮 電源OFF 420 cm 逆回転 330 cm (参考) ショートブレーキは
あまり効果なかった。
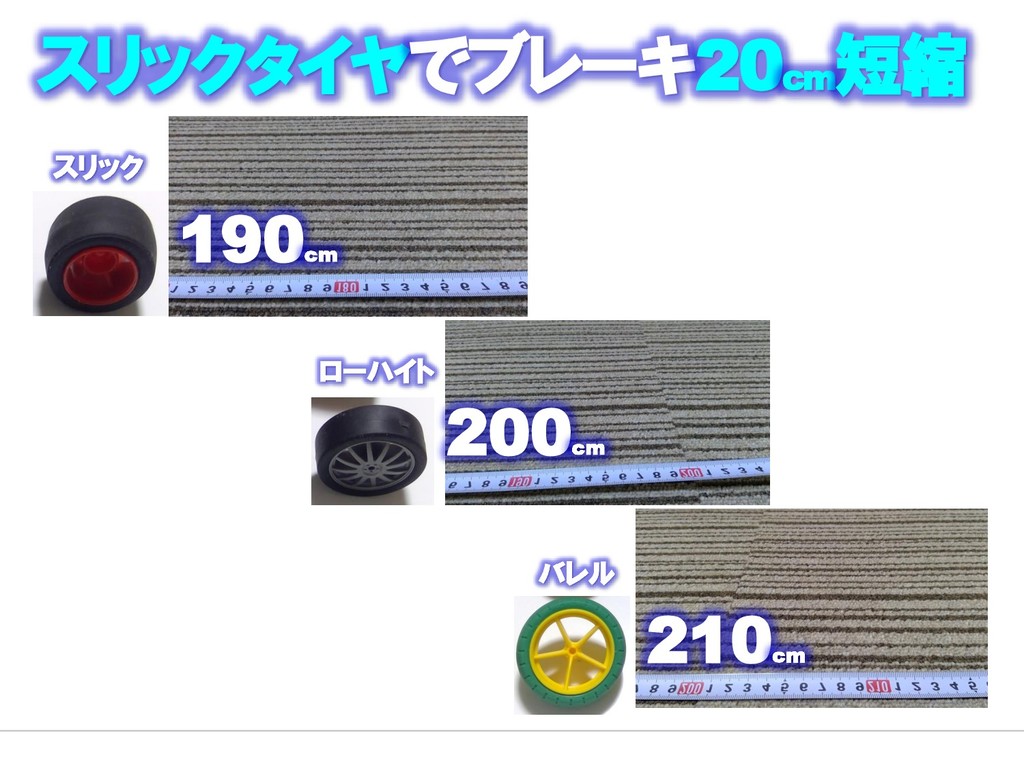
190cm スリックタイヤでブレーキ20cm 短縮 スリック ローハイト バレル 200cm 210cm
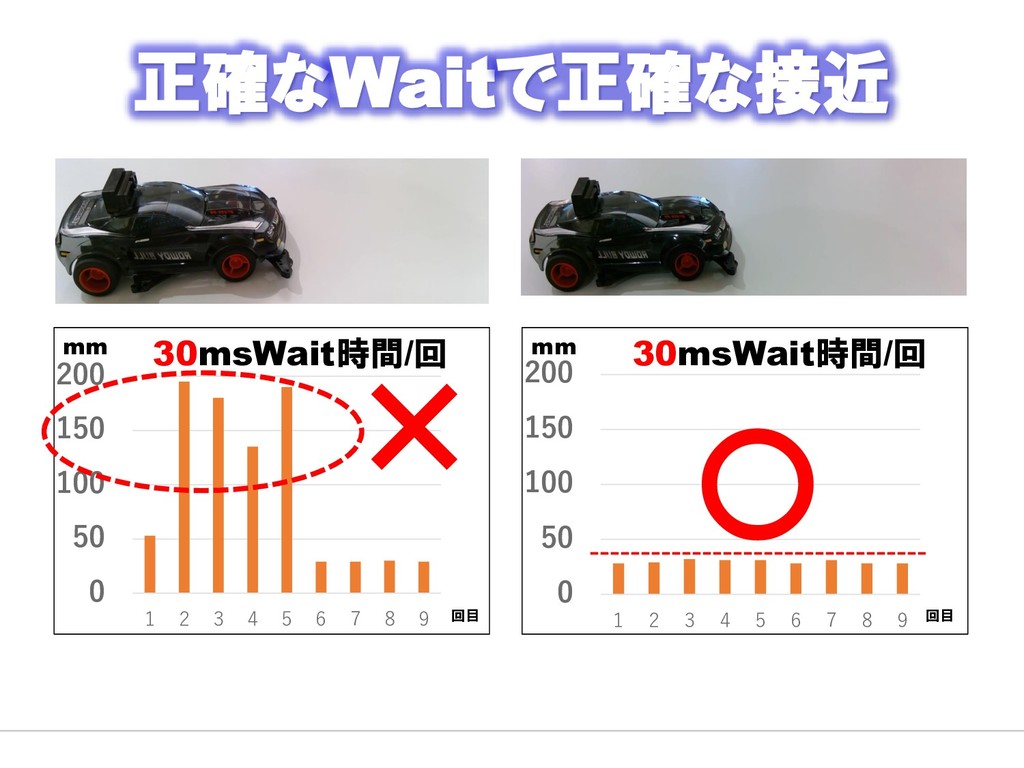
正確なWaitで正確な接近 0 50 100 150 200 1 2 3 4
5 6 7 8 9 0 50 100 150 200 1 2 3 4 5 6 7 8 9 mm mm 回目 回目 30msWait時間/回 30msWait時間/回 〇 ×
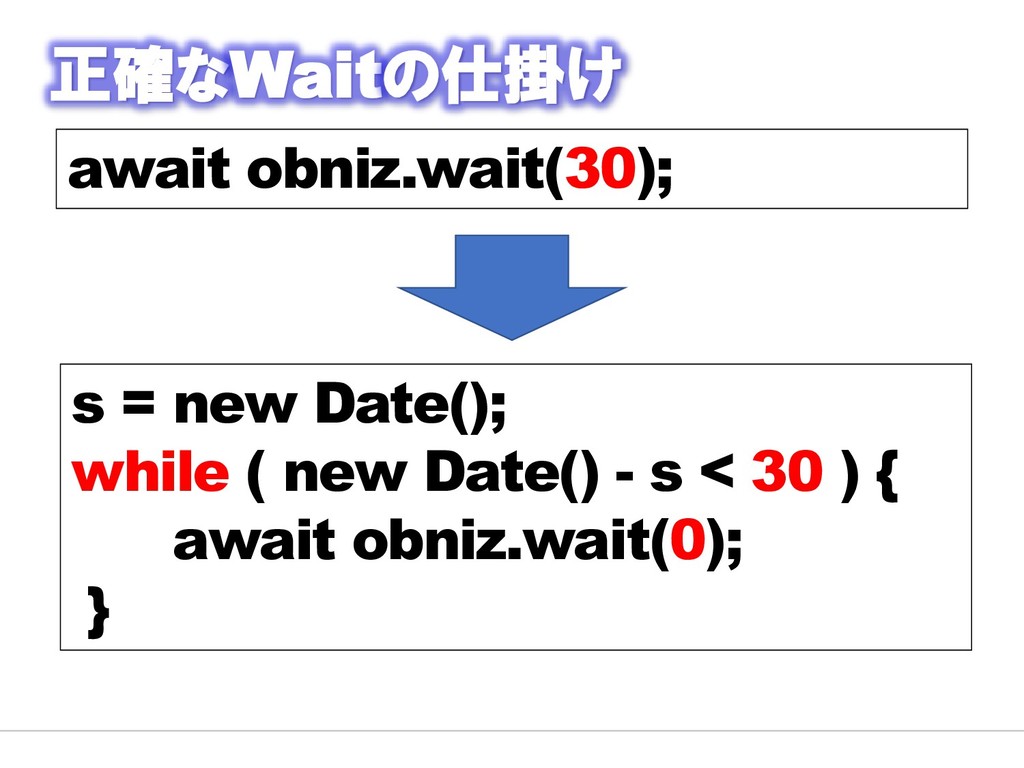
s = new Date(); while ( new Date() - s
< 30 ) { await obniz.wait(0); } await obniz.wait(30); 正確なWaitの仕掛け
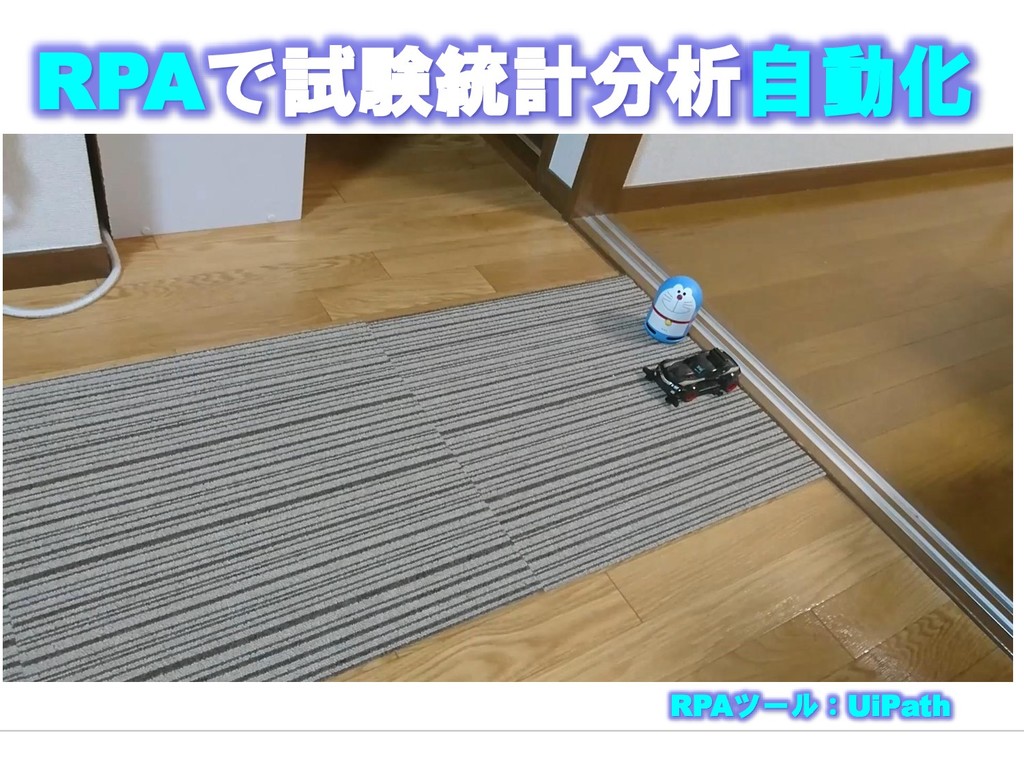
RPAで試験統計分析自動化 RPAツール:UiPath
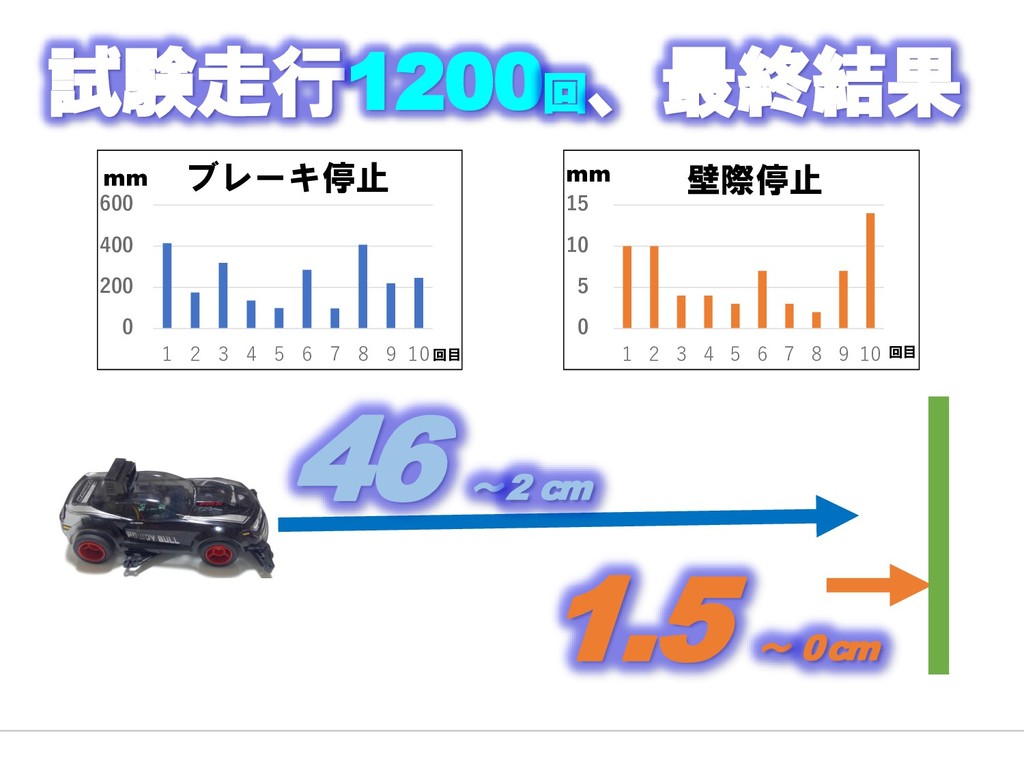
0 200 400 600 1 2 3 4 5 6
7 8 9 10 0 5 10 15 1 2 3 4 5 6 7 8 9 10 46 ~2 cm 1.5 ~ 0 cm ブレーキ停止 壁際停止 試験走行1200回 、最終結果 回目 回目 mm mm
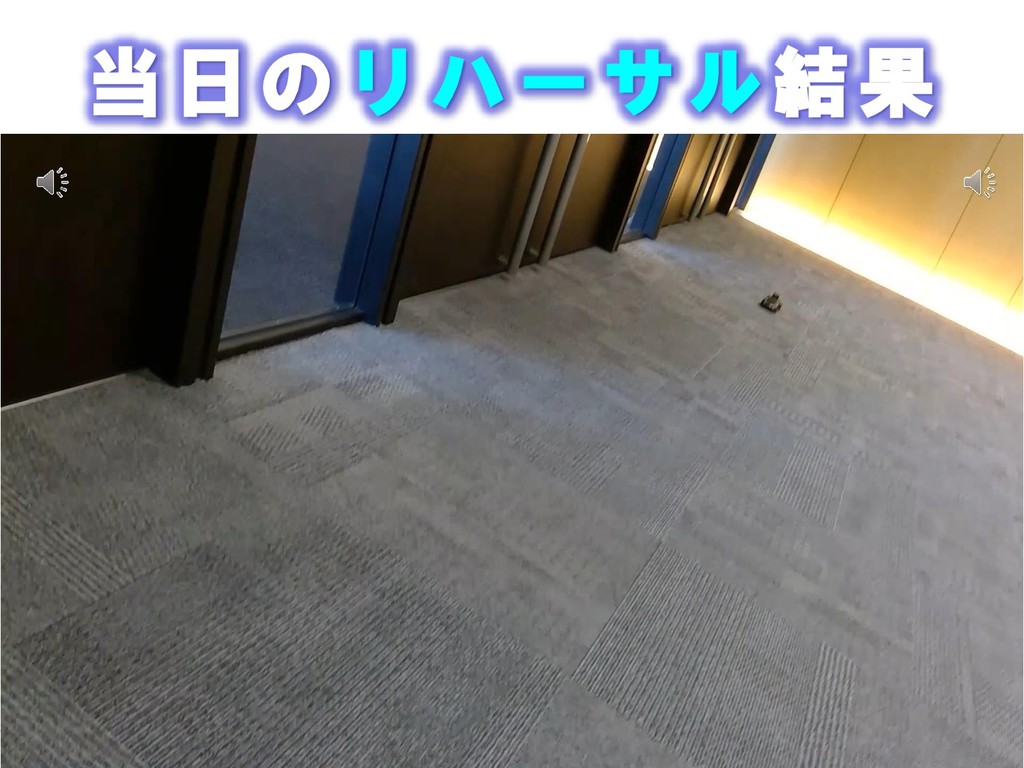
当日のリハーサル結果
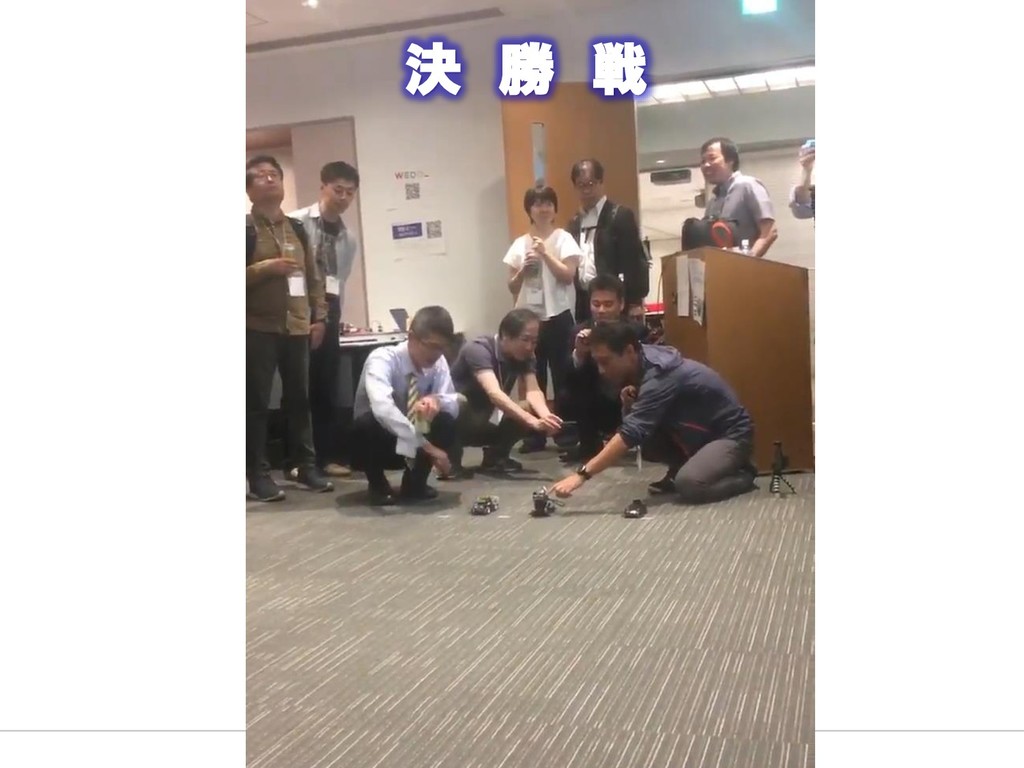
決 勝 戦
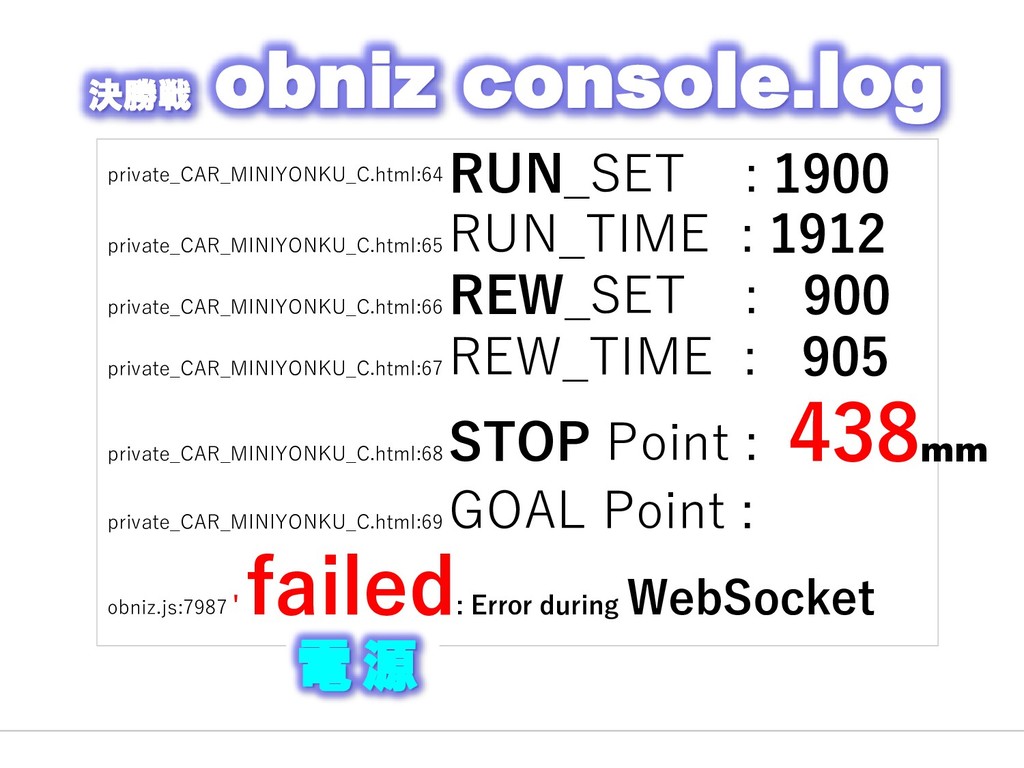
private_CAR_MINIYONKU_C.html:64 RUN_SET : 1900 private_CAR_MINIYONKU_C.html:65 RUN_TIME : 1912 private_CAR_MINIYONKU_C.html:66 REW_SET
: 900 private_CAR_MINIYONKU_C.html:67 REW_TIME : 905 private_CAR_MINIYONKU_C.html:68 STOP Point : 438 private_CAR_MINIYONKU_C.html:69 GOAL Point : obniz.js:7987 ' failed : Error during WebSocket 決勝戦 obniz console.log mm 電 源
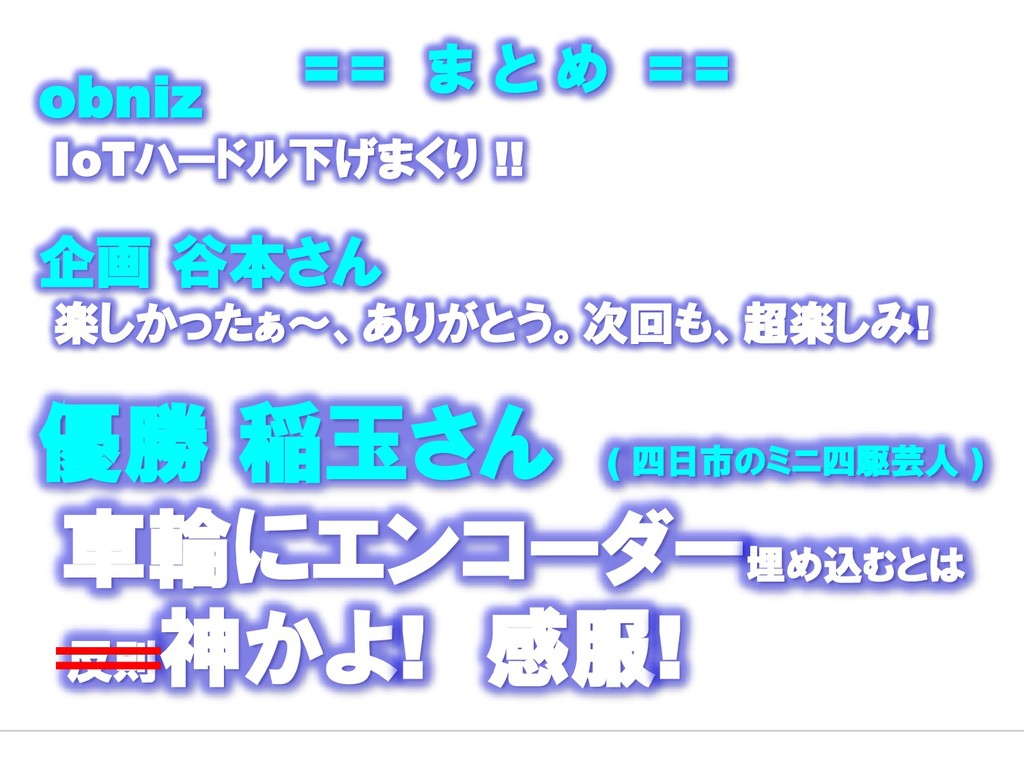
obniz IoTハードル下げまくり !! 企画 谷本さん 楽しかったぁ~、ありがとう。次回も、超楽しみ! 優勝 稲玉さん ( 四日市のミニ四駆芸人
) 車輪にエンコーダー埋め込むとは 反則 神かよ! 感服! = = ま と め = =


 googlehomer
 watany
 suikabar
 yama3133
 shugo
 bengo4com
 teamlab
 occhi
 terapyon
 persolserverworks
 rfdnxbro
 akizhou
 colopl
 bkeepers
 mfonobong
 tanoku
 bethany
 lynnandtonic
 honnibal
 aleyda
 tomoyanonymous
 samtorres
 axbom
 soysaucechin
 nonsquared