Share
Embed
Transcript
42 slides
-
Time-Independent Planning for Multiple Moving Agents Keisuke Okumura, Yasumasa Tamura
& Xavier Defago Feb. 2–9, 2021 Tokyo Institute of Technology, Japan ౦ژۀେֶ 5PLZP*OTUJUVUFPG5FDIOPMPHZ virtual conference AAAI-21 -
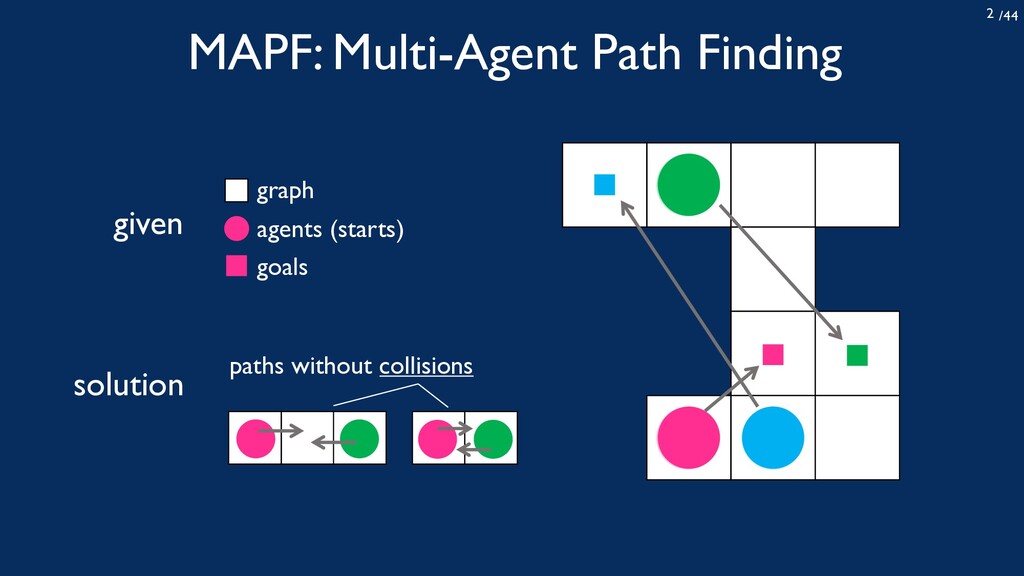
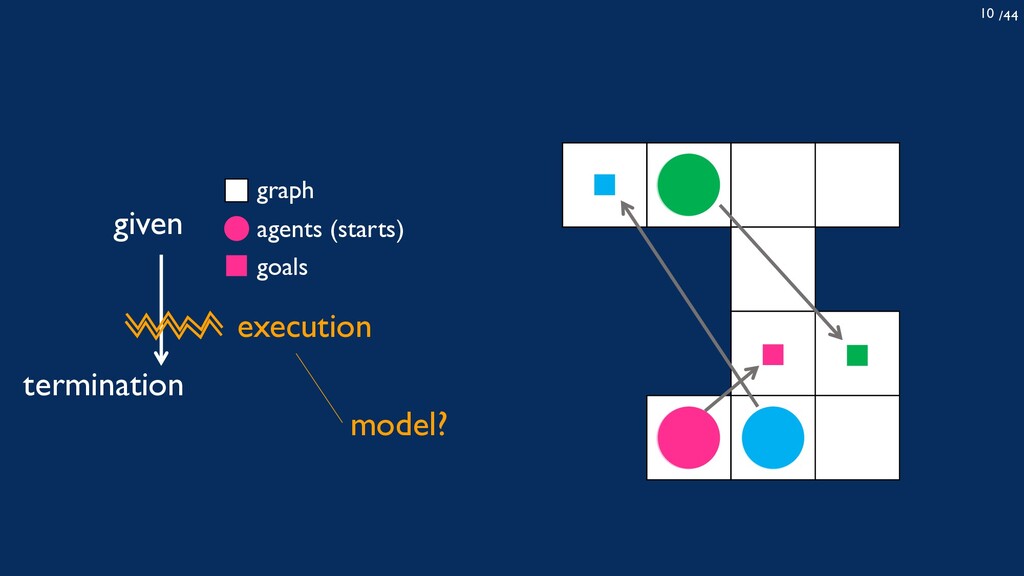
/44 2 MAPF: Multi-Agent Path Finding given agents (starts) graph
goals solution paths without collisions -
/44 4 Planning 1 2 1 2 3 4 Execution
assume that agents move synchronously -
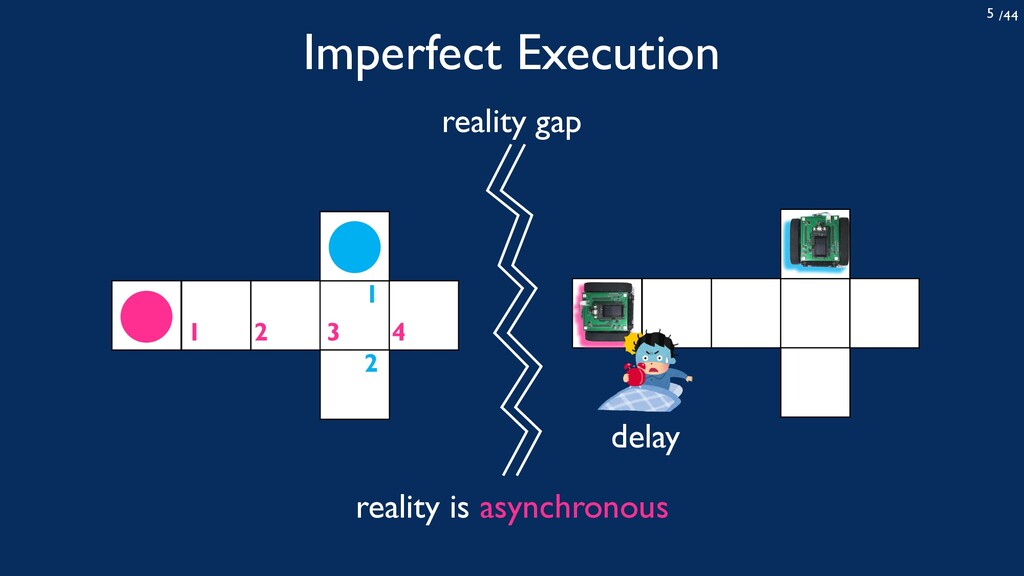
/44 5 Imperfect Execution 1 2 1 2 3 4
delay reality gap reality is asynchronous -
/44 6 Execution Policies [Ma+ AAAI-17] Fully Synchronized Policies Minimum
Communication Policies wait check temporal dependencies 1 2 1 2 3 4 => preserved, go arrival time: 3 arrival time: 2 -
/44 7 move very slowly / crash Minimum Communication Policies
check temporal dependencies 1 2 1 2 3 4 => violate, wait Still Vulnerable to Delays -
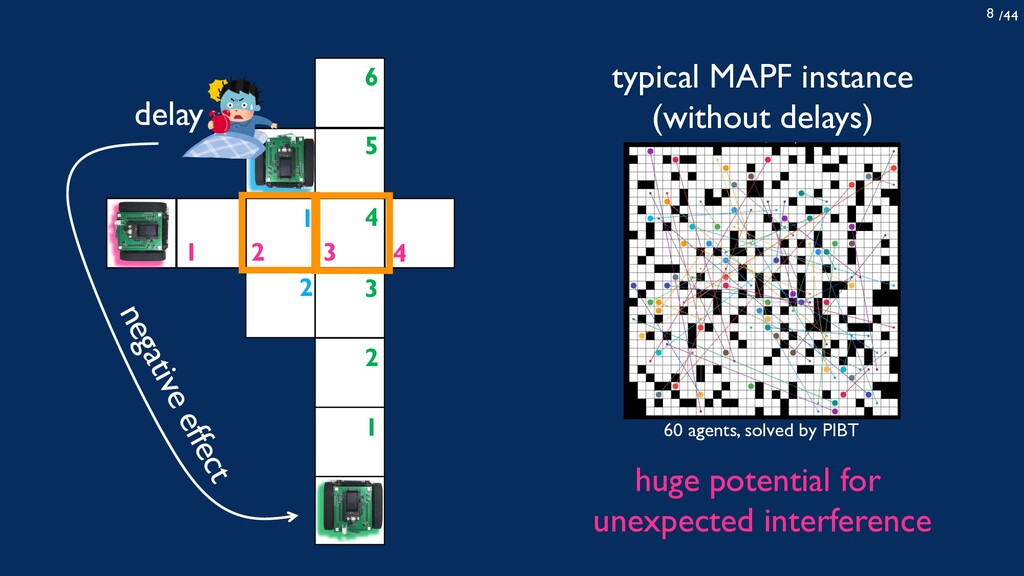
/44 8 1 2 1 2 3 4 1 2
3 4 5 6 delay negative effect typical MAPF instance (without delays) 60 agents, solved by PIBT huge potential for unexpected interference -
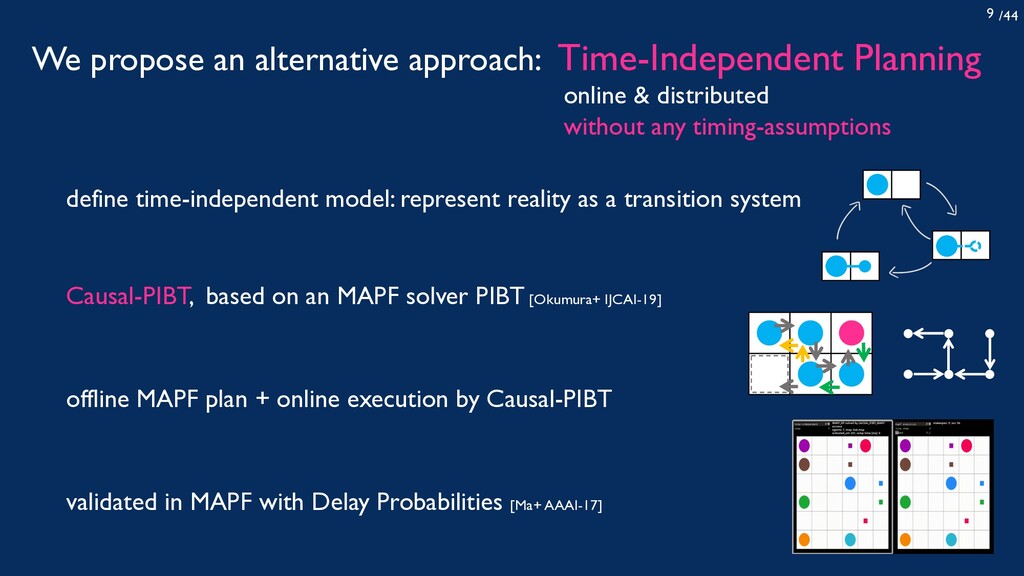
/44 9 We propose an alternative approach: Time-Independent Planning define
time-independent model: represent reality as a transition system Causal-PIBT, based on an MAPF solver PIBT [Okumura+ IJCAI-19] offline MAPF plan + online execution by Causal-PIBT validated in MAPF with Delay Probabilities [Ma+ AAAI-17] online & distributed without any timing-assumptions -
/44 11 Time-Independent Model inspired by models on theoretical distributed
algorithms c.f., [Tel, 2000] -
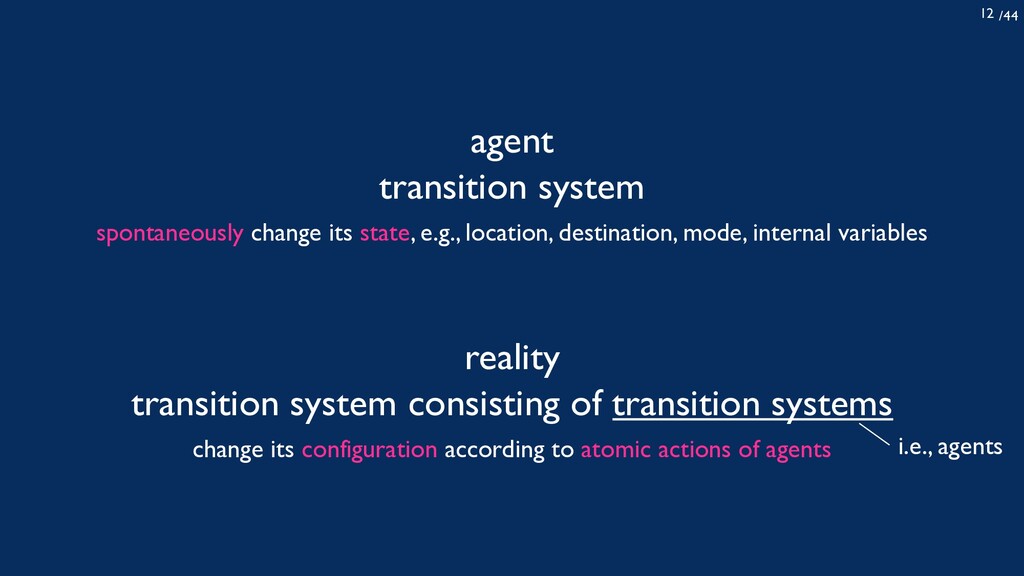
/44 12 agent transition system reality transition system consisting of
transition systems spontaneously change its state, e.g., location, destination, mode, internal variables change its configuration according to atomic actions of agents i.e., agents -
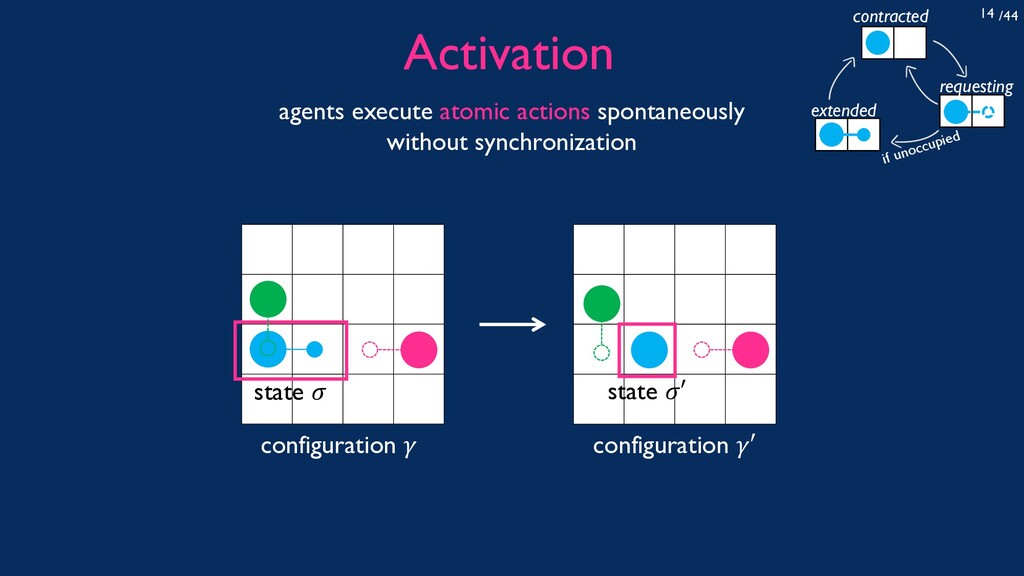
/44 14 configuration 𝛾 configuration 𝛾′ agents execute atomic actions
spontaneously without synchronization Activation contracted requesting extended if unoccupied state 𝜎 state 𝜎′ -
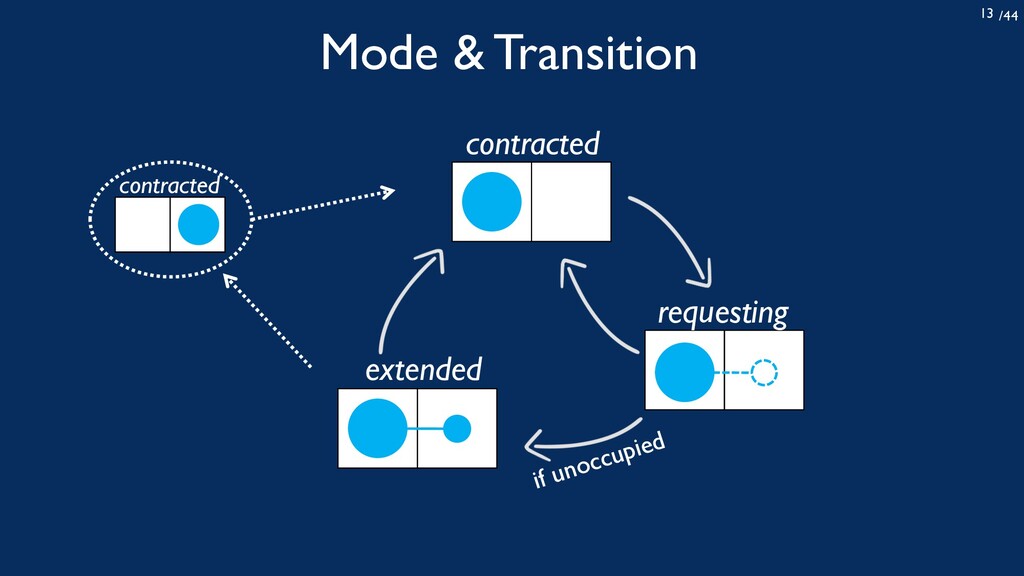
/44 15 interaction transit atomically … … contracted requesting extended
if unoccupied *address communication as a blackbox at most one agent is activated -
/44 16 strong termination all agents are on their goals
weak termination all agents have been on their goals at least once weak termination strong termination -
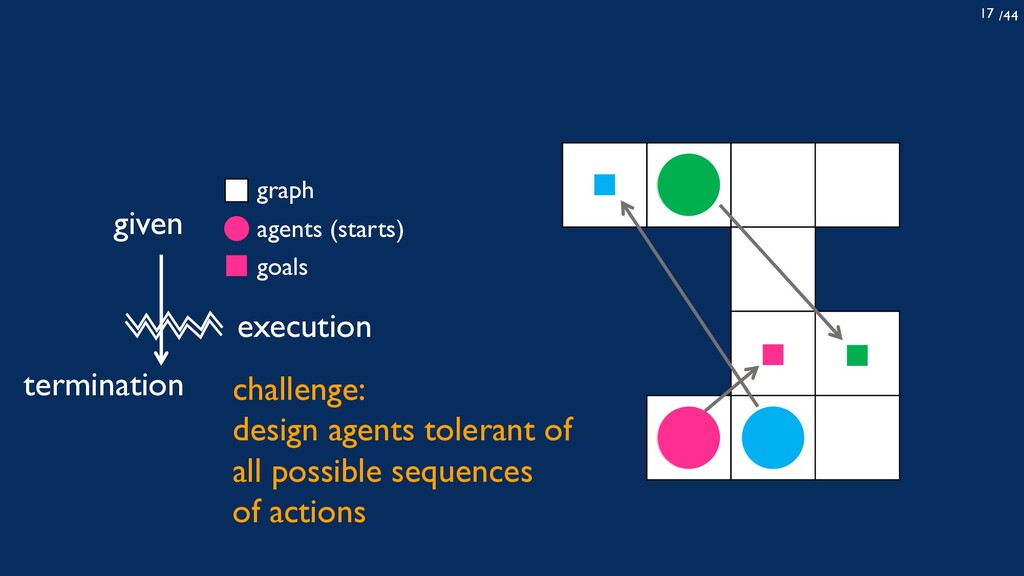
/44 17 given agents (starts) graph goals termination execution challenge:
design agents tolerant of all possible sequences of actions -
/44 19 Toy Example – GREEDY contracted requesting extended if
unoccupied the nearest adjacent location to the goal deadlock We need a sophisticated one… never back -
/44 21 PIBT Priority Inheritance with Backtracking [Okumura+ IJCAI-19] solving
MAPF iteratively quick & scalable adaptivity for decentralization 500 agents within 0.05 sec Applicable to Multi-agent Pickup & Delivery [Ma+ AAMAS-17] sub-optimal -
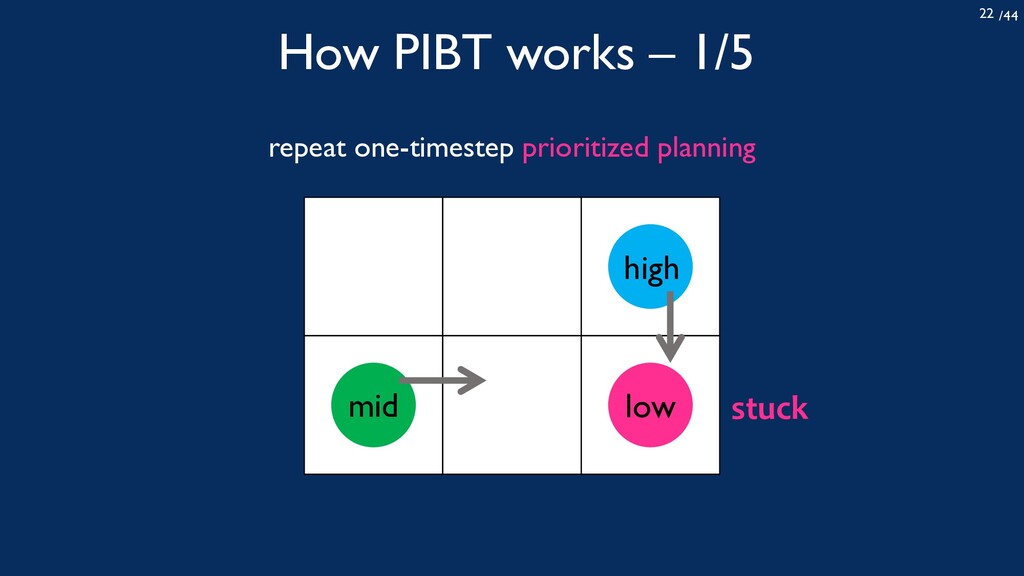
/44 22 How PIBT works – 1/5 repeat one-timestep prioritized
planning high low mid stuck -
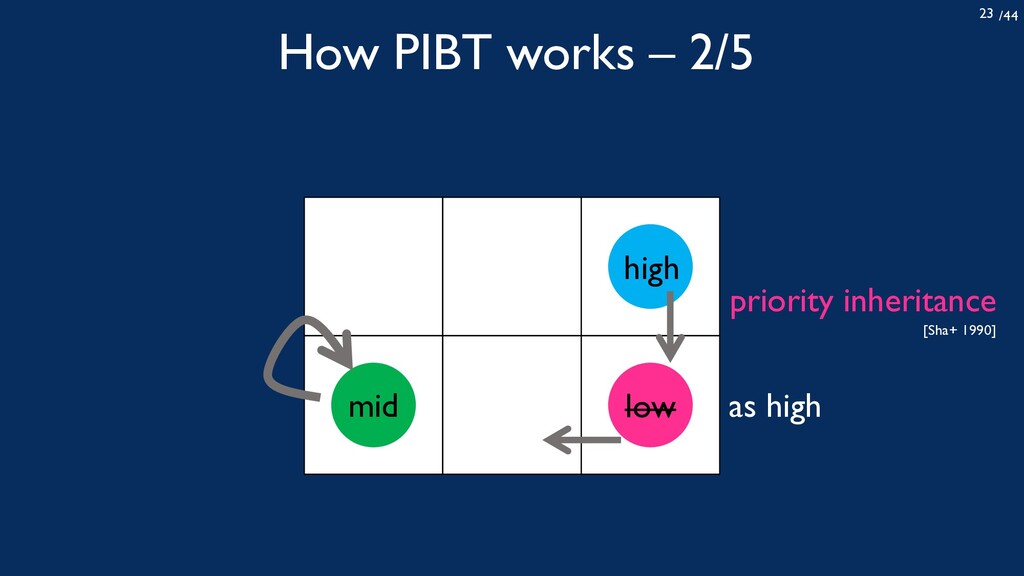
/44 23 How PIBT works – 2/5 high low mid
as high priority inheritance [Sha+ 1990] -
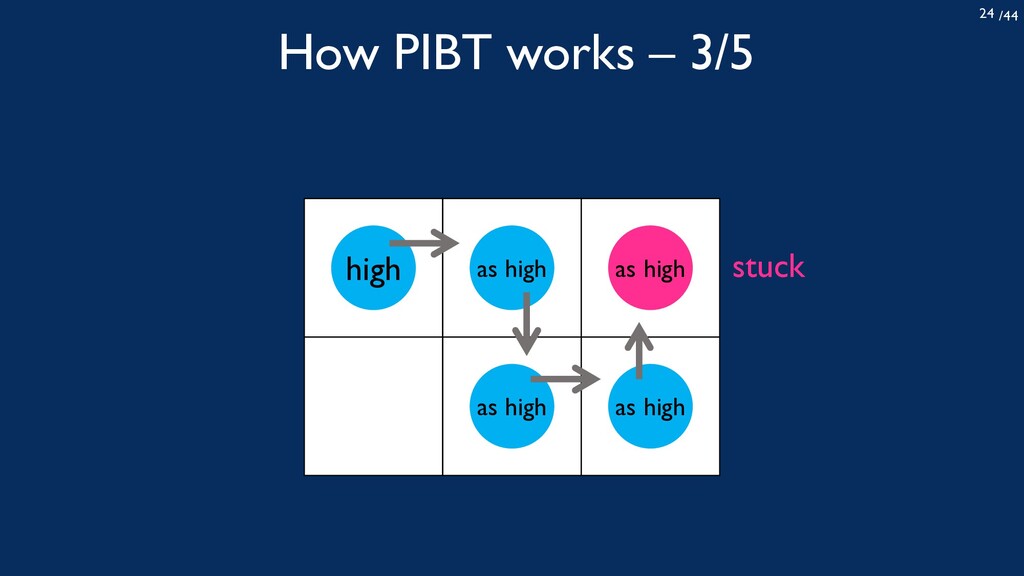
/44 24 How PIBT works – 3/5 high as high
as high as high as high stuck -
/44 25 How PIBT works – 4/5 invalid valid re-plan
re-plan valid You can move invalid You must re-plan, I will stay introduce backtracking -
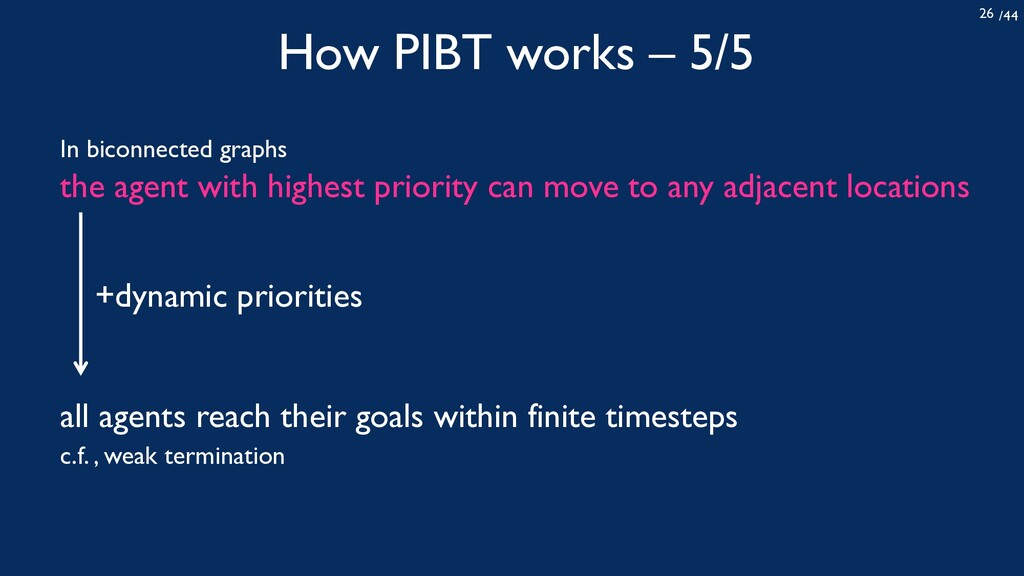
/44 26 In biconnected graphs the agent with highest priority
can move to any adjacent locations all agents reach their goals within finite timesteps +dynamic priorities c.f. , weak termination How PIBT works – 5/5 -
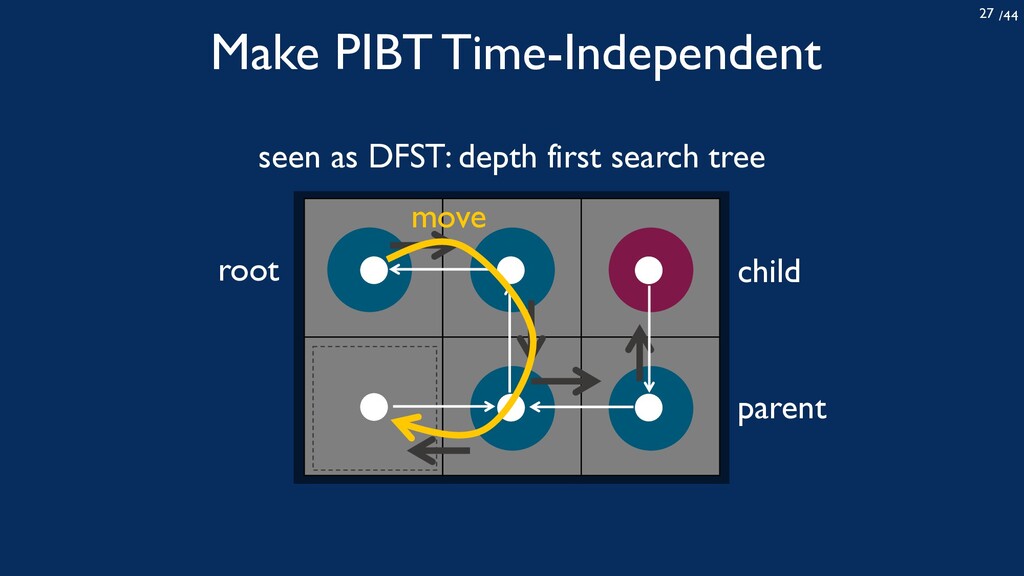
/44 27 Make PIBT Time-Independent child parent seen as DFST:
depth first search tree root move -
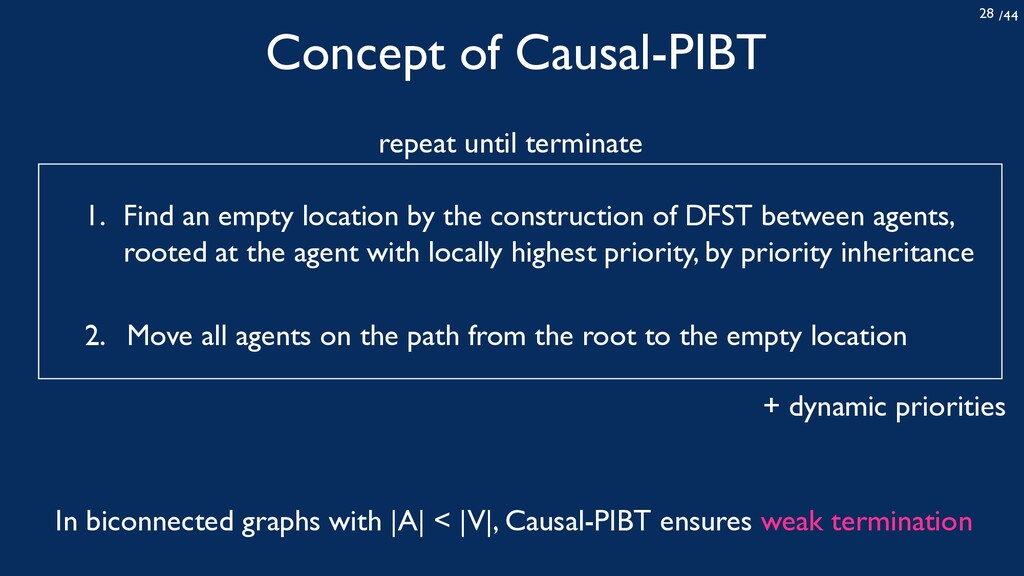
/44 28 Concept of Causal-PIBT Find an empty location by
the construction of DFST between agents, rooted at the agent with locally highest priority, by priority inheritance 1. Move all agents on the path from the root to the empty location 2. repeat until terminate + dynamic priorities In biconnected graphs with |A| < |V|, Causal-PIBT ensures weak termination -
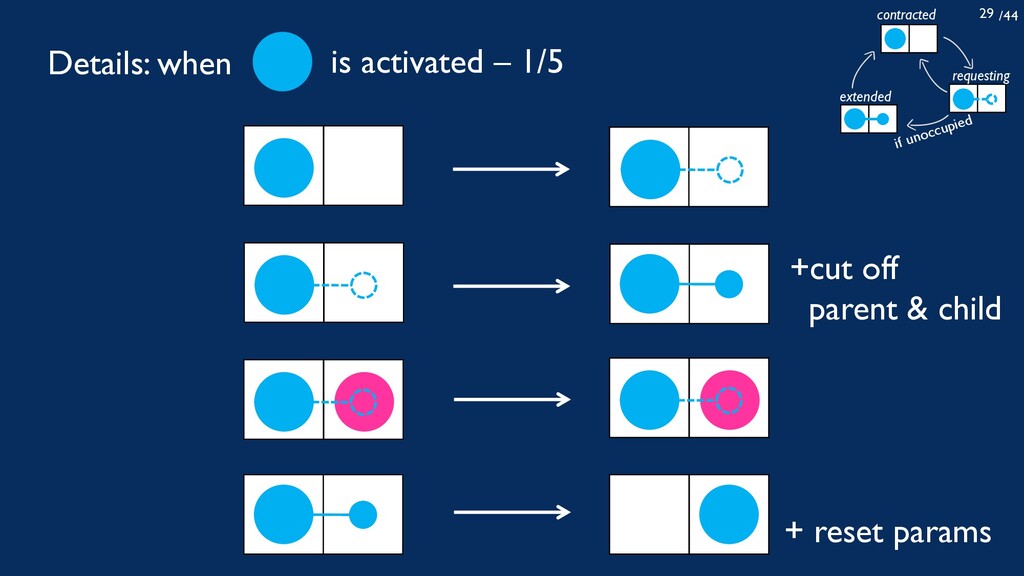
/44 29 + reset params is activated – 1/5 Details:
when +cut off parent & child contracted requesting extended if unoccupied -
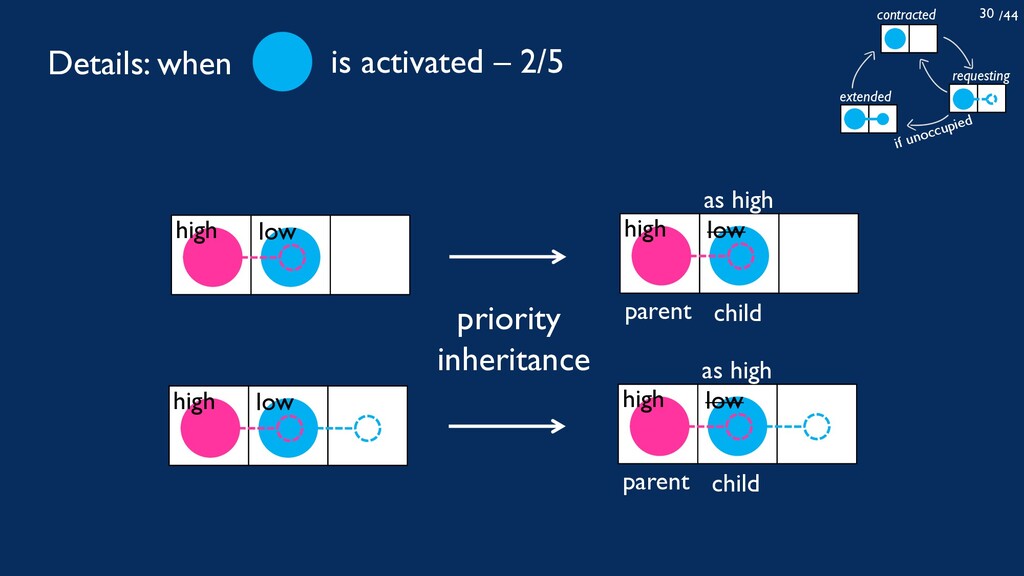
/44 30 priority inheritance high low high low as high
parent child high low high low as high parent child is activated – 2/5 Details: when contracted requesting extended if unoccupied -
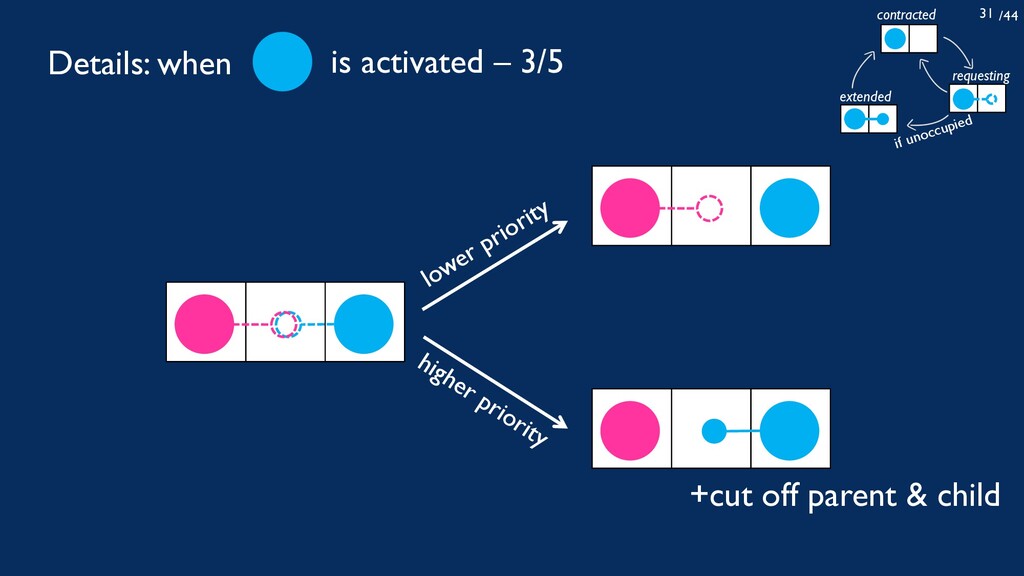
/44 31 +cut off parent & child lower priority higher
priority is activated – 3/5 Details: when contracted requesting extended if unoccupied -
/44 32 deadlock resolution ancestor stuck parent child backtracking invalid
case +prohibit to back to is activated – 4/5 Details: when +prohibit to back to contracted requesting extended if unoccupied -
/44 33 stuck child parent &root cut off child +reset
params is activated – 5/5 Details: when stuck activated cut off parent & child -
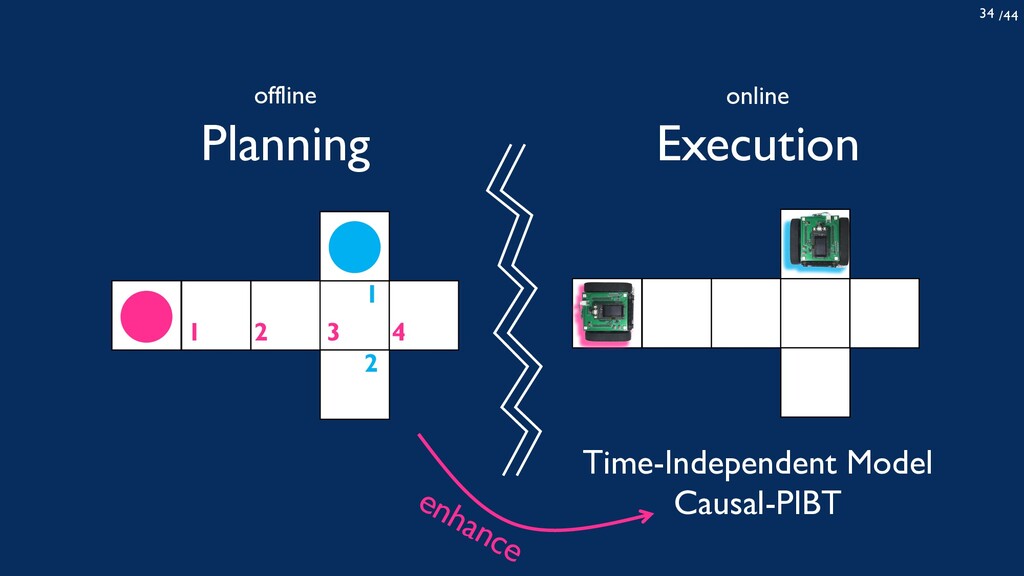
/44 34 Planning 1 2 1 2 3 4 Execution
Time-Independent Model Causal-PIBT enhance offline online -
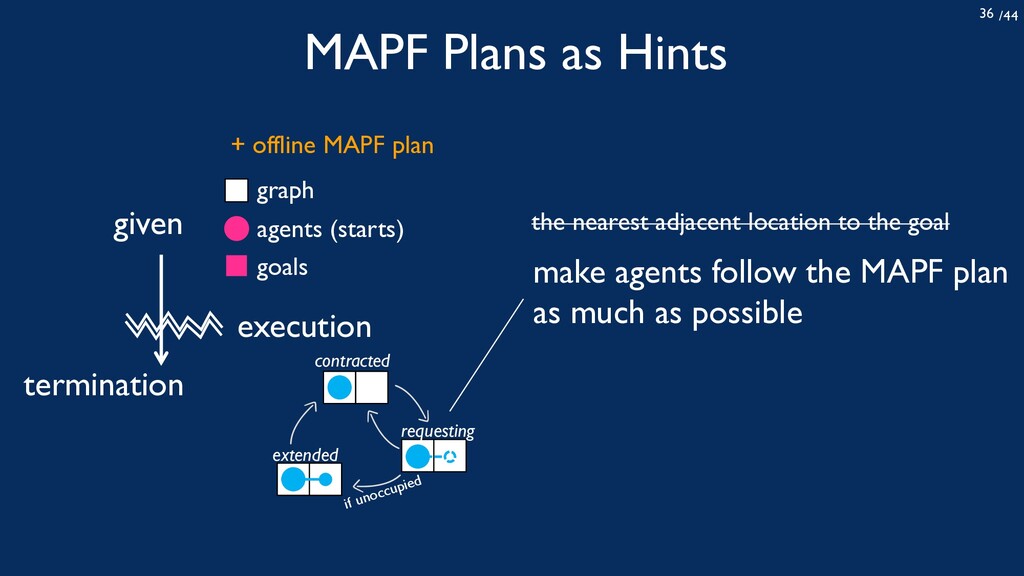
/44 36 given agents (starts) graph termination execution goals +
offline MAPF plan contracted requesting extended if unoccupied make agents follow the MAPF plan as much as possible MAPF Plans as Hints the nearest adjacent location to the goal -
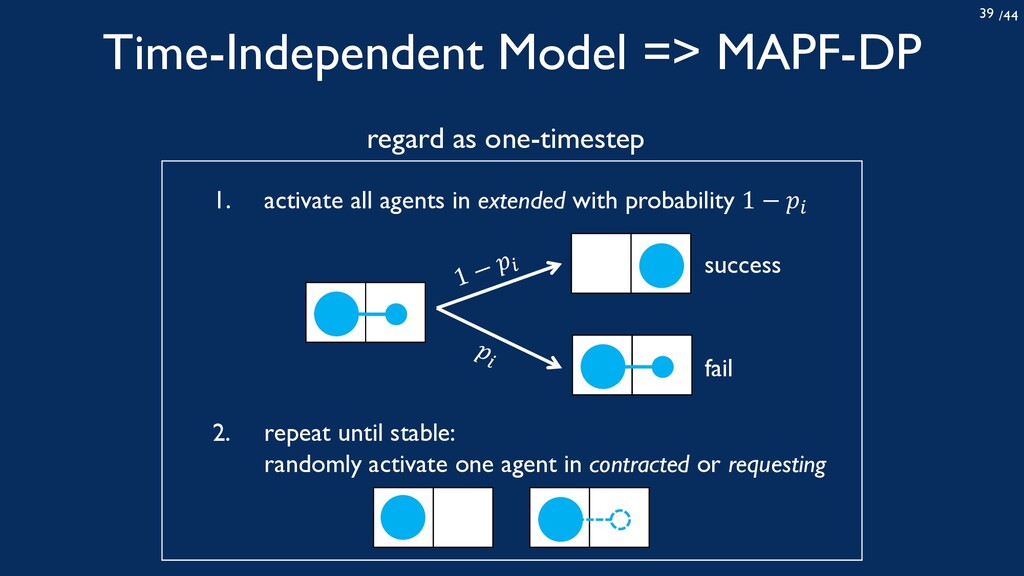
/44 38 MAPF-DP (with Delay Probabilities) [Ma+ AAAI-17] 1 −
𝑝! 𝑝 ! success fail emulate imperfect execution of MAPF plans by introducing the possibility of unsuccessful moves -
/44 39 Time-Independent Model => MAPF-DP 1. activate all agents
in extended with probability 1 − 𝑝! success fail 1 − 𝑝! 𝑝 ! 2. repeat until stable: randomly activate one agent in contracted or requesting regard as one-timestep -
/44 40 upper bound of delay probabilities 𝑝! sum of
costs x10^3 Fully Synchronous Policies Minimum Communication Policies Causal-PIBT Causal-PIBT +MAPF plan 32x32,20% obstacles 30 agents 100 repetitions MAPF plan by ECBS [Barer+ SoCS-14] Fix Agents -
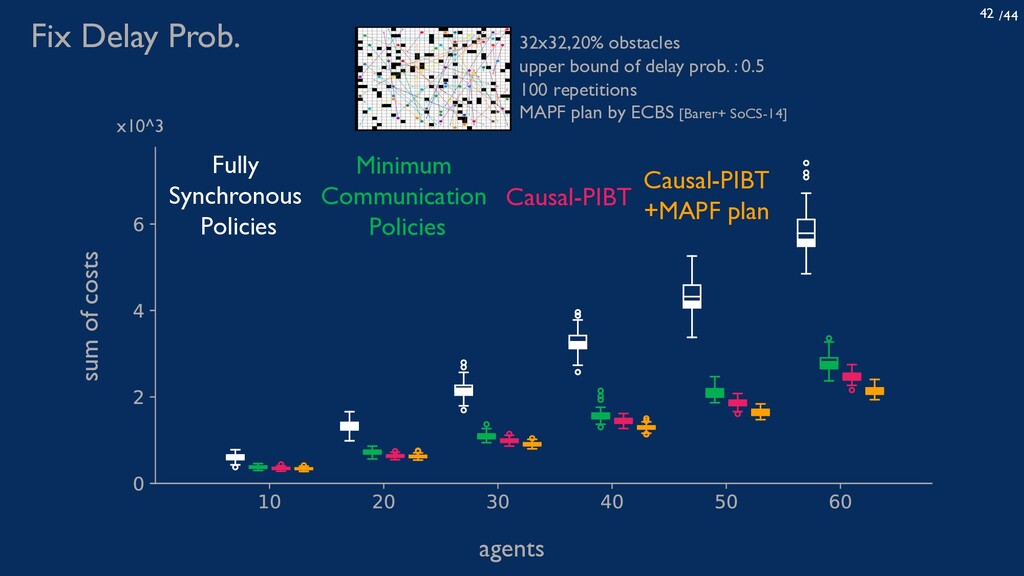
/44 42 agents sum of costs x10^3 Fully Synchronous Policies
Minimum Communication Policies Causal-PIBT Causal-PIBT +MAPF plan 32x32,20% obstacles upper bound of delay prob. : 0.5 100 repetitions MAPF plan by ECBS [Barer+ SoCS-14] Fix Delay Prob. -
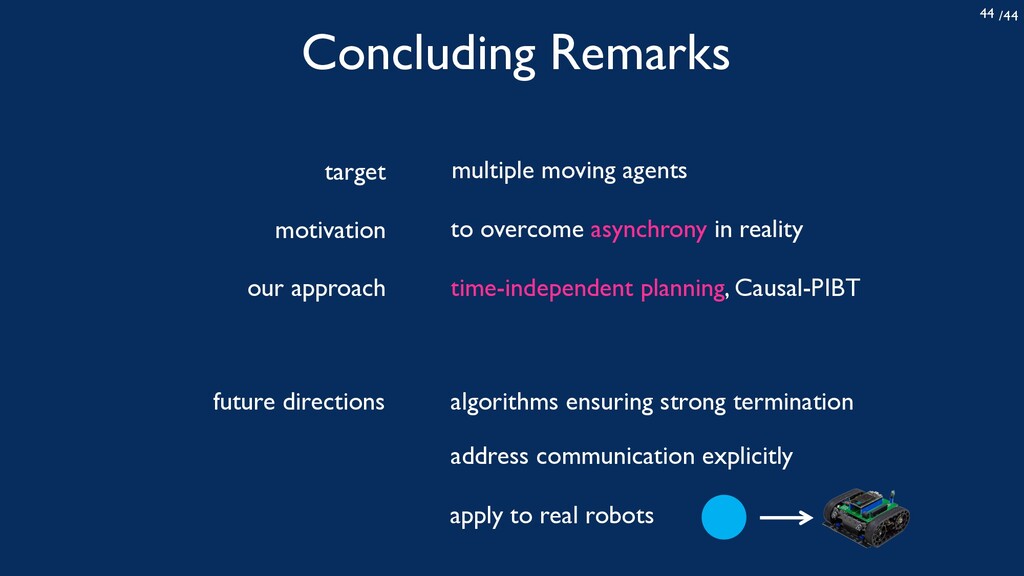
/44 44 Concluding Remarks time-independent planning, Causal-PIBT to overcome asynchrony
in reality motivation our approach target multiple moving agents algorithms ensuring strong termination future directions address communication explicitly apply to real robots