Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
Particle Filter Localization for Autonomous AUVs
Search
Sponsored
·
Your Podcast. Everywhere. Effortlessly.
Share. Educate. Inspire. Entertain. You do you. We'll handle the rest.
→
Ed Kelley
April 30, 2013
Research
42
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
Particle Filter Localization for Autonomous AUVs
Senior Thesis Presentation 2013
Ed Kelley
April 30, 2013
Other Decks in Research
See All in Research
山中市政の総括:相反する二つの顔
sishi
0
220
LA-Bench 2025:実験指示から 実行可能手順を生成するためのデータセット/LA-Bench 2025: A Dataset for Generating Executable Experimental Procedures from Experimental Instructions
stktu
0
200
Adapter les bergeries aux fortes chaleurs
institutdelelevage
PRO
0
140
OWASP AISVS - C7
shiell
2
830
Kaggle|AI Agent Security — しくじり先生、俺みたいになるな
pomcho555
1
120
TESSERA: Temporal Embeddings of Surface Spectra for Earth Representation and Analysis
satai
3
120
XDPerf: A High-Performance Traffic Generator Built with WASM and eBPF
takehaya
1
340
Cross-Media Human-Information Interaction
signer
PRO
0
280
モデル評価を効率的にする方法
ftakahashi
0
220
2026年6月_副業コンプライアンス調査_業界別リスク度分析_株式会社フクスケ.pdf
fkske
0
130
Hitting the buffers
beale
0
280
湯村研究室の紹介2026 / yumulab2026
yumulab
0
130
Featured
See All Featured
Refactoring Trust on Your Teams (GOTO; Chicago 2020)
rmw
35
3.8k
RailsConf & Balkan Ruby 2019: The Past, Present, and Future of Rails at GitHub
eileencodes
141
35k
Sharpening the Axe: The Primacy of Toolmaking
bcantrill
46
3k
The Anti-SEO Checklist Checklist. Pubcon Cyber Week
ryanjones
0
270
[RailsConf 2023] Rails as a piece of cake
palkan
59
7.1k
[SF Ruby Conf 2025] Rails X
palkan
3
1.5k
世界の人気アプリ100個を分析して見えたペイウォール設計の心得
akihiro_kokubo
PRO
74
43k
The MySQL Ecosystem @ GitHub 2015
samlambert
251
13k
Lightning talk: Run Django tests with GitHub Actions
sabderemane
0
300
Stewardship and Sustainability of Urban and Community Forests
pwiseman
0
550
Designing Dashboards & Data Visualisations in Web Apps
destraynor
232
55k
"I'm Feeling Lucky" - Building Great Search Experiences for Today's Users (#IAC19)
danielanewman
230
23k
Transcript
Particle Filter Localization for Autonomous AUVs Using Augmented Reality Tags
Ed Kelley, 2013 Szymon Rusinkiewicz
aka
Where is the Quadcopter?
Motivation
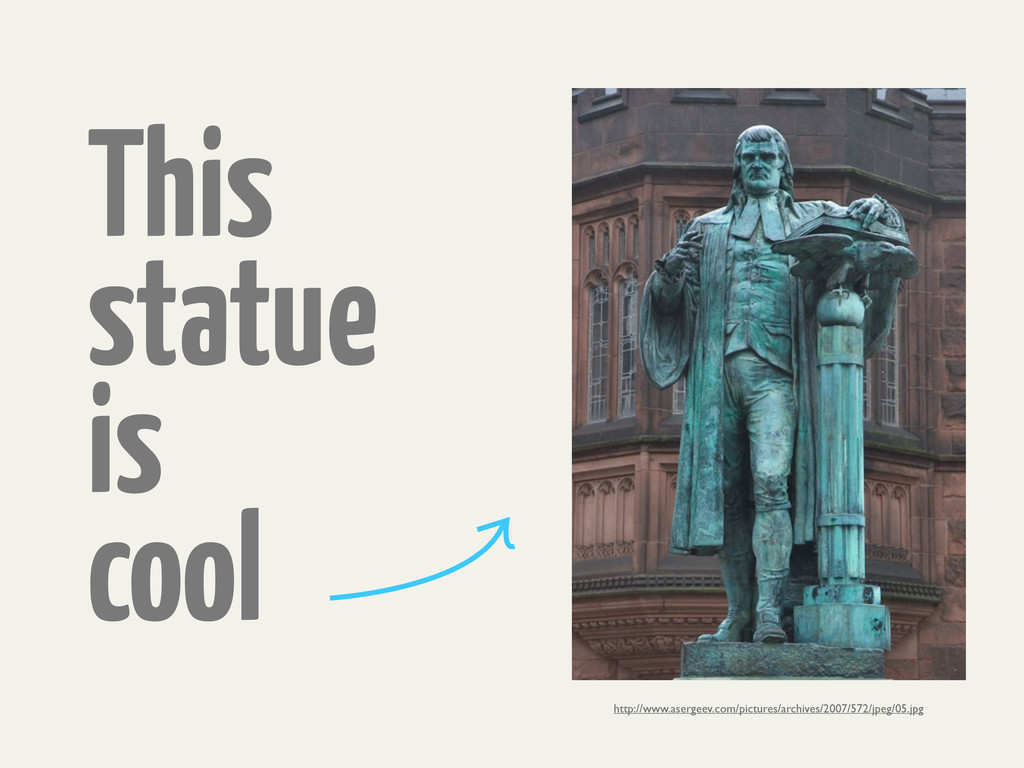
This statue is cool http://www.asergeev.com/pictures/archives/2007/572/jpeg/05.jpg
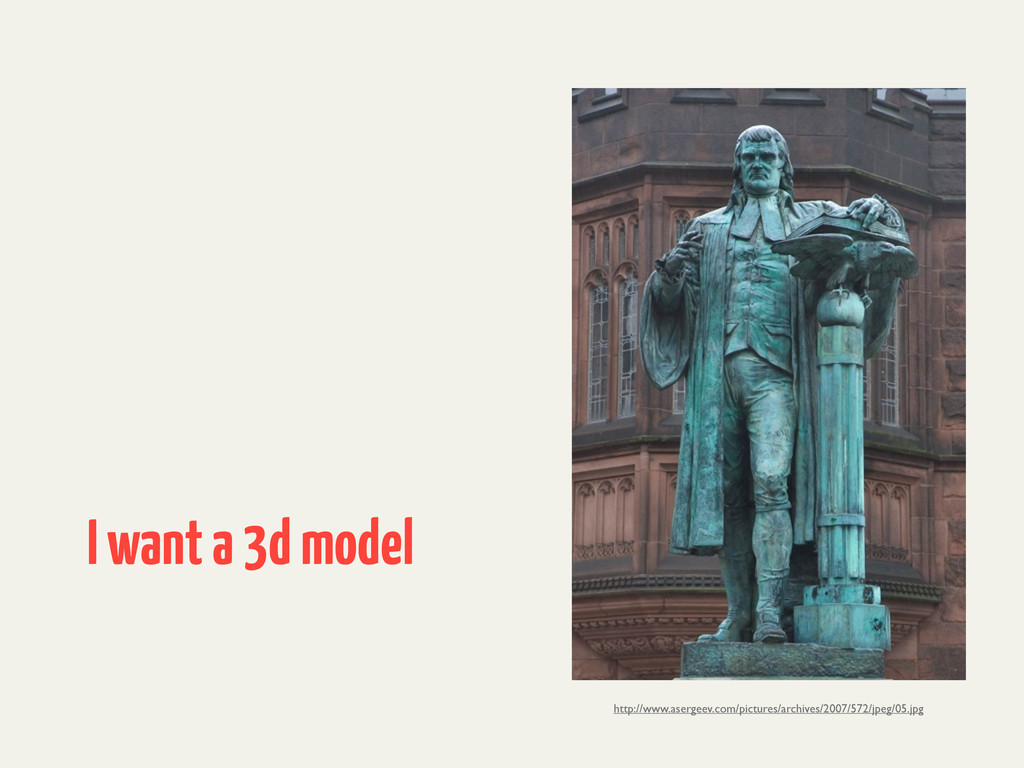
I want a 3d model http://www.asergeev.com/pictures/archives/2007/572/jpeg/05.jpg
Video Games Virtual Reality Movies Archeology Architecture Maps Crash Scenes
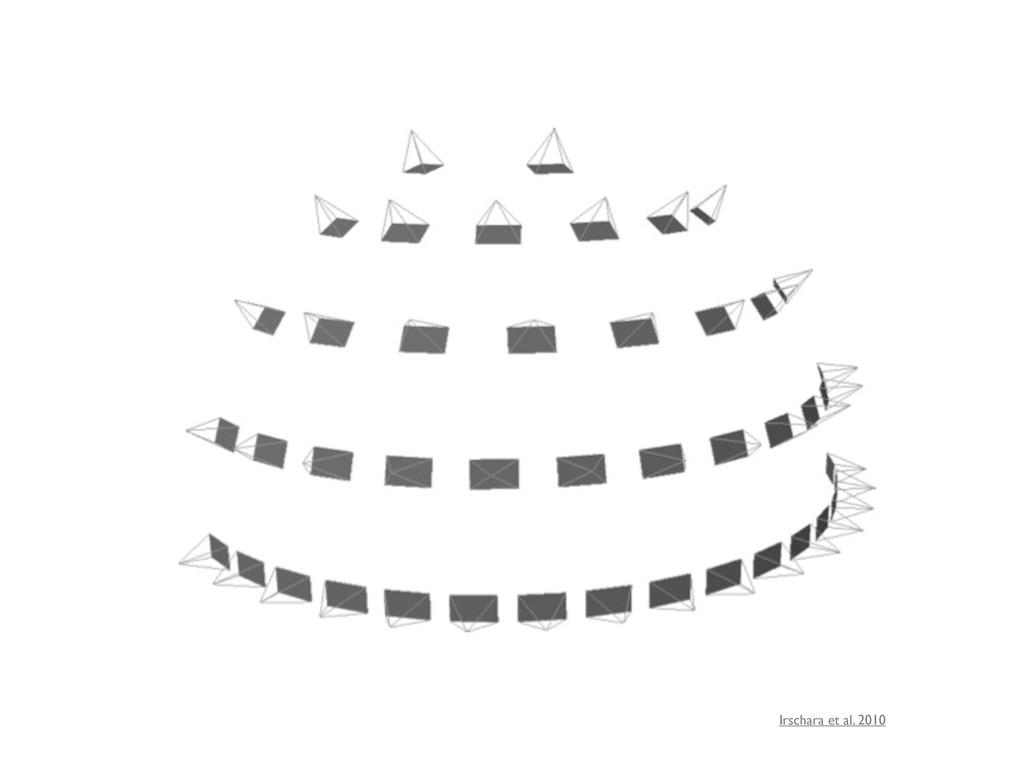
Manual Modeling? Laser Scanner? Multi-View Stereo? Microsoft Kinect?
Manual Modeling? Laser Scanner? Multi-View Stereo? Microsoft Kinect?
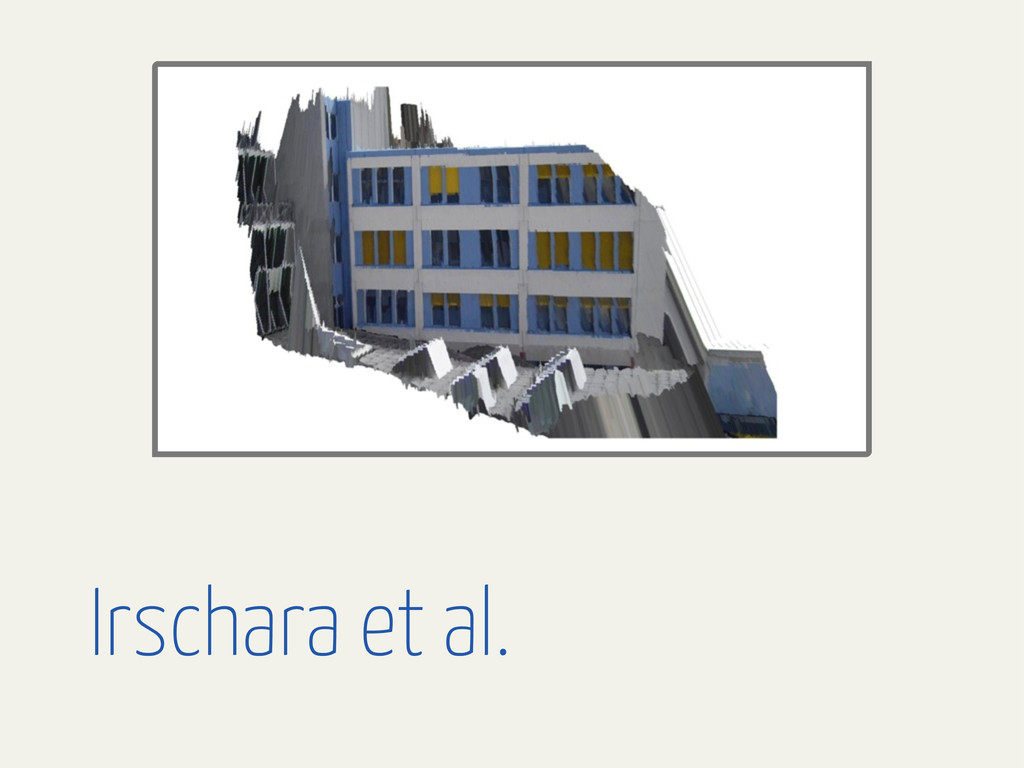
Irschara et al. 2010
Easy Cheap Complete High Quality
Quadcopters!
Related Work
Irschara et al.
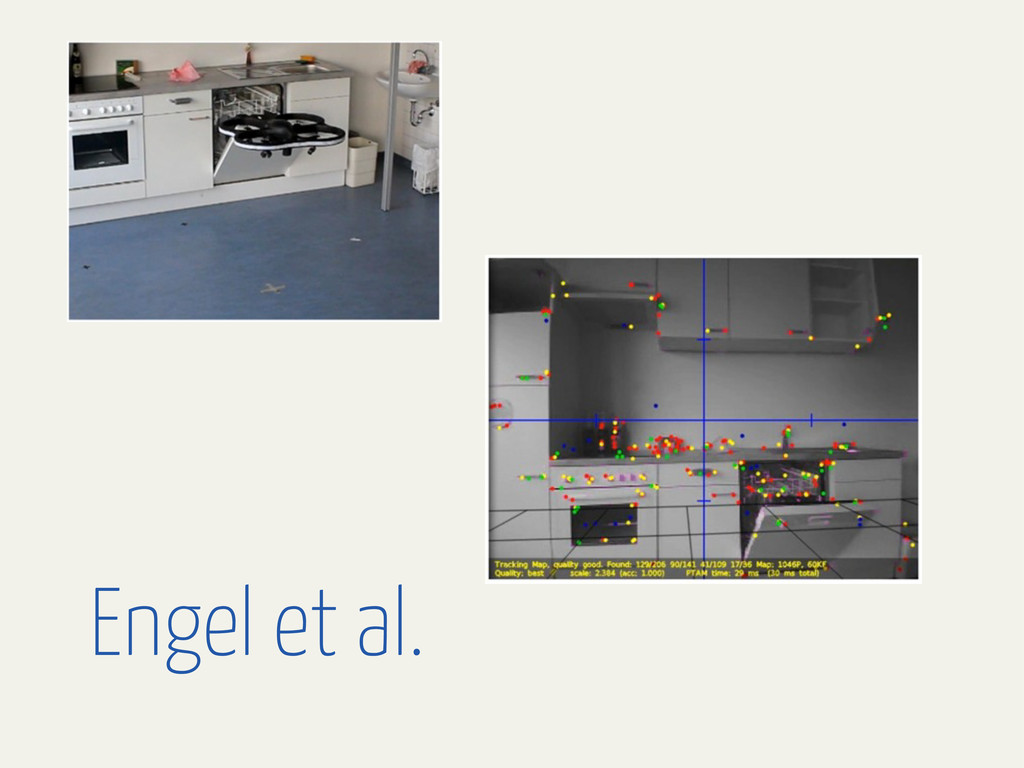
Engel et al.
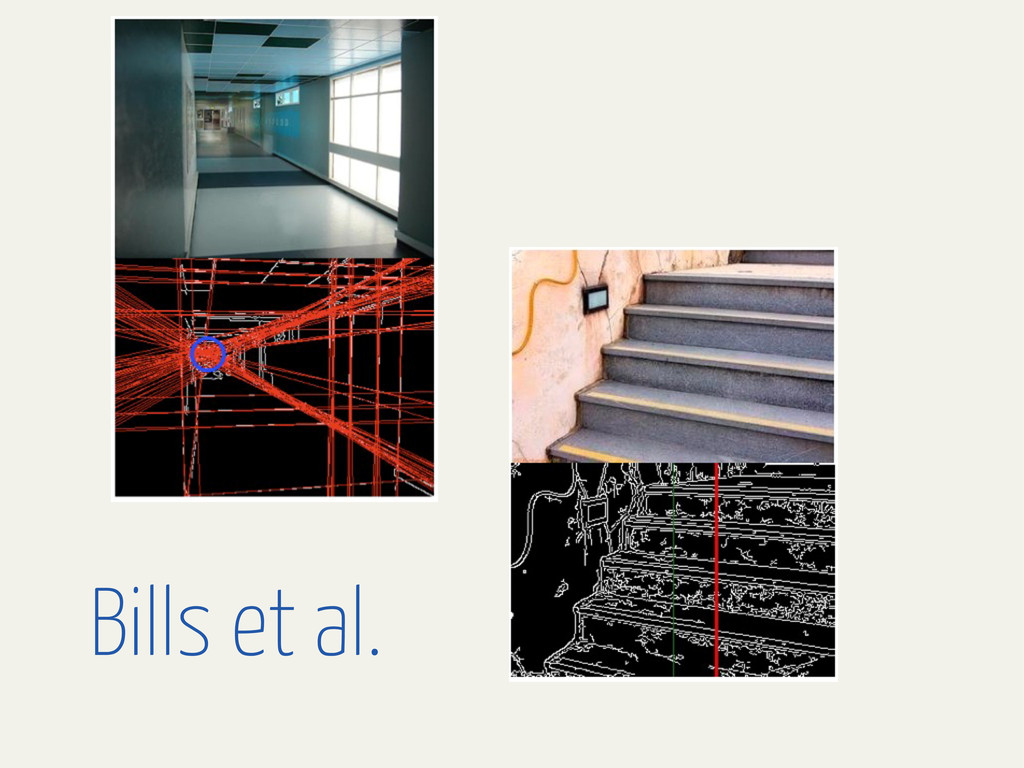
Bills et al.
System Design
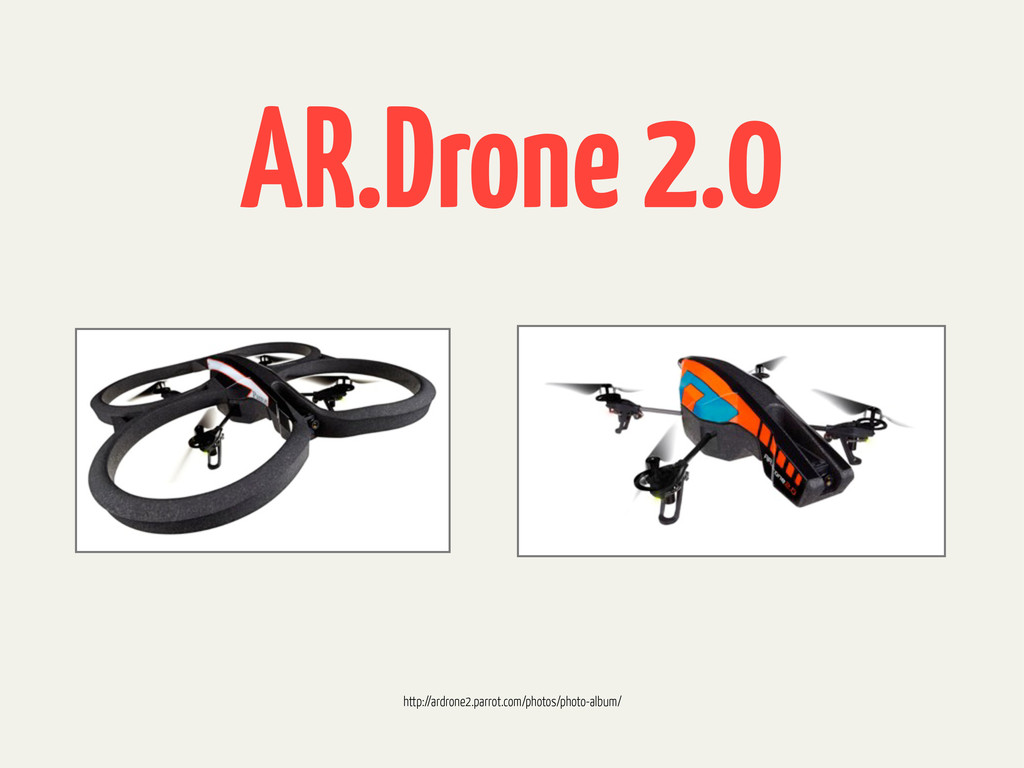
AR.Drone 2.0 http://ardrone2.parrot.com/photos/photo-album/
None
Localization + Controller = Autonomy
Localization
Local drift. tend to measurements
No GPS No rangefinders
None
Kalman Filter? Grid Based Markov? Particle Filter?
Kalman Filter? Grid Based Markov? Particle Filter?
. This is a particle
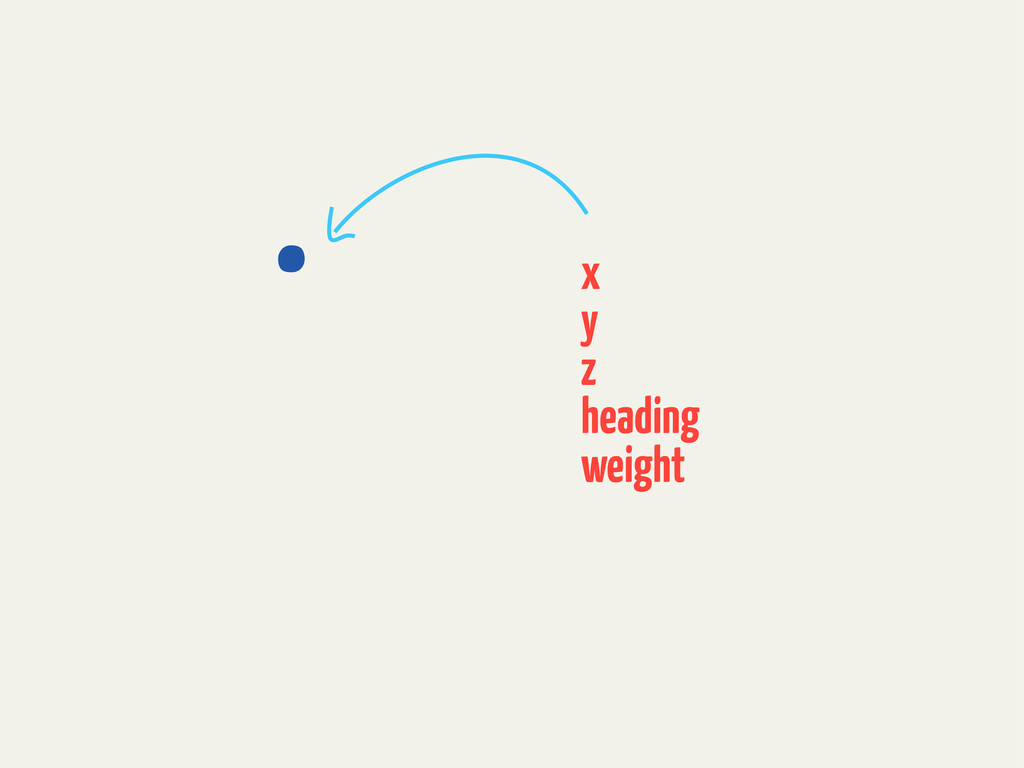
. It represents a possible pose
. x y z heading weight
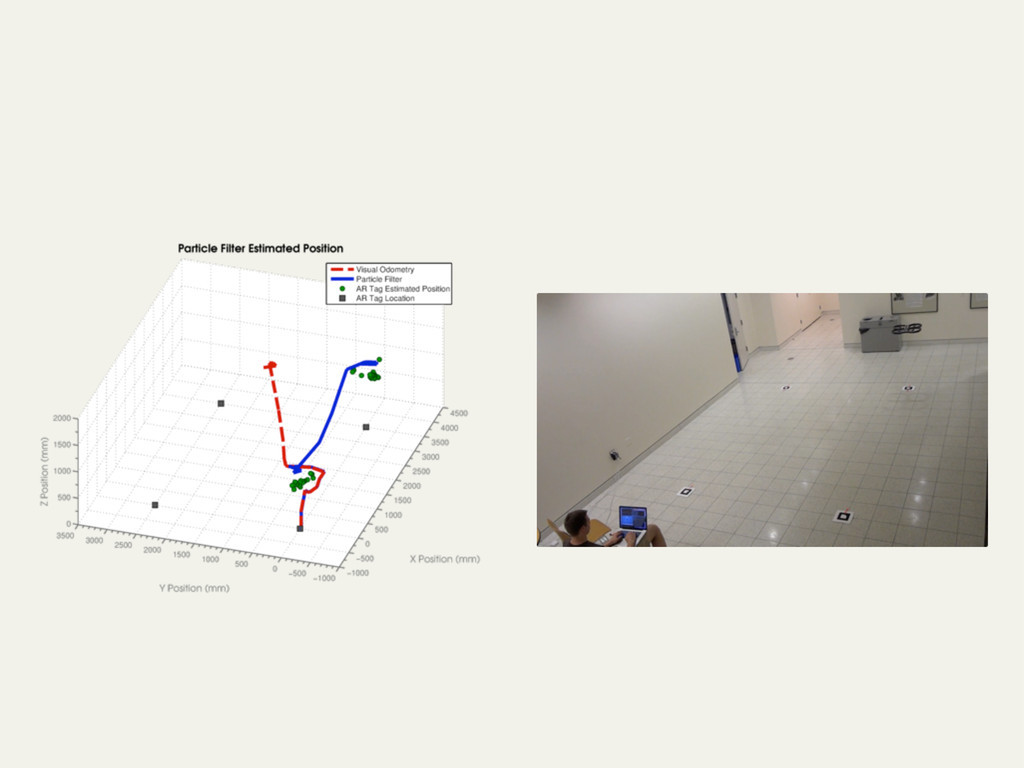
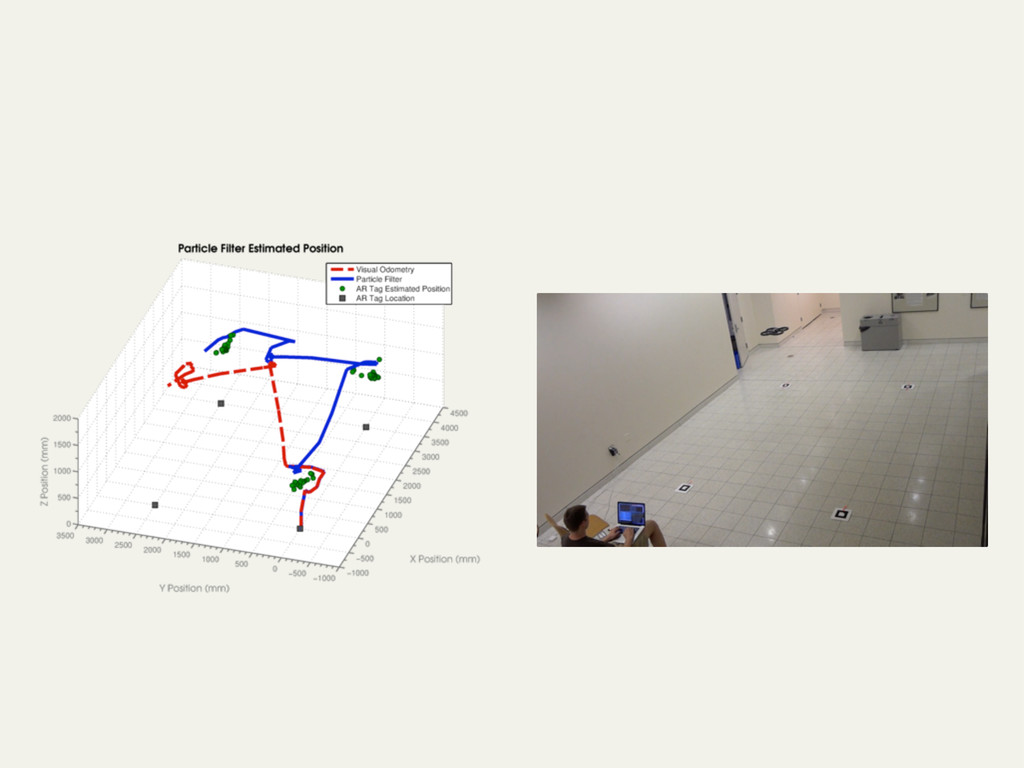
Prediction Step Update the position of each particle using noisy
velocity and gyroscope readings.
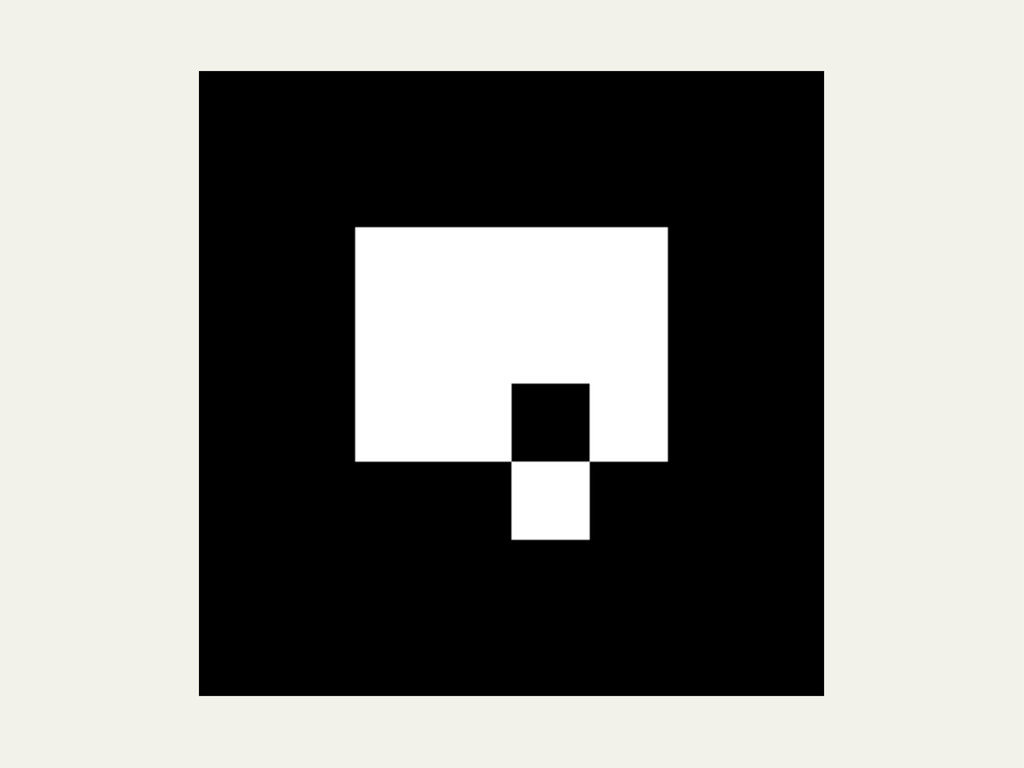
Correction Step 1. Check for an augmented reality tag. 2.
Calculate transformation from camera to tag. 3. Use known coordinates of the tag to calculate the position of the quadcopter.
Correction Step 4. Weight the particles using their similarity to
this calculated position. 5. Perform weighted resampling of the particles. 6. With some probability, replace particles with this calculated position.
Estimate Use a linear combination of the particle values to
create an estimated pose.
Testing
Gyroscope
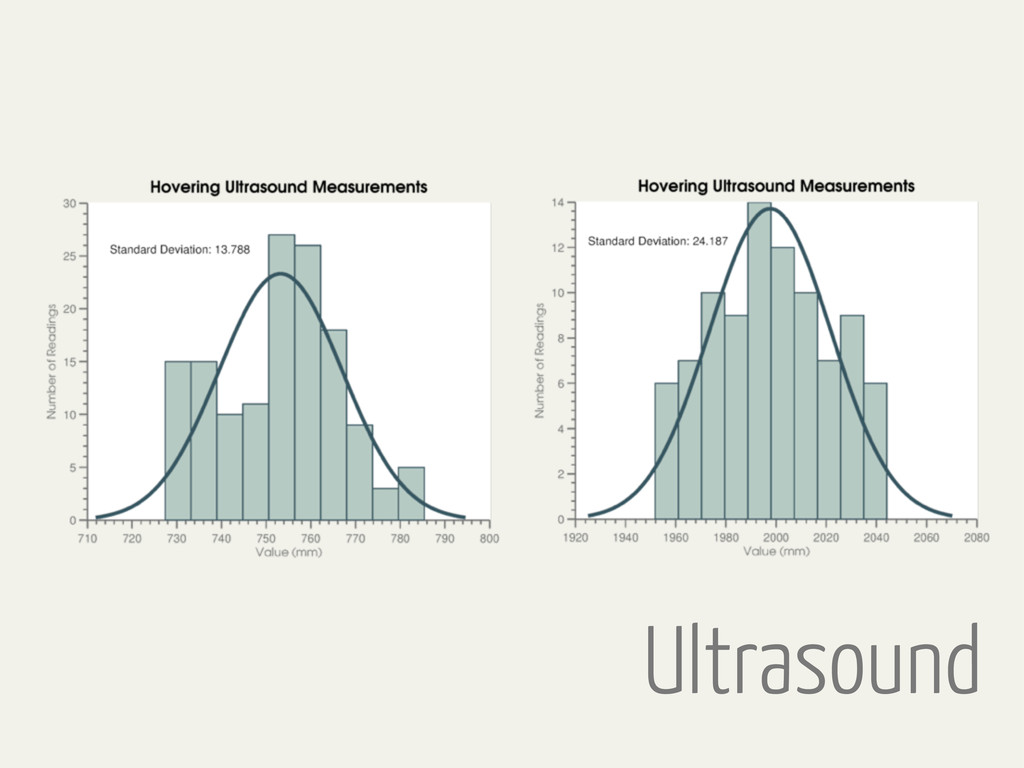
Ultrasound
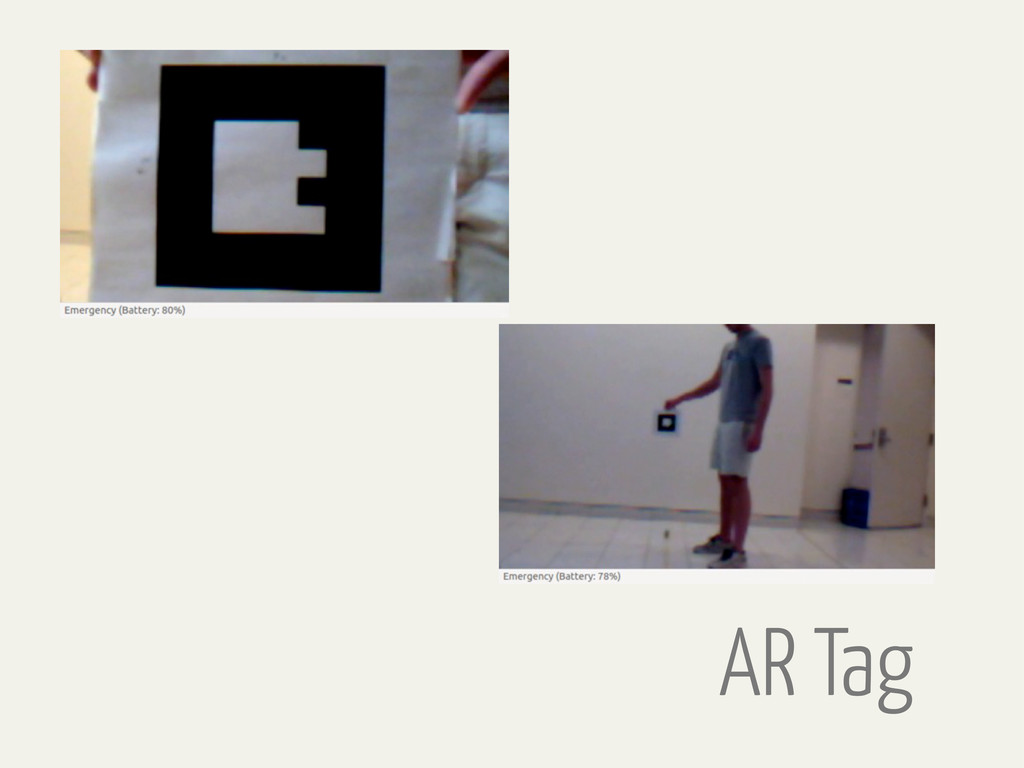
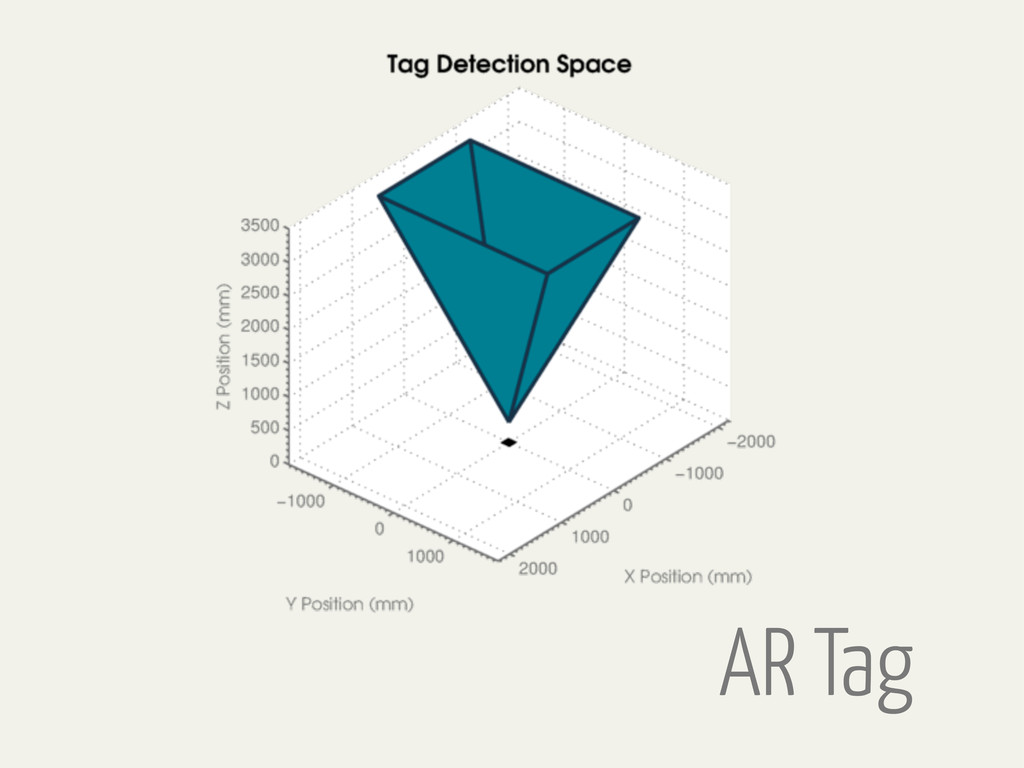
AR Tag
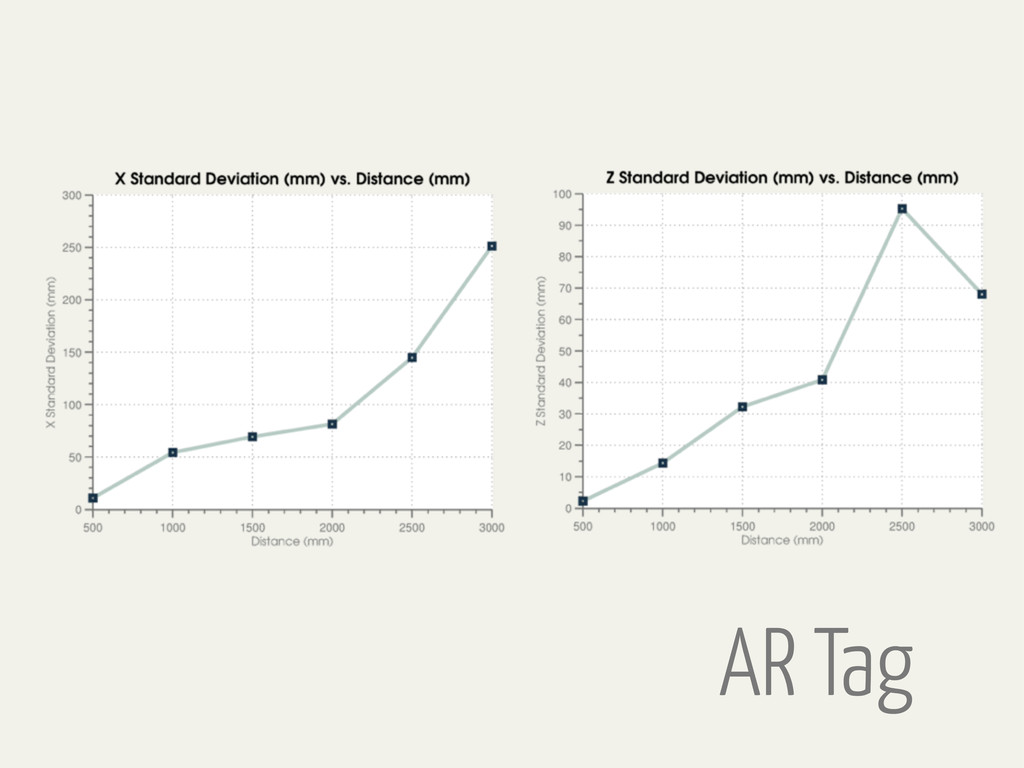
AR Tag
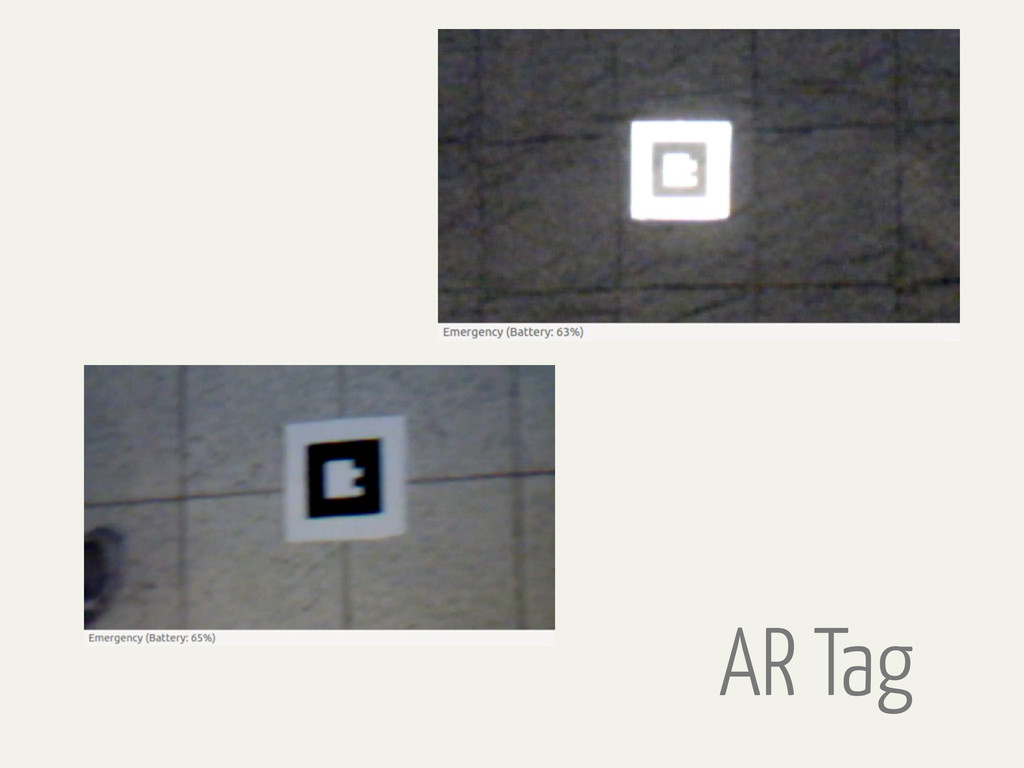
AR Tag
AR Tag
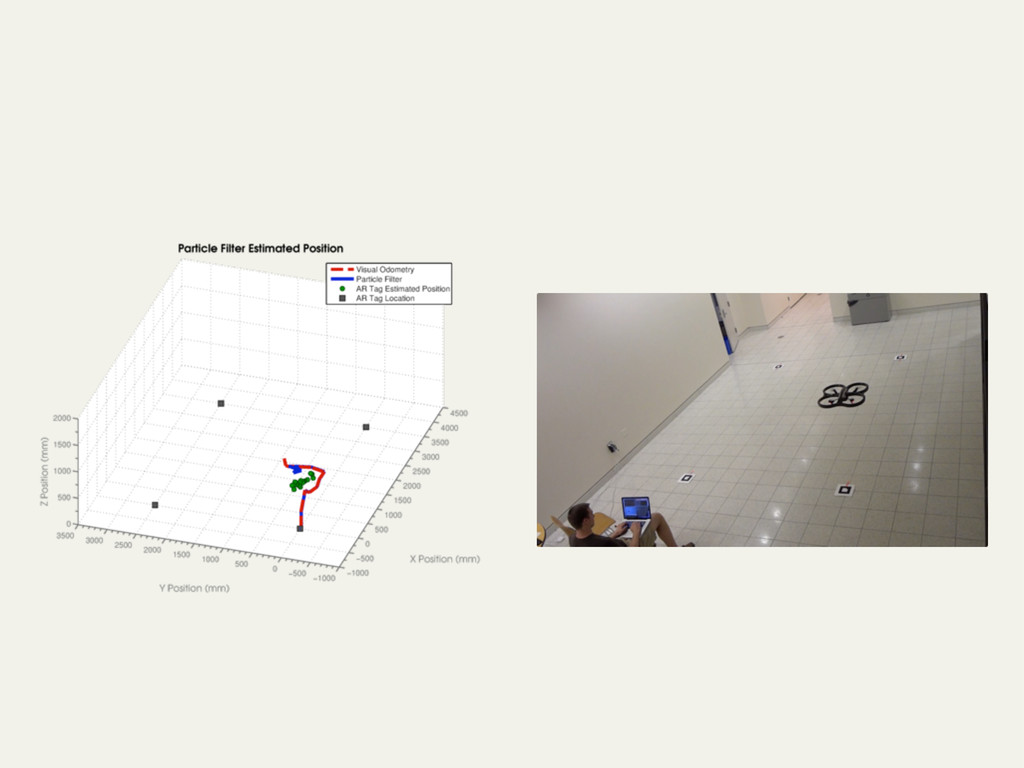
Manual Flight Test
None
None
None
None
None
Conclusion
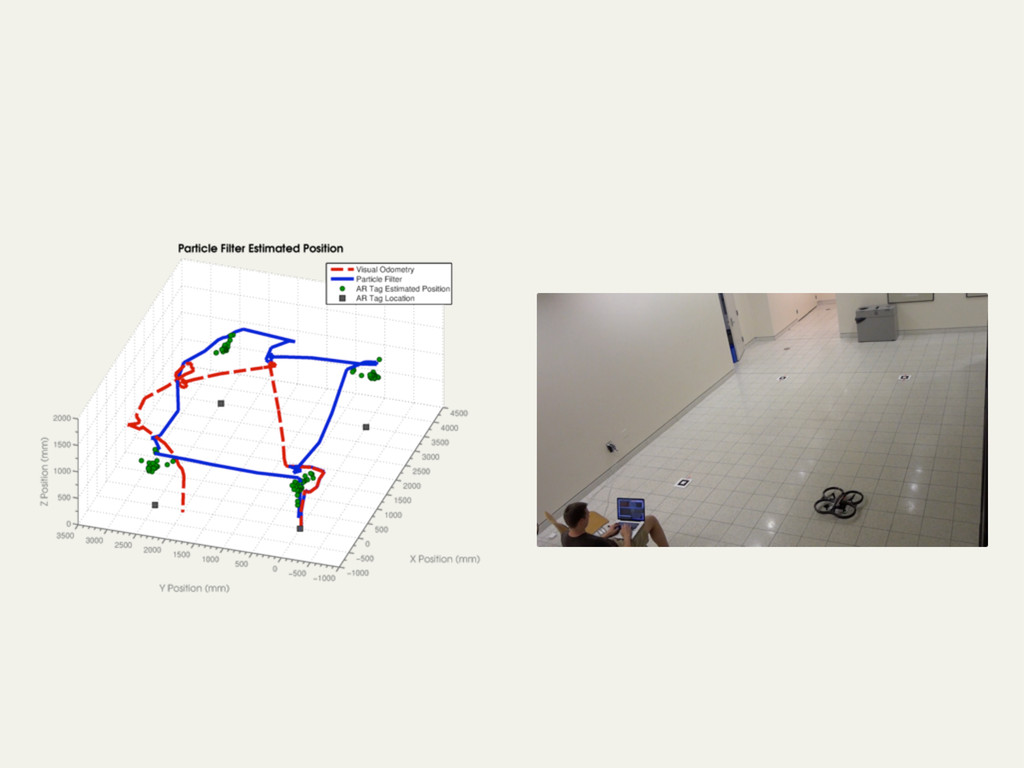
Particle filter localization using augmented reality tags performs substantially better
than integrated velocity alone.
AR Tags are highly dependent on lighting.
Its called Hardware for a reason.
Next steps... Full integration with controller. Modeling objects.
Thanks!

 Your Podcast. Everywhere. Effortlessly.


 sishi
 stktu
 institutdelelevage
 shiell
 pomcho555
 satai
 takehaya
 signer
 ftakahashi
 fkske
 beale
 yumulab
 rmw
 eileencodes
 bcantrill
 ryanjones
 palkan
 akihiro_kokubo
 samlambert
 sabderemane
 pwiseman
 destraynor
 danielanewman