Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
Physical computing with GPIO Zero - Peterboroug...
Search
Sponsored
·
Ship Features Fearlessly
Turn features on and off without deploys. Used by thousands of Ruby developers.
→
Ben Nuttall
November 28, 2015
Programming
800
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
Physical computing with GPIO Zero - Peterborough Raspberry Jam
Getting started with GPIO Zero talk given at Peterborough Raspberry Jam
Ben Nuttall
November 28, 2015
More Decks by Ben Nuttall
See All by Ben Nuttall
Numeronyms are obnoxious
bennuttall
1
780
Live Highlights in BBC iPlayer
bennuttall
0
200
Rapid prototyping in BBC News with Python and AWS
bennuttall
0
260
Rapid prototyping in BBC News with Python and AWS
bennuttall
0
200
Running a Python Package Index for Raspberry Pi
bennuttall
0
220
From Acorns to Raspberries
bennuttall
0
190
Innovation in the newsroom
bennuttall
0
250
Innovation in the newsroom - MOS Running Order Manager
bennuttall
0
270
How to market your open source project
bennuttall
0
310
Other Decks in Programming
See All in Programming
クラウドエージェントは、 何がそんなに便利なのか / what makes cloud agents so useful
rkaga
5
800
선언형 햅틱 라이브러리 진동을 소개합니다
l2hyunwoo
1
300
AIが生成したコードは読むべきか?抽象化設計とコードの品質保証 / abstraction-design-and-quality
minodriven
16
8.8k
複数ドメインを一つのアプリに統合するFlutterの設計と運用_FlutterKaigi2026登壇資料(須永高弘)
takahirosunaga
0
160
学びを記事・スライド・Xへ高速展開する― AI-assisted Learning Loopで回すコンテンツ生成術
ochtum
0
200
[DroidKnights 2026] Workflow AX: From Auto-Documented Policies to E2E Testing
raeminkang
0
540
社内AIエージェント「Askワンバン」における コストチューニングの取り組み
t0yohei
0
160
地方こそサーバーレス — 10年続けた、顔が見えるチームで確かな基盤を / Serverless Matters Most in Regional Areas — 10 Years of Building Reliable Foundations with Close-Knit Teams
seike460
PRO
1
280
AI時代のシニアエンジニアとは
yosuke_furukawa
PRO
15
11k
AI時代のIaC入門 〜なぜインフラをコードで管理したいのか?〜 / Introduction to IaC in the AI Era
akihisaikeda
6
1.4k
作れる、でも消せるか?──安全に「枯らして消す」機能削除術 / Drain, Then Delete
chobishiba
3
1.4k
Web Framework Benchmark Battle 2026, Any%
a_matsuda
3
3.2k
Featured
See All Featured
Navigating Algorithm Shifts & AI Overviews - #SMXNext
aleyda
1
1.7k
Visualizing Your Data: Incorporating Mongo into Loggly Infrastructure
mongodb
50
10k
BBQ
matthewcrist
90
10k
Rails Girls Zürich Keynote
gr2m
96
14k
Paper Plane
katiecoart
PRO
5
55k
Jess Joyce - The Pitfalls of Following Frameworks
techseoconnect
PRO
1
470
Primal Persuasion: How to Engage the Brain for Learning That Lasts
tmiket
0
520
Heart Work Chapter 1 - Part 1
lfama
PRO
10
37k
Amusing Abliteration
ianozsvald
1
380
SEO in 2025: How to Prepare for the Future of Search
ipullrank
3
3.9k
The Pragmatic Product Professional
lauravandoore
37
7.5k
Documentation Writing (for coders)
carmenintech
77
5.6k
Transcript
Physical computing with GPIO Zero Ben Nuttall Raspberry Pi Foundation
UK Charity 1129409
Ben Nuttall • Education Developer Advocate at the Raspberry Pi
Foundation – Software & project development – Learning resources & teacher training – Outreach • Hobbyist turned employee • Based in Cambridge (but from the North) • @ben_nuttall on Twitter
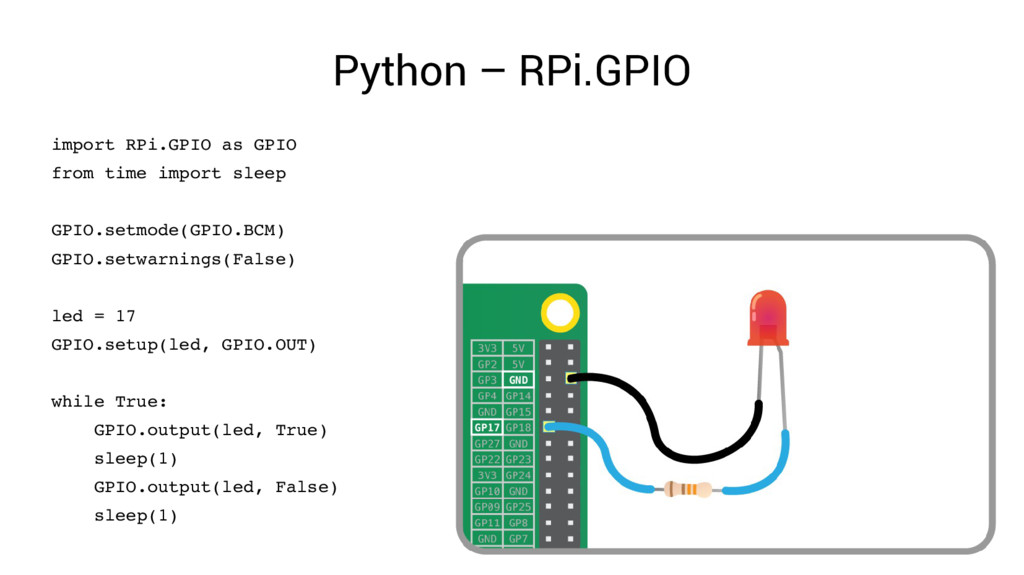
Python – RPi.GPIO import RPi.GPIO as GPIO from time import
sleep GPIO.setmode(GPIO.BCM) GPIO.setwarnings(False) led = 17 GPIO.setup(led, GPIO.OUT) while True: GPIO.output(led, True) sleep(1) GPIO.output(led, False) sleep(1)
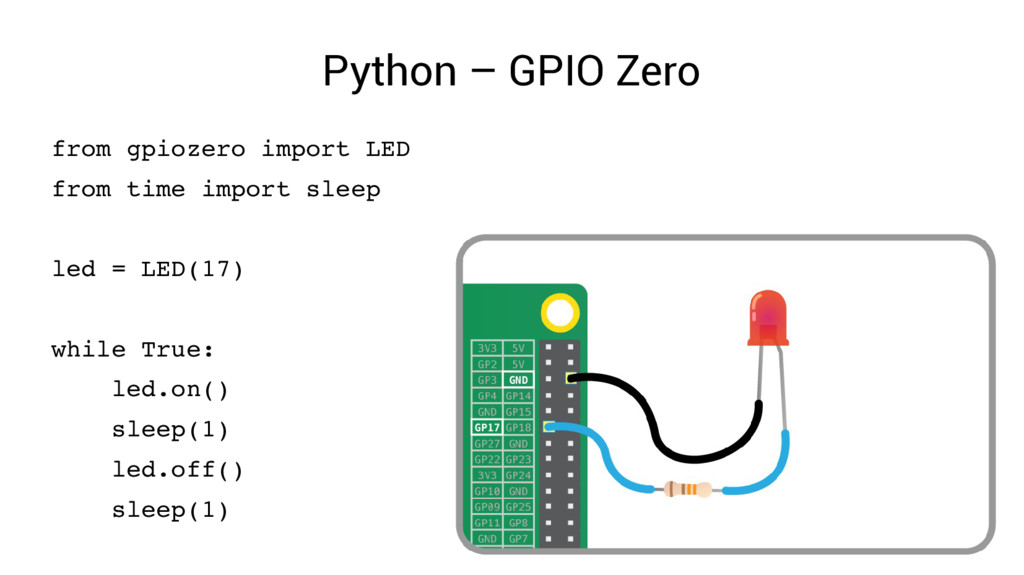
Python – GPIO Zero from gpiozero import LED from time
import sleep led = LED(17) while True: led.on() sleep(1) led.off() sleep(1)
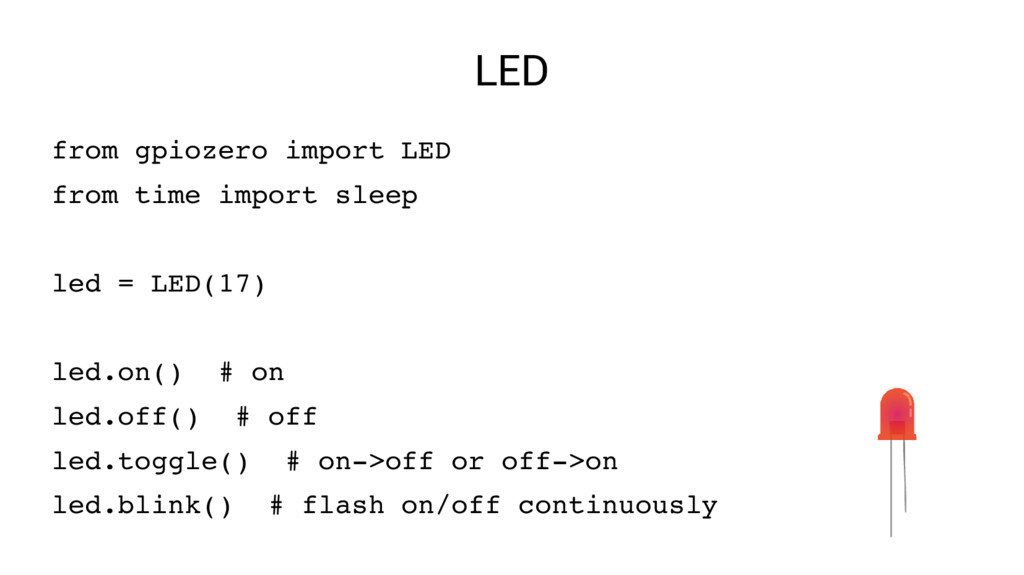
LED from gpiozero import LED from time import sleep led
= LED(17) led.on() # on led.off() # off led.toggle() # on>off or off>on led.blink() # flash on/off continuously
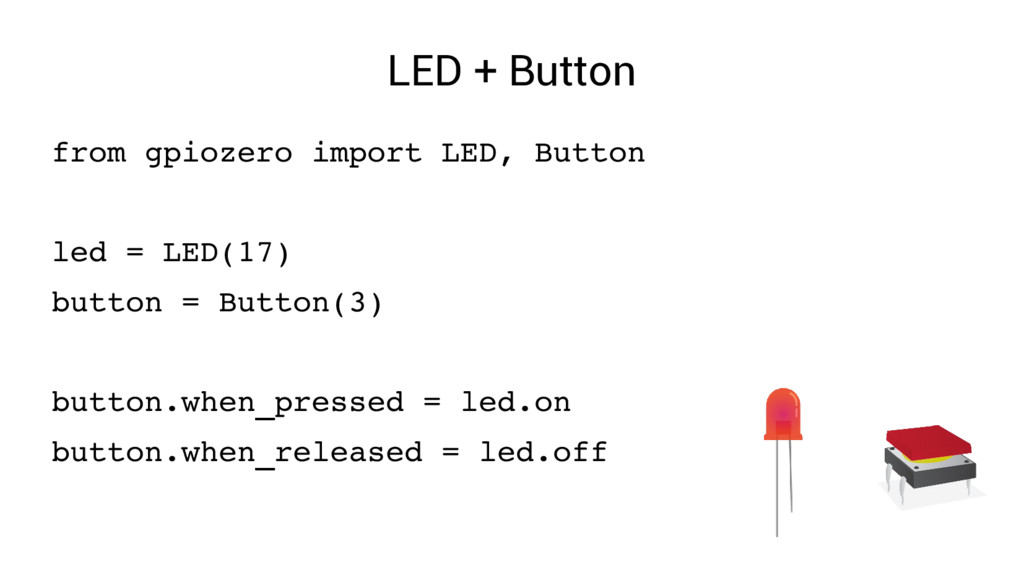
LED + Button from gpiozero import LED, Button led =
LED(17) button = Button(3) button.when_pressed = led.on button.when_released = led.off
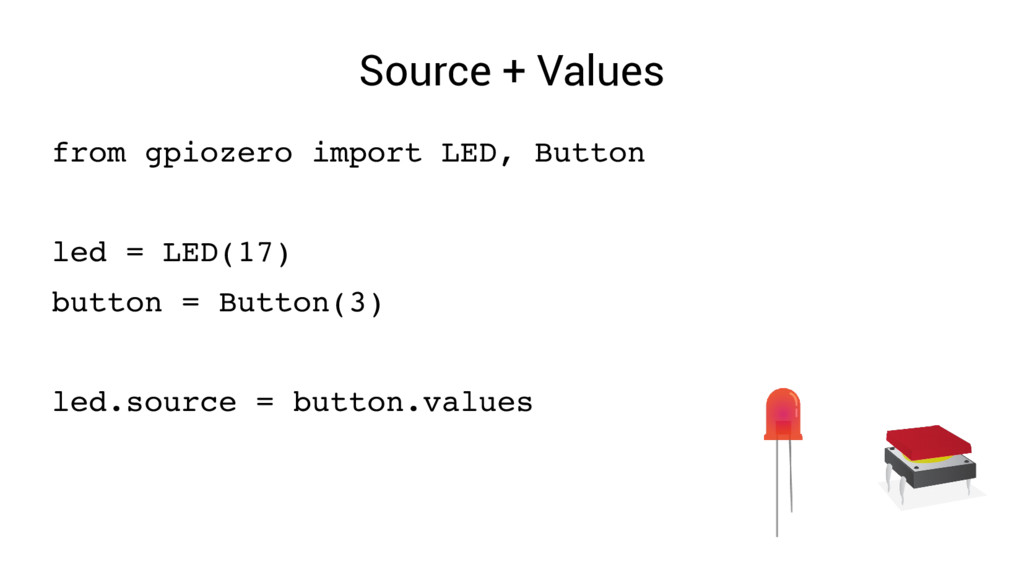
Source + Values from gpiozero import LED, Button led =
LED(17) button = Button(3) led.source = button.values
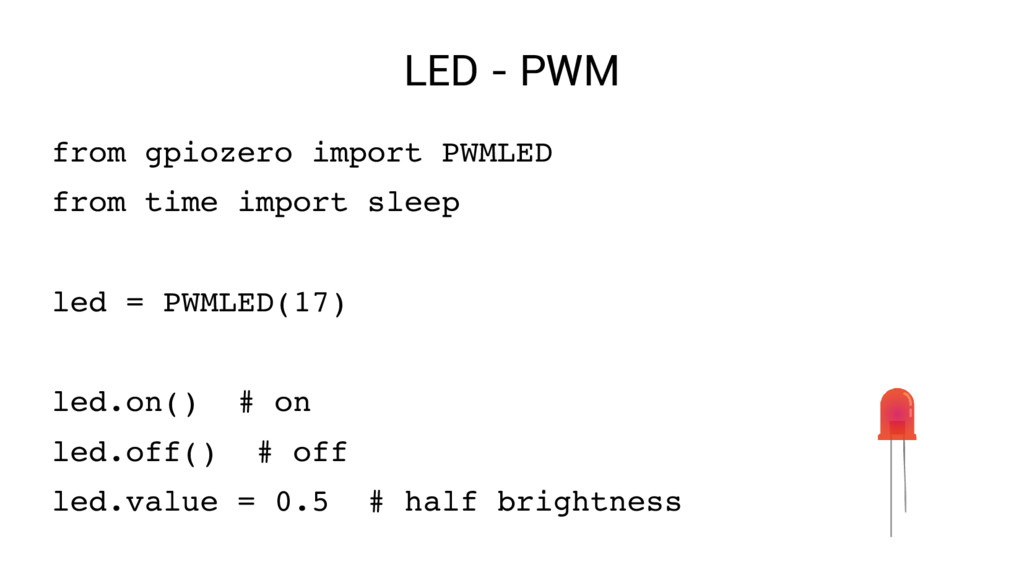
LED - PWM from gpiozero import PWMLED from time import
sleep led = PWMLED(17) led.on() # on led.off() # off led.value = 0.5 # half brightness
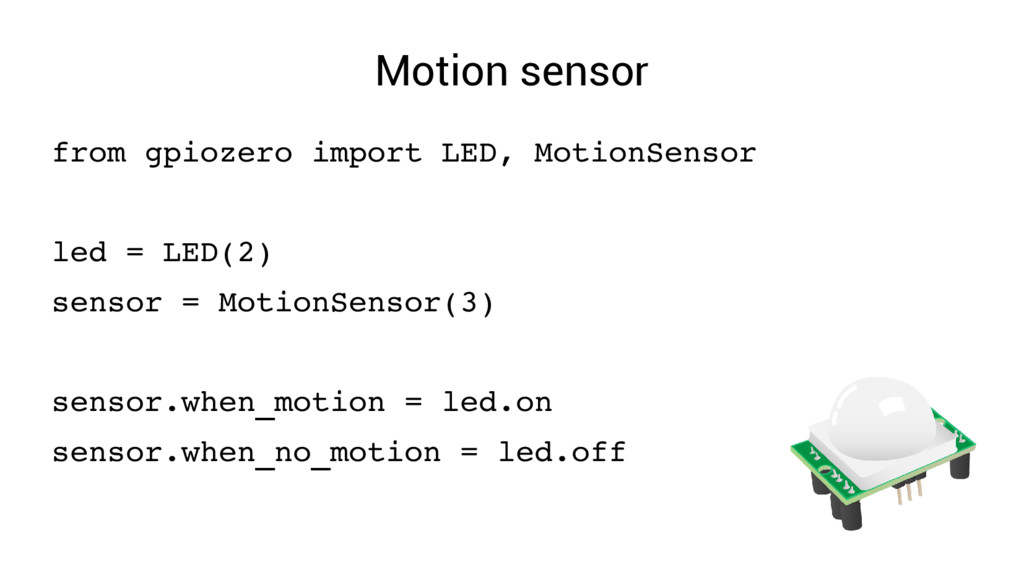
Motion sensor from gpiozero import LED, MotionSensor led = LED(2)
sensor = MotionSensor(3) sensor.when_motion = led.on sensor.when_no_motion = led.off
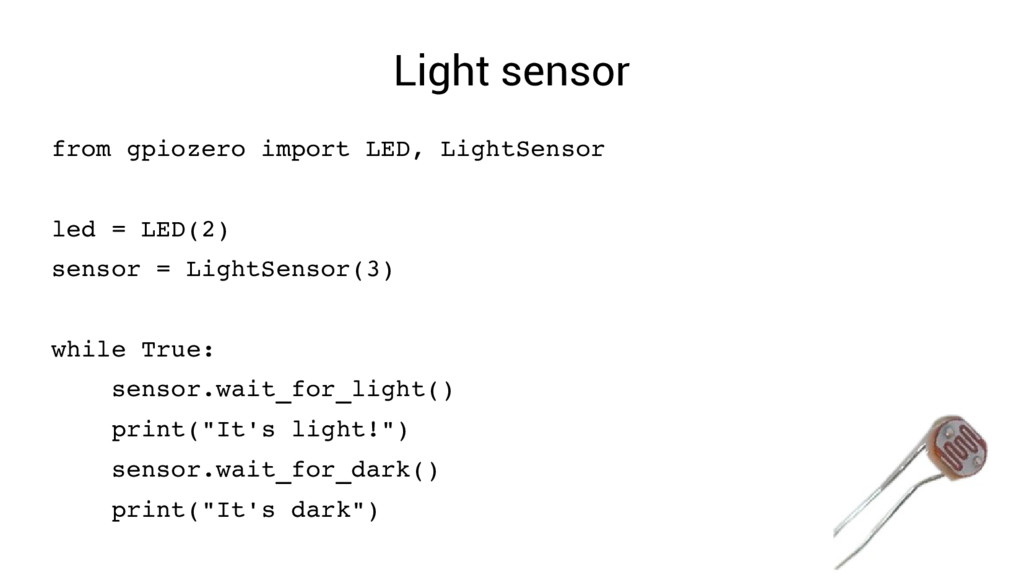
Light sensor from gpiozero import LED, LightSensor led = LED(2)
sensor = LightSensor(3) while True: sensor.wait_for_light() print("It's light!") sensor.wait_for_dark() print("It's dark")
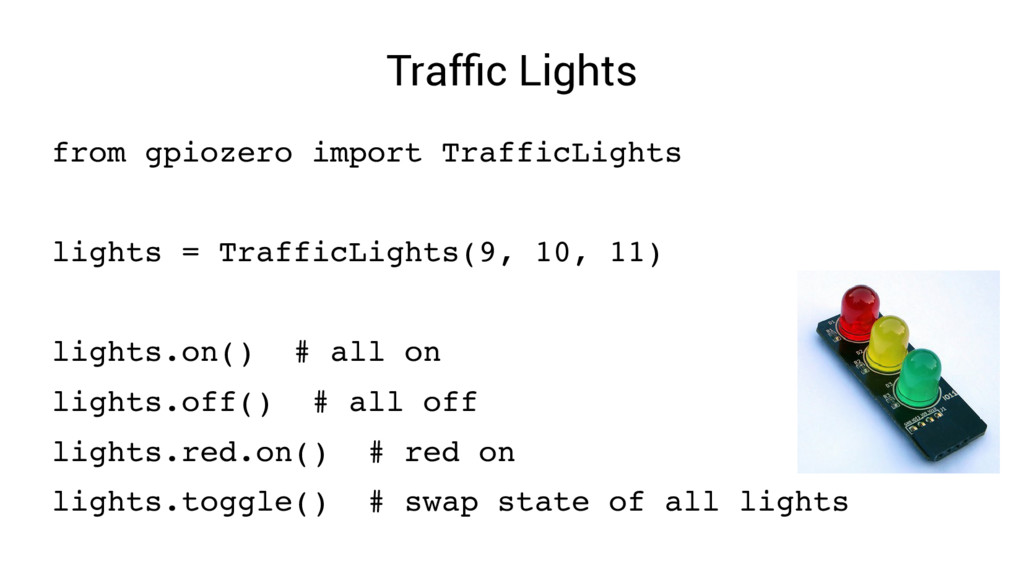
Traffic Lights from gpiozero import TrafficLights lights = TrafficLights(9, 10,
11) lights.on() # all on lights.off() # all off lights.red.on() # red on lights.toggle() # swap state of all lights
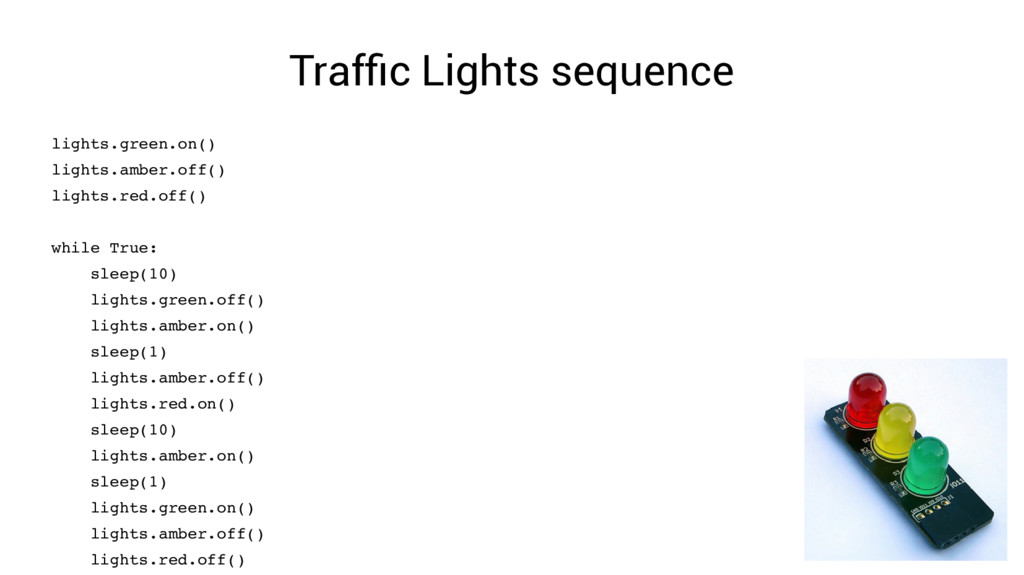
Traffic Lights sequence lights.green.on() lights.amber.off() lights.red.off() while True: sleep(10) lights.green.off()
lights.amber.on() sleep(1) lights.amber.off() lights.red.on() sleep(10) lights.amber.on() sleep(1) lights.green.on() lights.amber.off() lights.red.off()
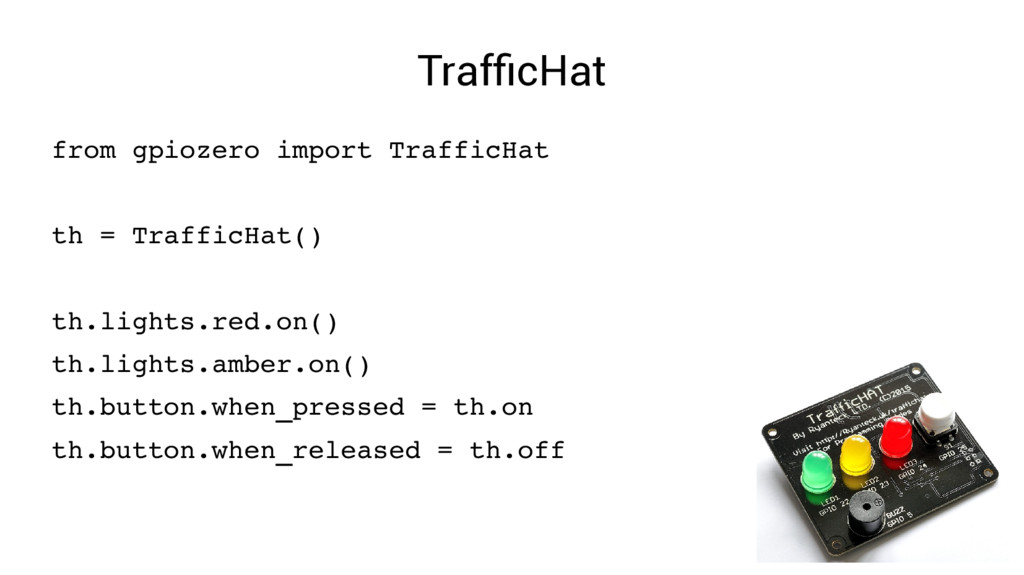
TrafficHat from gpiozero import TrafficHat th = TrafficHat() th.lights.red.on() th.lights.amber.on()
th.button.when_pressed = th.on th.button.when_released = th.off
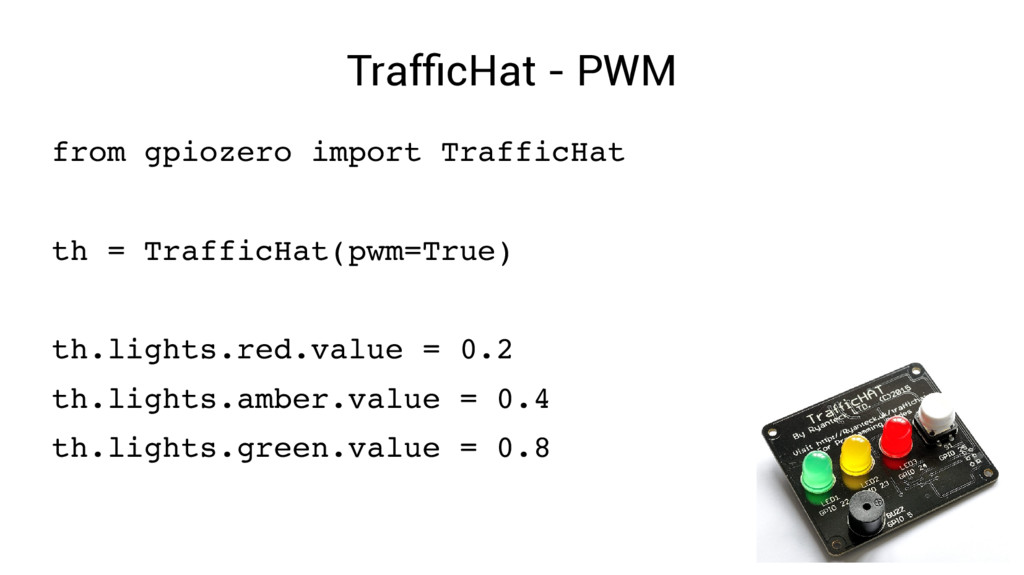
TrafficHat - PWM from gpiozero import TrafficHat th = TrafficHat(pwm=True)
th.lights.red.value = 0.2 th.lights.amber.value = 0.4 th.lights.green.value = 0.8
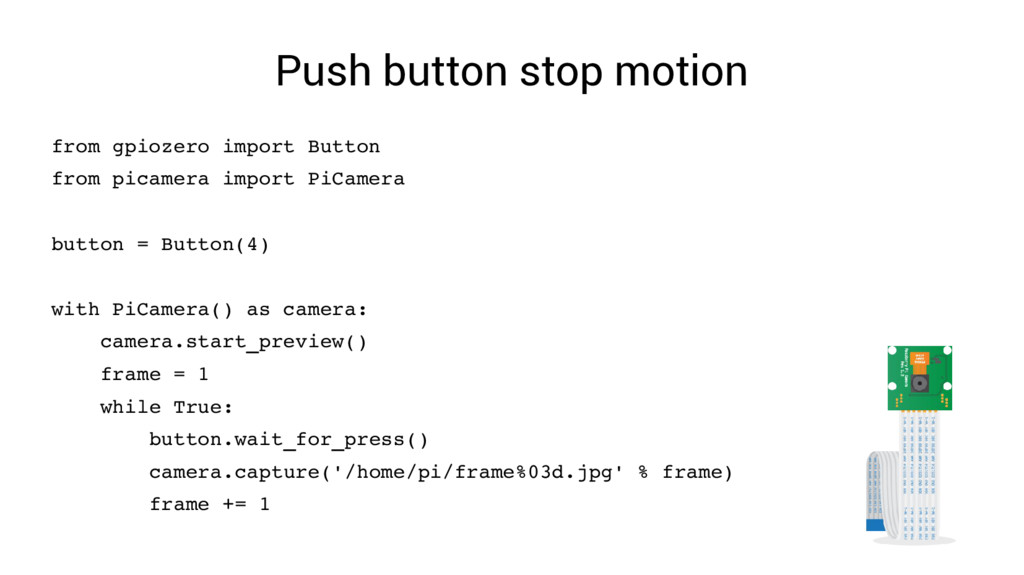
Push button stop motion from gpiozero import Button from picamera
import PiCamera button = Button(4) with PiCamera() as camera: camera.start_preview() frame = 1 while True: button.wait_for_press() camera.capture('/home/pi/frame%03d.jpg' % frame) frame += 1
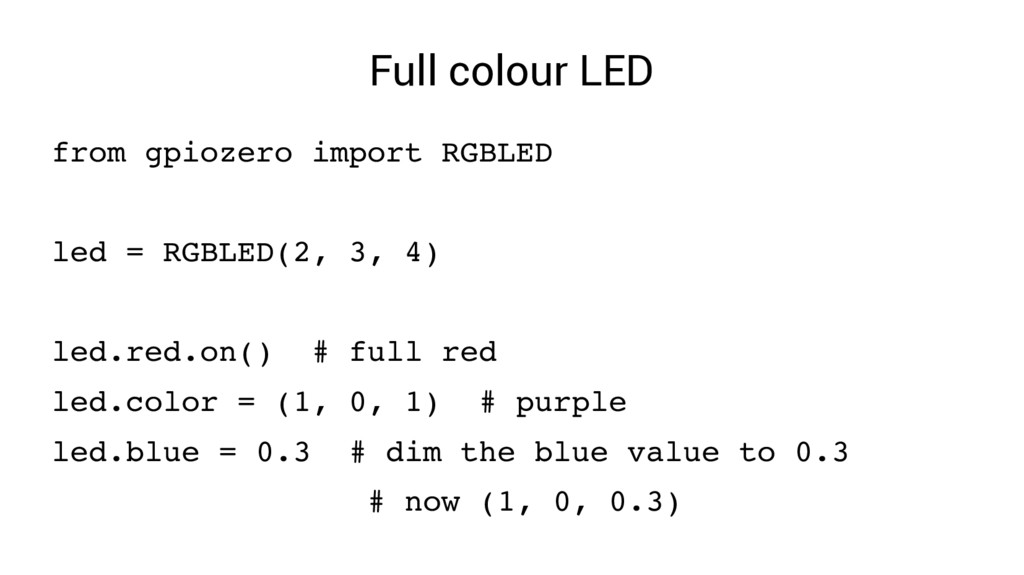
Full colour LED from gpiozero import RGBLED led = RGBLED(2,
3, 4) led.red.on() # full red led.color = (1, 0, 1) # purple led.blue = 0.3 # dim the blue value to 0.3 # now (1, 0, 0.3)
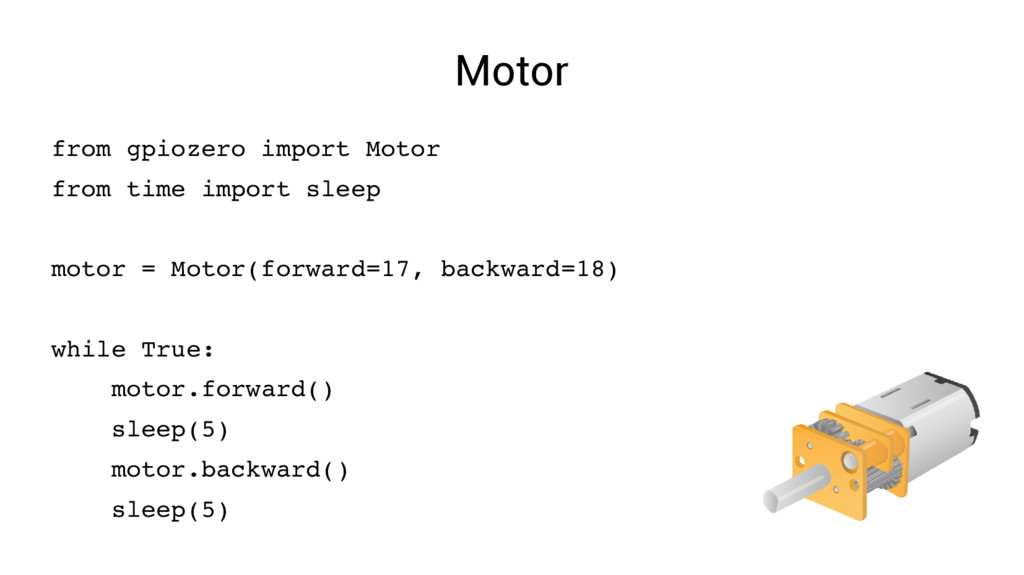
Motor from gpiozero import Motor from time import sleep motor
= Motor(forward=17, backward=18) while True: motor.forward() sleep(5) motor.backward() sleep(5)
Robot from gpiozero import Robot from time import sleep robot
= Robot(left=(17, 18), right=(22, 23)) while True: robot.forward() sleep(10) robot.left() sleep(1)
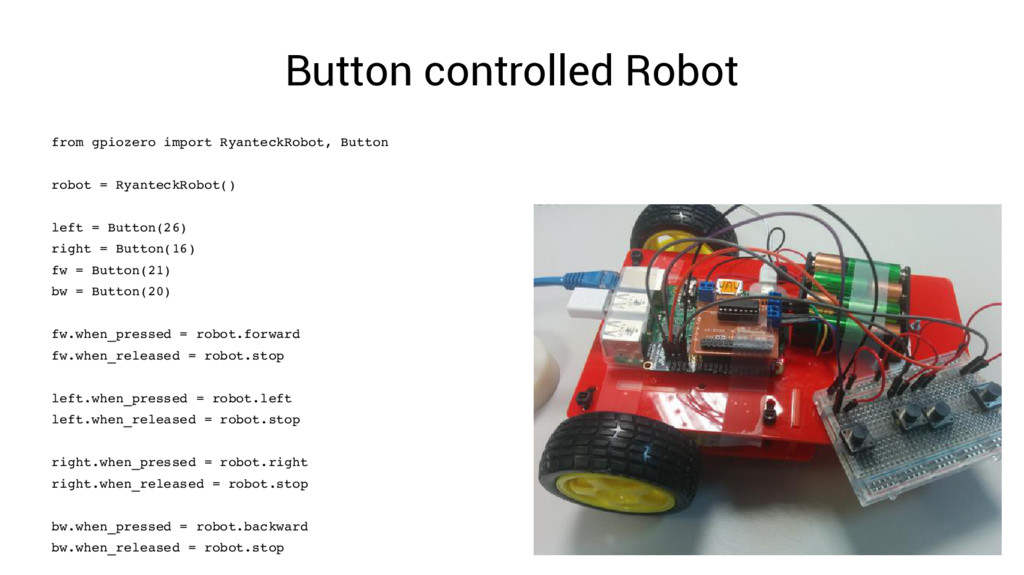
Button controlled Robot from gpiozero import RyanteckRobot, Button robot =
RyanteckRobot() left = Button(26) right = Button(16) fw = Button(21) bw = Button(20) fw.when_pressed = robot.forward fw.when_released = robot.stop left.when_pressed = robot.left left.when_released = robot.stop right.when_pressed = robot.right right.when_released = robot.stop bw.when_pressed = robot.backward bw.when_released = robot.stop
Analogue - potentiometers from gpiozero import MCP3008 pot = MCP3008()
while True: print(pot.value)
Dial up the brightness! from gpiozero import PWMLED, MCP3008 led
= PWMLED(2) pot = MCP3008() while True: led.value = pot.value
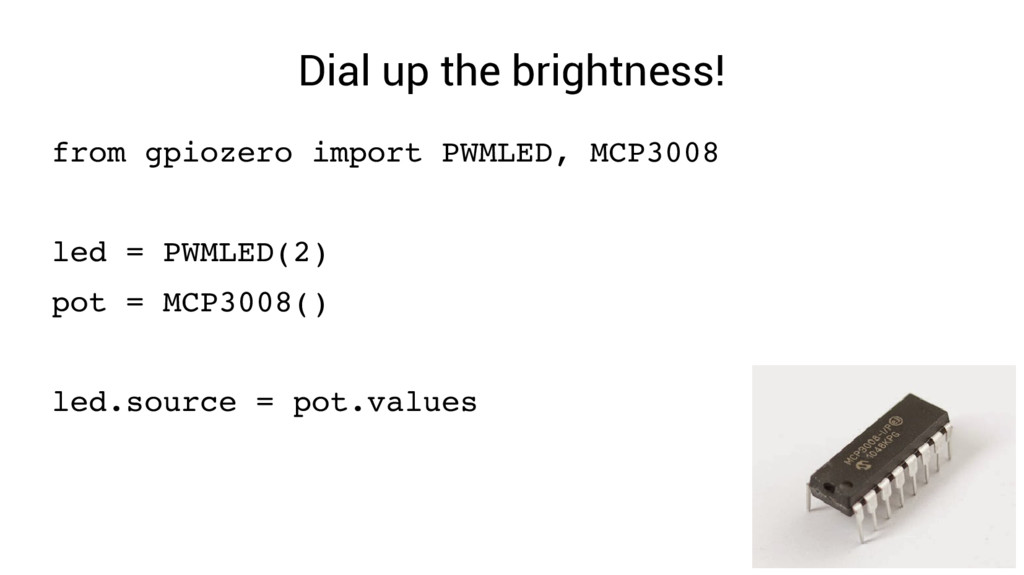
Dial up the brightness! from gpiozero import PWMLED, MCP3008 led
= PWMLED(2) pot = MCP3008() led.source = pot.values
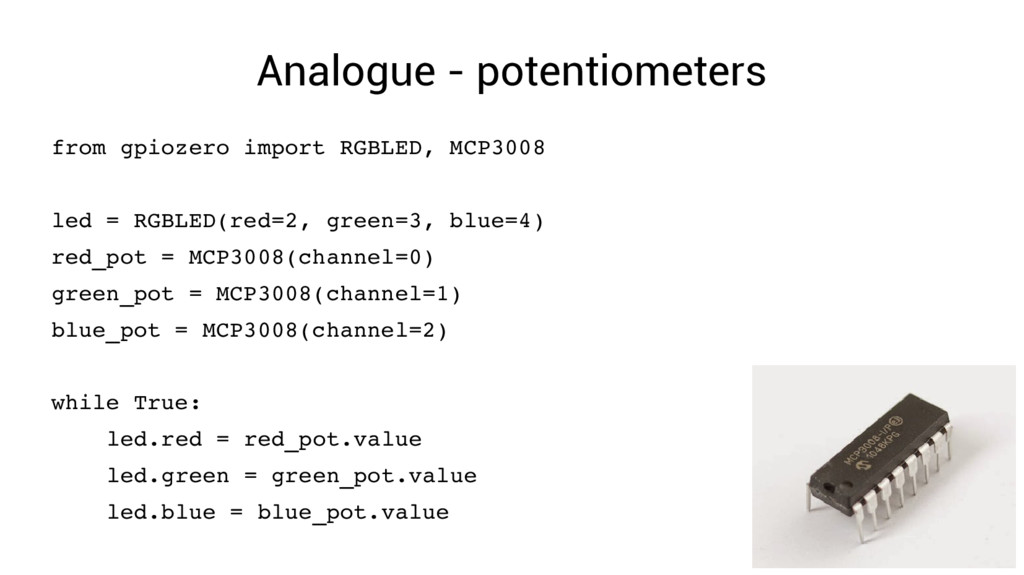
Analogue - potentiometers from gpiozero import RGBLED, MCP3008 led =
RGBLED(red=2, green=3, blue=4) red_pot = MCP3008(channel=0) green_pot = MCP3008(channel=1) blue_pot = MCP3008(channel=2) while True: led.red = red_pot.value led.green = green_pot.value led.blue = blue_pot.value
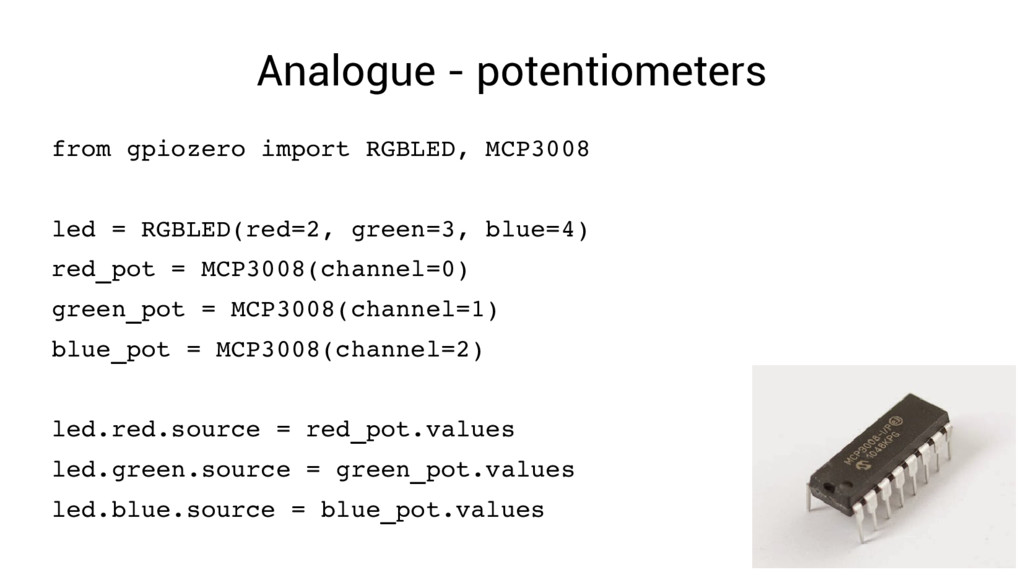
Analogue - potentiometers from gpiozero import RGBLED, MCP3008 led =
RGBLED(red=2, green=3, blue=4) red_pot = MCP3008(channel=0) green_pot = MCP3008(channel=1) blue_pot = MCP3008(channel=2) led.red.source = red_pot.values led.green.source = green_pot.values led.blue.source = blue_pot.values
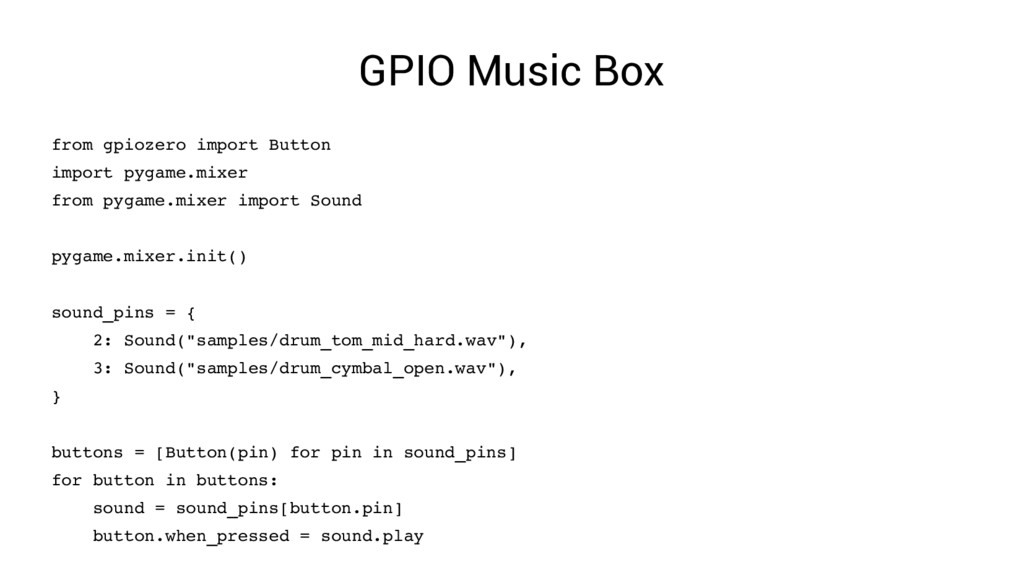
GPIO Music Box from gpiozero import Button import pygame.mixer from
pygame.mixer import Sound pygame.mixer.init() sound_pins = { 2: Sound("samples/drum_tom_mid_hard.wav"), 3: Sound("samples/drum_cymbal_open.wav"), } buttons = [Button(pin) for pin in sound_pins] for button in buttons: sound = sound_pins[button.pin] button.when_pressed = sound.play
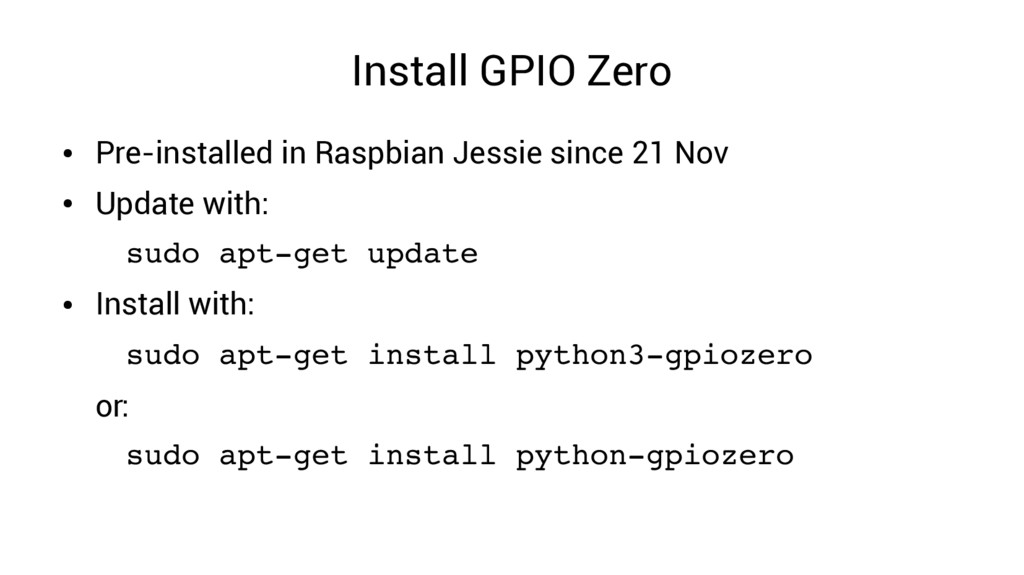
Install GPIO Zero • Pre-installed in Raspbian Jessie since 21
Nov • Update with: sudo aptget update • Install with: sudo aptget install python3gpiozero or: sudo aptget install pythongpiozero
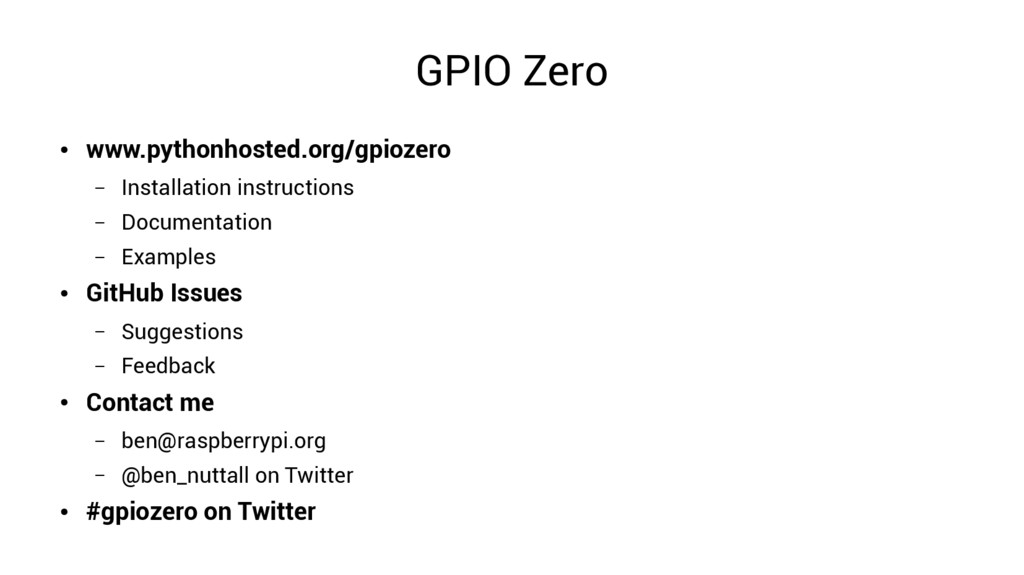
GPIO Zero • www.pythonhosted.org/gpiozero – Installation instructions – Documentation –
Examples • GitHub Issues – Suggestions – Feedback • Contact me –
[email protected]
– @ben_nuttall on Twitter • #gpiozero on Twitter
CamJam EduKit • £5 starter kit (kit 1) • £7
sensors kit (kit 2) • £17 robotics kit (kit 3) • Free worksheets • Very reusable
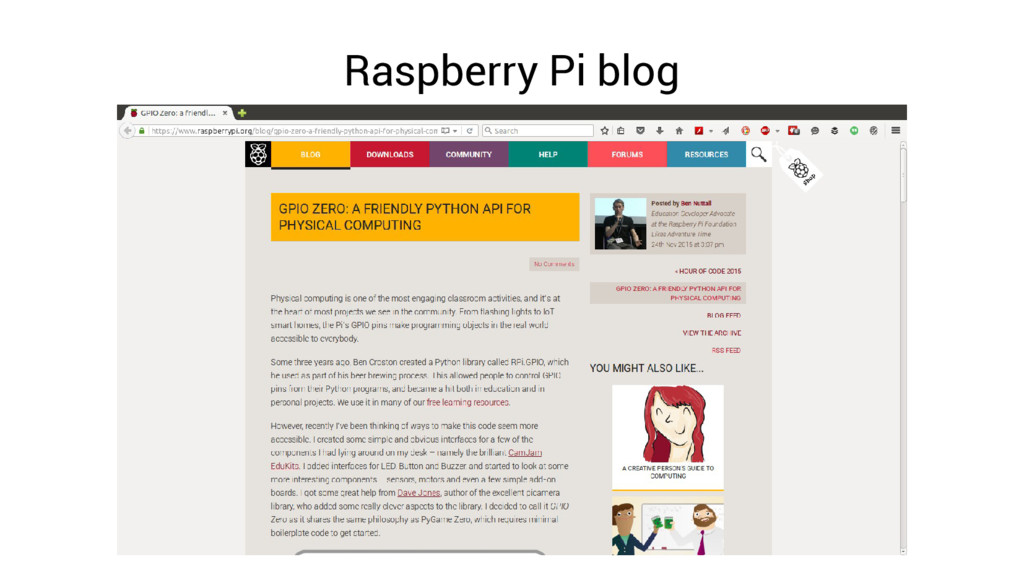
Raspberry Pi blog
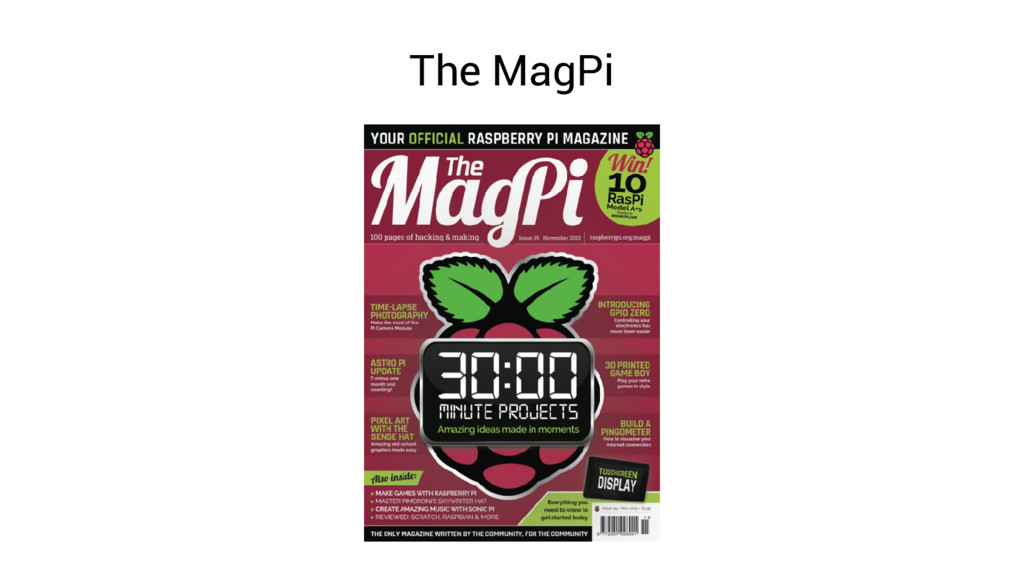
The MagPi
The MagPi
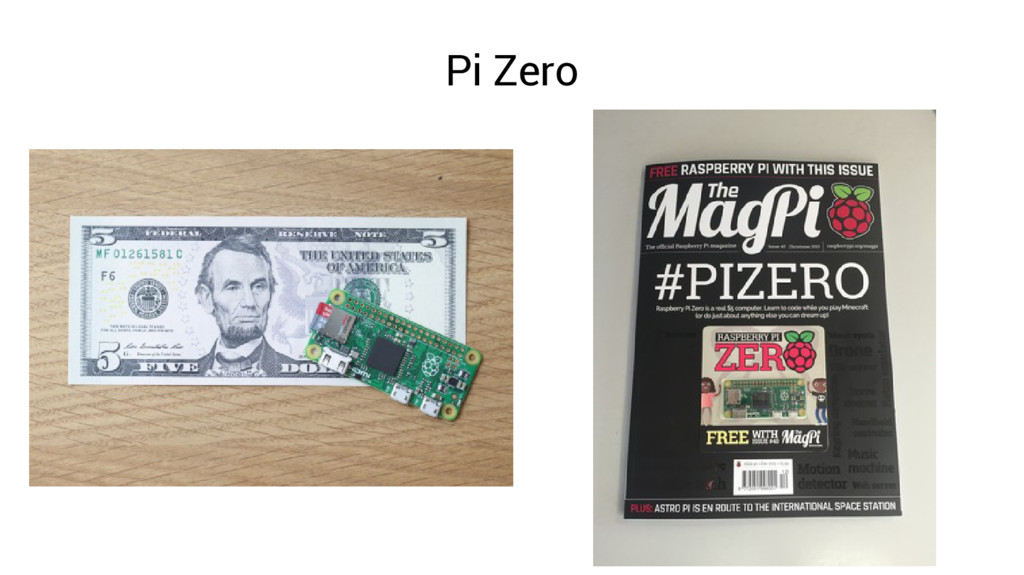
Pi Zero
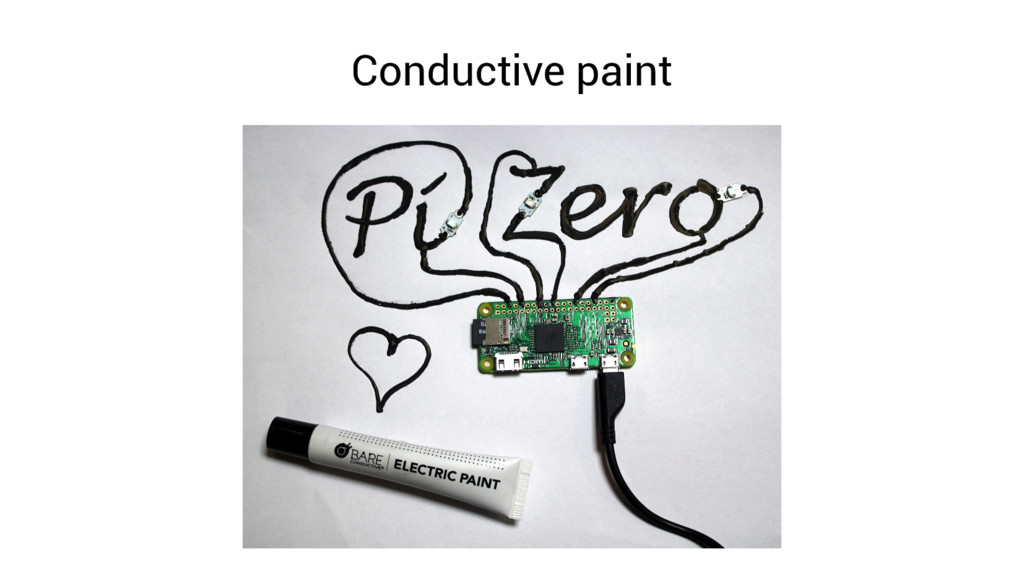
Conductive paint
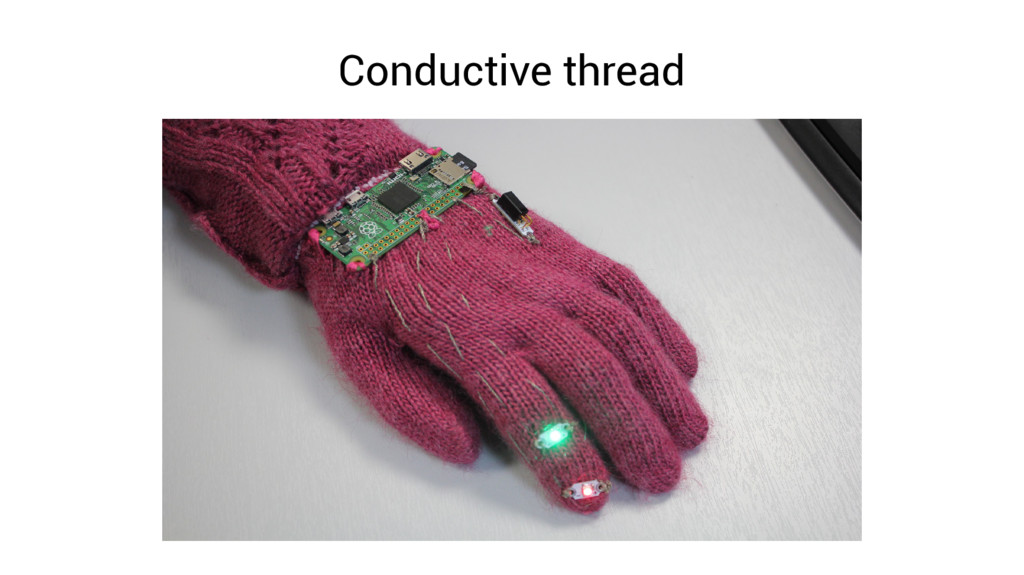
Conductive thread
Physical computing with GPIO Zero Ben Nuttall Raspberry Pi Foundation
UK Charity 1129409


 bennuttall
 rkaga
 l2hyunwoo
 minodriven
 takahirosunaga
 ochtum
 raeminkang
 t0yohei
 seike460
 yosuke_furukawa
 akihisaikeda
 chobishiba
 a_matsuda
 aleyda
 mongodb
 matthewcrist
 gr2m
 katiecoart
 techseoconnect
 tmiket
 lfama
 ianozsvald
 ipullrank
 lauravandoore
 carmenintech