Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
[RSJ25] Feasible RAG: Hierarchical Multimodal R...
Search
Sponsored
·
Ship Features Fearlessly
Turn features on and off without deploys. Used by thousands of Ruby developers.
→
Semantic Machine Intelligence Lab., Keio Univ.
PRO
September 02, 2025
Technology
300
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
[RSJ25] Feasible RAG: Hierarchical Multimodal Retrieval with Feasibility-Aware Embodied Memory for Mobile Manipulation
Semantic Machine Intelligence Lab., Keio Univ.
PRO
September 02, 2025
Transcript
17 slides
是方諒介1,2,3,Quanting Xie3,Yonatan Bisk3,杉浦孔明1,2 1慶應義塾大学,2慶應AIセンター,3Carnegie Mellon University 行動実現性を考慮した 階層型マルチモーダル検索に基づく 移動マニピュレーション
背景:Open-Vocabulary Mobile Manipulation (OVMM) ▪ OVMM [Yenamandra+, CoRL/NeurIPS23], [Liu+, 24]
▪ 自然言語指示に基づく物体操作 → 実世界検索 [Yashima+, RA-L25], [Kaneda+, RA-L/IROS24] ▪ 家庭や公共空間において言語で物体検索が可能 ▪ Motivation:行動実現性がより高い物体の特定 → 成功率向上に寄与 - 2 - ドライバの横にあるペンを 持ってきてください 既存手法は「視覚・言語的に」 正しい物体か否かのみを考慮
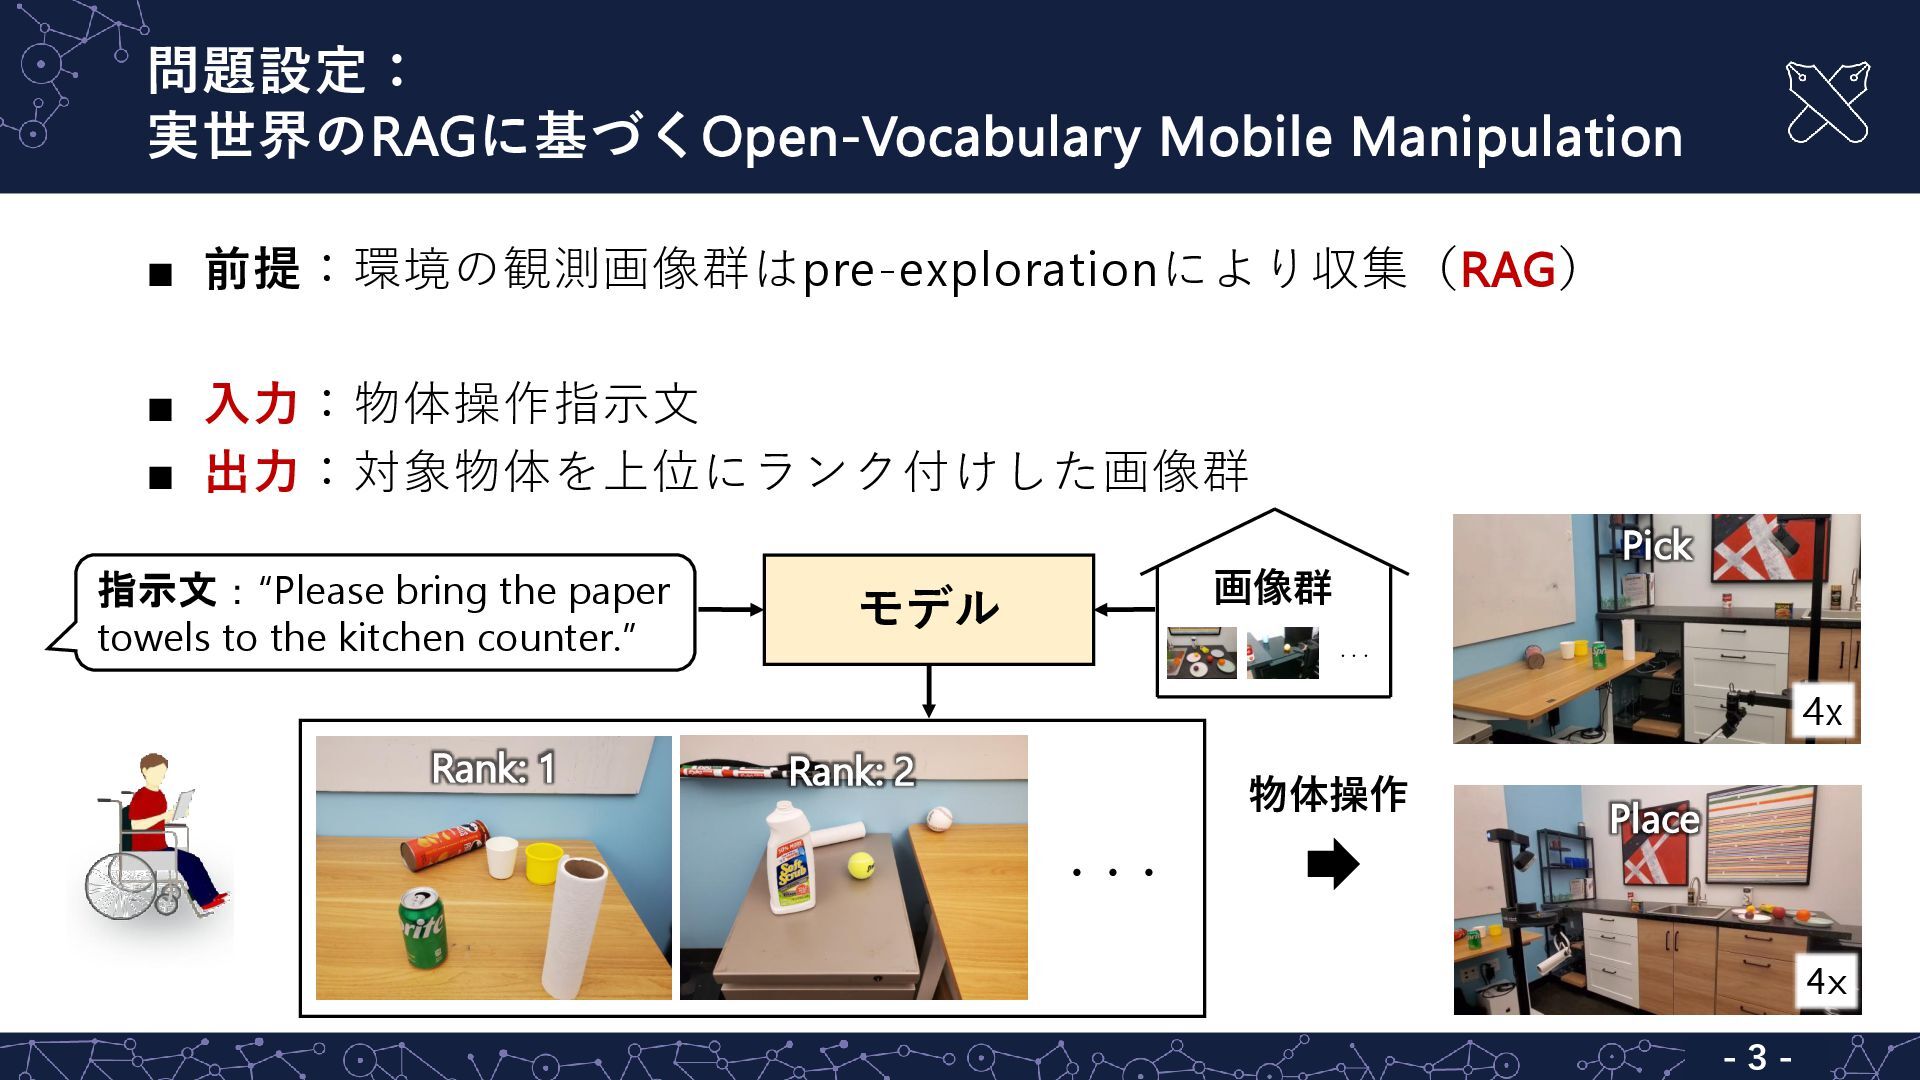
問題設定: 実世界のRAGに基づくOpen-Vocabulary Mobile Manipulation - 3 - ▪ 前提:環境の観測画像群はpre-explorationにより収集(RAG) ▪
入力:物体操作指示文 ▪ 出力:対象物体を上位にランク付けした画像群 4x 4x ・・・ モデル ・・・ 画像群 指示文:“Please bring the paper towels to the kitchen counter.” Rank: 1 Rank: 2 Pick Place 物体操作
関連研究:行動実現性の考慮は不十分 - 4 - マルチモーダル検索に 基づく移動・物体操作 NLMap [Chen+, ICRA23], MultiRankIt
[Kaneda+, RA-L/IROS24], RREx-BoT [Sigurdsson+, IROS23], RelaX-Former [Yashima+, RA-L25] 大規模画像・テキスト対 で訓練された基盤モデル CLIP [Radford+, ICML21], Long-CLIP [Zhang+, ECCV24], SigLIP [Zhai+, ICCV23], BLIP-2 [Li+, ICML23], BEiT-3 [Wang+, CVPR23] グラフ構造に基づく 実世界環境の表現 Embodied-RAG [Xie+, 24], MoMa-LLM [Honerkamp+, RA-L24], ConceptGraphs [Gu+, ICRA24], HOV-SG [Werby+, RSS24] RelaX-Former Embodied-RAG
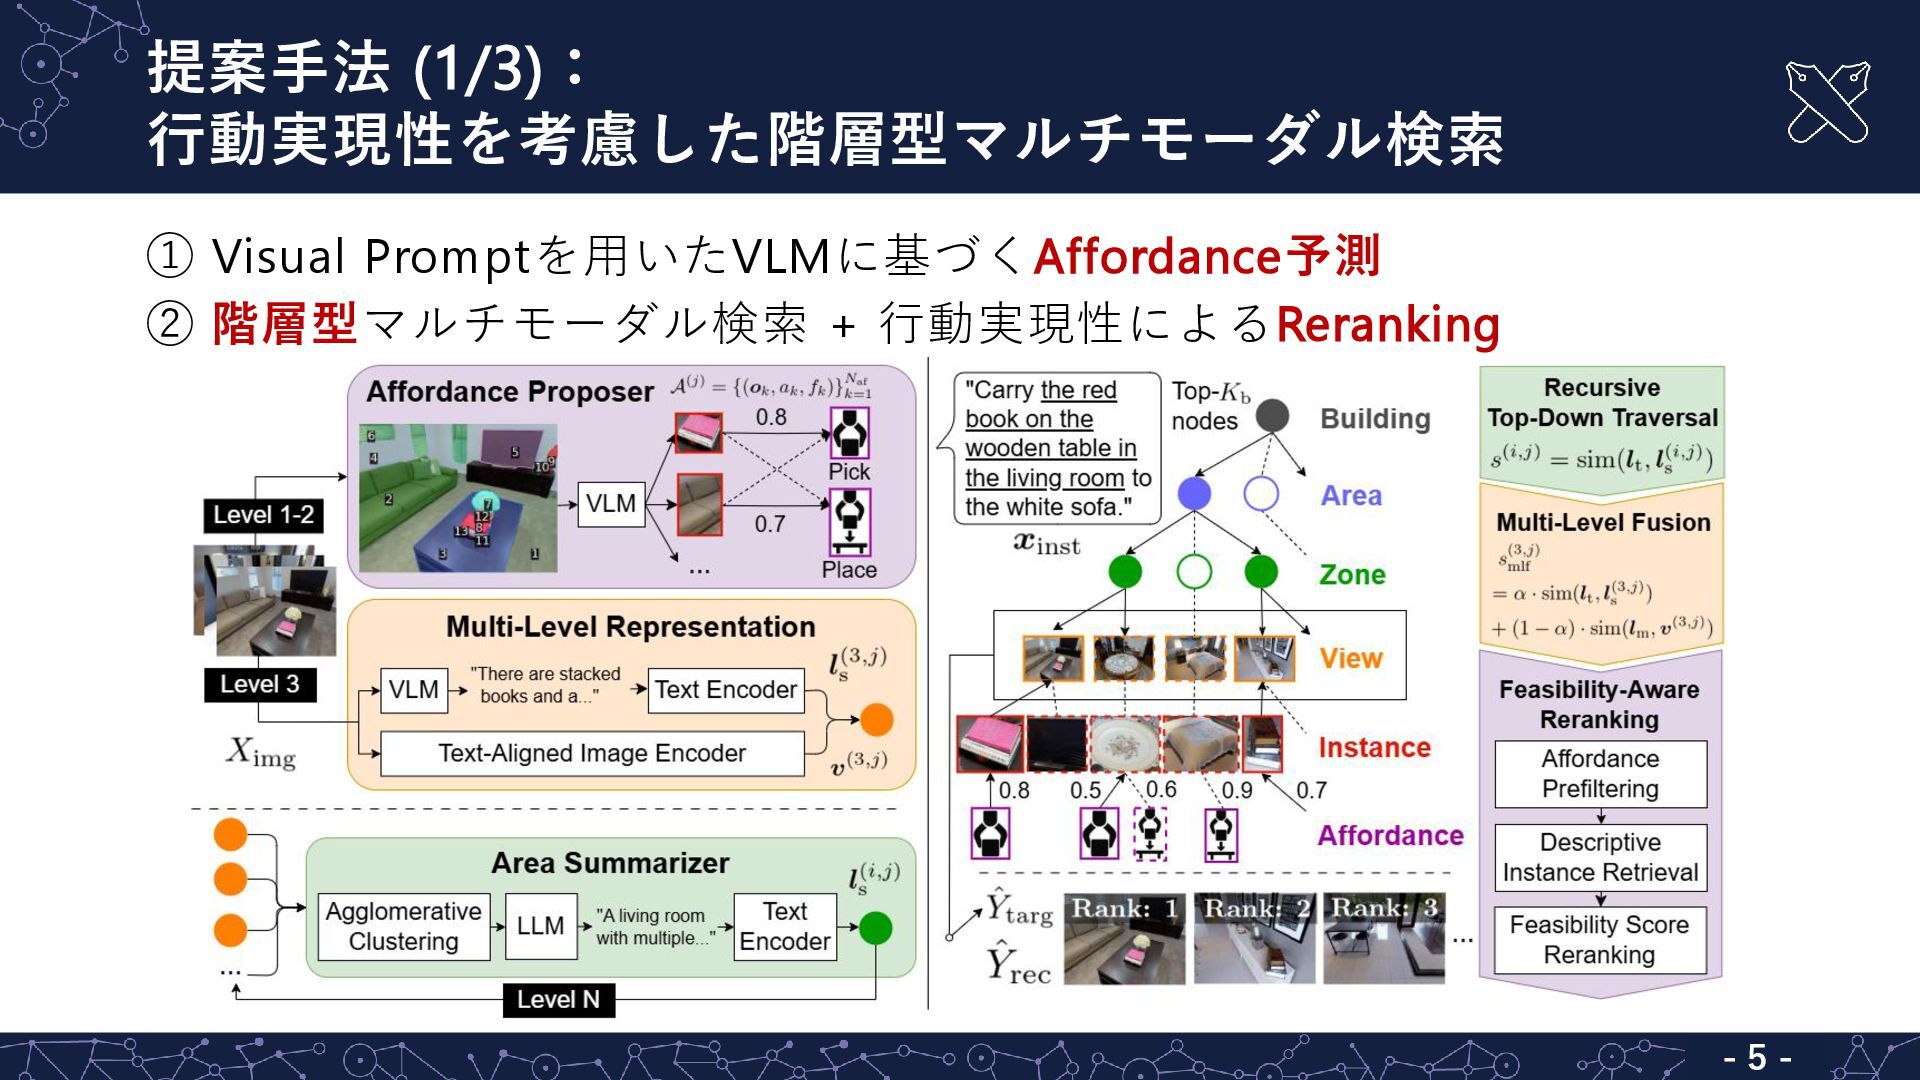
提案手法 (1/3): 行動実現性を考慮した階層型マルチモーダル検索 - 5 - ① Visual Promptを用いたVLMに基づくAffordance予測 ②
階層型マルチモーダル検索 + 行動実現性によるReranking
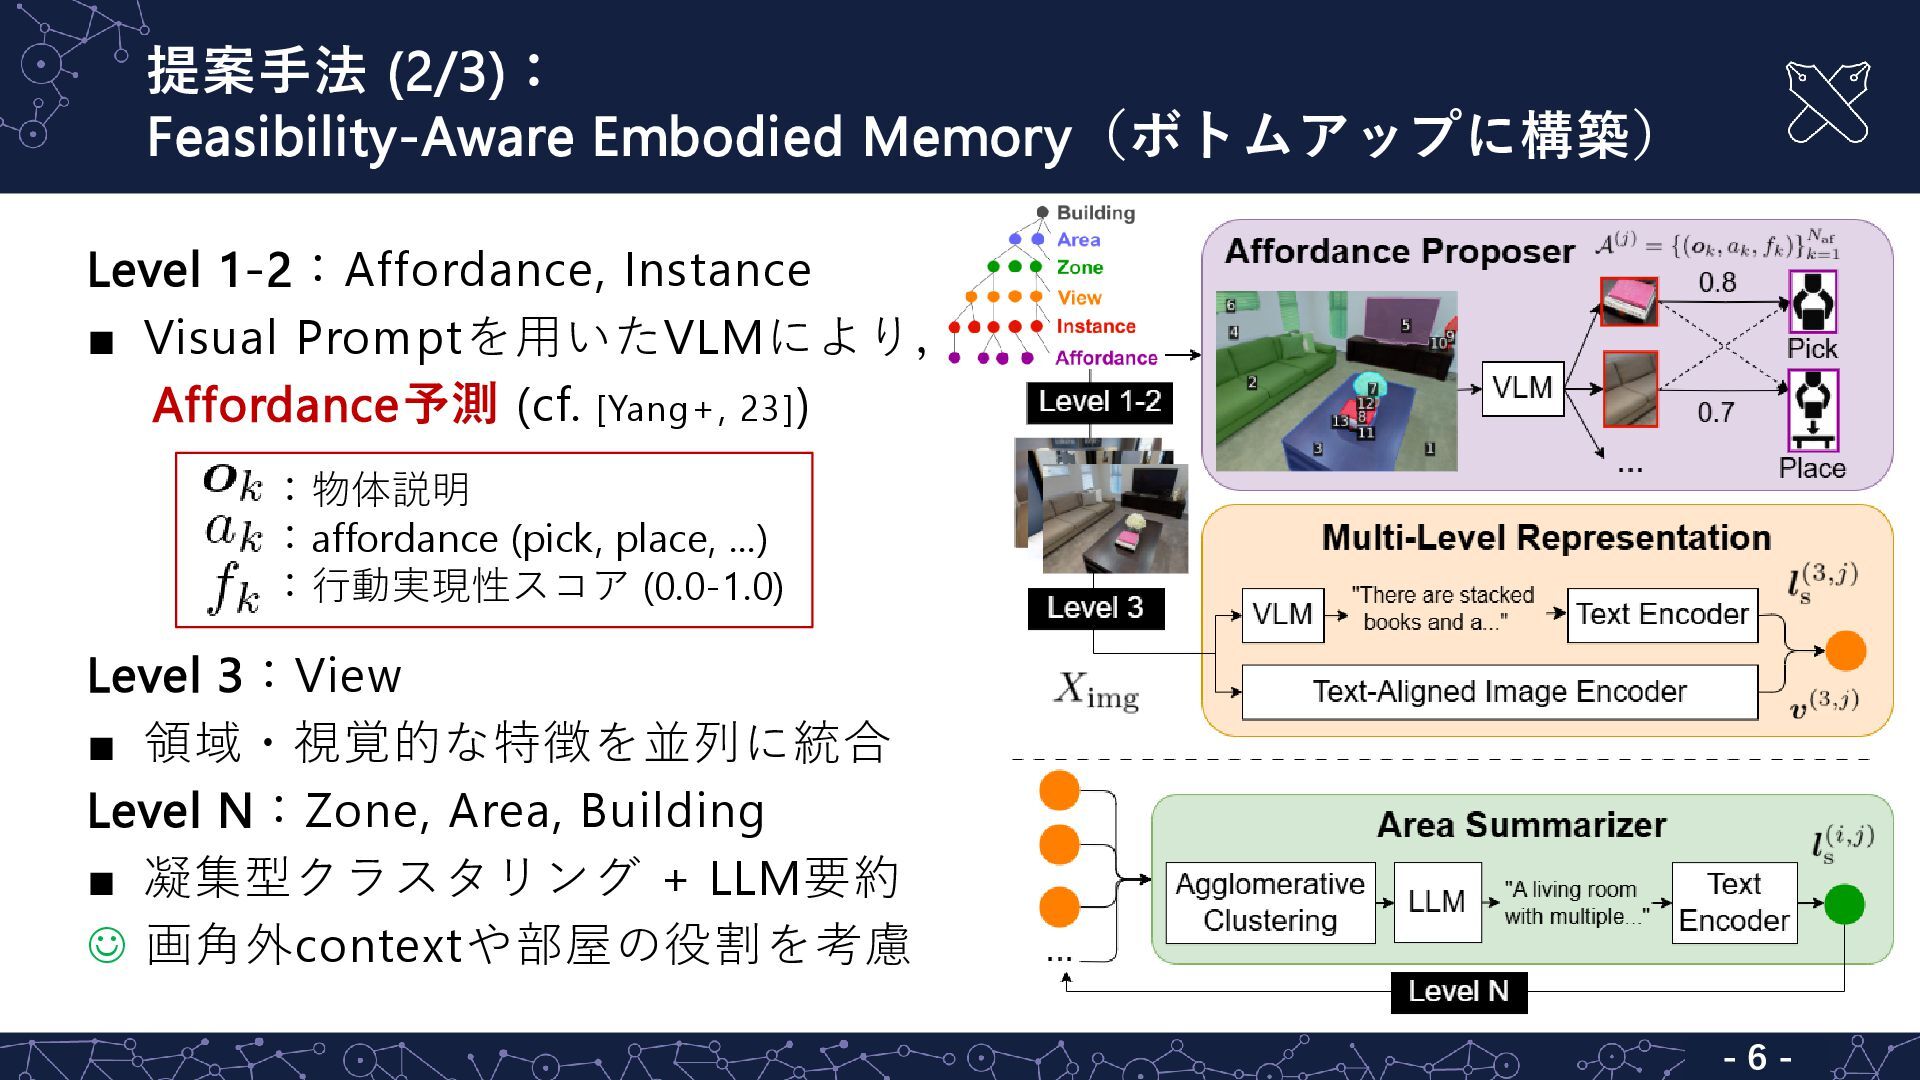
提案手法 (2/3): Feasibility-Aware Embodied Memory(ボトムアップに構築) - 6 - Level 1-2:Affordance,
Instance ▪ Visual Promptを用いたVLMにより, Affordance予測 (cf. [Yang+, 23]) Level 3:View ▪ 領域・視覚的な特徴を並列に統合 Level N:Zone, Area, Building ▪ 凝集型クラスタリング + LLM要約 ☺ 画角外contextや部屋の役割を考慮 :物体説明 :affordance (pick, place, …) :行動実現性スコア (0.0-1.0)
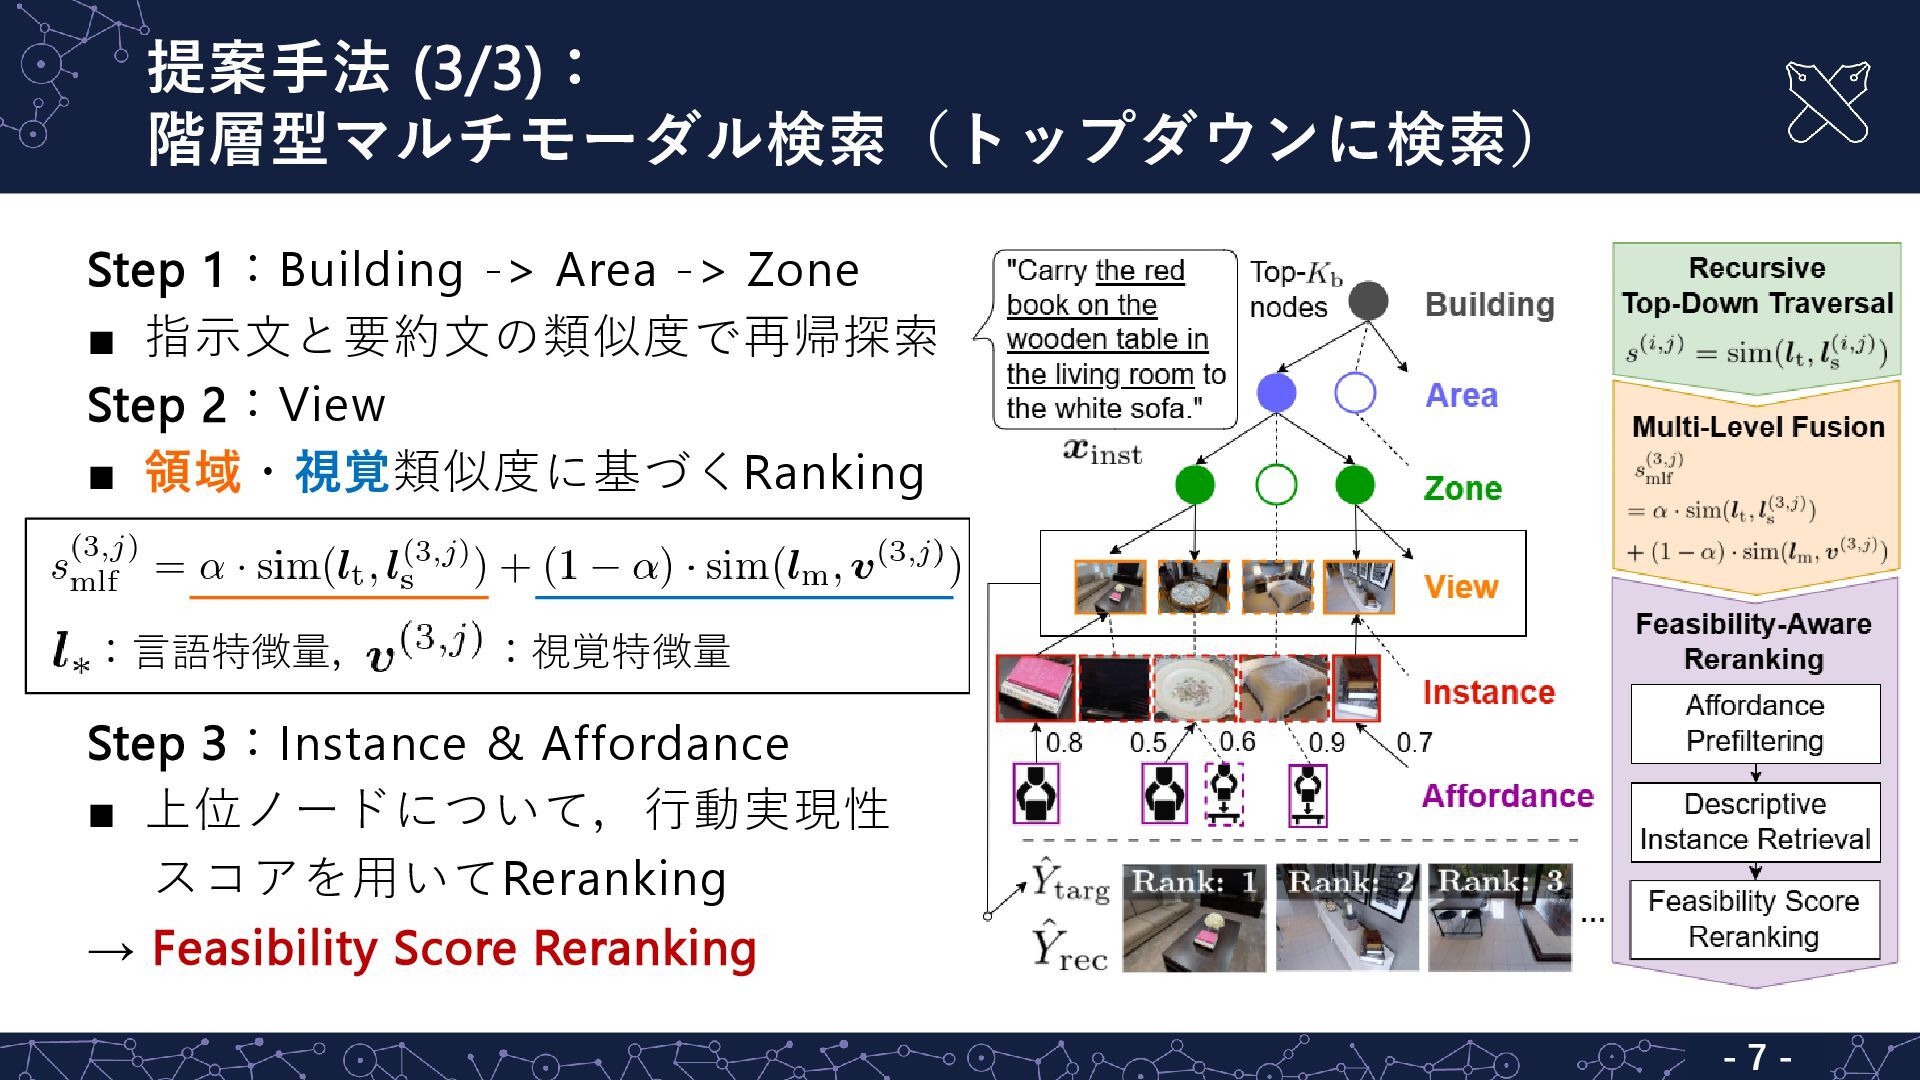
:言語特徴量, :視覚特徴量 提案手法 (3/3): 階層型マルチモーダル検索(トップダウンに検索) - 7 - Step 1:Building
-> Area -> Zone ▪ 指示文と要約文の類似度で再帰探索 Step 2:View ▪ 領域・視覚類似度に基づくRanking Step 3:Instance & Affordance ▪ 上位ノードについて,行動実現性 スコアを用いてReranking → Feasibility Score Reranking
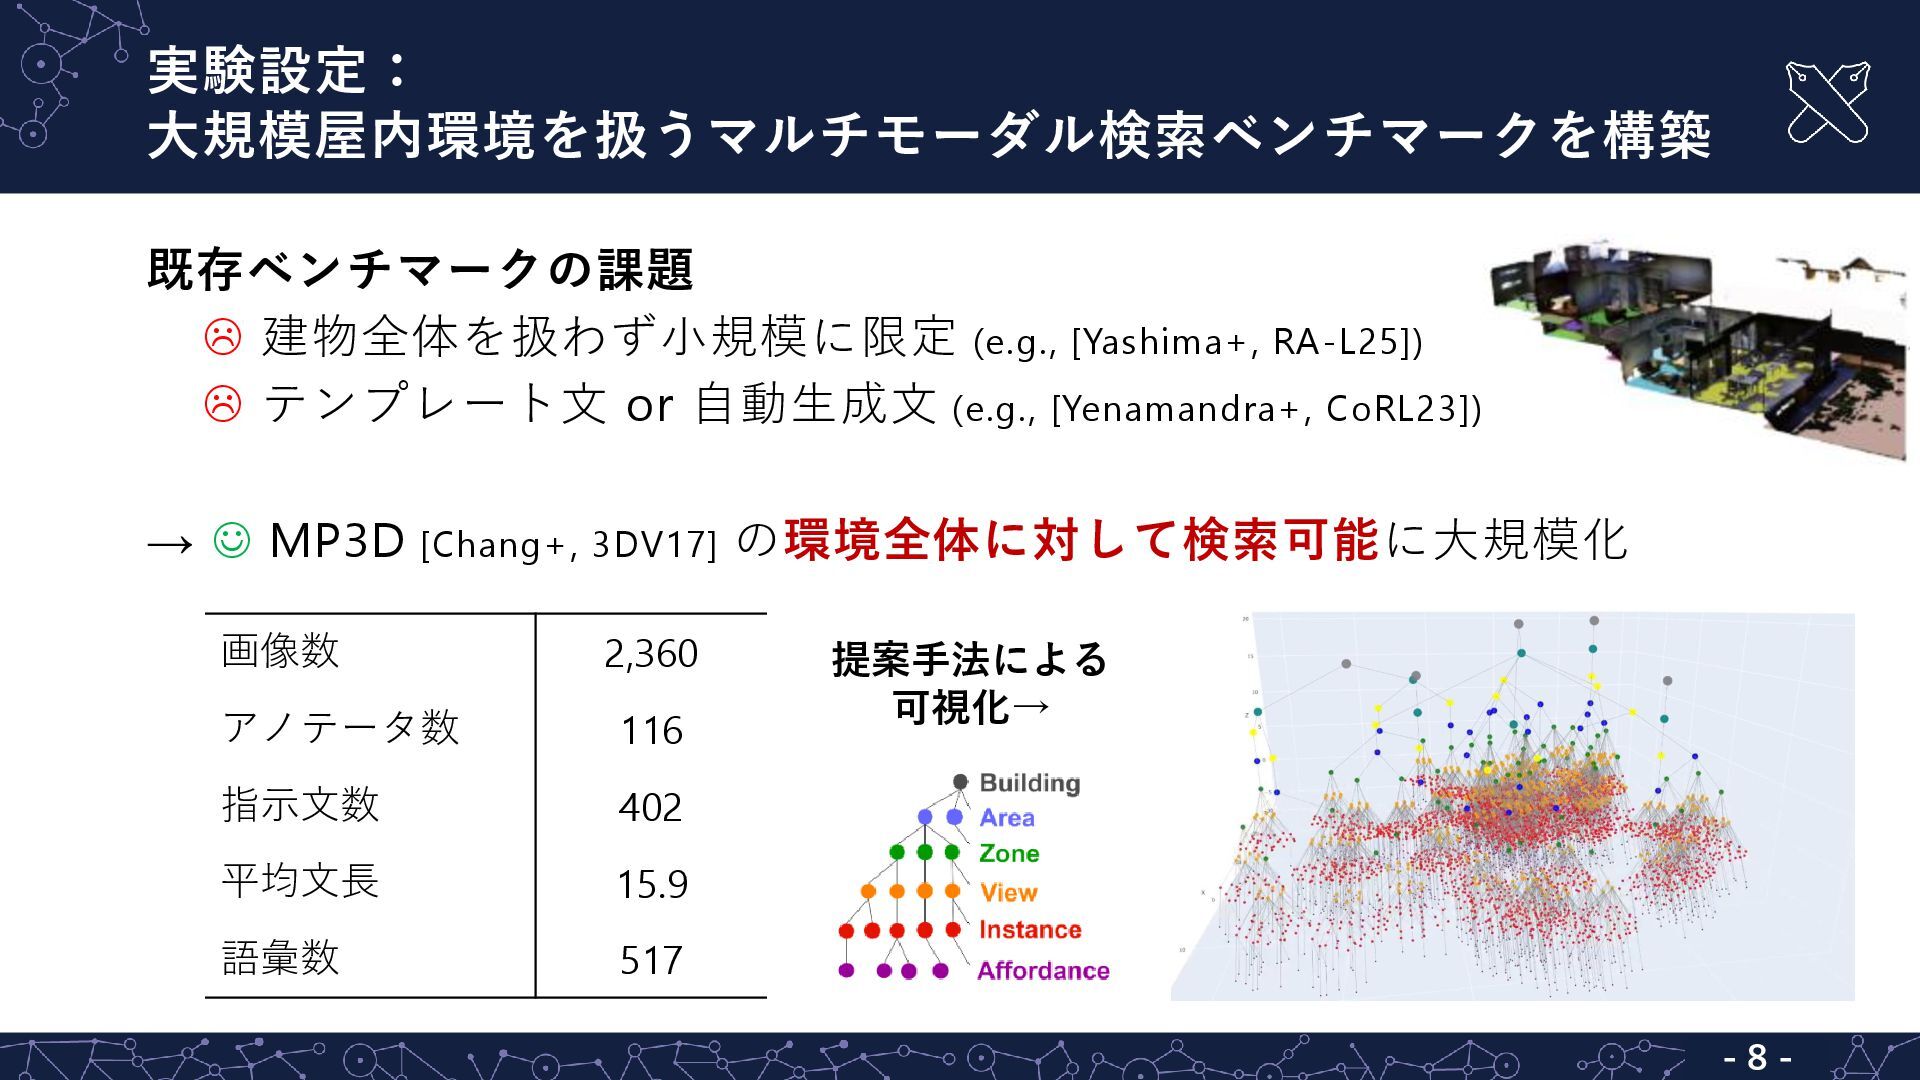
実験設定: 大規模屋内環境を扱うマルチモーダル検索ベンチマークを構築 - 8 - 既存ベンチマークの課題 建物全体を扱わず小規模に限定 (e.g., [Yashima+,
RA-L25]) テンプレート文 or 自動生成文 (e.g., [Yenamandra+, CoRL23]) → ☺ MP3D [Chang+, 3DV17] の環境全体に対して検索可能に大規模化 画像数 2,360 アノテータ数 116 指示文数 402 平均文長 15.9 語彙数 517 提案手法による 可視化→
定量的結果: 対象物体・配置目標ともにベースライン手法を上回る検索性能 [%] 手法 対象物体 配置目標 全体 R@10↑ R@20↑ R@10↑
R@20↑ R@10↑ R@20↑ 提案手法 49.9 61.7 24.3 30.2 37.1 45.9 NLMap* [Chen+, ICRA23] 19.2 30.4 15.1 23.6 17.2 27.0 BEiT-3 [Wang+, CVPR23] 42.1 53.8 15.4 27.6 28.7 40.7 HomeRobot* [Yenamandra+, CoRL23] 10.2 12.9 3.9 8.4 7.0 10.7 SigLIP [Zhai+, ICCV23] 34.5 47.3 11.0 22.4 22.7 34.8 Embodied-RAG [Xie+, 24] 18.5 22.8 11.3 14.4 14.9 18.6 MM-Embed [Lin+, ICLR25] 24.4 36.8 11.6 22.3 18.0 29.5 - 9 - +7.8 +8.9 +8.4 評価指標:Recall@K (R@K)
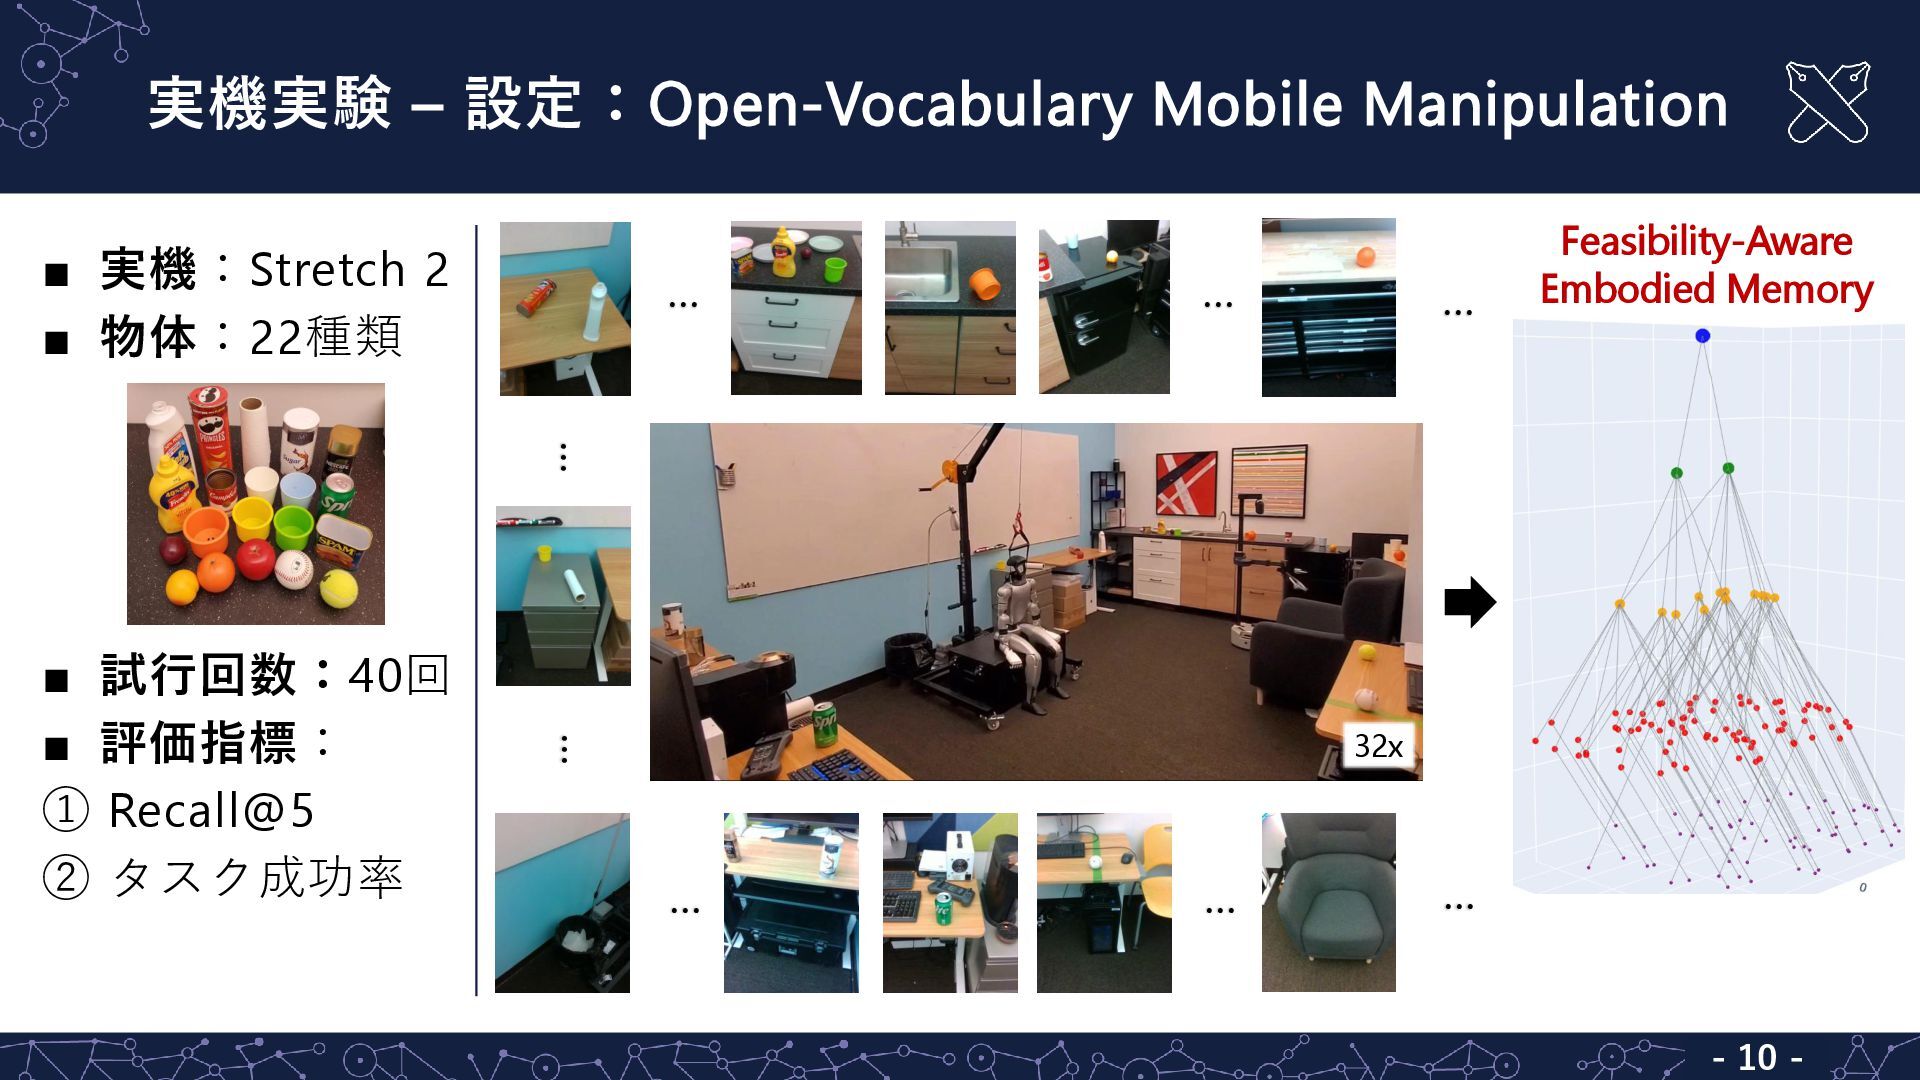
実機実験 – 設定:Open-Vocabulary Mobile Manipulation - 10 - ▪ 実機:Stretch
2 ▪ 物体:22種類 ▪ 試行回数:40回 ▪ 評価指標: ① Recall@5 ② タスク成功率 … 32x … … … … … … … Feasibility-Aware Embodied Memory
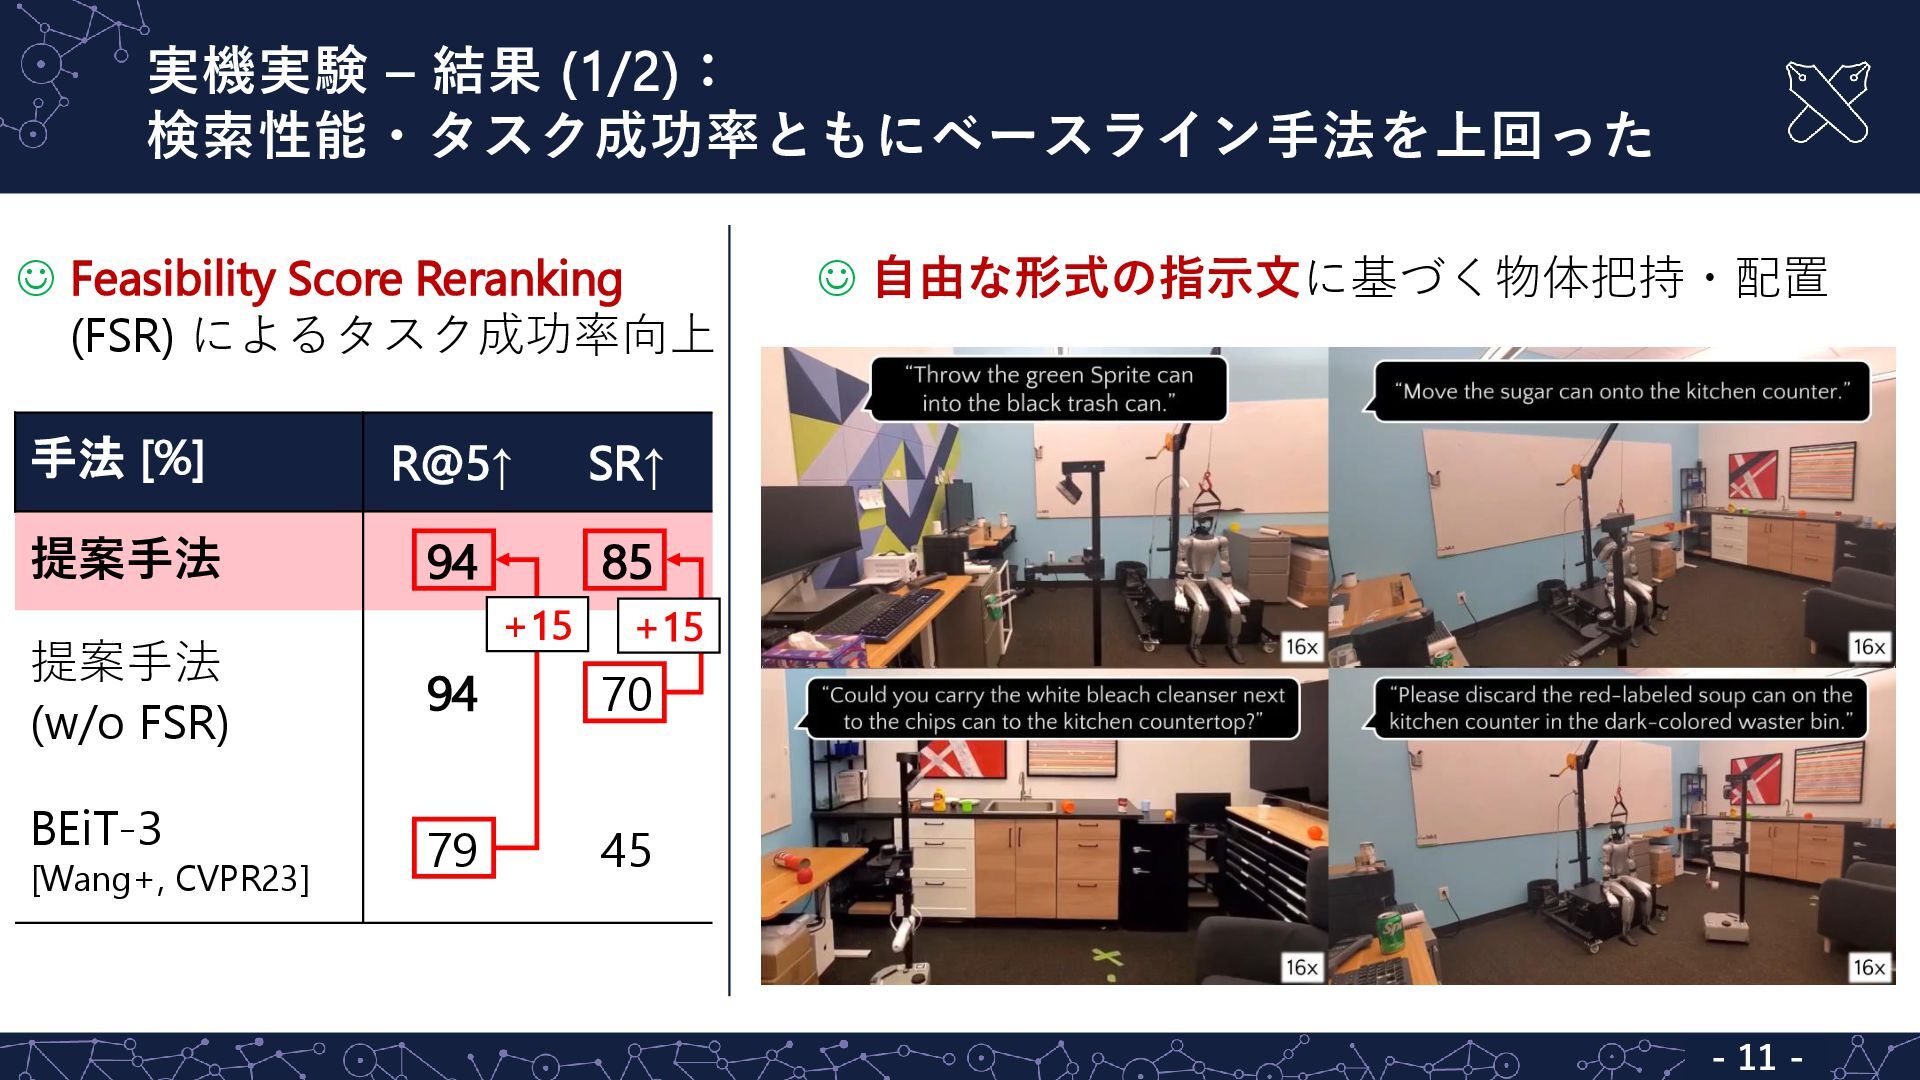
実機実験 – 結果 (1/2): 検索性能・タスク成功率ともにベースライン手法を上回った - 11 - ☺ 自由な形式の指示文に基づく物体把持・配置
手法 [%] R@5↑ SR↑ 提案手法 94 85 提案手法 (w/o FSR) 94 70 BEiT-3 [Wang+, CVPR23] 79 45 ☺ Feasibility Score Reranking (FSR) によるタスク成功率向上 +15 +15
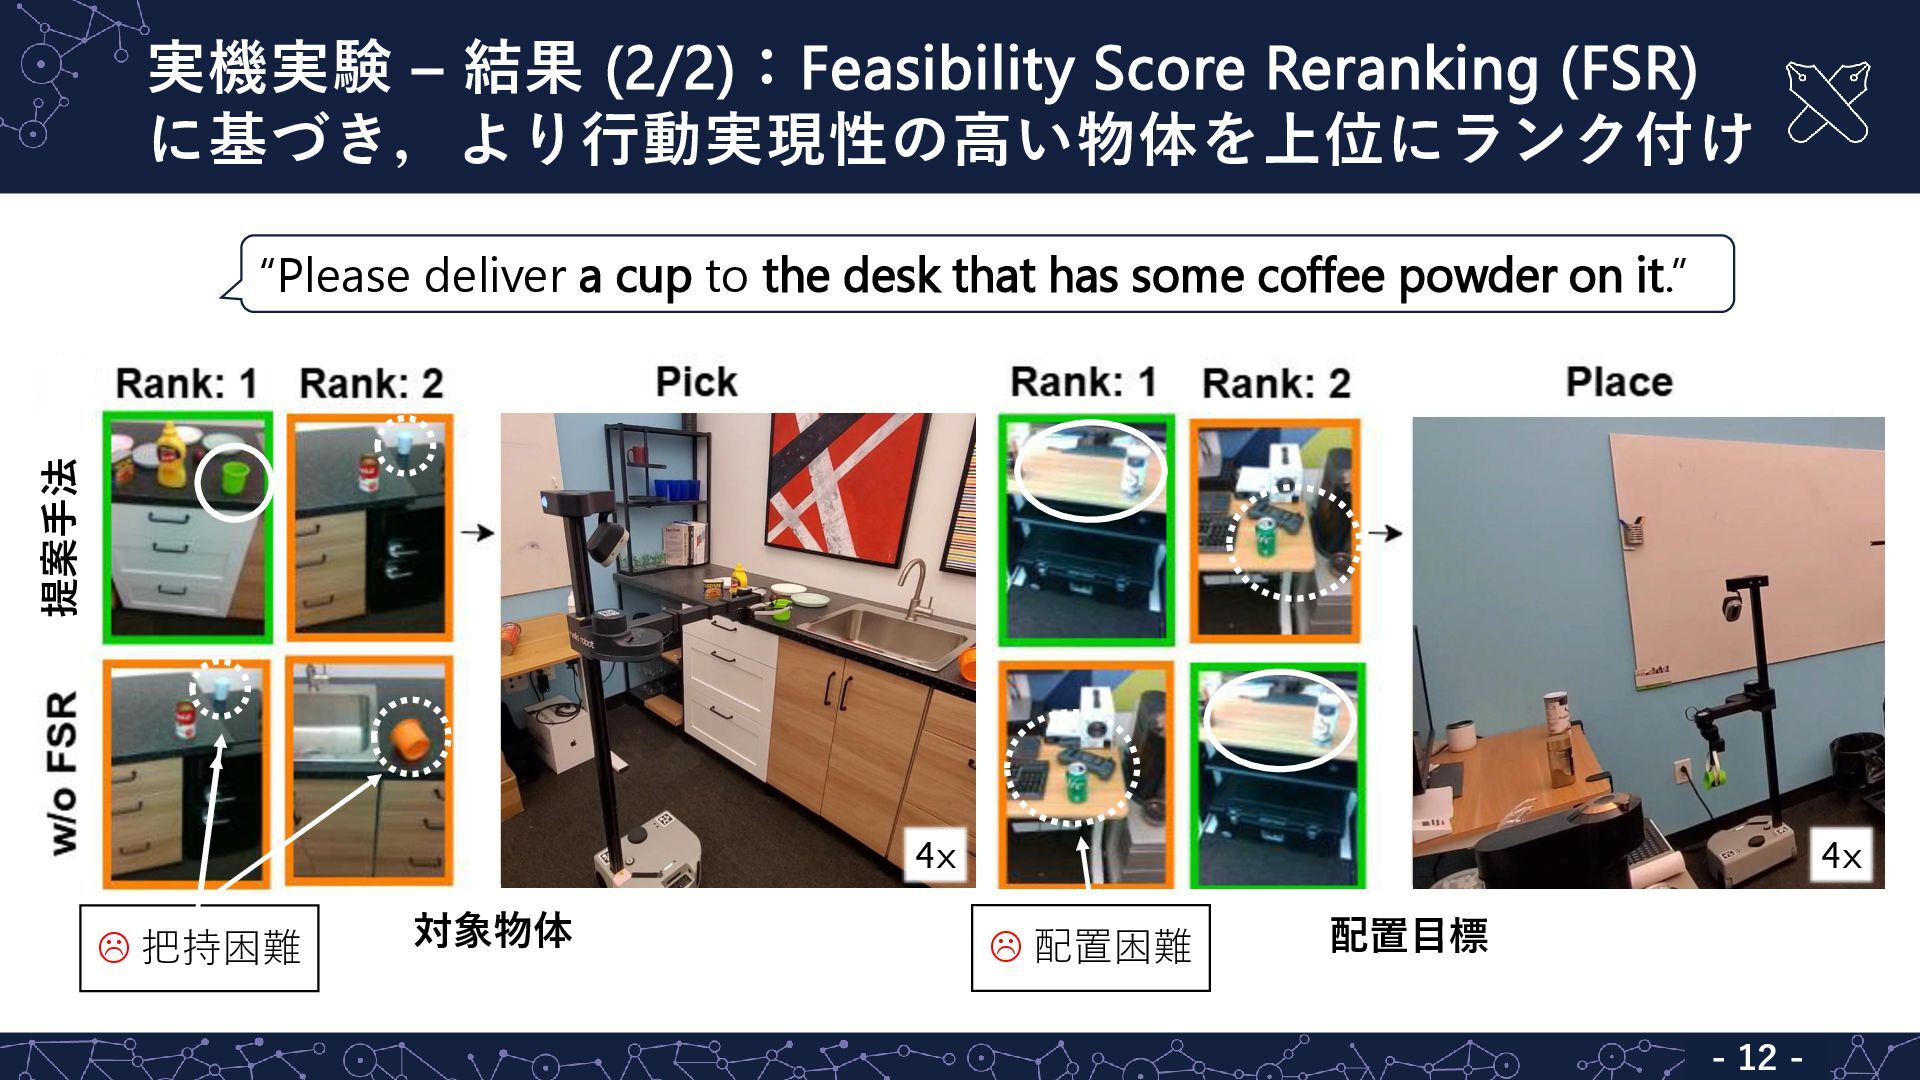
実機実験 – 結果 (2/2):Feasibility Score Reranking (FSR) に基づき,より行動実現性の高い物体を上位にランク付け - 12
- 4x 4x 対象物体 配置目標 提案手法 “Please deliver a cup to the desk that has some coffee powder on it.” 配置困難 把持困難
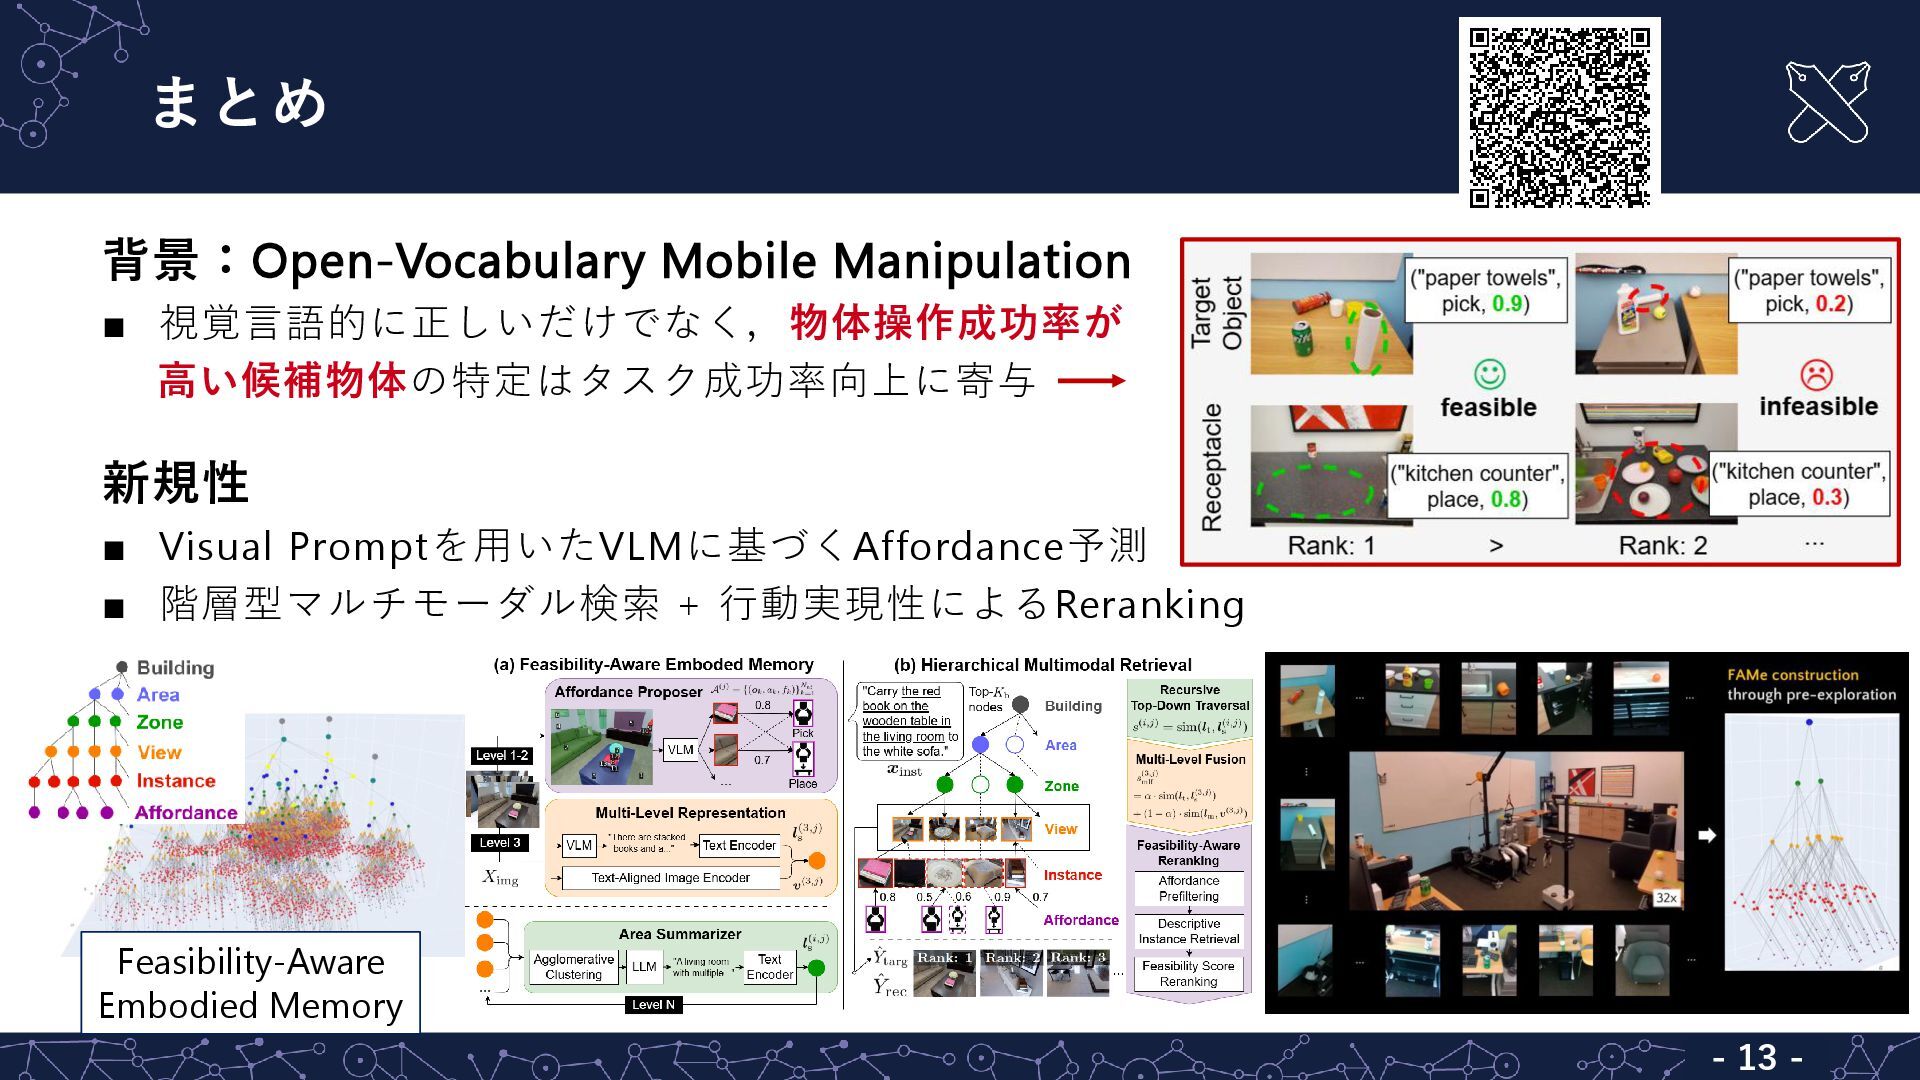
背景:Open-Vocabulary Mobile Manipulation ▪ 視覚言語的に正しいだけでなく,物体操作成功率が 高い候補物体の特定はタスク成功率向上に寄与 新規性 ▪ Visual Promptを用いたVLMに基づくAffordance予測
▪ 階層型マルチモーダル検索 + 行動実現性によるReranking Feasibility-Aware Embodied Memory まとめ - 13 -
Appendix
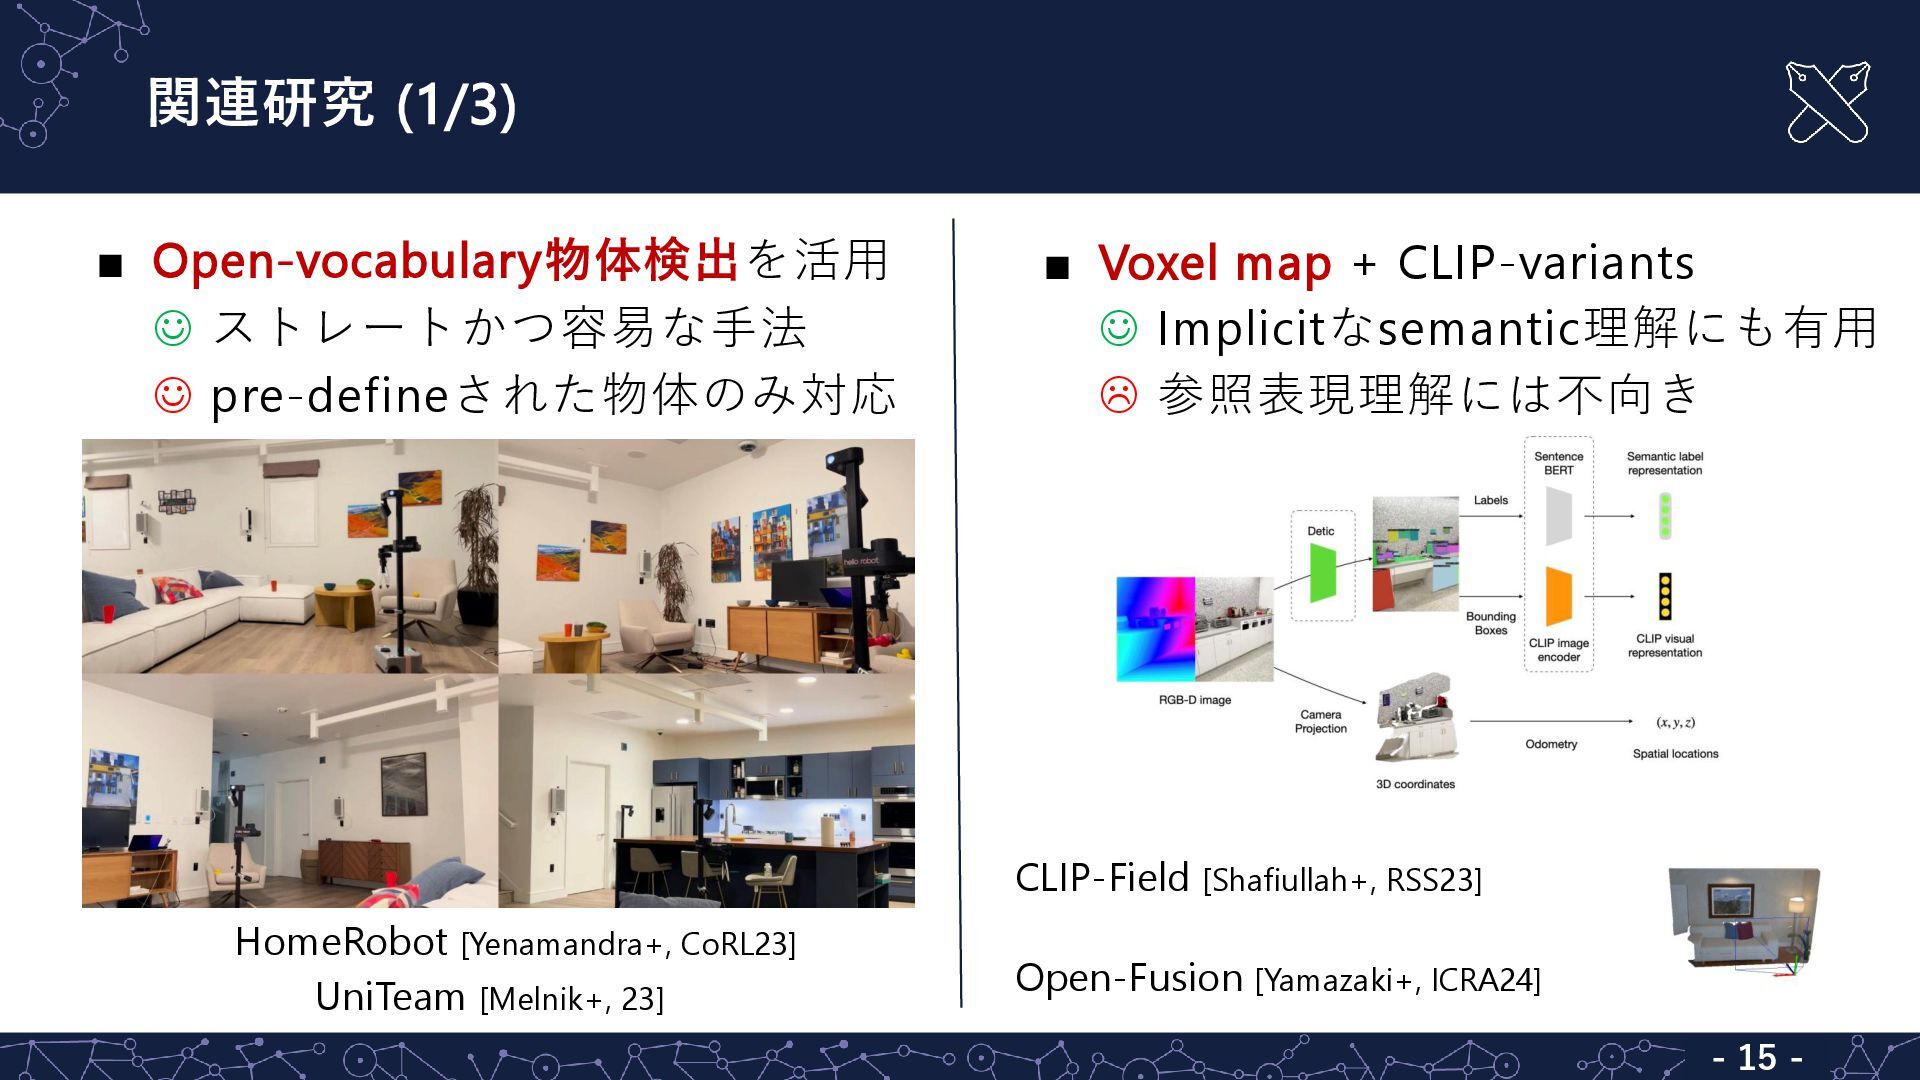
関連研究 (1/3) ▪ Open-vocabulary物体検出を活用 ☺ ストレートかつ容易な手法 ☺ pre-defineされた物体のみ対応 ▪ Voxel
map + CLIP-variants ☺ Implicitなsemantic理解にも有用 参照表現理解には不向き HomeRobot [Yenamandra+, CoRL23] UniTeam [Melnik+, 23] Open-Fusion [Yamazaki+, ICRA24] CLIP-Field [Shafiullah+, RSS23] - 15 -
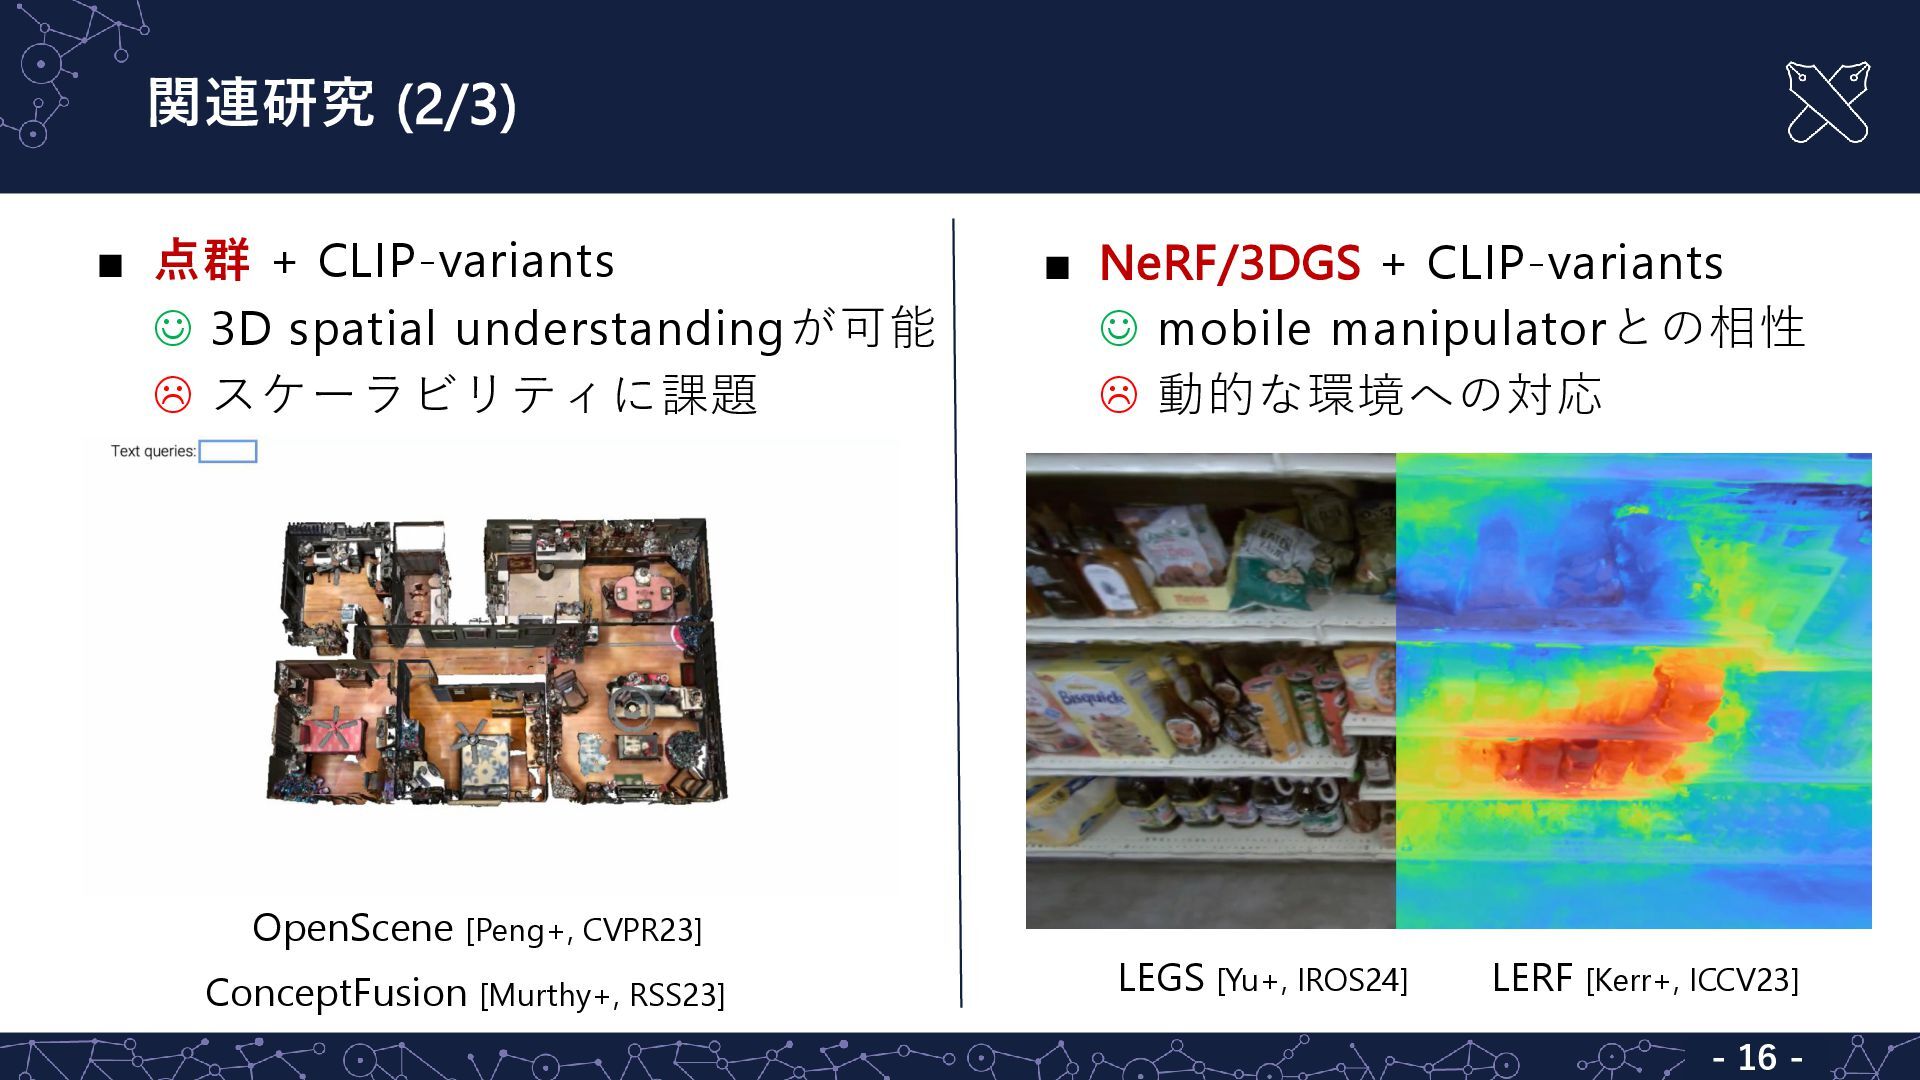
関連研究 (2/3) ▪ 点群 + CLIP-variants ☺ 3D spatial understandingが可能
スケーラビリティに課題 ▪ NeRF/3DGS + CLIP-variants ☺ mobile manipulatorとの相性 動的な環境への対応 LERF [Kerr+, ICCV23] LEGS [Yu+, IROS24] OpenScene [Peng+, CVPR23] ConceptFusion [Murthy+, RSS23] - 16 -
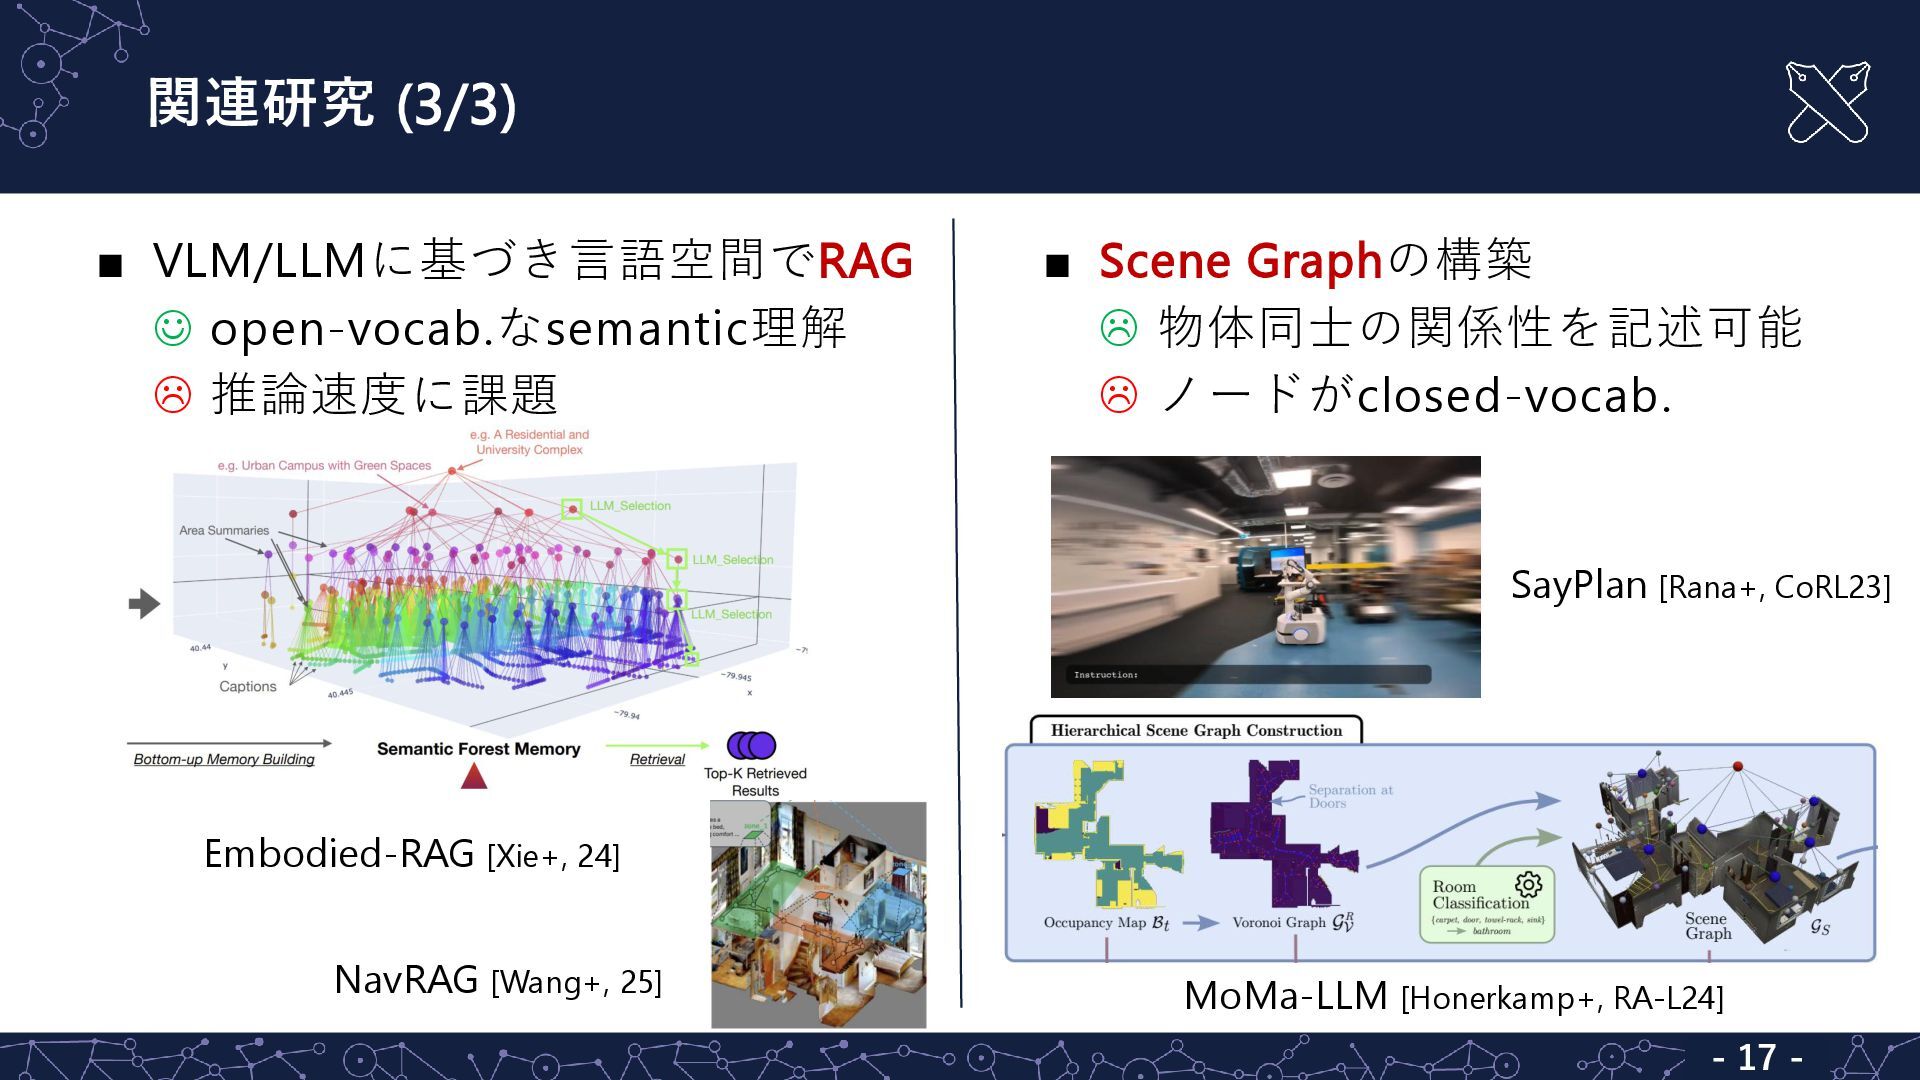
関連研究 (3/3) ▪ VLM/LLMに基づき言語空間でRAG ☺ open-vocab.なsemantic理解 推論速度に課題 ▪ Scene
Graphの構築 物体同士の関係性を記述可能 ノードがclosed-vocab. SayPlan [Rana+, CoRL23] MoMa-LLM [Honerkamp+, RA-L24] Embodied-RAG [Xie+, 24] NavRAG [Wang+, 25] - 17 -
More Decks by Semantic Machine Intelligence Lab., Keio Univ.
See All by Semantic Machine Intelligence Lab., Keio Univ.
慶應義塾大学 AI実践05 論文執筆の仕組み化
keio_smilab
PRO
7
3.9k
[EMNLP26] RIGEL: Self-Distilled Score Adaptation for Image and Video Captioning Evaluation
keio_smilab
PRO
0
170
[RSJ26] Building a VLA Model Based on Self-Distilled Classification
keio_smilab
PRO
0
230
[RSJ26] AnoleVLA: Lightweight Vision-Language-Action Model with Deep State Space Models for Mobile Manipulation
keio_smilab
PRO
0
200
[RSJ26] NarrativeFlow: Flow-Based Vision-Language-Action Model Using Robot Velocity Fields
keio_smilab
PRO
0
270
[RSJ26] Flow as Flow: Modeling Robot Velocity Fields as Probability Velocity Fields
keio_smilab
PRO
1
300
[RSJ26] Hierarchy-Aware Multimodal Retrieval-Augmented Generation for Embodied Question Answering
keio_smilab
PRO
1
210
[MIRU26] Open-Vocabulary Intention-Guided Object Detection in Diverse Scenes
keio_smilab
PRO
0
260
[Journal club] Evo-1: Lightweight Vision-Language-Action Model with Preserved Semantic Alignment
keio_smilab
PRO
0
79
Other Decks in Technology
See All in Technology
並列度を下げたら速くなった — go build の重複コンパイルを実測で見る
tomoaki25
2
1.2k
ぼくのClaude Codeの使い方
falken
PRO
4
6.5k
【Oracle AI SPOTLIGHT ウェビナー】【特別開催:日本語で解説!】Oracle AI World 2026 最新情報フィードバック
oracle4engineer
PRO
1
210
E2E Test というハーネス — AI時代の自動テスト民主化
daishukojima
1
430
Reticulum, le réseau cypherpunk dont vous avez besoin !
rlifchitz
0
140
複数システムが同居した 15 年物の AWS アカウントを解体するための考古学
wa6sn
3
140
Linuxネットワークスタック進化の軌跡: 過去10年の歩みと最新トレンド
orimanabu
3
600
属人化したISMS運用をGitHubとAIで仕組み化した1年間の記録
sioncojp
4
2.6k
Kiro アップデート 2026 年 11 月号 (11 月 8 日時点) | 目指せ Kiro マスター アップデート編
inariku
PRO
2
120
An Introduction to Context Ontology Accelerator (teaching AI agents what your data means)
inariku
PRO
1
240
サボる子はいねぇがー!AgentCoreハーネスの脆弱性に学ぶ、エージェントの入力バリデーション
iwamot
PRO
5
330
AWS Emulator を評価する: 手元で動く AWS の API の仕組み、始め方、確かめ方
inariku
PRO
1
220
Featured
See All Featured
Mind Mapping
helmedeiros
1
440
Six Lessons from altMBA
skipperchong
29
4.6k
Building Adaptive Systems
keathley
44
3.3k
Context Engineering - Making Every Token Count
addyosmani
9
1.3k
Ten Tips & Tricks for a 🌱 transition
stuffmc
1
280
A Guide to Academic Writing Using Generative AI - A Workshop
ks91
PRO
1
560
Speed Design
sergeychernyshev
33
2.2k
Dominate Local Search Results - an insider guide to GBP, reviews, and Local SEO
greggifford
PRO
0
400
SEO in 2025: How to Prepare for the Future of Search
ipullrank
3
3.9k
Marketing to machines
jonoalderson
1
6k
Game over? The fight for quality and originality in the time of robots
wayneb77
1
330
What the history of the web can teach us about the future of AI
inesmontani
PRO
3
810


 keio_smilab
 tomoaki25
 falken
 oracle4engineer
 daishukojima
 rlifchitz
 wa6sn
 orimanabu
 sioncojp
 inariku
 iwamot
 helmedeiros
 skipperchong
 keathley
 addyosmani
 stuffmc
 ks91
 sergeychernyshev
 greggifford
 ipullrank
 jonoalderson
 wayneb77
 inesmontani