Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
Analysis of the Foot Placement Estimator
Search
Sponsored
·
Your Podcast. Everywhere. Effortlessly.
Share. Educate. Inspire. Entertain. You do you. We'll handle the rest.
→
Safwan Choudhury
April 14, 2012
Research
240
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
Analysis of the Foot Placement Estimator
Safwan Choudhury
April 14, 2012
More Decks by Safwan Choudhury
See All by Safwan Choudhury
Design and Gait Synthesis for a 3D Lower Body Humanoid
safwanc
1
96
ECE 486 Lecture
safwanc
0
360
Controlling Wheelchair Motion with Electroencephalography
safwanc
3
210
Accurate Determination of Joint Angles from Inertial Measurement Unit Data
safwanc
0
210
Gait Controller for 3D Active Dynamic Walking
safwanc
0
180
Bipedal Locomotion
safwanc
2
81
Learning Thought-Based Motor Control using Gaussian Processes
safwanc
0
150
Electromechanical Design
safwanc
0
180
Other Decks in Research
See All in Research
HAKARI-Bench - 実運用視点での情報検索モデル評価ベンチマーク
hotchpotch
1
820
ふとした出会いで生まれたSkillが、 社内利用1位になるまで
mikimhk
22
25k
実例から見るLLMのマンガ理解:実務VQAタスクによる長期的文脈と視覚情報の定性評価
kzmssk
0
190
横浜市長(山中氏)の言動にかかる第三者による調査報告書
sishi2026
0
650
Evaluation génomique des femelles laitières croisées : comprendre la méthode pour accompagner les éleveurs à son utilisation
institutdelelevage
PRO
0
170
研究室単位での自律的 IPv6接続性確立に向けたAS共同運用モデルの提案と実証
reokashiwa
PRO
0
230
Visual SLAM未来予測 / Future Prediction in Visual SLAM
koide3
1
1.3k
進化?迷走?CasualConc ファミリーアプリの現在地 @ 英語コーパス学会 2026
casualconc
0
150
MIRU2026 チュートリアル講演2:三次元データ処理の動向
nnchiba
8
5.4k
某助成金プロジェクト採択に向けて企業研究所のアウトリーチ専任者がやったこと
afroscript
0
200
敵対生成プロンプト同時探索による内省型プロンプト最適化
kinoue_smarthr
0
450
A new deal for disabled people
resolutionfoundation
0
270
Featured
See All Featured
Responsive Adventures: Dirty Tricks From The Dark Corners of Front-End
smashingmag
254
22k
Redefining SEO in the New Era of Traffic Generation
szymonslowik
1
480
Optimising Largest Contentful Paint
csswizardry
37
4k
Build The Right Thing And Hit Your Dates
maggiecrowley
39
3.5k
So, you think you're a good person
axbom
PRO
2
2.2k
Collaborative Software Design: How to facilitate domain modelling decisions
baasie
1
340
Fight the Zombie Pattern Library - RWD Summit 2016
marcelosomers
234
18k
Faster Mobile Websites
deanohume
310
32k
svc-hook: hooking system calls on ARM64 by binary rewriting
retrage
2
630
How To Stay Up To Date on Web Technology
chriscoyier
790
250k
コードの90%をAIが書く世界で何が待っているのか / What awaits us in a world where 90% of the code is written by AI
rkaga
63
46k
Refactoring Trust on Your Teams (GOTO; Chicago 2020)
rmw
35
3.8k
Transcript
Foot Placement Estimator A Dynamic Measure of Balance for Bipedal
Robots ECE 688: Course Project Safwan Choudhury
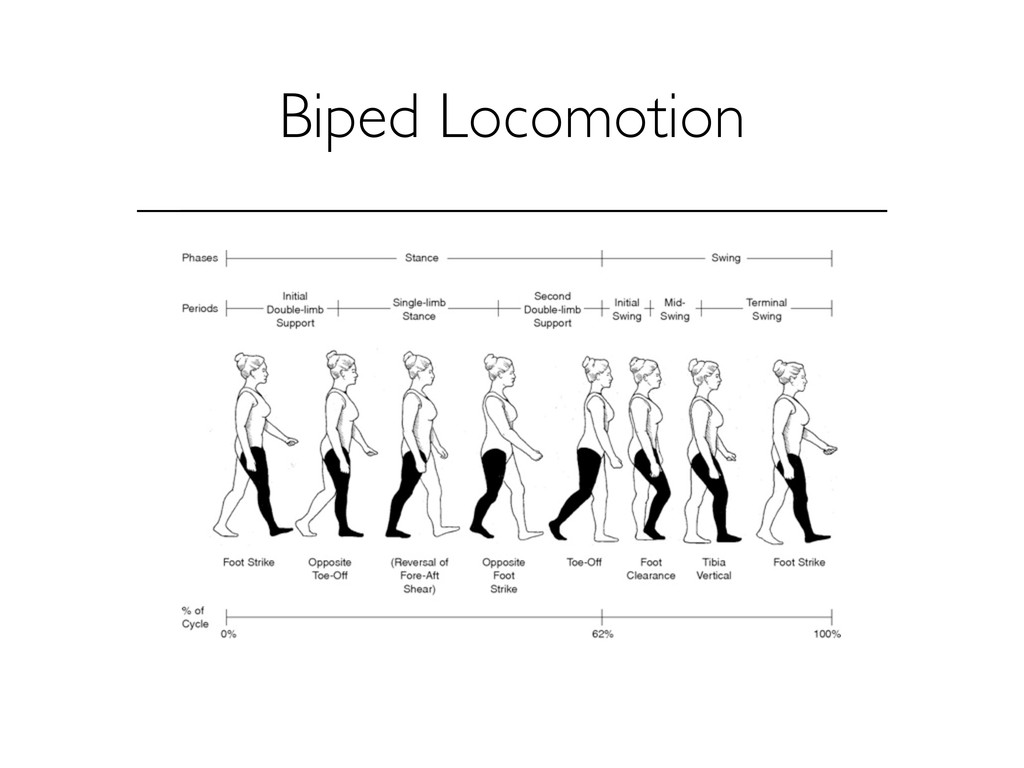
Biped Locomotion
Motivations ★ Navigating Human Environments ★ Space Exploration / Military
Applications ★ Rehabilitation / Prosthetics
2011 Honda ASIMO at FIRST Robotics ★ Navigating Human Environments
2011 Honda ASIMO at FIRST Robotics ★ Navigating Human Environments
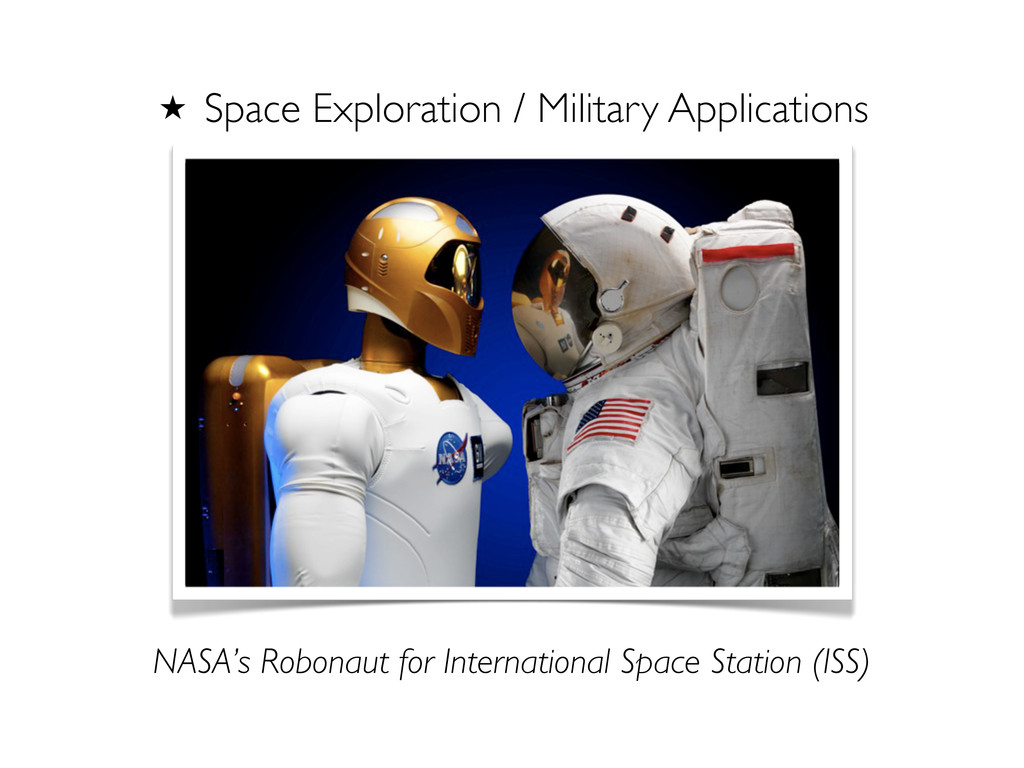
NASA’s Robonaut for International Space Station (ISS) ★ Space Exploration
/ Military Applications
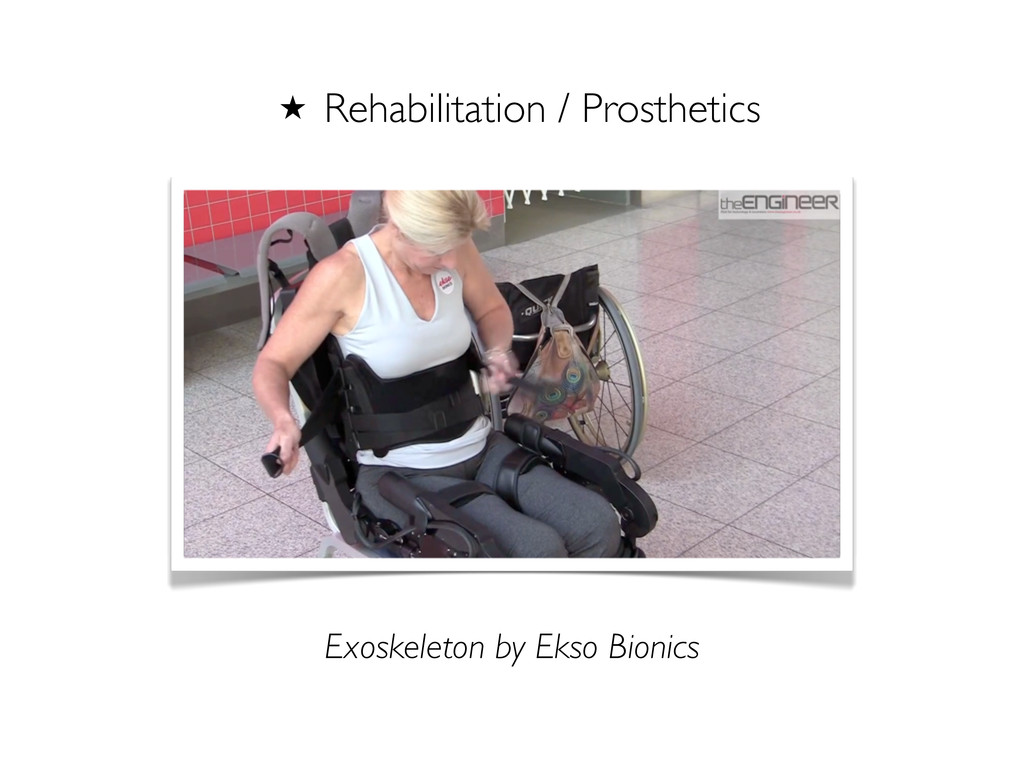
Exoskeleton by Ekso Bionics ★ Rehabilitation / Prosthetics
Exoskeleton by Ekso Bionics ★ Rehabilitation / Prosthetics
Achieve stable and energetically efficient walking control strategies for bipedal
robots which mimic human-like gait
Walking Control Strategies ★ Zero-Moment Point ★ Passive Dynamics ★
Biologically Inspired Techniques ★ Central Pattern Generators ★ Neural Networks ★ Zero-Hybrid Dynamics
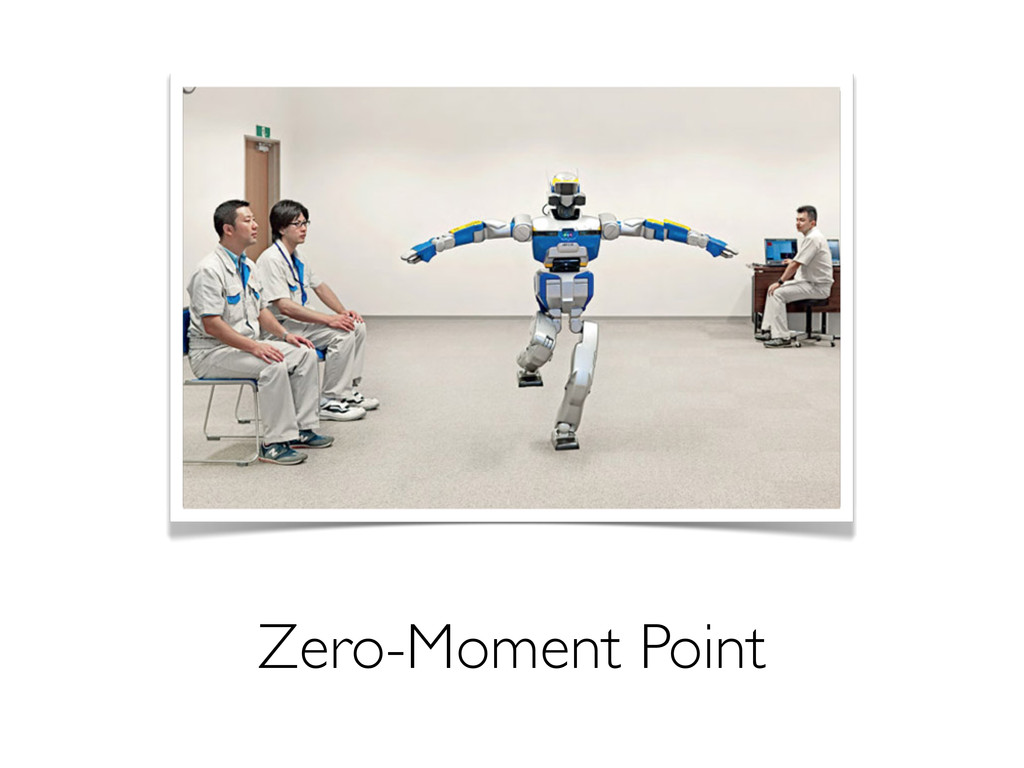
Zero-Moment Point
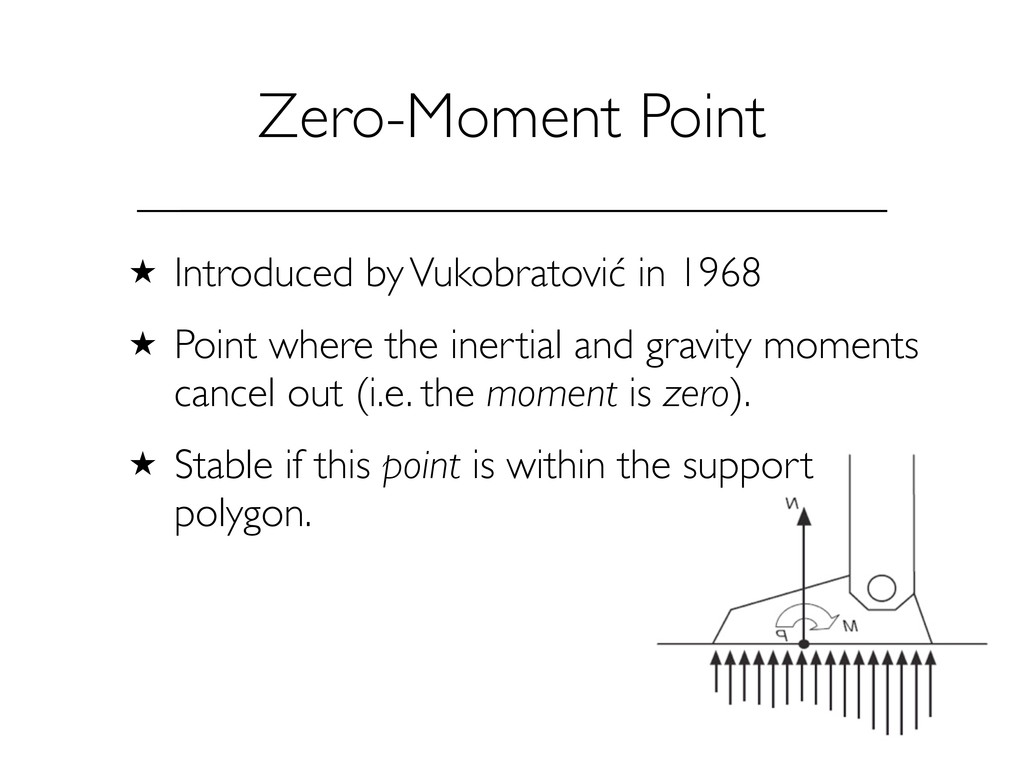
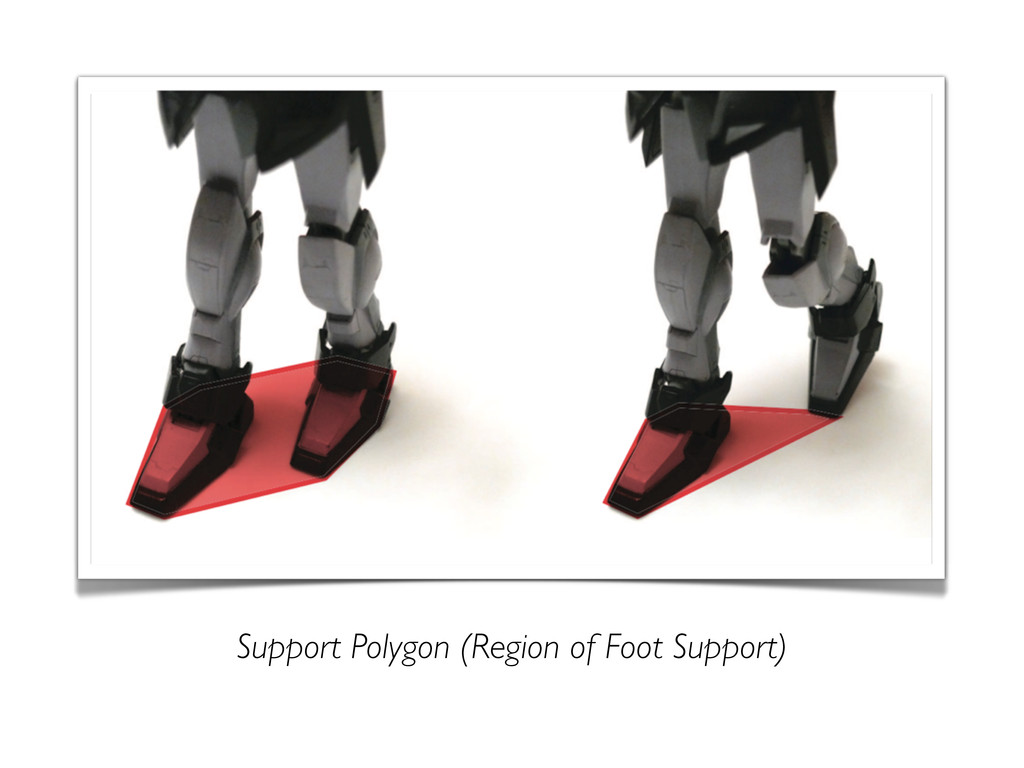
Zero-Moment Point ★ Introduced by Vukobratović in 1968 ★ Point
where the inertial and gravity moments cancel out (i.e. the moment is zero). ★ Stable if this point is within the support polygon.
Support Polygon (Region of Foot Support)
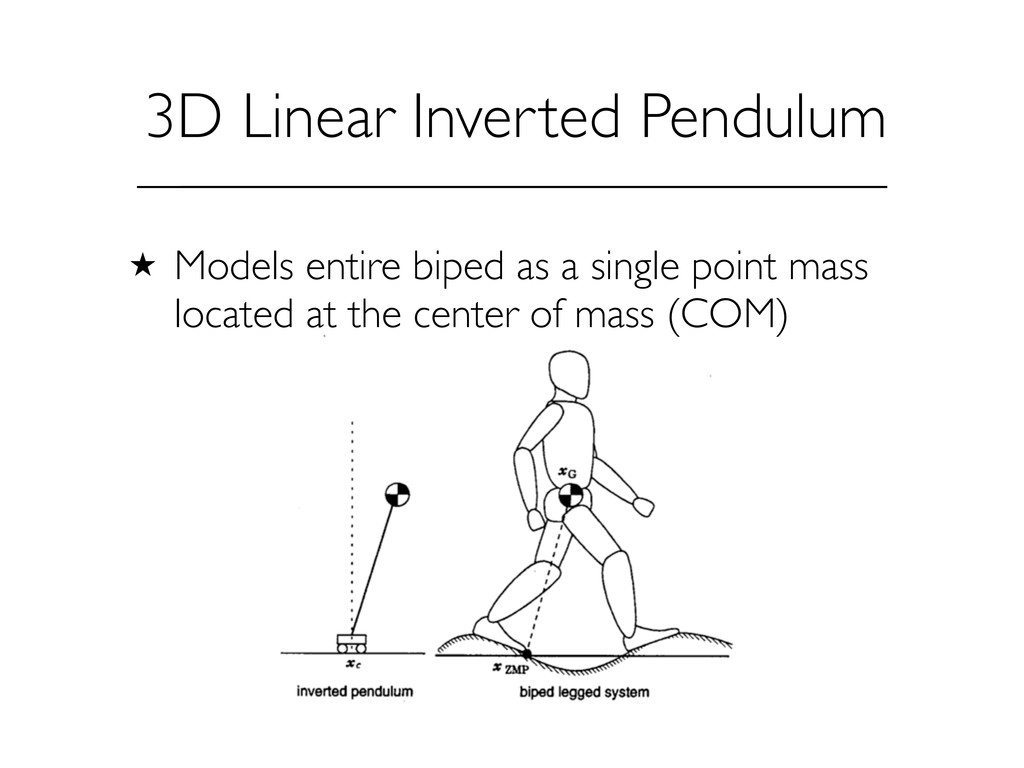
3D Linear Inverted Pendulum ★ Models entire biped as a
single point mass located at the center of mass (COM)
Remarks on ZMP ★ Popular but energetically inefficient ★ Statically
stable walking only ★ Very “robotic” (not human-like gait)
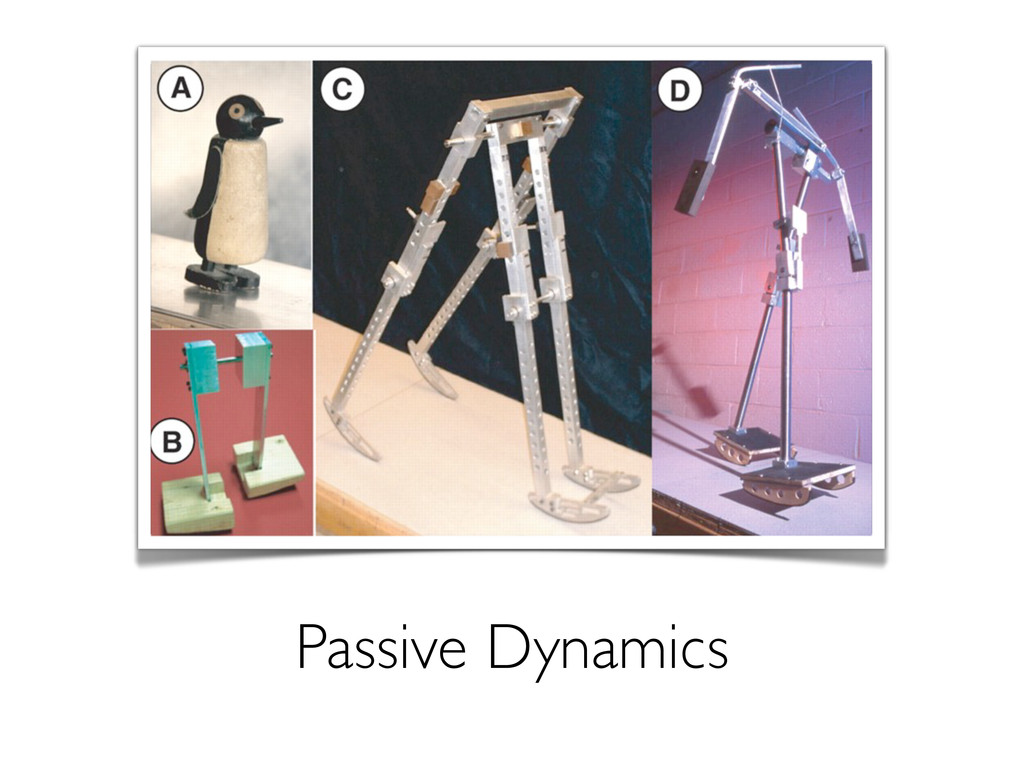
Passive Dynamics
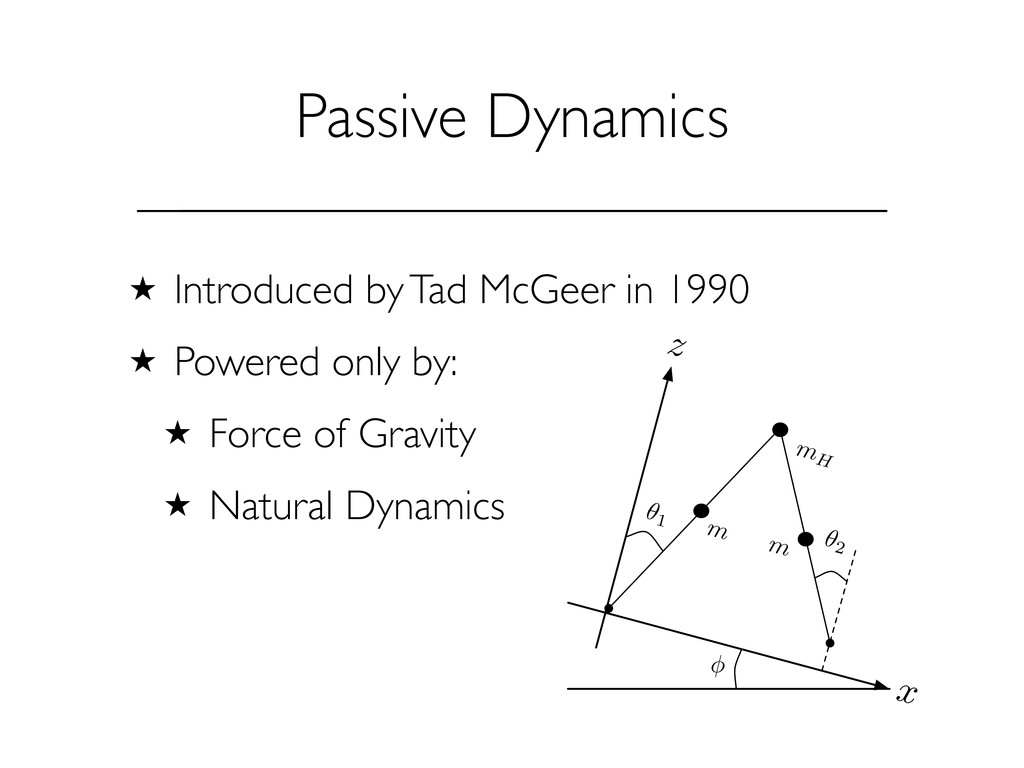
Passive Dynamics ★ Introduced by Tad McGeer in 1990 ★
Powered only by: ★ Force of Gravity ★ Natural Dynamics θ1 θ2 m m mH x z φ
Tad McGeer’s Seminal Work (1990) ★ Passive Dynamic Walker
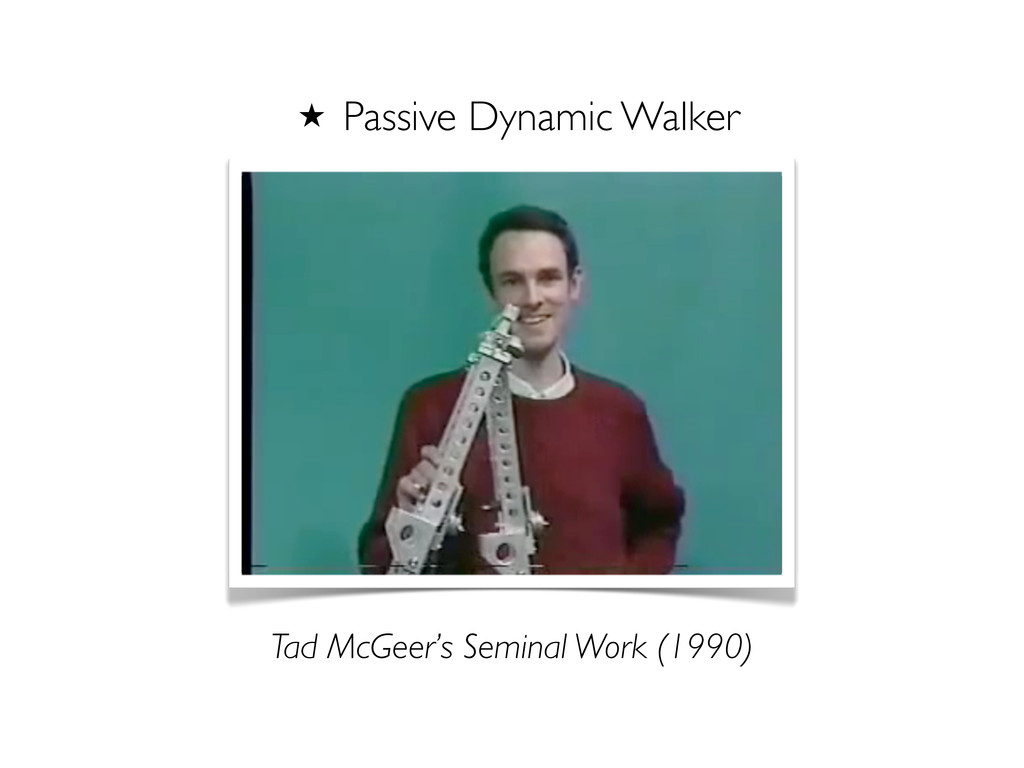
Tad McGeer’s Seminal Work (1990) ★ Passive Dynamic Walker
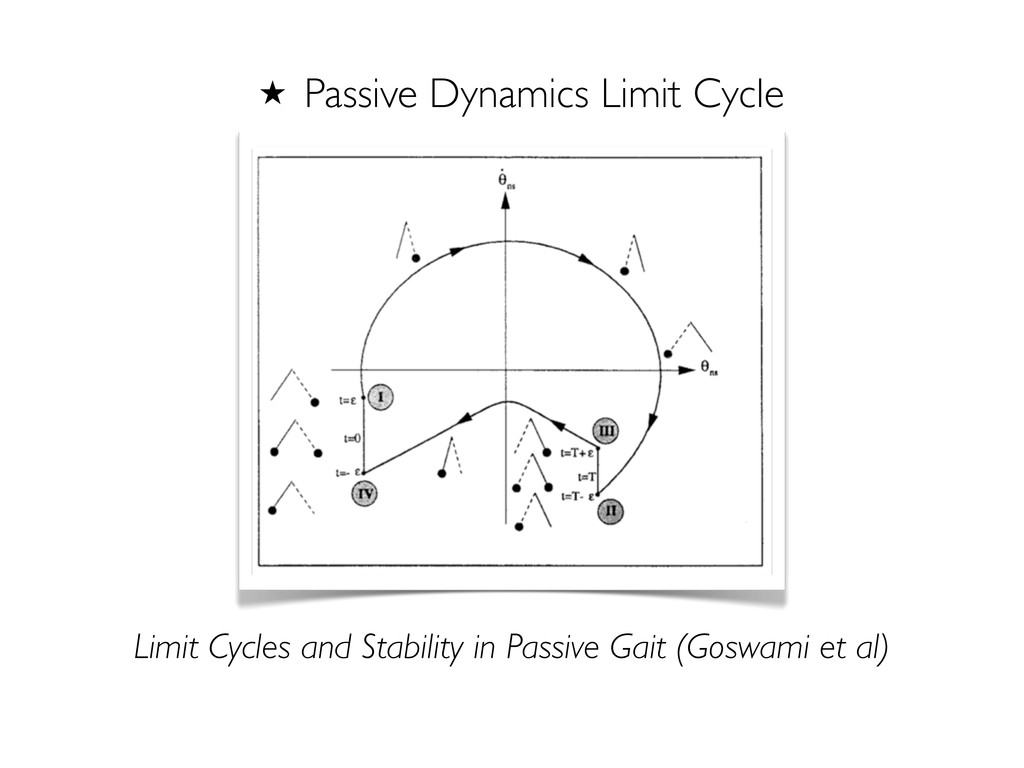
Limit Cycles and Stability in Passive Gait (Goswami et al)
★ Passive Dynamics Limit Cycle
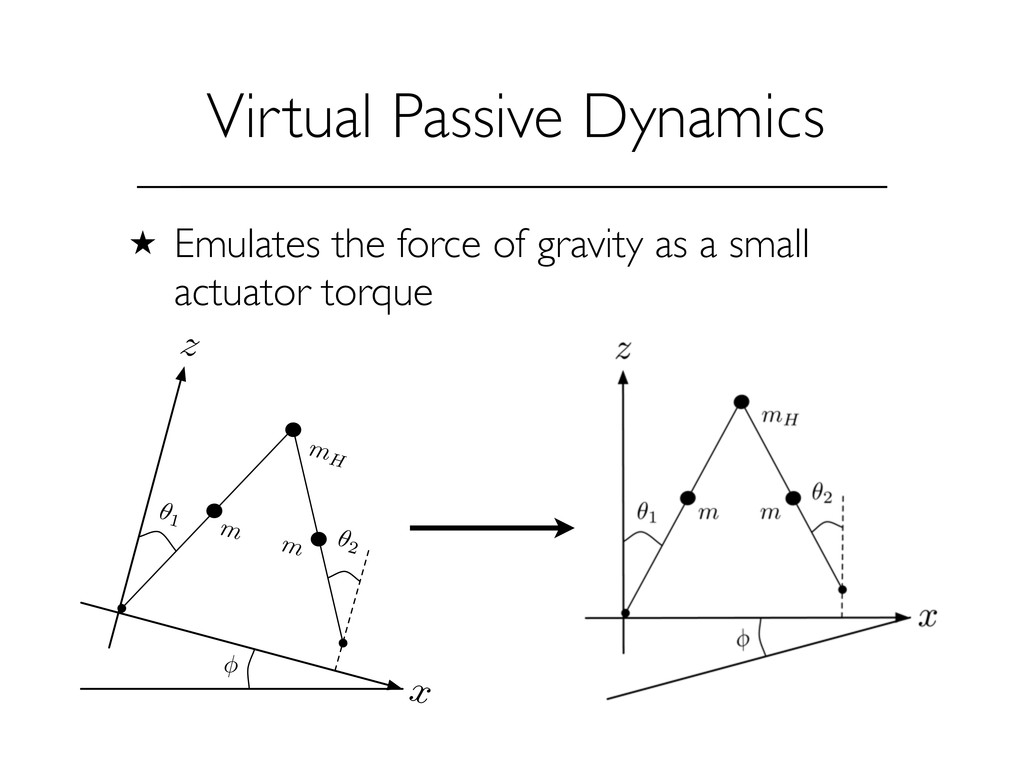
Virtual Passive Dynamics ★ Emulates the force of gravity as
a small actuator torque θ1 θ2 m m mH x z φ
Remarks on Passive Dynamics ★ Highly energetically efficient ★ Not
robust (even small perturbations) ★ Very specific initial conditions
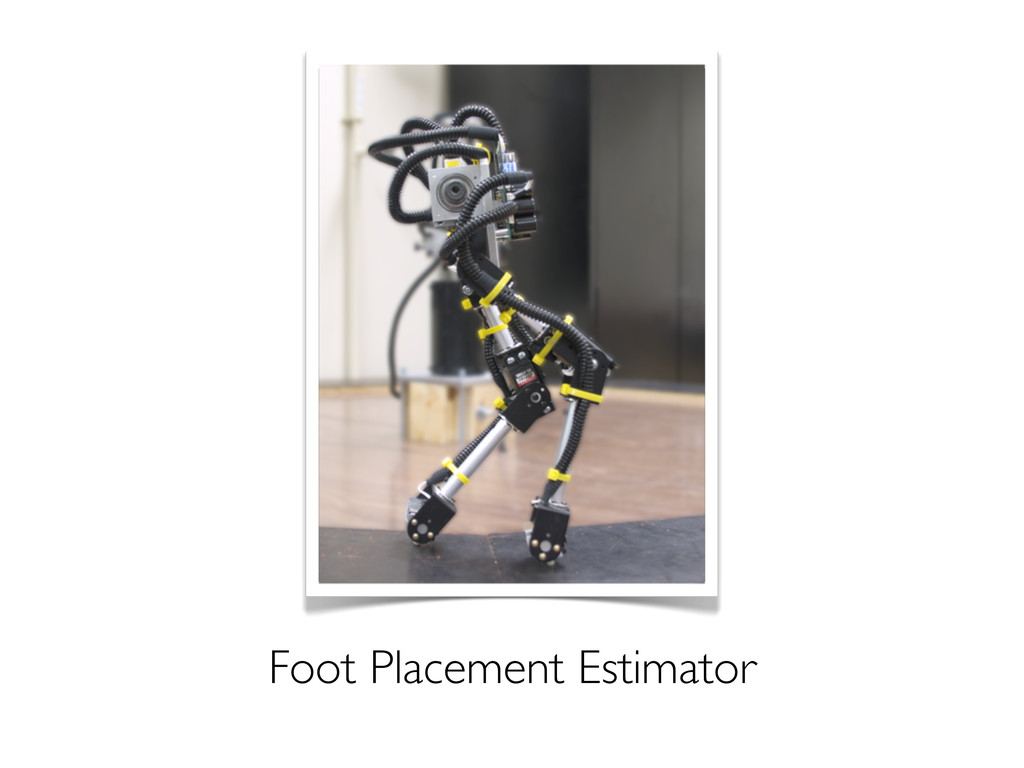
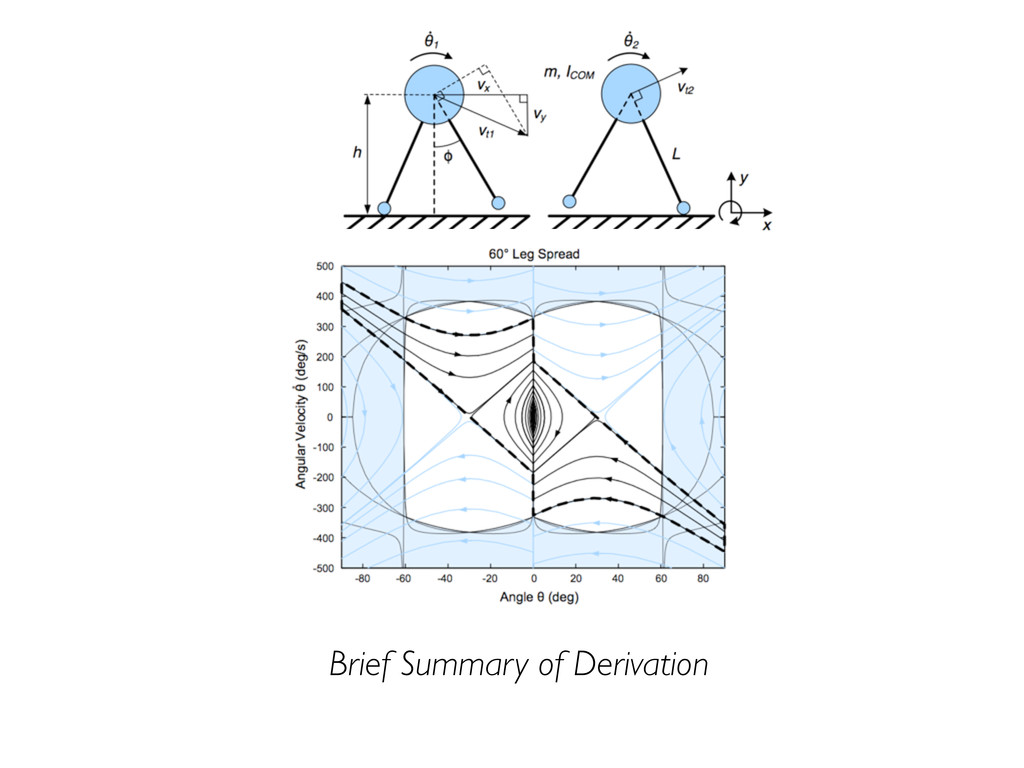
Foot Placement Estimator
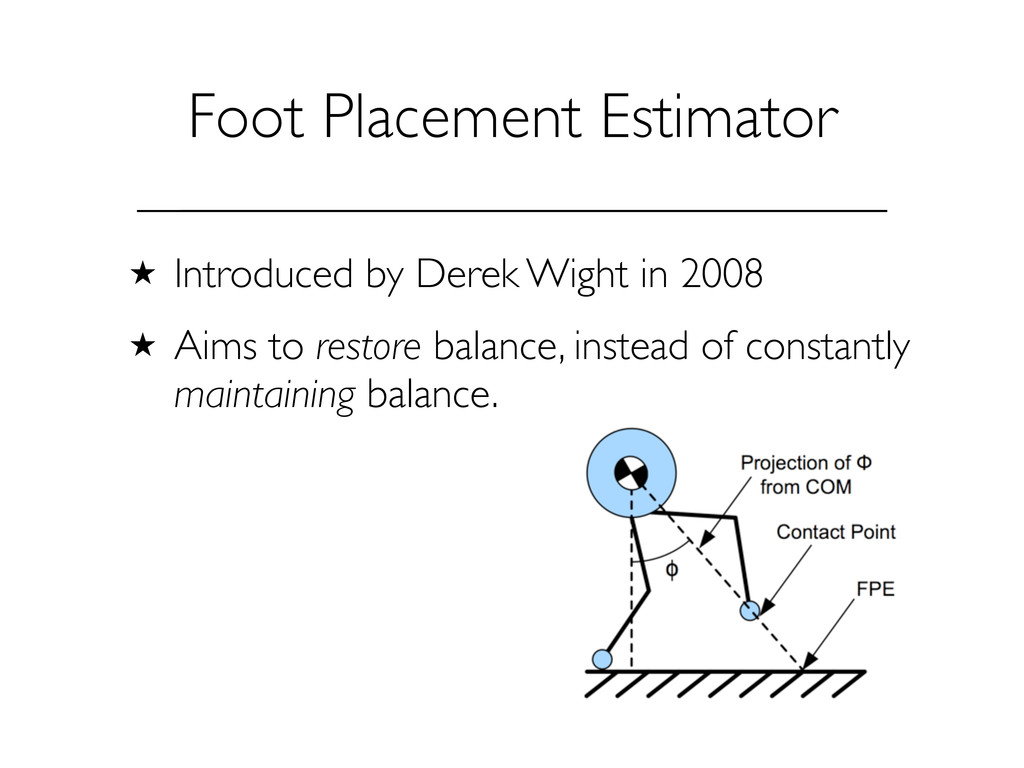
Foot Placement Estimator ★ Introduced by Derek Wight in 2008
★ Aims to restore balance, instead of constantly maintaining balance.
Brief Summary of Derivation
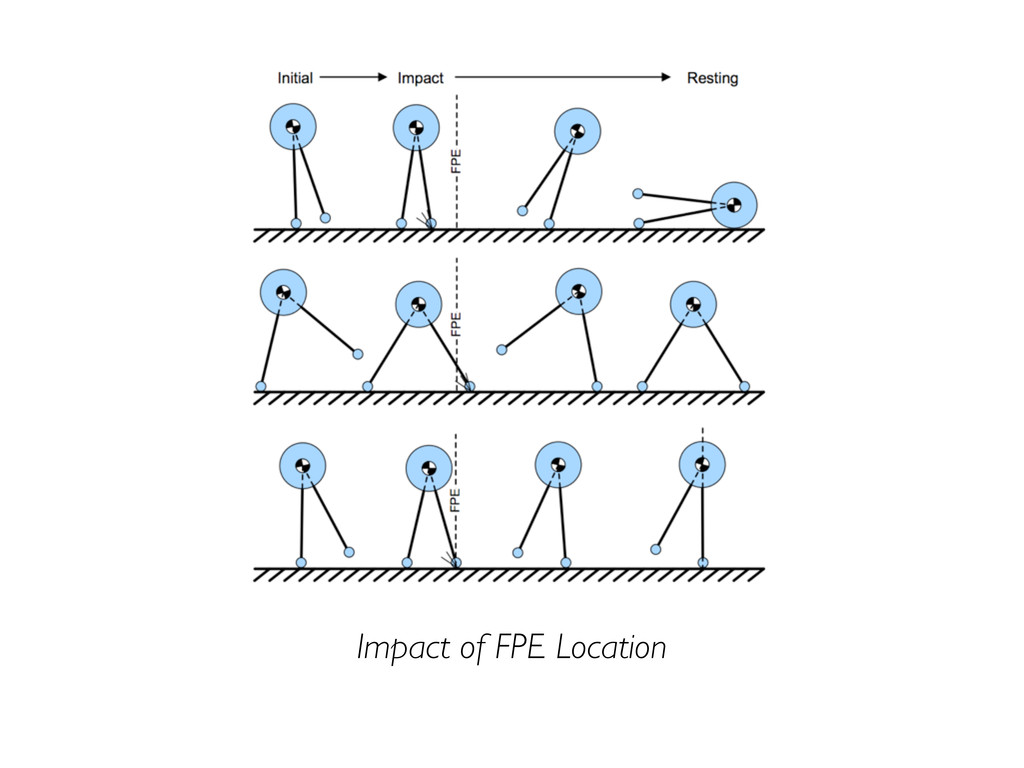
Impact of FPE Location
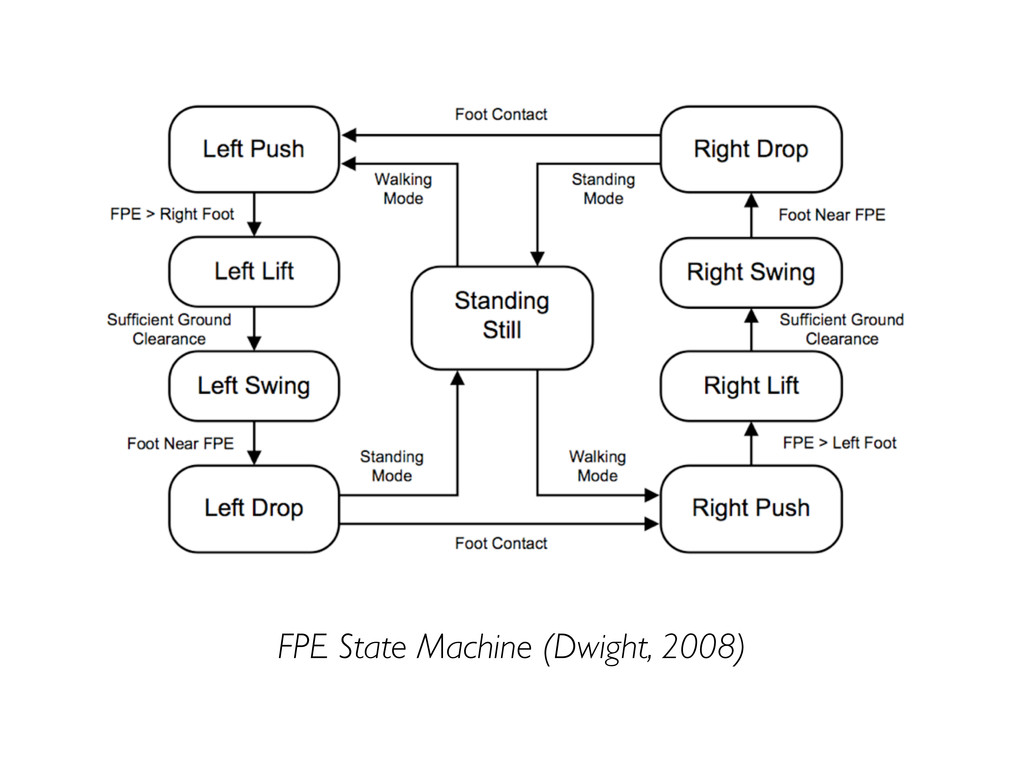
FPE State Machine (Dwight, 2008)
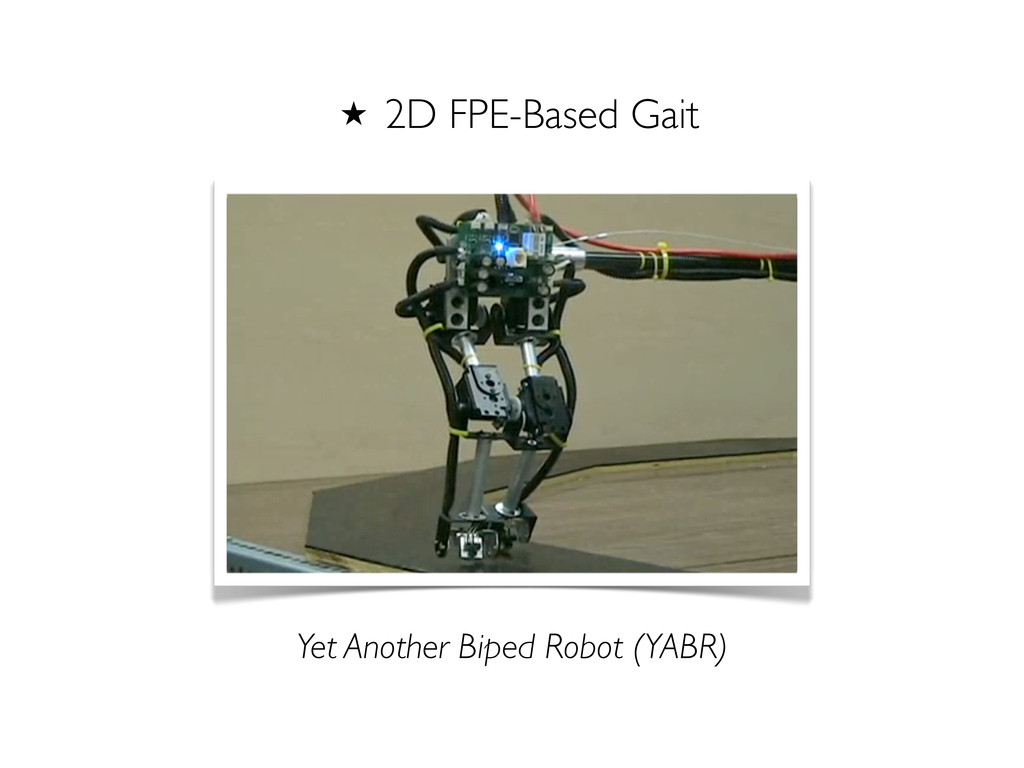
Yet Another Biped Robot (YABR) ★ 2D FPE-Based Gait
Yet Another Biped Robot (YABR) ★ 2D FPE-Based Gait
Remarks on FPE ★ Inherently robust (by design) ★ Can
combine with simple control strategies ★ Makes a few assumptions (i.e. mass-less legs) ★ Requires fast control + actuators
Contributions to Bipedal Locomotion ★ Can be combined with any
other approach as an emergency mechanism (even ZMP). ★ Provides an indicator of how unstable the biped is. ★ Biologically verified with human experiments
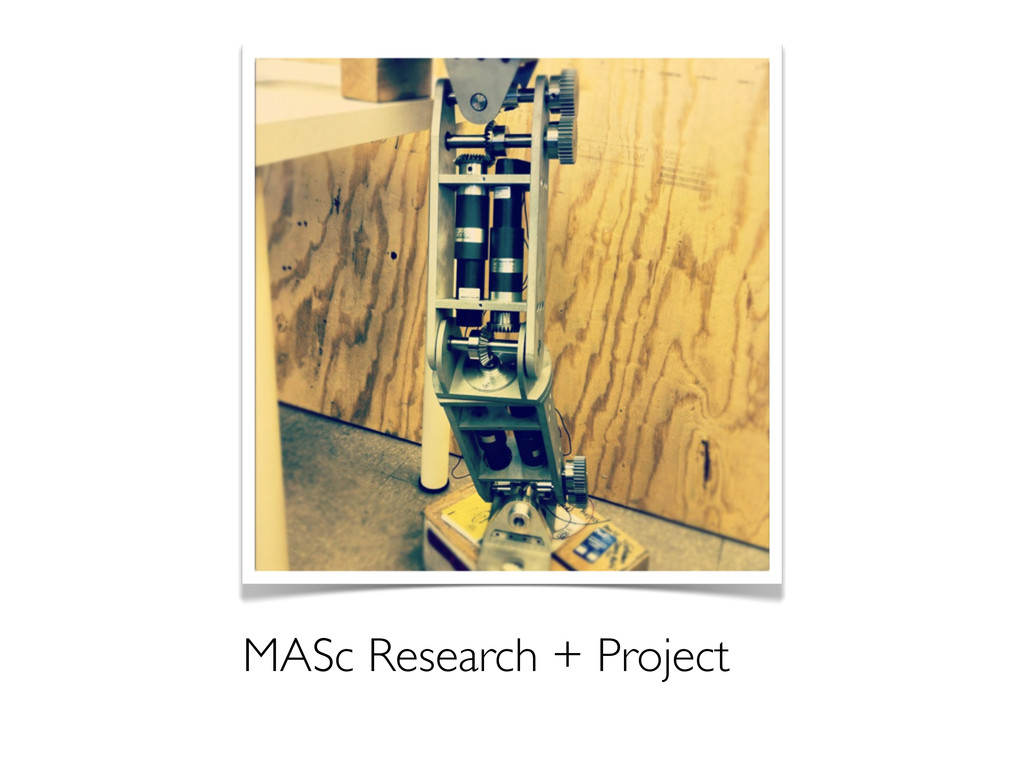
MASc Research + Project
Project Goals ★ Implement FPE-based control strategy in dynamic simulations
★ Constrain sagittal motion without the boom (!)
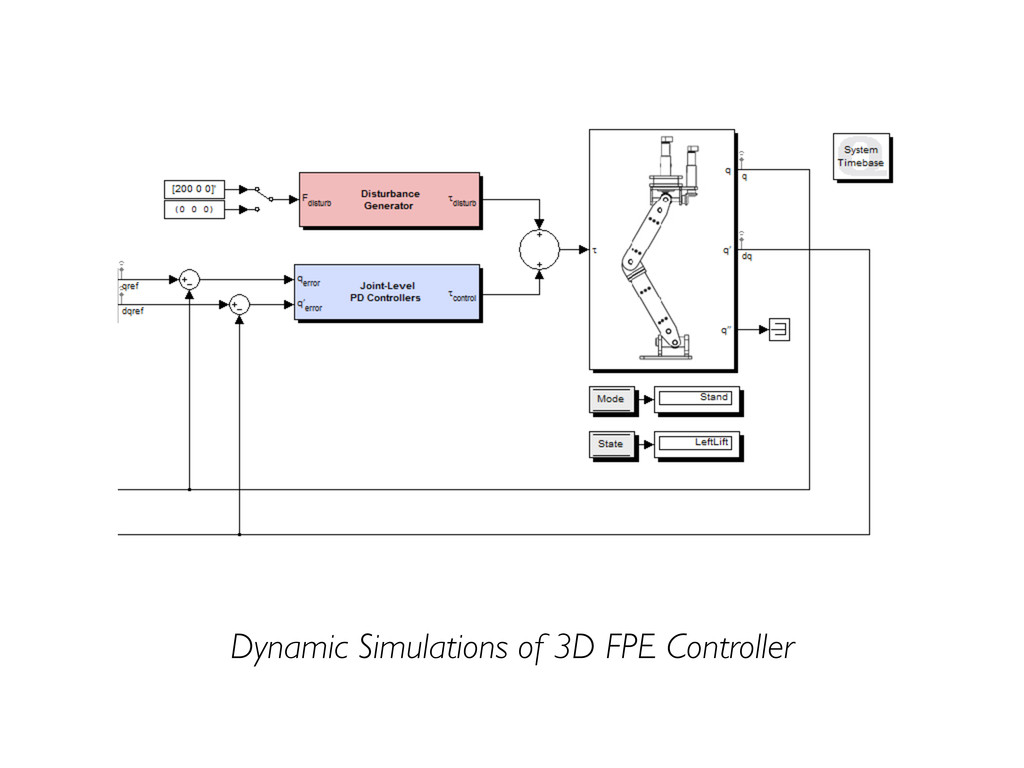
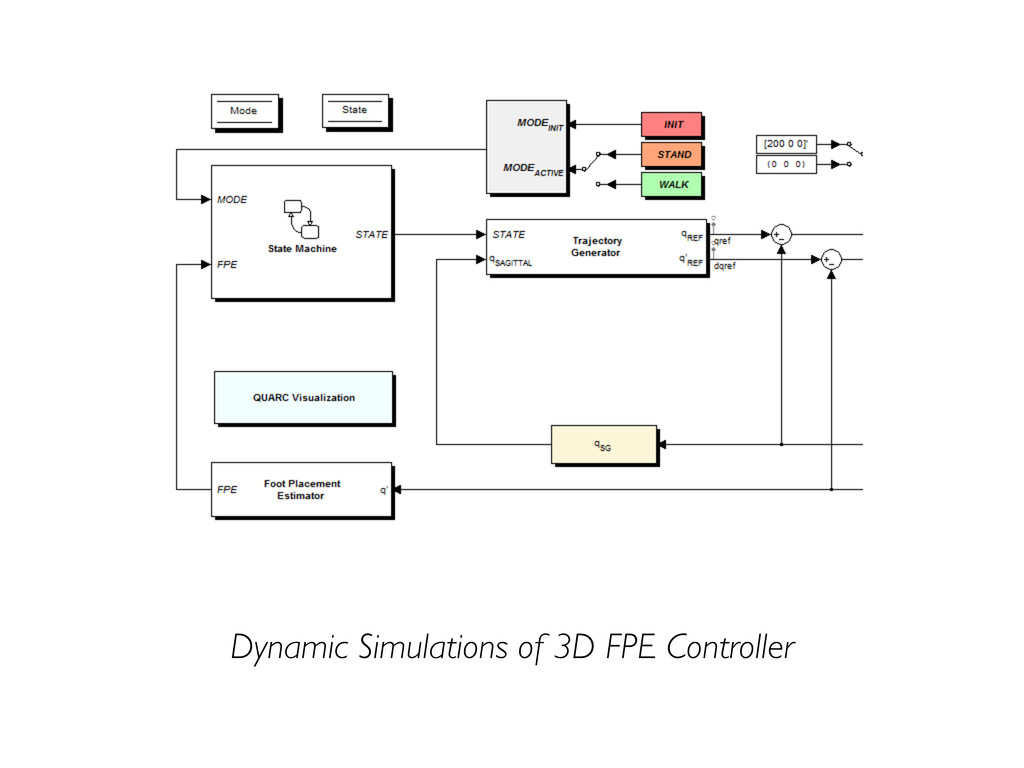
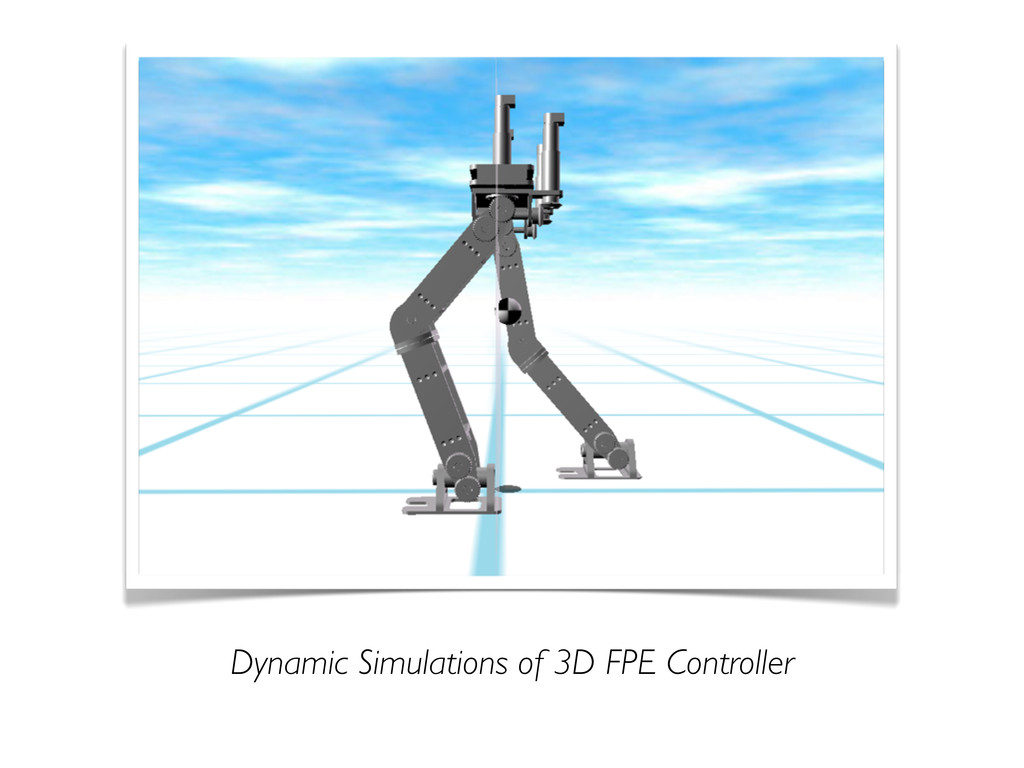
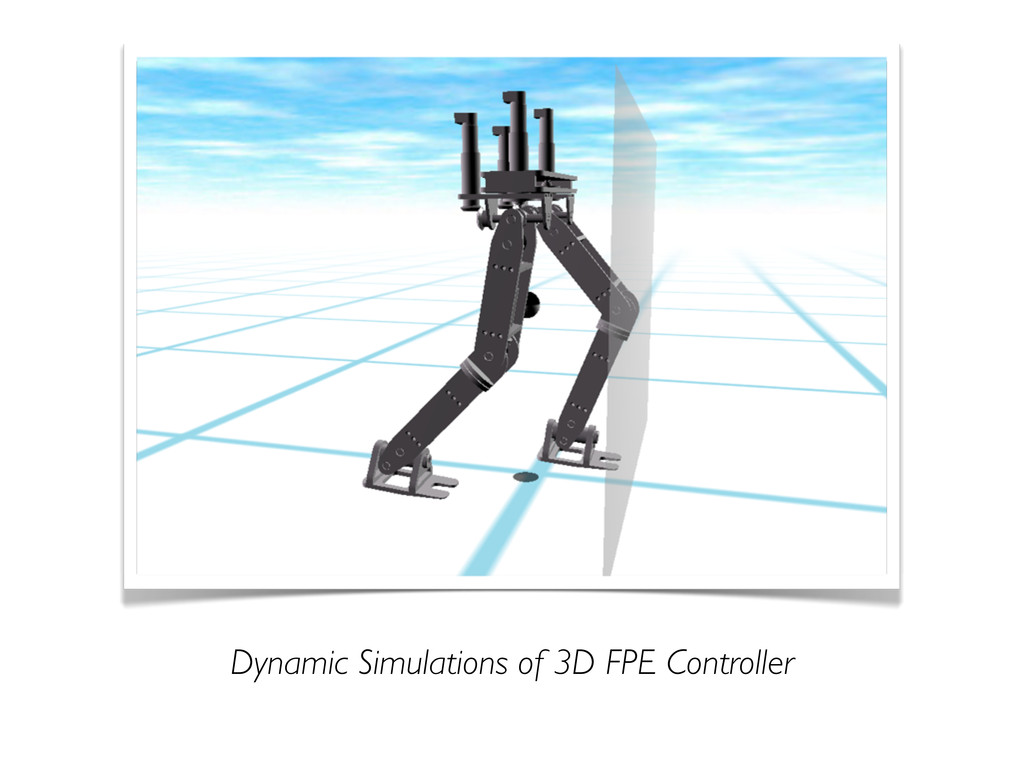
Dynamic Simulations of 3D FPE Controller
Dynamic Simulations of 3D FPE Controller
Dynamic Simulations of 3D FPE Controller
Dynamic Simulations of 3D FPE Controller
MASc Goals ★ Virtual Passive Dynamics ★ Foot Placement Estimator
★ Minimizing Energy Consumption ★ Human-Like Gait Cycles
Questions?


 safwanc
 hotchpotch
 mikimhk
 kzmssk
 sishi2026
 institutdelelevage
 reokashiwa
 koide3
 casualconc
 nnchiba
 afroscript
 kinoue_smarthr
 resolutionfoundation
 smashingmag
 szymonslowik
 csswizardry
 maggiecrowley
 axbom
 baasie
 marcelosomers
 deanohume
 retrage
 chriscoyier
 rkaga
 rmw