Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
Bipedal Locomotion
Search
Sponsored
·
Your Podcast. Everywhere. Effortlessly.
Share. Educate. Inspire. Entertain. You do you. We'll handle the rest.
→
Safwan Choudhury
April 25, 2012
Research
81
2
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
Bipedal Locomotion
ME 780 Graduate Course Presentation
Safwan Choudhury
April 25, 2012
More Decks by Safwan Choudhury
See All by Safwan Choudhury
Design and Gait Synthesis for a 3D Lower Body Humanoid
safwanc
1
96
ECE 486 Lecture
safwanc
0
360
Controlling Wheelchair Motion with Electroencephalography
safwanc
3
210
Accurate Determination of Joint Angles from Inertial Measurement Unit Data
safwanc
0
210
Gait Controller for 3D Active Dynamic Walking
safwanc
0
180
Learning Thought-Based Motor Control using Gaussian Processes
safwanc
0
150
Analysis of the Foot Placement Estimator
safwanc
0
240
Electromechanical Design
safwanc
0
180
Other Decks in Research
See All in Research
MIRU2026 チュートリアル講演2:三次元データ処理の動向
nnchiba
8
5.4k
就労支援の現場での生成AI活用
enochan
0
150
論文紹介:Doc-to-LoRA: Learning to Instantly Internalize Contexts
yukako_nakano
0
200
XDPerf: A High-Performance Traffic Generator Built with WASM and eBPF
takehaya
1
340
某助成金プロジェクト採択に向けて企業研究所のアウトリーチ専任者がやったこと
afroscript
0
200
Les émissions de méthane entérique en élevage laitier : Enjeux et travaux menés en Afrique de l’Ouest et en France
institutdelelevage
PRO
0
130
Cross-Media Human-Information Interaction
signer
PRO
0
280
超効率化への挑戦:1bit LLMの現状と展望
yumaichikawa
0
880
【Zozo Research 技術共有会】三次元領域の現在と展望
mickey_0226
3
680
HackSick vol.7 LT資料【LLMアーキテクチャ入門・事前学習時の躓き所解説】 スパースなAttention・状態空間モデル
rikkabotan7
0
220
ros2-perf-multihost: Automated Coordination Framework for Objective Architecture Evaluation in Distributed Systems
takasehideki
0
150
CDCL を用いた MILP の厳密解法
imai448
0
300
Featured
See All Featured
Become a Pro
speakerdeck
PRO
31
6.3k
SEOcharity - Dark patterns in SEO and UX: How to avoid them and build a more ethical web
sarafernandez
0
300
Making Projects Easy
brettharned
120
6.8k
Connecting the Dots Between Site Speed, User Experience & Your Business [WebExpo 2025]
tammyeverts
11
1.1k
Unsuck your backbone
ammeep
672
58k
4 Signs Your Business is Dying
shpigford
187
23k
Documentation Writing (for coders)
carmenintech
77
5.6k
Site-Speed That Sticks
csswizardry
13
1.6k
16th Malabo Montpellier Forum Presentation
akademiya2063
PRO
0
410
A designer walks into a library…
pauljervisheath
211
25k
The Impact of AI in SEO - AI Overviews June 2024 Edition
aleyda
6
1.2k
jQuery: Nuts, Bolts and Bling
dougneiner
66
8.6k
Transcript
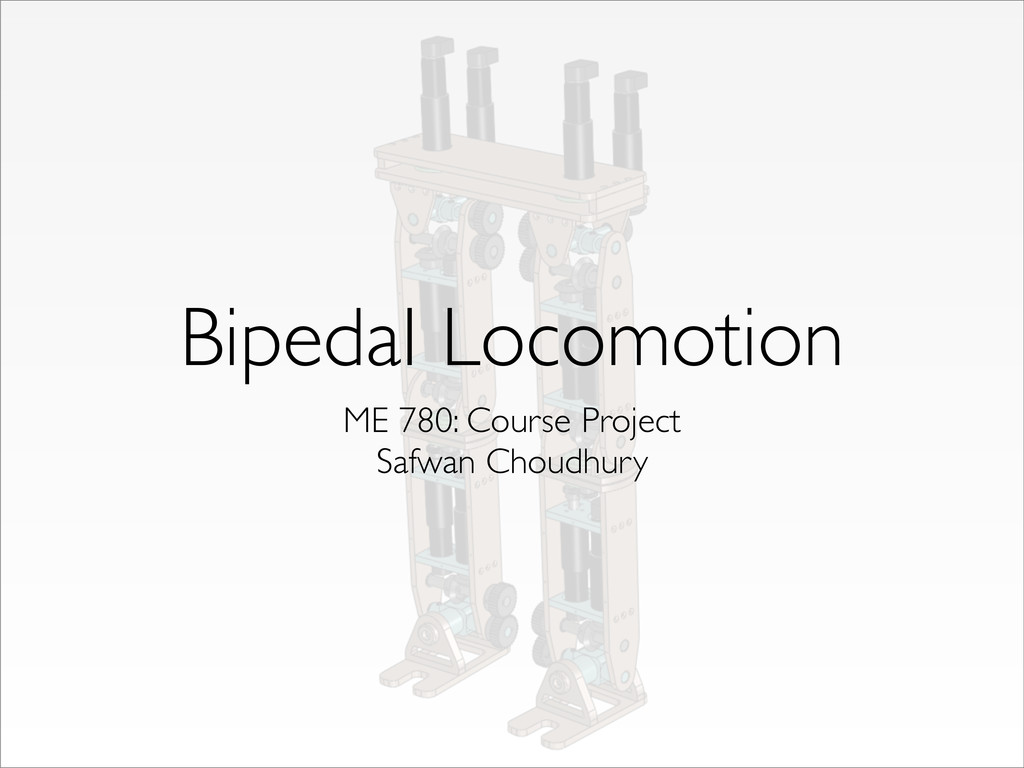
Bipedal Locomotion ME 780: Course Project Safwan Choudhury
Biped Locomotion ★ Motivations ★ Project Goals ★ Bipedal Locomotion
★ Control Strategy ★ Next Steps
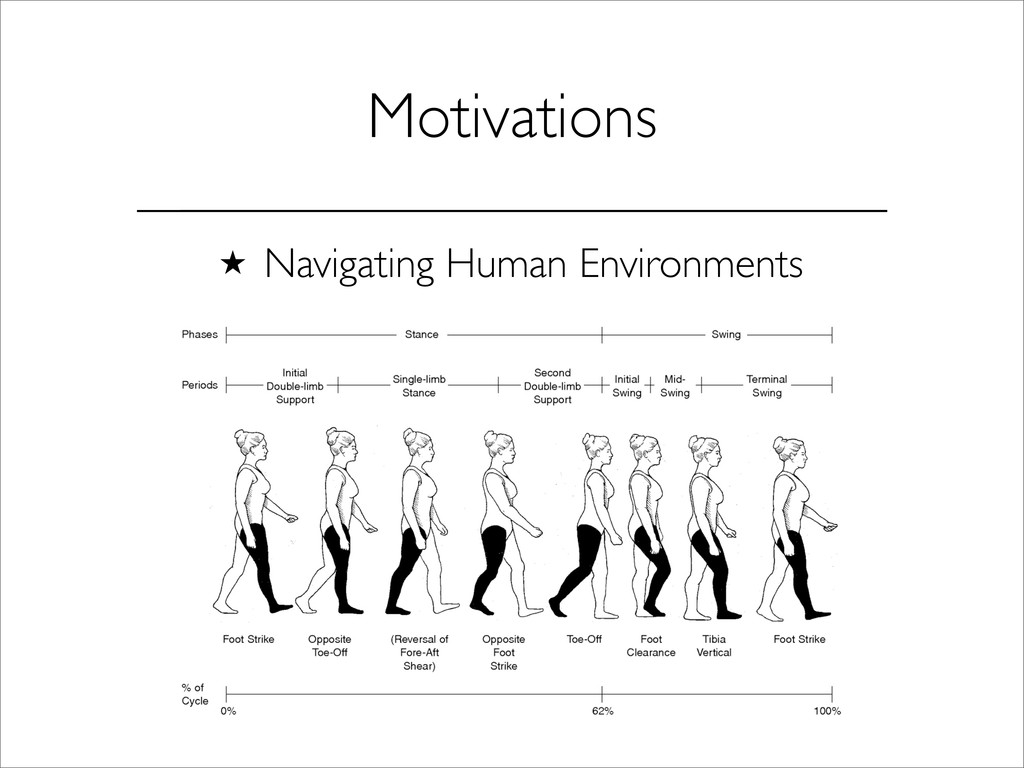
Motivations ★ Navigating Human Environments
ZMP Example 2011 Honda Asimo Video
Passive Dynamics Passive Dynamic Walker Video
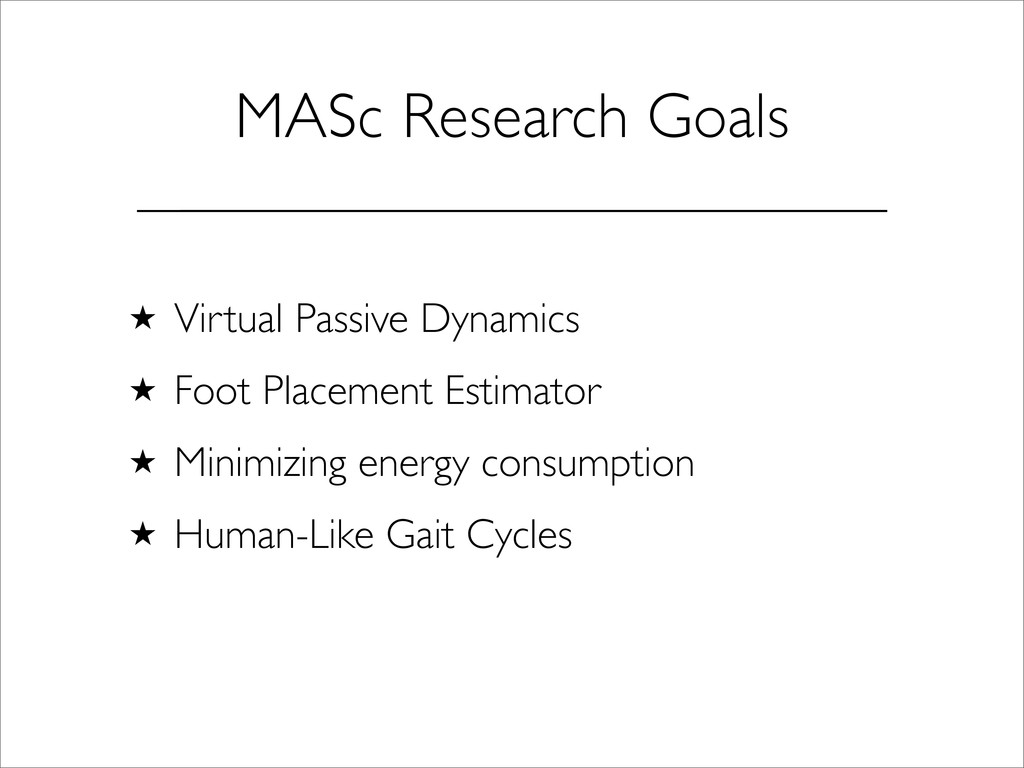
MASc Research Goals ★ Virtual Passive Dynamics ★ Foot Placement
Estimator ★ Minimizing energy consumption ★ Human-Like Gait Cycles
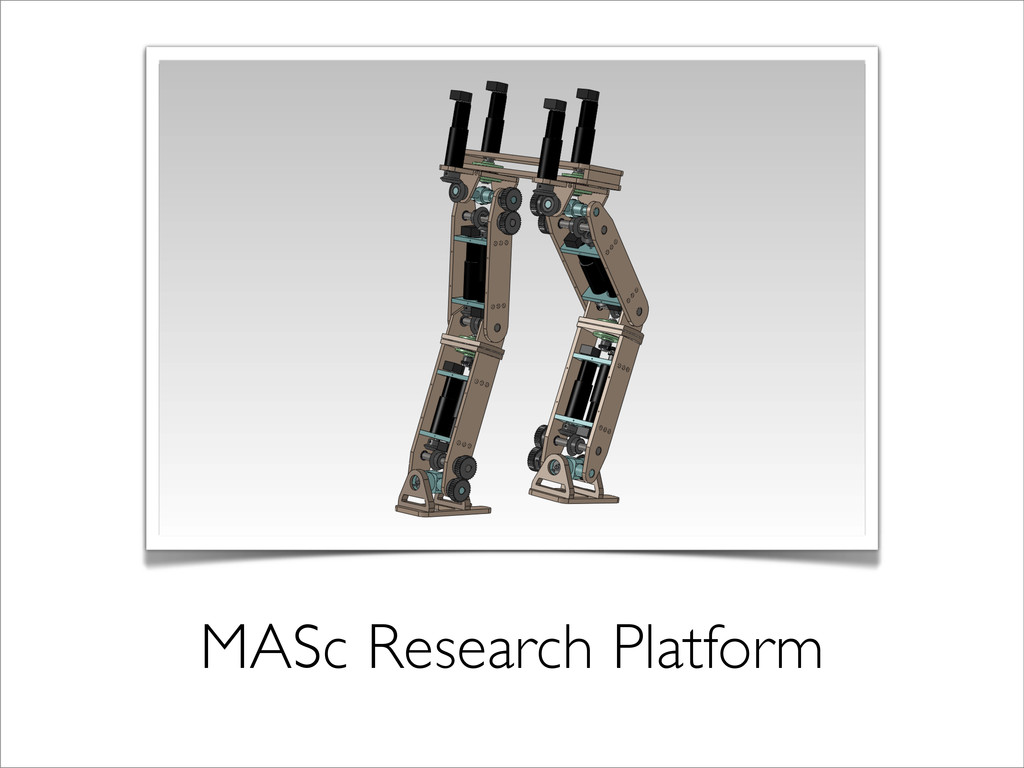
MASc Research Platform
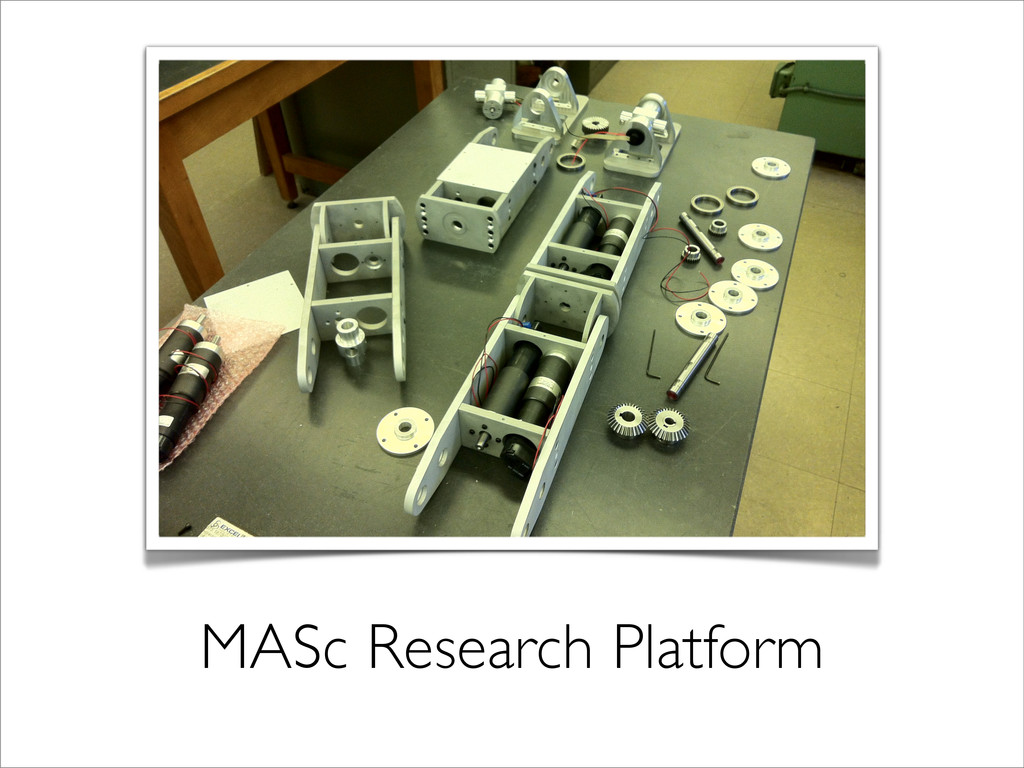
MASc Research Platform
Project Goals ★ ZMP-Based Walking Controller ★ Sensory Inputs: •
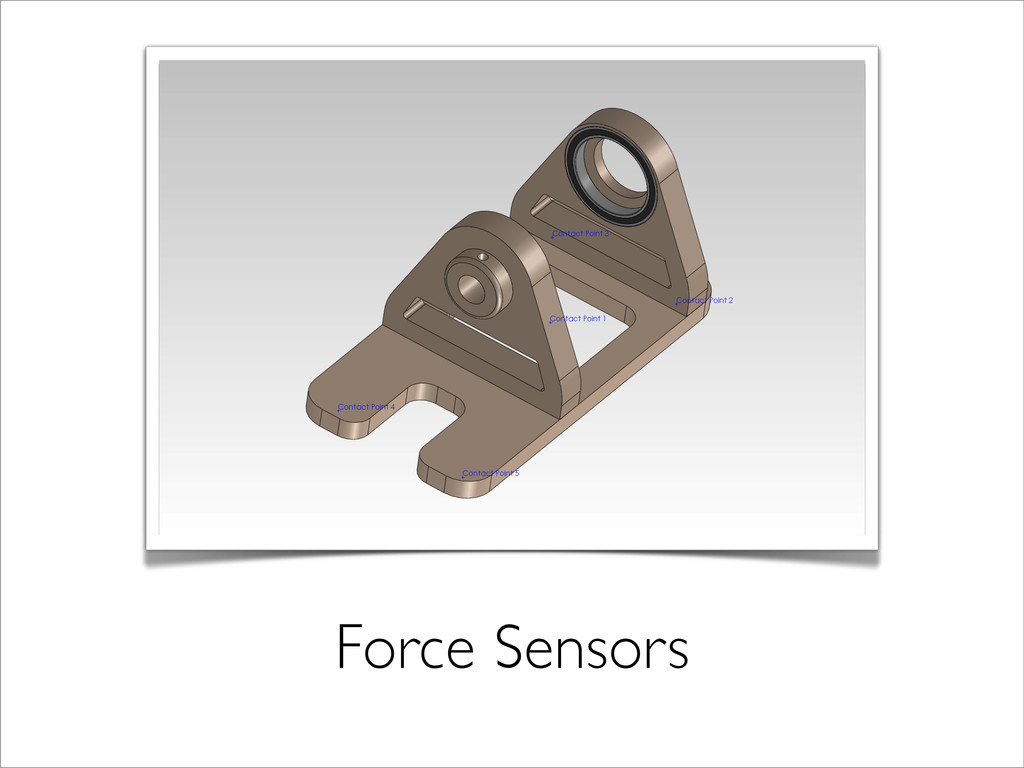
Inertial Measurement Units (IMU) • Force/Contact Sensors
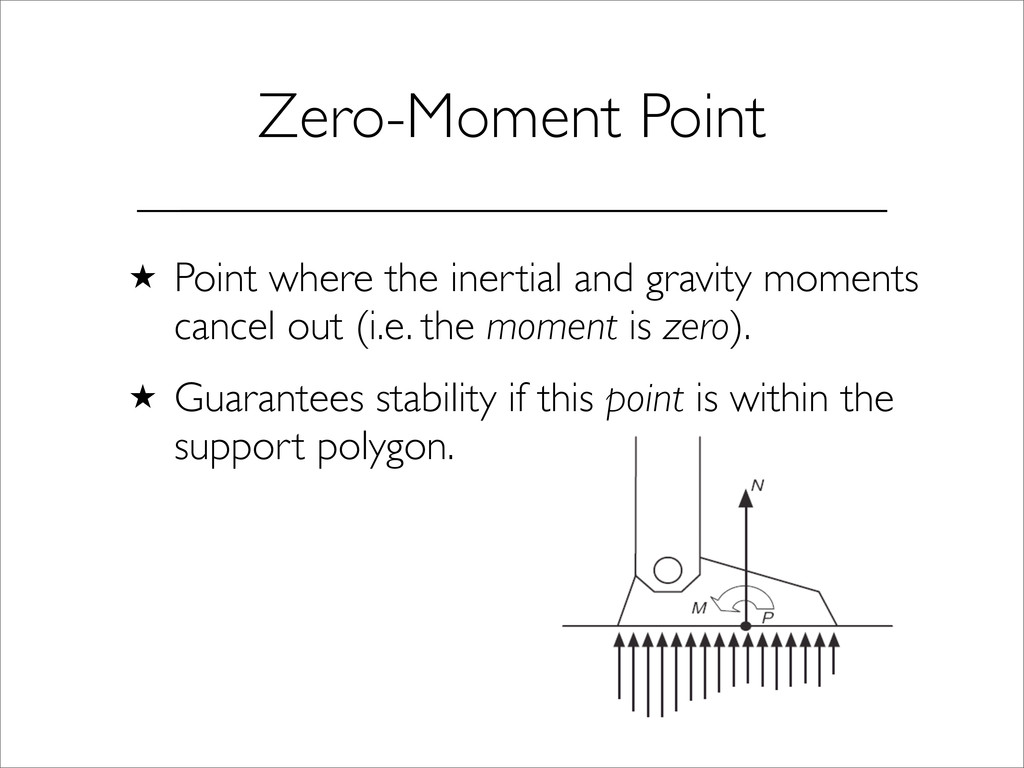
Zero-Moment Point ★ Point where the inertial and gravity moments
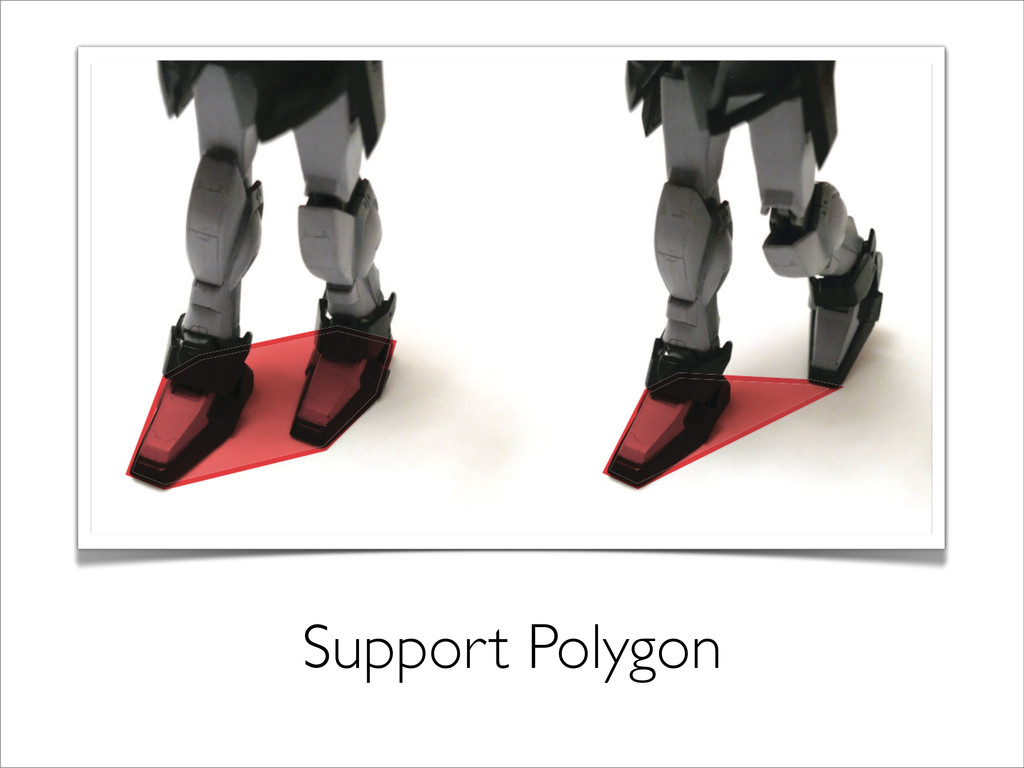
cancel out (i.e. the moment is zero). ★ Guarantees stability if this point is within the support polygon.
Support Polygon
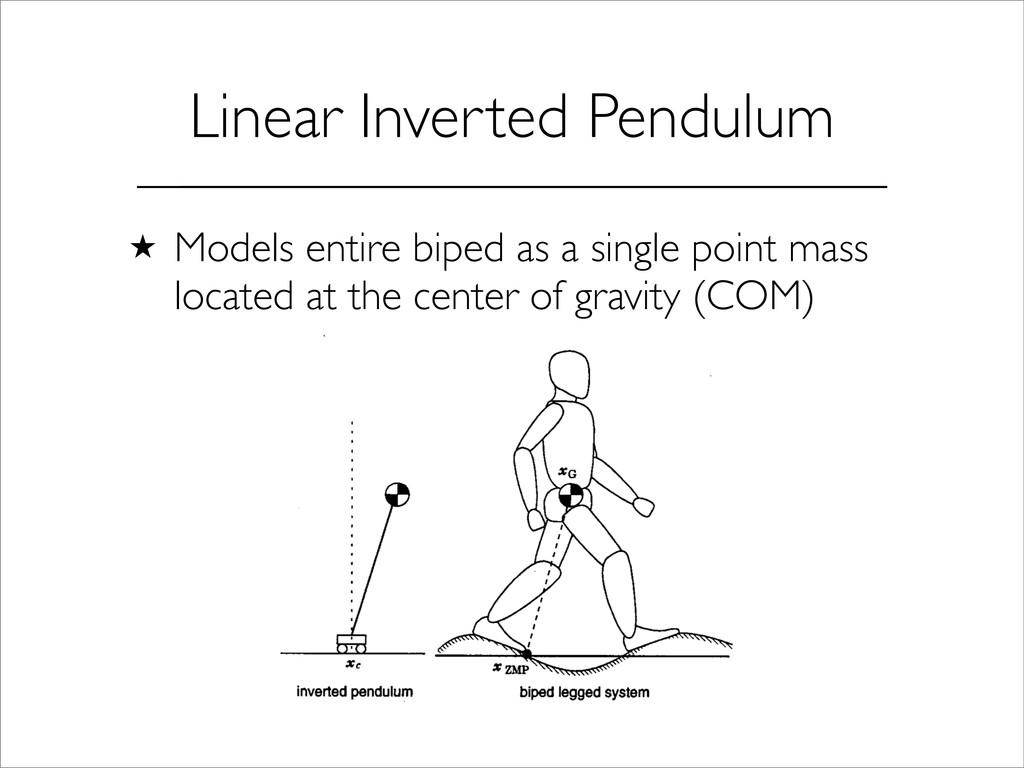
Linear Inverted Pendulum ★ Models entire biped as a single
point mass located at the center of gravity (COM)
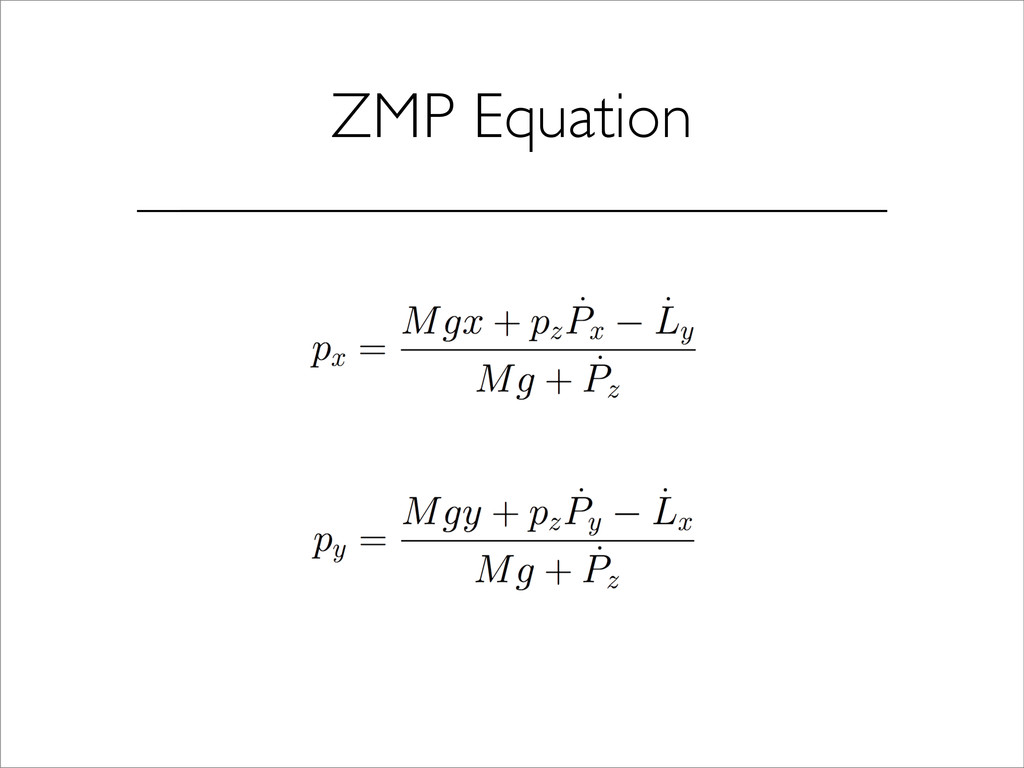
ZMP Equation
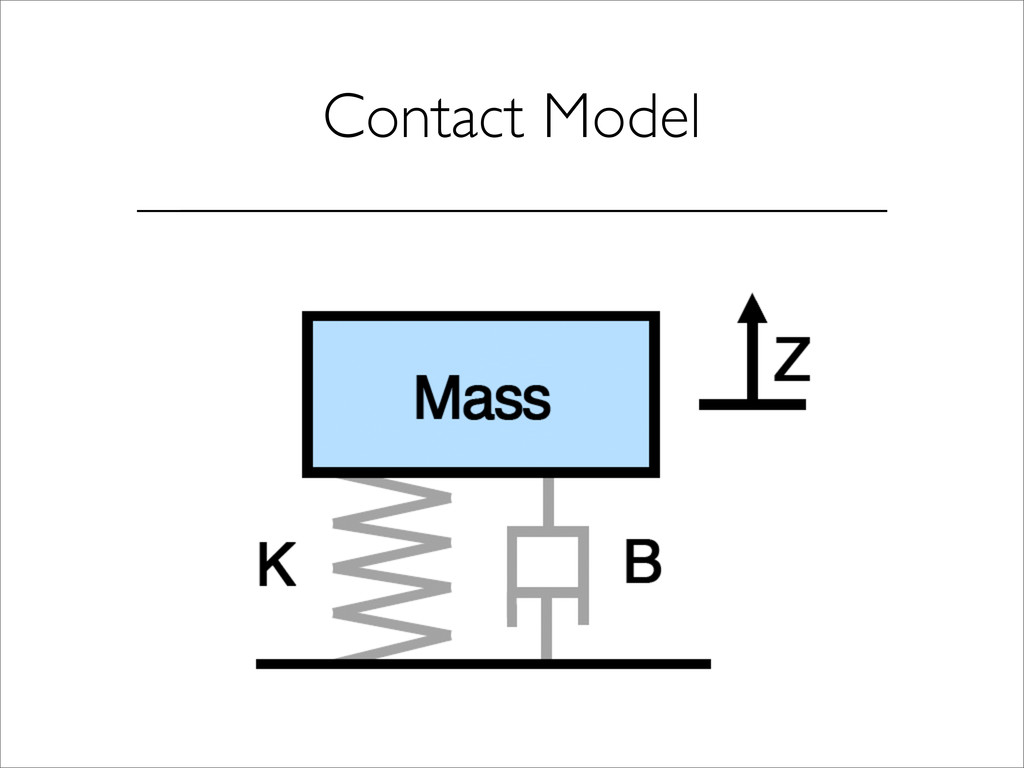
Contact Model
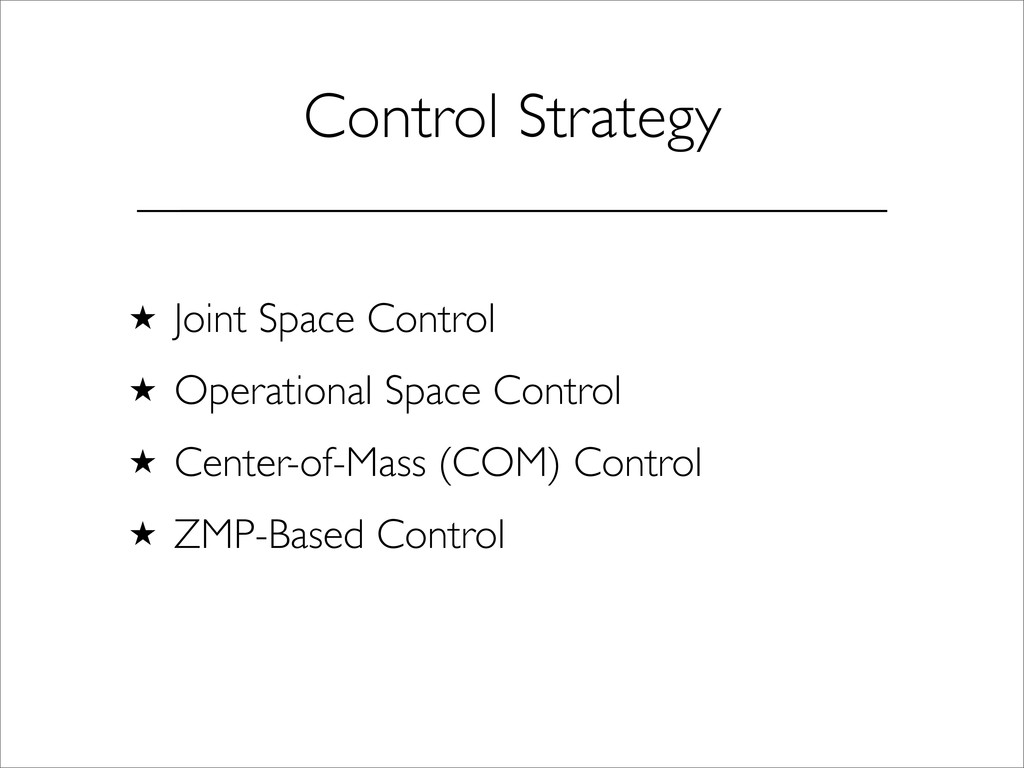
Control Strategy ★ Joint Space Control ★ Operational Space Control
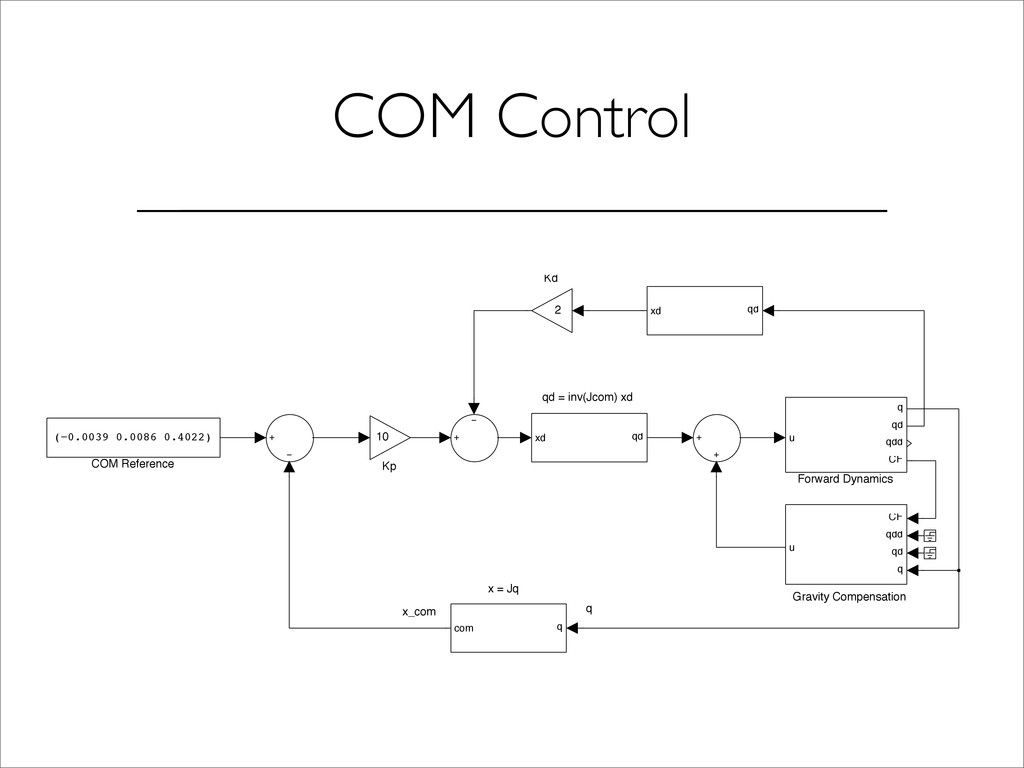
★ Center-of-Mass (COM) Control ★ ZMP-Based Control
qref [−0.8 0.3] Kp 0.1 Kd 0.02 ForwardDynamics u q
qd qdd Error Signal Command Torque Angular Velocites Angular Positions Joint Space Control
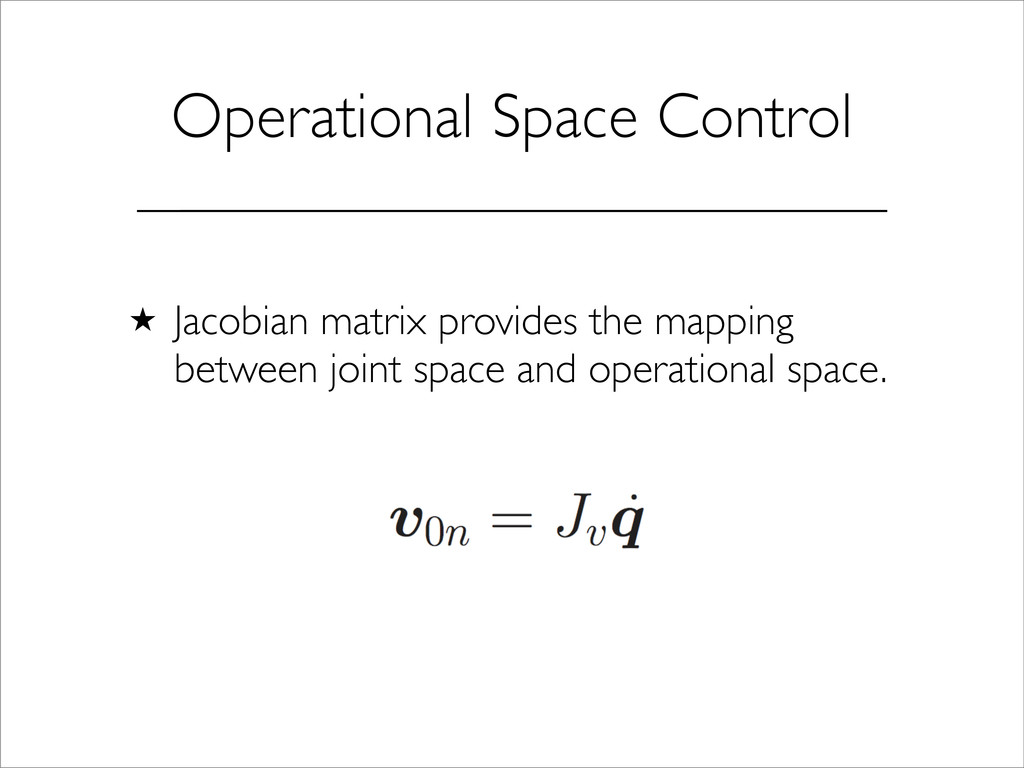
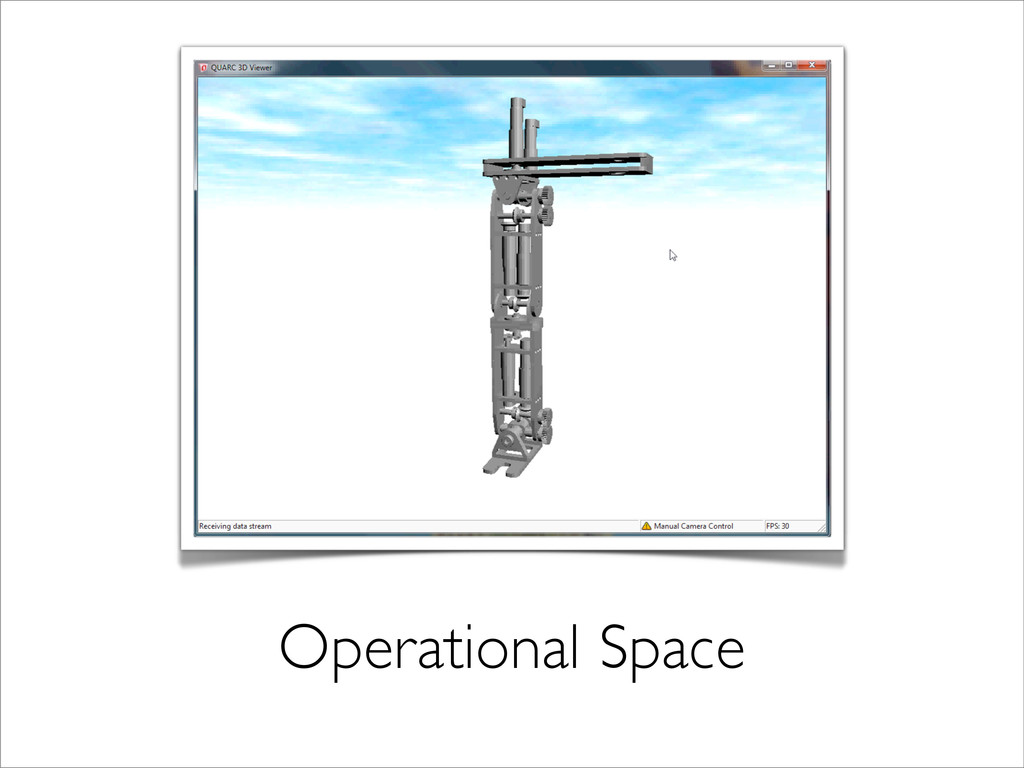
Operational Space Control ★ Jacobian matrix provides the mapping between
joint space and operational space.
Operational Space
Operational Space
Force Sensors
Gravity Compensation q x_com x = Jq qd = inv(Jcom)
xd Kp 10 Kd 2 CF qdd qd q u Forward Dynamics u q qd qdd CF qd xd xd qd q com COM Reference (−0.0039 0.0086 0.4022) COM Control
Gravity Compensation q x_com x = Jq qd = inv(Jcom)
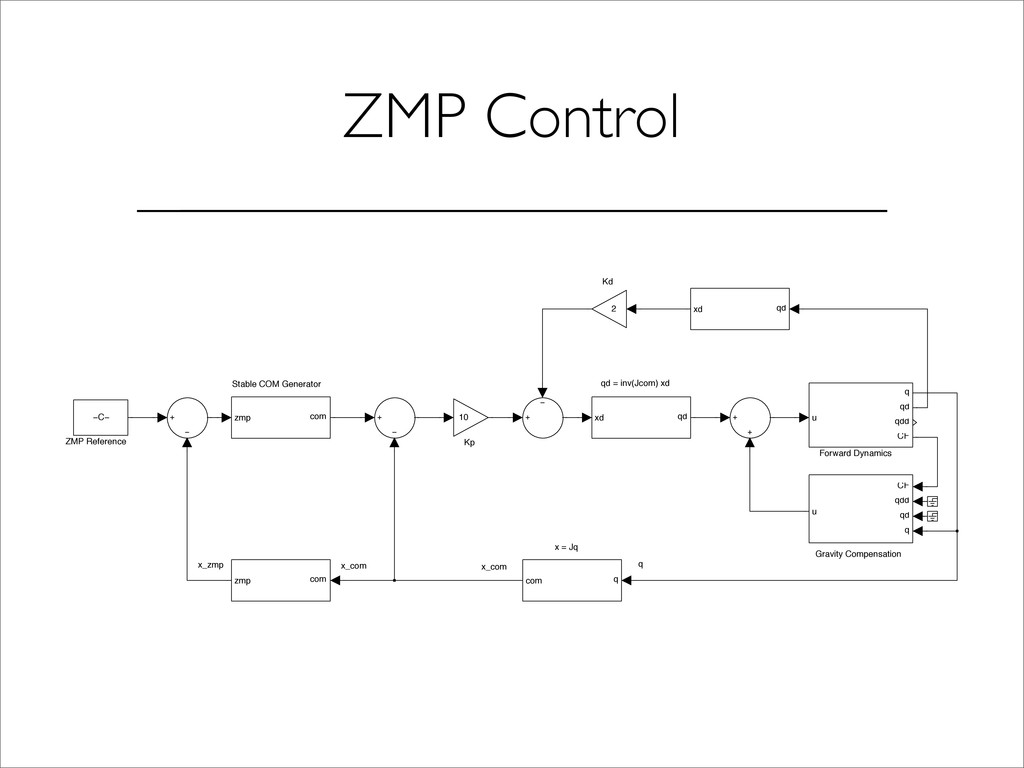
xd x_com x_zmp Stable COM Generator ZMP Reference −C− Kp 10 Kd 2 CF qdd qd q u Forward Dynamics u q qd qdd CF zmp com com zmp qd xd xd qd q com ZMP Control
Walking Simulation
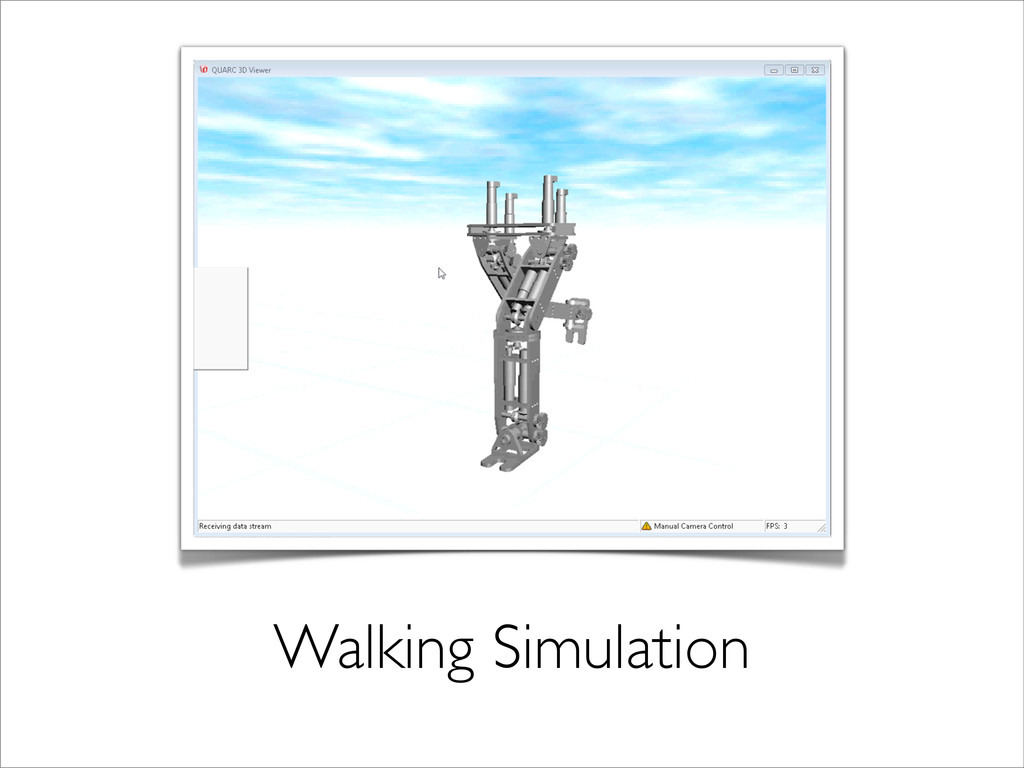
Walking Simulation
Next Steps ★ IMU Modelling + Additive Noise ★ Implementing
EKF-Based Estimation ★ State Machine for Cyclic Gait
Questions?


 safwanc
 nnchiba
 enochan
 yukako_nakano
 takehaya
 afroscript
 institutdelelevage
 signer
 yumaichikawa
 mickey_0226
 rikkabotan7
 takasehideki
 imai448
 speakerdeck
 sarafernandez
 brettharned
 tammyeverts
 ammeep
 shpigford
 carmenintech
 csswizardry
 akademiya2063
 pauljervisheath
 aleyda
 dougneiner