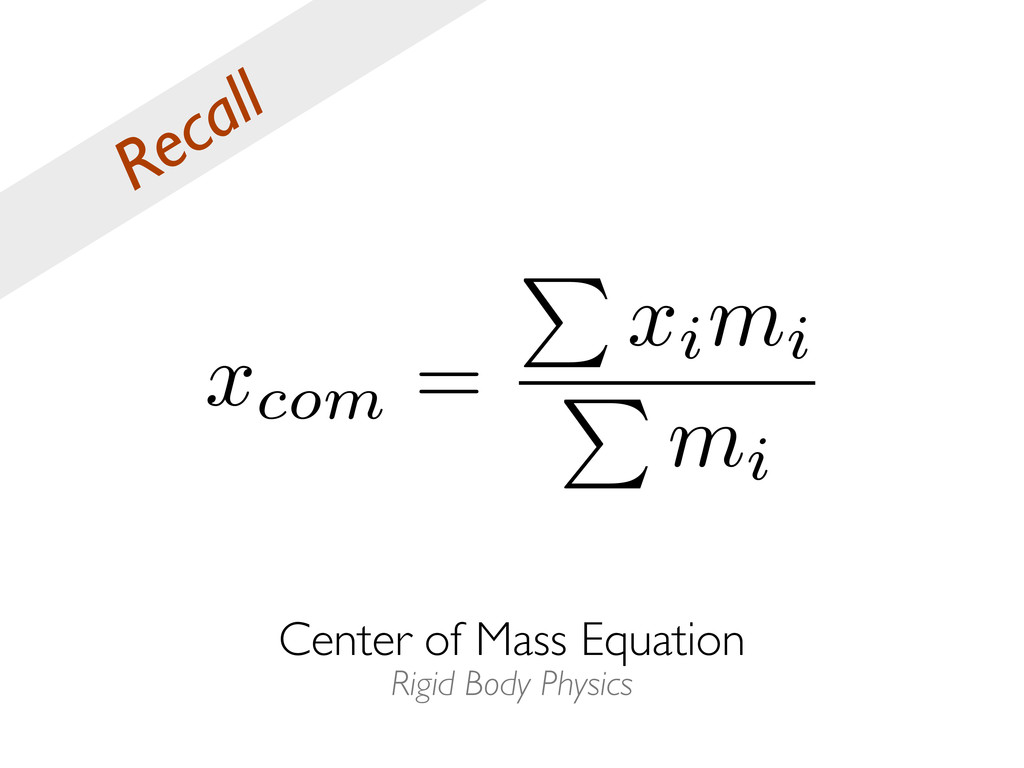Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
ECE 486 Lecture
Search
Safwan Choudhury
June 06, 2012
Education
360
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
ECE 486 Lecture
Safwan Choudhury
June 06, 2012
More Decks by Safwan Choudhury
See All by Safwan Choudhury
Design and Gait Synthesis for a 3D Lower Body Humanoid
safwanc
1
96
Controlling Wheelchair Motion with Electroencephalography
safwanc
3
210
Accurate Determination of Joint Angles from Inertial Measurement Unit Data
safwanc
0
210
Gait Controller for 3D Active Dynamic Walking
safwanc
0
180
Bipedal Locomotion
safwanc
2
81
Learning Thought-Based Motor Control using Gaussian Processes
safwanc
0
150
Analysis of the Foot Placement Estimator
safwanc
0
240
Electromechanical Design
safwanc
0
180
Other Decks in Education
See All in Education
Web Application Frameworks - Lecture 3 - Web Technologies (1019888BNR)
signer
PRO
0
3.6k
Introduction to M&A
bvr7352
0
240
Padlet opetuksessa
matleenalaakso
12
16k
新型コロナ禍をともに「楽しみながら開いていこう!」 :中門 吉松 会員(2720 Japan O.K.ロータリーEクラブ)卓話 : 2026.10.19.例会・卓話
2720japanoke
0
210
2026年度秋学期 統計学 第2回 統計資料の収集と読み方 (2026. 10. 6)
akiraasano
PRO
0
270
HCI and Interaction Design - Lecture 2 - Human-Computer Interaction (1023841ANR)
signer
PRO
0
2k
AIの力を100%引き出すために
frievea
0
610
Web Architectures - Lecture 2 - Web Technologies (1019888BNR)
signer
PRO
0
3.7k
EL GEOPARQUE MUNDIAL UNESCO VOLCANES DE CALATRAVA: DE LA INVESTIGACIÓN CIENTÍFICA A LA TRANSPOSICIÓN DIDÁCTICA EN EL AULA
juanmartin2026
0
32k
General Introduction, Composition, Chemistry & Chemical Classes, Biosources, Therapeutic uses and Commercial Application of Secondary Metabolites.
drpoonamkc
0
170
Invest Early, Build Together
rashwhitman
0
750
LEGO Geometry Tutorial
arnoknobbe
0
720
Featured
See All Featured
30 Presentation Tips
portentint
PRO
1
430
Faster Mobile Websites
deanohume
310
32k
Producing Creativity
orderedlist
PRO
348
41k
The Straight Up "How To Draw Better" Workshop
denniskardys
239
140k
Building Flexible Design Systems
yeseniaperezcruz
330
41k
The Curious Case for Waylosing
cassininazir
1
570
First, design no harm
axbom
PRO
2
1.3k
Leadership Guide Workshop - DevTernity 2021
reverentgeek
1
400
The Spectacular Lies of Maps
axbom
PRO
1
1.1k
Ruling the World: When Life Gets Gamed
codingconduct
0
400
Rebuilding a faster, lazier Slack
samanthasiow
85
9.7k
技術選定の審美眼(2025年版) / Understanding the Spiral of Technologies 2025 edition
twada
PRO
120
120k
Transcript
ECE 486: Robot Dynamics and Control Practical Applications of the
Jacobian Safwan Choudhury May 31, 2012
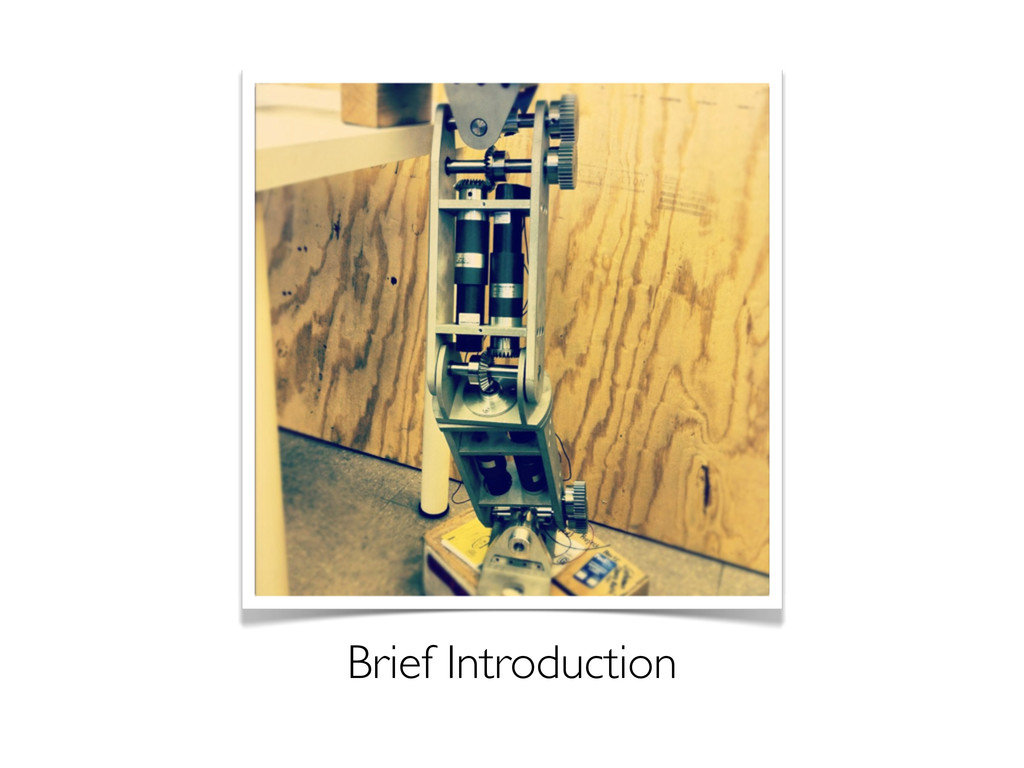
Brief Introduction
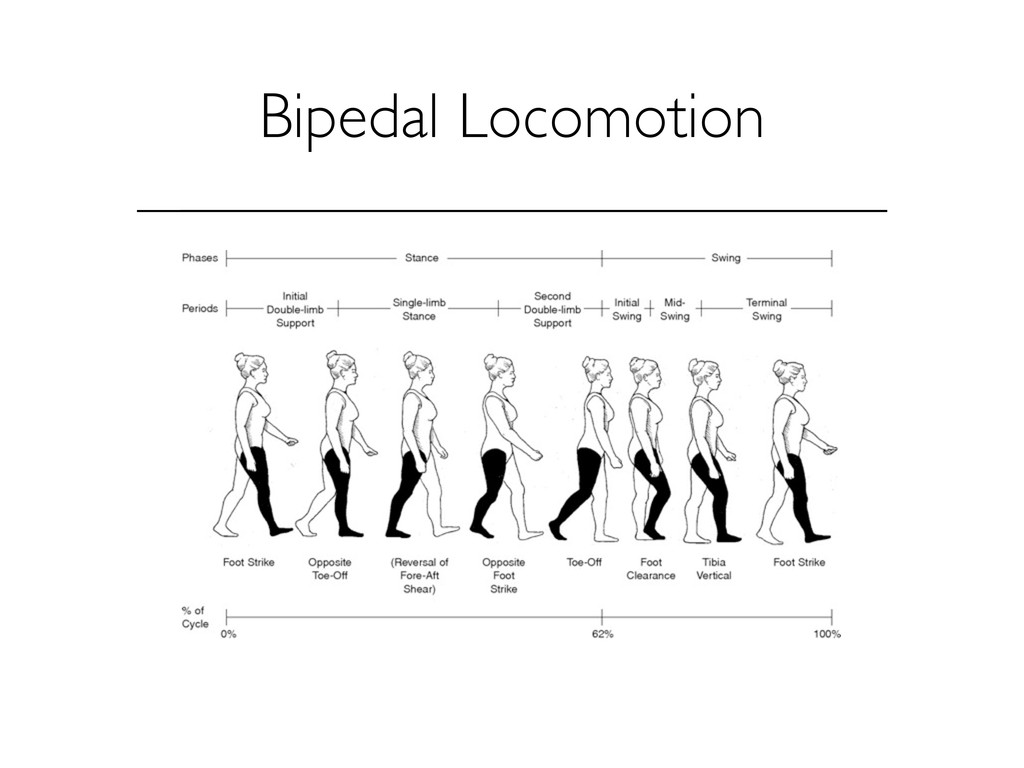
Bipedal Locomotion
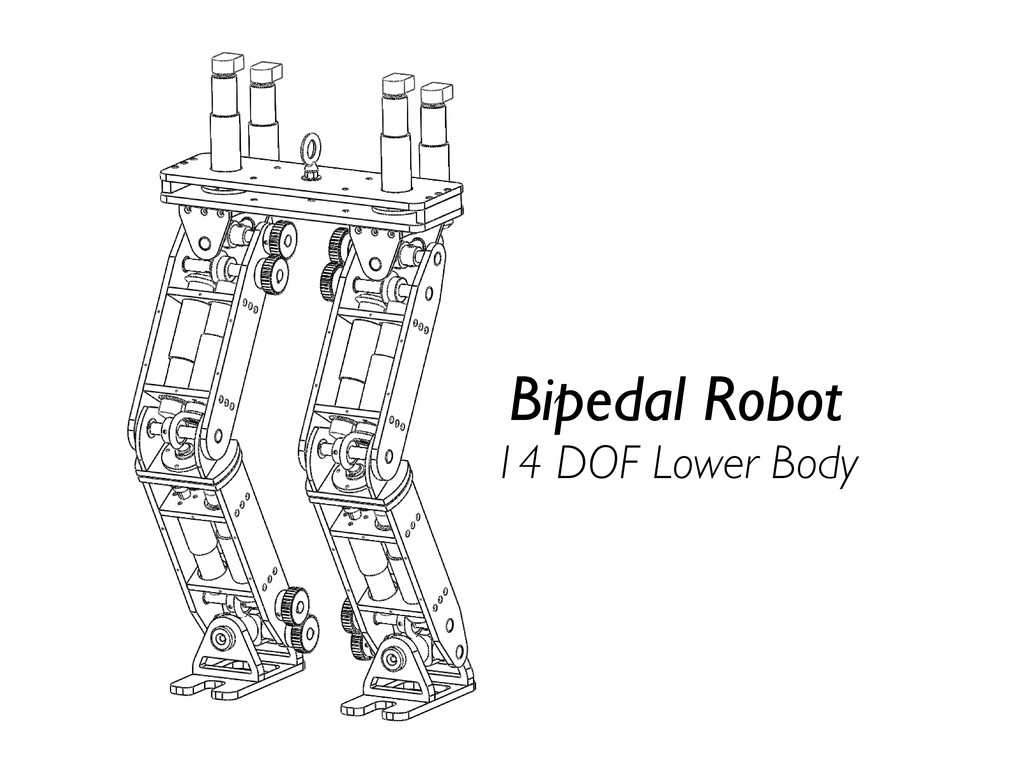
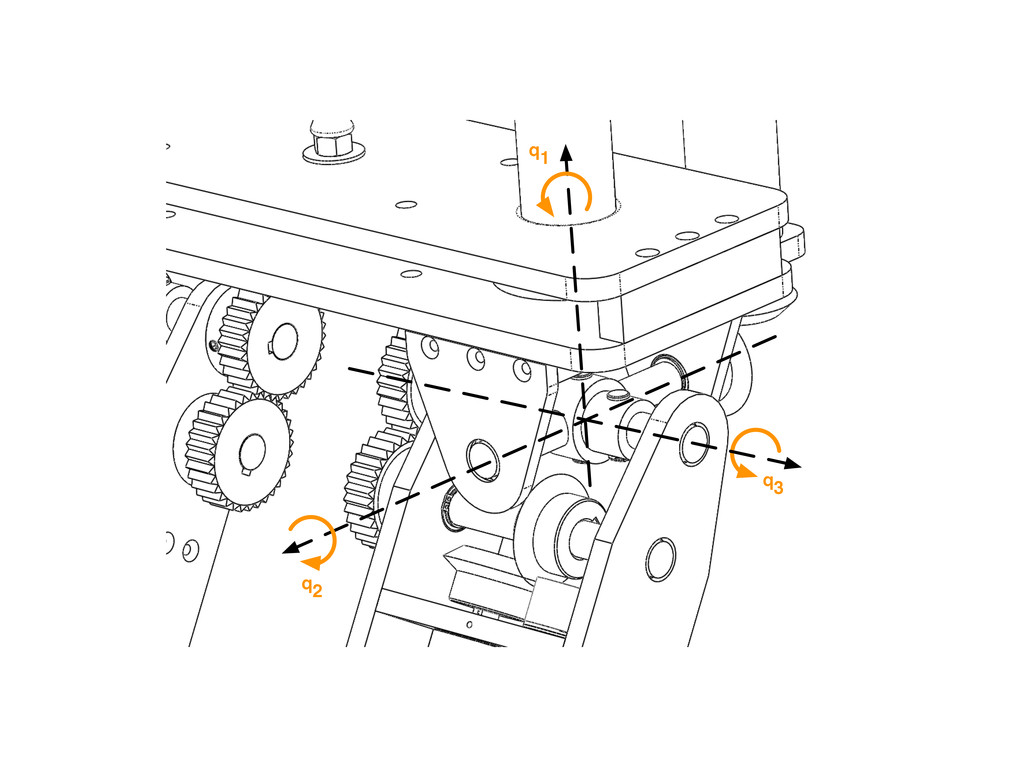
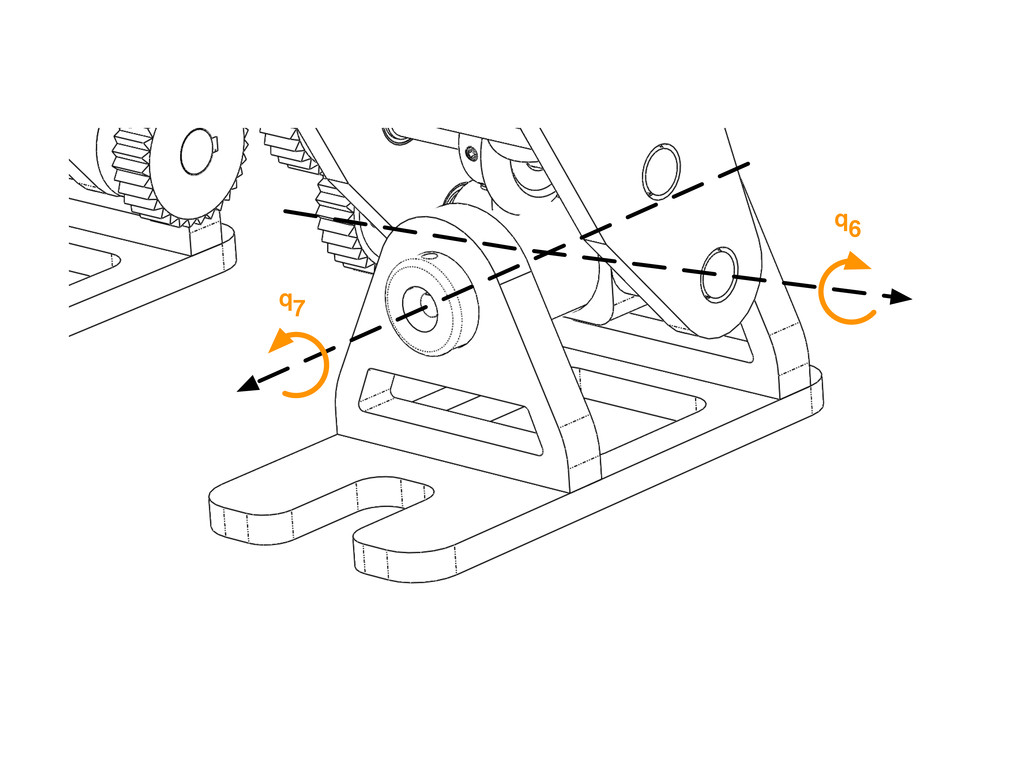
Bipedal Robot 14 DOF Lower Body
q3 q2 q1
q4 q5
q7 q6
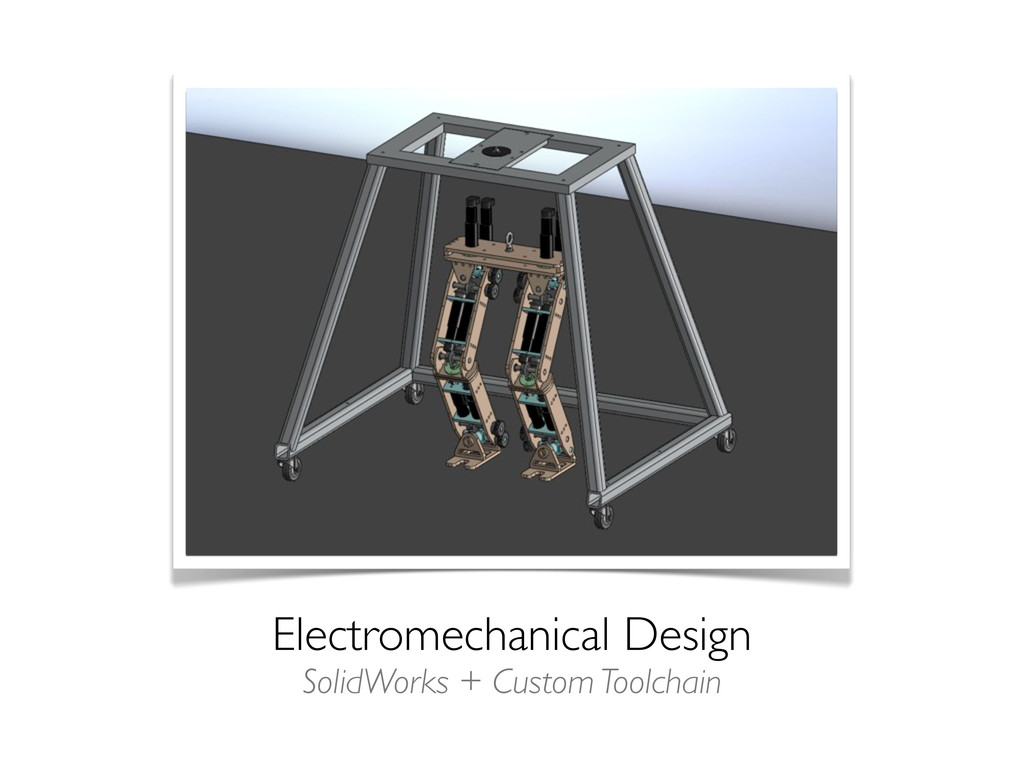
Electromechanical Design SolidWorks + Custom Toolchain
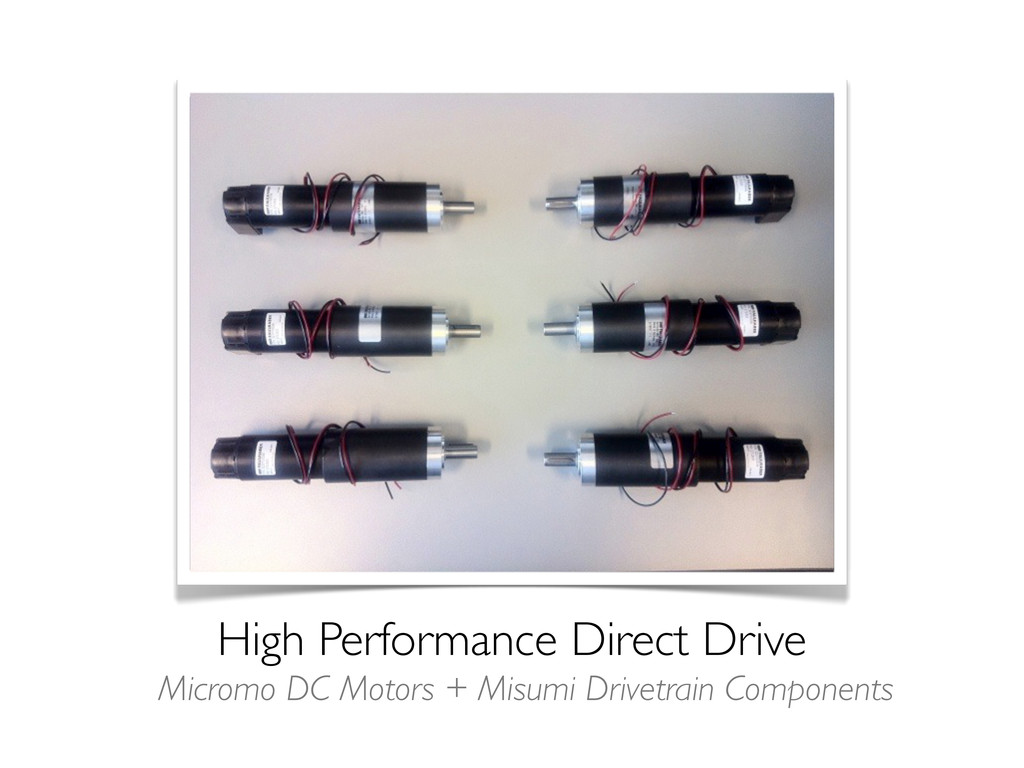
High Performance Direct Drive Micromo DC Motors + Misumi Drivetrain
Components
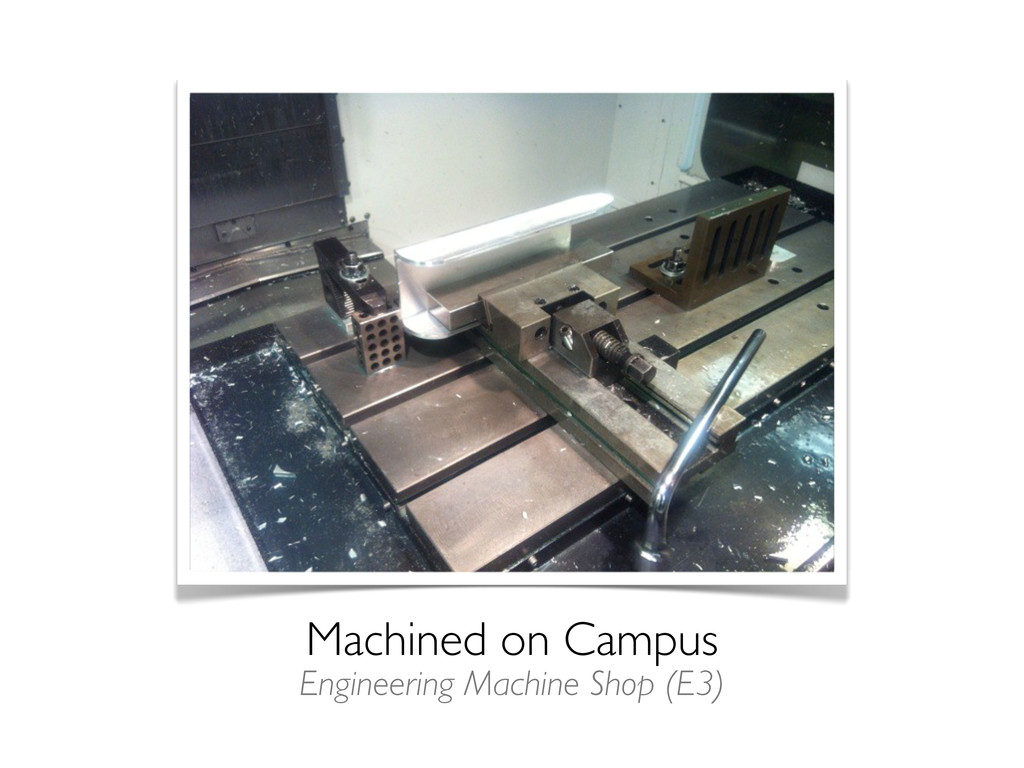
Machined on Campus Engineering Machine Shop (E3)
Full Dynamic Simulations Simulink + SimMechanics + QUARC
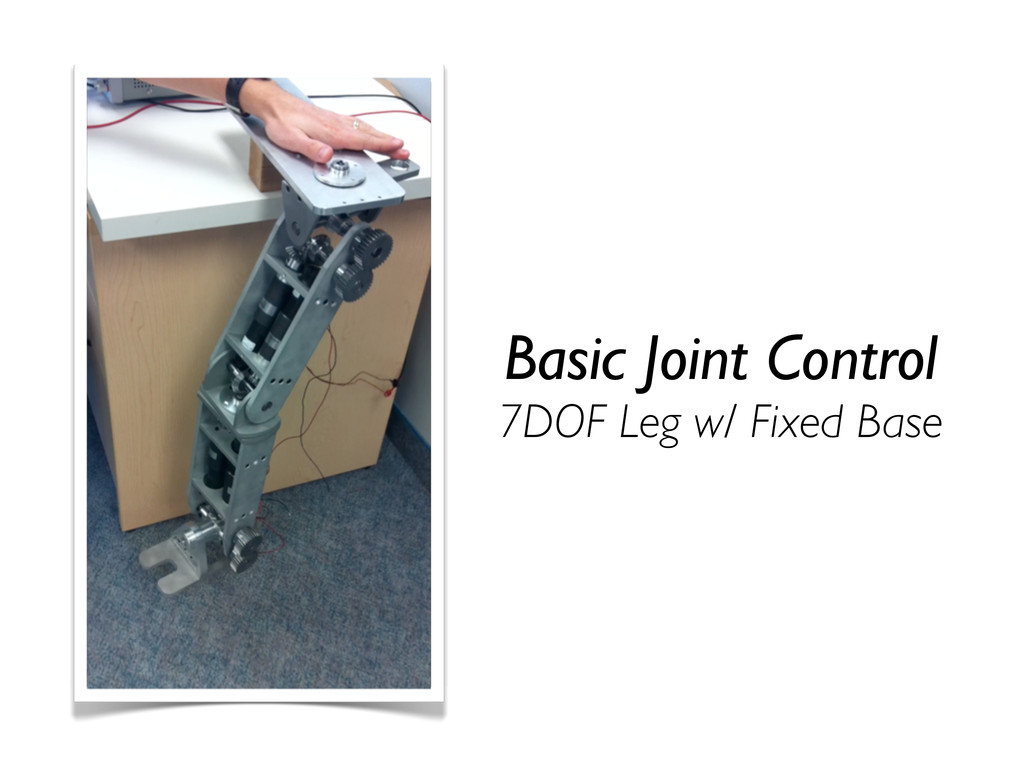
Basic Joint Control 7DOF Leg w/ Fixed Base
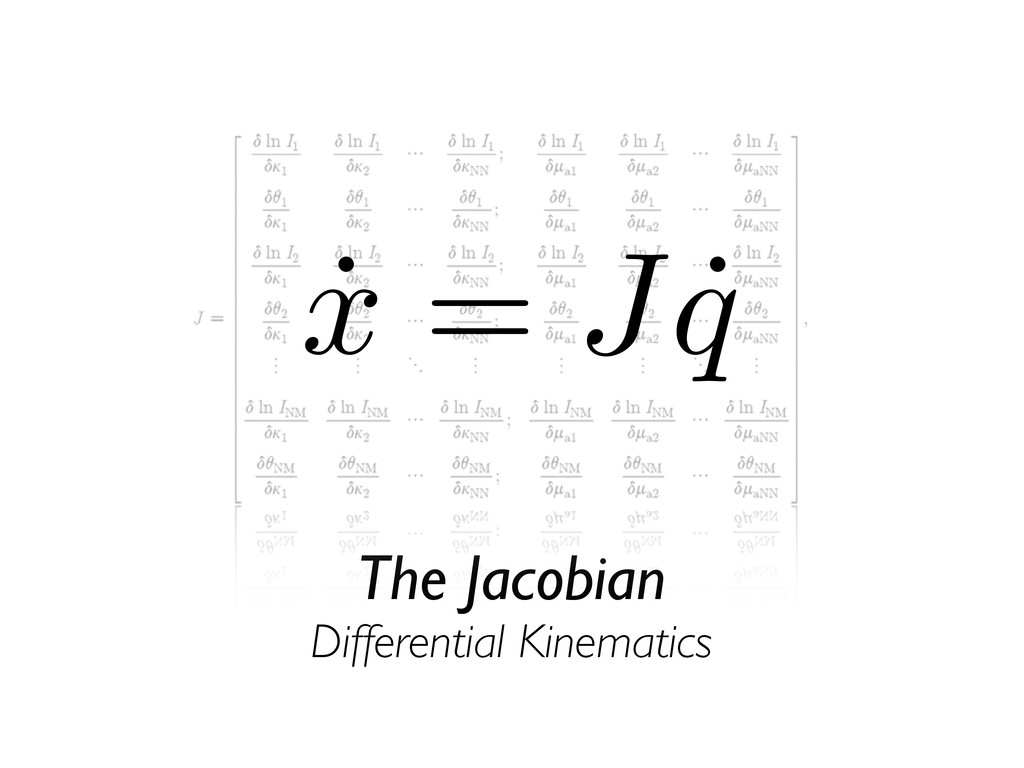
The Jacobian Differential Kinematics ˙ x = J ˙ q
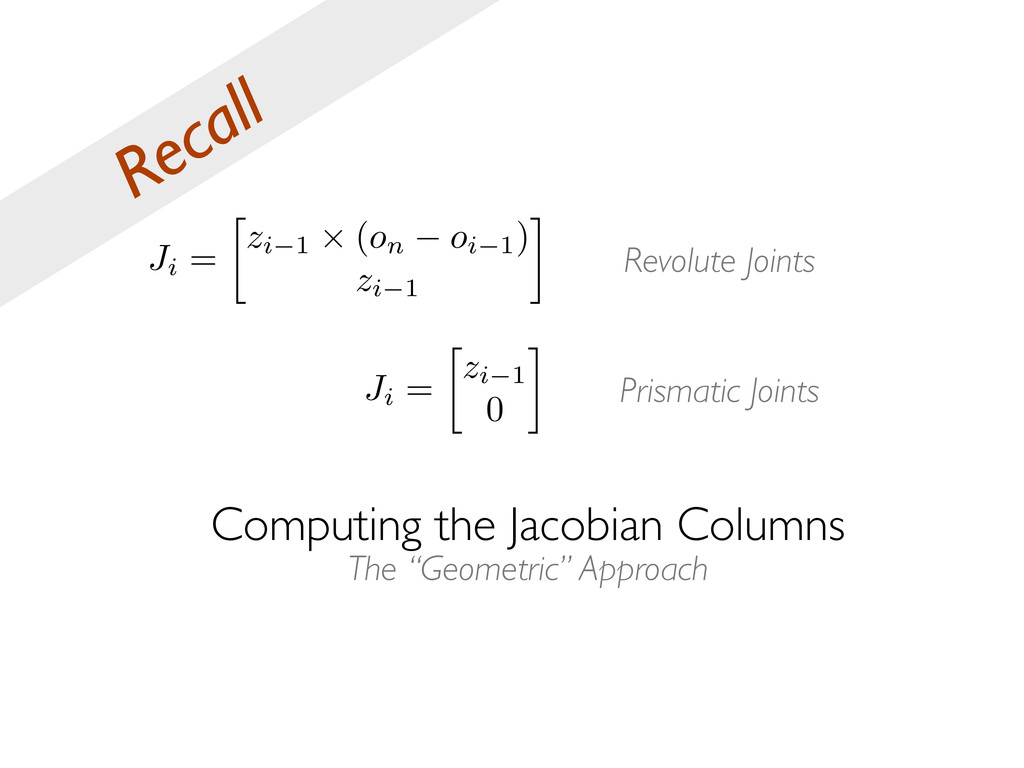
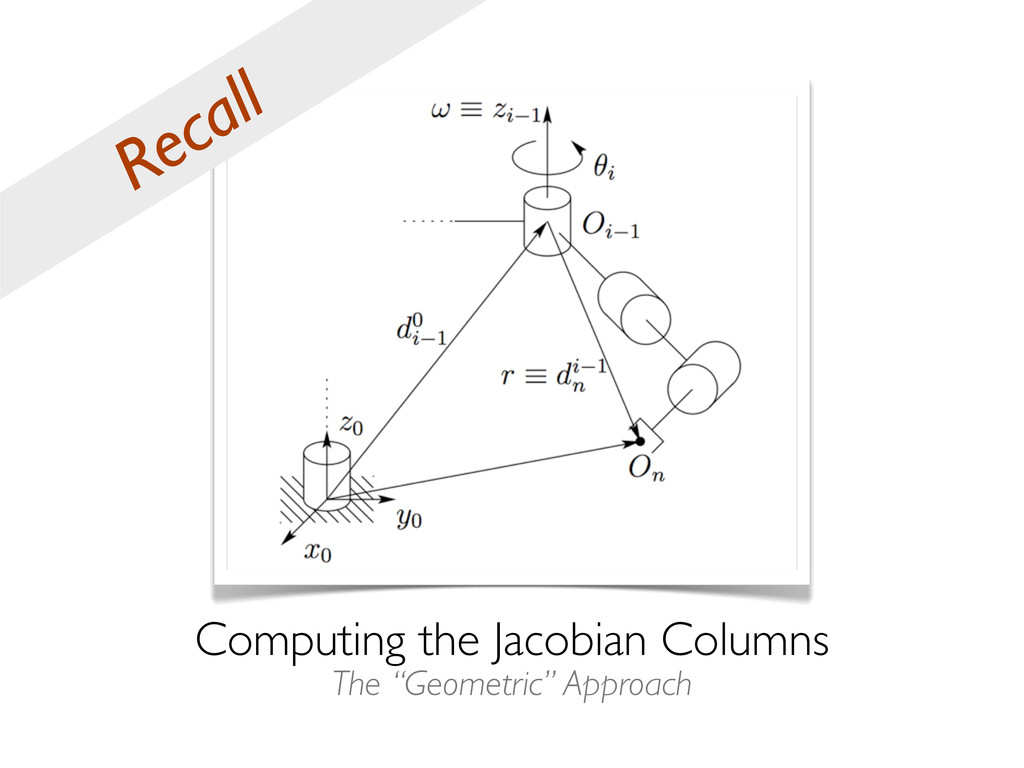
Computing the Jacobian Columns The “Geometric” Approach Recall
Computing the Jacobian Columns The “Geometric” Approach Revolute Joints Ji
= zi 1 ⇥ ( on oi 1) zi 1 Ji = zi 1 0 Prismatic Joints Recall
Why?
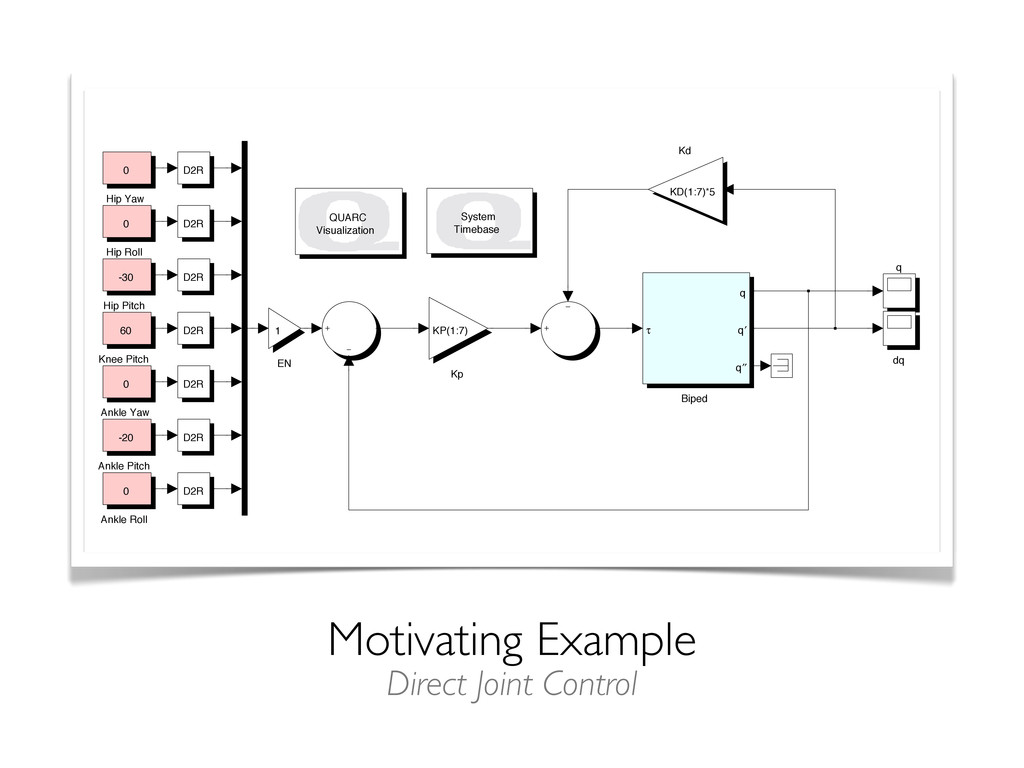
Motivating Example q dq QUARC Visualization System Timebase Kp KP(1:7)
Knee Pitch 60 Kd KD(1:7)*5 Hip Yaw 0 Hip Roll 0 Hip Pitch -30 EN 1 D2R D2R D2R D2R D2R D2R D2R Biped τ q q′ q′′ Ankle Yaw 0 Ankle Roll 0 Ankle Pitch -20 Direct Joint Control
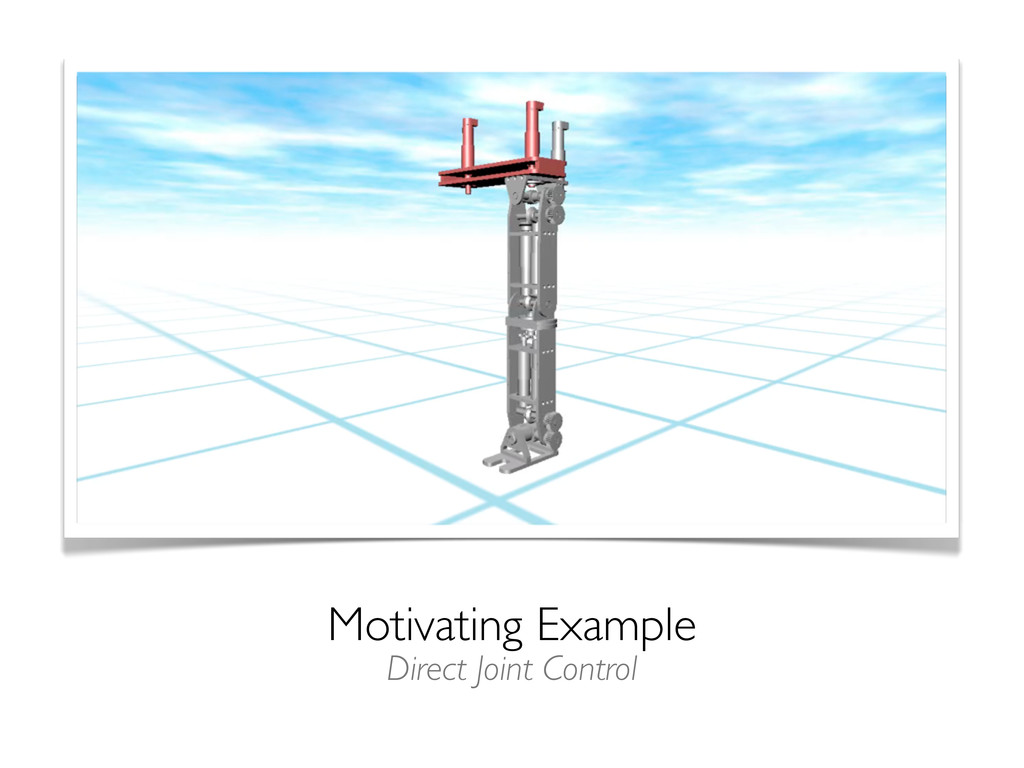
Motivating Example Direct Joint Control
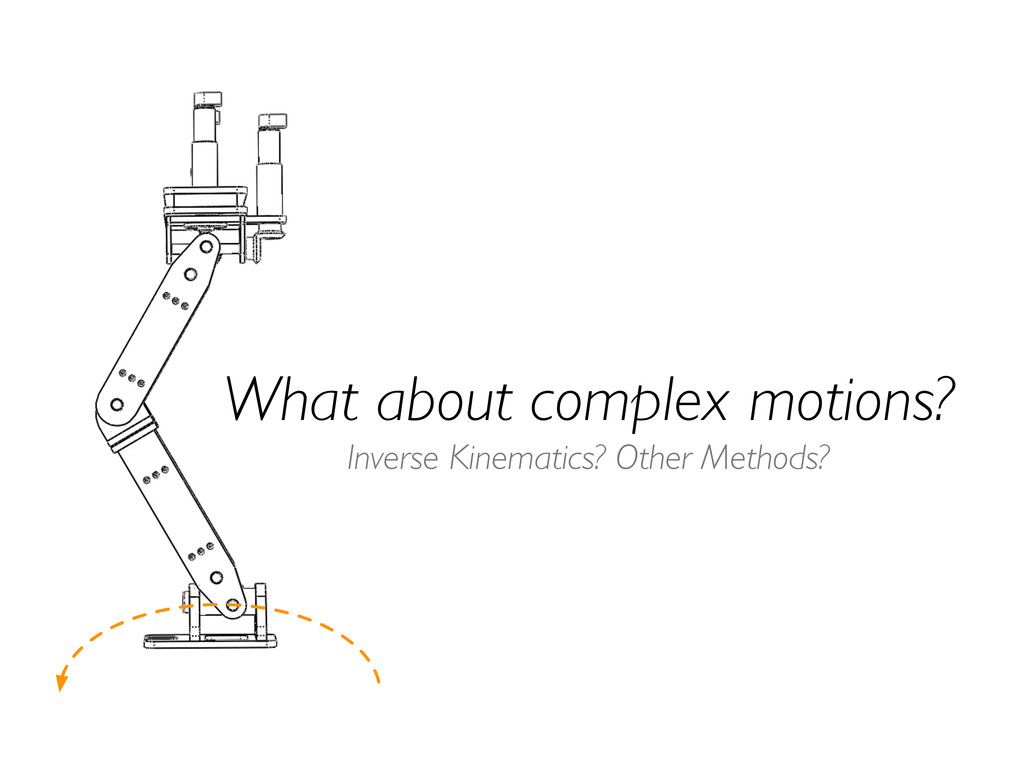
What about complex motions? Inverse Kinematics? Other Methods?
Jacobian Inverse Control Differential Kinematics ˙ q = J 1
˙ x
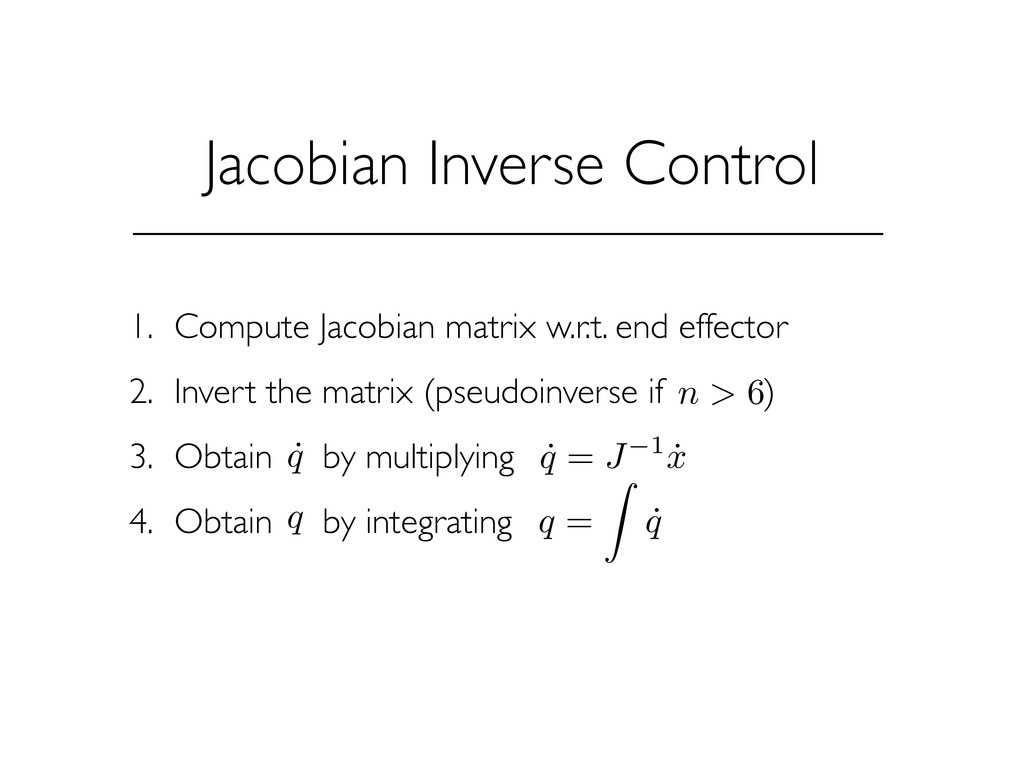
Jacobian Inverse Control 1. Compute Jacobian matrix w.r.t. end effector
2. Invert the matrix (pseudoinverse if ) 3. Obtain by multiplying 4. Obtain by integrating ˙ q q = Z ˙ q q ˙ q = J 1 ˙ x n > 6
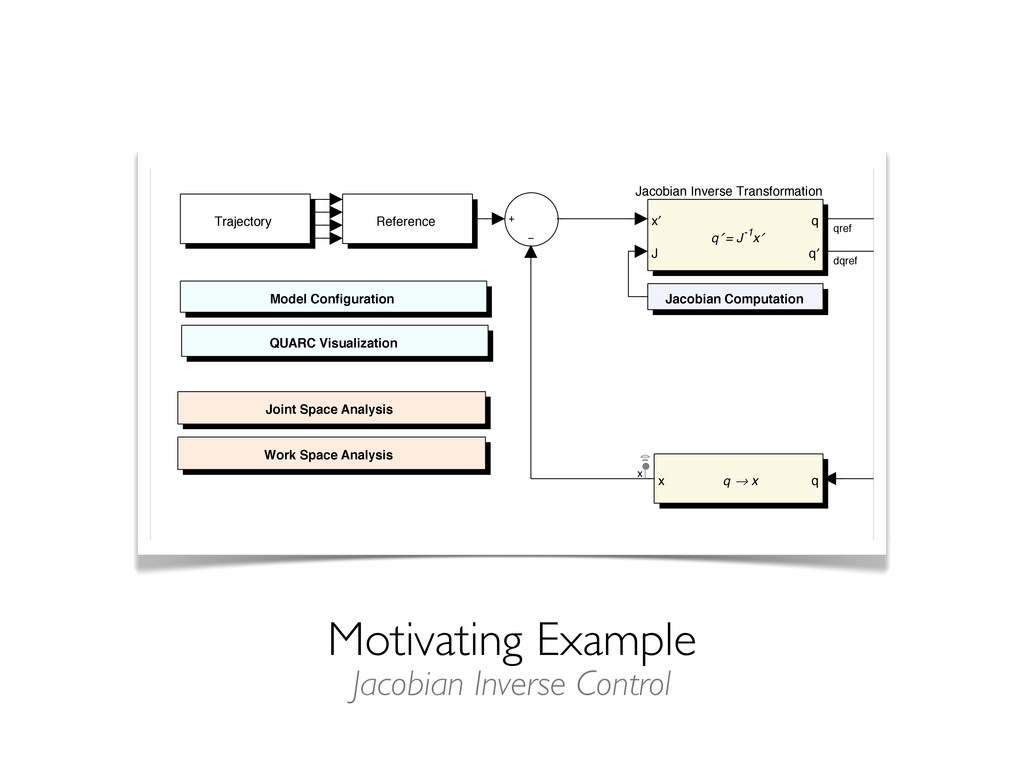
Motivating Example Work Space Analysis QUARC Visualization Trajectory Reference Model
Configuration Joint Space Analysis Jacobian Inverse Transformation q′ = J-1x′ J x′ q q′ Jacobian Computation DQREF QREF q → x q x x dqref qref Jacobian Inverse Control
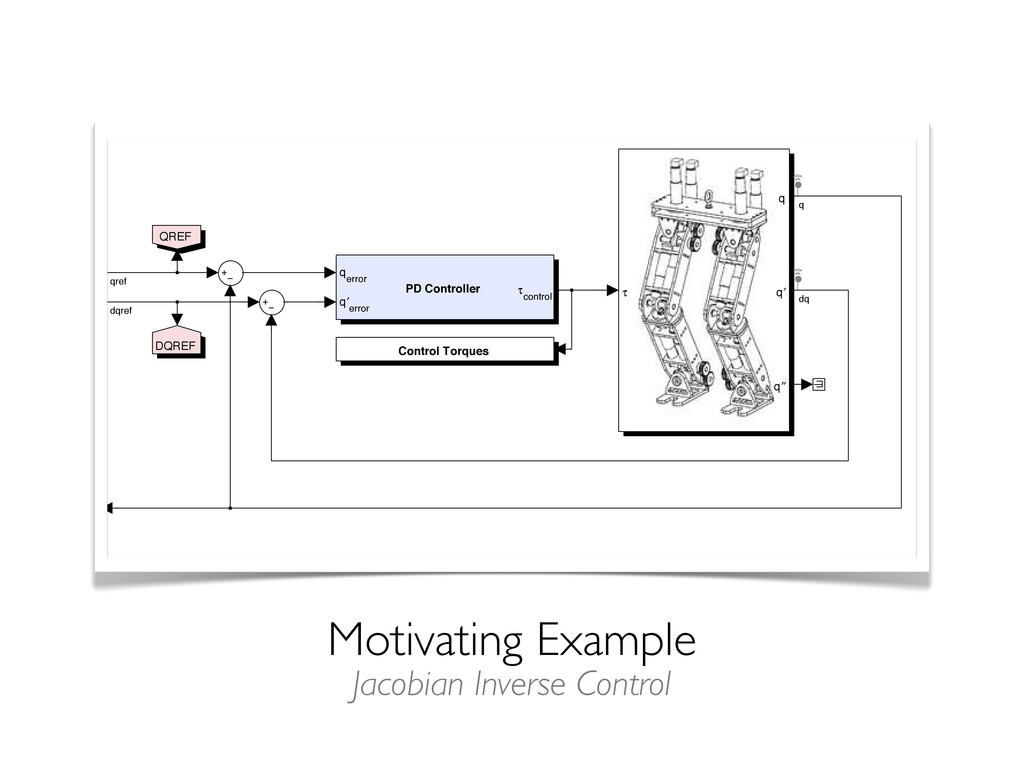
Motivating Example τ q q′ q′′ PD Controller q error
q′ error τ control erse Transformation q′ = J-1x′ q q′ an Computation Control Torques DQREF QREF q → x q q dq dqref qref Jacobian Inverse Control
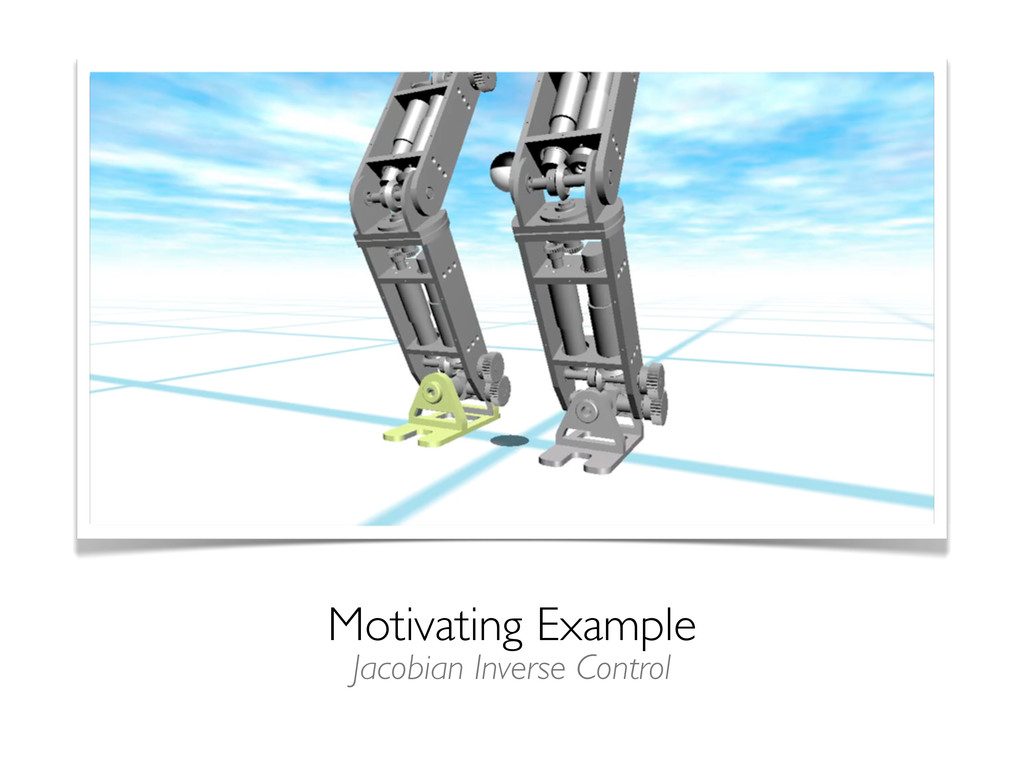
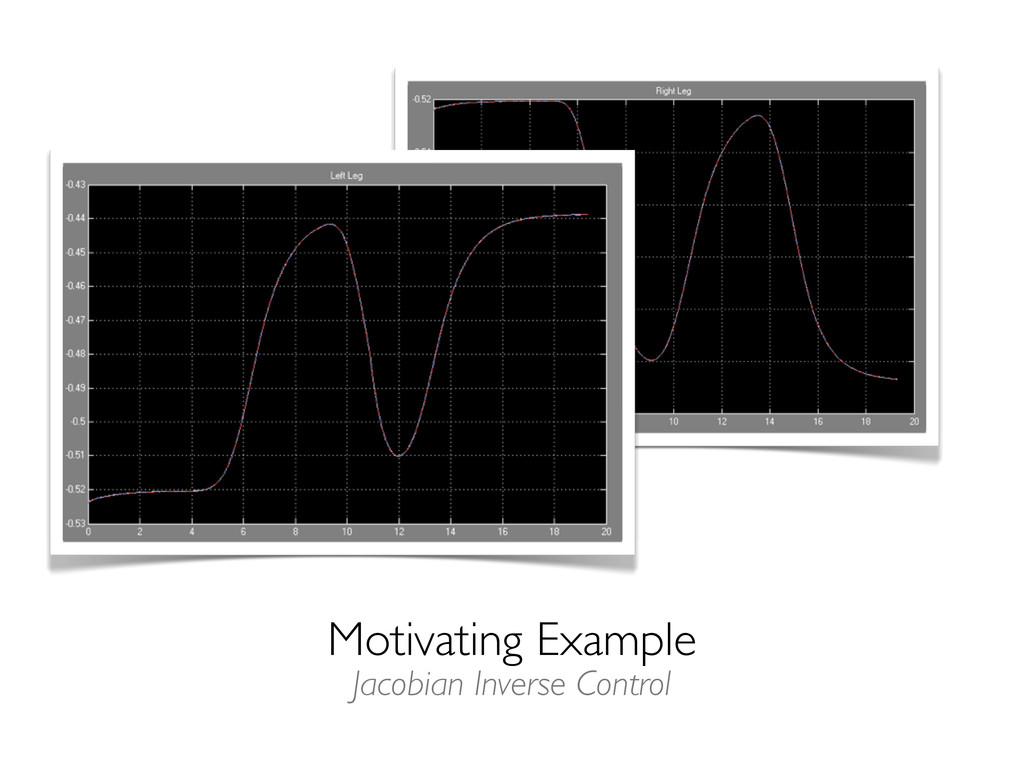
Motivating Example Jacobian Inverse Control
Motivating Example Jacobian Inverse Control
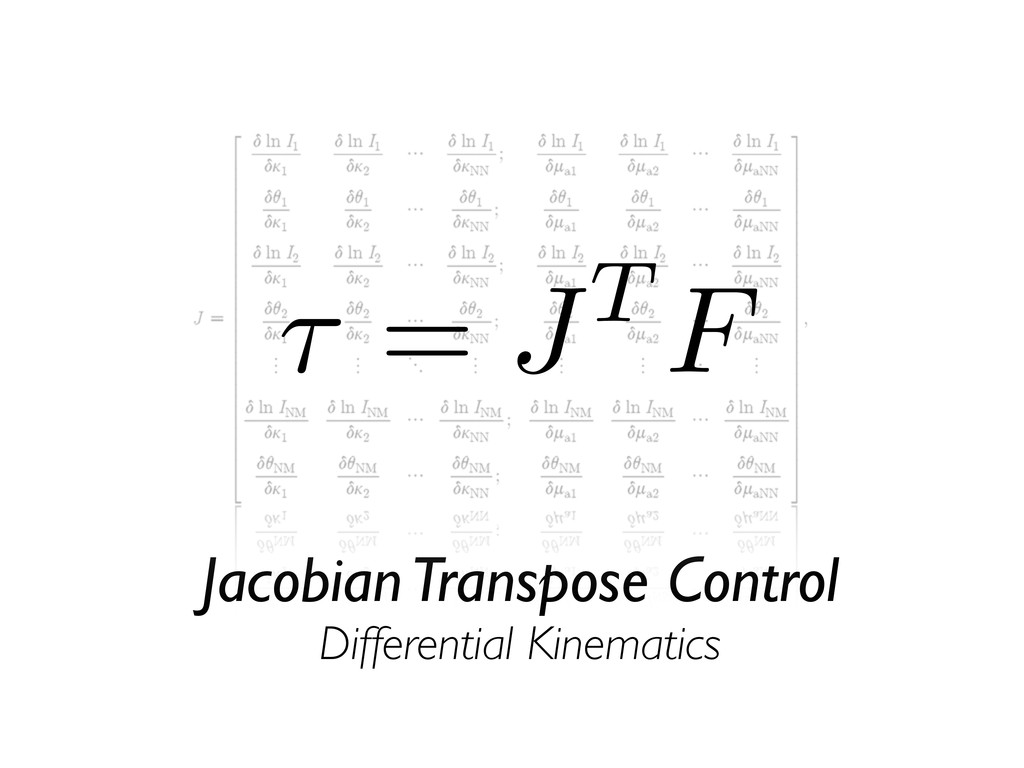
Jacobian Transpose Control Differential Kinematics ⌧ = JT F
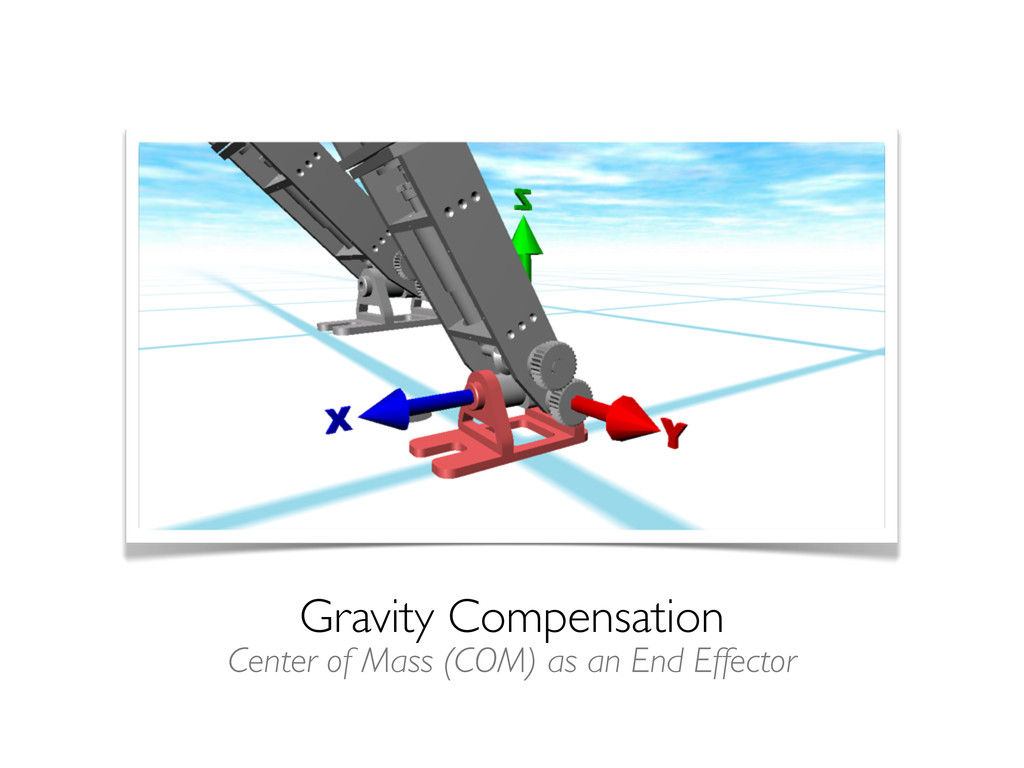
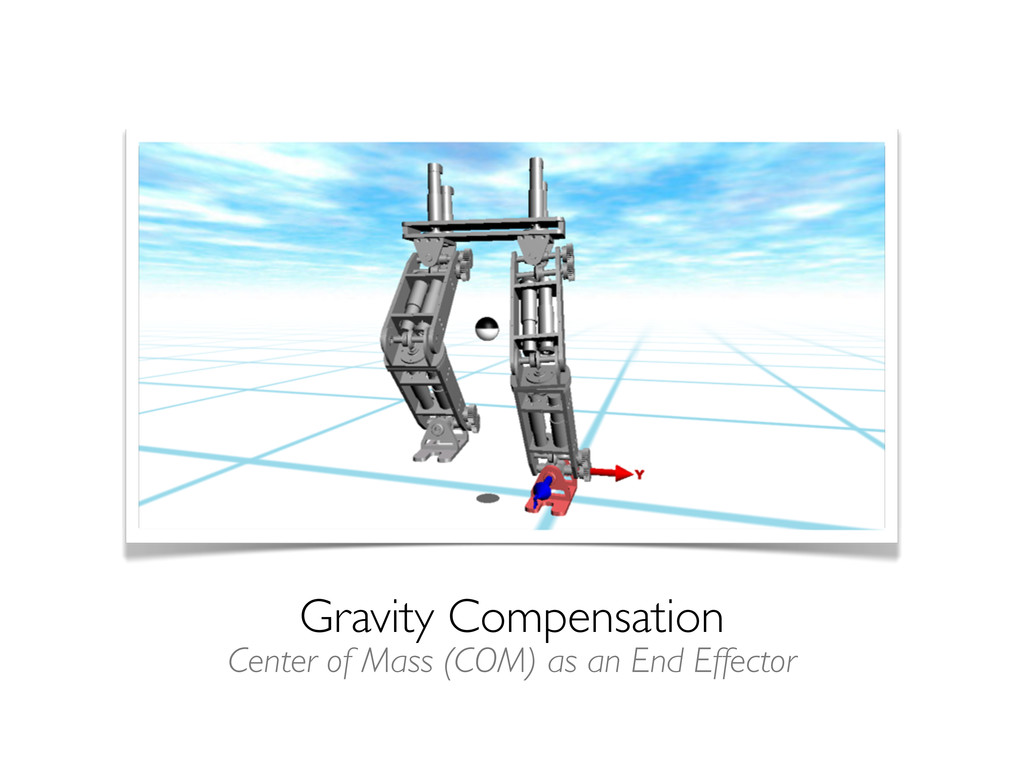
Gravity Compensation Center of Mass (COM) as an End Effector
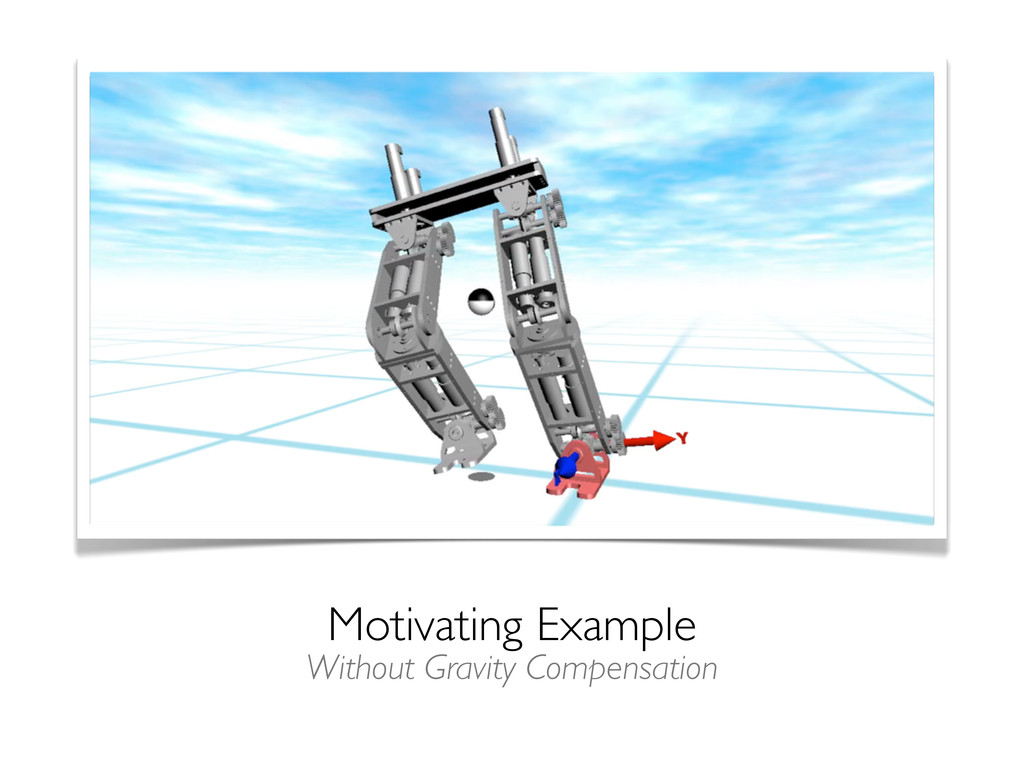
Motivating Example Without Gravity Compensation
Computing the Jacobian Columns The “Geometric” Approach Recall
Center of Mass Equation Rigid Body Physics Recall xcom =
P ximi P mi
Gravity Compensation Center of Mass (COM) as an End Effector
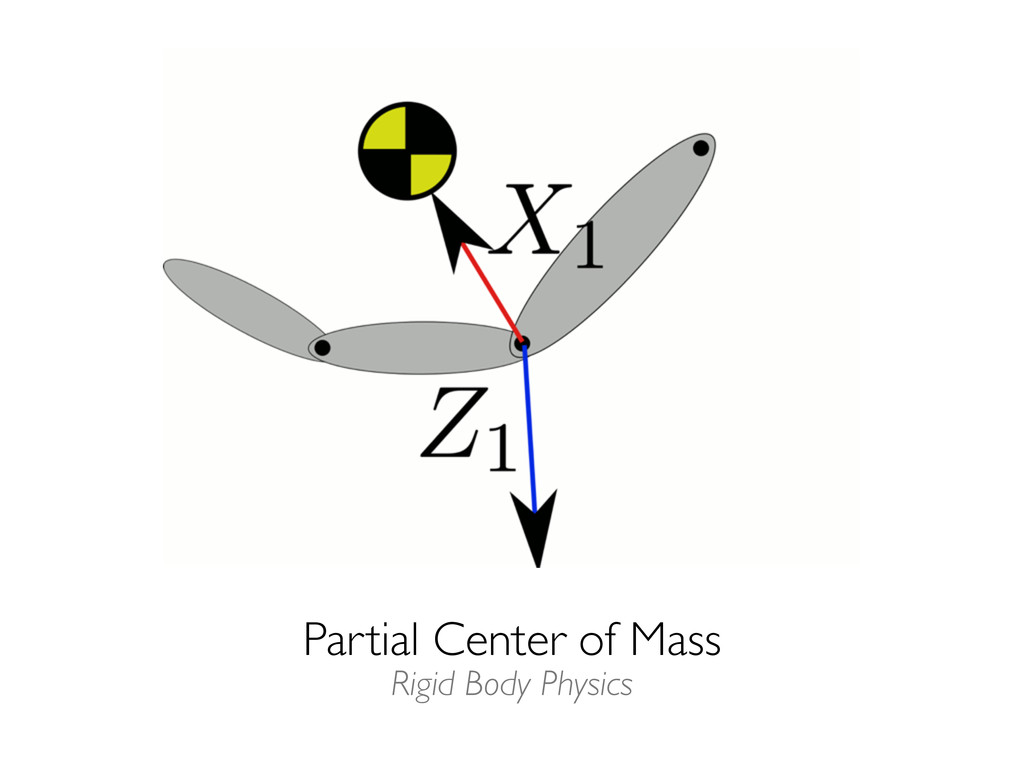
Partial Center of Mass Rigid Body Physics
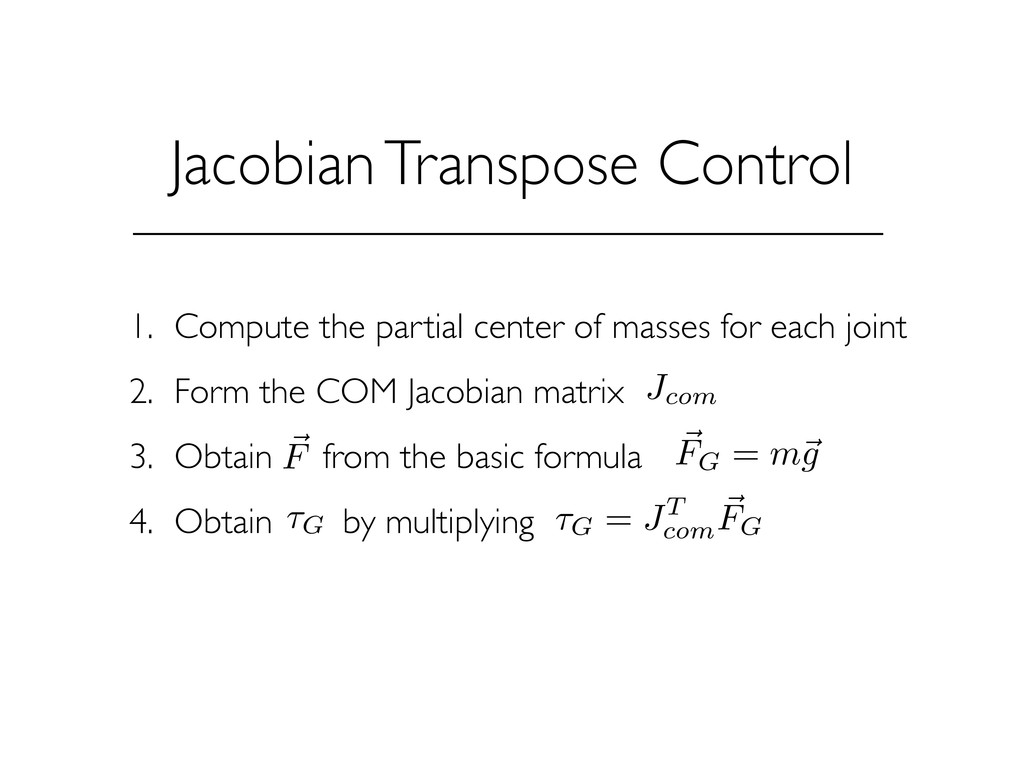
Jacobian Transpose Control 1. Compute the partial center of masses
for each joint 2. Form the COM Jacobian matrix 3. Obtain from the basic formula 4. Obtain by multiplying J com ~ FG = m~ g ~ F ⌧G ⌧ G = JT com ~ F G
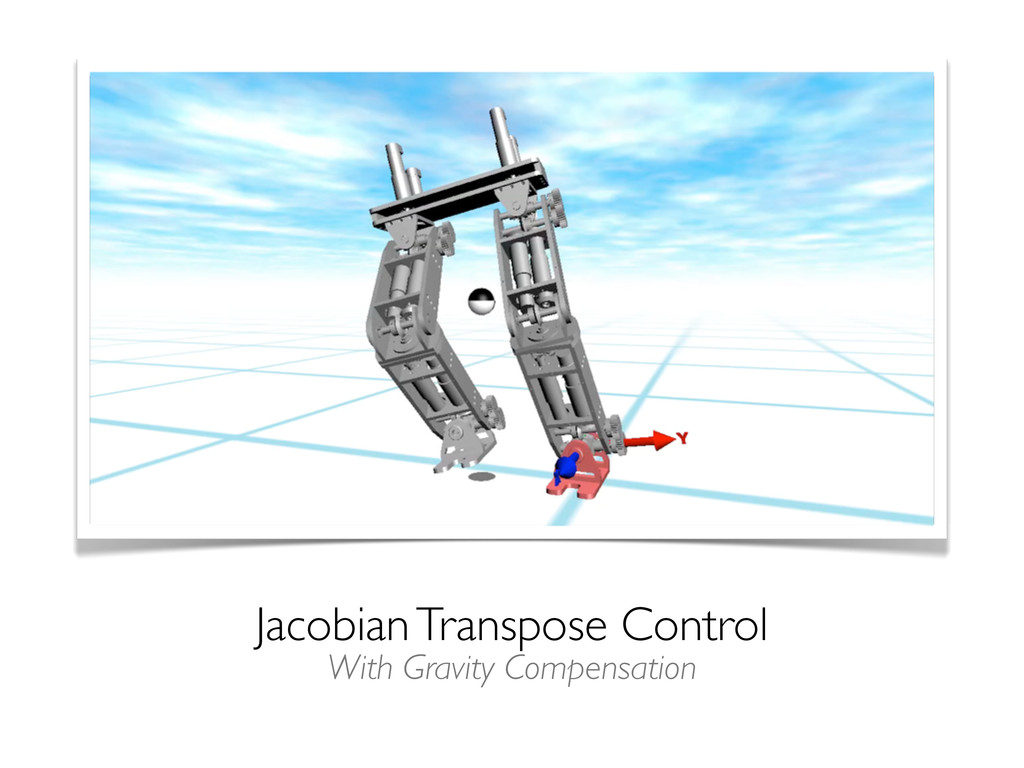
Jacobian Transpose Control With Gravity Compensation
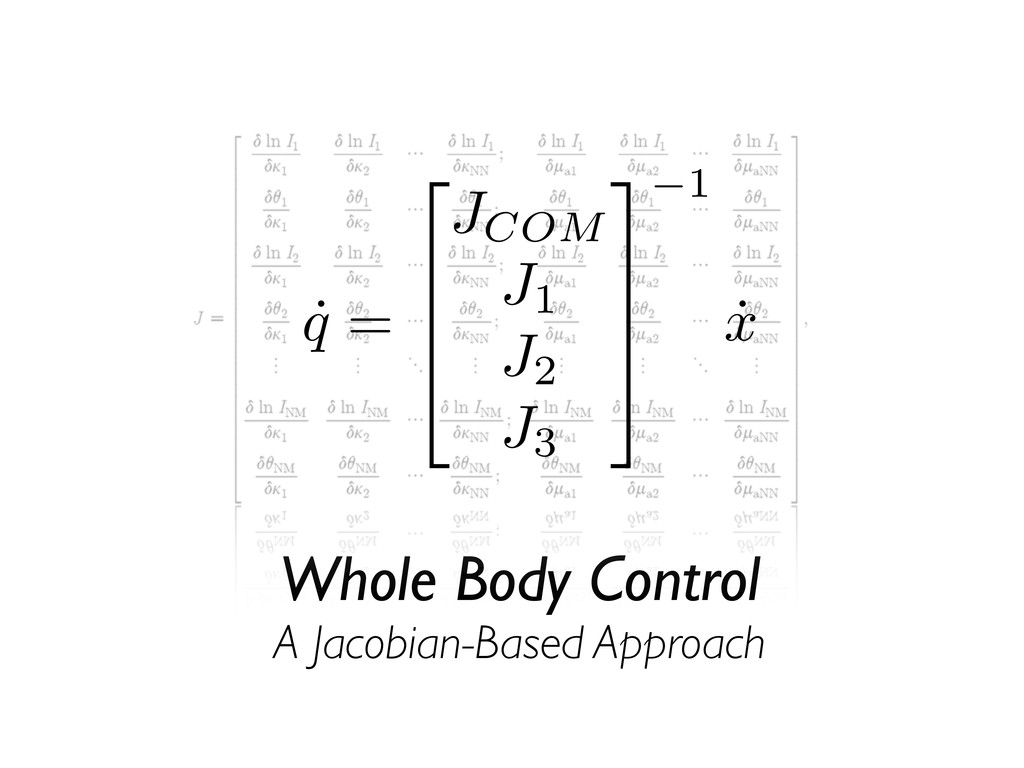
Whole Body Control A Jacobian-Based Approach ˙ q = 2
6 6 4 JCOM J1 J2 J3 3 7 7 5 1 ˙ x
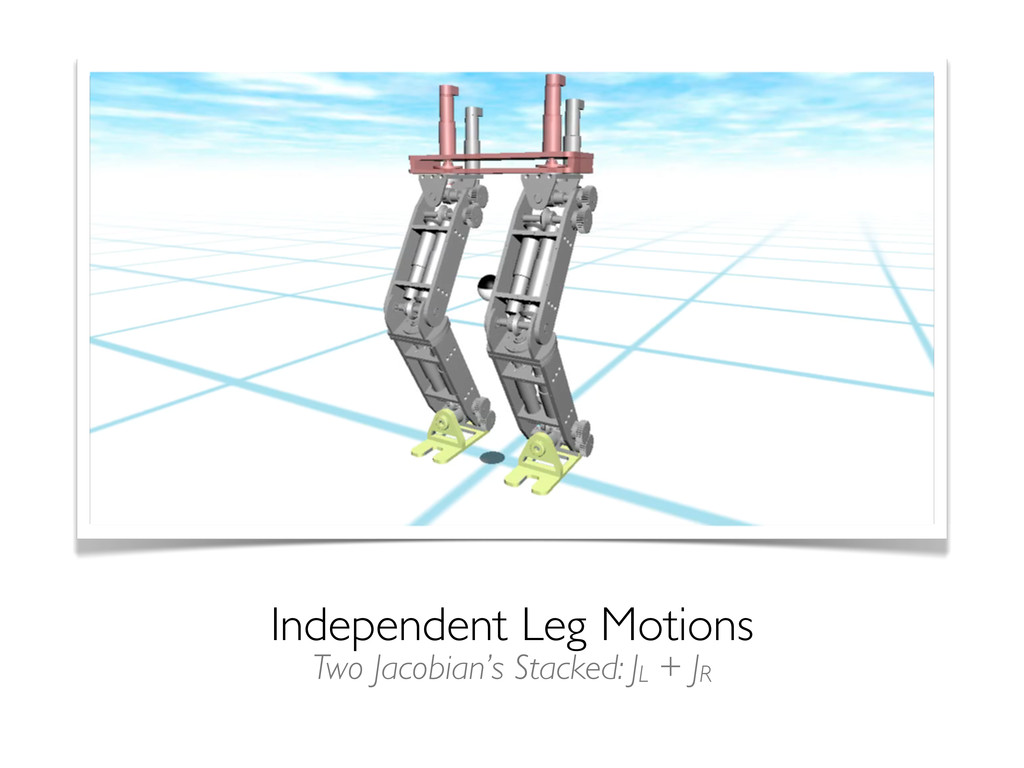
Independent Leg Motions Two Jacobian’s Stacked: JL + JR
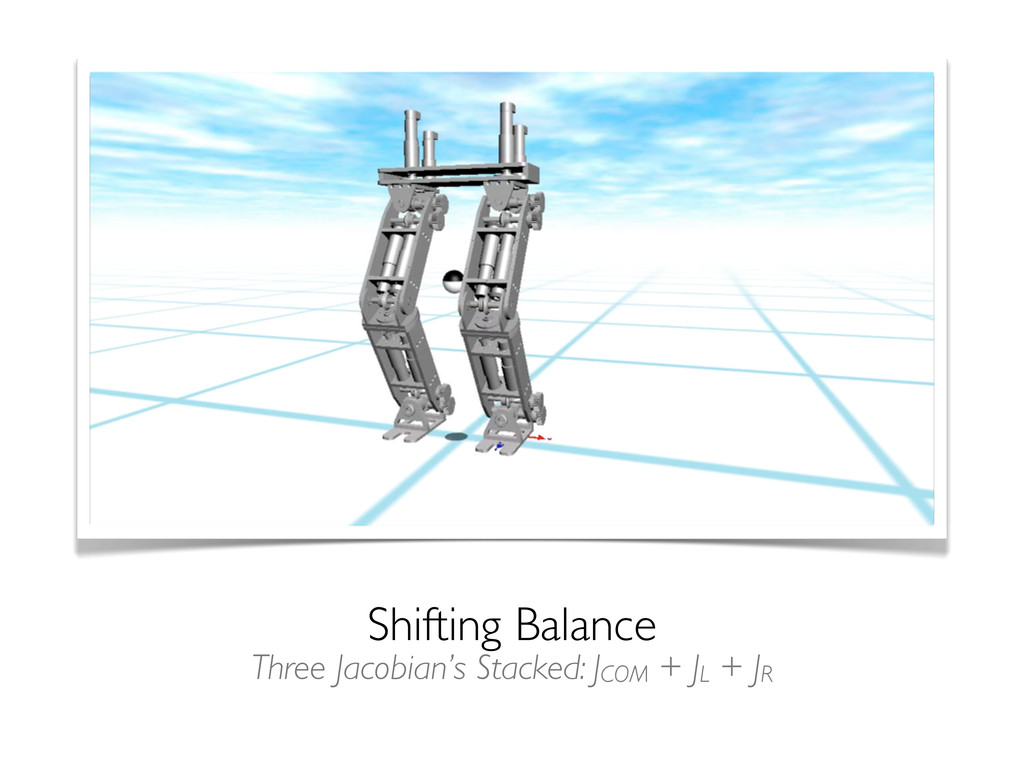
Shifting Balance Three Jacobian’s Stacked: JCOM + JL + JR
Questions?


 safwanc
 signer
 bvr7352
 matleenalaakso
 2720japanoke
 akiraasano
 frievea
 juanmartin2026
 drpoonamkc
 rashwhitman
 arnoknobbe
 portentint
 deanohume
 orderedlist
 denniskardys
 yeseniaperezcruz
 cassininazir
 axbom
 reverentgeek
 codingconduct
 samanthasiow
 twada