Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
ロボが人間並みに器用になる日は近い~ロボット触覚と深層強化学習の融合
Search
Sponsored
·
Your Podcast. Everywhere. Effortlessly.
Share. Educate. Inspire. Entertain. You do you. We'll handle the rest.
→
moroqq82
July 25, 2025
Research
32
0
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
ロボが人間並みに器用になる日は近い~ロボット触覚と深層強化学習の融合
ロボット触覚の進展と深層強化学習によるロボット制御が合わされば、ロボットは人間並みに器用になるのでは?と考えて、私見をまとめました。
moroqq82
July 25, 2025
More Decks by moroqq82
See All by moroqq82
LA-Bench2025取り組みと解法(専門家評価部門 最優秀賞)
motohiro_okaya
0
34
GPT-4による足し算実験から示唆されるLLMの課題
motohiro_okaya
0
230
Business Platform based on Artificial General Intelligence
motohiro_okaya
0
160
Other Decks in Research
See All in Research
最先端NLP 2026 論文紹介: Wait, Wait, Wait... Why Do Reasoning Models Loop? / SNLP Paper Review: Wait, Wait, Wait... Why Do Reasoning Models Loop?
tkng
0
260
A new deal for disabled people
resolutionfoundation
0
270
[webinaire du Ciirpo] Agnelages plein air : des éleveurs partagent leurs pratiques
institutdelelevage
PRO
0
230
【ローカルAIに向き合う展示会vol.2】液体時間定数型モジュールを用いた オリジナルの双方向エンコーダーモデルNexteraBERT 推論速度向上検討並びにダウンストリーム評価
rikkabotan7
0
230
【中間報告】国会議員の立法・政策実務を支える環境を巡る現状と課題
polipoli
0
770
最先端NLP勉強会2026 論文紹介:Reasoning with Sampling: Your Base Model is Smarter Than You Think (ICLR 2026 paper)
kogoro
4
720
Santé et fertilité des sols : ce que nous disent les pratiques dans les systèmes de polyculture-élevage
institutdelelevage
PRO
0
130
Sleuthcon Keynote - How Cybercriminals (ab)use AI
fr0gger
0
390
VLMの推論を高速化する視覚トークン削減の仕組み
tattaka
2
380
Evaluation génomique des femelles laitières croisées : comprendre la méthode pour accompagner les éleveurs à son utilisation
institutdelelevage
PRO
0
170
2026年6月_副業コンプライアンス調査_業界別リスク度分析_株式会社フクスケ.pdf
fkske
0
130
PHTalks Bengaluru - SSRF When All Else Fails
dk999
0
1.2k
Featured
See All Featured
The Cost Of JavaScript in 2023
addyosmani
55
10k
Designing for Performance
lara
612
70k
The Psychology of Web Performance [Beyond Tellerrand 2023]
tammyeverts
49
3.6k
How People are Using Generative and Agentic AI to Supercharge Their Products, Projects, Services and Value Streams Today
helenjbeal
2
360
Exploring anti-patterns in Rails
aemeredith
4
540
ReactJS: Keep Simple. Everything can be a component!
pedronauck
666
130k
Evolution of real-time – Irina Nazarova, EuRuKo, 2024
irinanazarova
9
1.6k
Impact Scores and Hybrid Strategies: The future of link building
tamaranovitovic
0
460
We Analyzed 250 Million AI Search Results: Here's What I Found
joshbly
2
2k
Producing Creativity
orderedlist
PRO
348
41k
Measuring & Analyzing Core Web Vitals
bluesmoon
9
1k
Distributed Sagas: A Protocol for Coordinating Microservices
caitiem20
333
23k
Transcript
ロボが人間並みに器用になる日は近い ~ロボット触覚と深層強化学習の融合~ 1 2025年7月26日 岡谷 基弘
この資料は何? 2 向こう1~2年で起きる可能性が高いと考えている ロボット業界のブレークスルーについての私見を述 べたもの
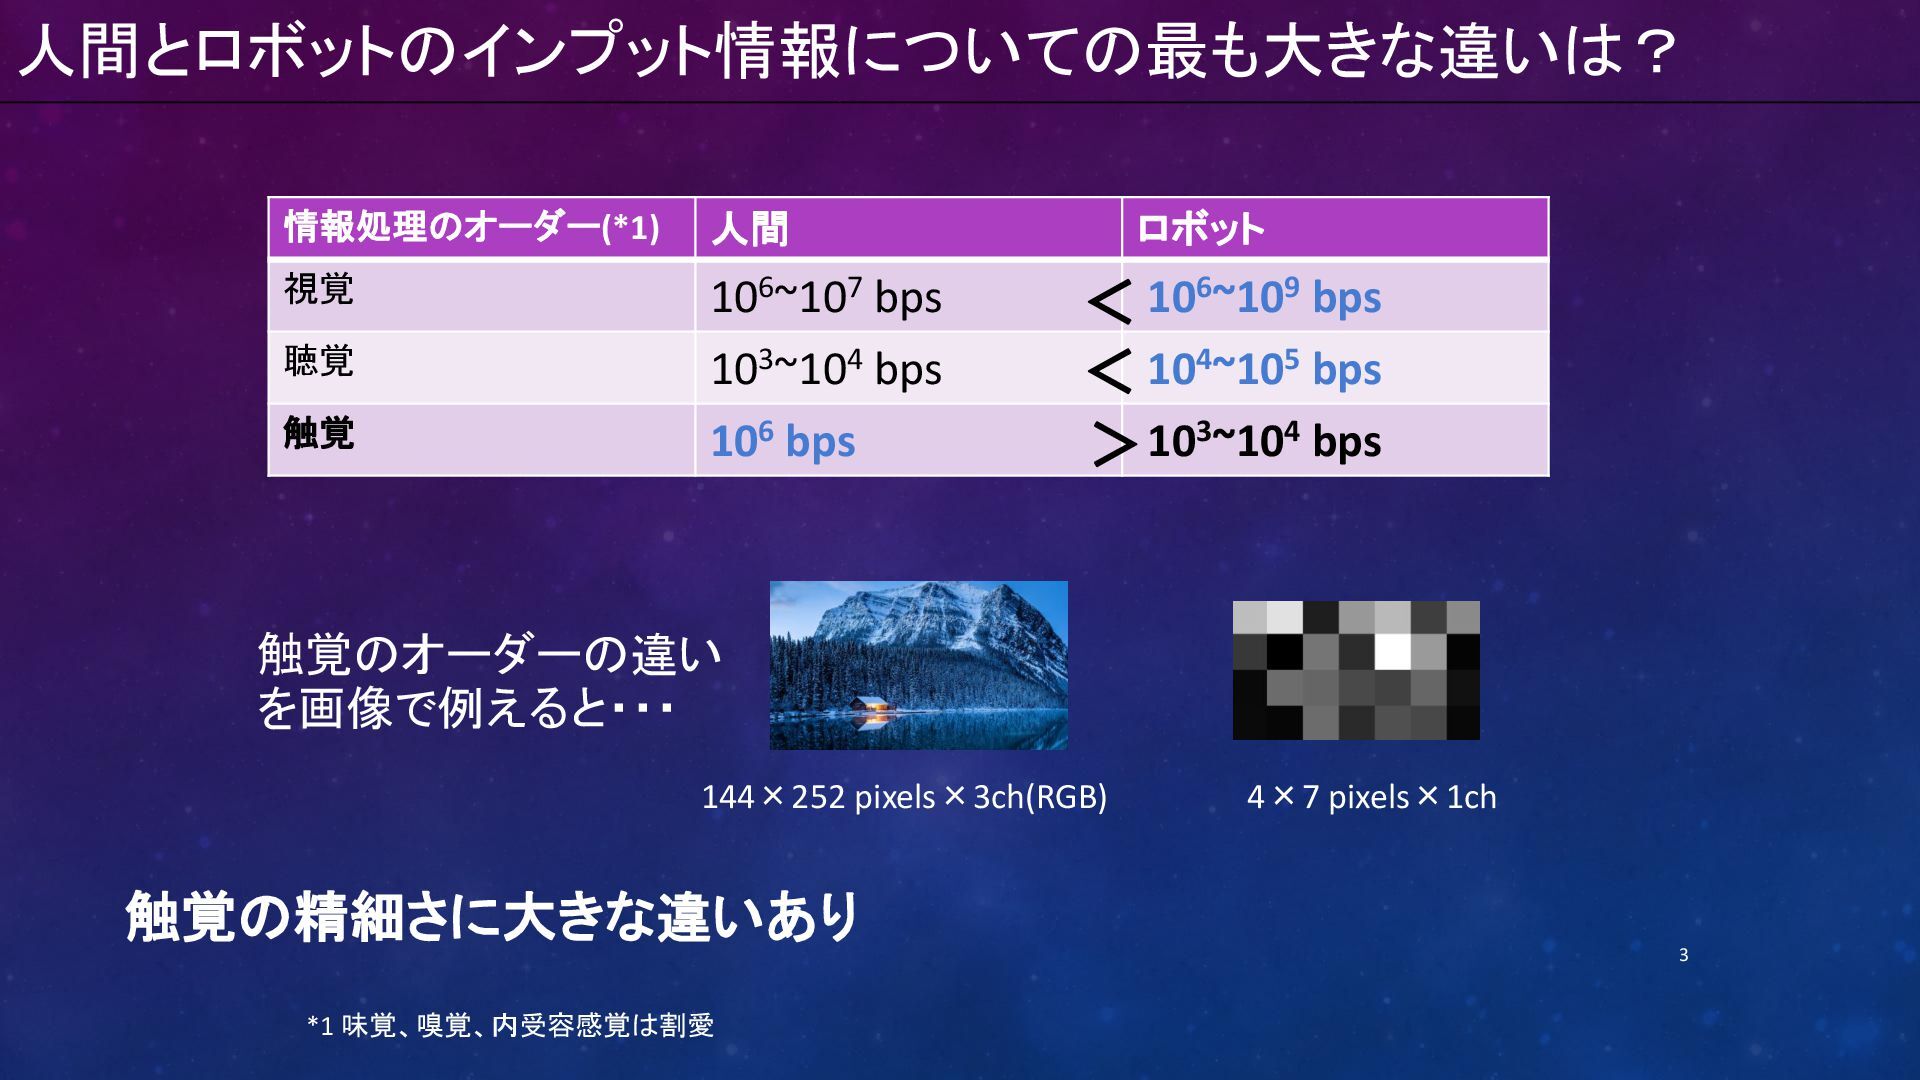
人間とロボットのインプット情報についての最も大きな違いは? 3 情報処理のオーダー(*1) 人間 ロボット 視覚 106~107 bps 106~109 bps
聴覚 103~104 bps 104~105 bps 触覚 106 bps 103~104 bps *1 味覚、嗅覚、内受容感覚は割愛 触覚の精細さに大きな違いあり 144×252 pixels×3ch(RGB) 4×7 pixels×1ch 触覚のオーダーの違い を画像で例えると・・・ < < >
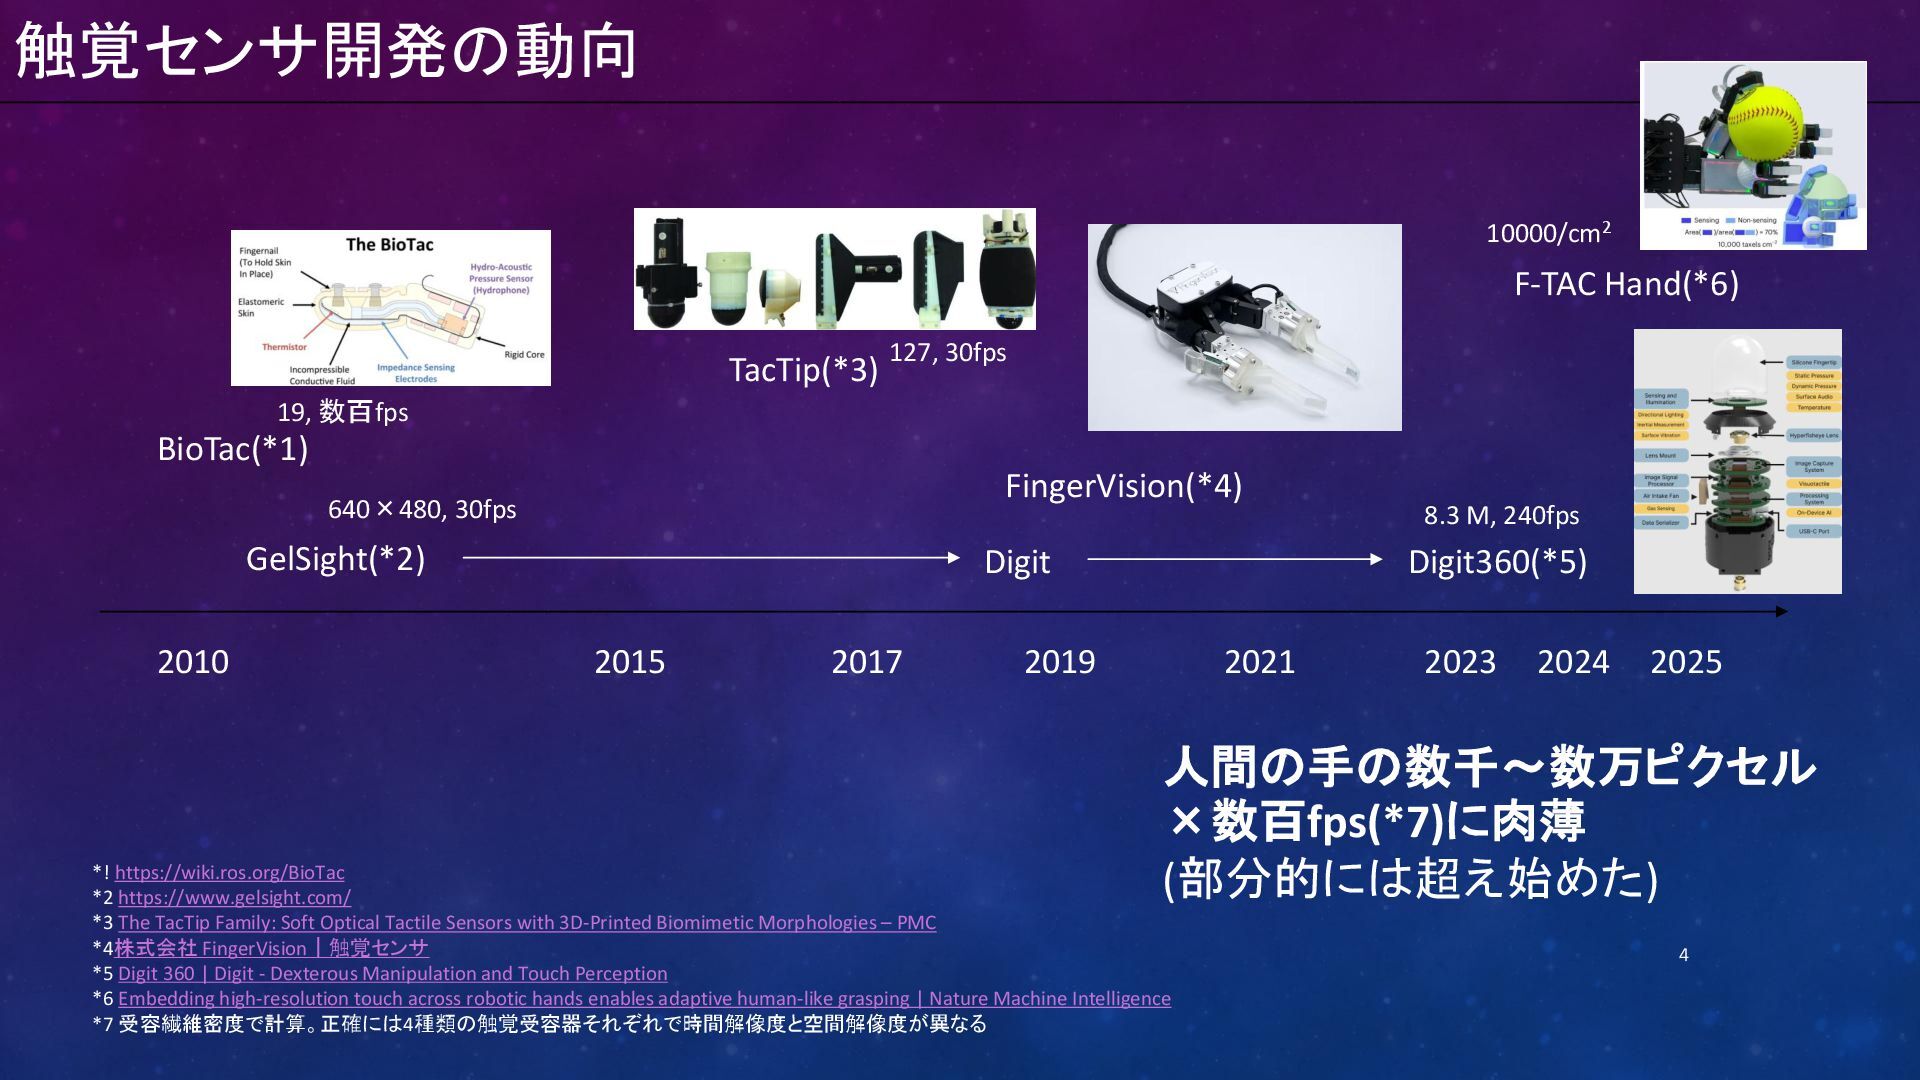
触覚センサ開発の動向 4 2024 Digit360(*5) 2010 2015 2017 2019 2021 2023
GelSight(*2) Digit 2025 640×480, 30fps BioTac(*1) *! https://wiki.ros.org/BioTac *2 https://www.gelsight.com/ *3 The TacTip Family: Soft Optical Tactile Sensors with 3D-Printed Biomimetic Morphologies – PMC *4株式会社 FingerVision|触覚センサ *5 Digit 360 | Digit - Dexterous Manipulation and Touch Perception *6 Embedding high-resolution touch across robotic hands enables adaptive human-like grasping | Nature Machine Intelligence *7 受容繊維密度で計算。正確には4種類の触覚受容器それぞれで時間解像度と空間解像度が異なる 19, 数百fps TacTip(*3) 127, 30fps FingerVision(*4) F-TAC Hand(*6) 10000/cm2 8.3 M, 240fps 人間の手の数千~数万ピクセル ×数百fps(*7)に肉薄 (部分的には超え始めた)
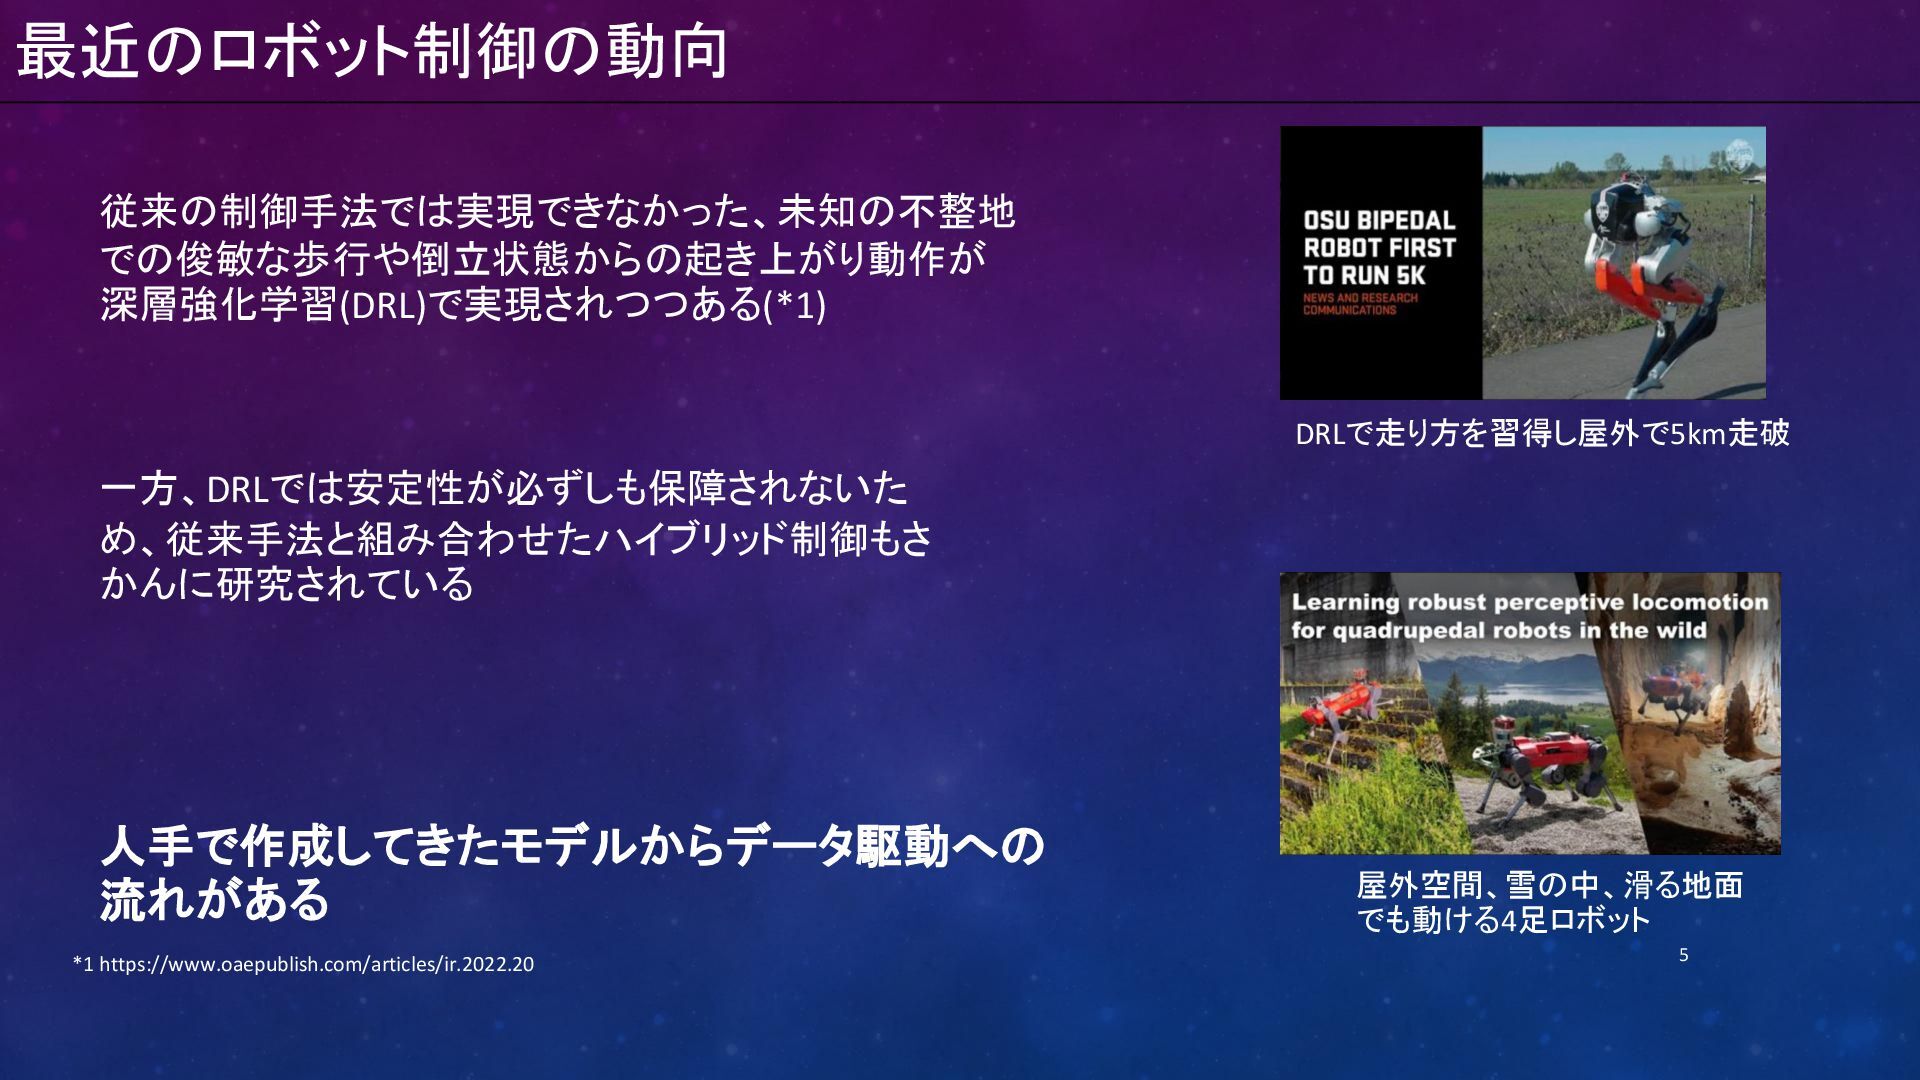
最近のロボット制御の動向 5 従来の制御手法では実現できなかった、未知の不整地 での俊敏な歩行や倒立状態からの起き上がり動作が 深層強化学習(DRL)で実現されつつある(*1) 一方、DRLでは安定性が必ずしも保障されないた め、従来手法と組み合わせたハイブリッド制御もさ かんに研究されている 人手で作成してきたモデルからデータ駆動への 流れがある
*1 https://www.oaepublish.com/articles/ir.2022.20 DRLで走り方を習得し屋外で5km走破 屋外空間、雪の中、滑る地面 でも動ける4足ロボット
BITTER LESSON 6 人手で作ったモデルではなく、汎用的な手法がデータと計算量で圧倒してきた 画像処理:SIFT特徴量などから深層学習へ 自然言語処理:n-gramなどからLLMへ 触覚は・・・ 触覚は今までデータがなかった (柔らかいハンドの場合、シミュレーションでデータを得ることも難しい(*1)) これからは?
*1 有限要素法による計算が必要でそれに莫大な計算時間がかかるため http://www.incompleteideas.net/IncIdeas/BitterLesson.html
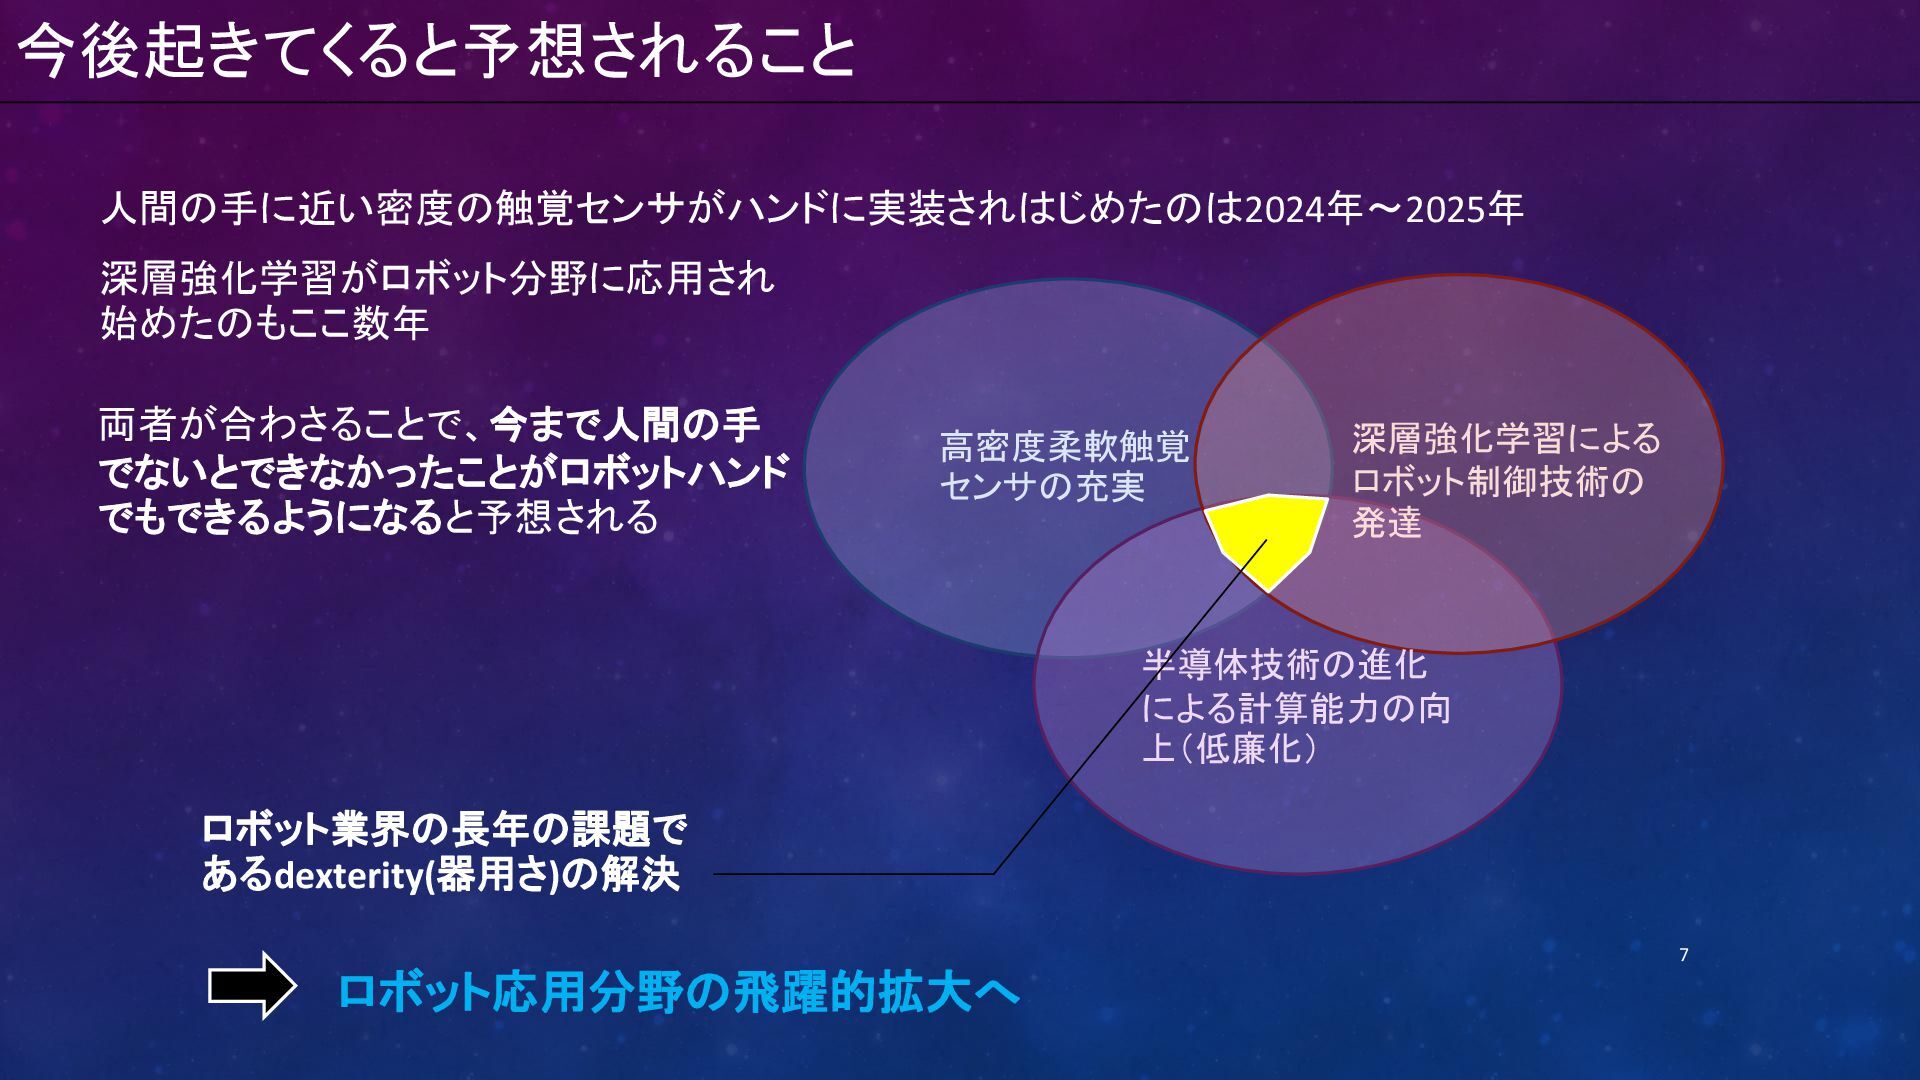
今後起きてくると予想されること 7 人間の手に近い密度の触覚センサがハンドに実装されはじめたのは2024年~2025年 高密度柔軟触覚 センサの充実 深層強化学習による ロボット制御技術の 発達 半導体技術の進化 による計算能力の向
上(低廉化) ロボット業界の長年の課題で あるdexterity(器用さ)の解決 ロボット応用分野の飛躍的拡大へ 深層強化学習がロボット分野に応用され 始めたのもここ数年 両者が合わさることで、今まで人間の手 でないとできなかったことがロボットハンド でもできるようになると予想される
まとめ 8
まとめ 9 • 2025年現在、ロボット触覚は人間の手の触覚の解像度に肉薄している • 4足ロボットやヒューマノイドは深層強化学習によって、従来の制御手法だけではでき ない多様な行動が可能になっている • Bitter lessonを踏まえると、人間の手に準ずる触覚(データ)と深層強化学習(計算量)
によって、ロボットハンドの「器用さ」の問題は解決される可能性が高い(少なくとも、 「解決された」と主張する論文が1年以内程度で出てくると予想される) • 触覚センサとハンドの開発動向は要チェック!
END 10

 Your Podcast. Everywhere. Effortlessly.


 motohiro_okaya
 tkng
 resolutionfoundation
 institutdelelevage
 rikkabotan7
 polipoli
 kogoro
 fr0gger
 tattaka
 fkske
 dk999
 addyosmani
 lara
 tammyeverts
 helenjbeal
 aemeredith
 pedronauck
 irinanazarova
 tamaranovitovic
 joshbly
 orderedlist
 bluesmoon
 caitiem20