Mesorasi: Architecture Support for Point Cloud ...
Sponsored
·
 Your Podcast. Everywhere. Effortlessly.
Share. Educate. Inspire. Entertain. You do you. We'll handle the rest.
→
Your Podcast. Everywhere. Effortlessly.
Share. Educate. Inspire. Entertain. You do you. We'll handle the rest.
→

Share
Embed
Mesorasi: Architecture Support for Point Cloud Analytics via Delayed-Aggregation
MICRO 2020 talk slides by Yu Feng and Tiancheng Xu.

HorizonLab
October 24, 2020
Transcript
104 slides
-
1 Mesorasi: Architecture Support for Point Cloud Analytics via Delayed-Aggregation
Yu Feng, Boyuan Tian, Tiancheng Xu with Paul Whatmough (Arm Research) and Yuhao Zhu Department of Computer Science University of Rochester http://horizon-lab.org https://github.com/horizon-research/Efficient-Deep-Learning-for-Point-Clouds -
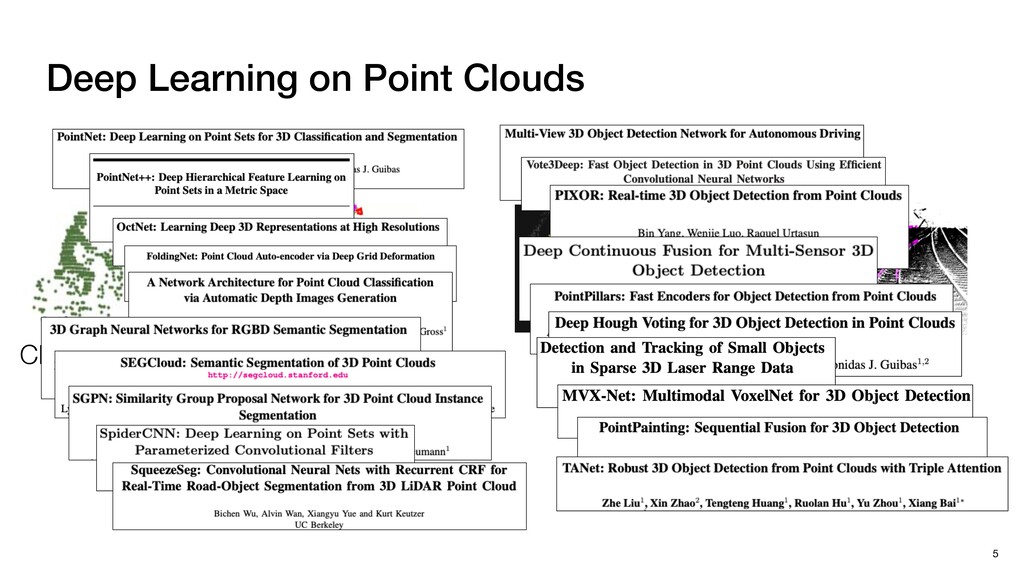
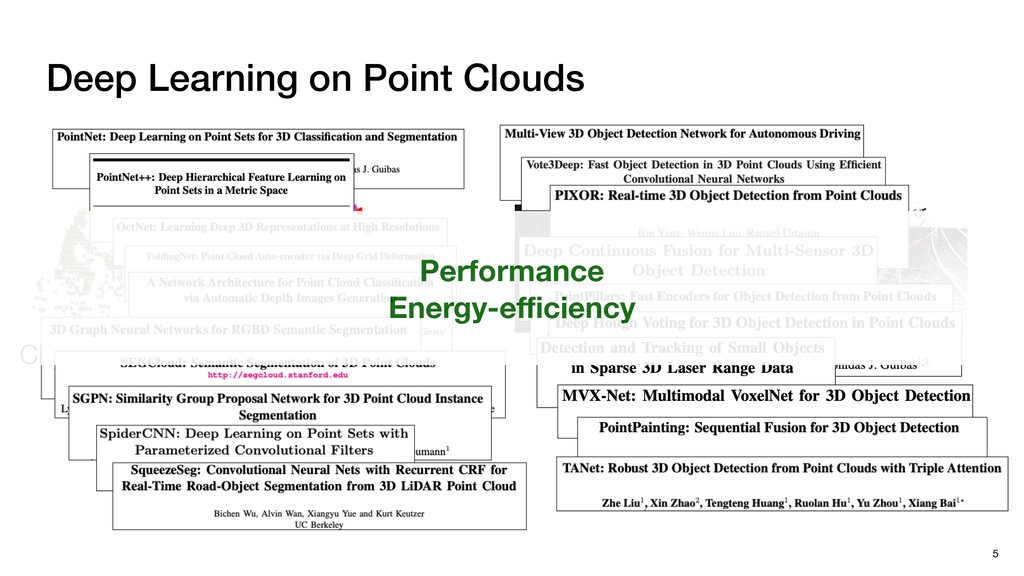
Classification Segmentation Detection SLAM Deep Learning on Point Clouds 5
Performance Energy-efficiency -
Classification Segmentation Detection SLAM Deep Learning on Point Clouds 5
Can we use existing neural network accelerators on point cloud workloads? -
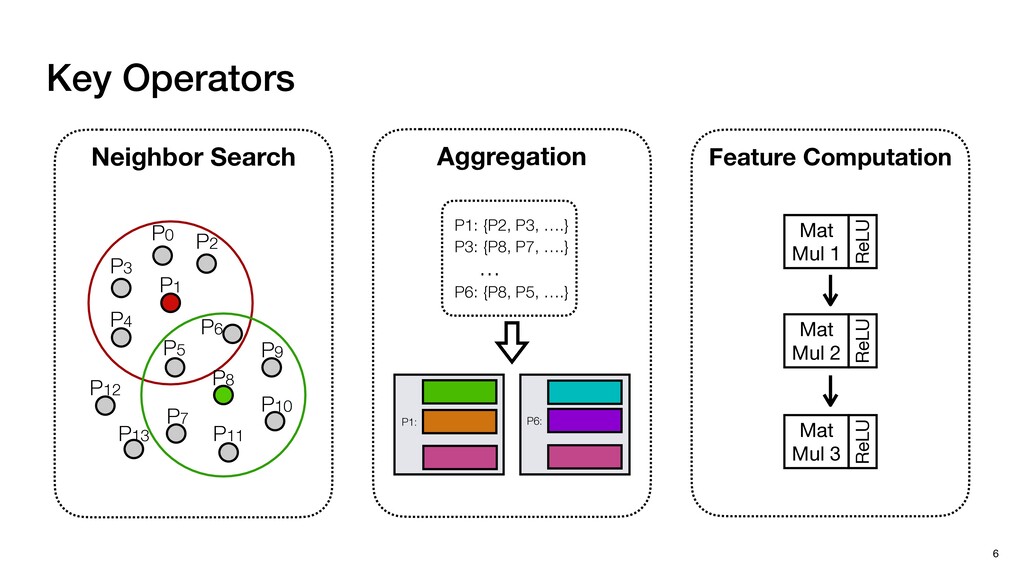
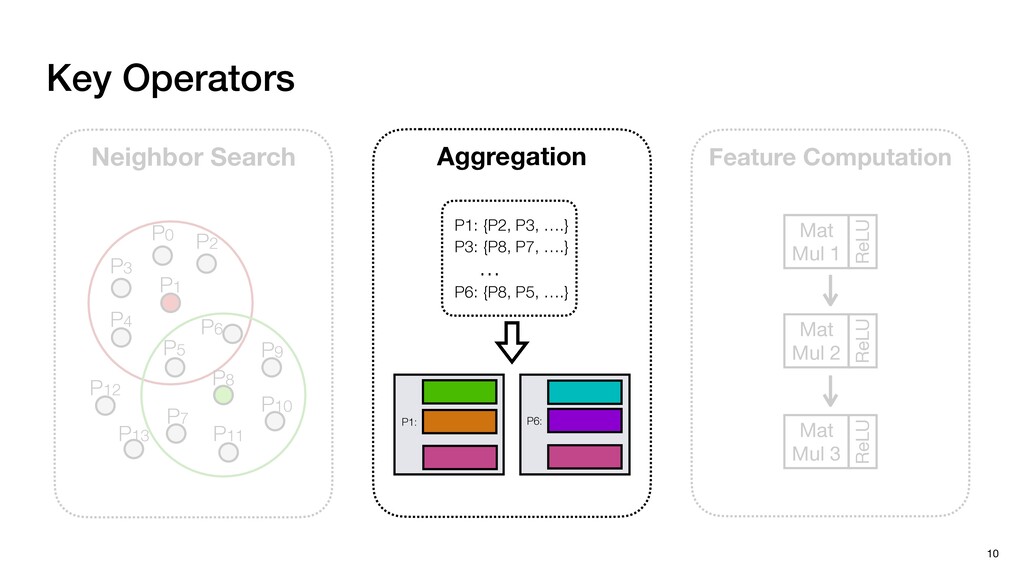
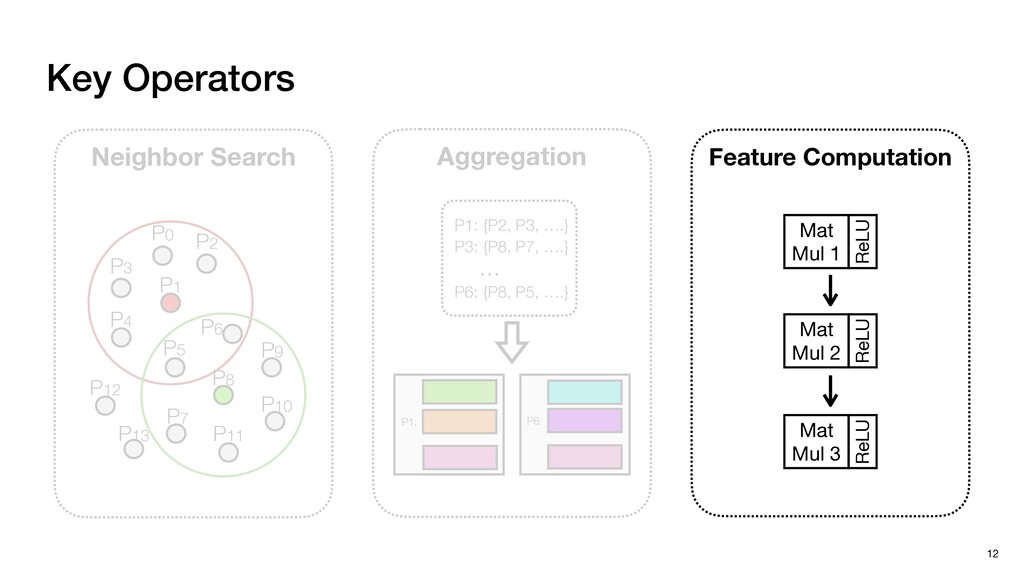
6 Aggregation P3 P4 P12 P13 Neighbor Search P0 P2
P1 P6 P5 P7 P8 P9 P10 P11 Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU Key Operators P1: {P2, P3, ….} P3: {P8, P7, ….} P6: {P8, P5, ….} … … P6: … P1: -
P1: {P2, P3, ….} P3: {P8, P7, ….} P6: {P8,
P5, ….} … … P6: … P1: 7 Aggregation P3 P4 P12 P13 Neighbor Search P0 P2 P1 P6 P5 P7 P8 P9 P10 P11 Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU Key Operators -
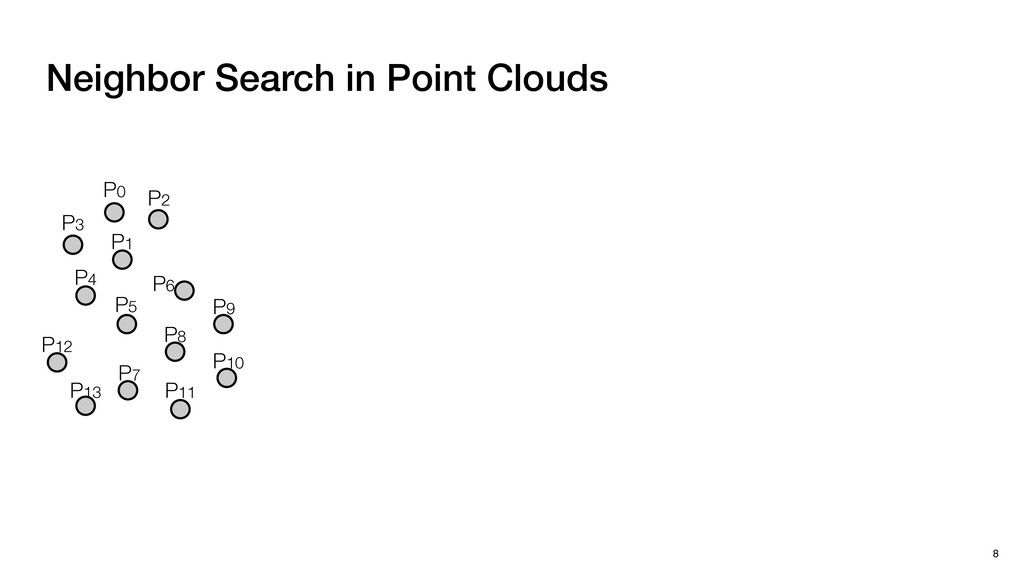
8 Neighbor Search in Point Clouds P1 P8 P0 P2
P3 P6 P5 P7 P9 P10 P12 P13 P11 P4 -
8 Neighbor Search in Point Clouds P1 P8 P0 P2
P3 P6 P5 P7 P9 P10 P12 P13 P11 P4 -
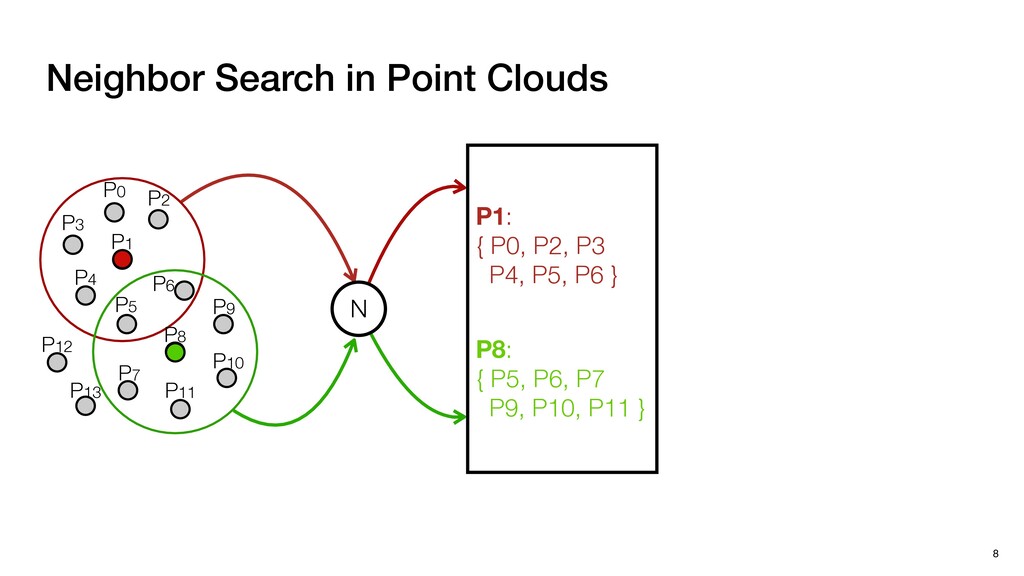
8 Neighbor Search in Point Clouds N P1 P8 P0
P2 P3 P6 P5 P7 P9 P10 P12 P13 P11 P4 -
8 Neighbor Search in Point Clouds N P1: { P0,
P2, P3 P4, P5, P6 } P8: { P5, P6, P7 P9, P10, P11 } P1 P8 P0 P2 P3 P6 P5 P7 P9 P10 P12 P13 P11 P4 -
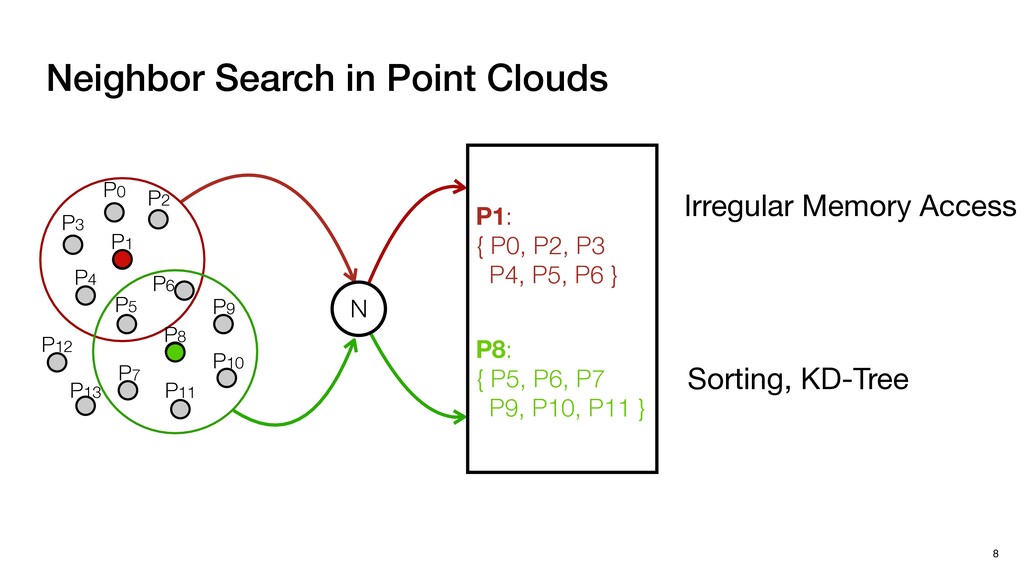
8 Neighbor Search in Point Clouds N P1: { P0,
P2, P3 P4, P5, P6 } P8: { P5, P6, P7 P9, P10, P11 } P1 P8 P0 P2 P3 P6 P5 P7 P9 P10 P12 P13 P11 P4 Sorting, KD-Tree Irregular Memory Access -
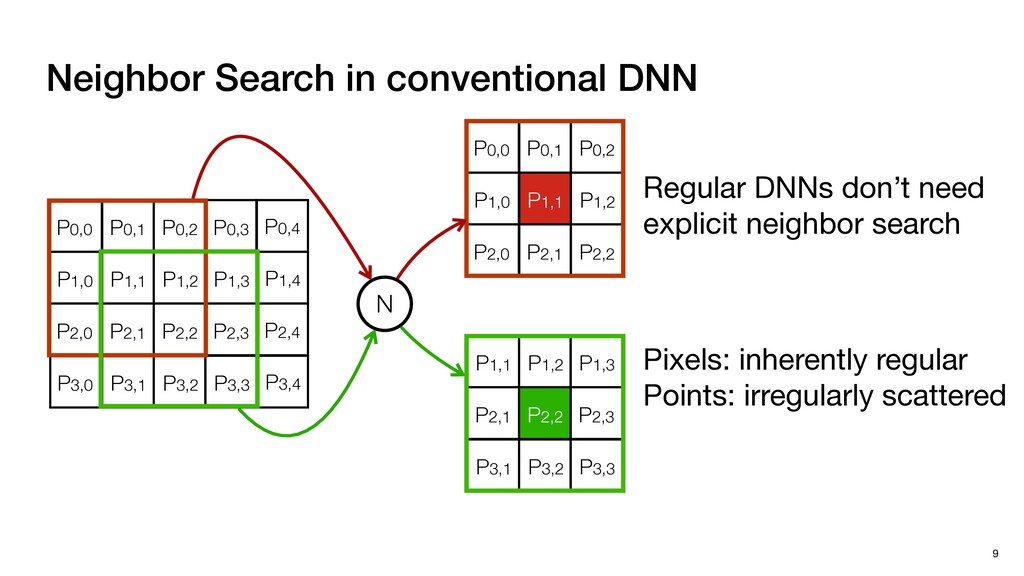
Neighbor Search in conventional DNN 9 P0,0 P0,1 P0,2 P1,0
P1,1 P1,2 P2,0 P2,1 P2,2 P1,1 P1,2 P1,3 P2,1 P2,2 P2,3 P3,1 P3,2 P3,3 N P0,0 P0,1 P0,2 P0,3 P0,4 P1,0 P1,1 P1,2 P1,3 P1,4 P2,0 P2,1 P2,2 P2,3 P2,4 P3,0 P3,1 P3,2 P3,3 P3,4 Pixels: inherently regular Points: irregularly scattered Regular DNNs don’t need explicit neighbor search -
10 Aggregation P3 P4 P12 P13 Neighbor Search P0 P2
P1 P6 P5 P7 P8 P9 P10 P11 Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU Key Operators P1: {P2, P3, ….} P3: {P8, P7, ….} P6: {P8, P5, ….} … … P6: … P1: -
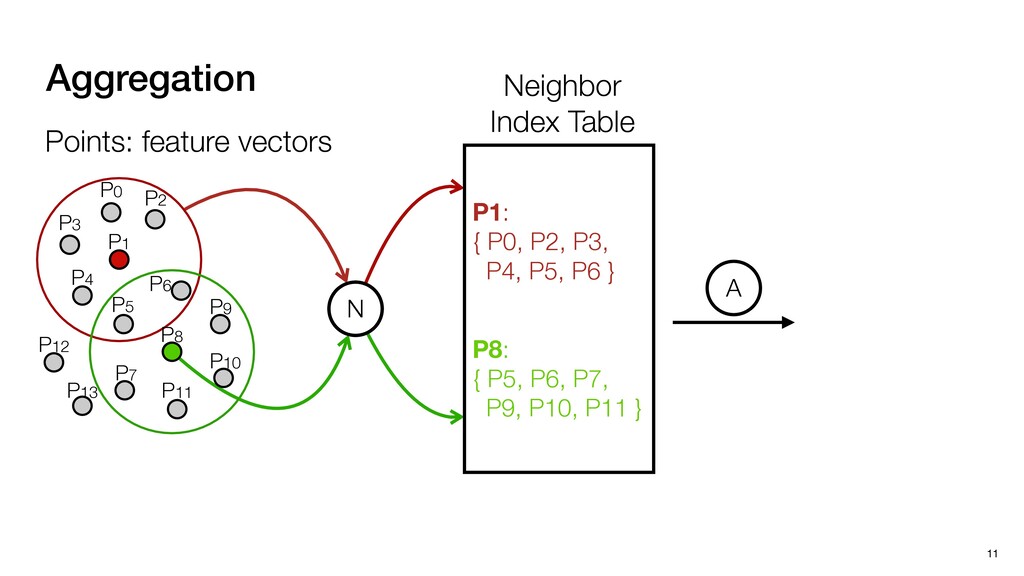
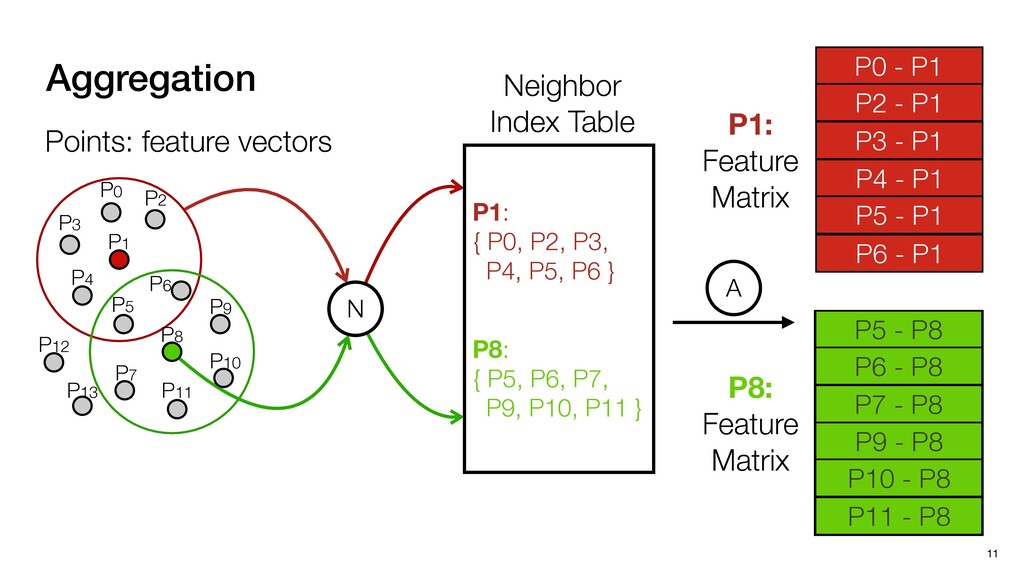
11 Aggregation P0 P2 P3 P1 P6 P5 P7 P8
P9 P10 P12 P13 P11 N P1: { P0, P2, P3, P4, P5, P6 } P8: { P5, P6, P7, P9, P10, P11 } P4 N A Points: feature vectors Neighbor Index Table -
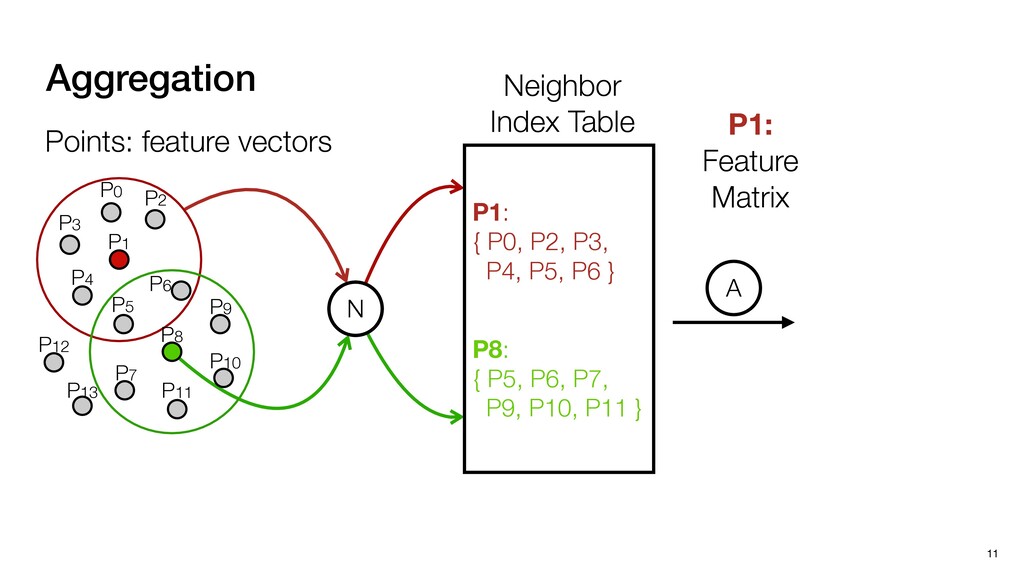
11 Aggregation P0 P2 P3 P1 P6 P5 P7 P8
P9 P10 P12 P13 P11 N P1: { P0, P2, P3, P4, P5, P6 } P8: { P5, P6, P7, P9, P10, P11 } P4 N A P1: Feature Matrix Points: feature vectors Neighbor Index Table -
11 Aggregation P0 P2 P3 P1 P6 P5 P7 P8
P9 P10 P12 P13 P11 N P1: { P0, P2, P3, P4, P5, P6 } P8: { P5, P6, P7, P9, P10, P11 } P4 N A P0 P1: Feature Matrix Points: feature vectors Neighbor Index Table -
11 Aggregation P0 P2 P3 P1 P6 P5 P7 P8
P9 P10 P12 P13 P11 N P1: { P0, P2, P3, P4, P5, P6 } P8: { P5, P6, P7, P9, P10, P11 } P4 N A P0 - P1 P1: Feature Matrix Points: feature vectors Neighbor Index Table -
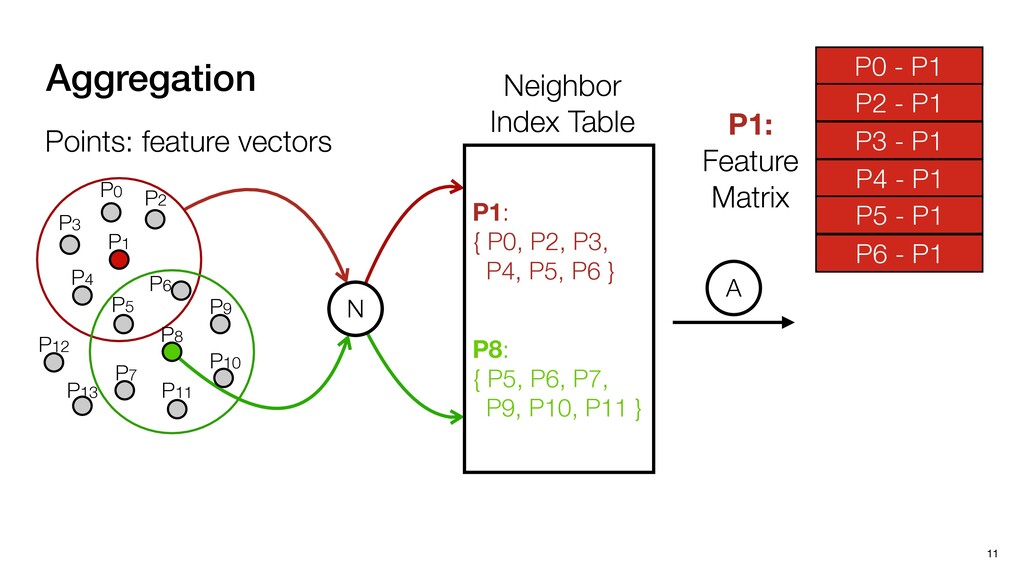
11 Aggregation P0 P2 P3 P1 P6 P5 P7 P8
P9 P10 P12 P13 P11 N P1: { P0, P2, P3, P4, P5, P6 } P8: { P5, P6, P7, P9, P10, P11 } P4 N A P0 - P1 P2 - P1 P3 - P1 P4 - P1 P5 - P1 P6 - P1 P1: Feature Matrix Points: feature vectors Neighbor Index Table -
11 Aggregation P0 P2 P3 P1 P6 P5 P7 P8
P9 P10 P12 P13 P11 N P1: { P0, P2, P3, P4, P5, P6 } P8: { P5, P6, P7, P9, P10, P11 } P4 N A P0 - P1 P2 - P1 P3 - P1 P4 - P1 P5 - P1 P6 - P1 P1: Feature Matrix P5 - P8 P6 - P8 P7 - P8 P9 - P8 P10 - P8 P11 - P8 P8: Feature Matrix Points: feature vectors Neighbor Index Table -
P1: {P2, P3, ….} P3: {P8, P7, ….} P6: {P8,
P5, ….} … … P6: … P1: 12 Aggregation P3 P4 P12 P13 Neighbor Search P0 P2 P1 P6 P5 P7 P8 P9 P10 P11 Key Operators Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU -
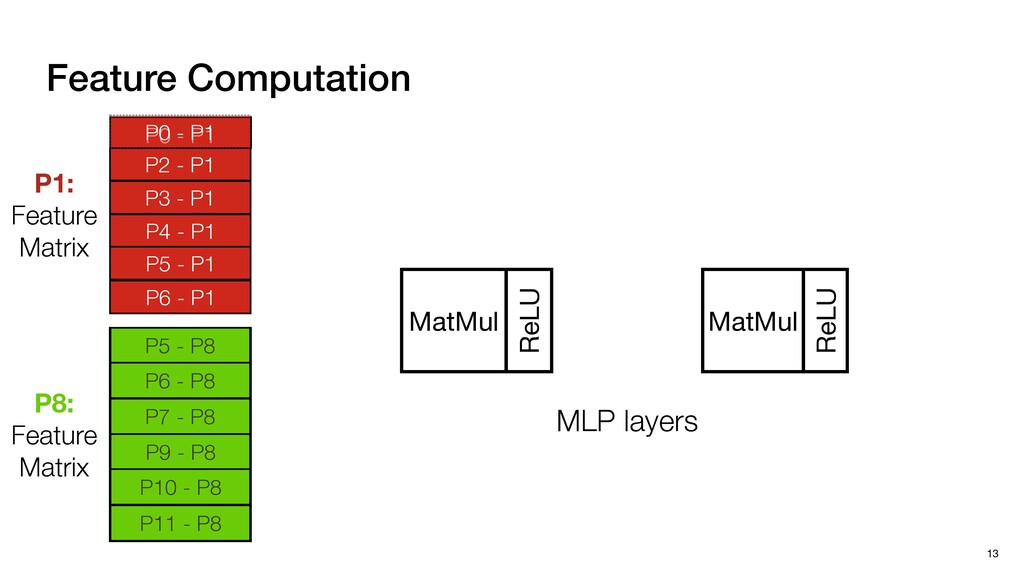
13 Feature Computation MatMul ReLU MatMul ReLU MLP layers P2
- P1 P3 - P1 P4 - P1 P5 - P1 P6 - P1 P1: Feature Matrix P5 - P8 P6 - P8 P7 - P8 P9 - P8 P10 - P8 P11 - P8 P8: Feature Matrix P0 - P1 P0 - P1 -
13 Feature Computation MatMul ReLU MatMul ReLU MLP layers P2
- P1 P3 - P1 P4 - P1 P5 - P1 P6 - P1 P1: Feature Matrix P5 - P8 P6 - P8 P7 - P8 P9 - P8 P10 - P8 P11 - P8 P8: Feature Matrix P0’ P0 - P1 -
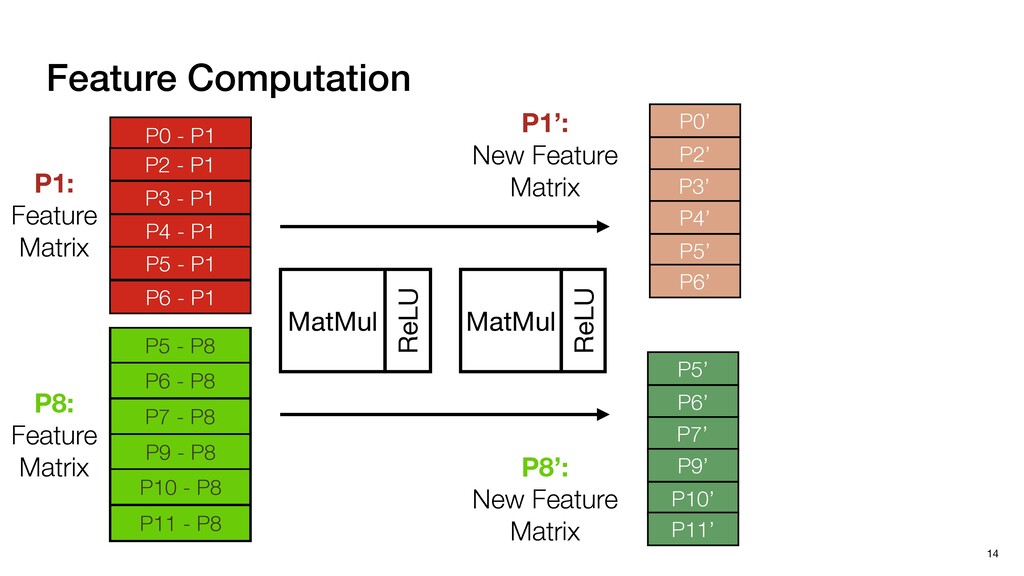
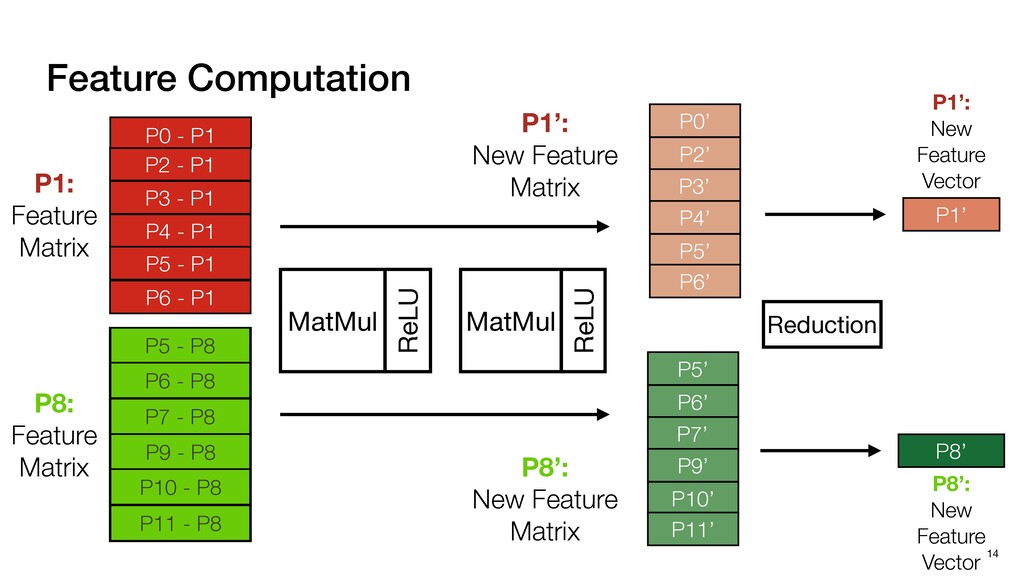
14 Feature Computation MatMul ReLU MatMul ReLU P1: Feature Matrix
P5 - P8 P6 - P8 P7 - P8 P9 - P8 P10 - P8 P11 - P8 P8: Feature Matrix P2 - P1 P3 - P1 P4 - P1 P5 - P1 P6 - P1 P0 - P1 P0’ P2’ P3’ P4’ P5’ P6’ P1’: New Feature Matrix P5’ P6’ P7’ P9’ P10’ P11’ P8’: New Feature Matrix -
14 Feature Computation MatMul ReLU MatMul ReLU P1: Feature Matrix
P5 - P8 P6 - P8 P7 - P8 P9 - P8 P10 - P8 P11 - P8 P8: Feature Matrix P2 - P1 P3 - P1 P4 - P1 P5 - P1 P6 - P1 P0 - P1 P0’ P2’ P3’ P4’ P5’ P6’ P1’: New Feature Matrix P5’ P6’ P7’ P9’ P10’ P11’ P8’: New Feature Matrix Reduction P1’ P1’: New Feature Vector P8’ P8’: New Feature Vector -
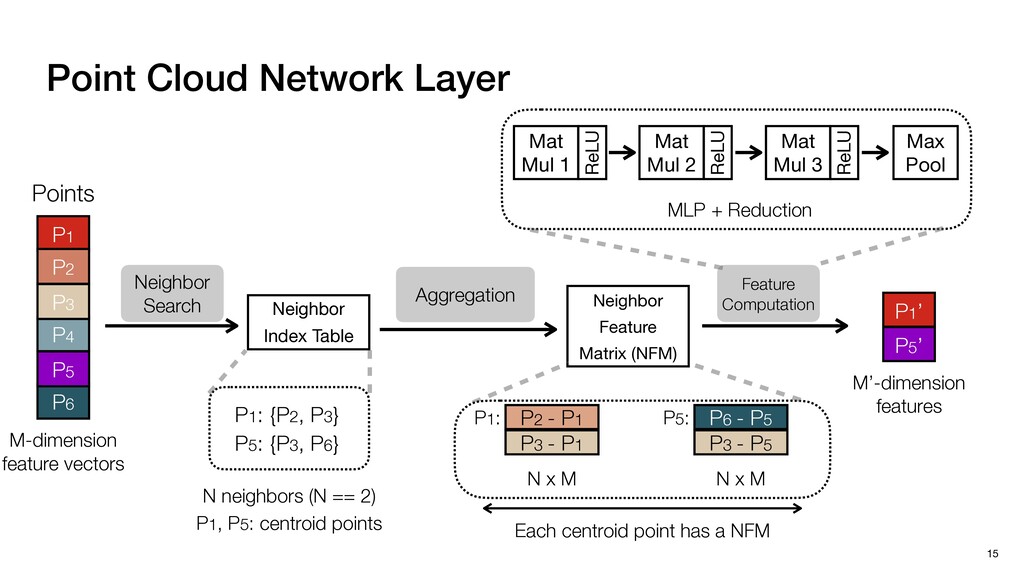
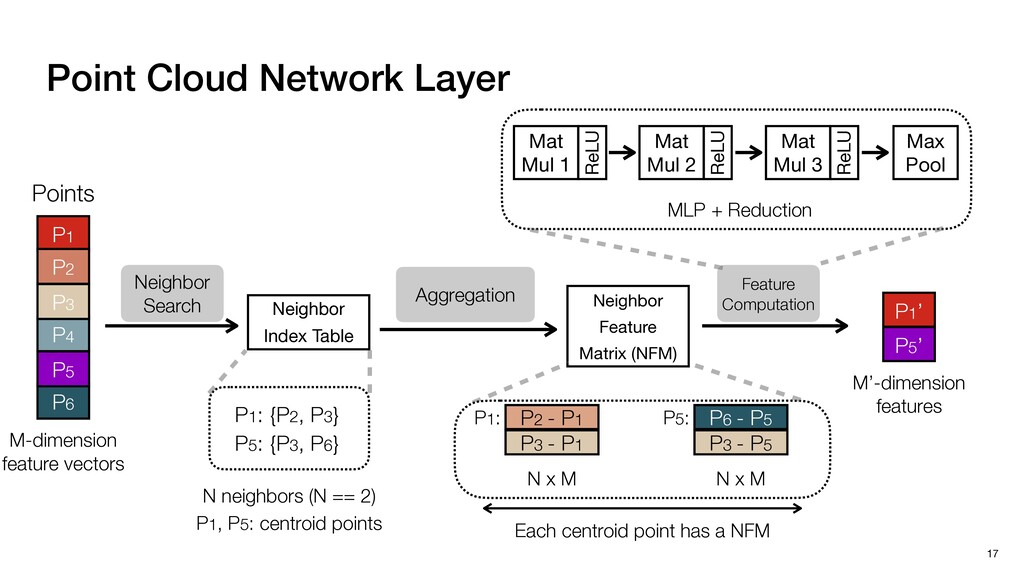
Point Cloud Network Layer 15 P1’ P5’ M’-dimension features Feature
Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool Aggregation Neighbor Feature Matrix (NFM) Each centroid point has a NFM N x M P1: P3 - P1 P2 - P1 N x M P5: P6 - P5 P3 - P5 N neighbors (N == 2) Neighbor Search Neighbor Index Table P1: {P2, P3} P5: {P3, P6} P1, P5: centroid points M-dimension feature vectors P1 P4 P6 P2 P3 P5 Points -
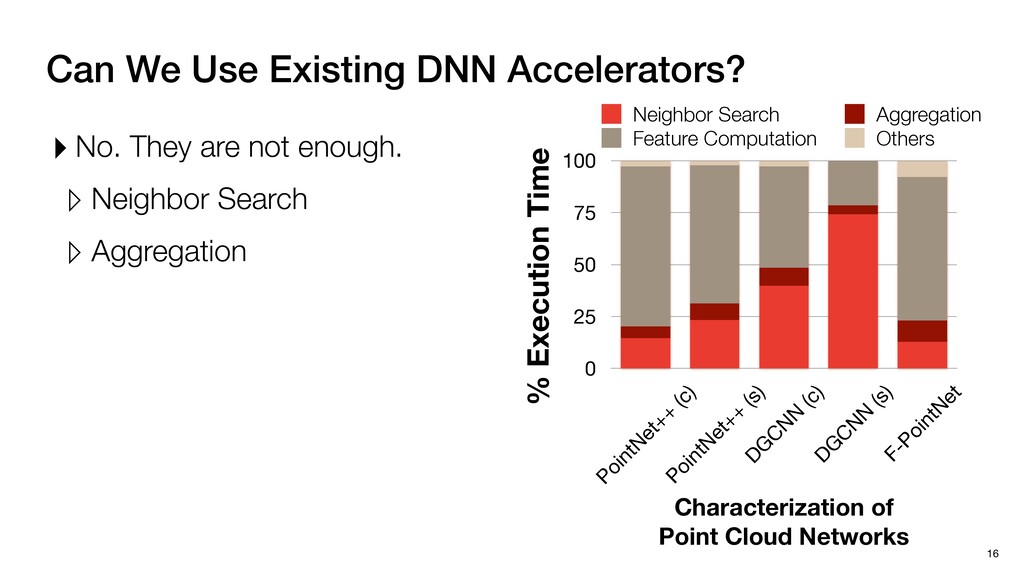
Can We Use Existing DNN Accelerators? 16 ▸ No. They
are not enough. -
Can We Use Existing DNN Accelerators? 16 ▸ No. They
are not enough. ▹ Neighbor Search -
Can We Use Existing DNN Accelerators? 16 ▸ No. They
are not enough. ▹ Neighbor Search ▹ Aggregation -
Can We Use Existing DNN Accelerators? 16 ▸ No. They
are not enough. ▹ Neighbor Search ▹ Aggregation 0 25 50 75 100 PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et Neighbor Search Aggregation Feature Computation Others Characterization of Point Cloud Networks % Execution Time -
Can We Use Existing DNN Accelerators? 16 ▸ No. They
are not enough. ▹ Neighbor Search ▹ Aggregation 0 25 50 75 100 PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et Neighbor Search Aggregation Feature Computation Others Characterization of Point Cloud Networks % Execution Time -
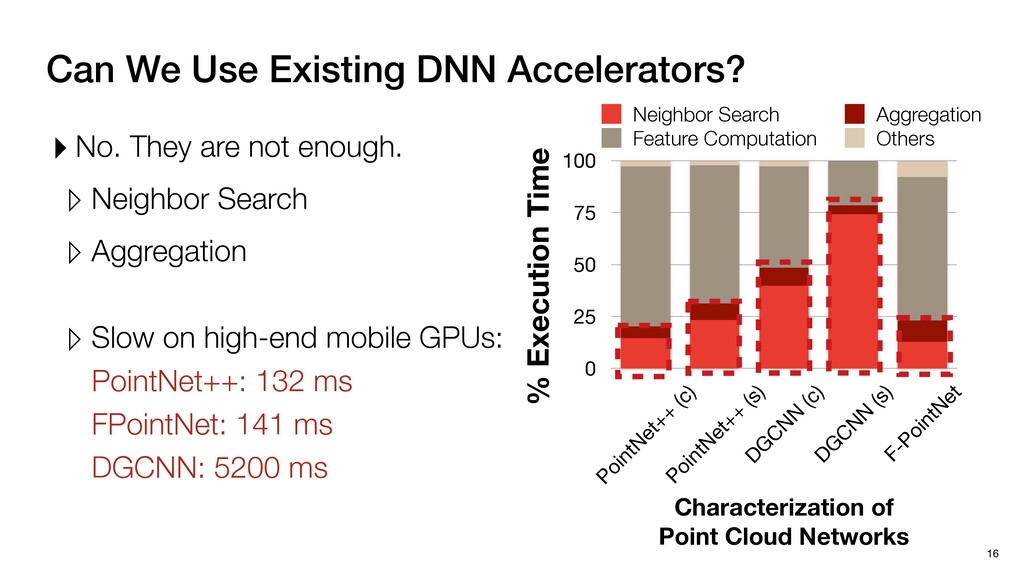
Can We Use Existing DNN Accelerators? 16 ▸ No. They
are not enough. ▹ Neighbor Search ▹ Aggregation 0 25 50 75 100 PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et Neighbor Search Aggregation Feature Computation Others Characterization of Point Cloud Networks % Execution Time ▹ Slow on high-end mobile GPUs: PointNet++: 132 ms FPointNet: 141 ms DGCNN: 5200 ms -
Point Cloud Network Layer 17 P1’ P5’ M’-dimension features Feature
Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool Aggregation Neighbor Feature Matrix (NFM) Each centroid point has a NFM N x M P1: P3 - P1 P2 - P1 N x M P5: P6 - P5 P3 - P5 N neighbors (N == 2) Neighbor Search Neighbor Index Table P1: {P2, P3} P5: {P3, P6} P1, P5: centroid points M-dimension feature vectors P1 P4 P6 P2 P3 P5 Points -
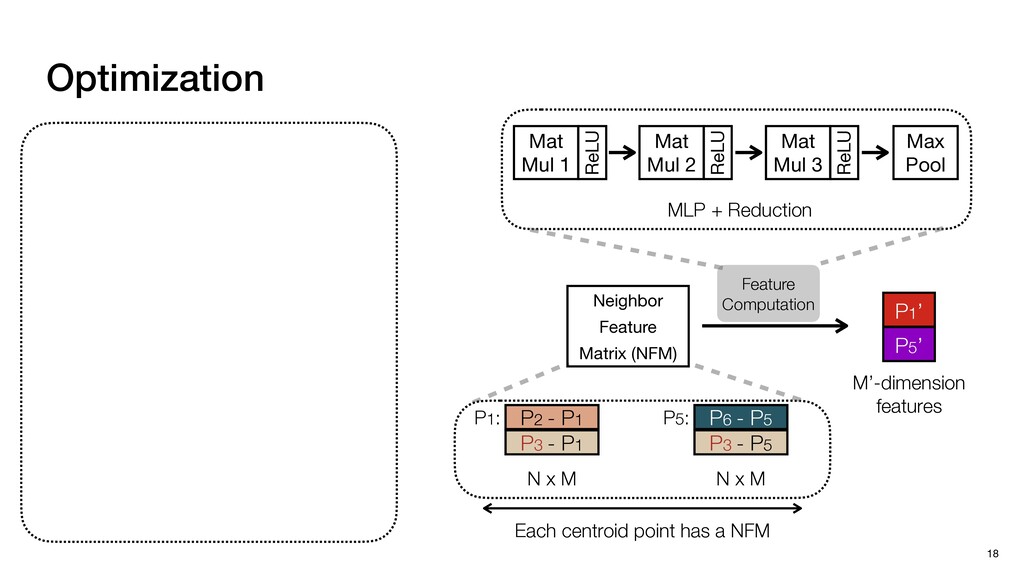
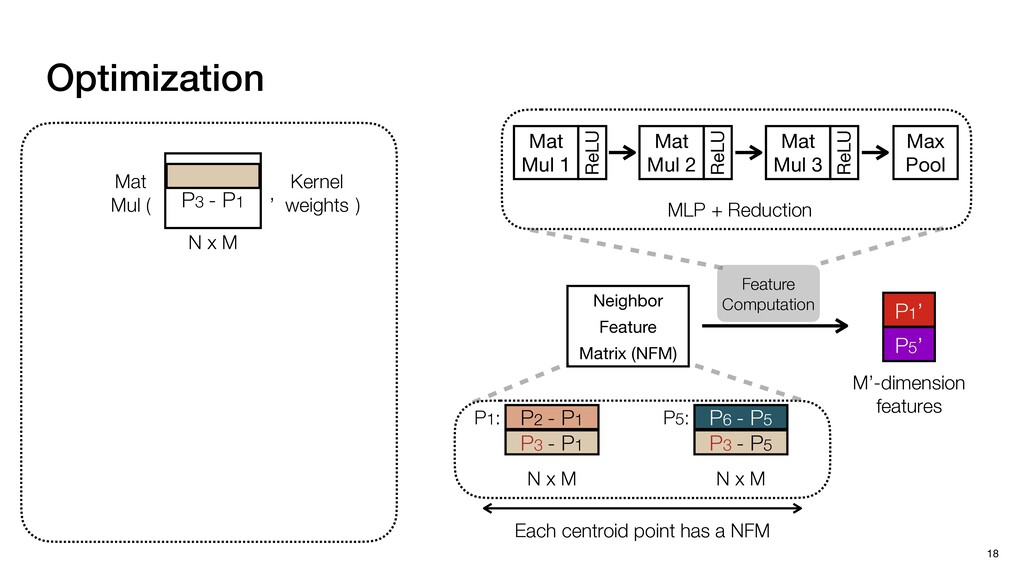
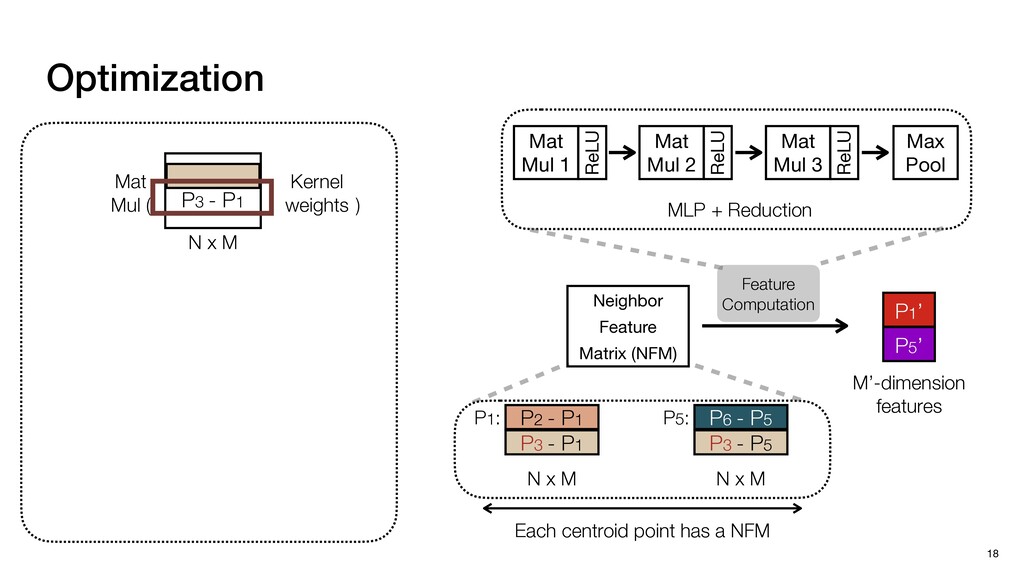
Neighbor Feature Matrix (NFM) N x M P3 - P1
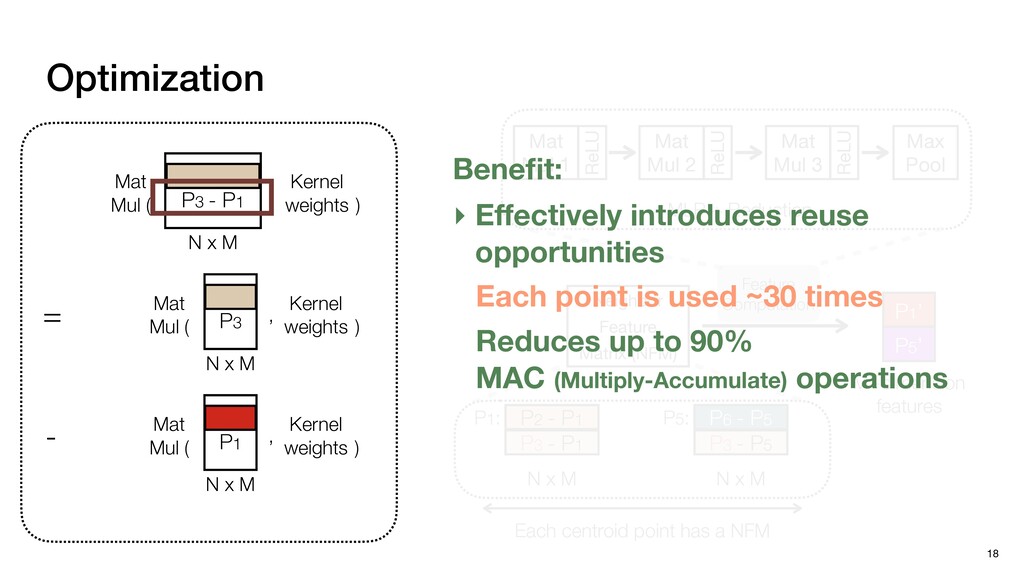
P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: Each centroid point has a NFM P1’ P5’ M’-dimension features Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool Optimization 18 -
Neighbor Feature Matrix (NFM) N x M P3 - P1
P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: Each centroid point has a NFM P1’ P5’ M’-dimension features Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool Optimization 18 N x M P3 - P1 Mat Mul ( Kernel weights , ) -
Neighbor Feature Matrix (NFM) N x M P3 - P1
P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: Each centroid point has a NFM P1’ P5’ M’-dimension features Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool Optimization 18 N x M P3 - P1 Mat Mul ( Kernel weights , ) -
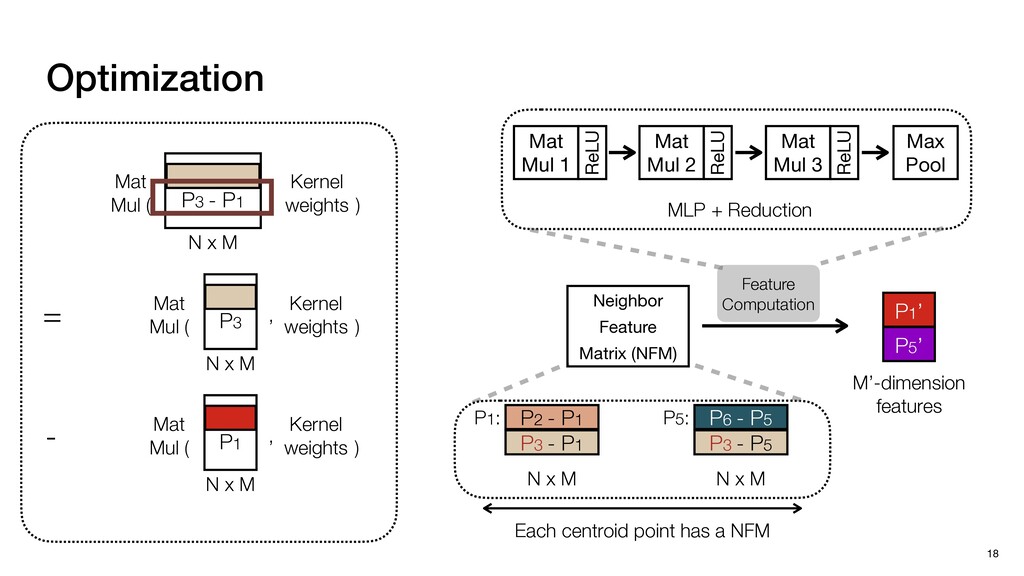
Neighbor Feature Matrix (NFM) N x M P3 - P1
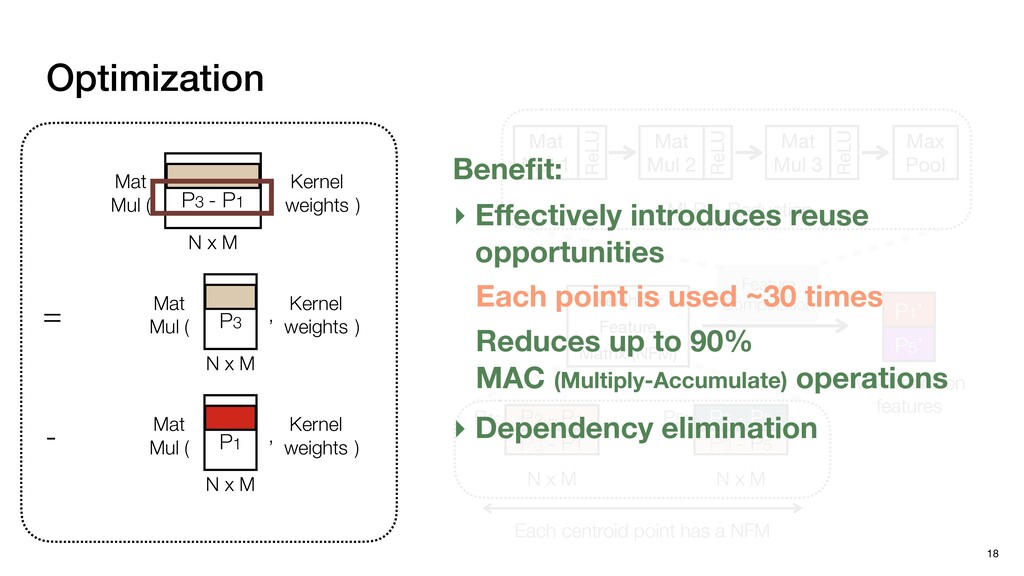
P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: Each centroid point has a NFM P1’ P5’ M’-dimension features Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool = Optimization 18 N x M P3 - P1 Mat Mul ( Kernel weights , ) Mat Mul ( Kernel weights , ) N x M P3 Mat Mul ( Kernel weights , ) N x M P1 - -
Neighbor Feature Matrix (NFM) N x M P3 - P1
P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: Each centroid point has a NFM P1’ P5’ M’-dimension features Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool = Optimization 18 N x M P3 - P1 Mat Mul ( Kernel weights , ) Mat Mul ( Kernel weights , ) N x M P3 Mat Mul ( Kernel weights , ) N x M P1 - -
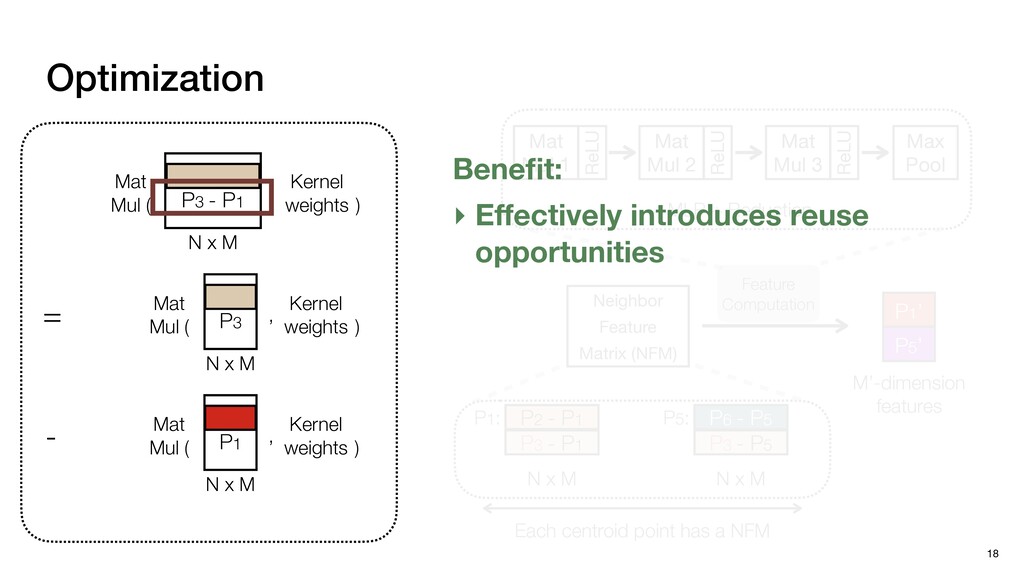
Neighbor Feature Matrix (NFM) N x M P3 - P1
P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: Each centroid point has a NFM P1’ P5’ M’-dimension features Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool = Optimization 18 N x M P3 - P1 Mat Mul ( Kernel weights , ) Mat Mul ( Kernel weights , ) N x M P3 Mat Mul ( Kernel weights , ) N x M P1 - Benefit: -
Neighbor Feature Matrix (NFM) N x M P3 - P1
P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: Each centroid point has a NFM P1’ P5’ M’-dimension features Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool = Optimization 18 N x M P3 - P1 Mat Mul ( Kernel weights , ) Mat Mul ( Kernel weights , ) N x M P3 Mat Mul ( Kernel weights , ) N x M P1 - ▸ Effectively introduces reuse opportunities Benefit: -
Neighbor Feature Matrix (NFM) N x M P3 - P1
P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: Each centroid point has a NFM P1’ P5’ M’-dimension features Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool = Optimization 18 N x M P3 - P1 Mat Mul ( Kernel weights , ) Mat Mul ( Kernel weights , ) N x M P3 Mat Mul ( Kernel weights , ) N x M P1 - ▸ Effectively introduces reuse opportunities Reduces up to 90% MAC (Multiply-Accumulate) operations Benefit: Each point is used ~30 times -
Neighbor Feature Matrix (NFM) N x M P3 - P1
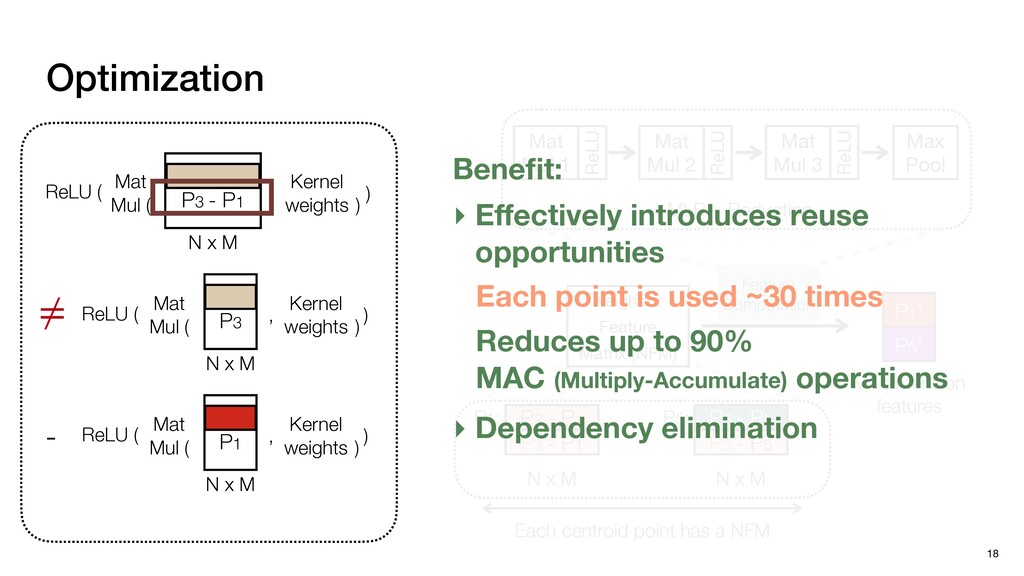
P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: Each centroid point has a NFM P1’ P5’ M’-dimension features Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool = Optimization 18 N x M P3 - P1 Mat Mul ( Kernel weights , ) Mat Mul ( Kernel weights , ) N x M P3 Mat Mul ( Kernel weights , ) N x M P1 - ▸ Effectively introduces reuse opportunities Reduces up to 90% MAC (Multiply-Accumulate) operations ▸ Dependency elimination Benefit: Each point is used ~30 times -
Neighbor Feature Matrix (NFM) N x M P3 - P1
P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: Each centroid point has a NFM P1’ P5’ M’-dimension features Feature Computation Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool Optimization 18 N x M P3 - P1 Mat Mul ( Kernel weights , ) Mat Mul ( Kernel weights , ) N x M P3 Mat Mul ( Kernel weights , ) N x M P1 - ReLU ( ) ReLU ( ) ReLU ( ) ≠ ▸ Effectively introduces reuse opportunities Reduces up to 90% MAC (Multiply-Accumulate) operations ▸ Dependency elimination Benefit: Each point is used ~30 times -
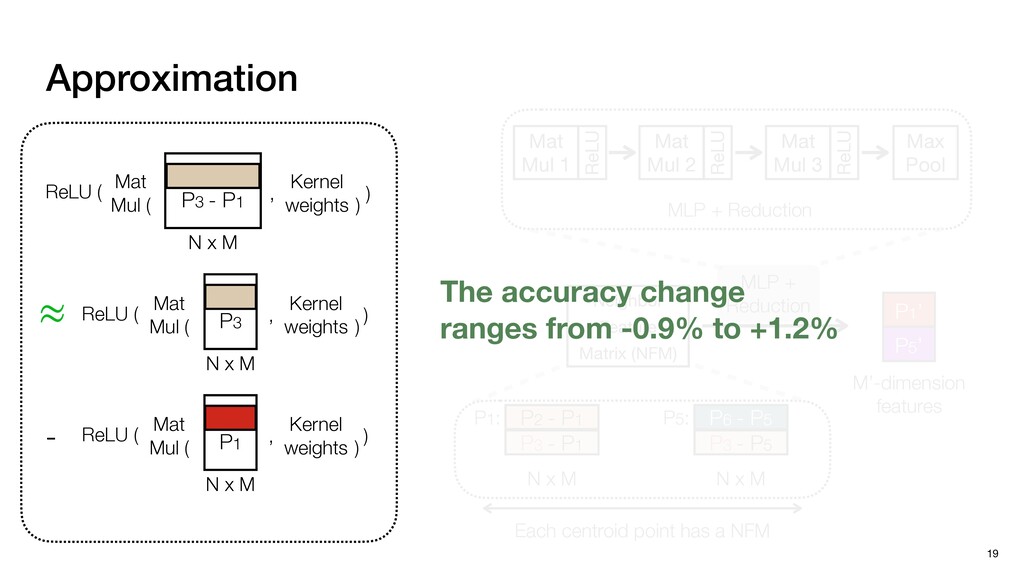
Approximation 19 Neighbor Feature Matrix (NFM) MLP + Reduction Mat
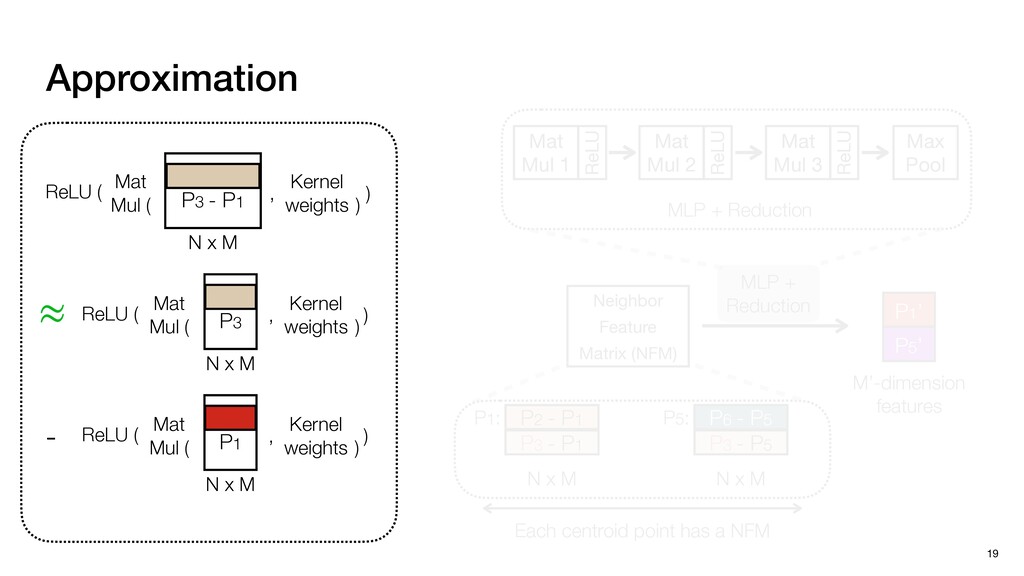
Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool N x M P3 - P1 Mat Mul ( Kernel weights , ) Mat Mul ( Kernel weights , ) N x M P3 Mat Mul ( Kernel weights , ) N x M P1 - ReLU ( ) ReLU ( ) ReLU ( ) ≈ P1’ P5’ M’-dimension features Each centroid point has a NFM N x M P3 - P1 P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: -
Approximation 19 Neighbor Feature Matrix (NFM) MLP + Reduction Mat
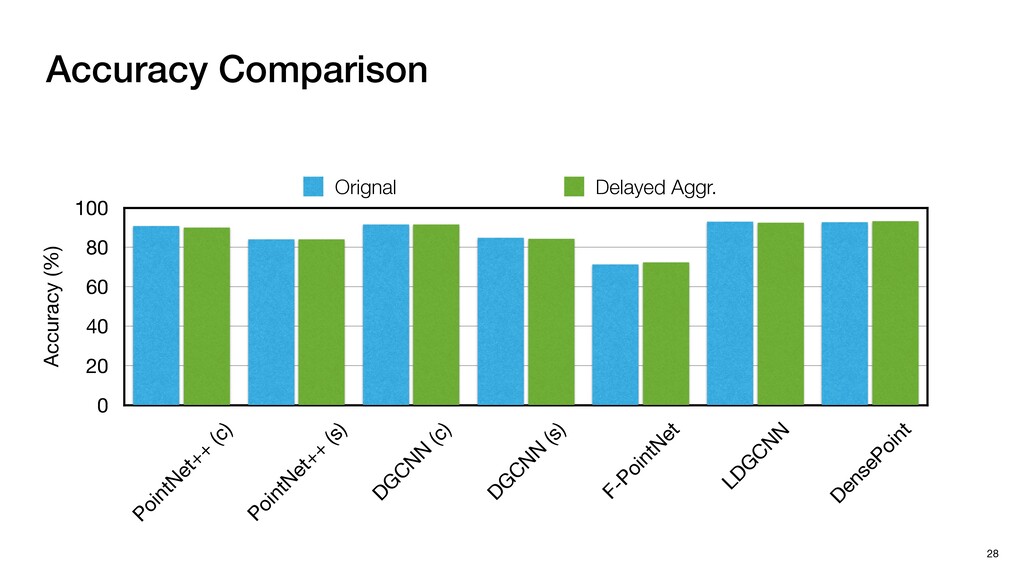
Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP + Reduction Max Pool N x M P3 - P1 Mat Mul ( Kernel weights , ) Mat Mul ( Kernel weights , ) N x M P3 Mat Mul ( Kernel weights , ) N x M P1 - ReLU ( ) ReLU ( ) ReLU ( ) ≈ P1’ P5’ M’-dimension features Each centroid point has a NFM N x M P3 - P1 P2 - P1 N x M P5: P6 - P5 P3 - P5 P1: The accuracy change ranges from -0.9% to +1.2% -
Delayed Aggregation 20 Neighbor Search Neighbor Index Table Feature Compute
Point Feature Table Aggregation Neighbor Feature Matrix (NFM) } Reduction P1’ P5’ M’-dimension features Mat Mul 1 ReLU Mat Mul 2 ReLU Mat Mul 3 ReLU MLP M-dimension feature vectors P1 P4 P6 P2 P3 P5 Points -
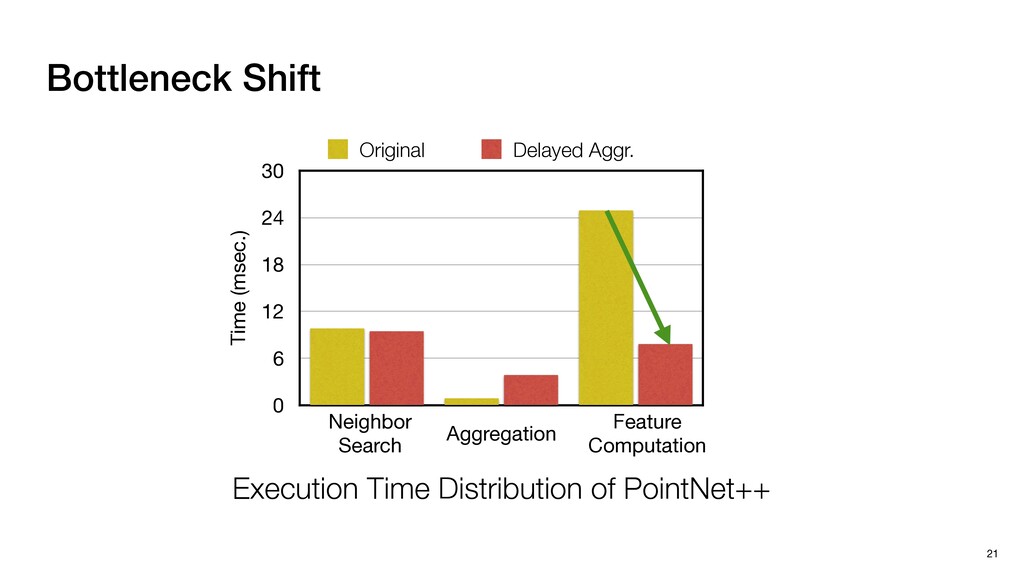
Bottleneck Shift 21 Time (msec.) 0 6 12 18 24
30 Original Delayed Aggr. Feature Computation Aggregation Neighbor Search Execution Time Distribution of PointNet++ -
Bottleneck Shift 21 Time (msec.) 0 6 12 18 24
30 Original Delayed Aggr. Feature Computation Aggregation Neighbor Search Execution Time Distribution of PointNet++ -
Bottleneck Shift 21 Time (msec.) 0 6 12 18 24
30 Original Delayed Aggr. Feature Computation Aggregation Neighbor Search Execution Time Distribution of PointNet++ -
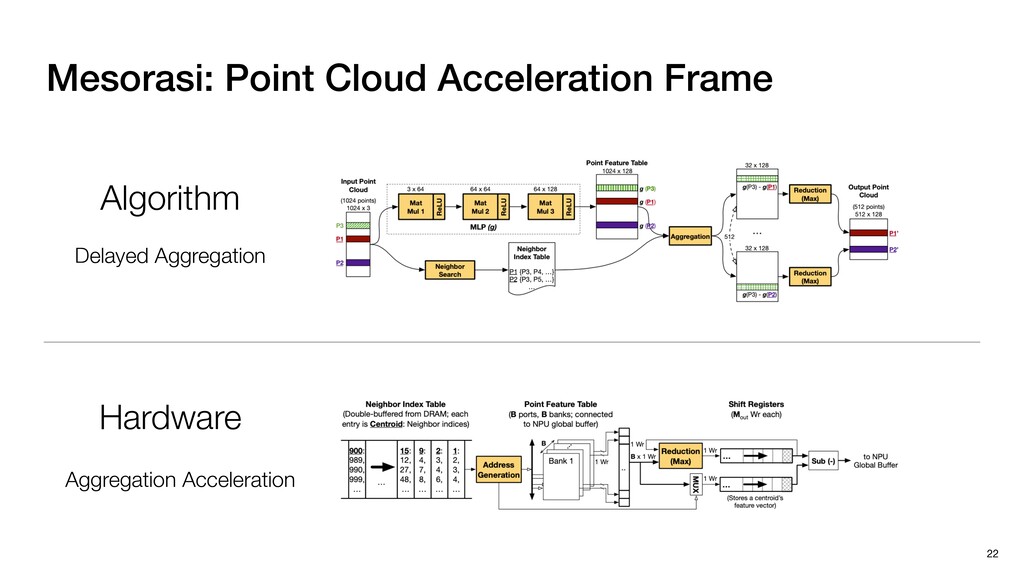
Mesorasi: Point Cloud Acceleration Frame 22 Algorithm Hardware Delayed Aggregation
Aggregation Acceleration -
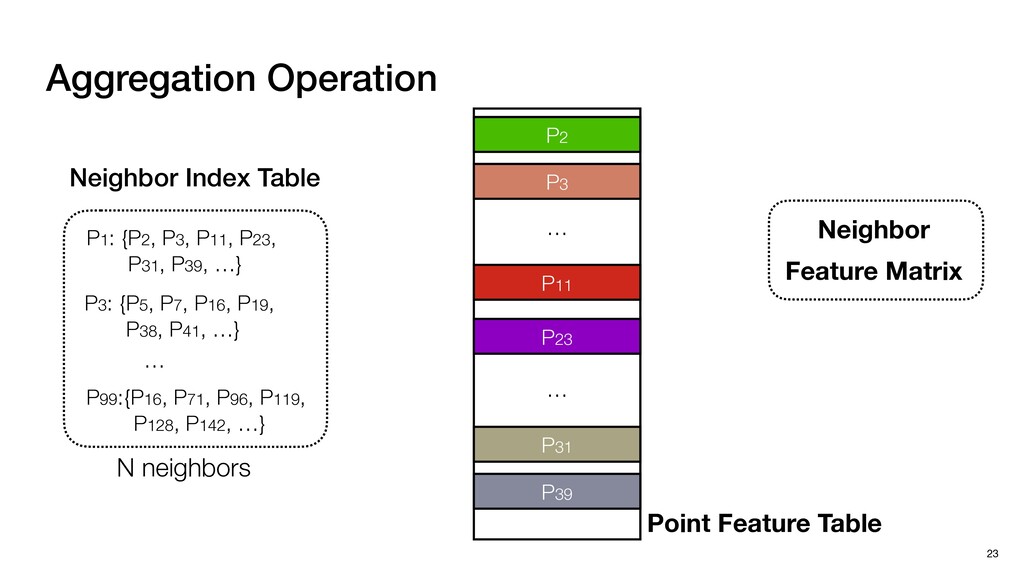
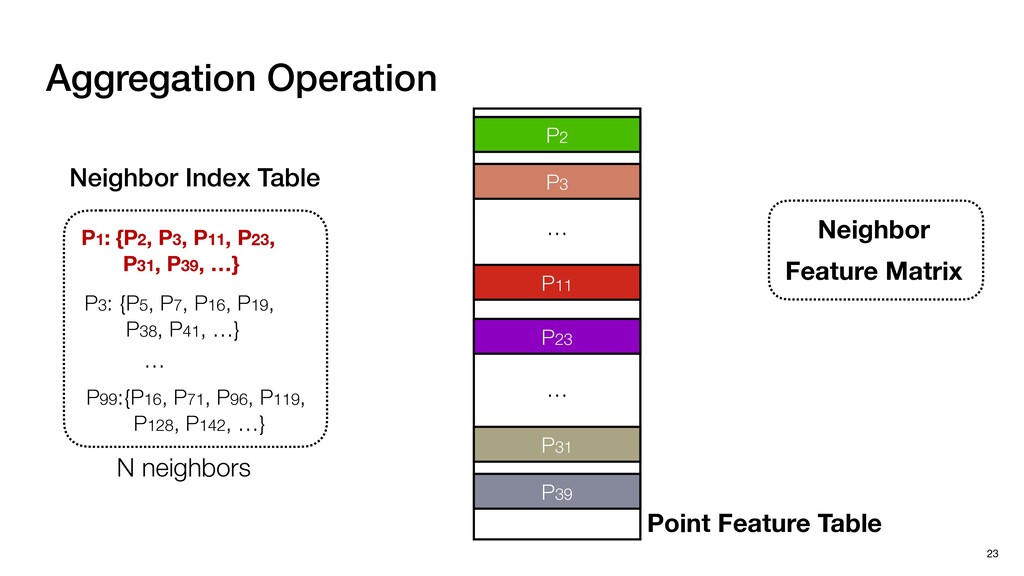
Aggregation Operation 23 Neighbor Feature Matrix Point Feature Table N
neighbors P1: {P2, P3, P11, P23, P31, P39, …} P3: {P5, P7, P16, P19, P38, P41, …} … Neighbor Index Table P99:{P16, P71, P96, P119, P128, P142, …} P11 P31 P23 P3 P39 P2 … … -
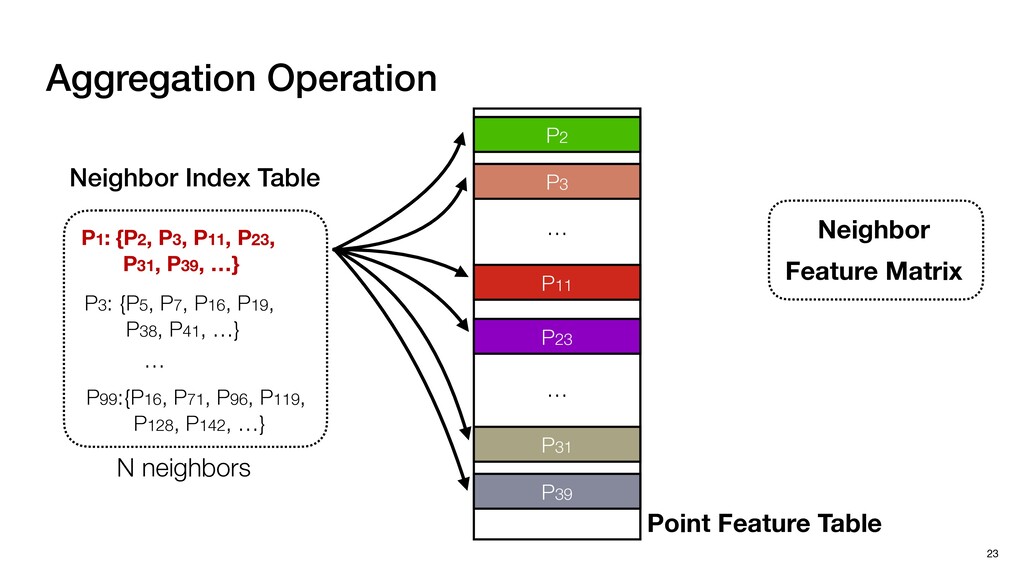
Aggregation Operation 23 Neighbor Feature Matrix Point Feature Table N
neighbors P1: {P2, P3, P11, P23, P31, P39, …} P3: {P5, P7, P16, P19, P38, P41, …} … Neighbor Index Table P99:{P16, P71, P96, P119, P128, P142, …} P11 P31 P23 P3 P39 P2 … … P1: {P2, P3, P11, P23, P31, P39, …} -
Aggregation Operation 23 Neighbor Feature Matrix Point Feature Table N
neighbors P1: {P2, P3, P11, P23, P31, P39, …} P3: {P5, P7, P16, P19, P38, P41, …} … Neighbor Index Table P99:{P16, P71, P96, P119, P128, P142, …} P11 P31 P23 P3 P39 P2 … … P1: {P2, P3, P11, P23, P31, P39, …} -
Aggregation Operation 23 Neighbor Feature Matrix Point Feature Table N
neighbors P1: {P2, P3, P11, P23, P31, P39, …} P3: {P5, P7, P16, P19, P38, P41, …} … Neighbor Index Table P99:{P16, P71, P96, P119, P128, P142, …} P11 P31 P23 P3 P39 P2 … … P1: {P2, P3, P11, P23, P31, P39, …} -
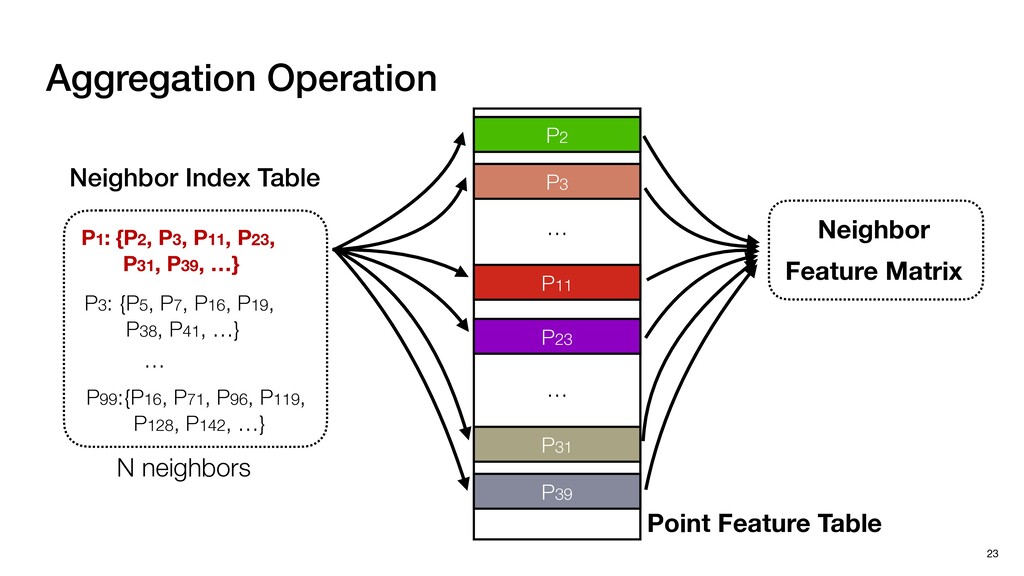
Aggregation Operation 23 Neighbor Feature Matrix Point Feature Table N
neighbors P1: {P2, P3, P11, P23, P31, P39, …} P3: {P5, P7, P16, P19, P38, P41, …} … Neighbor Index Table P99:{P16, P71, P96, P119, P128, P142, …} P11 P31 P23 P3 P39 P2 … … P1: {P2, P3, P11, P23, P31, P39, …} -
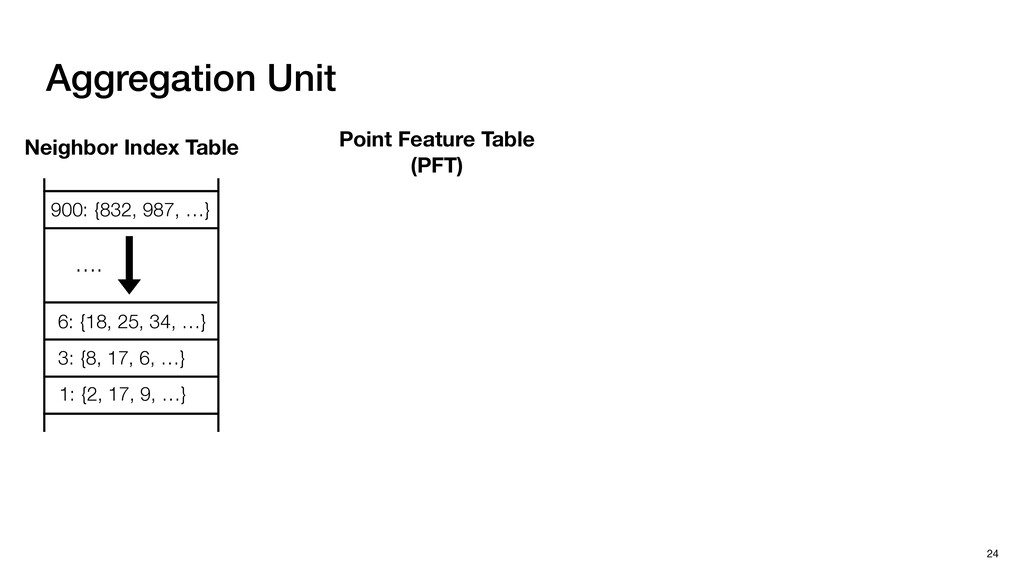
Aggregation Unit 24 1: {2, 17, 9, …} 3: {8,
17, 6, …} 6: {18, 25, 34, …} …. 900: {832, 987, …} Point Feature Table (PFT) Neighbor Index Table -
Aggregation Unit 24 1: {2, 17, 9, …} 3: {8,
17, 6, …} 6: {18, 25, 34, …} …. 900: {832, 987, …} Address Generation Point Feature Table (PFT) Neighbor Index Table -
Aggregation Unit 24 1: {2, 17, 9, …} 3: {8,
17, 6, …} 6: {18, 25, 34, …} …. 900: {832, 987, …} Address Generation Bank 1 Bank 2 Bank B … Bank 3 … Point Feature Table (PFT) Neighbor Index Table -
Aggregation Unit 24 1: {2, 17, 9, …} 3: {8,
17, 6, …} 6: {18, 25, 34, …} …. 900: {832, 987, …} Address Generation Bank 1 Bank 2 Bank B … Bank 3 … B-ported, B-banked; No Crossbar Point Feature Table (PFT) Neighbor Index Table -
Aggregation Unit 25 1: {2, 17, 9, …} 3: {8,
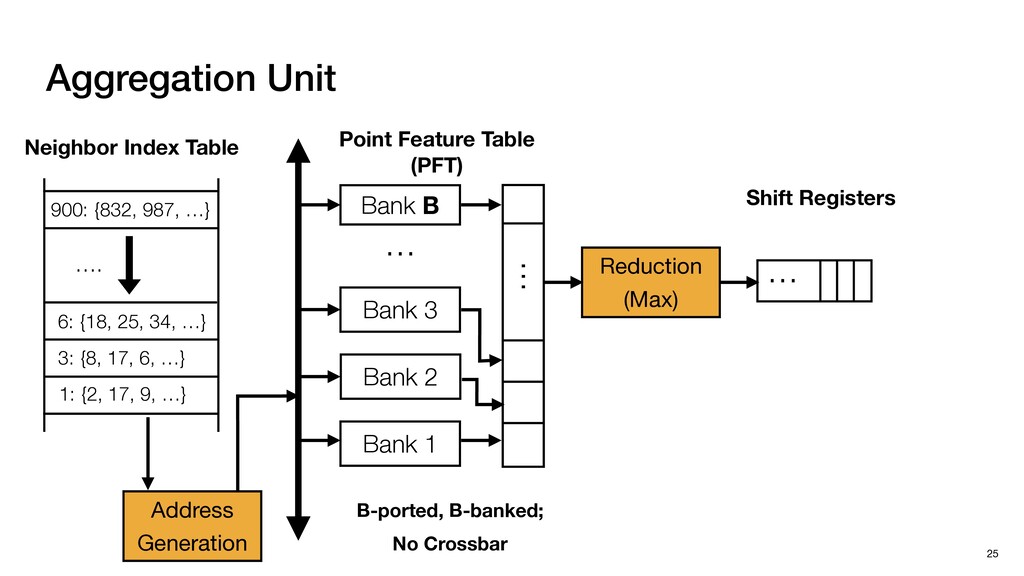
17, 6, …} 6: {18, 25, 34, …} …. 900: {832, 987, …} Address Generation Bank 1 Bank 2 Bank B … Bank 3 … Neighbor Index Table Point Feature Table (PFT) Reduction (Max) … Shift Registers B-ported, B-banked; No Crossbar -
Aggregation Unit 25 1: {2, 17, 9, …} 3: {8,
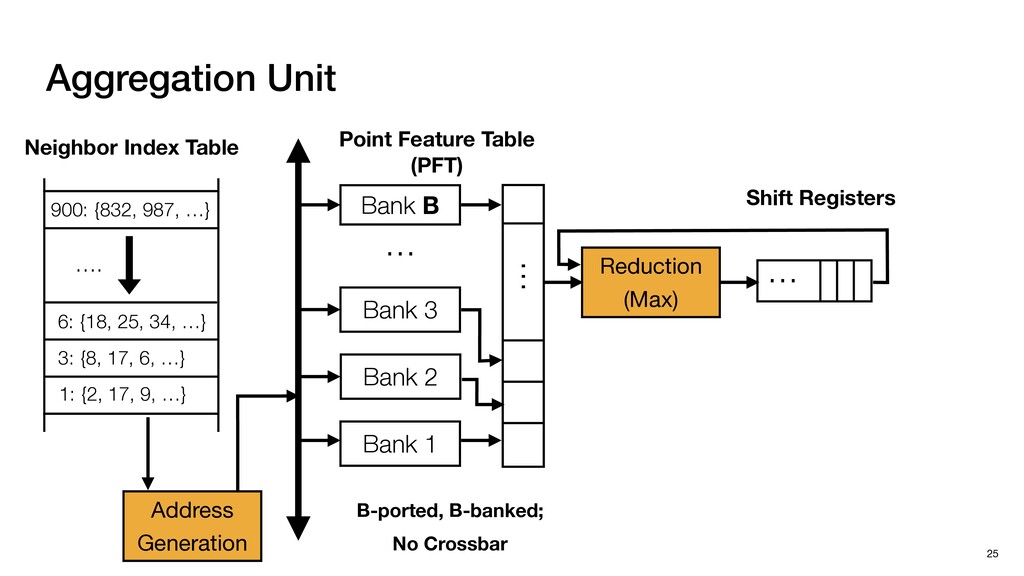
17, 6, …} 6: {18, 25, 34, …} …. 900: {832, 987, …} Address Generation Bank 1 Bank 2 Bank B … Bank 3 … Neighbor Index Table Point Feature Table (PFT) Reduction (Max) … Shift Registers B-ported, B-banked; No Crossbar -
Aggregation Unit 25 1: {2, 17, 9, …} 3: {8,
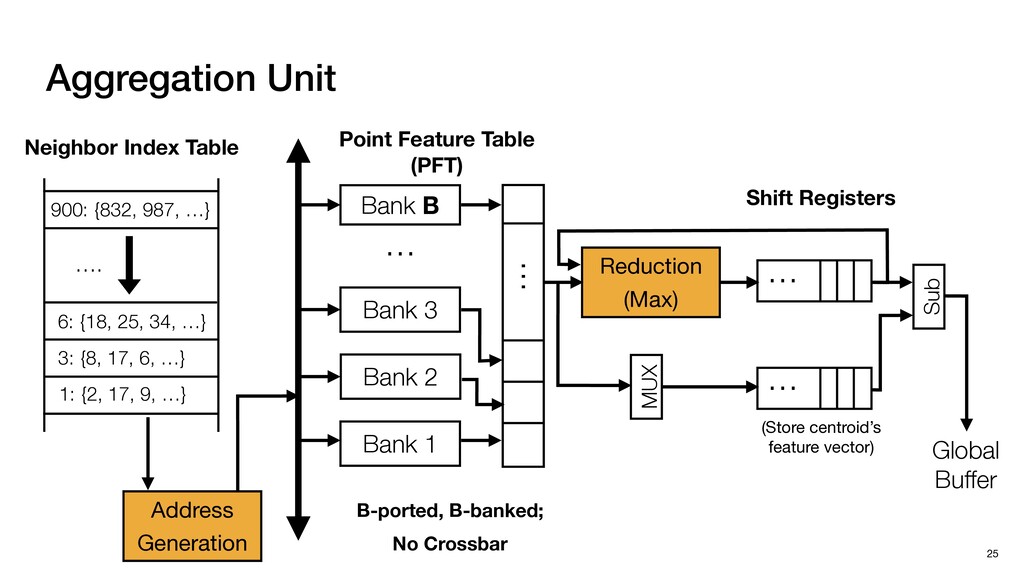
17, 6, …} 6: {18, 25, 34, …} …. 900: {832, 987, …} Address Generation Bank 1 Bank 2 Bank B … Bank 3 … Neighbor Index Table Point Feature Table (PFT) Reduction (Max) … Shift Registers MUX … (Store centroid’s feature vector) B-ported, B-banked; No Crossbar -
Aggregation Unit 25 1: {2, 17, 9, …} 3: {8,
17, 6, …} 6: {18, 25, 34, …} …. 900: {832, 987, …} Address Generation Bank 1 Bank 2 Bank B … Bank 3 … Neighbor Index Table Point Feature Table (PFT) Reduction (Max) Sub Global Buffer … Shift Registers MUX … (Store centroid’s feature vector) B-ported, B-banked; No Crossbar -
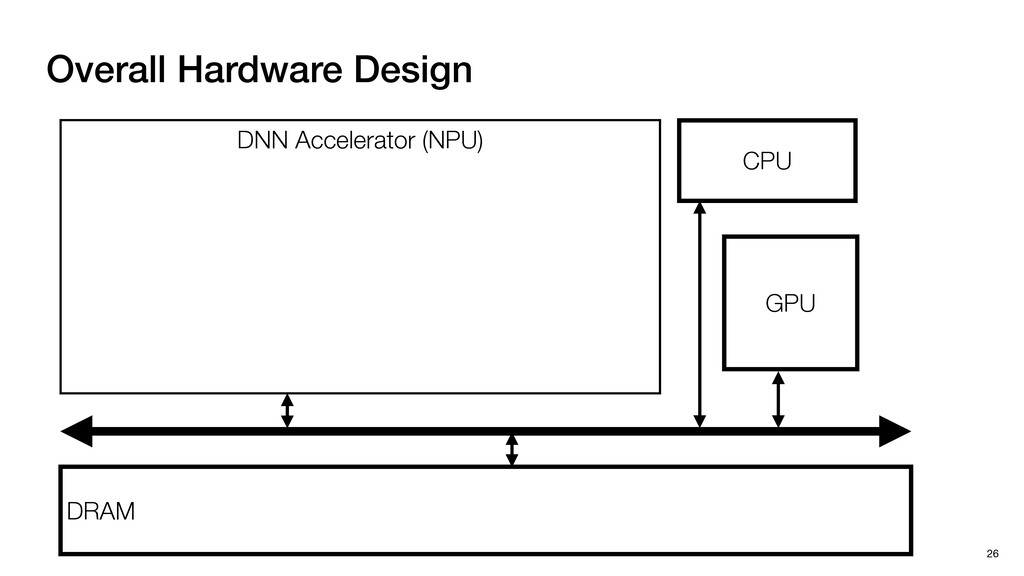
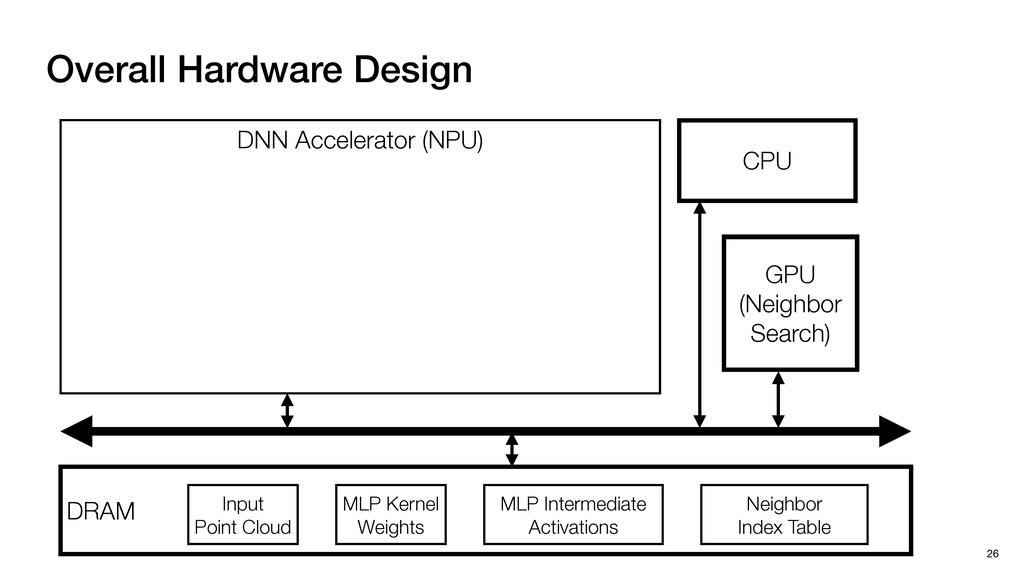
DNN Accelerator (NPU) DRAM CPU GPU Overall Hardware Design 26
Input Point Cloud MLP Kernel Weights MLP Intermediate Activations Neighbor Index Table -
DNN Accelerator (NPU) DRAM CPU GPU Overall Hardware Design 26
Input Point Cloud MLP Kernel Weights MLP Intermediate Activations Neighbor Index Table GPU (Neighbor Search) -
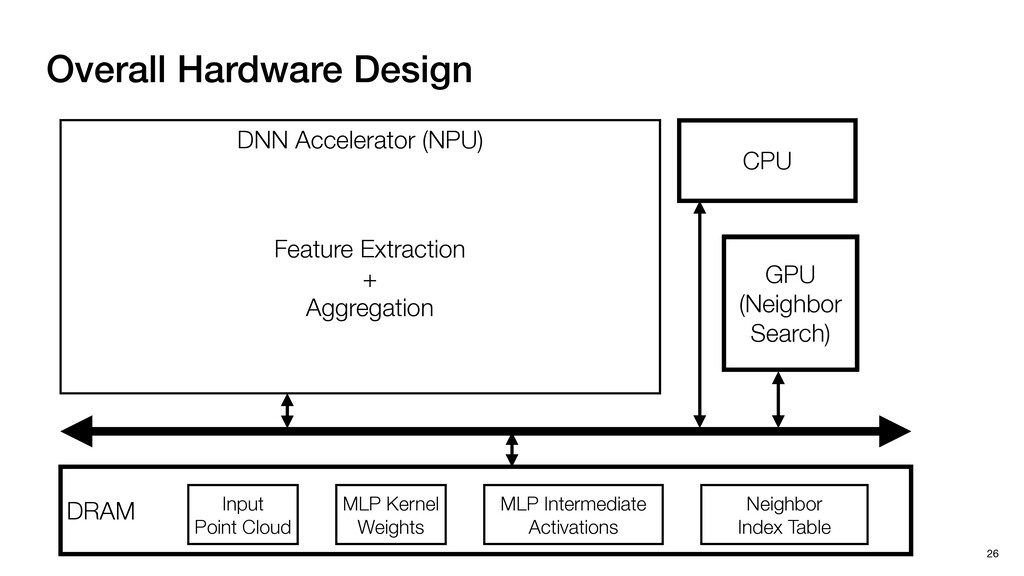
DNN Accelerator (NPU) DRAM CPU GPU Overall Hardware Design 26
Input Point Cloud MLP Kernel Weights MLP Intermediate Activations Neighbor Index Table GPU (Neighbor Search) Feature Extraction + Aggregation -
DNN Accelerator (NPU) DRAM CPU GPU Overall Hardware Design 26
Systolic MAC Unit Array BN/ReLU/ MaxPool Input Point Cloud MLP Kernel Weights MLP Intermediate Activations Neighbor Index Table GPU (Neighbor Search) -
DNN Accelerator (NPU) DRAM CPU GPU Overall Hardware Design 26
Global Buffer (Weights /Fmaps) Global Buffer (Weights /FMaps) MCU MCU Systolic MAC Unit Array BN/ReLU/ MaxPool Input Point Cloud MLP Kernel Weights MLP Intermediate Activations Neighbor Index Table GPU (Neighbor Search) -
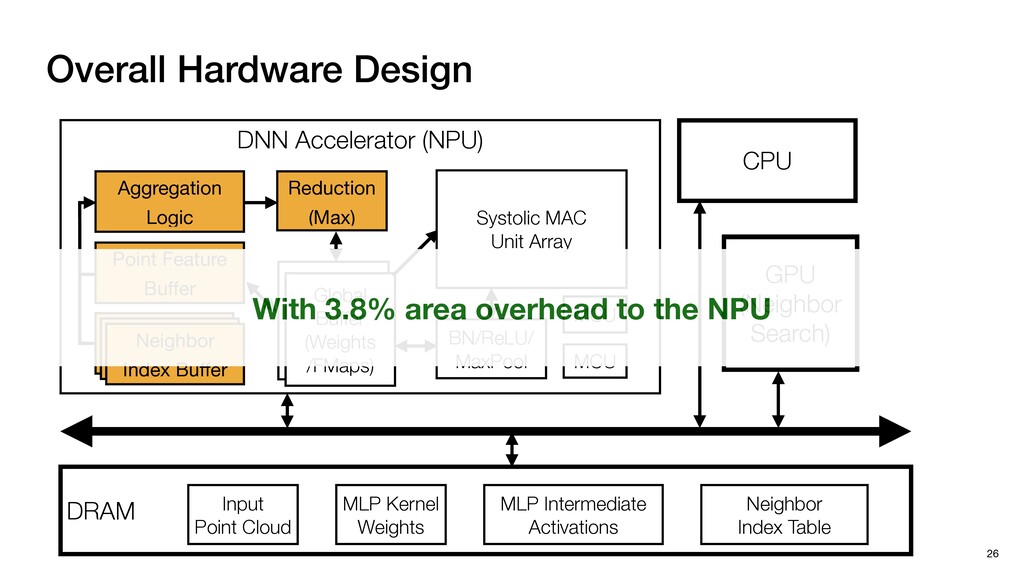
DNN Accelerator (NPU) DRAM CPU GPU Overall Hardware Design 26
Global Buffer (Weights /Fmaps) Global Buffer (Weights /FMaps) MCU MCU Systolic MAC Unit Array BN/ReLU/ MaxPool Input Point Cloud MLP Kernel Weights MLP Intermediate Activations Neighbor Index Table Aggregation Logic Neighbor Index Table Point Feature Buffer Reduction (Max) Neighbor Index Table Neighbor Index Buffer GPU (Neighbor Search) -
DNN Accelerator (NPU) DRAM CPU GPU Overall Hardware Design 26
Global Buffer (Weights /Fmaps) Global Buffer (Weights /FMaps) MCU MCU Systolic MAC Unit Array BN/ReLU/ MaxPool Input Point Cloud MLP Kernel Weights MLP Intermediate Activations Neighbor Index Table Aggregation Logic Neighbor Index Table Point Feature Buffer Reduction (Max) Neighbor Index Table Neighbor Index Buffer GPU (Neighbor Search) With 3.8% area overhead to the NPU -
Experimental Setup 27 Three Point Cloud Applications: ▹ Object Classification,
Object Segmentation, and Object Detection -
Experimental Setup 27 Three Point Cloud Applications: ▹ Object Classification,
Object Segmentation, and Object Detection Datasets: ▹ ModelNet40, ShapeNet, and KITTI dataset -
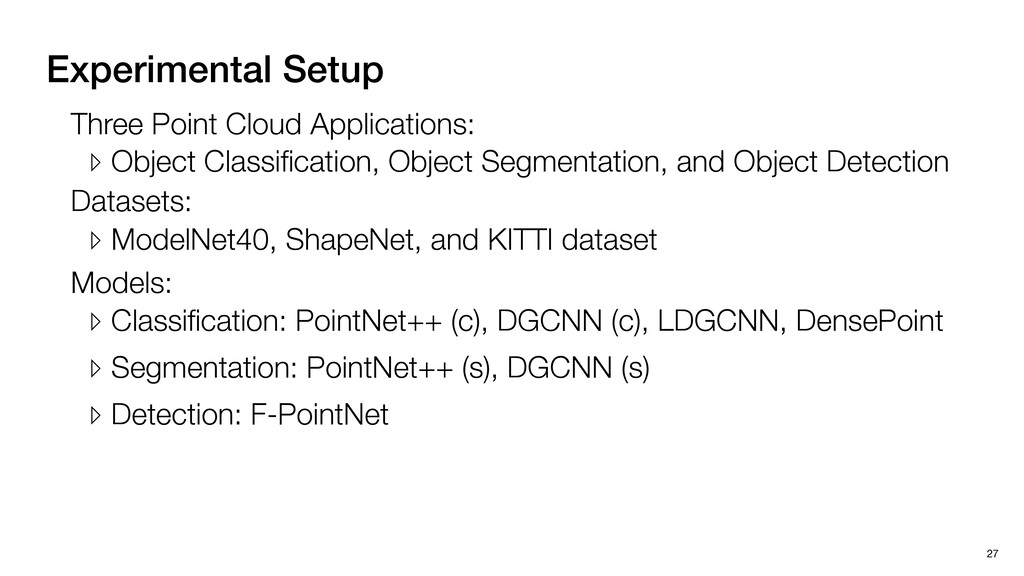
Experimental Setup 27 Three Point Cloud Applications: ▹ Object Classification,
Object Segmentation, and Object Detection Datasets: ▹ ModelNet40, ShapeNet, and KITTI dataset Models: ▹ Classification: PointNet++ (c), DGCNN (c), LDGCNN, DensePoint ▹ Segmentation: PointNet++ (s), DGCNN (s) ▹ Detection: F-PointNet -
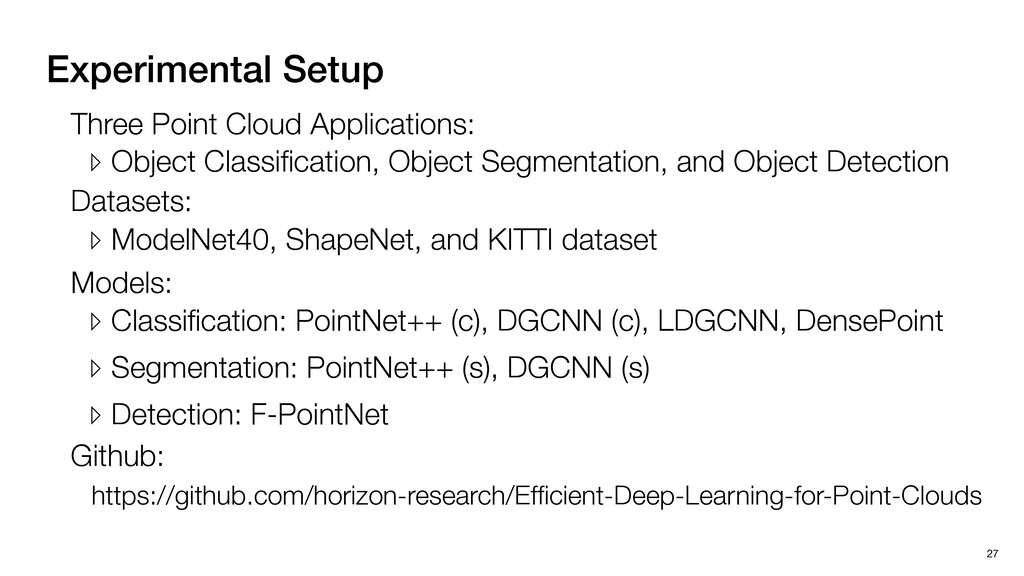
Experimental Setup 27 Three Point Cloud Applications: ▹ Object Classification,
Object Segmentation, and Object Detection Datasets: ▹ ModelNet40, ShapeNet, and KITTI dataset Models: ▹ Classification: PointNet++ (c), DGCNN (c), LDGCNN, DensePoint ▹ Segmentation: PointNet++ (s), DGCNN (s) ▹ Detection: F-PointNet https://github.com/horizon-research/Efficient-Deep-Learning-for-Point-Clouds Github: -
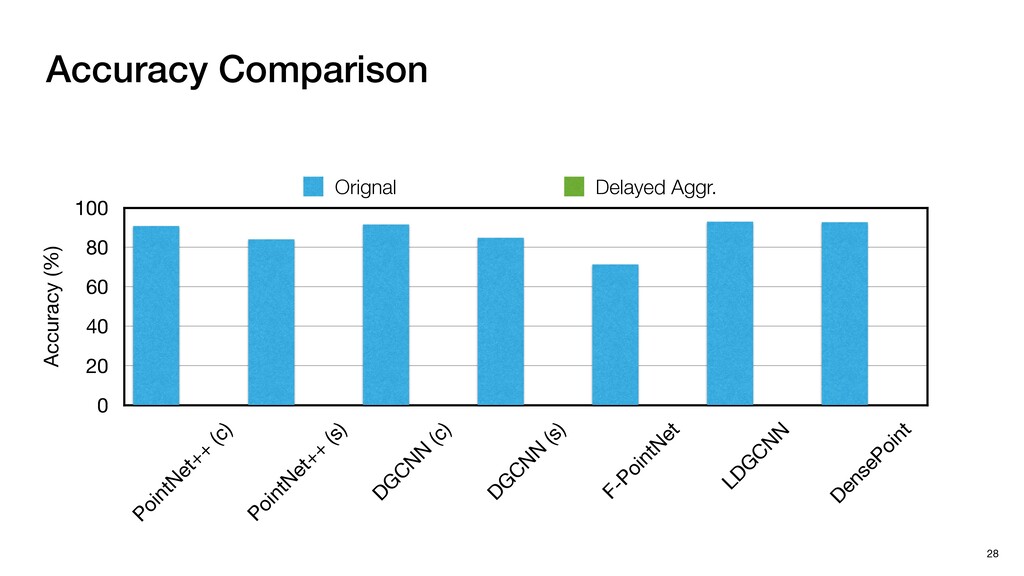
Accuracy Comparison 28 Accuracy (%) 0 20 40 60 80
100 PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint Orignal Delayed Aggr. -
Accuracy Comparison 28 Accuracy (%) 0 20 40 60 80
100 PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint Orignal Delayed Aggr. -
Accuracy Comparison 28 Accuracy (%) 0 20 40 60 80
100 PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint Orignal Delayed Aggr. -
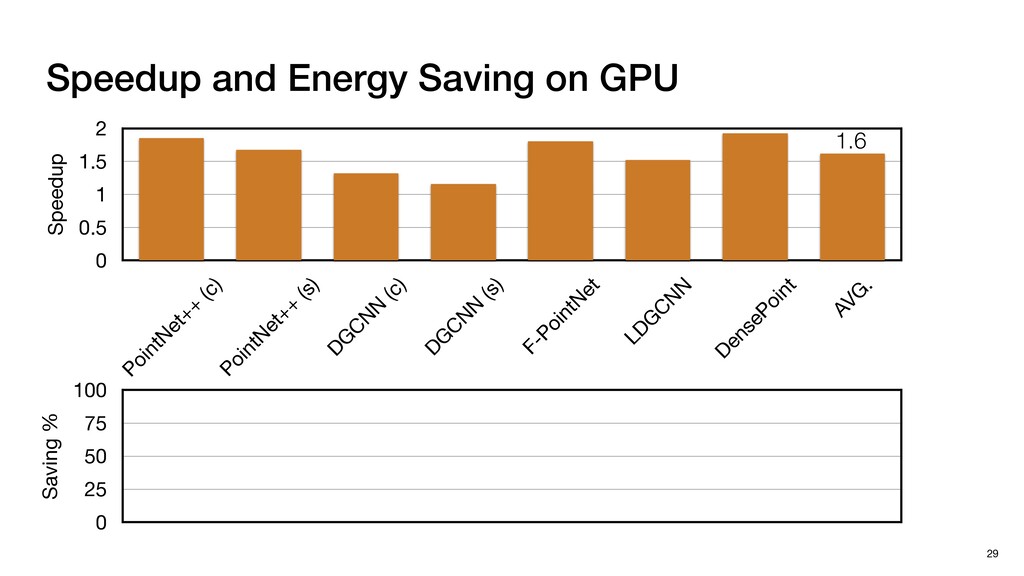
Speedup and Energy Saving on GPU 29 Speedup 0 0.5
1 1.5 2 PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint AVG . -
Speedup and Energy Saving on GPU 29 Speedup 0 0.5
1 1.5 2 PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint AVG . 1.6 -
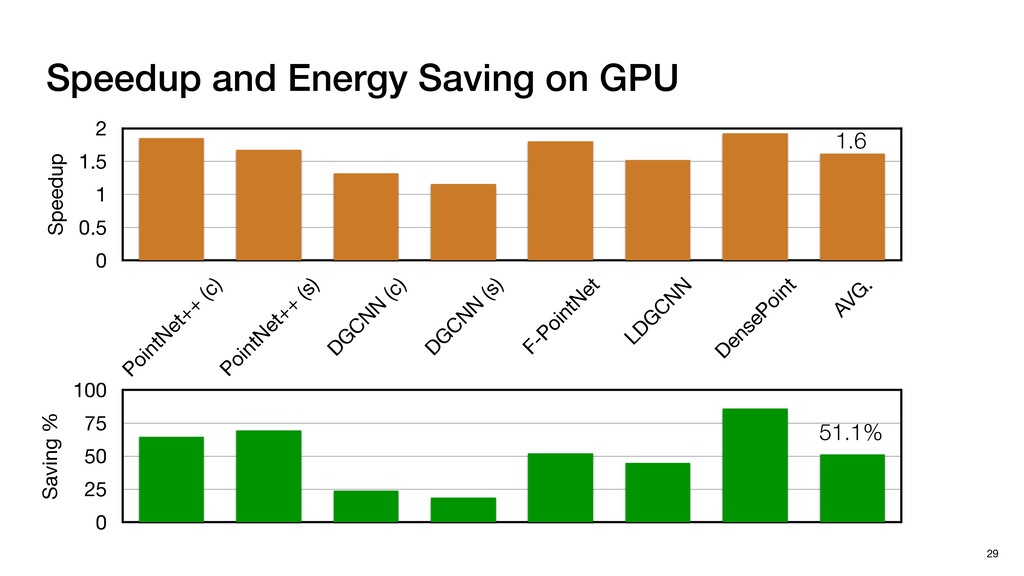
Speedup and Energy Saving on GPU 29 Speedup 0 0.5
1 1.5 2 PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint AVG . Saving % 0 25 50 75 100 1.6 -
Speedup and Energy Saving on GPU 29 Speedup 0 0.5
1 1.5 2 PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint AVG . Saving % 0 25 50 75 100 1.6 51.1% -
Hardware Performance Evaluation 30 Variants: ▹ Mesorasi-SW: delayed-aggregation without AU
support. ▹ Mesorasi-HW: delayed-aggregation with AU support. Hardware Baseline: ▹ A generic NPU + GPU SoC. -
Hardware Performance Evaluation 30 Variants: ▹ Mesorasi-SW: delayed-aggregation without AU
support. ▹ Mesorasi-HW: delayed-aggregation with AU support. Hardware Baseline: ▹ A generic NPU + GPU SoC. Implementation: ▹ 16x16 Systolic Array ▹ Synposys synthesis, TSMC 16nm FinFET technology ▹ -
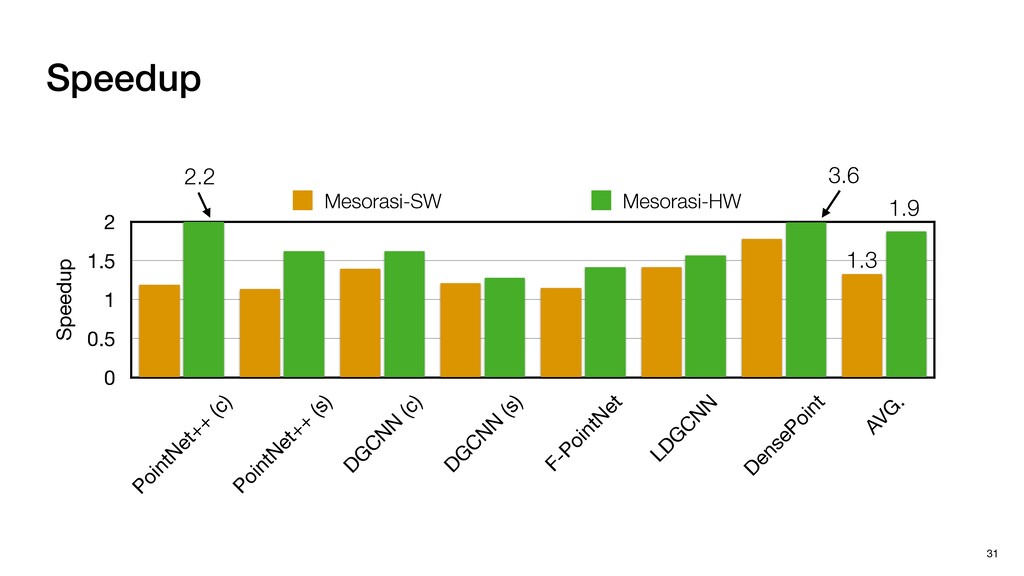
Speedup 31 Speedup 0 0.5 1 1.5 2 PointN et++
(c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint AVG . Mesorasi-SW Mesorasi-HW -
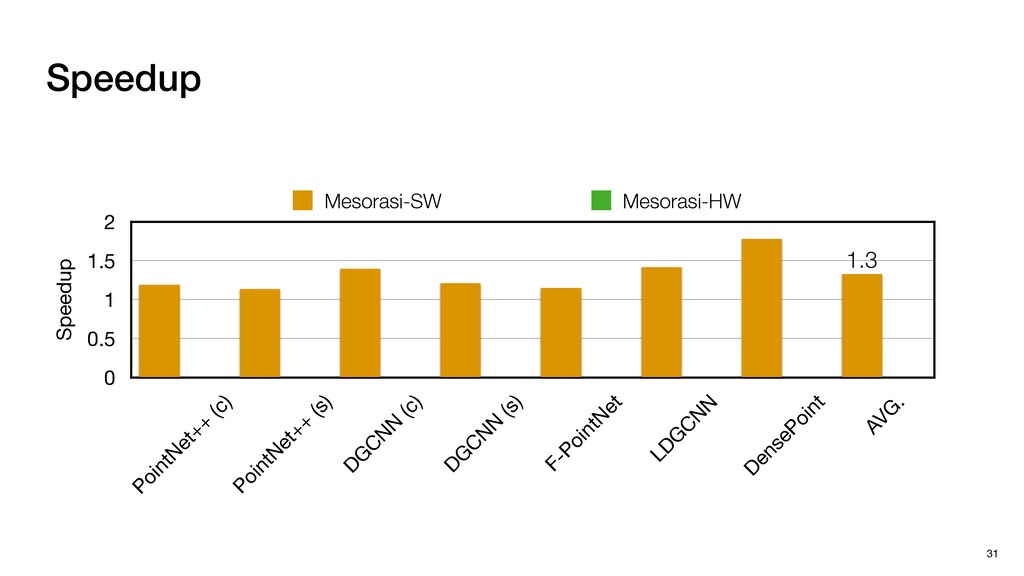
Speedup 31 Speedup 0 0.5 1 1.5 2 PointN et++
(c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint AVG . Mesorasi-SW Mesorasi-HW 1.3 -
Speedup 31 Speedup 0 0.5 1 1.5 2 PointN et++
(c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint AVG . Mesorasi-SW Mesorasi-HW 2.2 3.6 1.3 1.9 -
Energy Savings 32 Saving (%) 0 25 50 75 100
PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint AVG . Mesorasi-SW Mesorasi-HW -
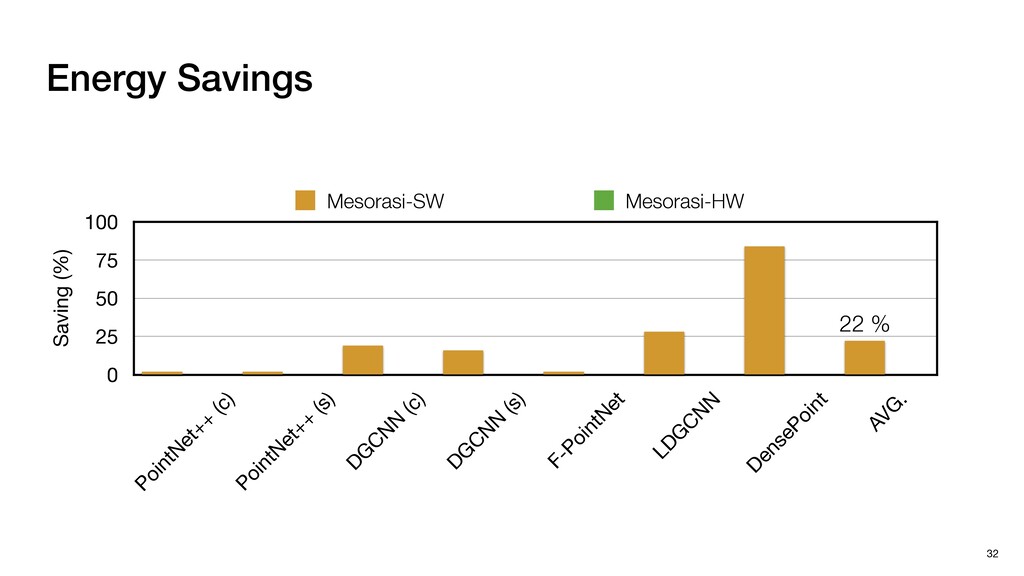
Energy Savings 32 Saving (%) 0 25 50 75 100
PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint AVG . Mesorasi-SW Mesorasi-HW 22 % -
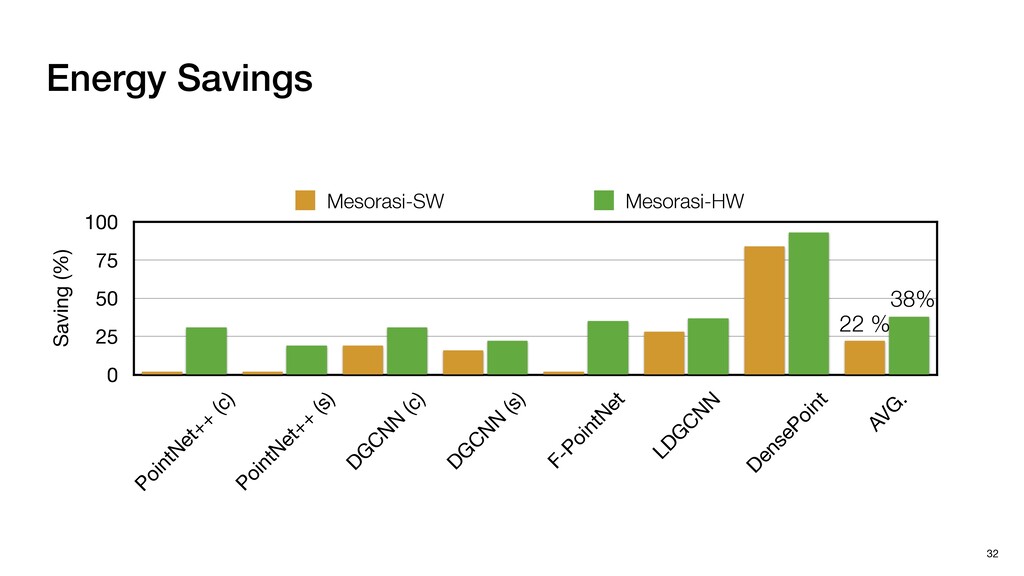
Energy Savings 32 Saving (%) 0 25 50 75 100
PointN et++ (c) PointN et++ (s) DG C N N (c) DG C N N (s) F-PointN et LDG C N N DensePoint AVG . Mesorasi-SW Mesorasi-HW 22 % 38% -
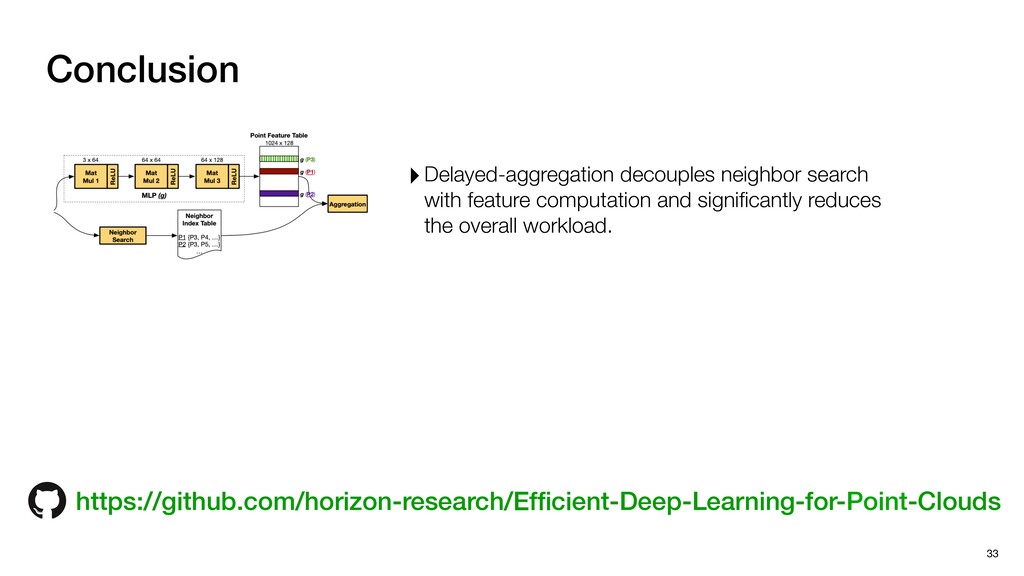
Conclusion 33 ‣Delayed-aggregation decouples neighbor search with feature computation and
significantly reduces the overall workload. https://github.com/horizon-research/Efficient-Deep-Learning-for-Point-Clouds -
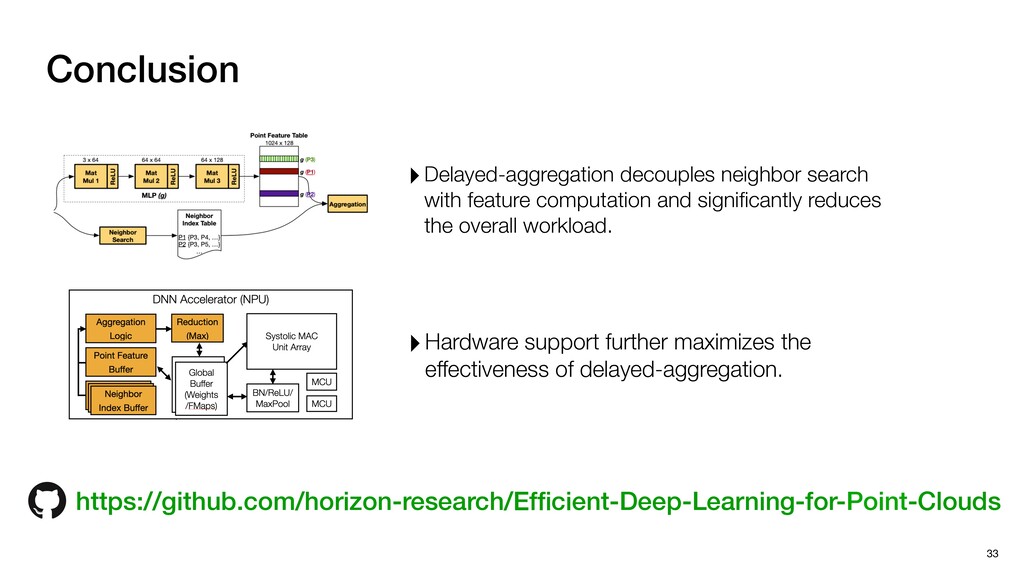
Conclusion 33 ‣Delayed-aggregation decouples neighbor search with feature computation and
significantly reduces the overall workload. ‣Hardware support further maximizes the effectiveness of delayed-aggregation. https://github.com/horizon-research/Efficient-Deep-Learning-for-Point-Clouds
 horizonlab
 yasulab
 signer
 cbtlibrary
 juanmartin2026
 adeputra13
 baltimoreniso
 akiraasano
 hiola
 terasawat
 2720japanoke
 erikaheidi
 jlugia
 aleyda
 mojombo
 techseoconnect
 thekraken
 mlcsv
 popppiees
 soudai
 morganepeng
 helenjbeal
 lfama